The French Newton PierreSimon Laplace Developed mathematics in
- Slides: 30
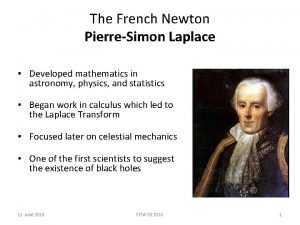
The French Newton Pierre-Simon Laplace • Developed mathematics in astronomy, physics, and statistics • Began work in calculus which led to the Laplace Transform • Focused later on celestial mechanics • One of the first scientists to suggest the existence of black holes 11 June 2016 FOW SS 2016 1
Real-Life Applications Semiconductor mobility Call completion in wireless networks Vehicle vibrations on compressed rails Behavior of magnetic and electric fields above the atmosphere 11 June 2016 FOW SS 2016 2
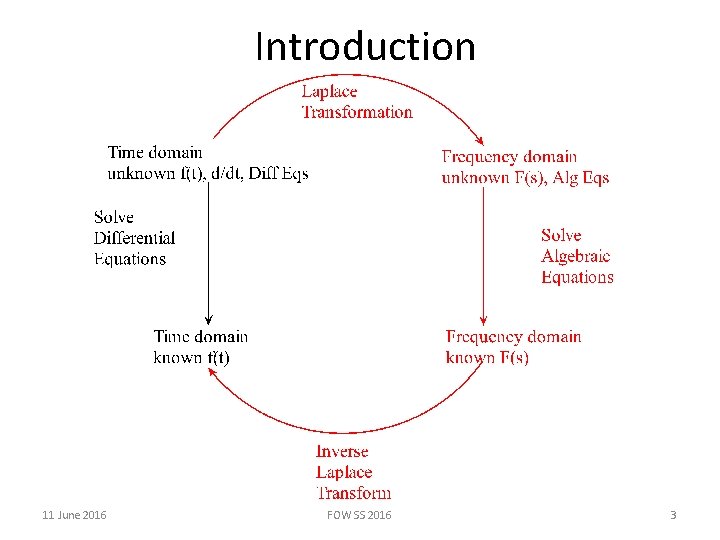
Introduction 11 June 2016 FOW SS 2016 3
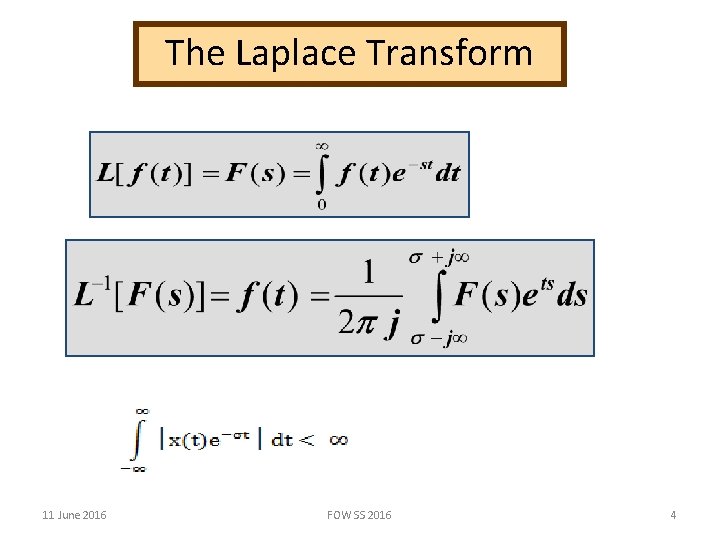
The Laplace Transform 11 June 2016 FOW SS 2016 4
Limitations of FT and need of LT ØLT can be used to analyze large class of CT problems involving signals that are not absolutely integrable. So FT based problems can not be employed in this class of problems ØUsing LT integrodifferential equations are transformed into simple algebraic equations and convolution in time domain becomes multiplication in s domain ØFT is evaluated on entire jω axis , LT is evaluated on s plane (consideration in stability) ØThe exponential factor (Complex Number) has the effect of forcing the signals to converge, hence LT can be applied to broader class of signals
Region of Convergence (ROC) Properties of ROC: Ø ROC Consists of strips parallel to jω axis. ØROC does not contain any pole. Ø If signal is time limited ROC is entire s plane. Ø If signal is right sided , ROC is also right sided with σ > 0 ØIf signal is left sided ROC is also left sided with σ < 0 ØA two sided signal has ROC given by a vertical strip of finite width in s plane.
Relation between LT and FT LT = FT when σ = 0 11 June 2016 FOW SS 2016 7
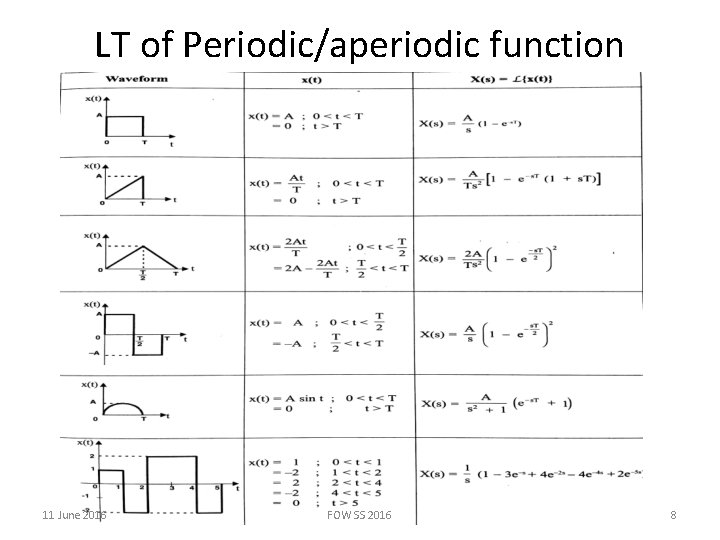
LT of Periodic/aperiodic function 11 June 2016 FOW SS 2016 8
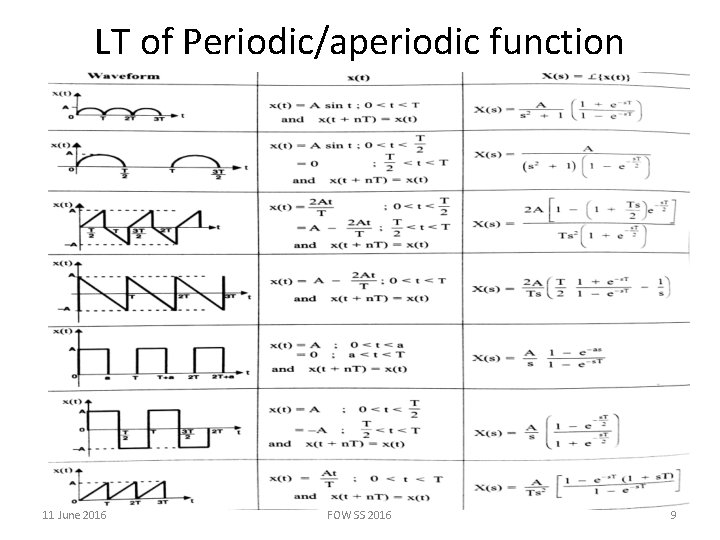
LT of Periodic/aperiodic function 11 June 2016 FOW SS 2016 9
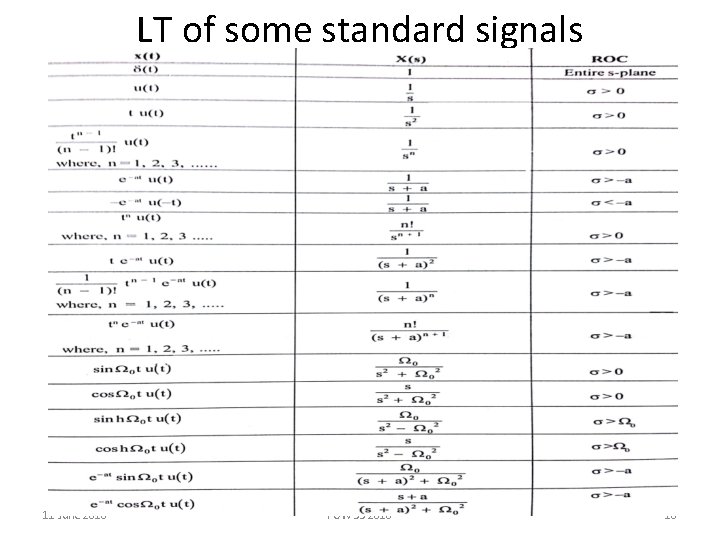
LT of some standard signals 11 June 2016 FOW SS 2016 10
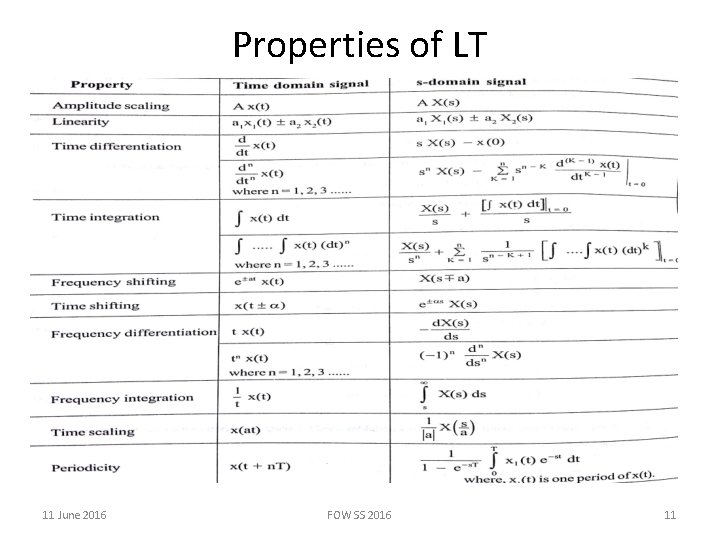
Properties of LT 11 June 2016 FOW SS 2016 11
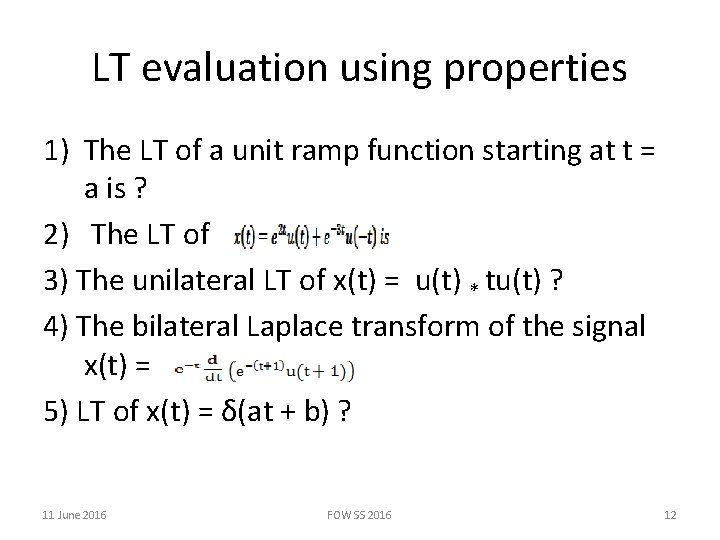
LT evaluation using properties 1) The LT of a unit ramp function starting at t = a is ? 2) The LT of 3) The unilateral LT of x(t) = u(t) * tu(t) ? 4) The bilateral Laplace transform of the signal x(t) = 5) LT of x(t) = δ(at + b) ? 11 June 2016 FOW SS 2016 12
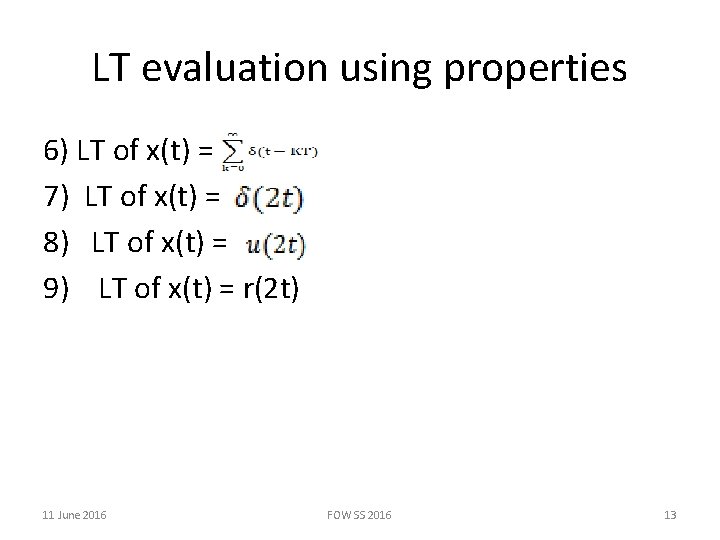
LT evaluation using properties 6) LT of x(t) = 7) LT of x(t) = 8) LT of x(t) = 9) LT of x(t) = r(2 t) 11 June 2016 FOW SS 2016 13
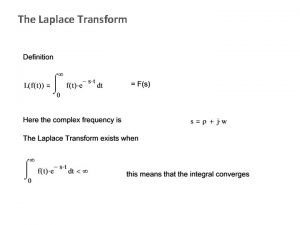
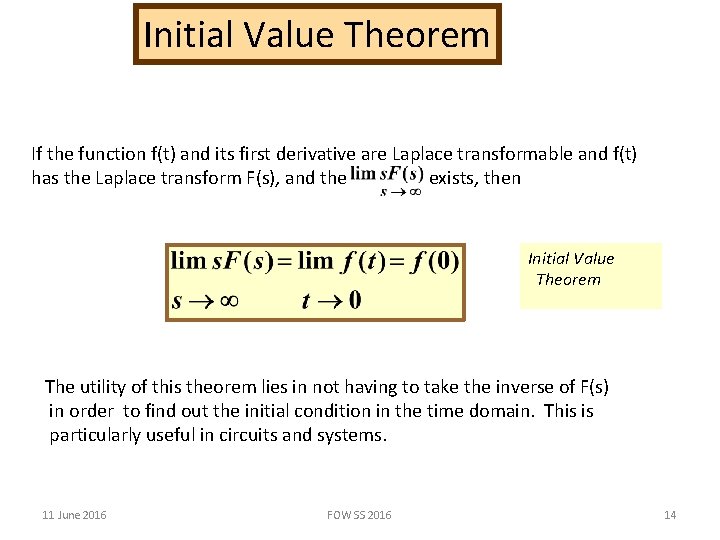
Initial Value Theorem If the function f(t) and its first derivative are Laplace transformable and f(t) has the Laplace transform F(s), and the exists, then Initial Value Theorem The utility of this theorem lies in not having to take the inverse of F(s) in order to find out the initial condition in the time domain. This is particularly useful in circuits and systems. 11 June 2016 FOW SS 2016 14
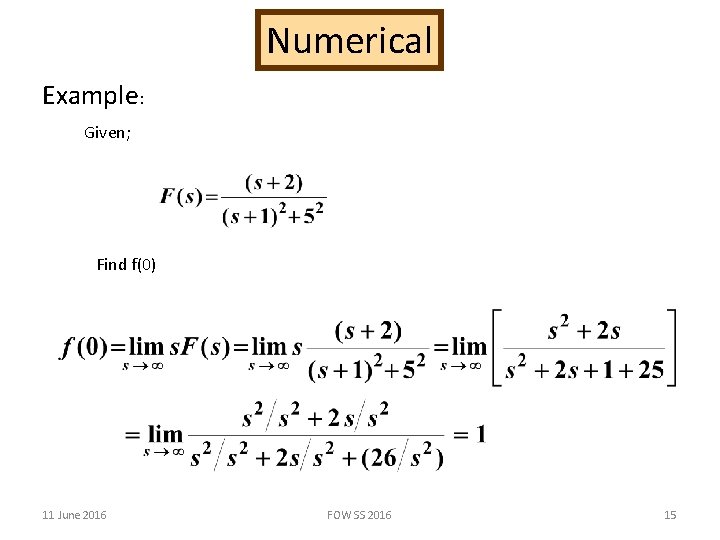
Numerical Example: Given; Find f(0) 11 June 2016 FOW SS 2016 15
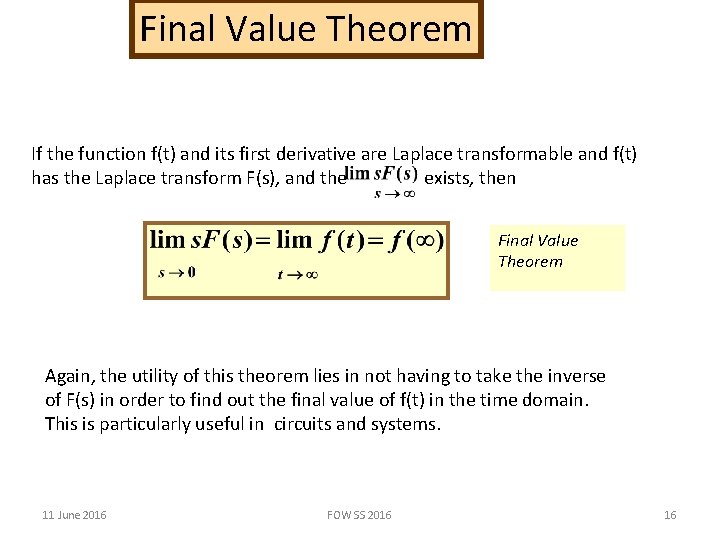
Final Value Theorem If the function f(t) and its first derivative are Laplace transformable and f(t) has the Laplace transform F(s), and the exists, then Final Value Theorem Again, the utility of this theorem lies in not having to take the inverse of F(s) in order to find out the final value of f(t) in the time domain. This is particularly useful in circuits and systems. 11 June 2016 FOW SS 2016 16
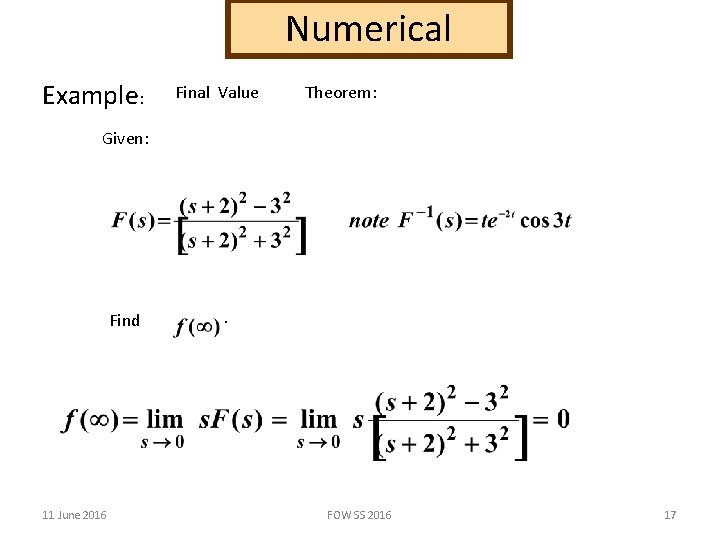
Numerical Example: Final Value Theorem: Given: Find 11 June 2016 . FOW SS 2016 17
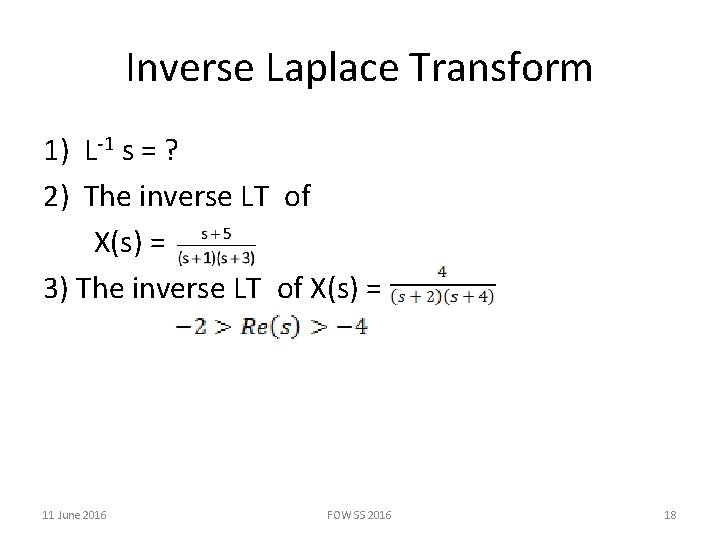
Inverse Laplace Transform 1) L-1 s = ? 2) The inverse LT of X(s) = 3) The inverse LT of X(s) = 11 June 2016 FOW SS 2016 18
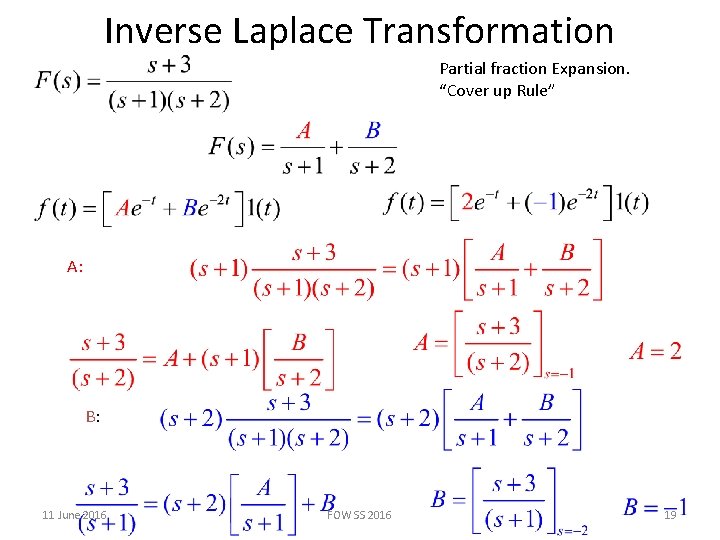
Inverse Laplace Transformation Partial fraction Expansion. “Cover up Rule” A: B: 11 June 2016 FOW SS 2016 19
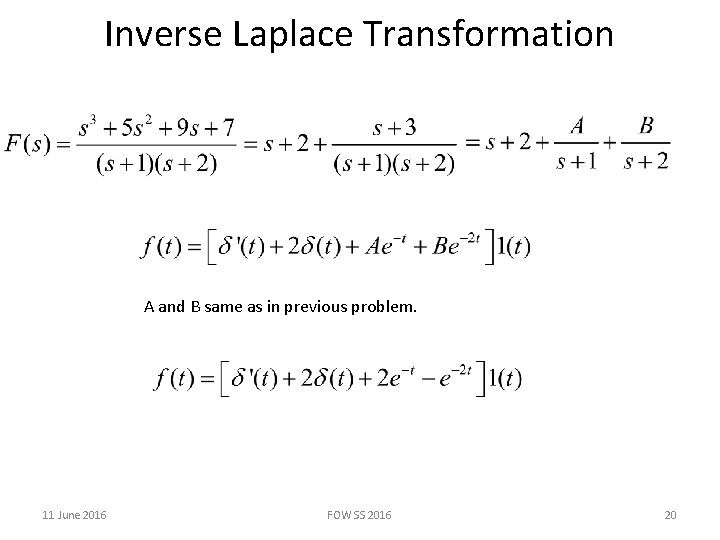
Inverse Laplace Transformation A and B same as in previous problem. 11 June 2016 FOW SS 2016 20
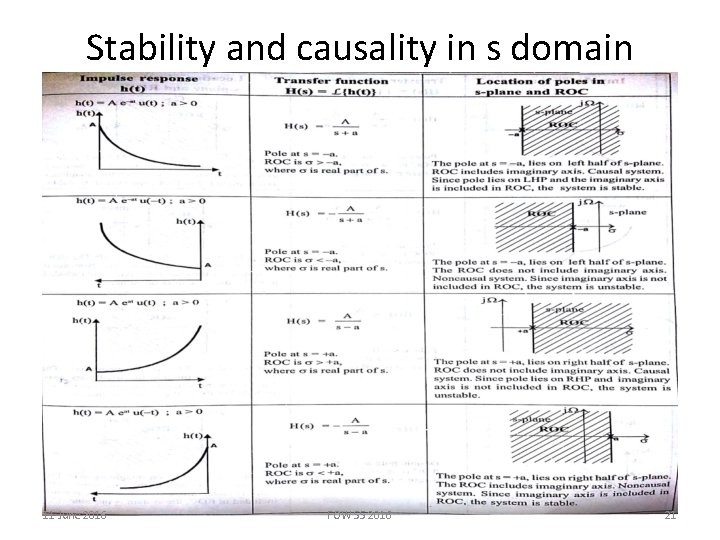
Stability and causality in s domain 11 June 2016 FOW SS 2016 21
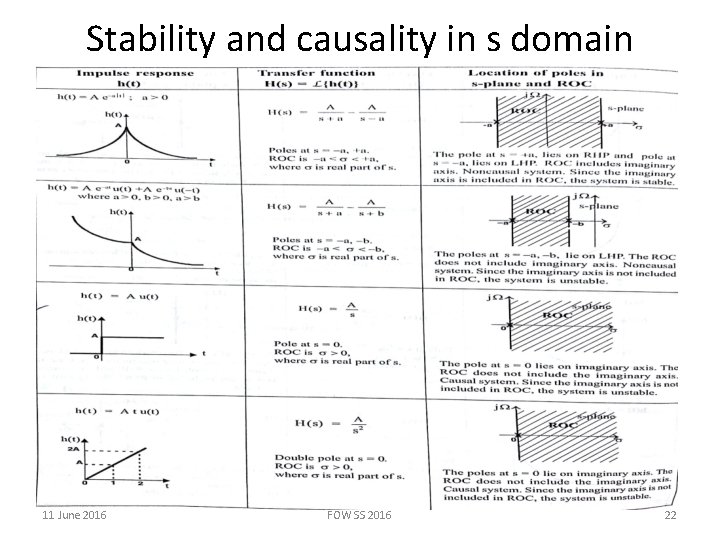
Stability and causality in s domain 11 June 2016 FOW SS 2016 22
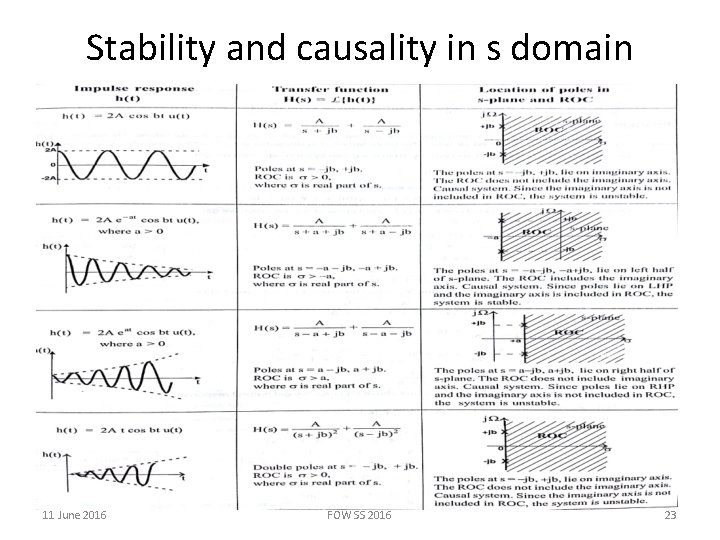
Stability and causality in s domain 11 June 2016 FOW SS 2016 23
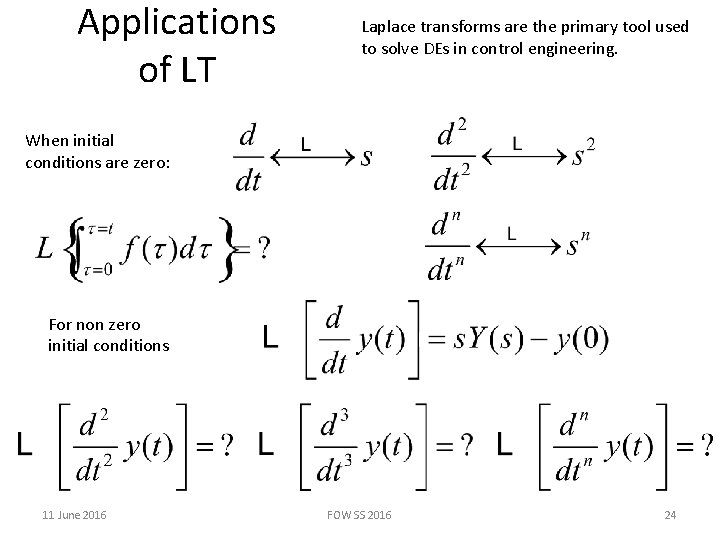
Applications of LT Laplace transforms are the primary tool used to solve DEs in control engineering. When initial conditions are zero: For non zero initial conditions 11 June 2016 FOW SS 2016 24
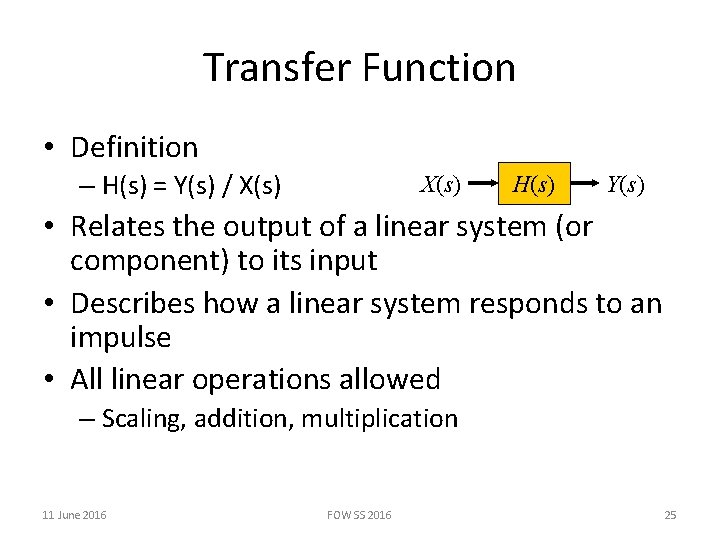
Transfer Function • Definition – H(s) = Y(s) / X(s) H(s) Y(s) • Relates the output of a linear system (or component) to its input • Describes how a linear system responds to an impulse • All linear operations allowed – Scaling, addition, multiplication 11 June 2016 FOW SS 2016 25
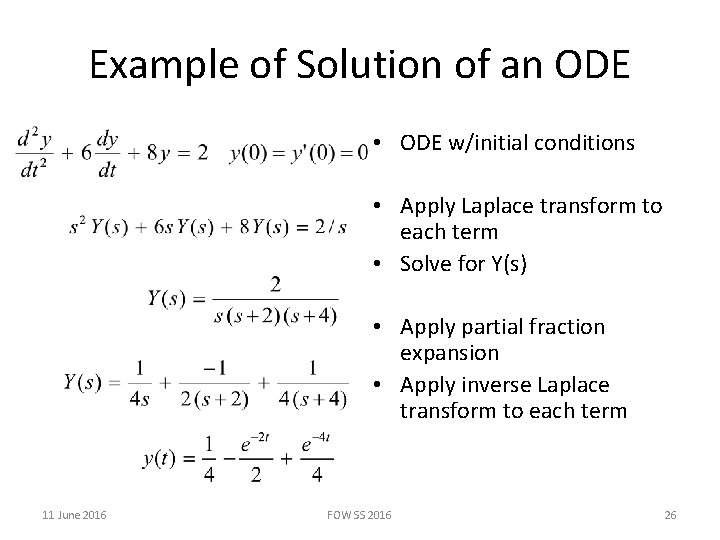
Example of Solution of an ODE • ODE w/initial conditions • Apply Laplace transform to each term • Solve for Y(s) • Apply partial fraction expansion • Apply inverse Laplace transform to each term 11 June 2016 FOW SS 2016 26
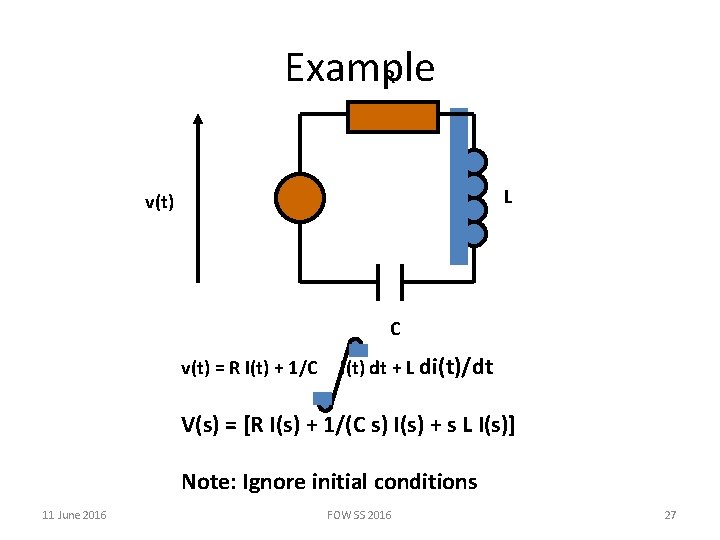
Example R L v(t) C v(t) = R I(t) + 1/C I(t) dt + L di(t)/dt V(s) = [R I(s) + 1/(C s) I(s) + s L I(s)] Note: Ignore initial conditions 11 June 2016 FOW SS 2016 27
Numerical on RLC circuit Step I: Apply KVL to entire circuit Step II : If initial conditions are not mentioned assume as zero. If initial conditions are given take them into account Step III : Find current i(t) from I(s) or asked parameter by taking Inverse LT 11 June 2016 FOW SS 2016 28
Mail id : For future communication gngaikwad. scoe@sinhgad. edu ganesh 1426@gmail. com 11 June 2016 FOW SS 2016 29
11 June 2016 FOW SS 2016 30