RealTime Systems CS 461 Senior Design Project AY
- Slides: 69
Real-Time Systems CS 461 - Senior Design Project (AY 2005)
Real-time research repository • For information on real-time research groups, conferences, journals, books, products, etc. , have a look at: http: //cs-www. bu. edu/pub/ieee-rts/Home. html CS 461 - Senior Design Project (AY 2005) 2
Introduction • A real-time system is a system whose specification includes both a logical and a temporal correctness requirement. – Logical correctness: produce correct output. • Can be checked by various means including Hoare axiomatics and other formal methods. – Temporal correctness: produces output at the right time. • A soft real-time system is one that can tolerate some delay in delivering the result. • A hard real-time system is one that can not afford to miss a dealine. CS 461 - Senior Design Project (AY 2005) 3
Characteristics of real-time systems • • • Event-driven, reactive High cost of failure Concurrency/multiprogramming Stand-alone/continuous operation. Reliability/fault tolerance requirements PREDICTABLE BEHAVIOR CS 461 - Senior Design Project (AY 2005) 4
Misconceptions about real-time systems • • • There is no science in real-time-system design. – We shall see… Advances in supercomputing hardware will take care of real-time requirements. – The old “buy a faster processor” argument… Real-time computing is equivalent to fast computing. – Only to ad agencies. To us, it means PREDICTABLE computing. CS 461 - Senior Design Project (AY 2005) 5
Misconceptions about real-time systems • • • Real-time programming is assembly coding, … – We would like to automate (as much as possible) real-time system design, instead of relying on clever hand-crafted code. “Real time” is performance engineering. – In real-time computing, timeliness is almost always more important than raw performance … “Real-time problems” have all been solved in other areas of CS or operations research. – OR people typically use stochastic queuing models or one-shot scheduling models to reason about systems. – CS people are usually interested in optimizing average-case performance. CS 461 - Senior Design Project (AY 2005) 6
Misconceptions about real-time systems • • It is not meaningful to talk about guaranteeing real-time performance when things can fail. – Though things may fail, we certainly don’t want the operating system to be the weakest link! Real-time systems function in a static environment. – Not true. We consider systems in which the operating mode may change dynamically. CS 461 - Senior Design Project (AY 2005) 7
Are all systems real-time systems? • • • Question: Is a payroll processing system a real-time system? – It has a time constraint: Print the pay checks every month. Perhaps it is a real-time system in a definitional sense, but it doesn’t pay us to view it as such. We are interested in systems for which it is not a priori obvious how to meet timing constraints. CS 461 - Senior Design Project (AY 2005) 8
Resources • Resources may be categorized as: – Abundant: Virtually any system design methodology can be used to realize the timing requirements of the application. – Insufficient: The application is ahead of the technology curve; no design methodology can be used to realize the timing requirements of the application. – Sufficient but scarce: It is possible to realize the timing requirements of the application, but careful resource allocation is required. CS 461 - Senior Design Project (AY 2005) 9
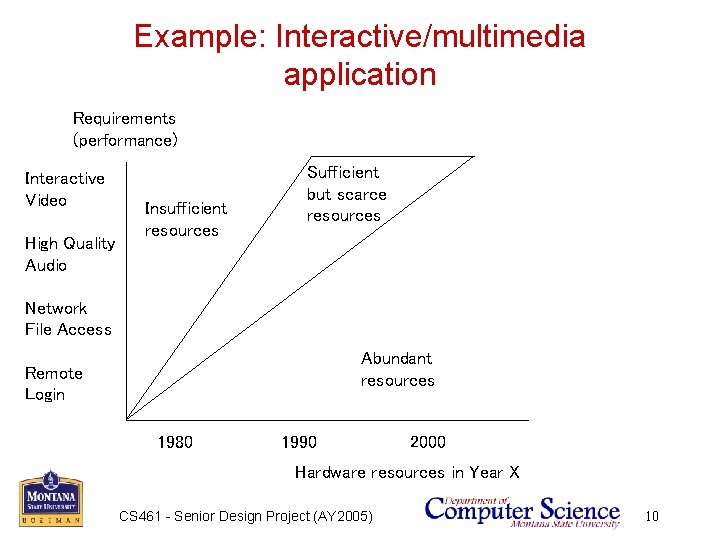
Example: Interactive/multimedia application Requirements (performance) Interactive Video High Quality Audio Insufficient resources Sufficient but scarce resources Network File Access Abundant resources Remote Login 1980 1990 2000 Hardware resources in Year X CS 461 - Senior Design Project (AY 2005) 10
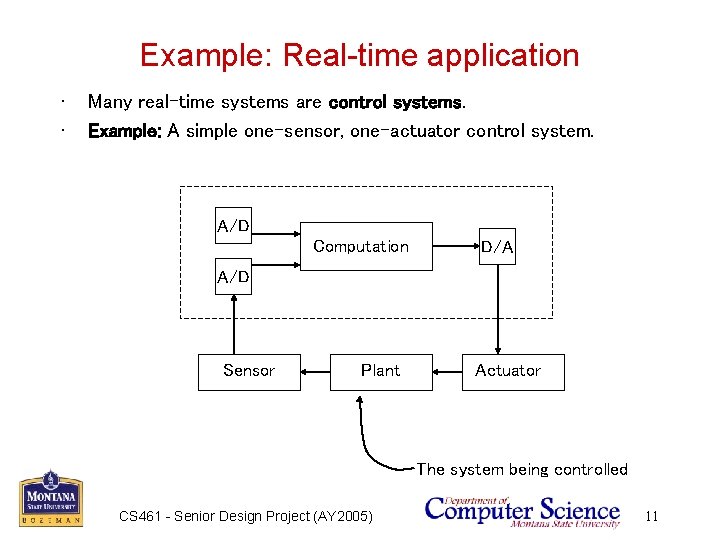
Example: Real-time application • • Many real-time systems are control systems. Example: A simple one-sensor, one-actuator control system. A/D Computation D/A A/D Sensor Plant Actuator The system being controlled CS 461 - Senior Design Project (AY 2005) 11
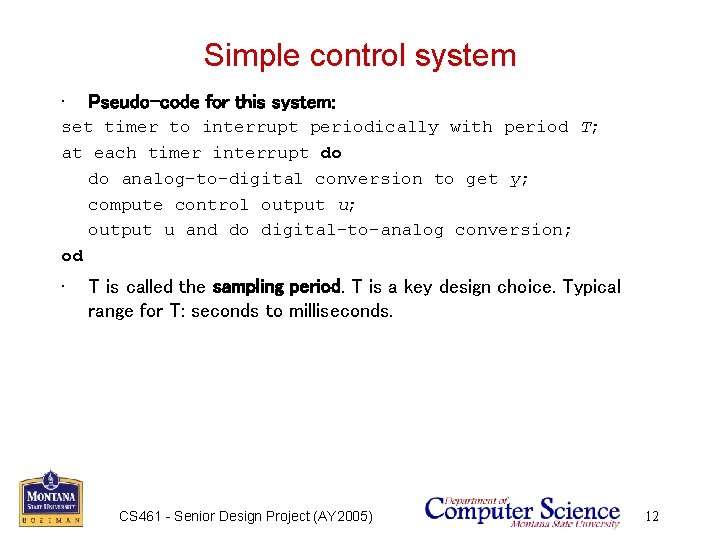
Simple control system • Pseudo-code for this system: set timer to interrupt periodically with period T; at each timer interrupt do do analog-to-digital conversion to get y; compute control output u; output u and do digital-to-analog conversion; od • T is called the sampling period. T is a key design choice. Typical range for T: seconds to milliseconds. CS 461 - Senior Design Project (AY 2005) 12
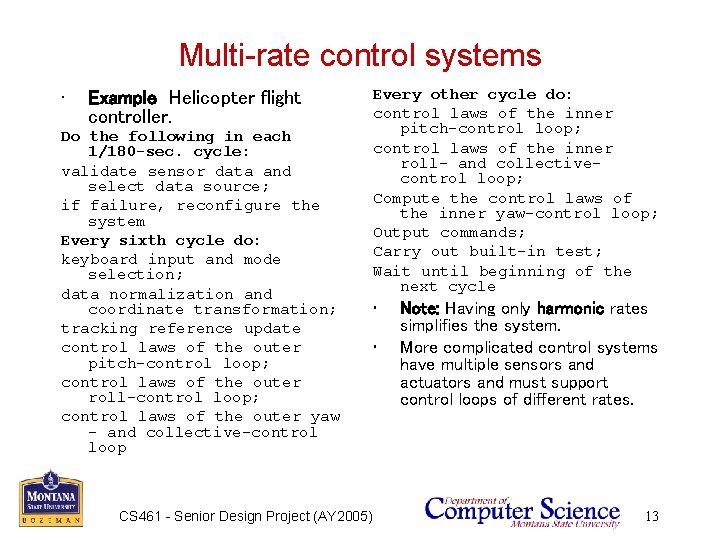
Multi-rate control systems • Example Helicopter flight controller. Do the following in each 1/180 -sec. cycle: validate sensor data and select data source; if failure, reconfigure the system Every sixth cycle do: keyboard input and mode selection; data normalization and coordinate transformation; tracking reference update control laws of the outer pitch-control loop; control laws of the outer roll-control loop; control laws of the outer yaw - and collective-control loop CS 461 - Senior Design Project (AY 2005) Every other cycle do: control laws of the inner pitch-control loop; control laws of the inner roll- and collectivecontrol loop; Compute the control laws of the inner yaw-control loop; Output commands; Carry out built-in test; Wait until beginning of the next cycle • • Note: Having only harmonic rates simplifies the system. More complicated control systems have multiple sensors and actuators and must support control loops of different rates. 13
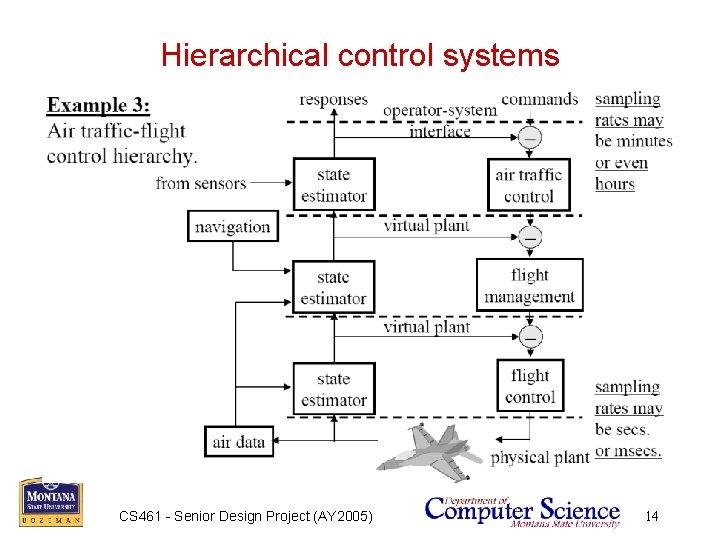
Hierarchical control systems CS 461 - Senior Design Project (AY 2005) 14
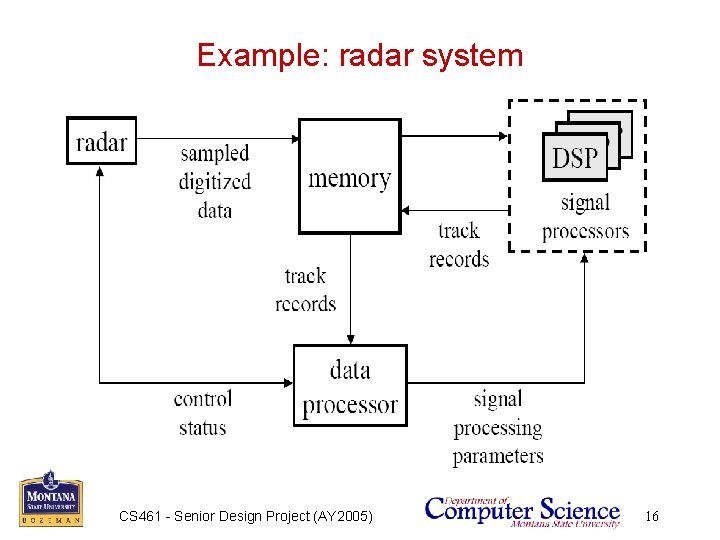
Signal processing systems • • • Signal-processing systems transform data from one form to another. Examples: – Digital filtering. – Video and voice compression/decompression. – Radar signal processing. Response times range from a few milliseconds to a few seconds. CS 461 - Senior Design Project (AY 2005) 15
Example: radar system CS 461 - Senior Design Project (AY 2005) 16
Other real-time applications • • Real-time databases. – Transactions must complete by deadlines. – Main dilemma: Transaction scheduling algorithms and real-time scheduling algorithms often have conflicting goals. – Data may be subject to absolute and relative temporal consistency requirements. Multimedia. – Want to process audio and video frames at steady rates. • TV video rate is 30 frames/sec. HDTV is 60 frames/sec. • Telephone audio is 16 Kbits/sec. CD audio is 128 Kbits/sec. – Other requirements: Lip synchronization, low jitter, low end-toend response times (if interactive). CS 461 - Senior Design Project (AY 2005) 17
Hard vs. soft real-time • • Task: A sequential piece of code. Job: Instance of a task. Jobs require resources to execute. – Example resources: CPU, network, disk, critical section. – We will simply call hardware resources “processors”. Release time of a job: The time instant the job becomes ready to execute. Deadline of a job: The time instant by which the job must complete execution. Relative deadline of a job: “Deadline - Release time”. Response time of a job: “Completion time - Release time”. CS 461 - Senior Design Project (AY 2005) 18
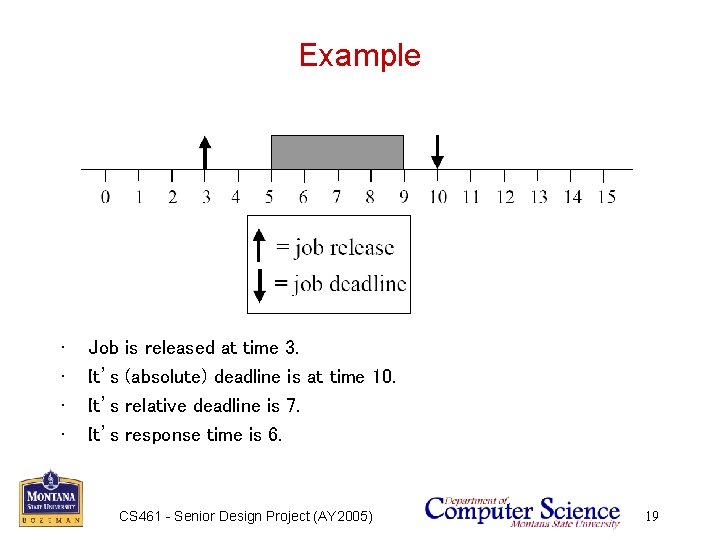
Example • • Job is released at time 3. It’s (absolute) deadline is at time 10. It’s relative deadline is 7. It’s response time is 6. CS 461 - Senior Design Project (AY 2005) 19
Hard real-time systems • • • A hard deadline must be met. – If any hard deadline is ever missed, then the system is incorrect. – Requires a means for validating that deadlines are met. Hard real-time system: A real-time system in which all deadlines are hard. Examples: Nuclear power plant control, flight control. CS 461 - Senior Design Project (AY 2005) 20
Soft real-time systems • • • A soft deadline may occasionally be missed. – Question: How to define “occasionally”? Soft real-time system: A real-time system in which some deadlines are soft. Examples: Telephone switches, multimedia applications. CS 461 - Senior Design Project (AY 2005) 21
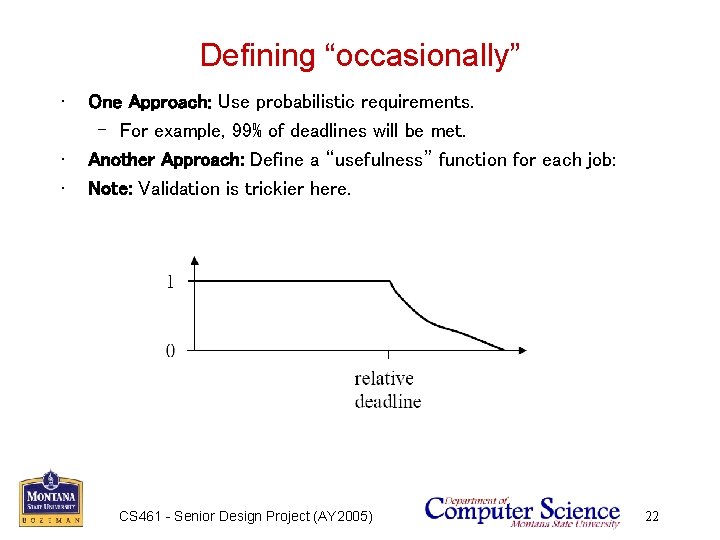
Defining “occasionally” • • • One Approach: Use probabilistic requirements. – For example, 99% of deadlines will be met. Another Approach: Define a “usefulness” function for each job: Note: Validation is trickier here. CS 461 - Senior Design Project (AY 2005) 22
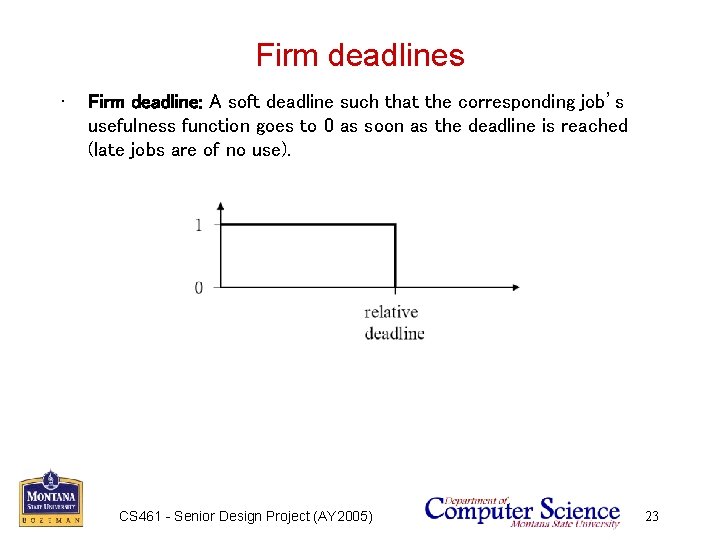
Firm deadlines • Firm deadline: A soft deadline such that the corresponding job’s usefulness function goes to 0 as soon as the deadline is reached (late jobs are of no use). CS 461 - Senior Design Project (AY 2005) 23
Reference model • • • Each job Ji is characterized by its release time ri, absolute deadline di, relative deadline Di, and execution time ei. Sometimes a range of release times is specified: [ri-, ri+]. This range is called release-time jitter. Likewise, sometimes instead of ei, execution time is specified to range over [ei-, ei+]. – Note: It can be difficult to get a precise estimate of ei CS 461 - Senior Design Project (AY 2005) 24
Periodic, sporadic aperiodic tasks • • Periodic task: – We associate a period pi with each task Ti. – pi is the time between job releases. Sporadic and aperiodic tasks: Released at arbitrary times. – Sporadic: Has a hard deadline. – Aperiodic: Has no deadline or a soft deadline. CS 461 - Senior Design Project (AY 2005) 25
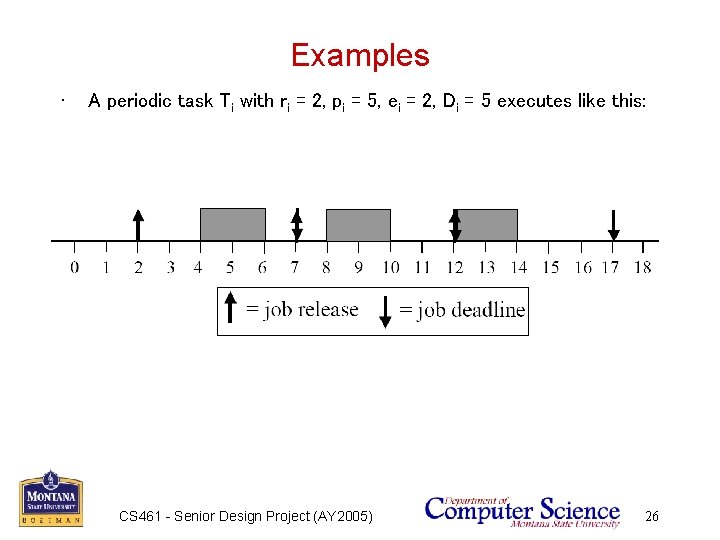
Examples • A periodic task Ti with ri = 2, pi = 5, ei = 2, Di = 5 executes like this: CS 461 - Senior Design Project (AY 2005) 26
Some definitions for periodic task systems • • • The jobs of task Ti are denoted Ji, 1, Ji, 2, …. ri, 1 (the release time of Ji, 1) is called the phase of Ti. – Synchronous System: Each task has a phase of 0. – Asynchronous System: Phases are arbitrary. Hyperperiod: Least common multiple of {pi}. Task utilization: ui = ei/pi. System utilization: U = Σi=1. . nui. CS 461 - Senior Design Project (AY 2005) 27
Task dependencies • • Two main kinds of dependencies: – Critical Sections. – Precedence Constraints. • For example, job Ji may be constrained to be released only after job Jk completes. Tasks with no dependencies are called independent. CS 461 - Senior Design Project (AY 2005) 28
Scheduling algorithms • We are generally interested in two kinds of algorithms: 1. A scheduler or scheduling algorithm, which generates a schedule at runtime. 2. A feasibility analysis algorithm, which checks if timing constraints are met. • Usually (but not always) Algorithm 1 is pretty straightforward, while Algorithm 2 is more complex. CS 461 - Senior Design Project (AY 2005) 29
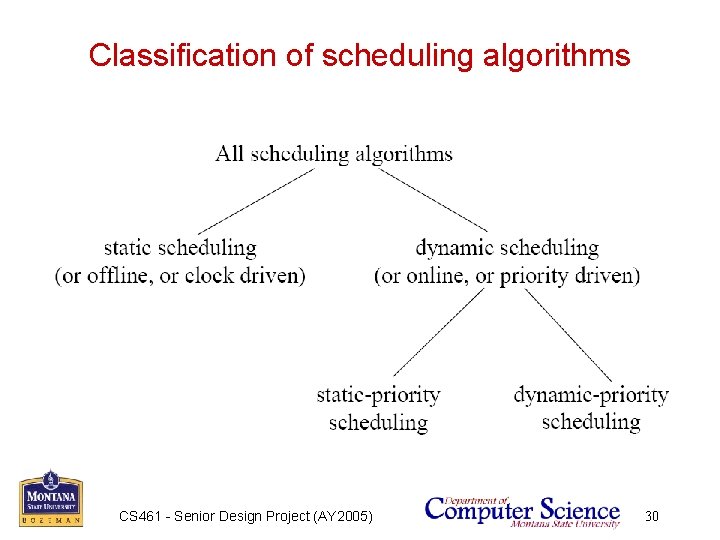
Classification of scheduling algorithms CS 461 - Senior Design Project (AY 2005) 30
Optimality and feasibility • • • A schedule is feasible if all timing constraints are met. – The term “correct” is probably better — see the next slide. A task set T is schedulable using scheduling algorithm A if A always produces a feasible schedule for T. A scheduling algorithm is optimal if it always produces a feasible schedule when one exists (under any scheduling algorithm). – Can similarly define optimality for a class of schedulers, e. g. , “an optimal static-priority scheduling algorithm. ” CS 461 - Senior Design Project (AY 2005) 31
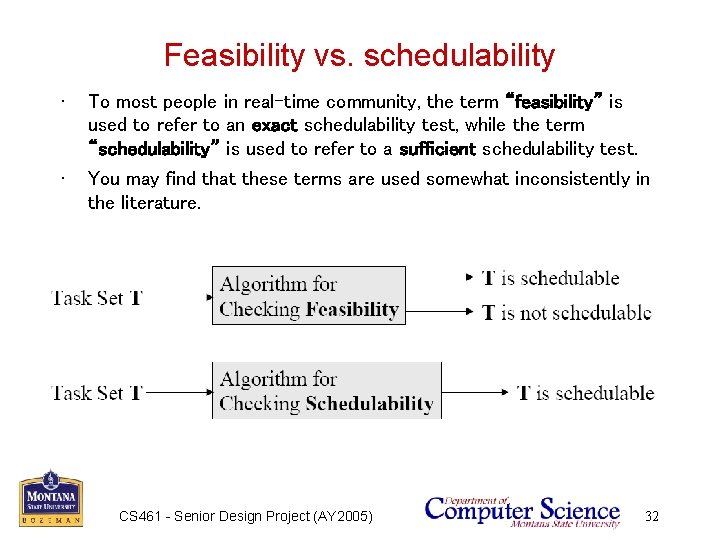
Feasibility vs. schedulability • • To most people in real-time community, the term “feasibility” is used to refer to an exact schedulability test, while the term “schedulability” is used to refer to a sufficient schedulability test. You may find that these terms are used somewhat inconsistently in the literature. CS 461 - Senior Design Project (AY 2005) 32
Clock driven (or static) scheduling • Model assumes – n periodic tasks T 1, …, Tn. – The “rest of the world” periodic model is assumed. – Ti is specified by (fi, pi, ei, Di), where • fi is its phase, • pi is its period, • ei is its execution cost per job, and • Di is its relative deadline. • Will abbreviate as (pi, ei, Di) if fi=0, and (pi, ei) if fi=0 ∧ pi=Di. – We also have aperiodic jobs that are released at arbitrary times CS 461 - Senior Design Project (AY 2005) 33
Schedule table • Our scheduler will schedule periodic jobs using a static schedule that is computed offline and stored in a table T. – T(tk) = Ti if Ti is to be scheduled at time tk I if no periodic task is scheduled at time tk – For most of this chapter, we assume the table is given. – Later, we consider one algorithm for producing the table. Note: This algorithm need not be highly efficient. – We will schedule aperiodic jobs (if any are ready) in intervals not used by periodic jobs. { • CS 461 - Senior Design Project (AY 2005) 34
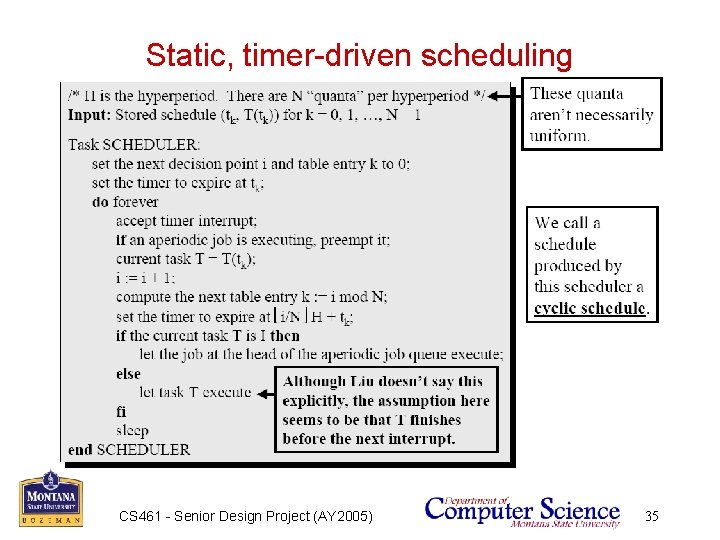
Static, timer-driven scheduling CS 461 - Senior Design Project (AY 2005) 35
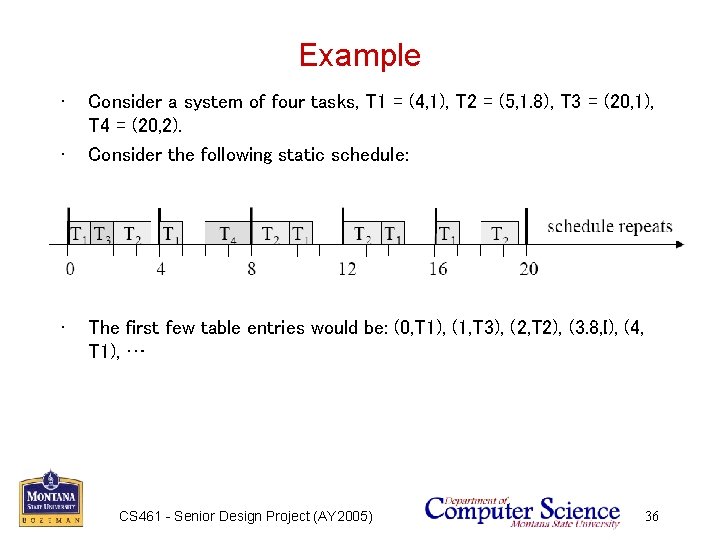
Example • • • Consider a system of four tasks, T 1 = (4, 1), T 2 = (5, 1. 8), T 3 = (20, 1), T 4 = (20, 2). Consider the following static schedule: The first few table entries would be: (0, T 1), (1, T 3), (2, T 2), (3. 8, I), (4, T 1), … CS 461 - Senior Design Project (AY 2005) 36
Frames • • • Let us refine this notion of scheduling… To keep the table small, we divide the time line into frames and make scheduling decisions only at frame boundaries. – Each job is executed as a procedure call that must fit within a frame. – Multiple jobs may be executed in a frame, but the table is only examined at frame boundaries (the number of “columns” in the table = the number of frames per hyperperiod). – In addition to making scheduling decisions, the scheduler also checks for various error conditions, like task overruns, at the beginning of each frame. We let f denote the frame size. CS 461 - Senior Design Project (AY 2005) 37
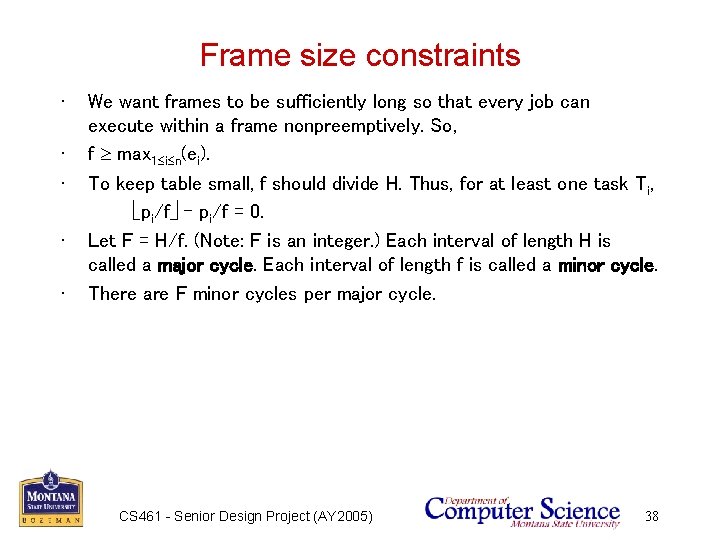
Frame size constraints • • • We want frames to be sufficiently long so that every job can execute within a frame nonpreemptively. So, f ³ max 1£i£n(ei). To keep table small, f should divide H. Thus, for at least one task T i, ëpi/fû - pi/f = 0. Let F = H/f. (Note: F is an integer. ) Each interval of length H is called a major cycle. Each interval of length f is called a minor cycle. There are F minor cycles per major cycle. CS 461 - Senior Design Project (AY 2005) 38
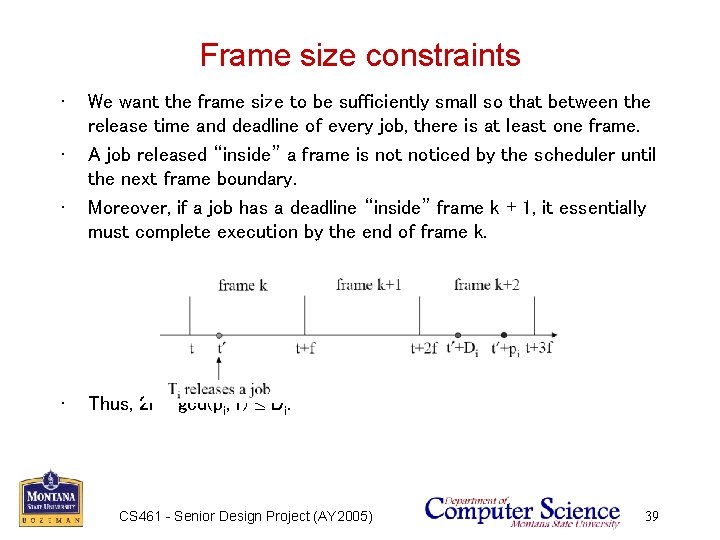
Frame size constraints • • We want the frame size to be sufficiently small so that between the release time and deadline of every job, there is at least one frame. A job released “inside” a frame is noticed by the scheduler until the next frame boundary. Moreover, if a job has a deadline “inside” frame k + 1, it essentially must complete execution by the end of frame k. Thus, 2 f - gcd(pi, f) £ Di. CS 461 - Senior Design Project (AY 2005) 39
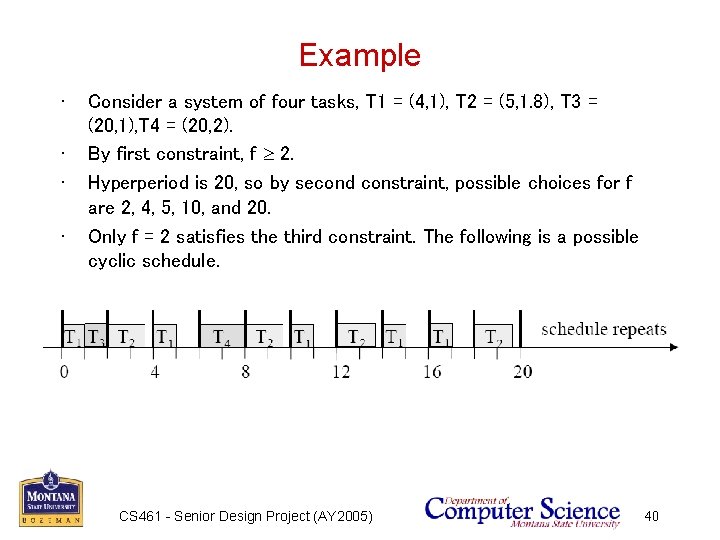
Example • • Consider a system of four tasks, T 1 = (4, 1), T 2 = (5, 1. 8), T 3 = (20, 1), T 4 = (20, 2). By first constraint, f ³ 2. Hyperperiod is 20, so by second constraint, possible choices for f are 2, 4, 5, 10, and 20. Only f = 2 satisfies the third constraint. The following is a possible cyclic schedule. CS 461 - Senior Design Project (AY 2005) 40
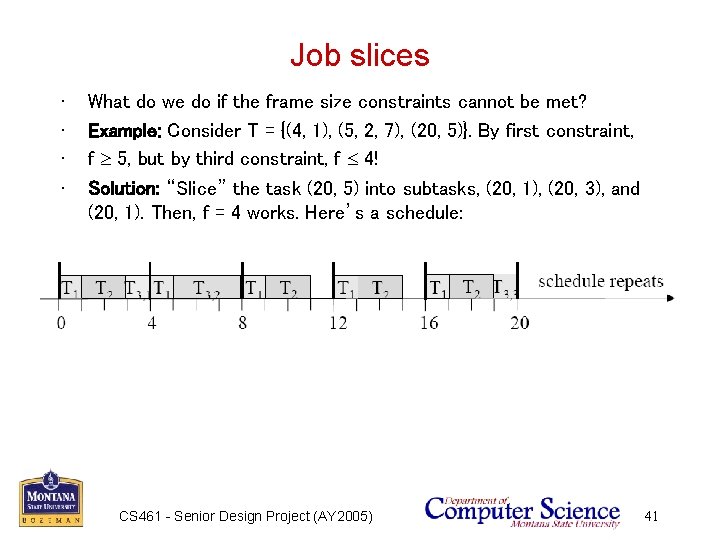
Job slices • • What do we do if the frame size constraints cannot be met? Example: Consider T = {(4, 1), (5, 2, 7), (20, 5)}. By first constraint, f ³ 5, but by third constraint, f £ 4! Solution: “Slice” the task (20, 5) into subtasks, (20, 1), (20, 3), and (20, 1). Then, f = 4 works. Here’s a schedule: CS 461 - Senior Design Project (AY 2005) 41
Summary of design decisions • • Three design decisions: – choosing a frame size, – partitioning jobs into slices, and – placing slices in frames. In general, these decisions cannot be made independently. CS 461 - Senior Design Project (AY 2005) 42
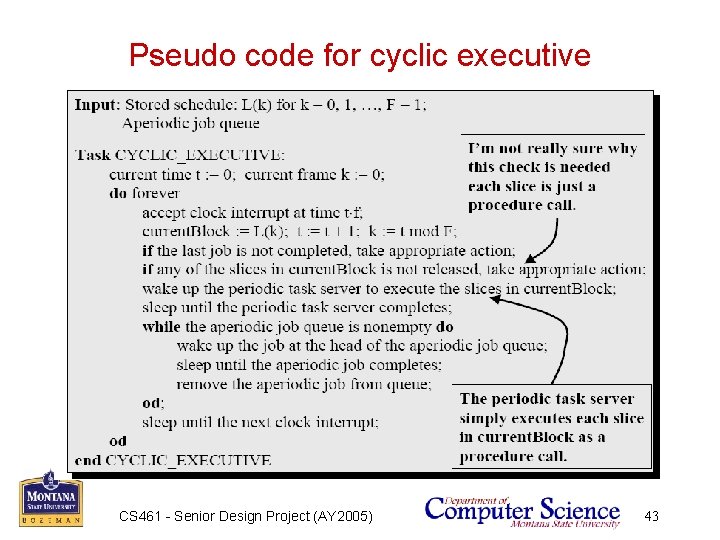
Pseudo code for cyclic executive CS 461 - Senior Design Project (AY 2005) 43
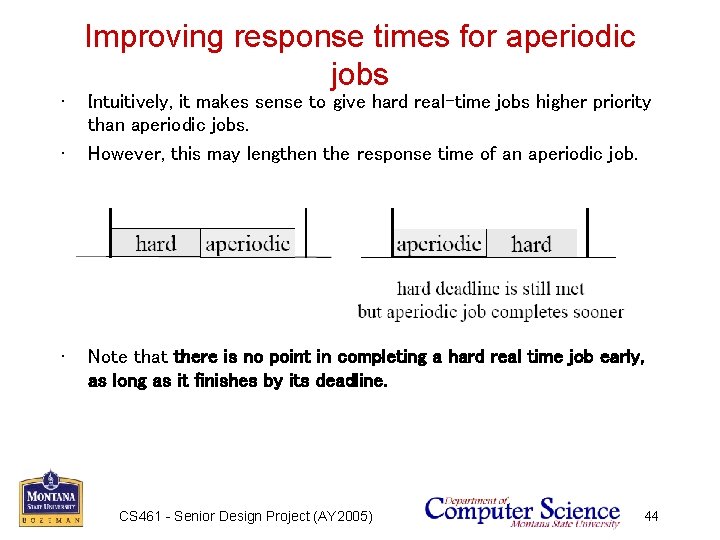
• • • Improving response times for aperiodic jobs Intuitively, it makes sense to give hard real-time jobs higher priority than aperiodic jobs. However, this may lengthen the response time of an aperiodic job. Note that there is no point in completing a hard real time job early, as long as it finishes by its deadline. CS 461 - Senior Design Project (AY 2005) 44
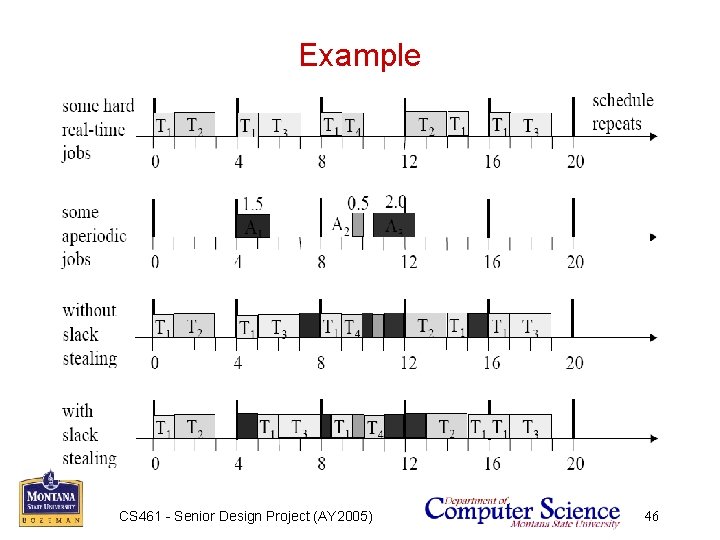
Slack stealing • • • Let the total amount of time allocated to all the slices scheduled in frame k be xk. Definition: The slack available at the beginning of frame k is f - xk. Change to scheduler: – If the aperiodic job queue is non-empty, let aperiodic jobs execute in each frame whenever there is nonzero slack. CS 461 - Senior Design Project (AY 2005) 45
Example CS 461 - Senior Design Project (AY 2005) 46
Implementing slack stealing • • Use a pre-computed “initial slack” table. – Initial slack depends only on static quantities. Use an interval timer to keep track of available slack. – Set the timer when an aperiodic job begins to run. If it goes off, must start executing periodic jobs. – Problem: Most OSs do not provide sub-millisecond granularity interval timers. – So, to use slack stealing, temporal parameters must be on the order of 100 s of msecs. or secs. CS 461 - Senior Design Project (AY 2005) 47
Scheduling sporiadic jobs • • • Sporadic jobs arrive at arbitrary times. They have hard deadlines. Implies we cannot hope to schedule every sporadic job. When a sporadic job arrives, the scheduler performs an acceptance test to see if the job can be completed by its deadline. We must ensure that a new sporadic job does not cause a previously-accepted sporadic job to miss its deadline. We assume sporadic jobs are prioritized on an earliest deadlinefirst (EDF) basis. CS 461 - Senior Design Project (AY 2005) 48
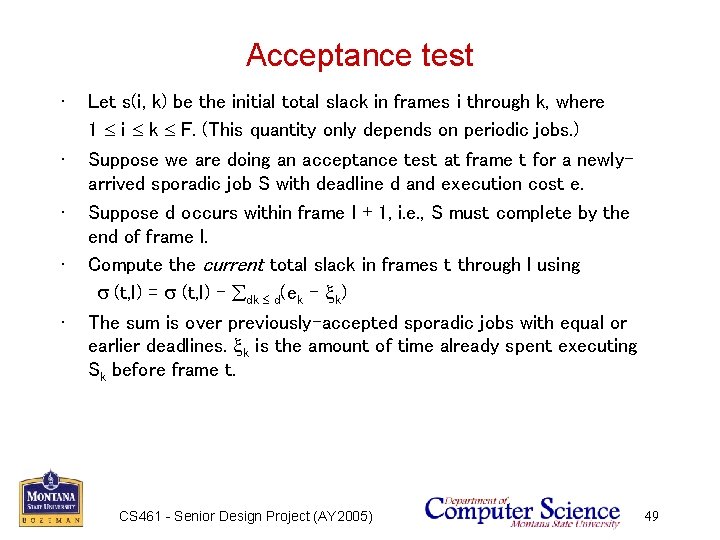
Acceptance test • • • Let s(i, k) be the initial total slack in frames i through k, where 1 £ i £ k £ F. (This quantity only depends on periodic jobs. ) Suppose we are doing an acceptance test at frame t for a newlyarrived sporadic job S with deadline d and execution cost e. Suppose d occurs within frame l + 1, i. e. , S must complete by the end of frame l. Compute the current total slack in frames t through l using s (t, l) = s (t, l) - ådk £ d(ek - xk) The sum is over previously-accepted sporadic jobs with equal or earlier deadlines. xk is the amount of time already spent executing Sk before frame t. CS 461 - Senior Design Project (AY 2005) 49
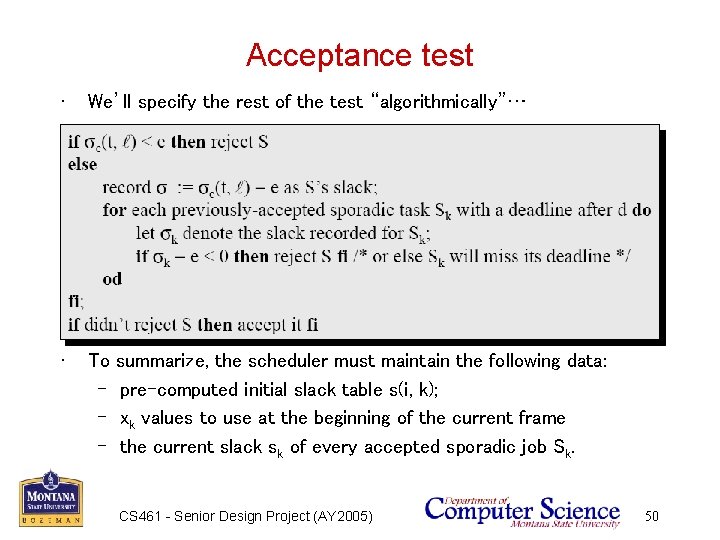
Acceptance test • We’ll specify the rest of the test “algorithmically”… • To – – – summarize, the scheduler must maintain the following data: pre-computed initial slack table s(i, k); xk values to use at the beginning of the current frame the current slack sk of every accepted sporadic job Sk. CS 461 - Senior Design Project (AY 2005) 50
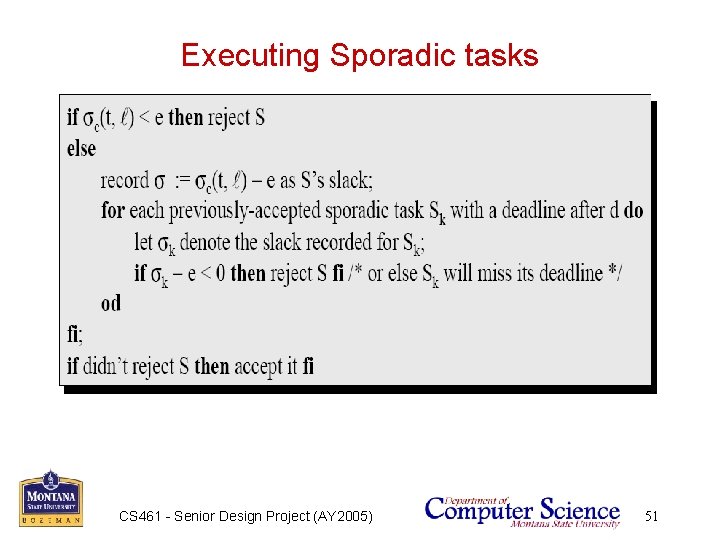
Executing Sporadic tasks CS 461 - Senior Design Project (AY 2005) 51
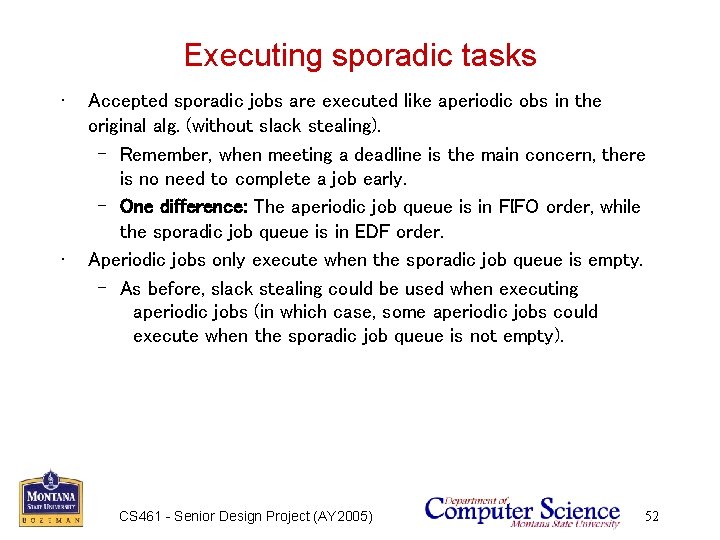
Executing sporadic tasks • • Accepted sporadic jobs are executed like aperiodic obs in the original alg. (without slack stealing). – Remember, when meeting a deadline is the main concern, there is no need to complete a job early. – One difference: The aperiodic job queue is in FIFO order, while the sporadic job queue is in EDF order. Aperiodic jobs only execute when the sporadic job queue is empty. – As before, slack stealing could be used when executing aperiodic jobs (in which case, some aperiodic jobs could execute when the sporadic job queue is not empty). CS 461 - Senior Design Project (AY 2005) 52
Practical considerations • • • Handling frame overruns. – Main Issue: Should offending job be completed or aborted? Mode changes. – During a mode change, the running set of tasks is replaced by a new set of tasks (i. e. , the table is changed). – Can implement mode change by having an aperiodic or sporadic mode-change job. (If sporadic, what if it fails the acceptance test? ? ? ) Multiprocessors. – Like uniprocessors, but table probably takes longer to precompute. CS 461 - Senior Design Project (AY 2005) 53
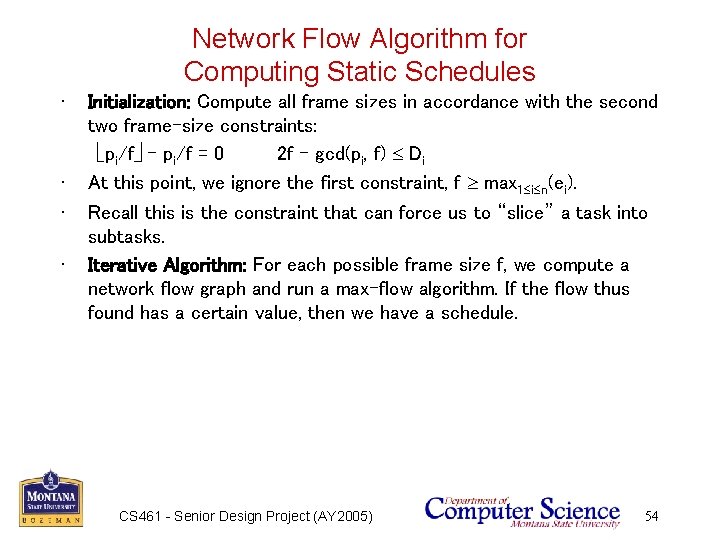
Network Flow Algorithm for Computing Static Schedules • • Initialization: Compute all frame sizes in accordance with the second two frame-size constraints: ëpi/fû - pi/f = 0 2 f - gcd(pi, f) £ Di At this point, we ignore the first constraint, f ³ max 1£i£n(ei). Recall this is the constraint that can force us to “slice” a task into subtasks. Iterative Algorithm: For each possible frame size f, we compute a network flow graph and run a max-flow algorithm. If the flow thus found has a certain value, then we have a schedule. CS 461 - Senior Design Project (AY 2005) 54
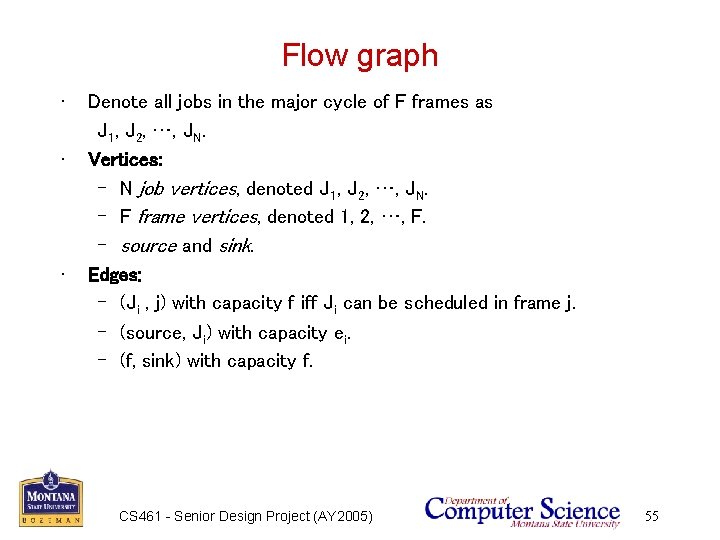
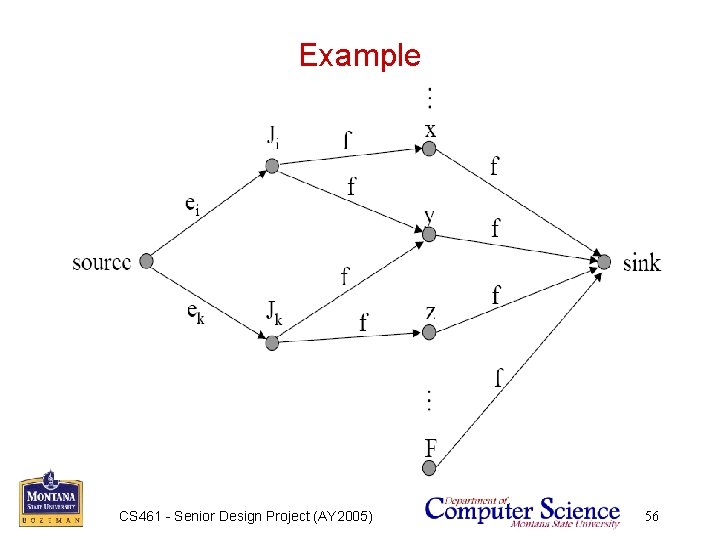
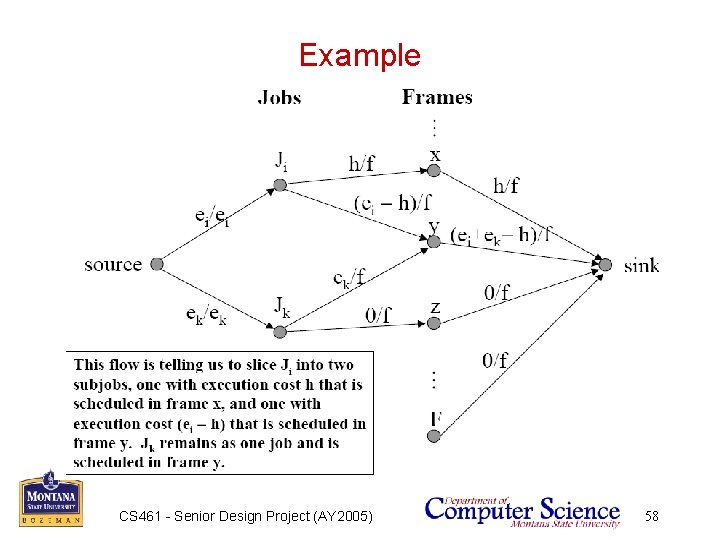
Flow graph • • • Denote all jobs in the major cycle of F frames as J 1, J 2, …, JN. Vertices: – N job vertices, denoted J 1, J 2, …, JN. – F frame vertices, denoted 1, 2, …, F. – source and sink. Edges: – (Ji , j) with capacity f iff Ji can be scheduled in frame j. – (source, Ji) with capacity ei. – (f, sink) with capacity f. CS 461 - Senior Design Project (AY 2005) 55
Example CS 461 - Senior Design Project (AY 2005) 56
Finding a schedule • • The maximum attainable flow value is clearly åi=1, …, N ei. This corresponds to the exact amount of computation to be scheduled in the major cycle. If a max flow is found with value åi=1, …, N ei, then we have a schedule. If a job is scheduled across multiple frames, then we must slice it into corresponding subjobs. CS 461 - Senior Design Project (AY 2005) 57
Example CS 461 - Senior Design Project (AY 2005) 58
Non-independent tasks • • Tasks with precedence constraints are no problem. – We can enforce precedence constraint like “Ji precedes Jk” by simply making sure Ji’s release is at or before Jk’s release, and Ji’s deadline is at or before Jk’s deadline. – If slices of Ji and Jk are scheduled in the wrong order, we can just swap them. Critical sections pose a greater challenge. – We can try to “massage” the flow-network schedule into one where nonpreemption constraints are respected. – Unfortunately, there is no known efficient, optimal algorithm for doing this (the problem is actually NP-hard). CS 461 - Senior Design Project (AY 2005) 59
Pros and Cons of Cyclic Executives • Main Advantage: CEs are very simple - you just need a table. – For example, additional mechanisms for concurrency control and synchronization are not needed. In fact, there’s really no notion of a “process” here – just procedure calls. – Can validate, test, and certify with very high confidence. – Certain anomalies will not occur. – For these reasons, cyclic executives are the predominant approach in many safety-critical applications (like airplanes). CS 461 - Senior Design Project (AY 2005) 60
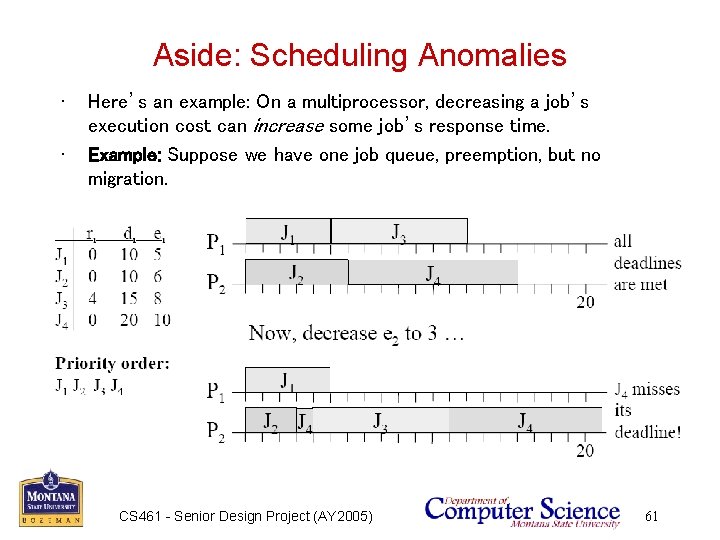
Aside: Scheduling Anomalies • • Here’s an example: On a multiprocessor, decreasing a job’s execution cost can increase some job’s response time. Example: Suppose we have one job queue, preemption, but no migration. CS 461 - Senior Design Project (AY 2005) 61
Disadvantages • Disadvantages of cyclic executives: – Very brittle: Any change, no matter how trivial, requires that a new table be computed! – Release times of all jobs must be fixed, i. e. , “real-world” sporadic tasks are difficult to support. – Temporal parameters essentially must be multiples of f. – F could be huge! – All combinations of periodic tasks that may execute together must a priori be analyzed. – From a software engineering standpoint, “slicing” one procedure into several could be error-prone. CS 461 - Senior Design Project (AY 2005) 62
Dynamic-priority scheduling • • Let us consider a priority-based dynamic scheduling approach. – Each job is assigned a priority, and the highest-priority job executes at any time. Under dynamic-priority scheduling, different jobs of a task may be assigned different priorities. – Can have the following: job Ji, k of task Ti has higher priority than job Jj, m of task Tj, but job Ji, l of Ti has lower priority than job Jj, n of Tj. CS 461 - Senior Design Project (AY 2005) 63
Outline • • We consider both earliest-deadline-first (EDF) and least-laxity-first (LLF) scheduling. Outline: – Optimality of EDF and LLF – Utilization-based schedulability test for EDF CS 461 - Senior Design Project (AY 2005) 64
Optimality of EDF • • Theorem: [Liu and Layland] When preemption is allowed and jobs do not contend for resources, the EDF algorithm can produce a feasible schedule of a set J of independent jobs with arbitrary release times and deadlines on a processor if and only if J has feasible schedules. Notes: – Applies even if tasks are not periodic. – If periodic, a task’s relative deadline can be less than its period, equal to its period, or greater than its period. CS 461 - Senior Design Project (AY 2005) 65
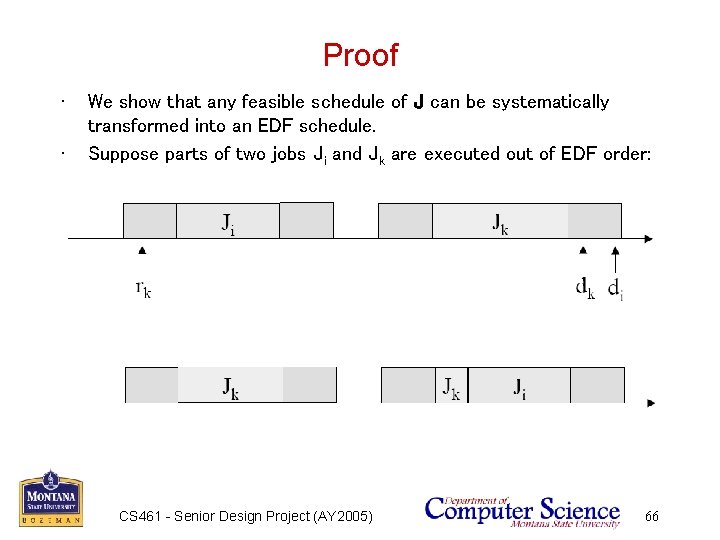
Proof • • We show that any feasible schedule of J can be systematically transformed into an EDF schedule. Suppose parts of two jobs Ji and Jk are executed out of EDF order: • This situation can be corrected by performing a “swap”: CS 461 - Senior Design Project (AY 2005) 66
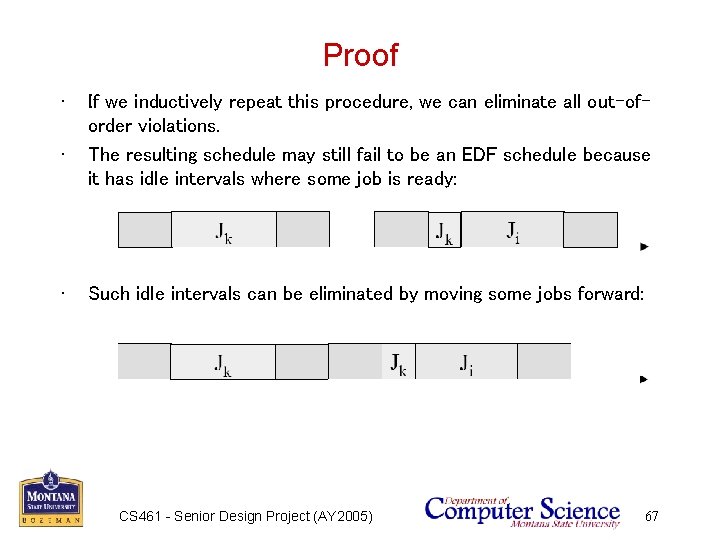
Proof • • • If we inductively repeat this procedure, we can eliminate all out-oforder violations. The resulting schedule may still fail to be an EDF schedule because it has idle intervals where some job is ready: Such idle intervals can be eliminated by moving some jobs forward: CS 461 - Senior Design Project (AY 2005) 67
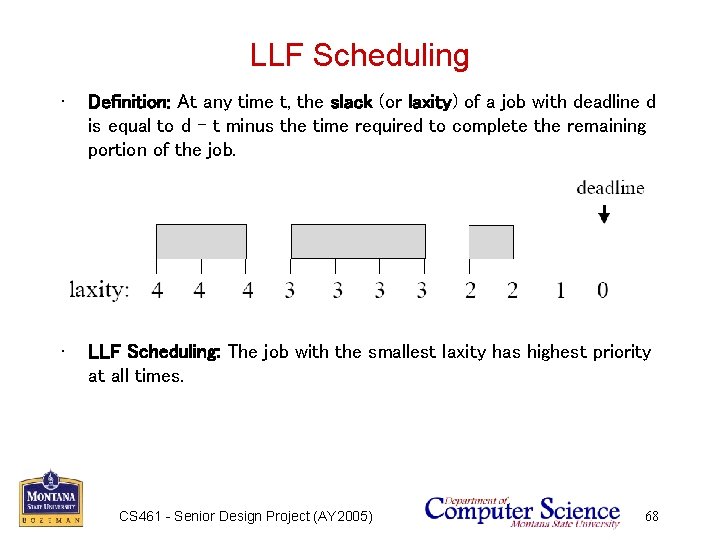
LLF Scheduling • Definition: At any time t, the slack (or laxity) of a job with deadline d is equal to d - t minus the time required to complete the remaining portion of the job. • LLF Scheduling: The job with the smallest laxity has highest priority at all times. CS 461 - Senior Design Project (AY 2005) 68
Optimality of LLF • • Theorem: When preemption is allowed and jobs do not contend for resources, the LLF algorithm can produce a feasible schedule of a set J of independent jobs with arbitrary release times and deadlines on a processor if and only if J has feasible schedules. The proof is similar to that for EDF. CS 461 - Senior Design Project (AY 2005) 69