ACS Dave Auslander Dave Pankow Han Chen YaoTing
- Slides: 27
ACS Dave Auslander, Dave Pankow, Han Chen, Yao-Ting Mao, UC Berkeley Space Sciences Laboratory University of California, Berkeley August 10, 2010 TRIO-CINEMA 1 UCB, 2/08/2010
Overview ACS creates Magnetic Torques to control CINEMA attitude & spin • Torque = M (coil moment = mn. IA) X B (Earth’s magnetic field) • Precession (or pointing) coil is parallel to spin axis (quasi-DC currents) • Spin coil is orthogonal to spin axis (AC current to spin) • SENSORS: Sun Sensor & Magnetometer • ACTUATORS: two onboard coils • Direction of B changes over each orbit (this data is not available on Cinema) • Ground Station will daily uplink direction of B vs. time (ground ephemeris) • ACS MODES • After Launch: B dot de-tumble mode (has limit function) • Operational: Spin Control ; Precession Control; TRIO-CINEMA 2 OFF for Science UCB, 2/08/2010
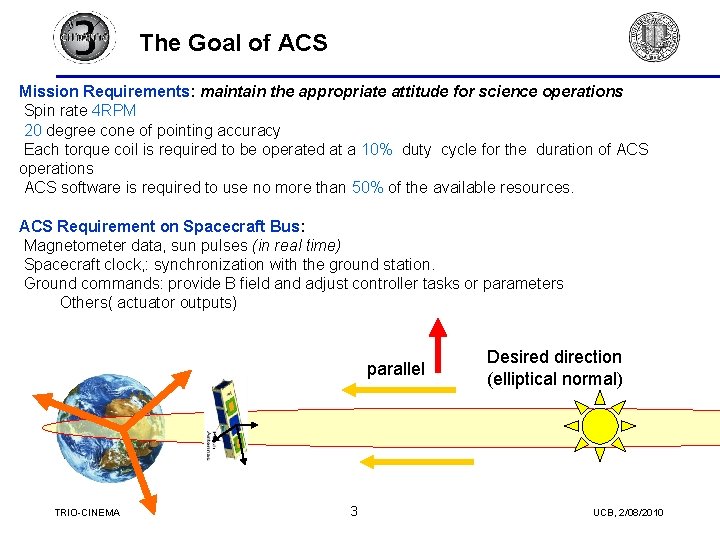
The Goal of ACS Mission Requirements: maintain the appropriate attitude for science operations Spin rate 4 RPM 20 degree cone of pointing accuracy Each torque coil is required to be operated at a 10% duty cycle for the duration of ACS operations ACS software is required to use no more than 50% of the available resources. ACS Requirement on Spacecraft Bus: Magnetometer data, sun pulses (in real time) Spacecraft clock, : synchronization with the ground station. Ground commands: provide B field and adjust controller tasks or parameters Others( actuator outputs) parallel TRIO-CINEMA 3 Desired direction (elliptical normal) UCB, 2/08/2010
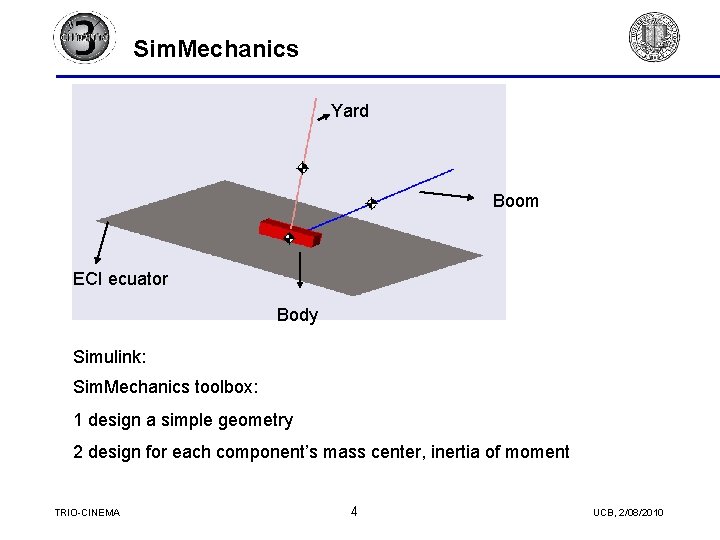
Sim. Mechanics Yard Boom ECI ecuator Body Simulink: Sim. Mechanics toolbox: 1 design a simple geometry 2 design for each component’s mass center, inertia of moment TRIO-CINEMA 4 UCB, 2/08/2010
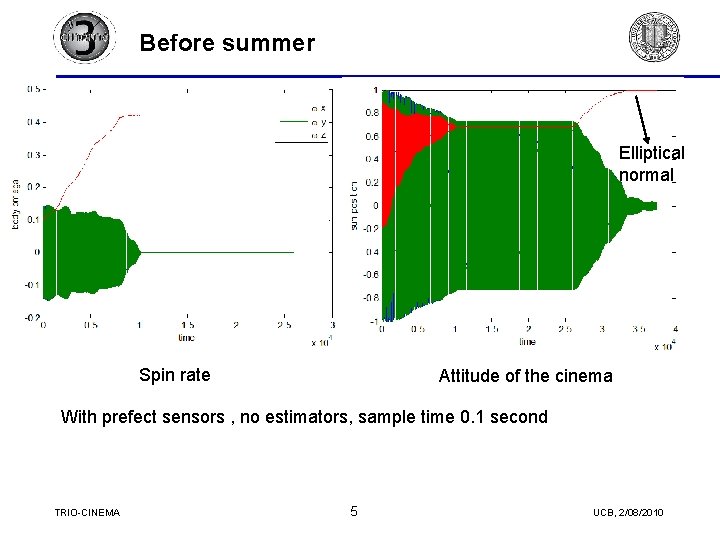
Before summer Elliptical normal Spin rate Attitude of the cinema With prefect sensors , no estimators, sample time 0. 1 second TRIO-CINEMA 5 UCB, 2/08/2010
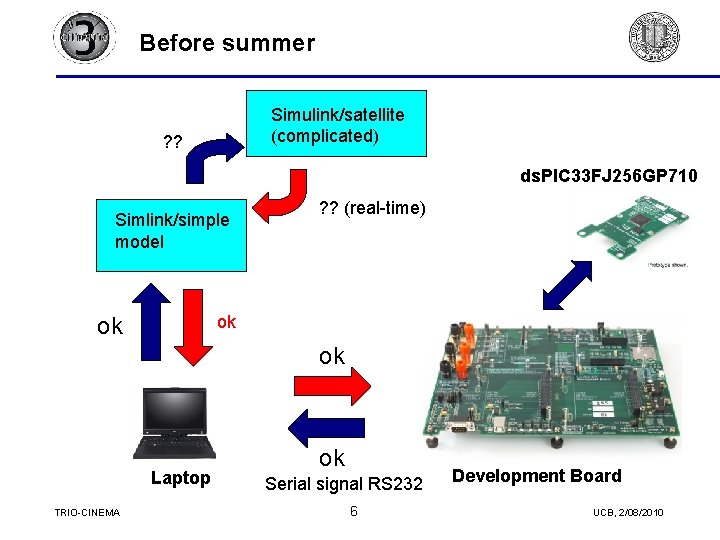
Before summer Simulink/satellite (complicated) ? ? ds. PIC 33 FJ 256 GP 710 Simlink/simple model ? ? (real-time) ok ok ok Laptop TRIO-CINEMA ok Serial signal RS 232 6 Development Board UCB, 2/08/2010
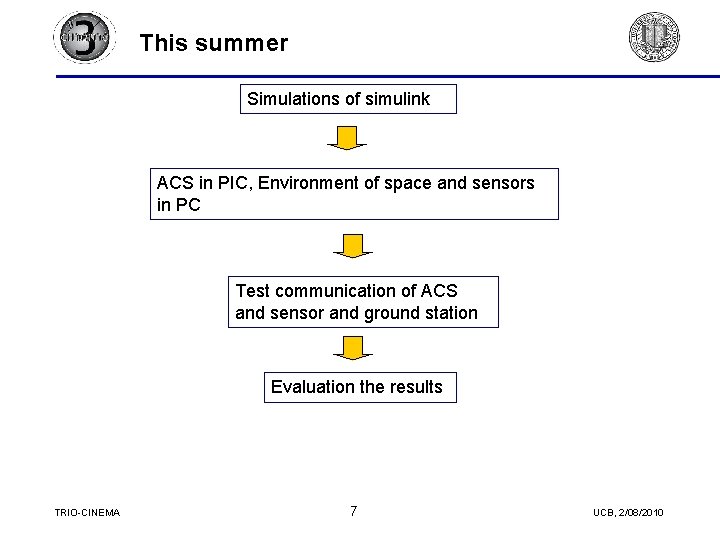
This summer Simulations of simulink ACS in PIC, Environment of space and sensors in PC Test communication of ACS and sensor and ground station Evaluation the results TRIO-CINEMA 7 UCB, 2/08/2010
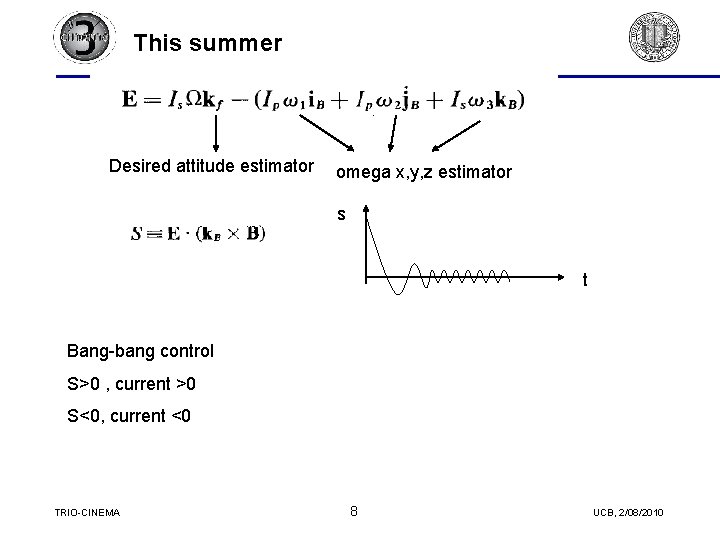
This summer Desired attitude estimator omega x, y, z estimator s t Bang-bang control S>0 , current >0 S<0, current <0 TRIO-CINEMA 8 UCB, 2/08/2010
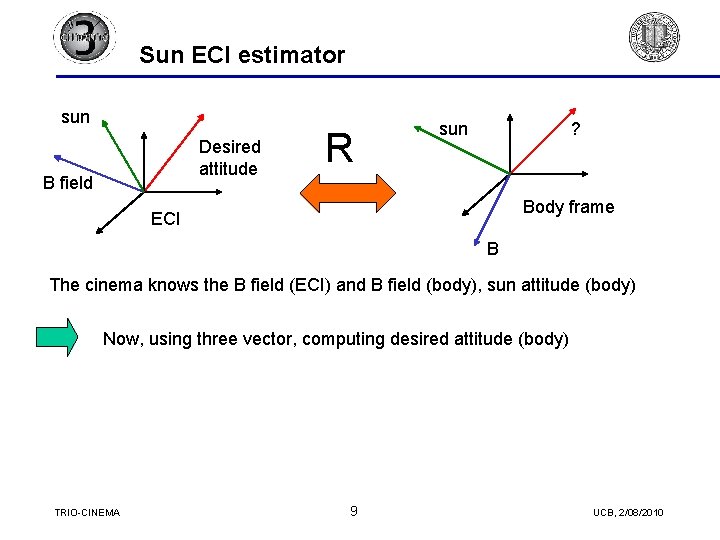
Sun ECI estimator sun Desired attitude B field R sun ? Body frame ECI B The cinema knows the B field (ECI) and B field (body), sun attitude (body) Now, using three vector, computing desired attitude (body) TRIO-CINEMA 9 UCB, 2/08/2010
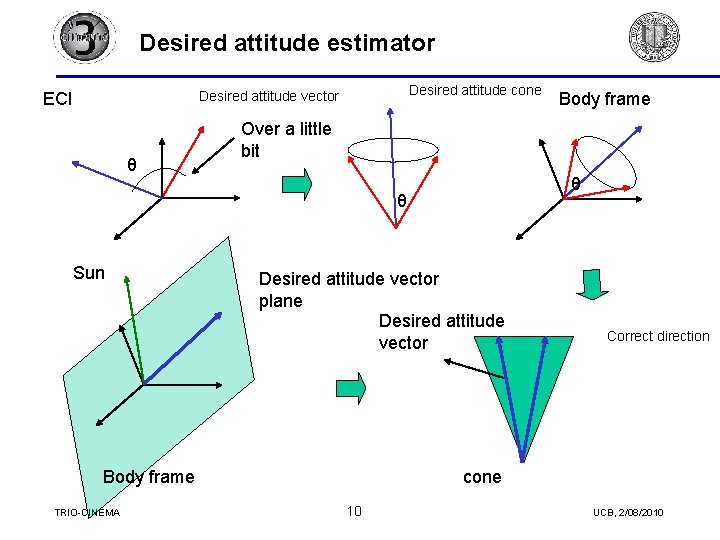
Desired attitude estimator Desired attitude cone Desired attitude vector ECI θ Over a little bit θ θ Sun Desired attitude vector plane Desired attitude vector Body frame TRIO-CINEMA Body frame Correct direction cone 10 UCB, 2/08/2010
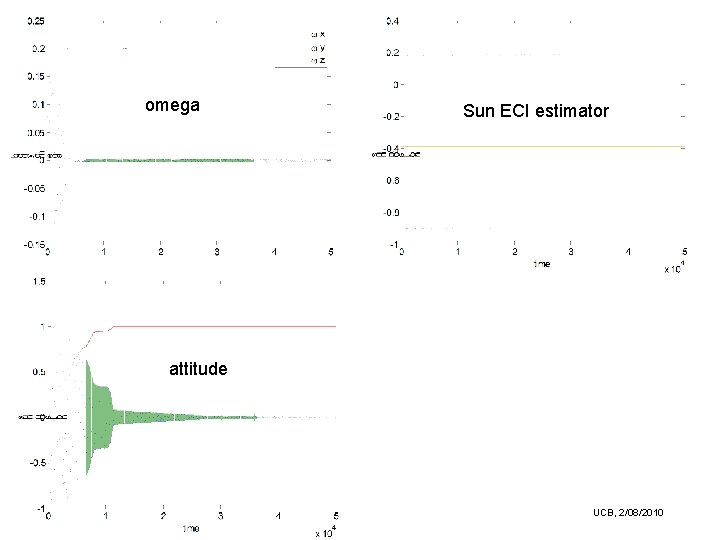
omega Sun ECI estimator attitude TRIO-CINEMA 11 UCB, 2/08/2010
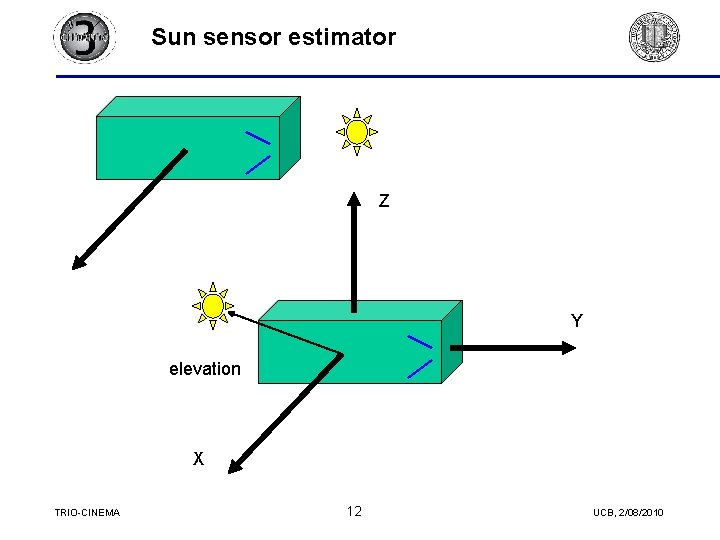
Sun sensor estimator Z Y elevation X TRIO-CINEMA 12 UCB, 2/08/2010
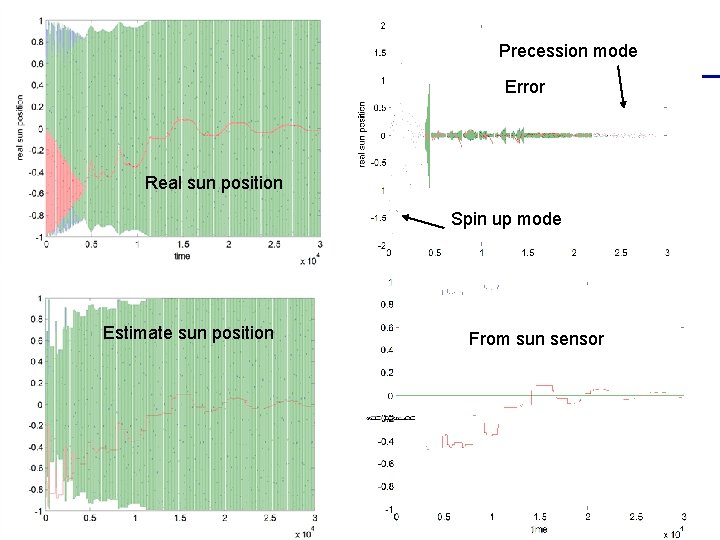
Precession mode Error Real sun position Spin up mode Estimate sun position TRIO-CINEMA From sun sensor 13 UCB, 2/08/2010
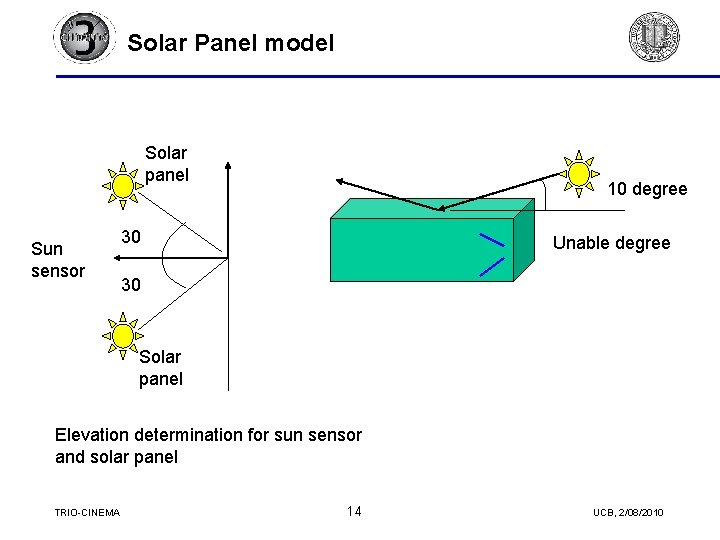
Solar Panel model Solar panel Sun sensor 10 degree 30 Unable degree 30 Solar panel Elevation determination for sun sensor and solar panel TRIO-CINEMA 14 UCB, 2/08/2010
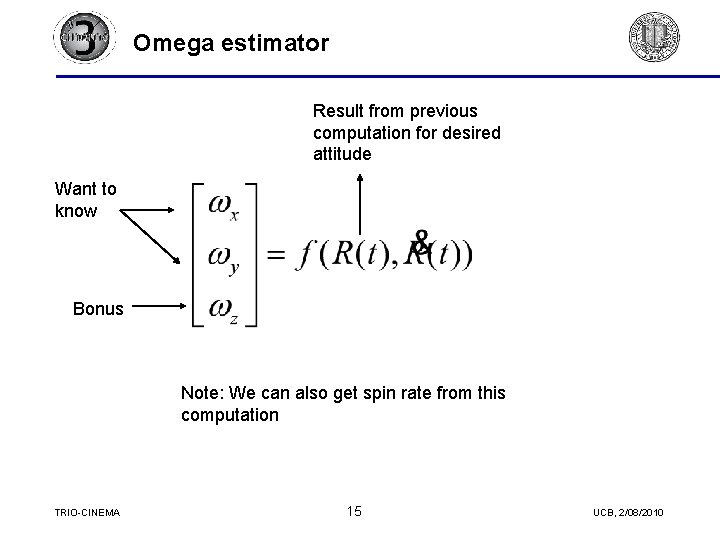
Omega estimator Result from previous computation for desired attitude Want to know Bonus Note: We can also get spin rate from this computation TRIO-CINEMA 15 UCB, 2/08/2010
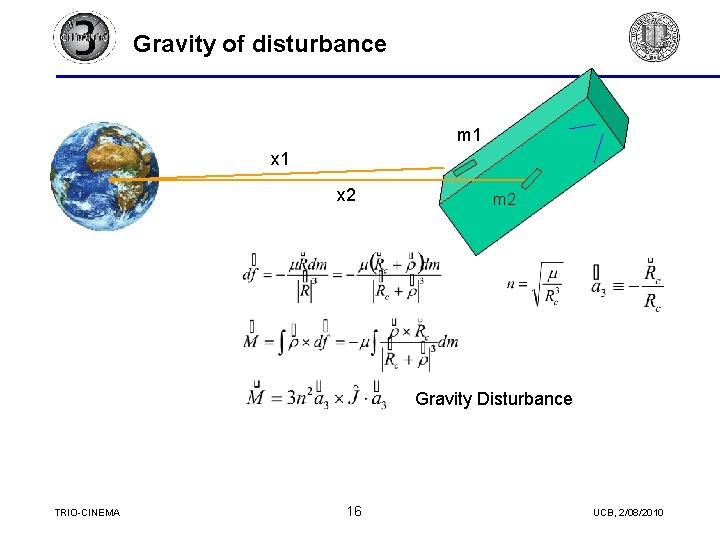
Gravity of disturbance m 1 x 2 m 2 Gravity Disturbance TRIO-CINEMA 16 UCB, 2/08/2010
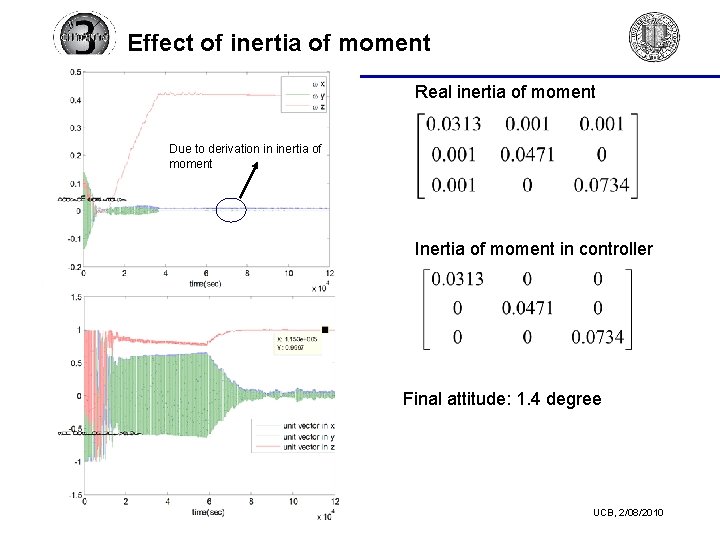
Effect of inertia of moment Real inertia of moment Due to derivation in inertia of moment Inertia of moment in controller Final attitude: 1. 4 degree TRIO-CINEMA 17 UCB, 2/08/2010
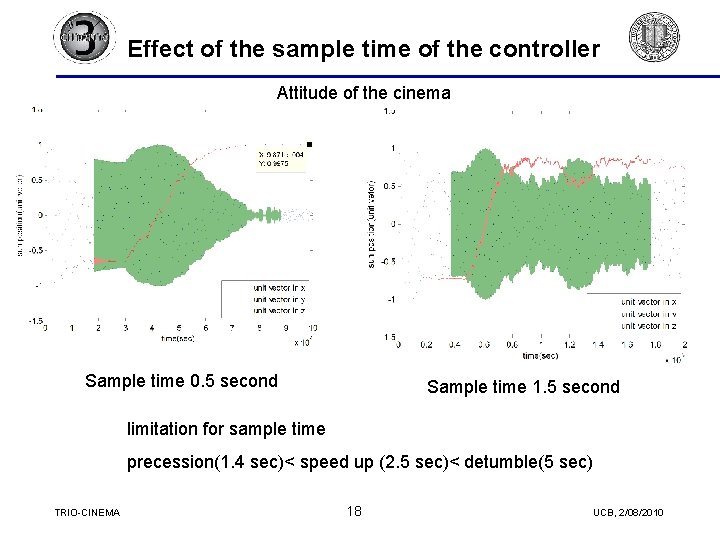
Effect of the sample time of the controller Attitude of the cinema Sample time 0. 5 second Sample time 1. 5 second limitation for sample time precession(1. 4 sec)< speed up (2. 5 sec)< detumble(5 sec) TRIO-CINEMA 18 UCB, 2/08/2010
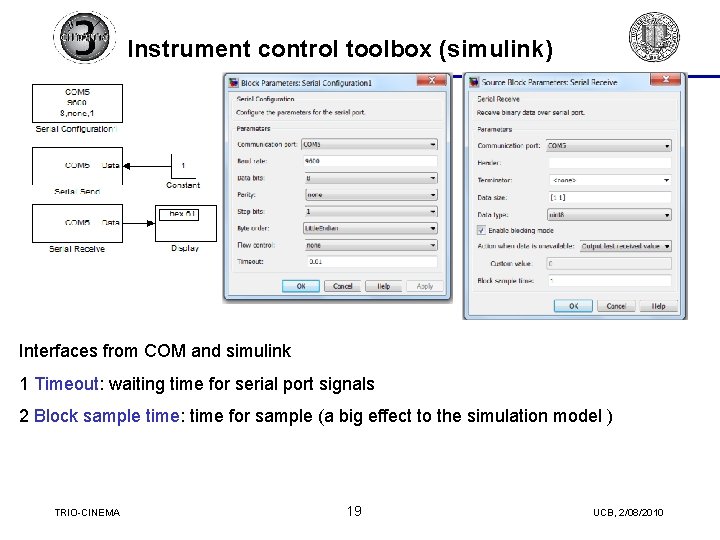
Instrument control toolbox (simulink) Interfaces from COM and simulink 1 Timeout: waiting time for serial port signals 2 Block sample time: time for sample (a big effect to the simulation model ) TRIO-CINEMA 19 UCB, 2/08/2010
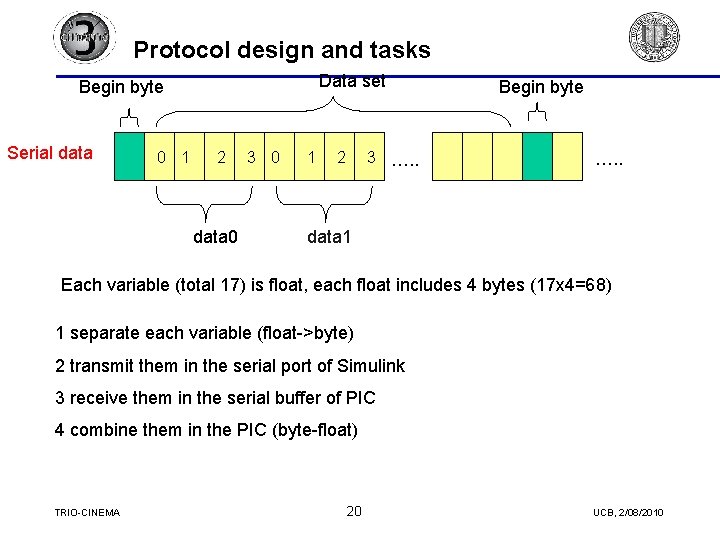
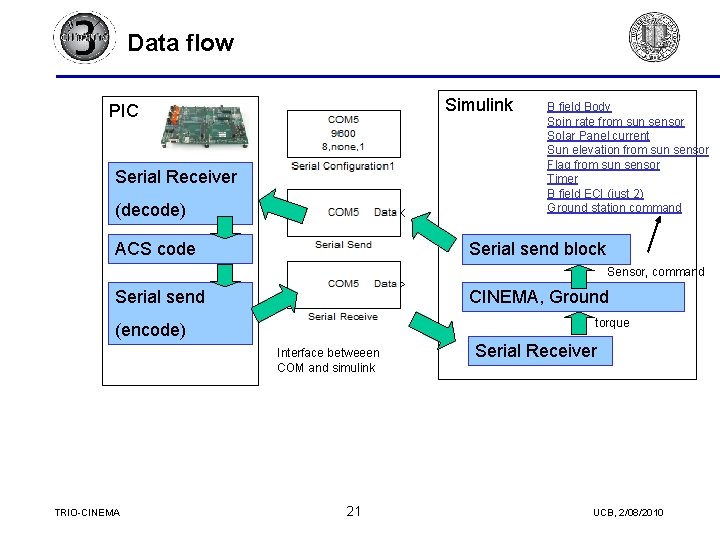
Protocol design and tasks Data set Begin byte Serial data 0 1 2 data 0 3 0 1 2 3 …. . Begin byte …. . data 1 Each variable (total 17) is float, each float includes 4 bytes (17 x 4=68) 1 separate each variable (float->byte) 2 transmit them in the serial port of Simulink 3 receive them in the serial buffer of PIC 4 combine them in the PIC (byte-float) TRIO-CINEMA 20 UCB, 2/08/2010
Data flow Simulink PIC Serial Receiver (decode) ACS code B field Body Spin rate from sun sensor Solar Panel current Sun elevation from sun sensor Flag from sun sensor Timer B field ECI (just 2) Ground station command Serial send block Sensor, command Serial send CINEMA, Ground torque (encode) Interface betweeen COM and simulink TRIO-CINEMA 21 Serial Receiver UCB, 2/08/2010
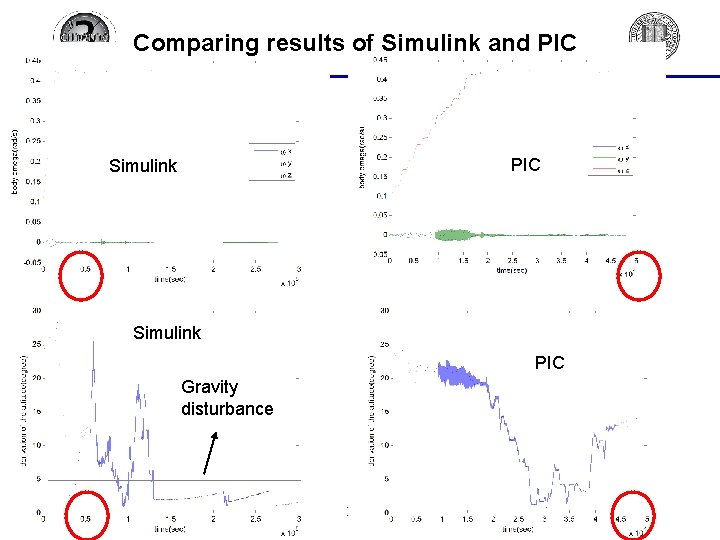
Comparing results of Simulink and PIC Simulink PIC Gravity disturbance TRIO-CINEMA 22 UCB, 2/08/2010
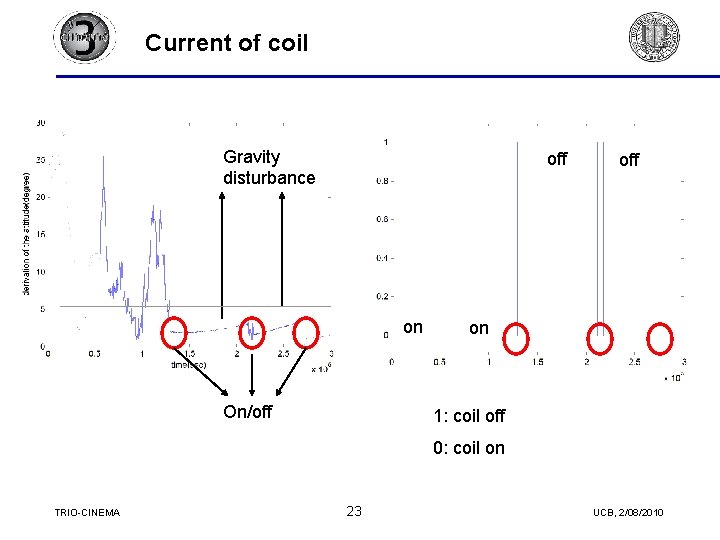
Current of coil off Gravity disturbance off on On/off on 1: coil off 0: coil on TRIO-CINEMA 23 UCB, 2/08/2010
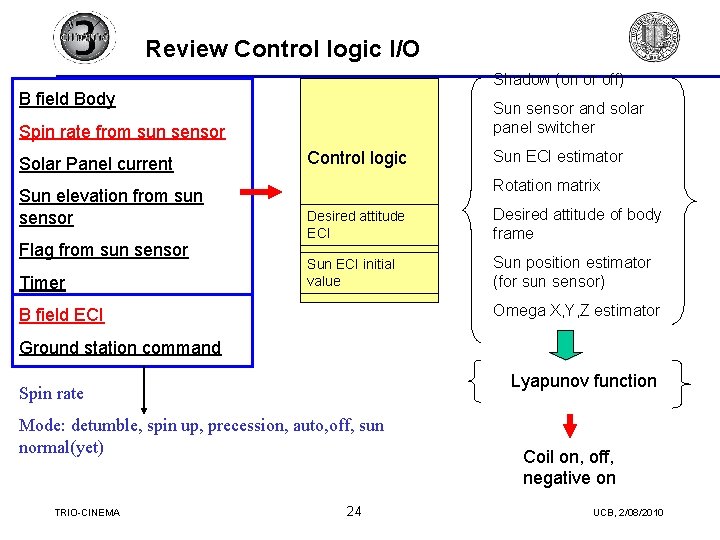
Review Control logic I/O Shadow (on or off) B field Body Sun sensor and solar panel switcher Spin rate from sun sensor Solar Panel current Sun elevation from sun sensor Flag from sun sensor Timer Control logic Sun ECI estimator Rotation matrix Desired attitude ECI Desired attitude of body frame Sun ECI initial value Sun position estimator (for sun sensor) Omega X, Y, Z estimator B field ECI Ground station command Lyapunov function Spin rate Mode: detumble, spin up, precession, auto, off, sun normal(yet) TRIO-CINEMA 24 Coil on, off, negative on UCB, 2/08/2010
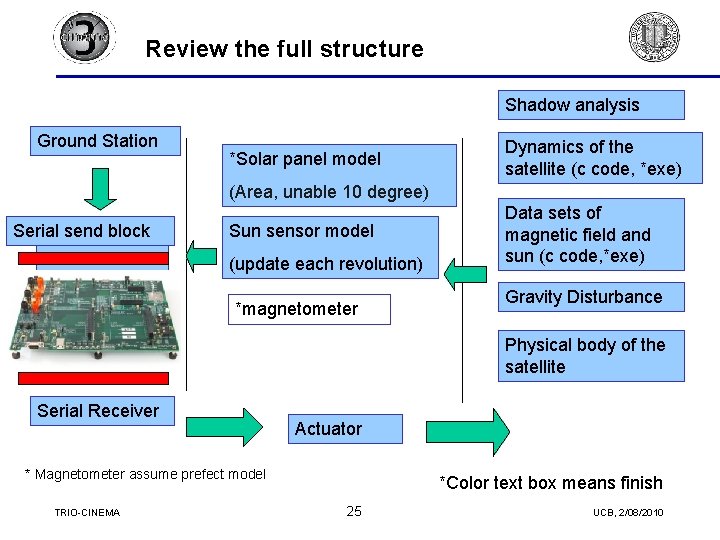
Review the full structure Shadow analysis Ground Station *Solar panel model Dynamics of the satellite (c code, *exe) (Area, unable 10 degree) Serial send block Sun sensor model (update each revolution) Control logic *magnetometer Data sets of magnetic field and sun (c code, *exe) Gravity Disturbance Physical body of the satellite Serial Receiver Actuator * Magnetometer assume prefect model TRIO-CINEMA *Color text box means finish 25 UCB, 2/08/2010
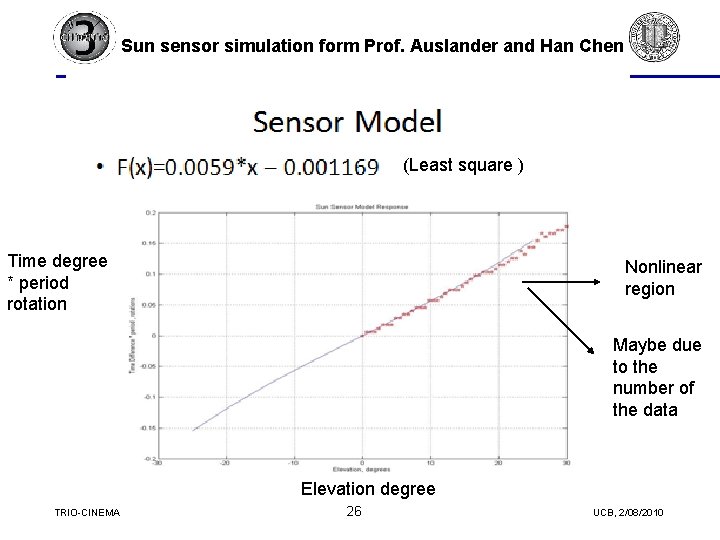
Sun sensor simulation form Prof. Auslander and Han Chen (Least square ) Time degree * period rotation Nonlinear region Maybe due to the number of the data Elevation degree TRIO-CINEMA 26 UCB, 2/08/2010
Q&A TRIO-CINEMA 27 UCB, 2/08/2010