Multilayer Sparse LSMDeep Neural Network LS M Zhaolun
- Slides: 20
Multilayer Sparse LSM=Deep Neural Network LS M Zhaolun Liu and Gerard Schuster KAUST N N C p Dee Neural Network LSM
Outline Ø Neural Networks & Sparse LSM Ø Neural Networks Least Squares Migration Ø Numerical Results Ø Summary 2
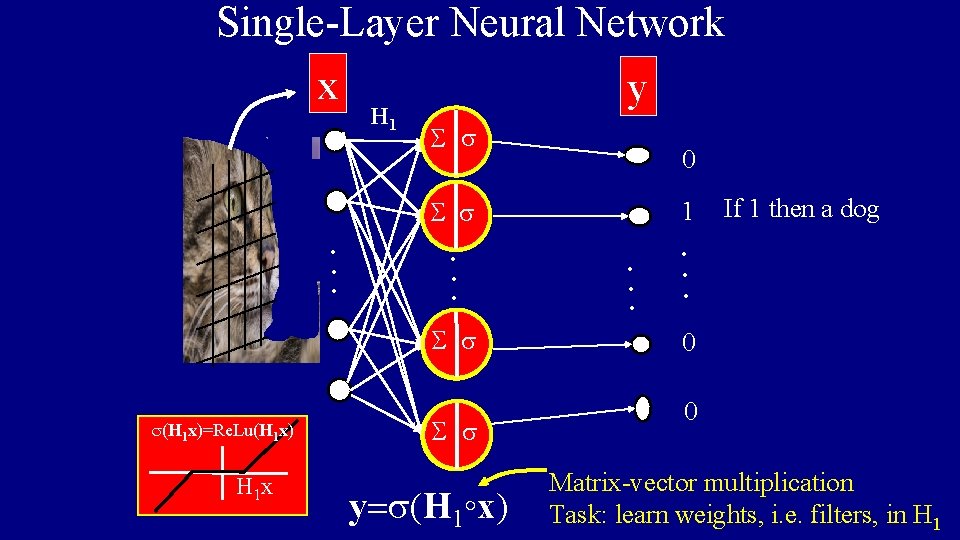
Single-Layer Neural Network x y H 1 . . . S s s(H 1 x)=Re. Lu(H 1 x) H 1 x S s y=s(H 1◦x) 10 If 1 then a cat 01 . . . If 1 then a dog 0 0 Matrix-vector multiplication Task: learn weights, i. e. filters, in H 1
Feed. Forward Neural. Network Feed. Forward Neural Layer 1 Layer 2. . Layer N-1 Layer N x H 1 S s . . . LS M S s H 2 S s . . S s S s . . . N N C p Dee s(H 2 s(H 1 x)) s(H 1 x) S s . . HN y S s 1 S s . . . 0 . . . S s y=s(HNs(…s(H 1 x))…) 0 0
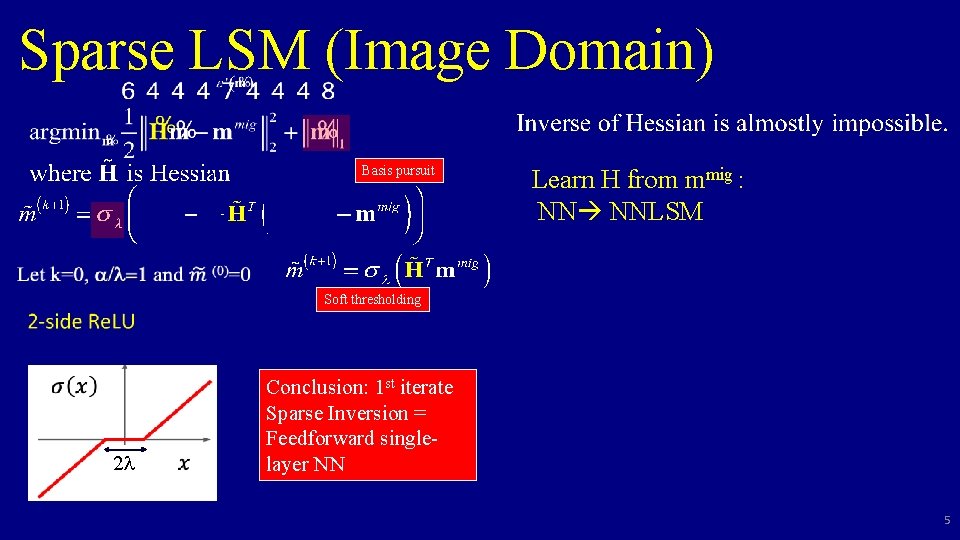
Sparse LSM (Image Domain) Basis pursuit Learn H from mmig : NN NNLSM Soft thresholding 2 l Conclusion: 1 st iterate Sparse Inversion = Feedforward singlelayer NN 5
Outline Ø Neural Networks & Sparse LSM Ø Neural Networks Least Squares Migration Ø Numerical Results Ø Summary 6
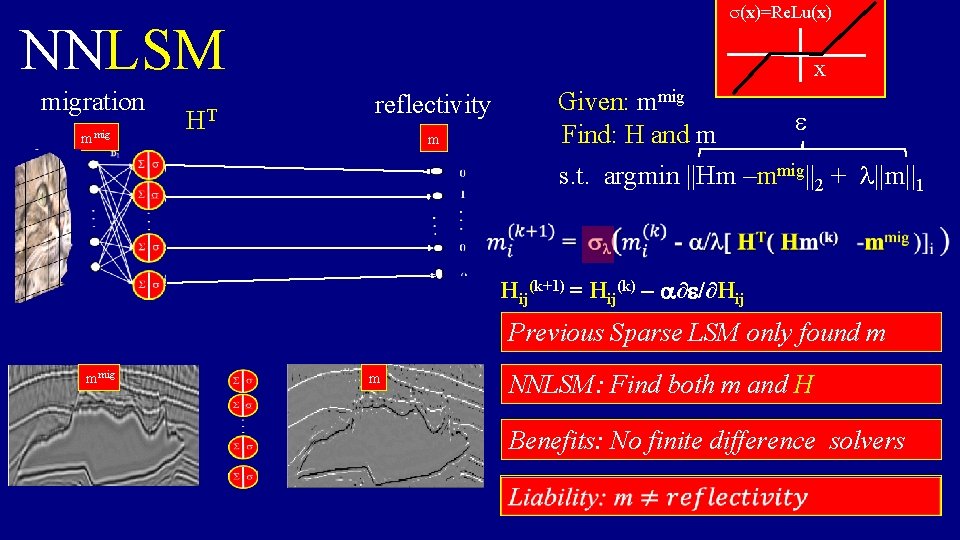
s(x)=Re. Lu(x) NNLSM migration mmig HT x Given: mmig Find: H and m reflectivity m e s. t. argmin ||Hm –mmig||2 + l||m||1 Hij(k+1) = Hij(k) – a∂e/∂Hij Previous Sparse LSM only found m mmig m NNLSM: Find both m and H Benefits: No finite difference solvers
Outline Ø Neural Networks & Sparse LSM Ø Neural Networks Least Squares Migration Ø Numerical Results Ø Summary 8
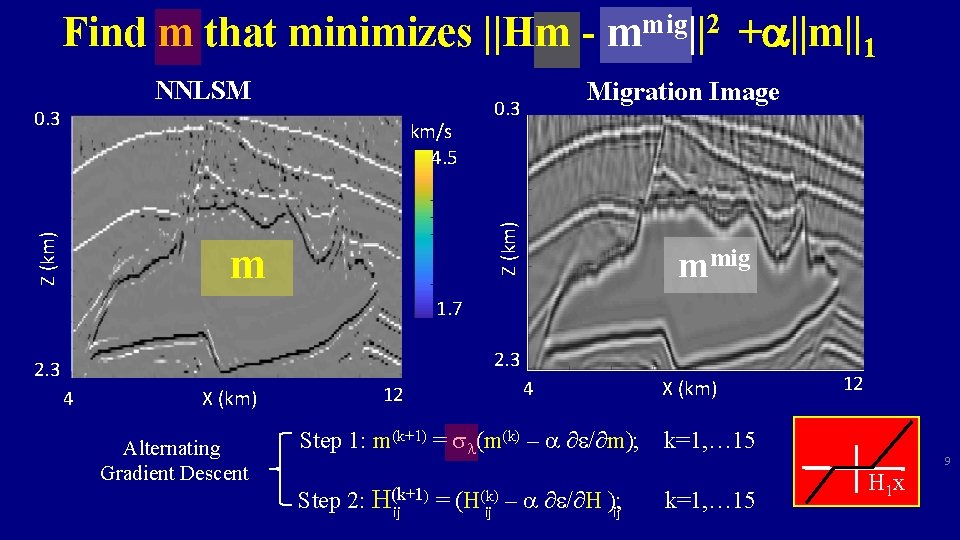
Find m that minimizes ||Hm - mmig||2 +a||m||1 Velocity Model NNLSM 0. 3 Z (km) km/s 4. 5 Z (km) Migration Image 0. 3 m mmig 1. 7 2. 3 4 X (km) Alternating Gradient Descent 4 12 Step 1: m(k+1) = sl(m(k) – a ∂e/∂m); Step 2: H(k+1) ij = (H(k) ij – a ∂e/∂H ); ij X (km) 12 k=1, … 15 9 k=1, … 15 H 1 x
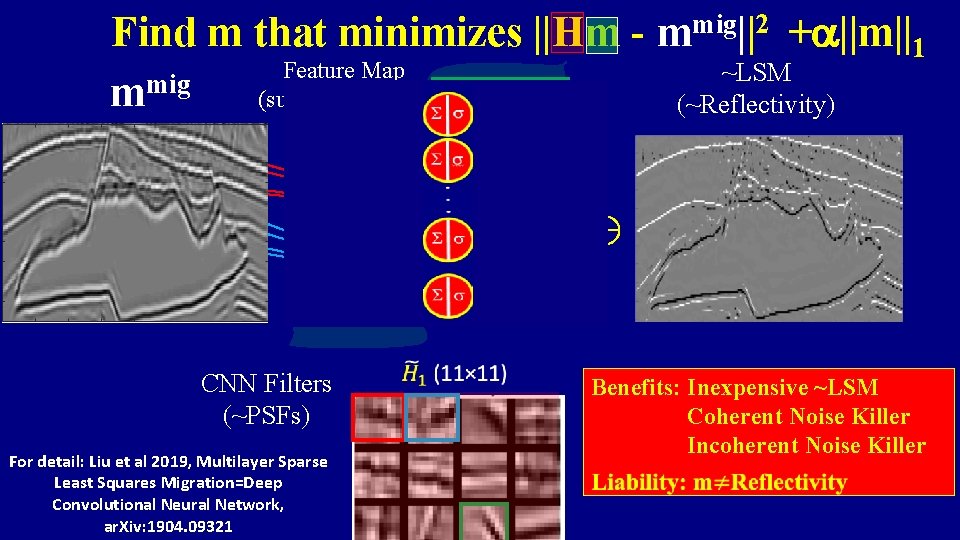
Find m that minimizes ||Hm - mmig||2 +a||m||1 Feature Map ~LSM mig m (sub-Reflectivity) (~Reflectivity) CNN Filters (~PSFs) For detail: Liu et al 2019, Multilayer Sparse Least Squares Migration=Deep Convolutional Neural Network, ar. Xiv: 1904. 09321 Benefits: Inexpensive ~LSM Coherent Noise Killer Incoherent Noise Killer
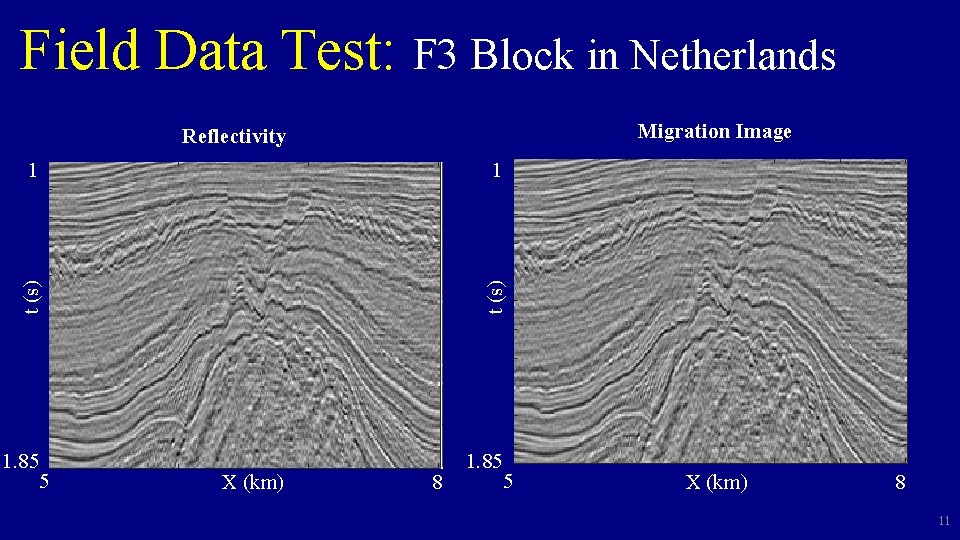
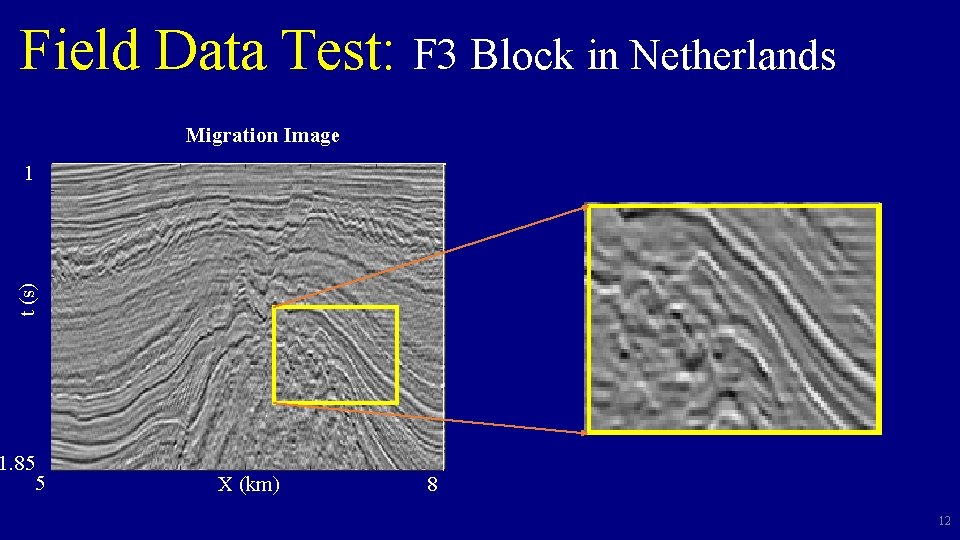
Field Data Test: F 3 Block in Netherlands Migration Image Reflectivity 1 t (s) 1 1. 85 5 X (km) 8 11
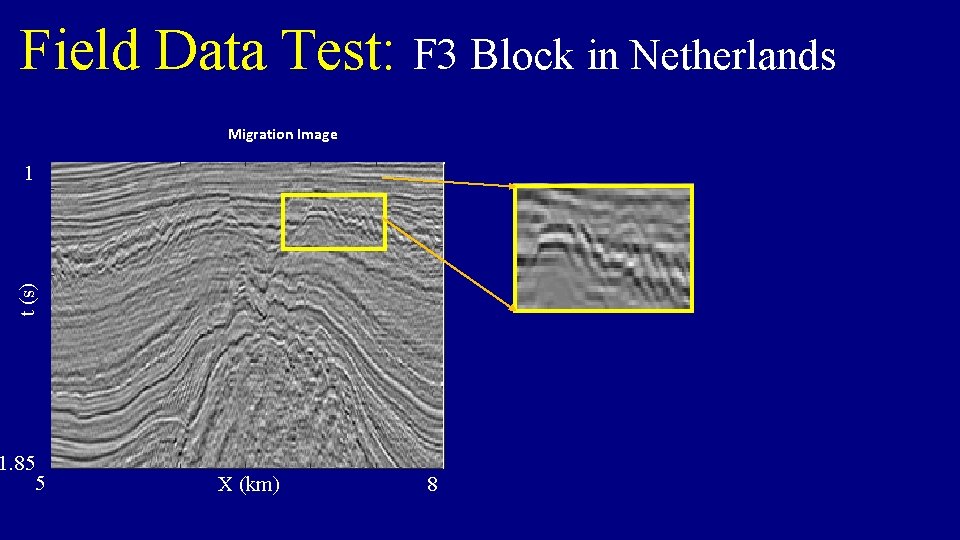
Field Data Test: F 3 Block in Netherlands Migration Image Reconstructed Migration t (s) 1 1. 85 5 X (km) 8 12
Field Data Test: F 3 Block in Netherlands Migration Image Reconstructed Migration Image t (s) 1 1. 85 5 X (km) 8
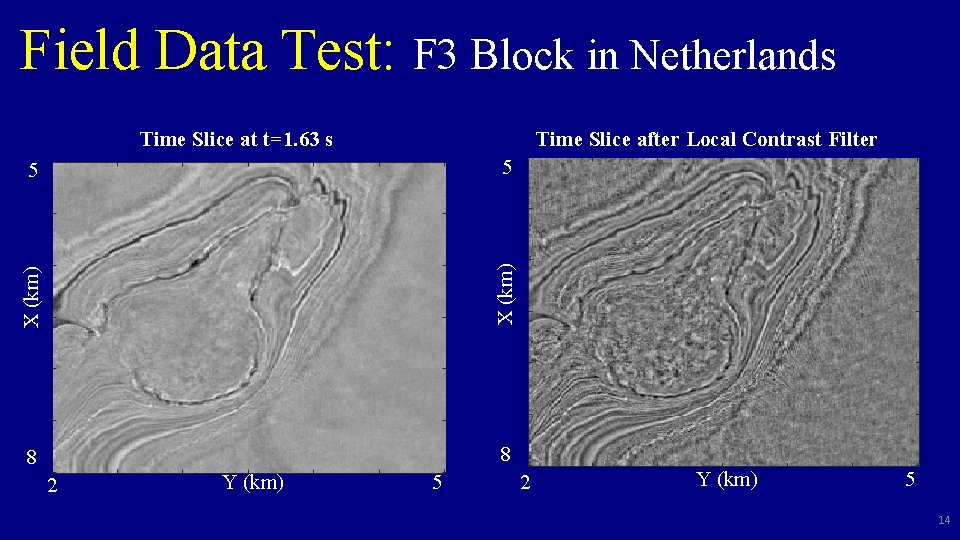
Field Data Test: F 3 Block in Netherlands Time Slice at t=1. 63 s 5 5 X (km) Time Slice after Local Contrast Filter 8 8 2 Y (km) 5 14
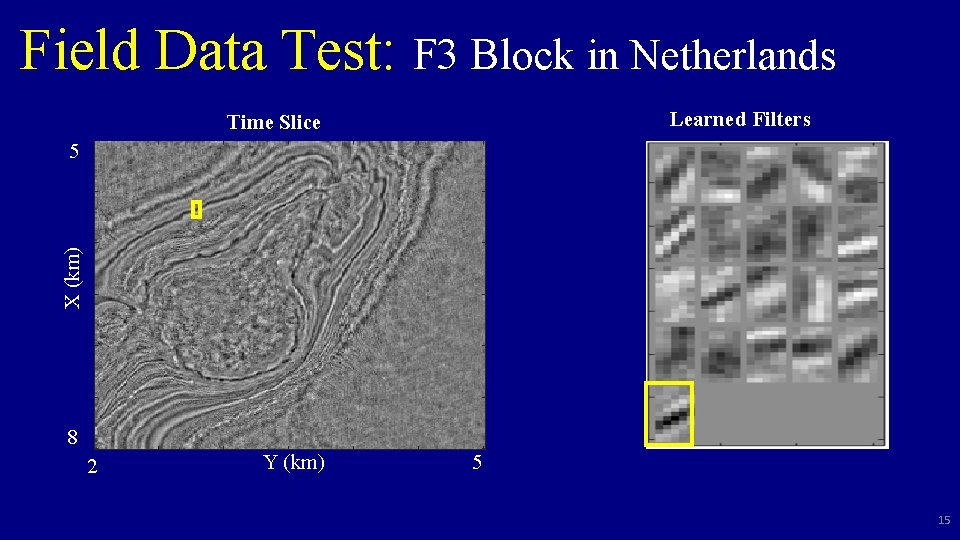
Field Data Test: F 3 Block in Netherlands Learned Filters Time Slice X (km) 5 8 2 Y (km) 5 15
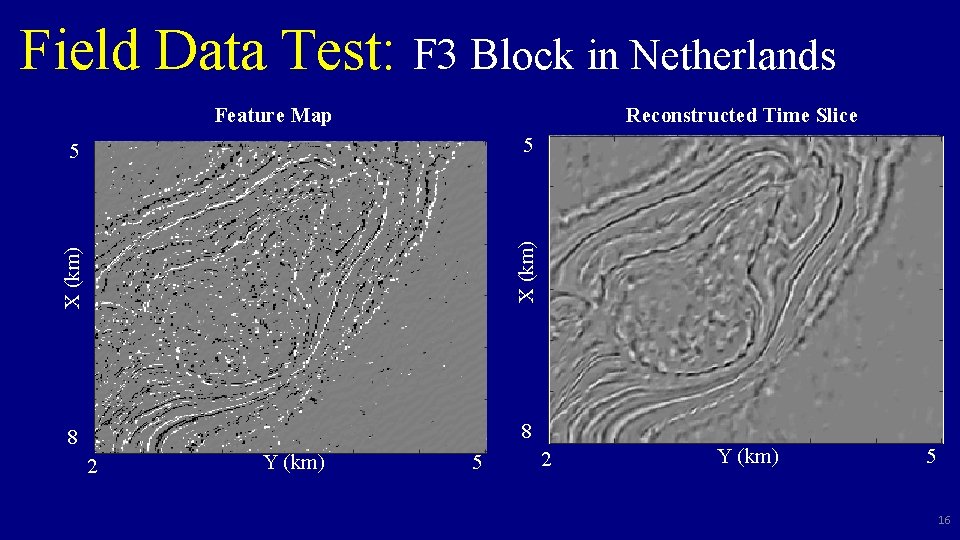
Field Data Test: F 3 Block in Netherlands Reconstructed Time Slice 5 5 X (km) Feature Time. Map Slice 8 8 2 Y (km) 5 16
Outline Ø Neural Networks & Sparse LSM Ø Neural Networks Least Squares Migration Ø Numerical Results Ø Summary 17
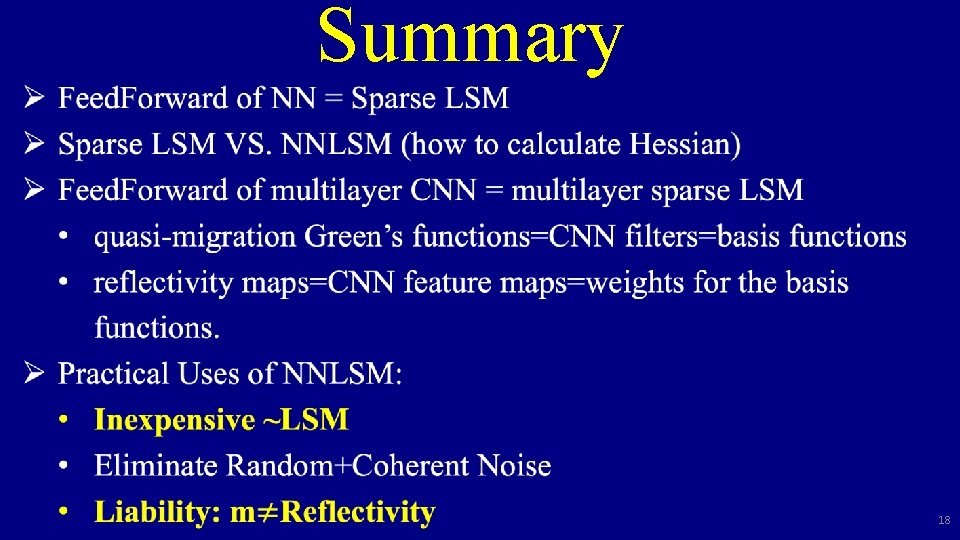
Summary 18
LS M N N C p Dee Neural Network LSM
Acknowledgements • The research reported in this publication was supported by the King Abdullah University of Science and Technology (KAUST) in Thuwal, Saudi Arabia. We are grateful to the sponsors of the Center for Subsurface Imaging and Modeling Consortium for their financial support. For computer time, this research used the resources of the Supercomputing Laboratory at KAUST and the IT Research Computing Group. We thank them for providing the computational resources required for carrying out this work.