Lecture 02 Modeling i Transfer function 2 1
- Slides: 22
Lecture 02 Modeling (i) –Transfer function 2. 1 Circuit Systems 2. 2 Mechanical Systems 2. 3 Transfer Function Modern Control Systems 1
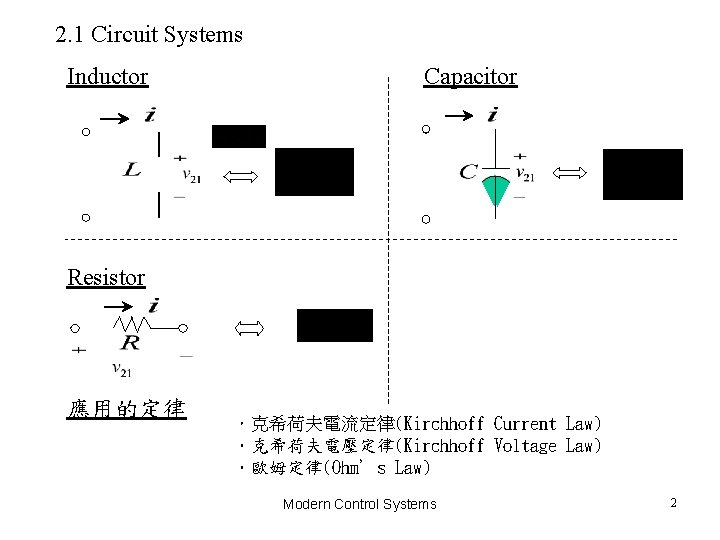
2. 1 Circuit Systems Inductor Capacitor Resistor 應用的定律 .克希荷夫電流定律(Kirchhoff Current Law) .克希荷夫電壓定律(Kirchhoff Voltage Law) .歐姆定律(Ohm’s Law) Modern Control Systems 2
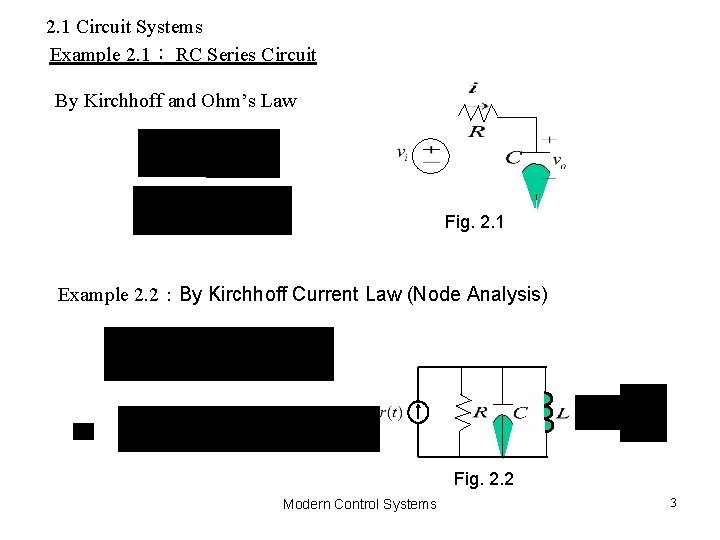
2. 1 Circuit Systems Example 2. 1: RC Series Circuit By Kirchhoff and Ohm’s Law Fig. 2. 1 Example 2. 2:By Kirchhoff Current Law (Node Analysis) Fig. 2. 2 Modern Control Systems 3
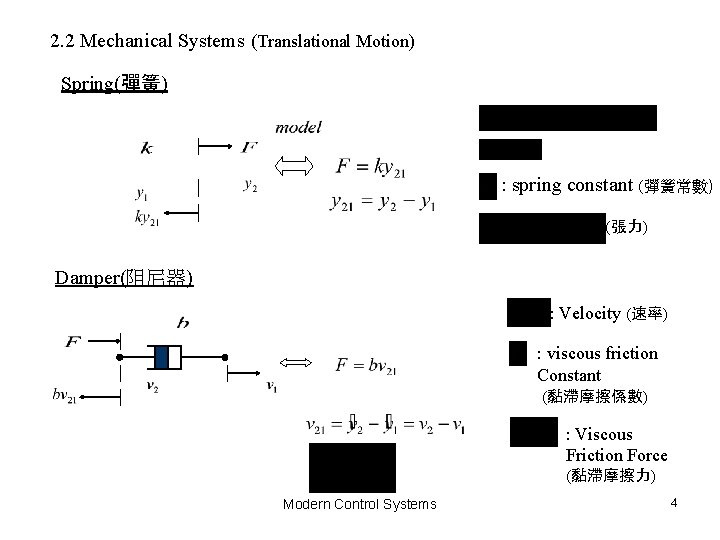
2. 2 Mechanical Systems (Translational Motion) Spring(彈簧) : spring constant (彈簧常數) (張力) Damper(阻尼器) : Velocity (速率) : viscous friction Constant (黏滯摩擦係數) : Viscous Friction Force (黏滯摩擦力) Modern Control Systems 4
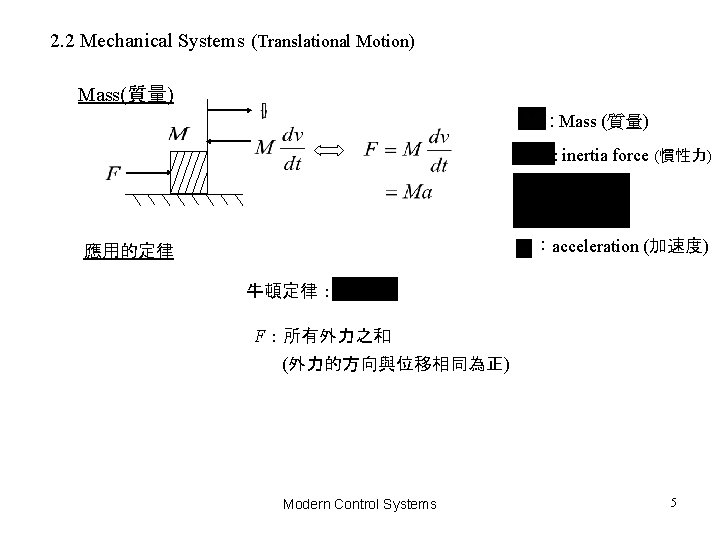
2. 2 Mechanical Systems (Translational Motion) Mass(質量) : Mass (質量) : inertia force (慣性力) :acceleration (加速度) 應用的定律 牛頓定律: F:所有外力之和 (外力的方向與位移相同為正) Modern Control Systems 5
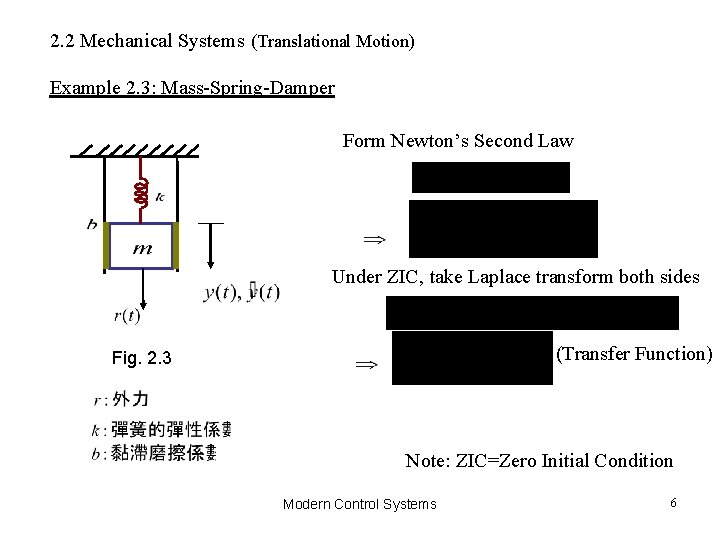
2. 2 Mechanical Systems (Translational Motion) Example 2. 3: Mass-Spring-Damper Form Newton’s Second Law Under ZIC, take Laplace transform both sides (Transfer Function) Fig. 2. 3 Note: ZIC=Zero Initial Condition Modern Control Systems 6
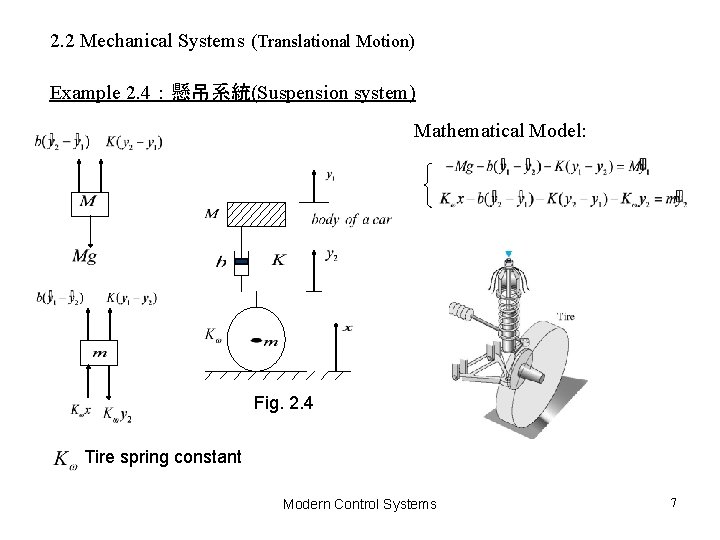
2. 2 Mechanical Systems (Translational Motion) Example 2. 4:懸吊系統(Suspension system) Mathematical Model: Fig. 2. 4 Tire spring constant Modern Control Systems 7
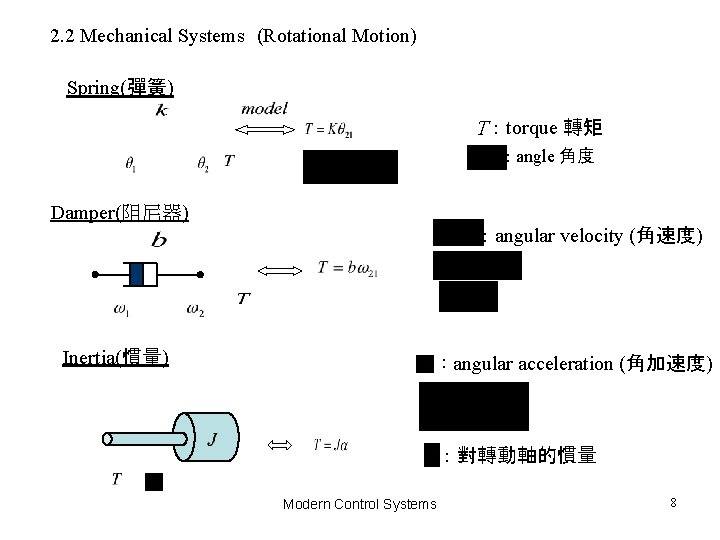
2. 2 Mechanical Systems (Rotational Motion) Spring(彈簧) T:torque 轉矩 : angle 角度 Damper(阻尼器) :angular velocity (角速度) Inertia(慣量) :angular acceleration (角加速度) :對轉動軸的慣量 Modern Control Systems 8
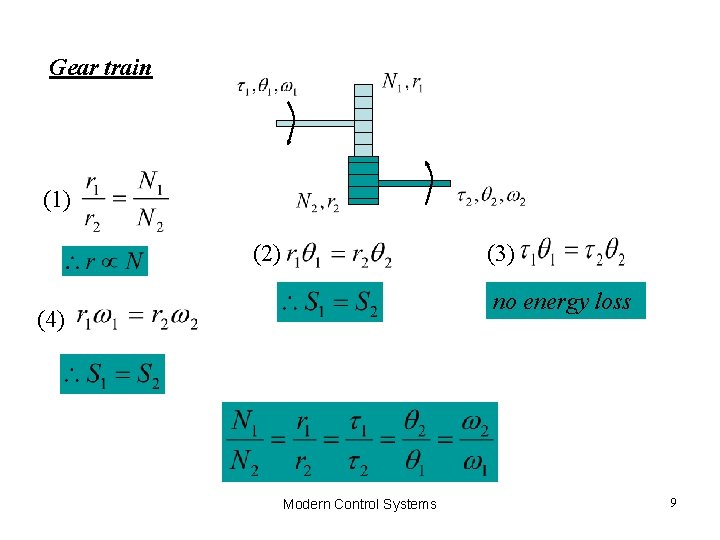
Gear train (1) (2) (3) no energy loss (4) Modern Control Systems 9
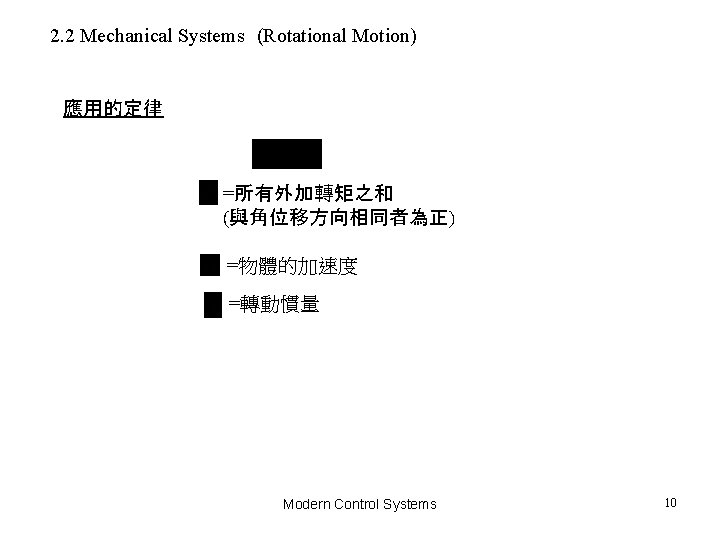
2. 2 Mechanical Systems (Rotational Motion) 應用的定律 =所有外加轉矩之和 (與角位移方向相同者為正) =物體的加速度 =轉動慣量 Modern Control Systems 10
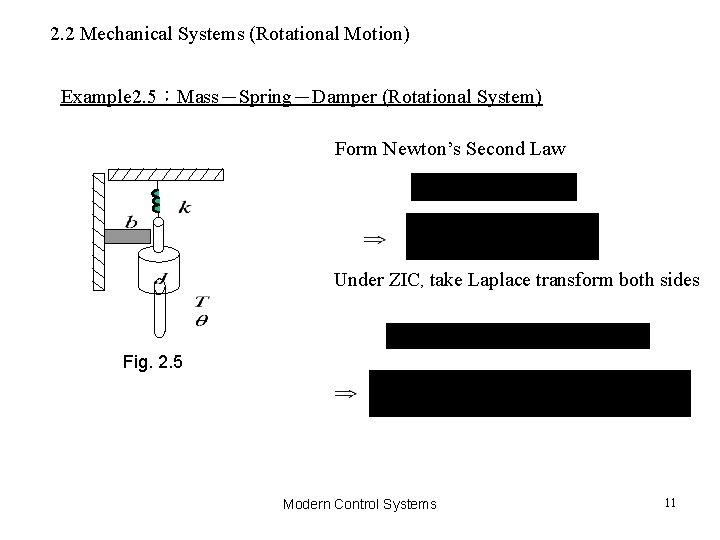
2. 2 Mechanical Systems (Rotational Motion) Example 2. 5:Mass-Spring-Damper (Rotational System) Form Newton’s Second Law Under ZIC, take Laplace transform both sides Fig. 2. 5 Modern Control Systems 11
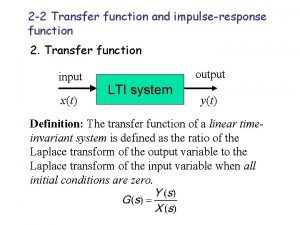
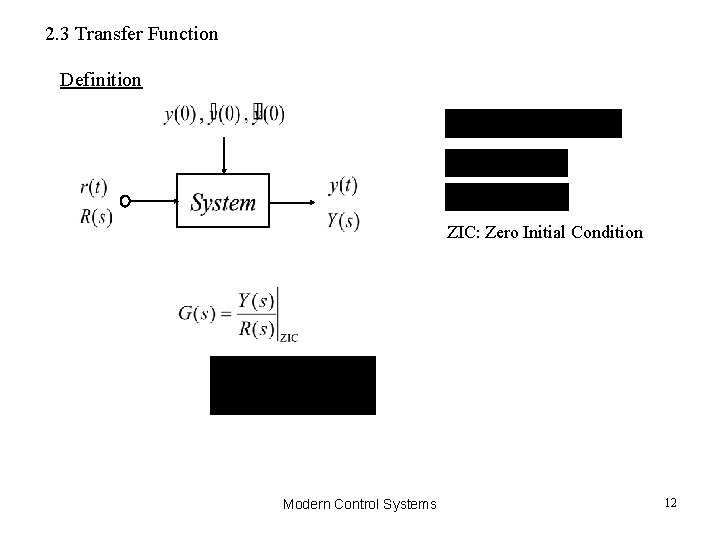
2. 3 Transfer Function Definition ZIC: Zero Initial Condition Modern Control Systems 12
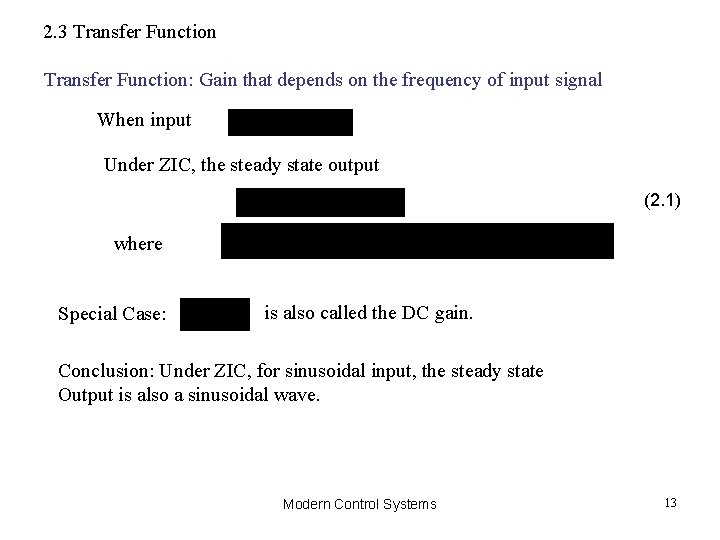
2. 3 Transfer Function: Gain that depends on the frequency of input signal When input Under ZIC, the steady state output (2. 1) where Special Case: is also called the DC gain. Conclusion: Under ZIC, for sinusoidal input, the steady state Output is also a sinusoidal wave. Modern Control Systems 13
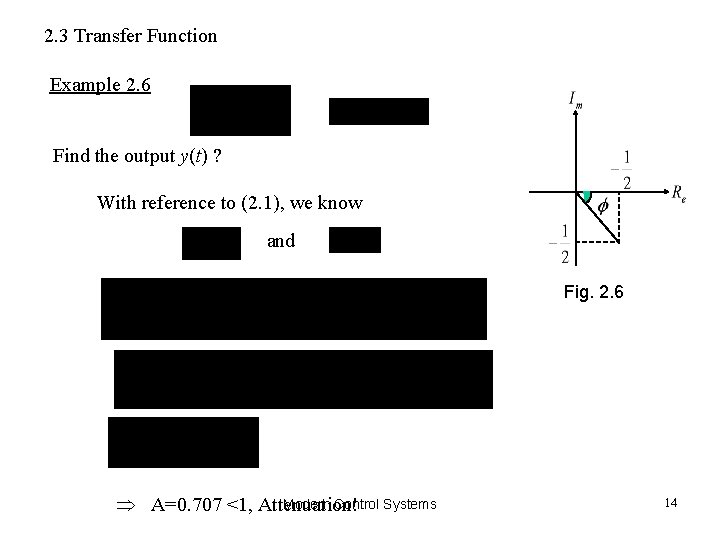
2. 3 Transfer Function Example 2. 6 Find the output y(t) ? With reference to (2. 1), we know and Fig. 2. 6 Modern Control Systems A=0. 707 <1, Attenuation! 14
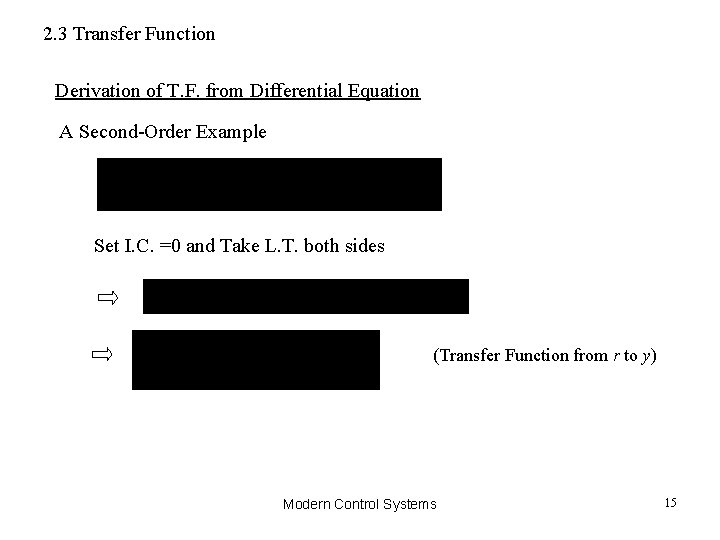
2. 3 Transfer Function Derivation of T. F. from Differential Equation A Second-Order Example Set I. C. =0 and Take L. T. both sides (Transfer Function from r to y) Modern Control Systems 15
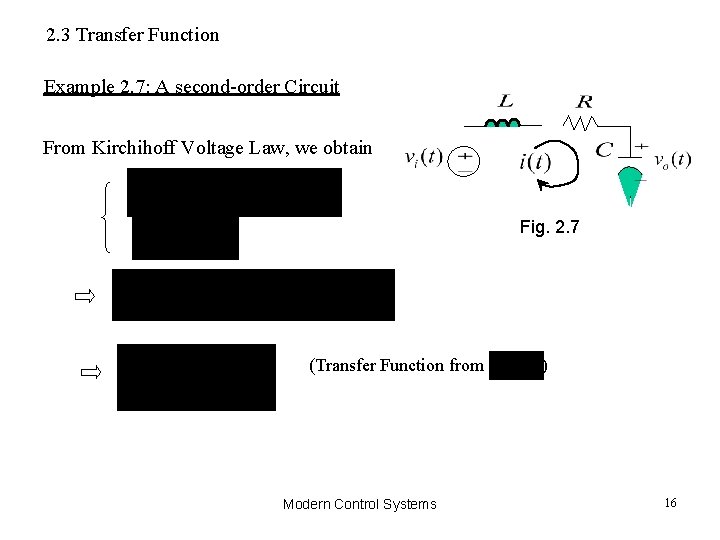
2. 3 Transfer Function Example 2. 7: A second-order Circuit From Kirchihoff Voltage Law, we obtain Fig. 2. 7 (Transfer Function from Modern Control Systems ) 16
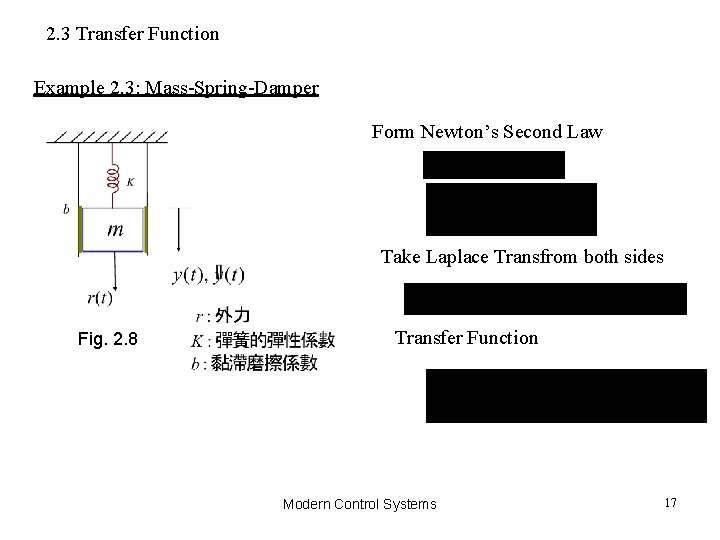
2. 3 Transfer Function Example 2. 3: Mass-Spring-Damper Form Newton’s Second Law Take Laplace Transfrom both sides Fig. 2. 8 Transfer Function Modern Control Systems 17
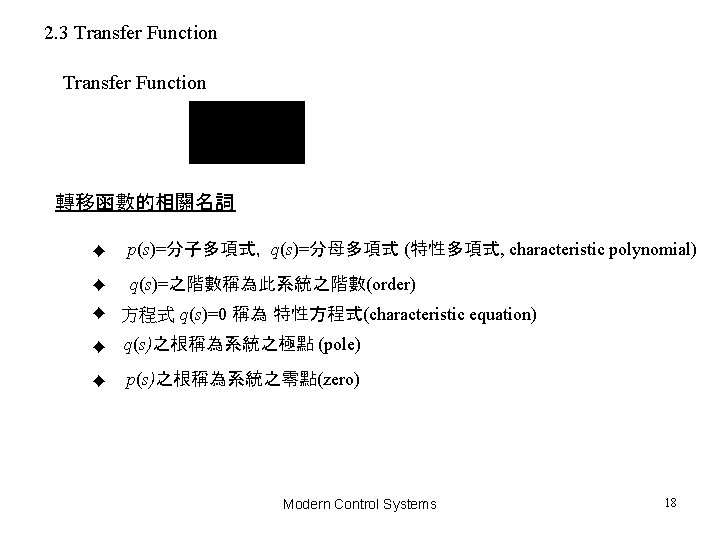
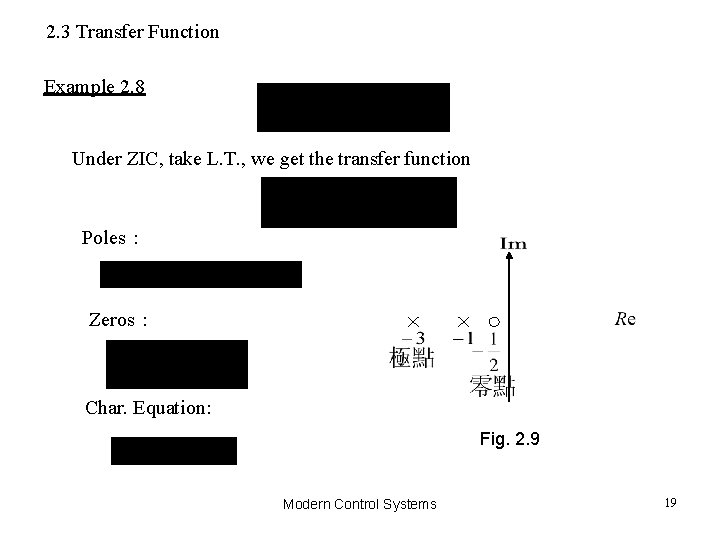
2. 3 Transfer Function Example 2. 8 Under ZIC, take L. T. , we get the transfer function Poles: Zeros: Char. Equation: Fig. 2. 9 Modern Control Systems 19
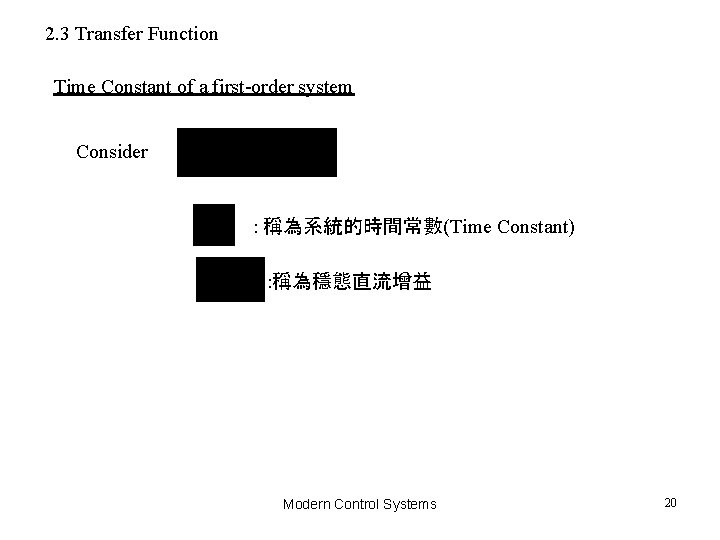
2. 3 Transfer Function Time Constant of a first-order system Consider : 稱為系統的時間常數(Time Constant) : 稱為穩態直流增益 Modern Control Systems 20
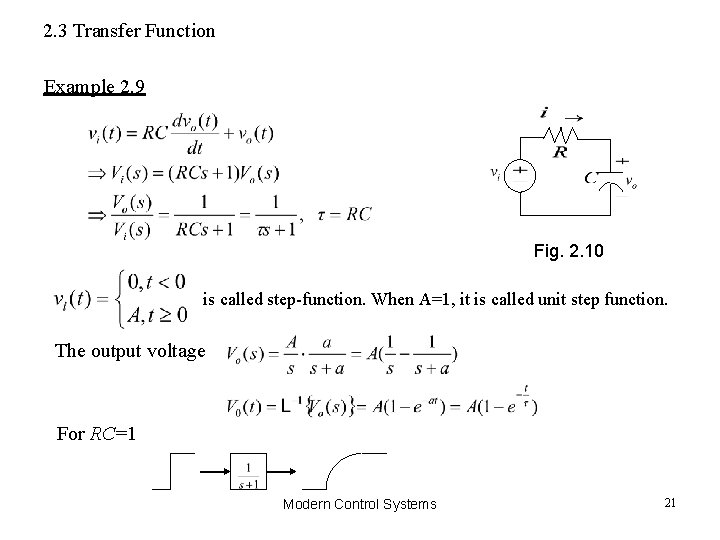
2. 3 Transfer Function Example 2. 9 Fig. 2. 10 is called step-function. When A=1, it is called unit step function. The output voltage For RC=1 Modern Control Systems 21
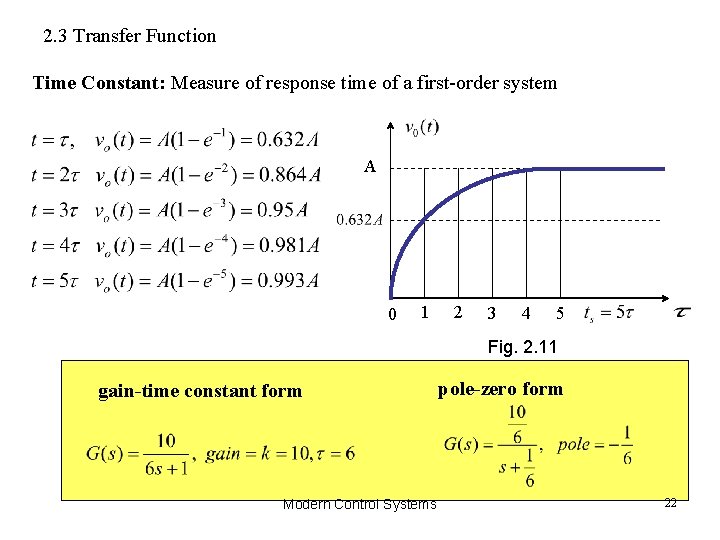
2. 3 Transfer Function Time Constant: Measure of response time of a first-order system A 0 1 2 3 4 5 Fig. 2. 11 gain-time constant form Modern Control Systems pole-zero form 22