
Time Response ME 451 Instructor Jongeun Choi This

- Slides: 84
Time Response*, ME 451 Instructor: Jongeun Choi * This presentation is created by Jongeun Choi and Gabrial Gomes
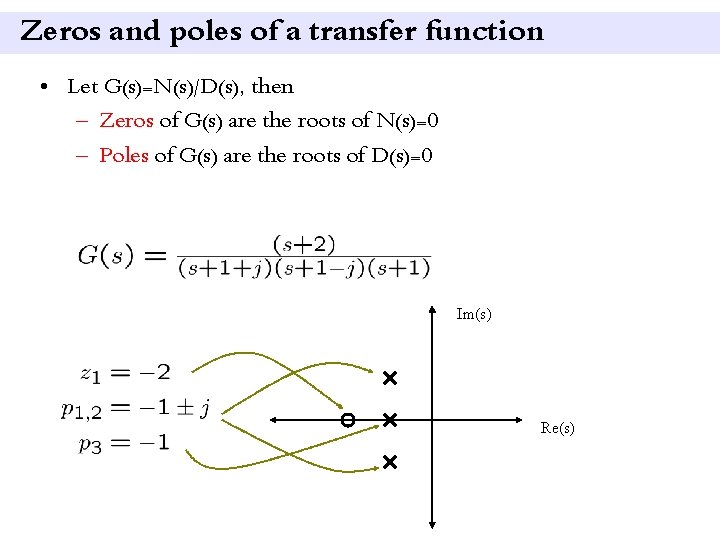
Zeros and poles of a transfer function • Let G(s)=N(s)/D(s), then – Zeros of G(s) are the roots of N(s)=0 – Poles of G(s) are the roots of D(s)=0 Im(s) Re(s)
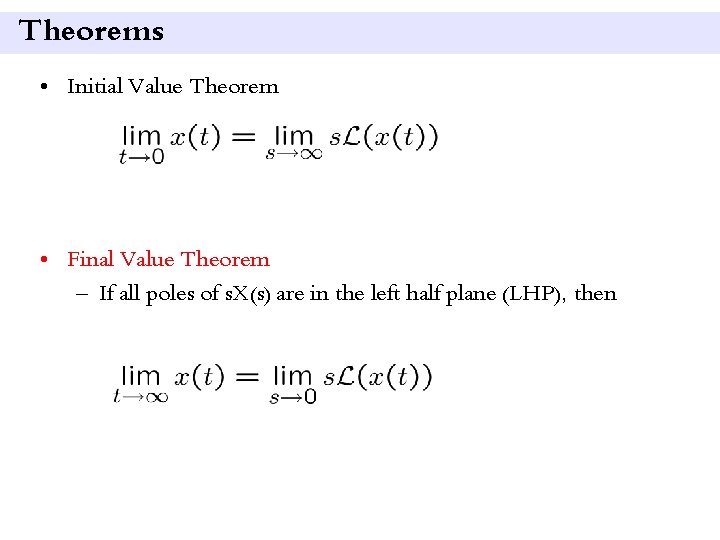
Theorems • Initial Value Theorem • Final Value Theorem – If all poles of s. X(s) are in the left half plane (LHP), then
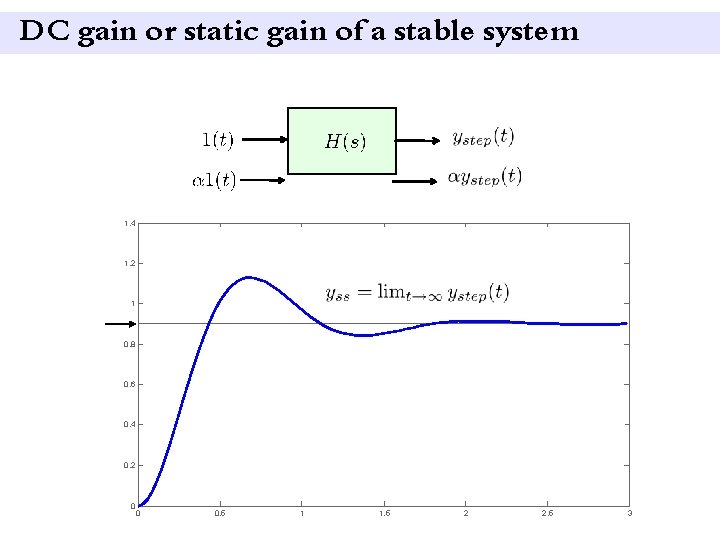
DC gain or static gain of a stable system 1. 4 1. 2 1 0. 8 0. 6 0. 4 0. 2 0 0 0. 5 1 1. 5 2 2. 5 3
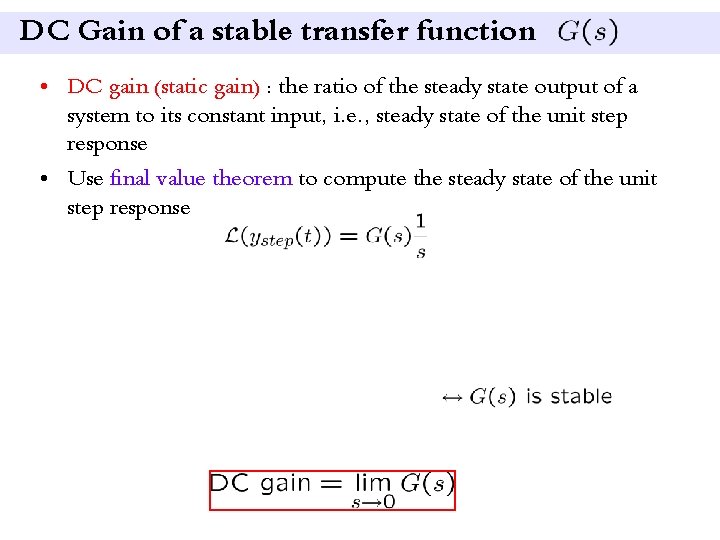
DC Gain of a stable transfer function • DC gain (static gain) : the ratio of the steady state output of a system to its constant input, i. e. , steady state of the unit step response • Use final value theorem to compute the steady state of the unit step response
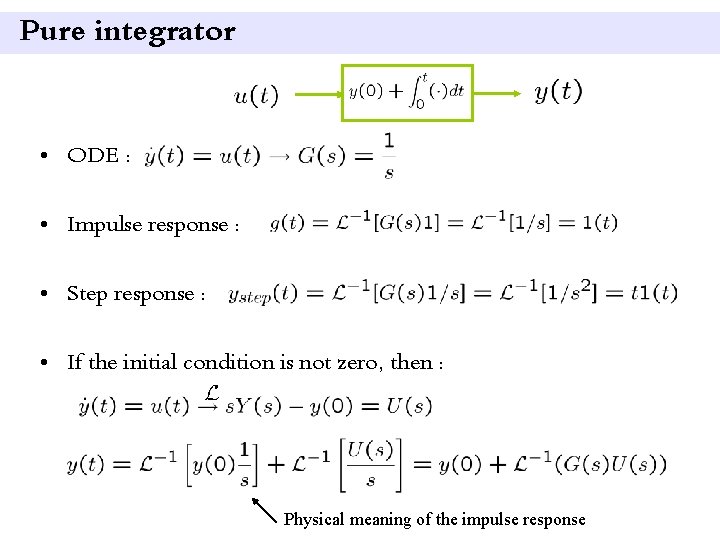
Pure integrator • ODE : • Impulse response : • Step response : • If the initial condition is not zero, then : Physical meaning of the impulse response
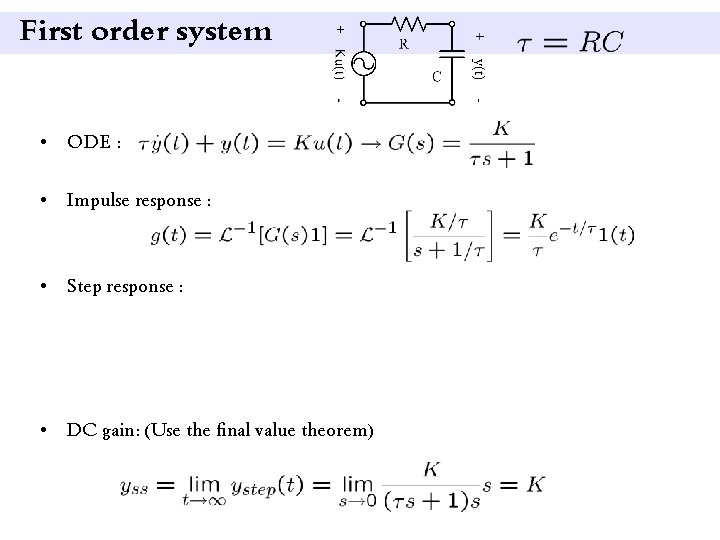
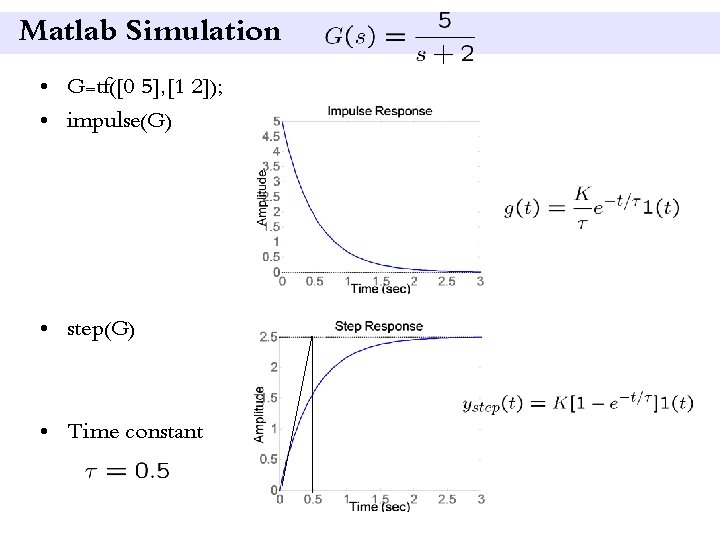
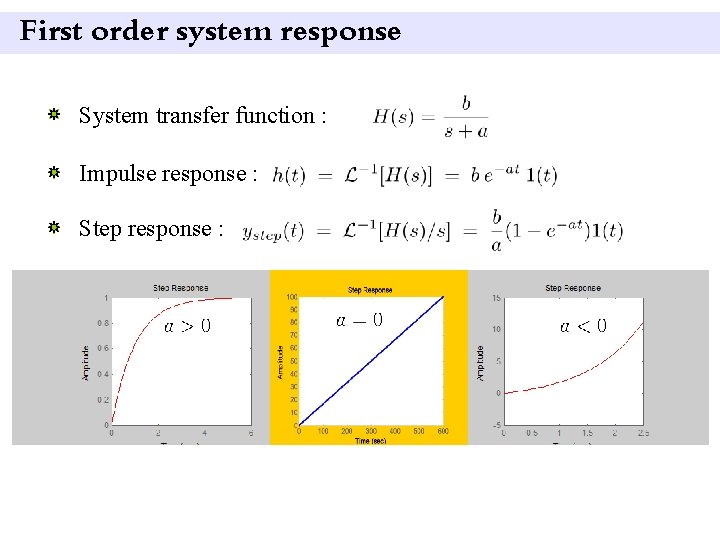
First order system • ODE : • Impulse response : • Step response : • DC gain: (Use the final value theorem)
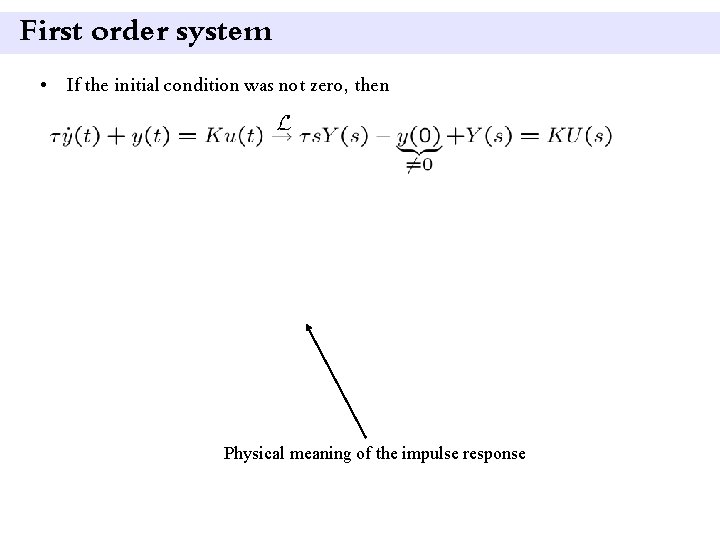
First order system • If the initial condition was not zero, then Physical meaning of the impulse response
Matlab Simulation • G=tf([0 5], [1 2]); • impulse(G) • step(G) • Time constant
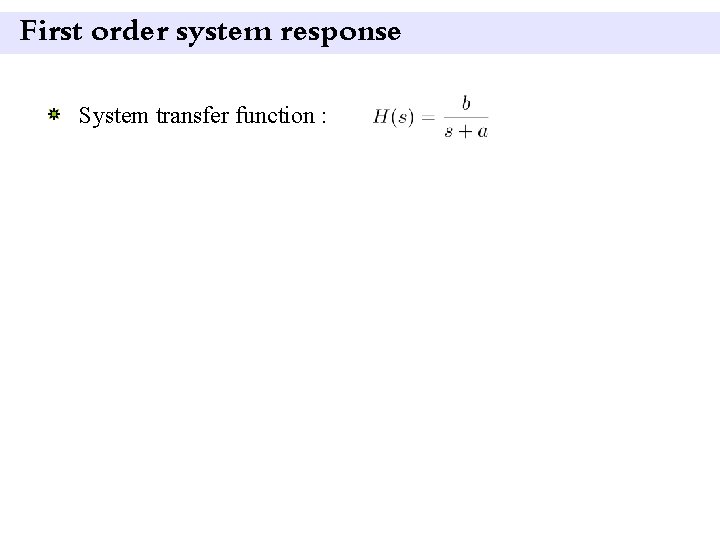
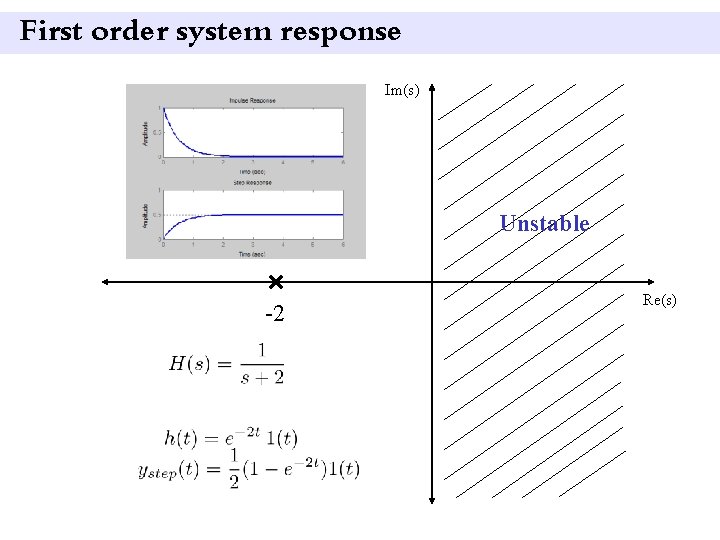
First order system response System transfer function :
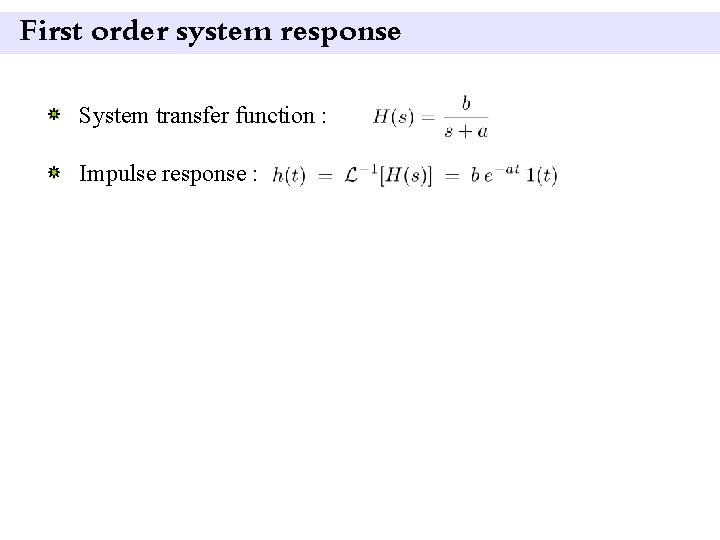
First order system response System transfer function : Impulse response :
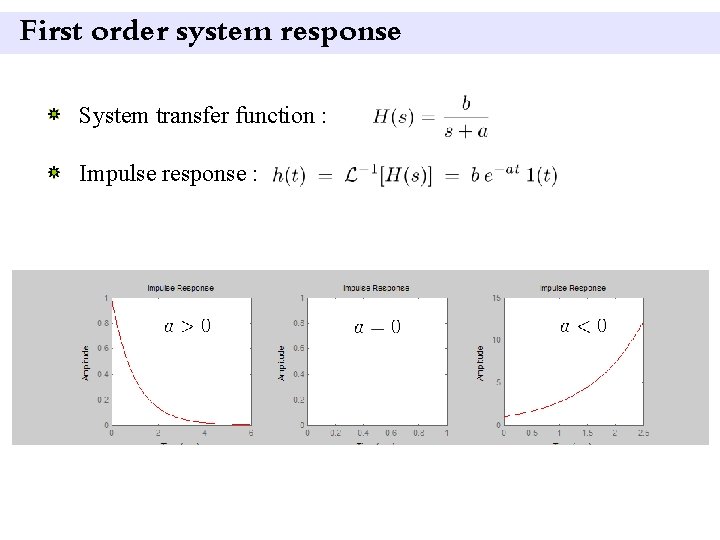
First order system response System transfer function : Impulse response :
First order system response System transfer function : Impulse response : Step response :
First order system response Im(s) Re(s)
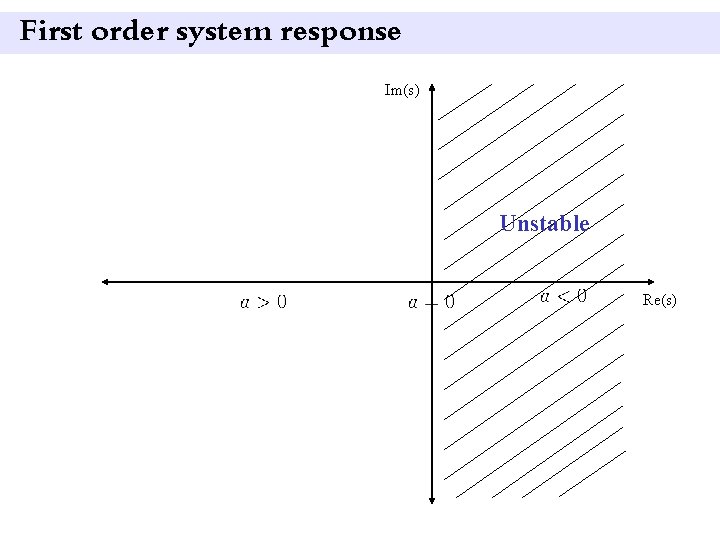
First order system response Im(s) Unstable Re(s)
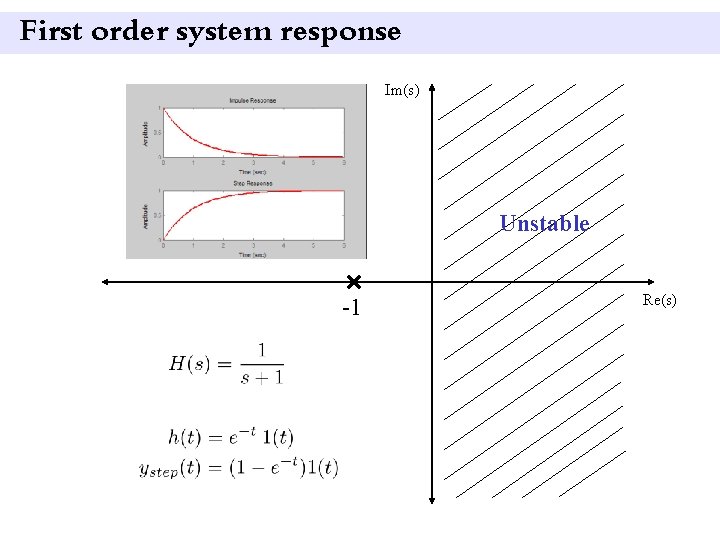
First order system response Im(s) Unstable -1 Re(s)
First order system response Im(s) Unstable -2 Re(s)
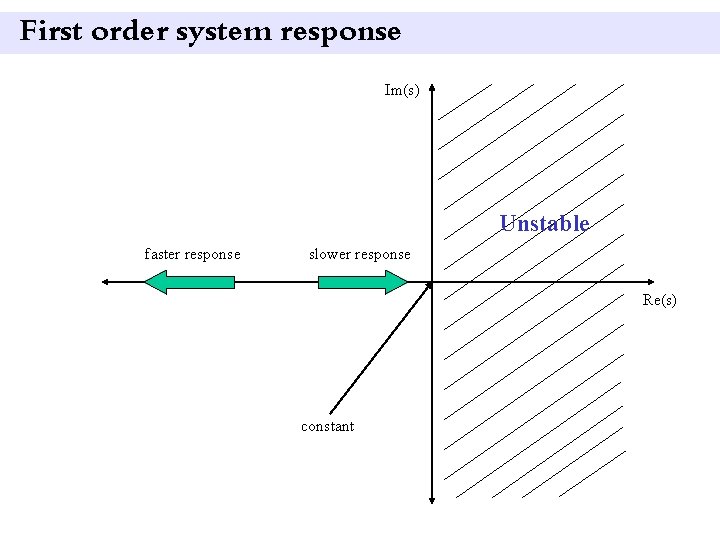
First order system response Im(s) Unstable faster response slower response Re(s) constant
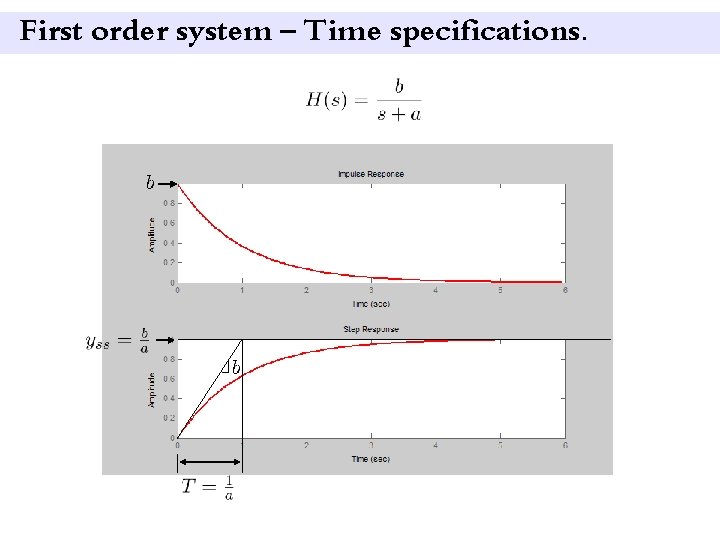
First order system – Time specifications.
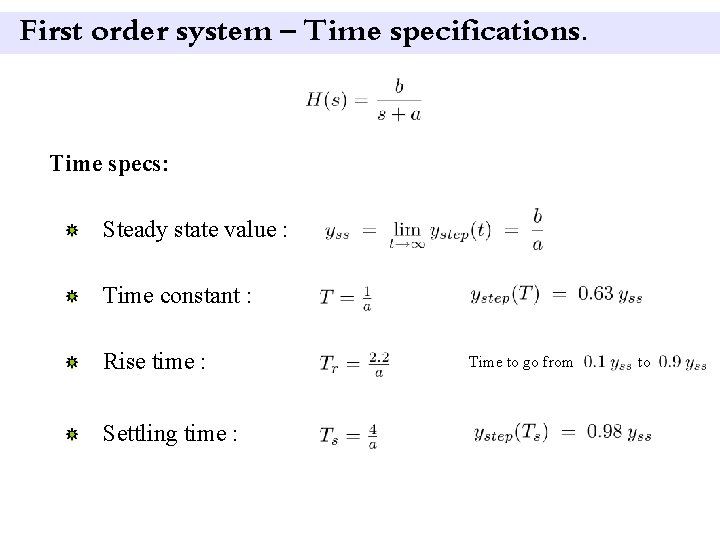
First order system – Time specifications. Time specs: Steady state value : Time constant : Rise time : Settling time : Time to go from to
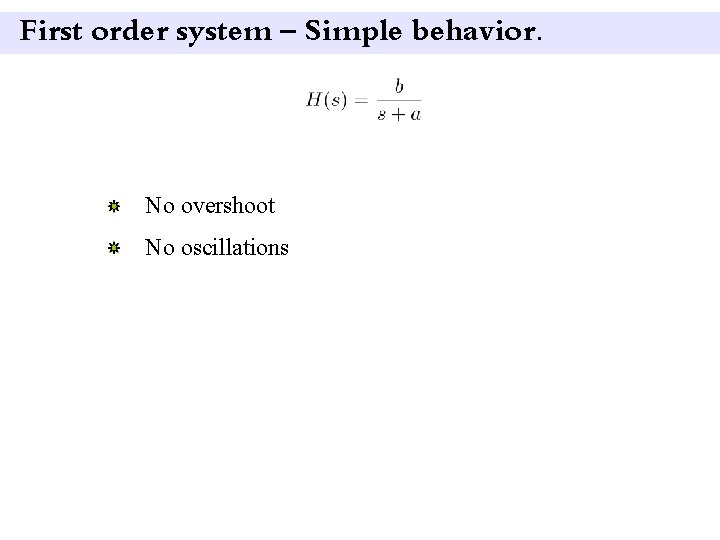
First order system – Simple behavior. No overshoot No oscillations
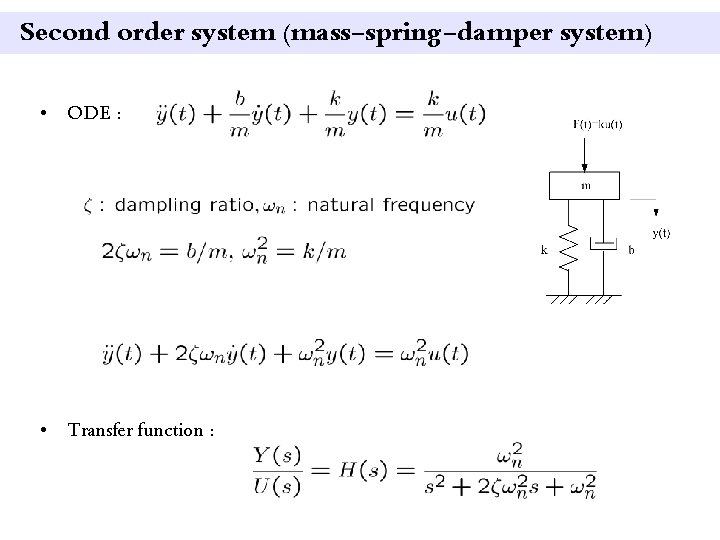
Second order system (mass-spring-damper system) • ODE : • Transfer function :
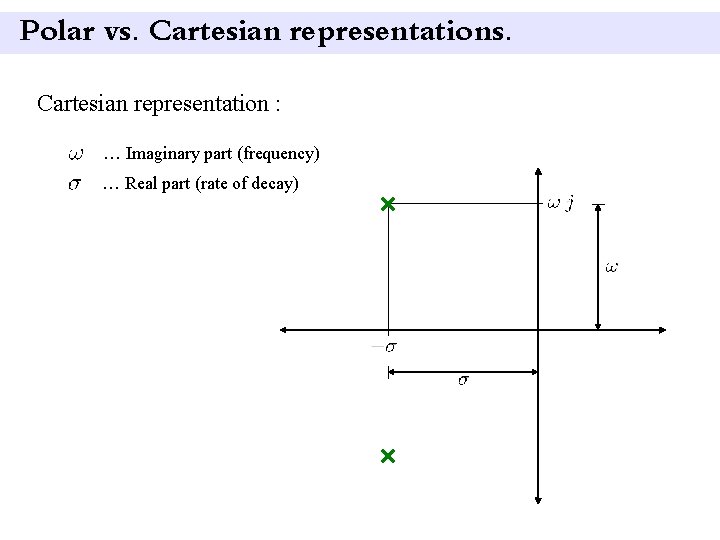
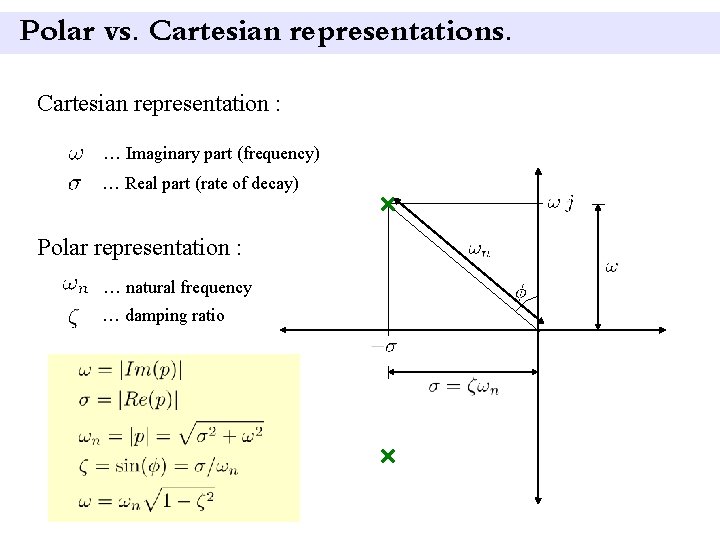
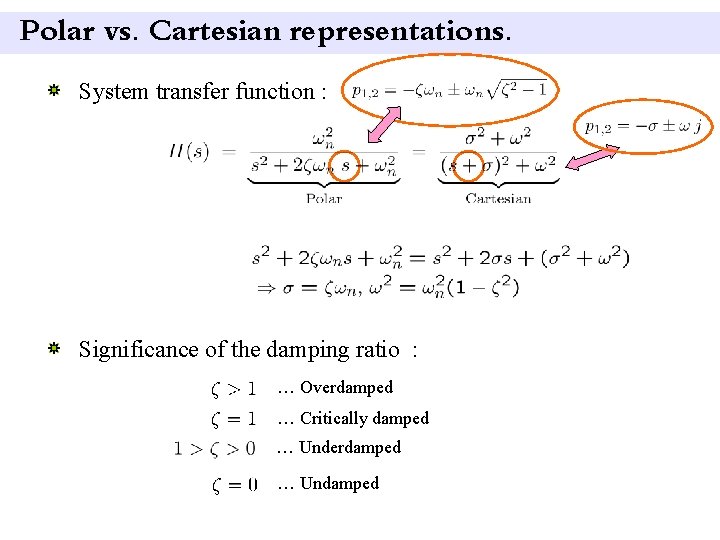
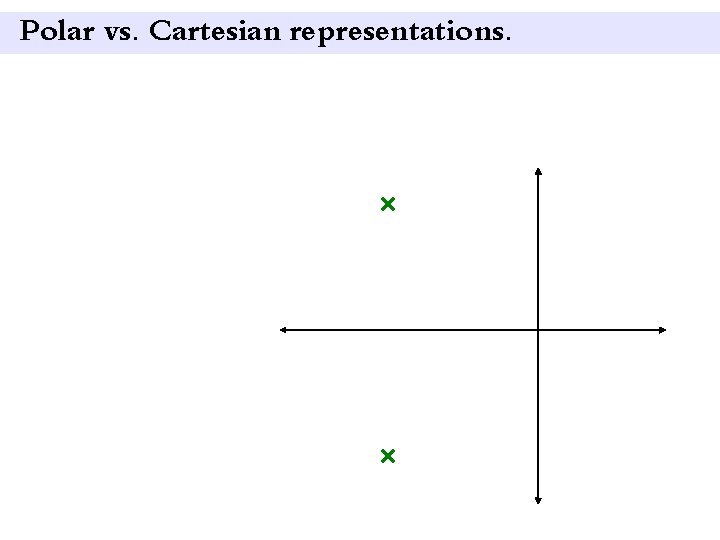
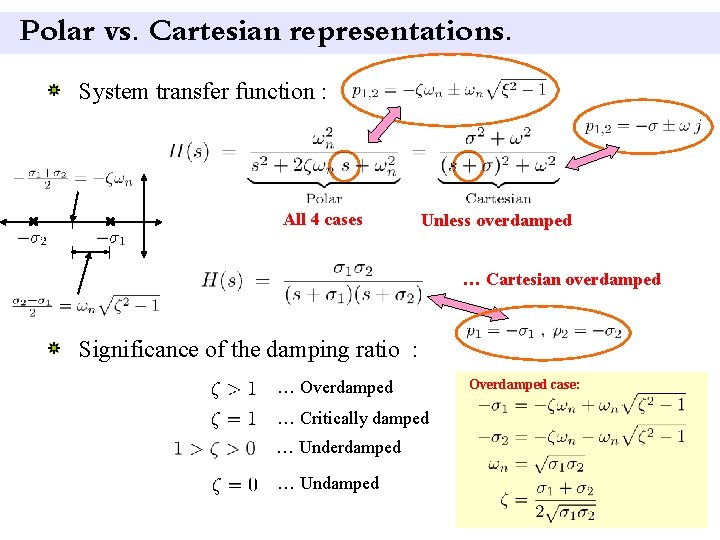
Polar vs. Cartesian representation : … Imaginary part (frequency) … Real part (rate of decay)
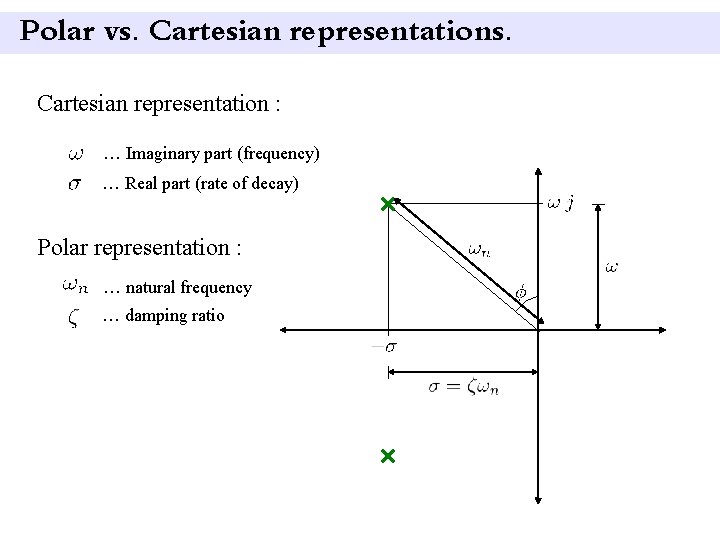
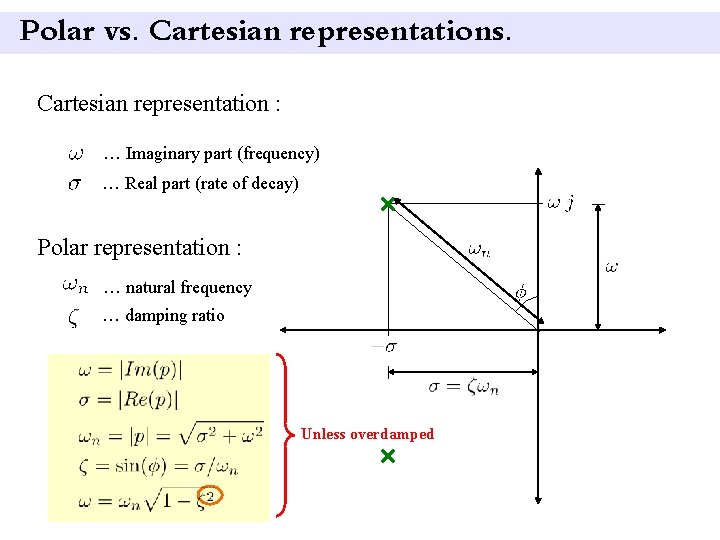
Polar vs. Cartesian representation : … Imaginary part (frequency) … Real part (rate of decay) Polar representation : … natural frequency … damping ratio
Polar vs. Cartesian representation : … Imaginary part (frequency) … Real part (rate of decay) Polar representation : … natural frequency … damping ratio
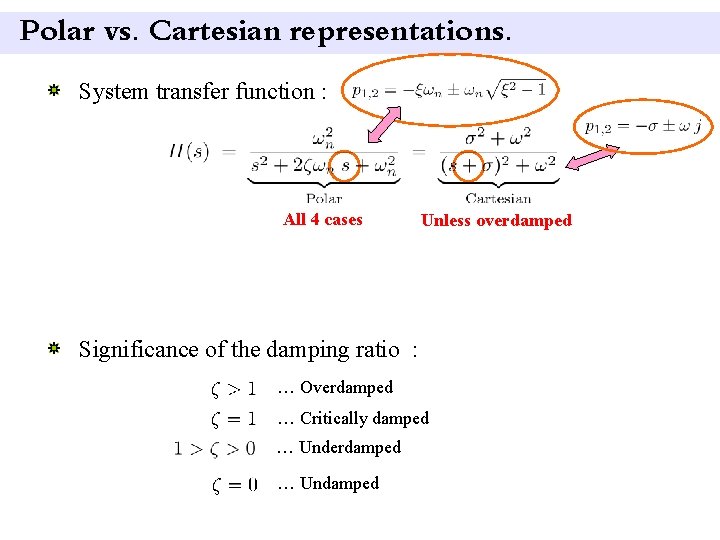
Polar vs. Cartesian representation : … Imaginary part (frequency) … Real part (rate of decay) Polar representation : … natural frequency … damping ratio Unless overdamped
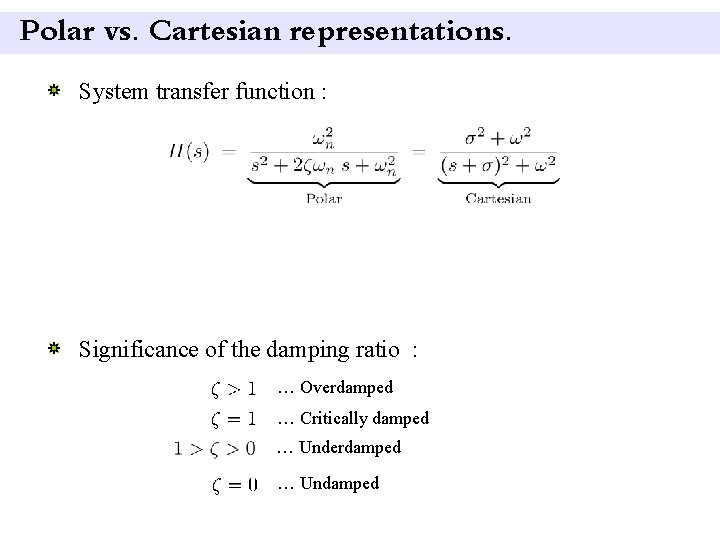
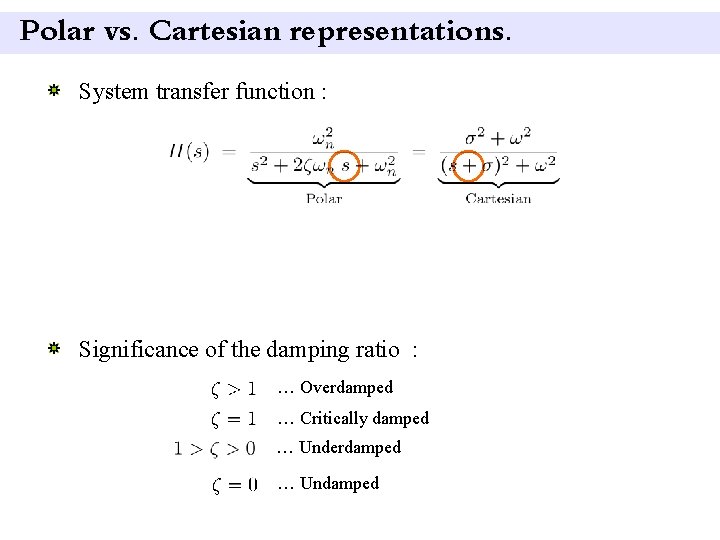
Polar vs. Cartesian representations. System transfer function : Significance of the damping ratio : … Overdamped … Critically damped … Underdamped … Undamped
Polar vs. Cartesian representations. System transfer function : Significance of the damping ratio : … Overdamped … Critically damped … Underdamped … Undamped
Polar vs. Cartesian representations. System transfer function : Significance of the damping ratio : … Overdamped … Critically damped … Underdamped … Undamped
Polar vs. Cartesian representations. System transfer function : All 4 cases Unless overdamped Significance of the damping ratio : … Overdamped … Critically damped … Underdamped … Undamped
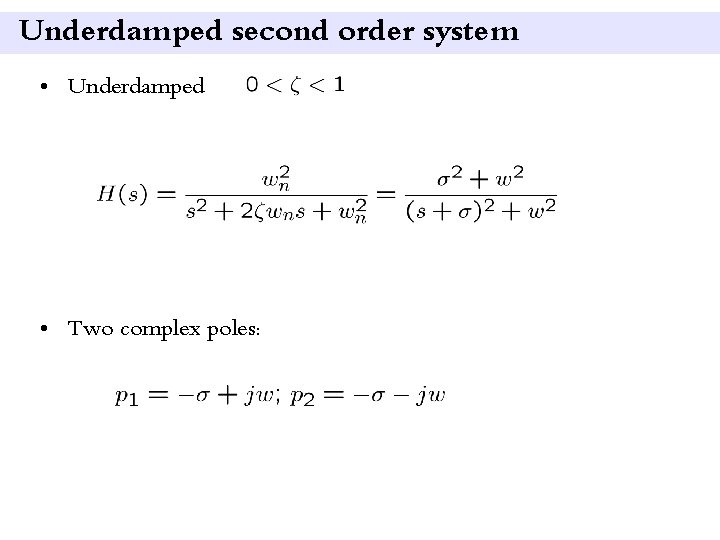
Underdamped second order system • Underdamped • Two complex poles:
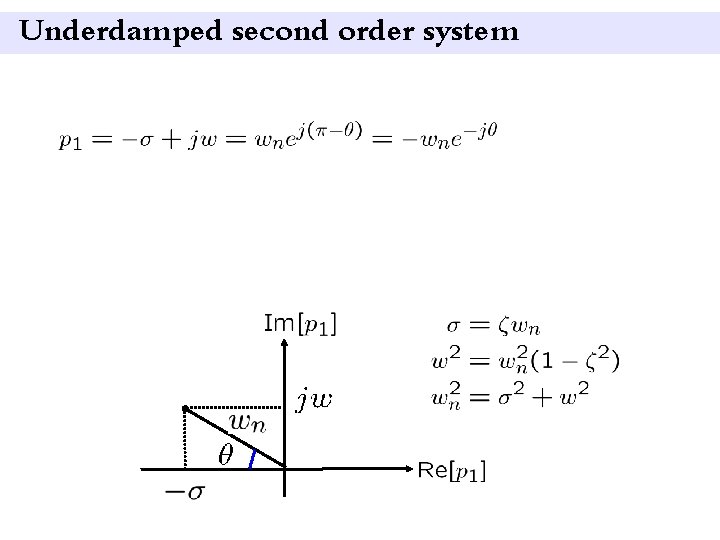
Underdamped second order system
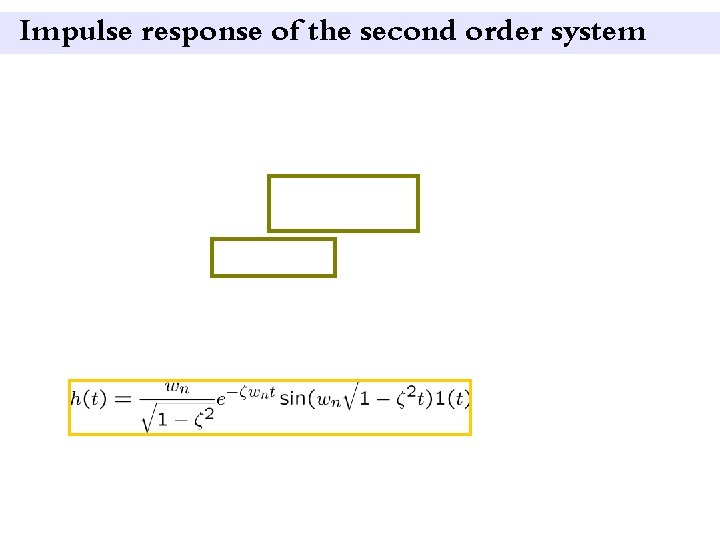
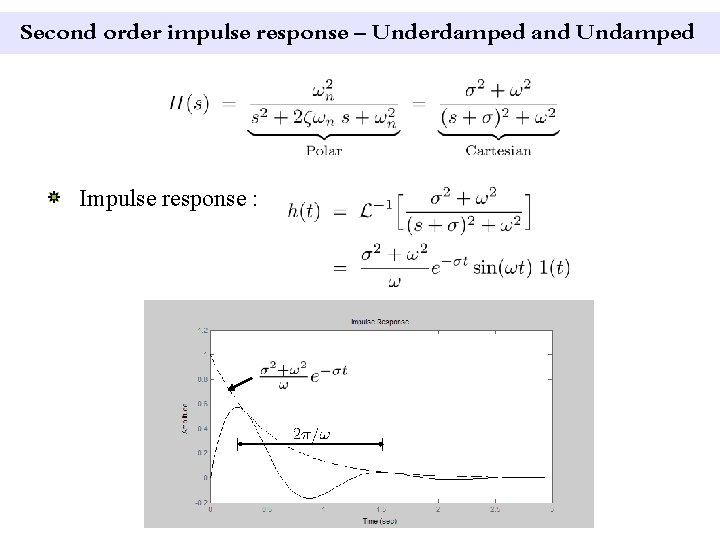
Impulse response of the second order system
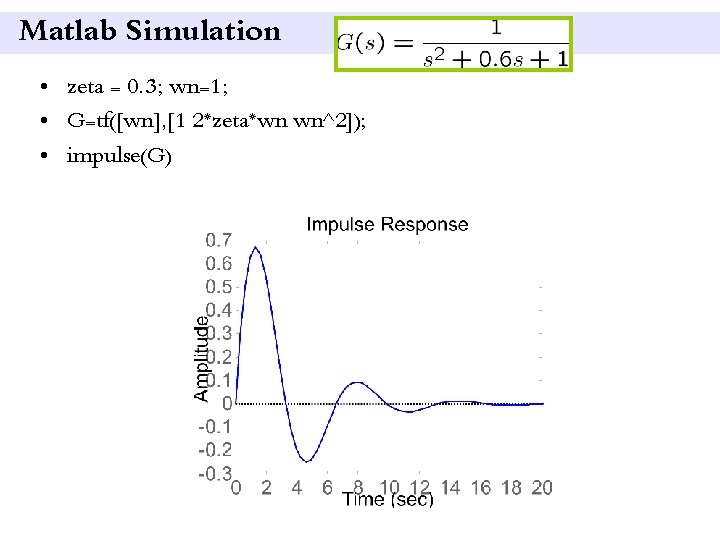
Matlab Simulation • zeta = 0. 3; wn=1; • G=tf([wn], [1 2*zeta*wn wn^2]); • impulse(G)
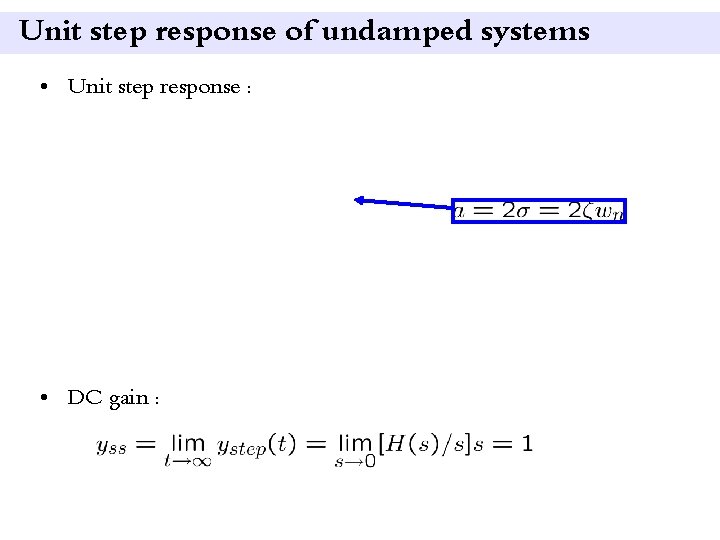
Unit step response of undamped systems • Unit step response : • DC gain :
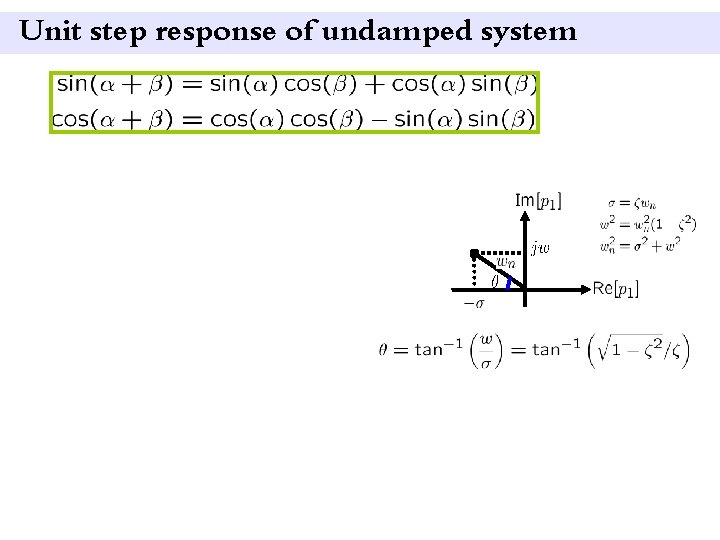
Unit step response of undamped system
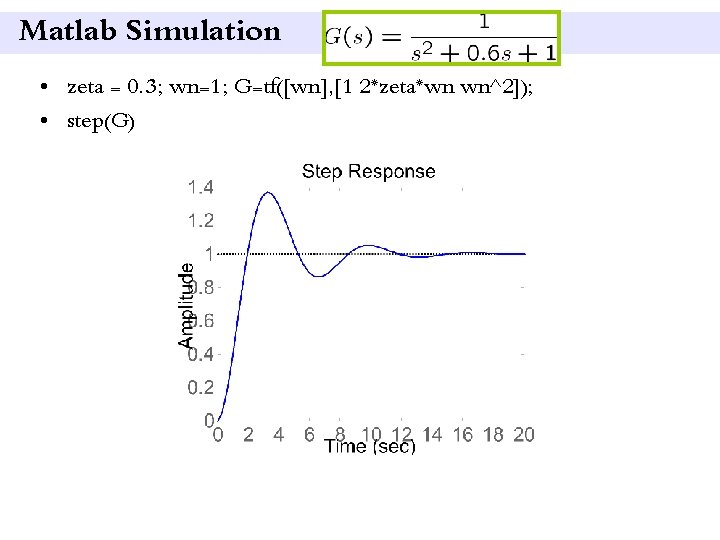
Matlab Simulation • zeta = 0. 3; wn=1; G=tf([wn], [1 2*zeta*wn wn^2]); • step(G)
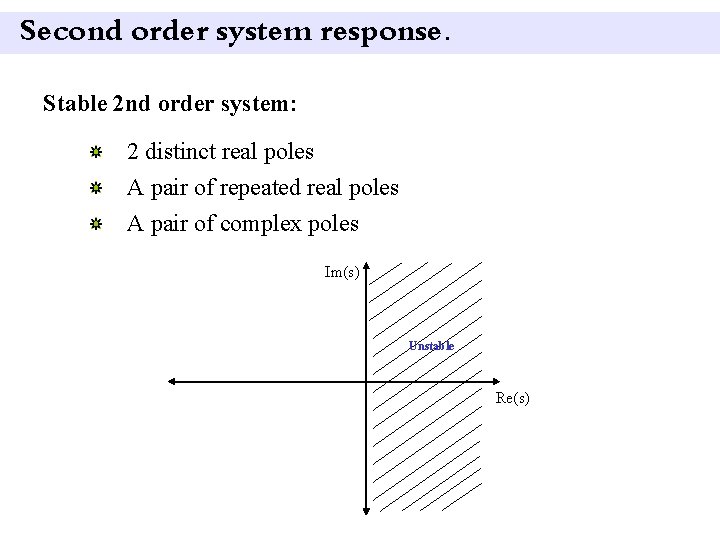
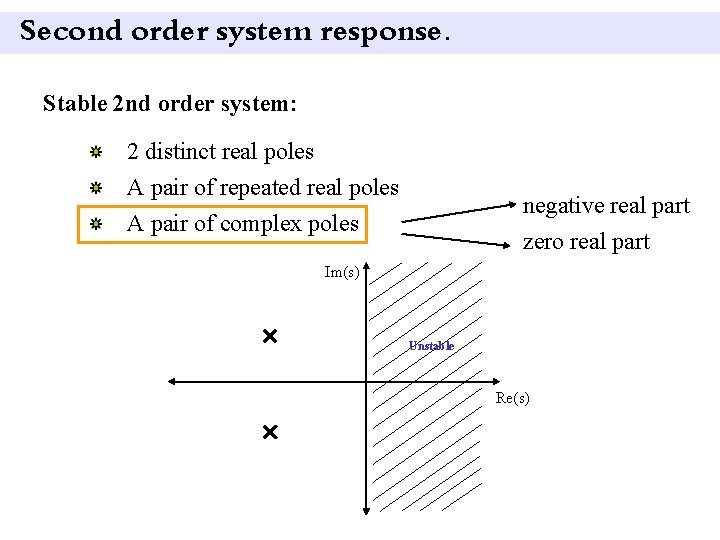
Second order system response. Stable 2 nd order system: 2 distinct real poles A pair of repeated real poles A pair of complex poles Im(s) Unstable Re(s)
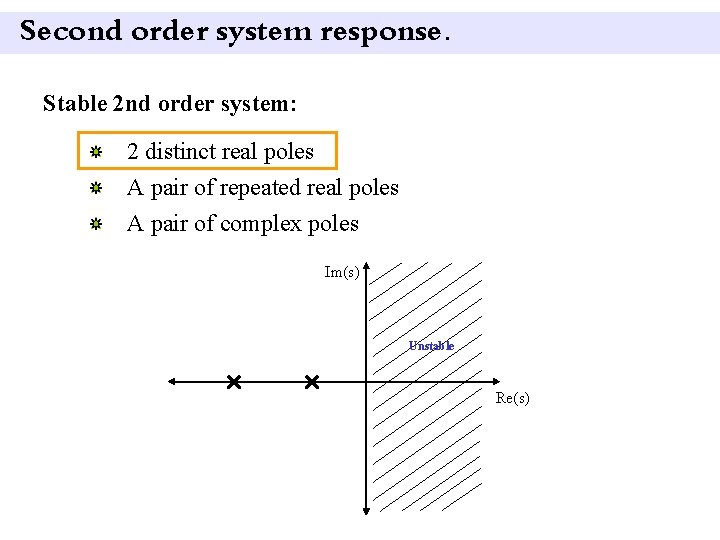
Second order system response. Stable 2 nd order system: 2 distinct real poles A pair of repeated real poles A pair of complex poles Im(s) Unstable Re(s)
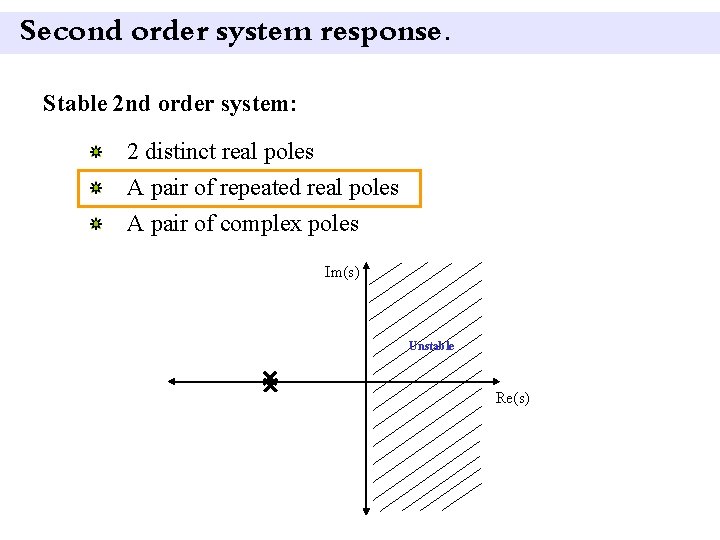
Second order system response. Stable 2 nd order system: 2 distinct real poles A pair of repeated real poles A pair of complex poles Im(s) Unstable Re(s)
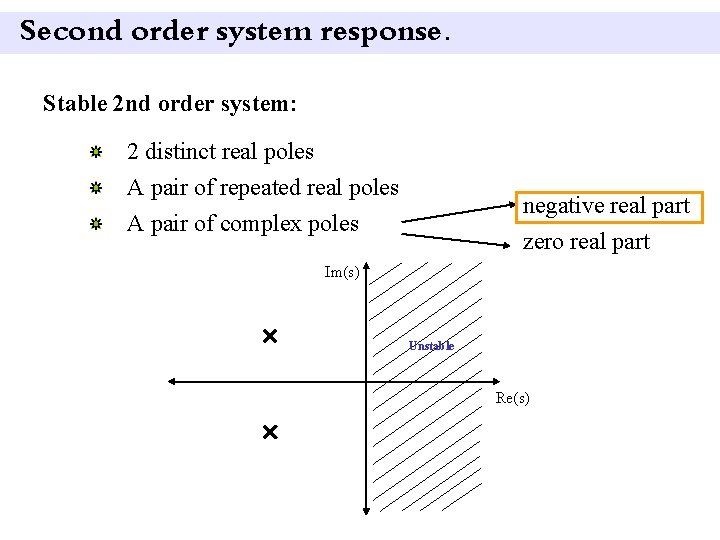
Second order system response. Stable 2 nd order system: 2 distinct real poles A pair of repeated real poles A pair of complex poles negative real part zero real part Im(s) Unstable Re(s)
Second order system response. Stable 2 nd order system: 2 distinct real poles A pair of repeated real poles A pair of complex poles negative real part zero real part Im(s) Unstable Re(s)
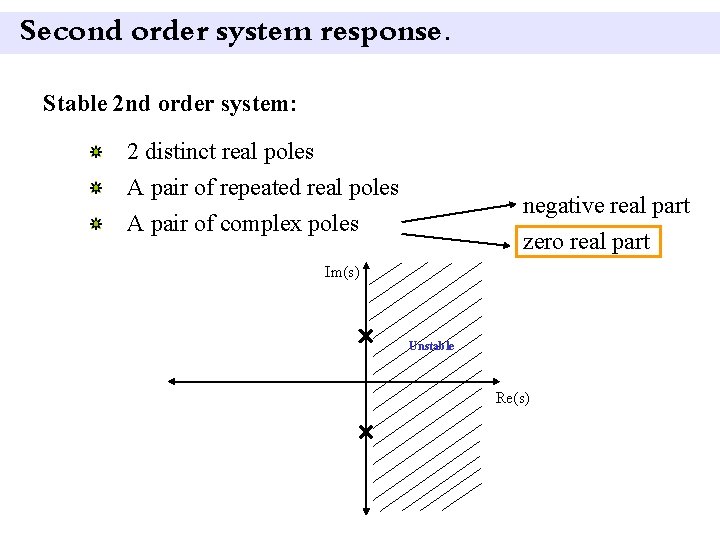
Second order system response. Stable 2 nd order system: 2 distinct real poles A pair of repeated real poles A pair of complex poles negative real part zero real part Im(s) Unstable Re(s)
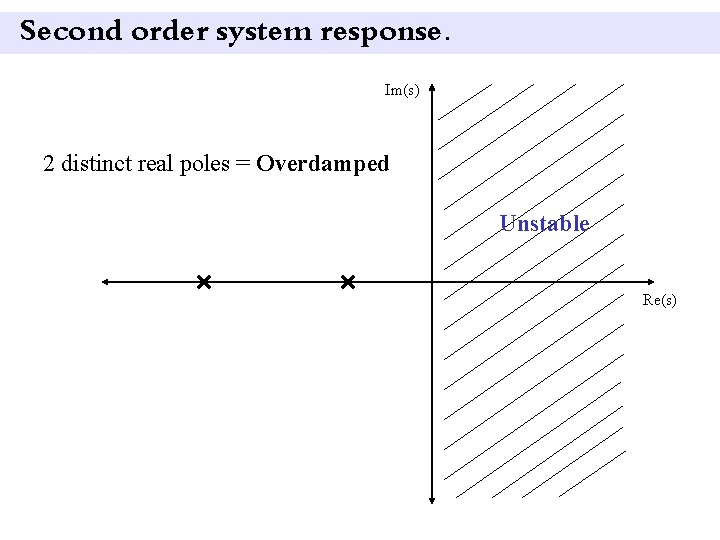
Second order system response. Im(s) 2 distinct real poles = Overdamped Unstable Re(s)
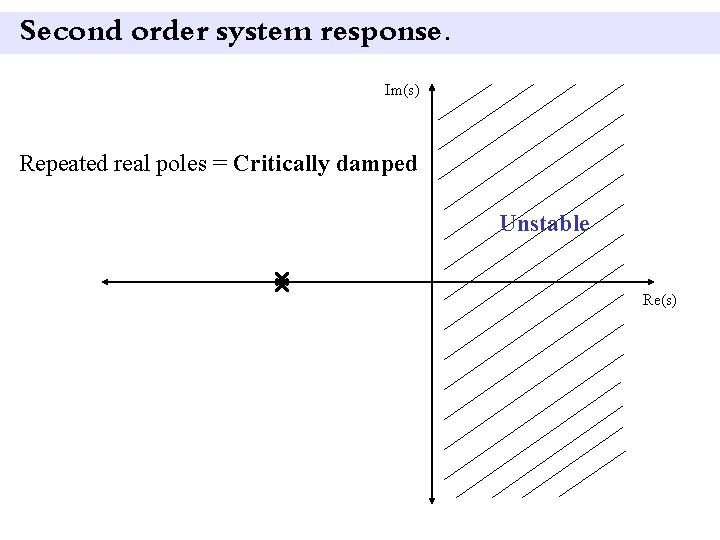
Second order system response. Im(s) Repeated real poles = Critically damped Unstable Re(s)
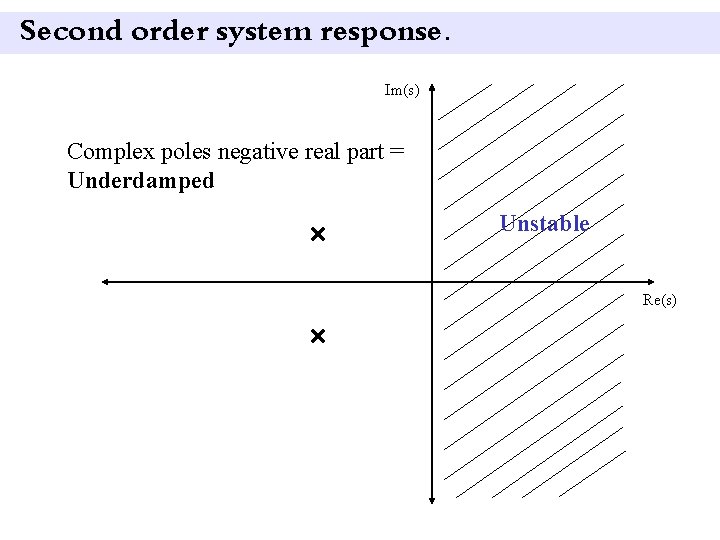
Second order system response. Im(s) Complex poles negative real part = Underdamped Unstable Re(s)
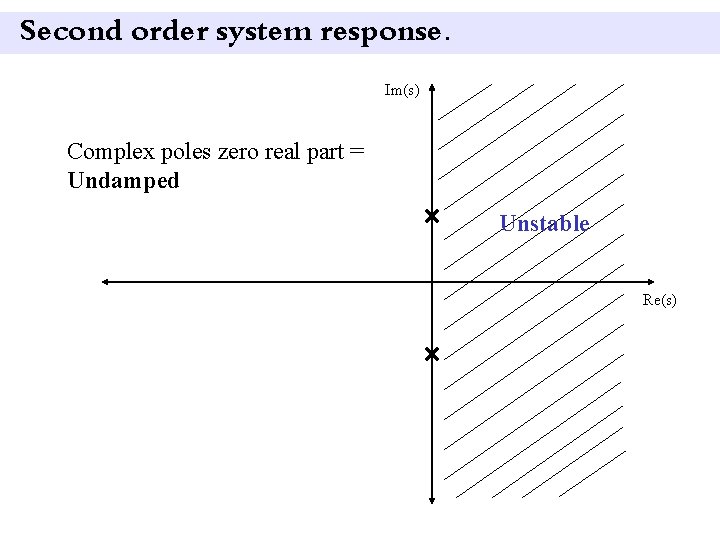
Second order system response. Im(s) Complex poles zero real part = Undamped Unstable Re(s)
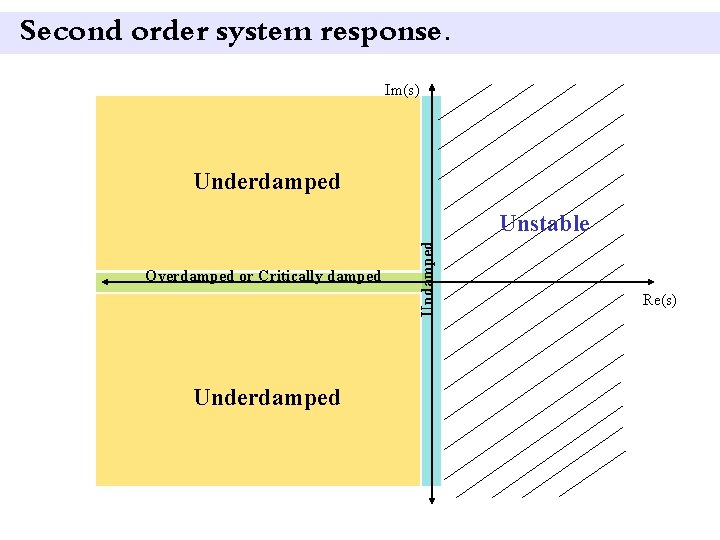
Second order system response. Im(s) Underdamped Overdamped or Critically damped Underdamped Unstable Re(s)
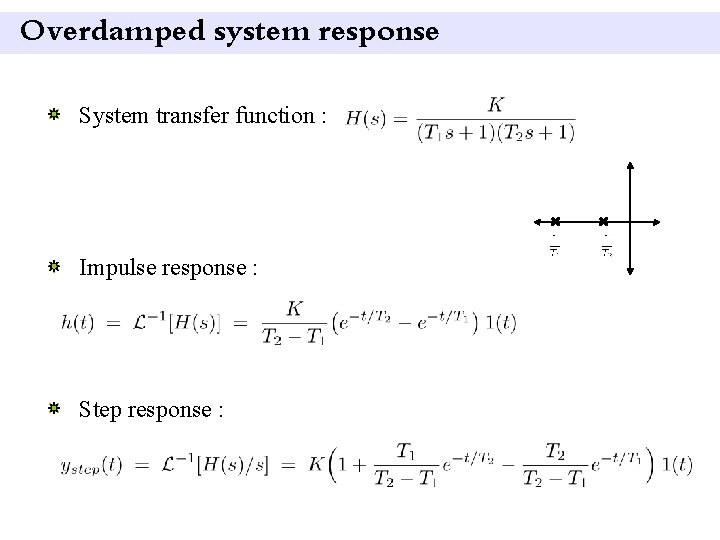
Overdamped system response System transfer function : Impulse response : Step response :
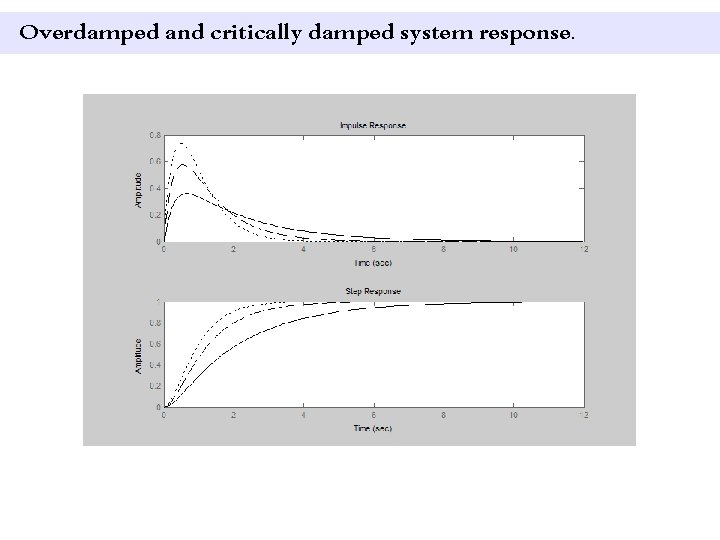
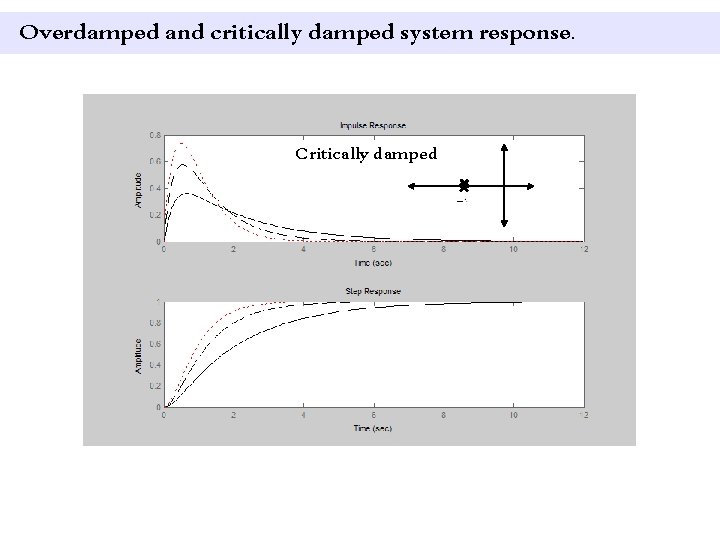
Overdamped and critically damped system response.
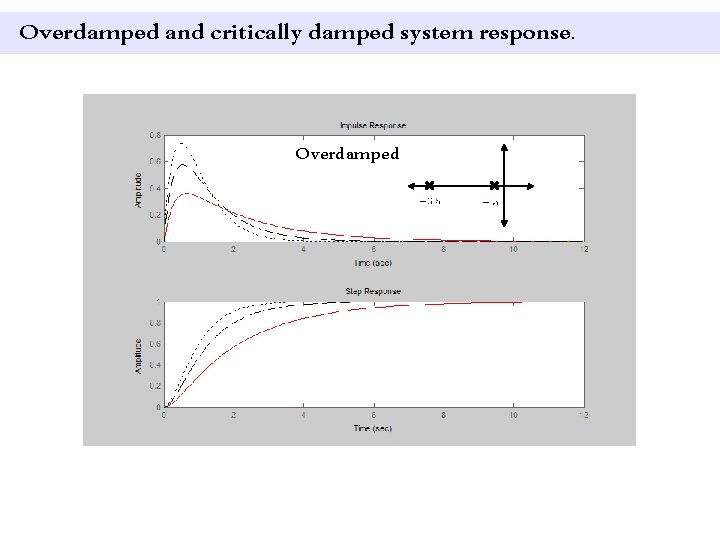
Overdamped and critically damped system response. Overdamped
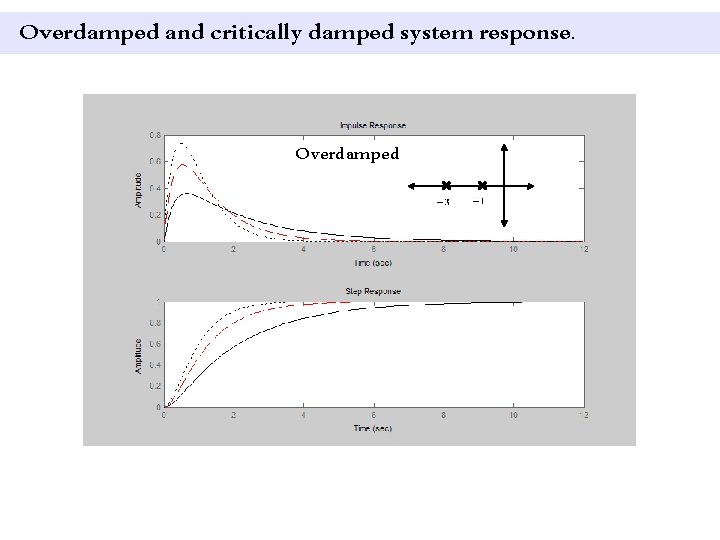
Overdamped and critically damped system response. Overdamped
Overdamped and critically damped system response. Critically damped
Polar vs. Cartesian representations.
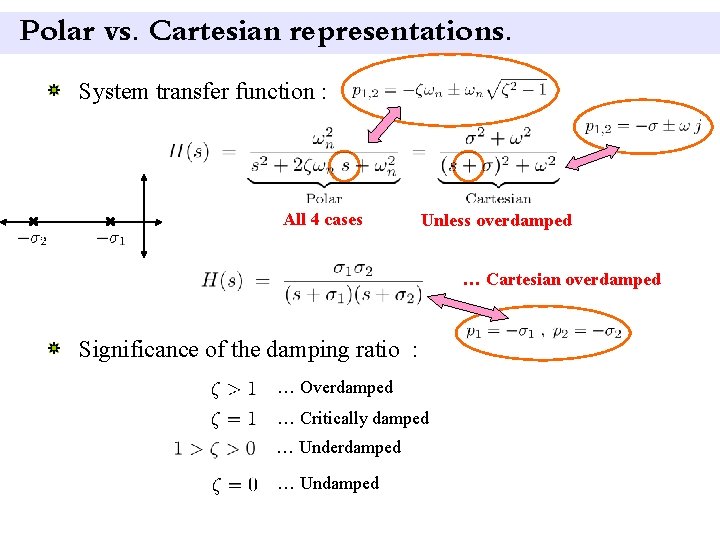
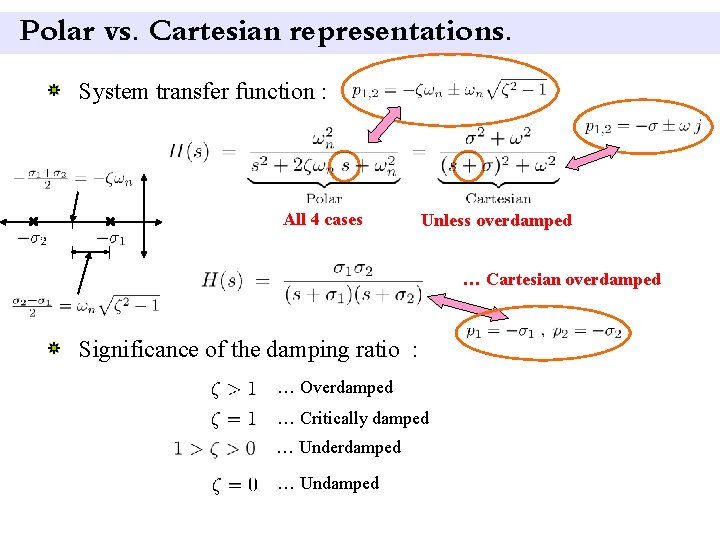
Polar vs. Cartesian representations. System transfer function : All 4 cases Unless overdamped … Cartesian overdamped Significance of the damping ratio : … Overdamped … Critically damped … Underdamped … Undamped
Polar vs. Cartesian representations. System transfer function : All 4 cases Unless overdamped … Cartesian overdamped Significance of the damping ratio : … Overdamped … Critically damped … Underdamped … Undamped
Polar vs. Cartesian representations. System transfer function : All 4 cases Unless overdamped … Cartesian overdamped Significance of the damping ratio : … Overdamped … Critically damped … Underdamped … Undamped Overdamped case:
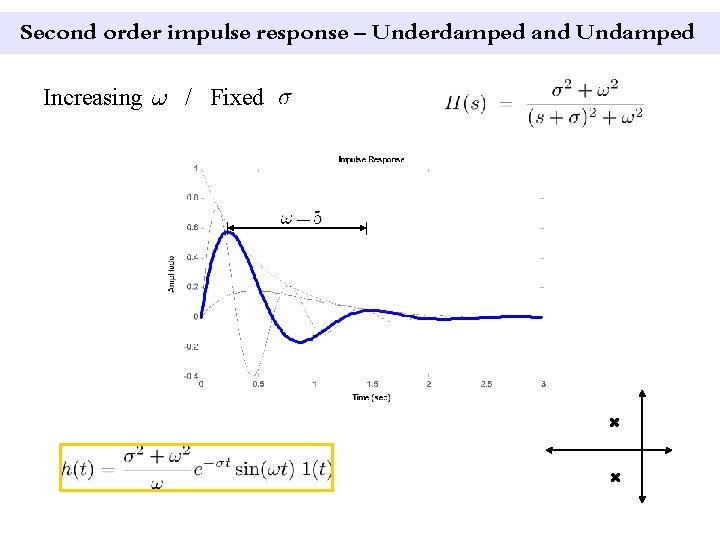
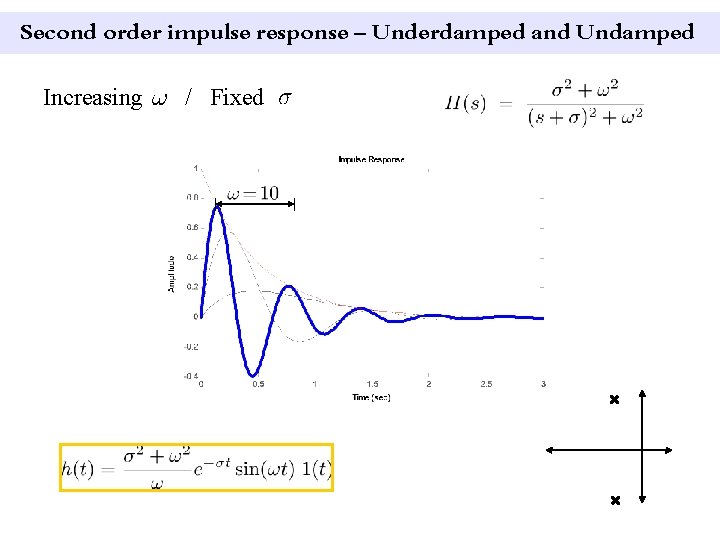
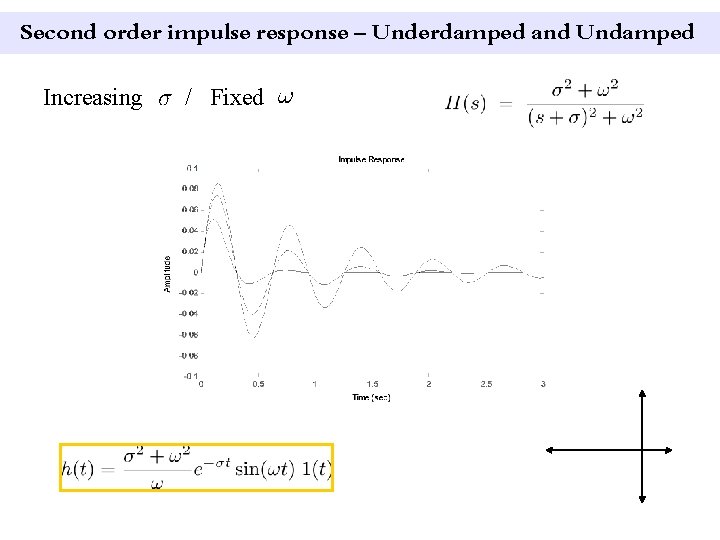
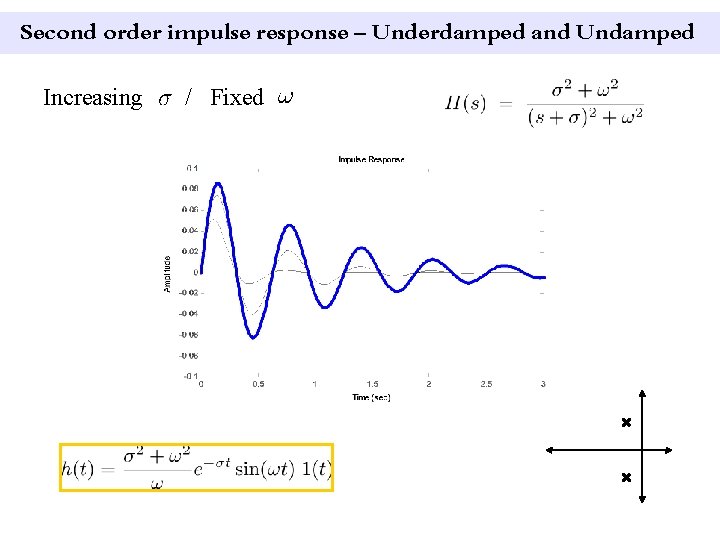
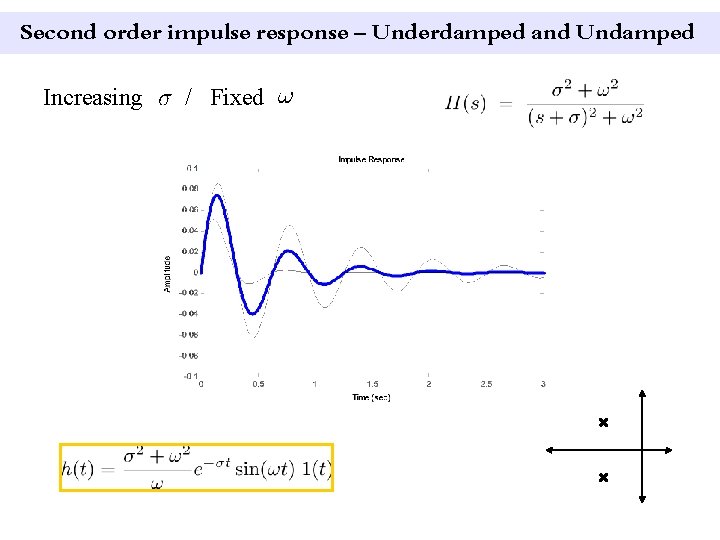
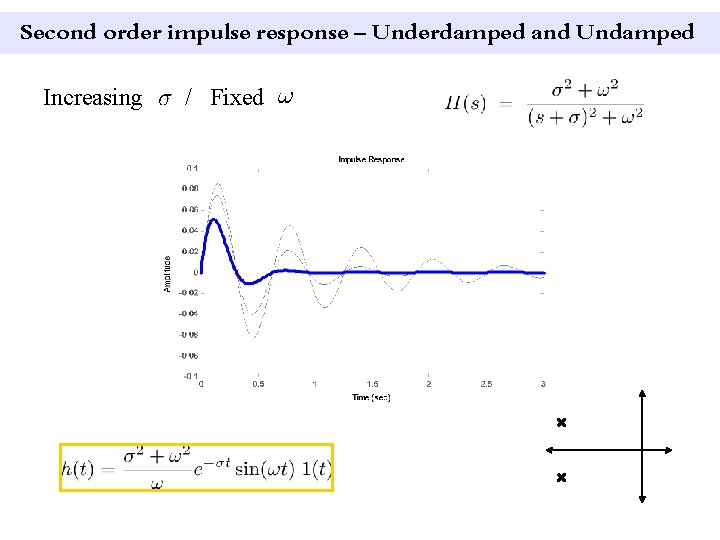
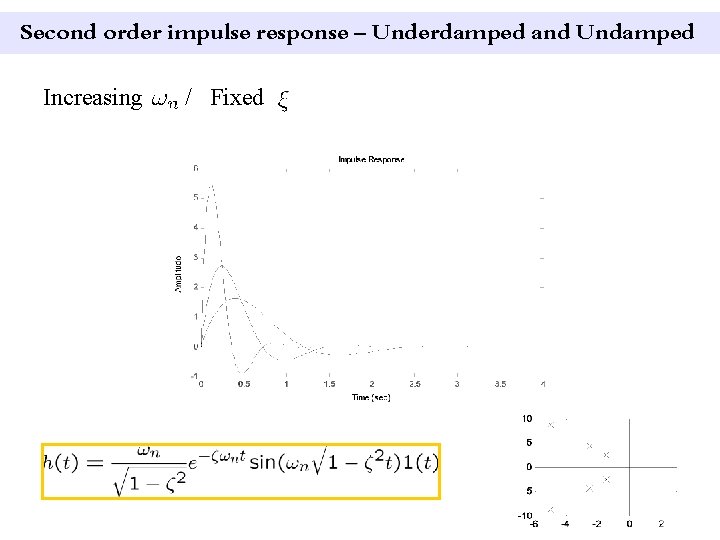
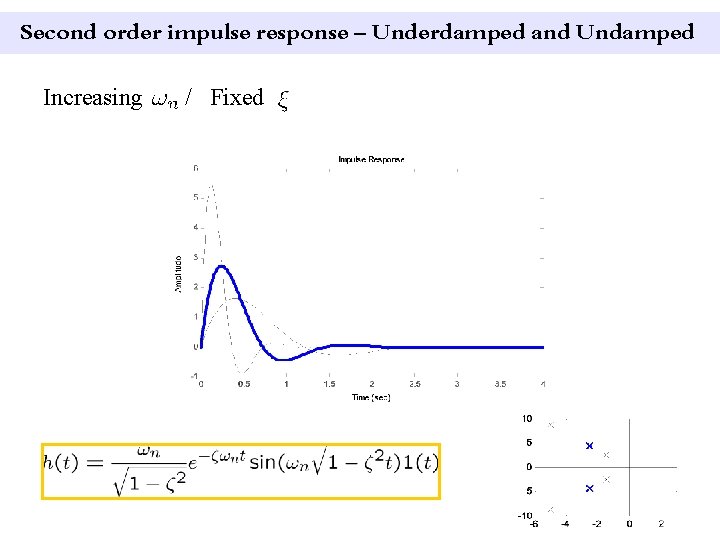
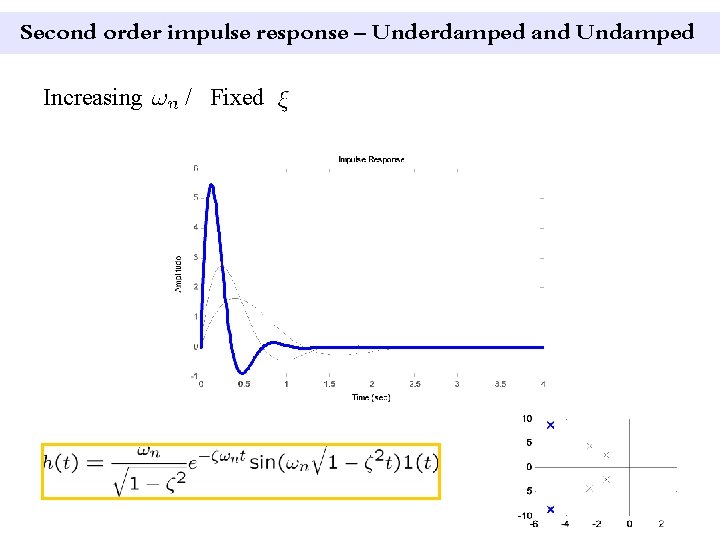
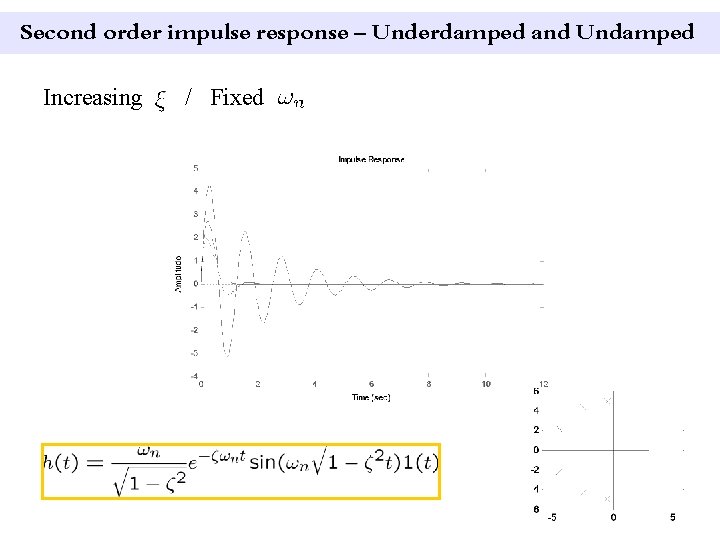
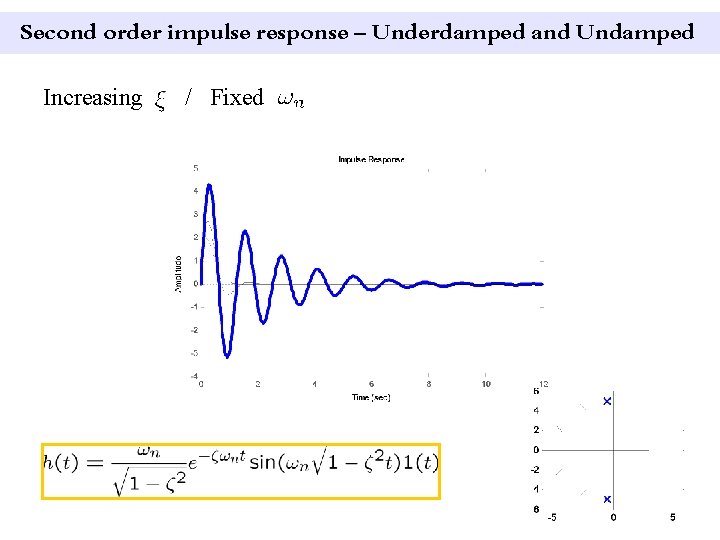
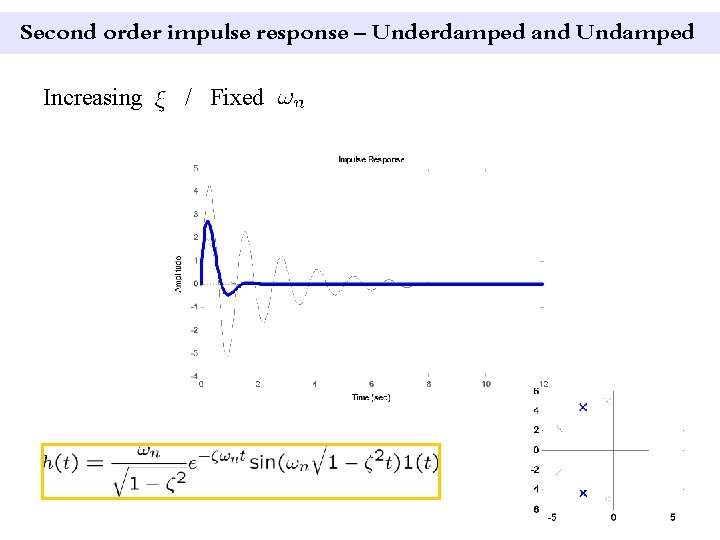
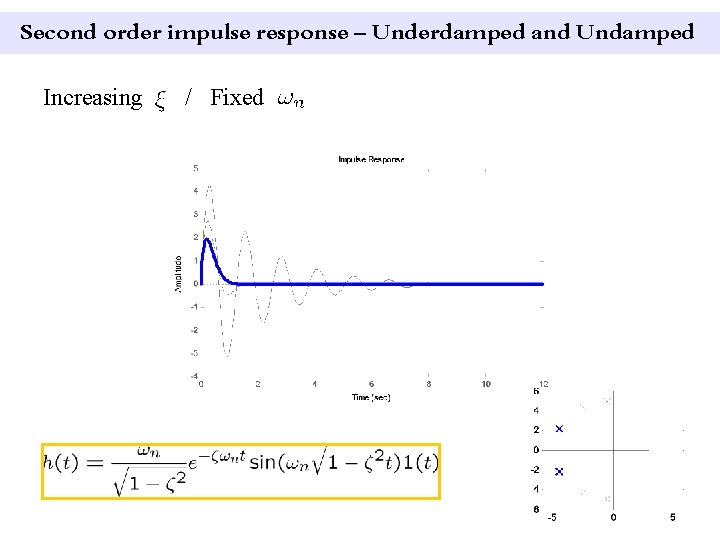
Second order impulse response – Underdamped and Undamped Impulse response :
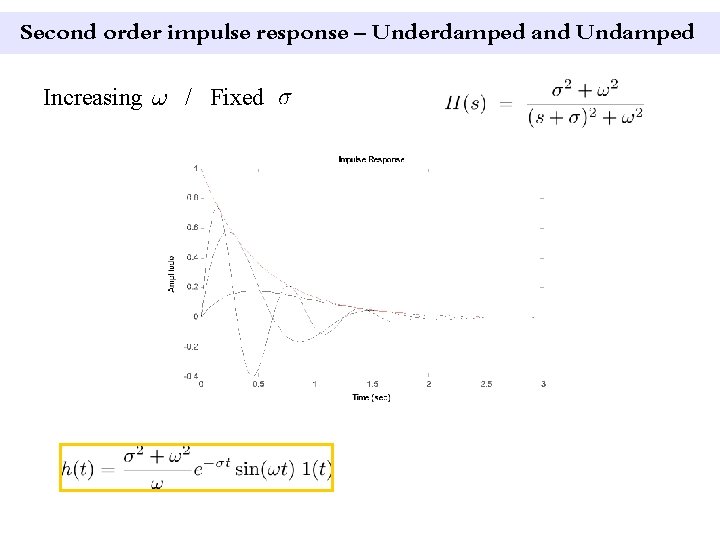
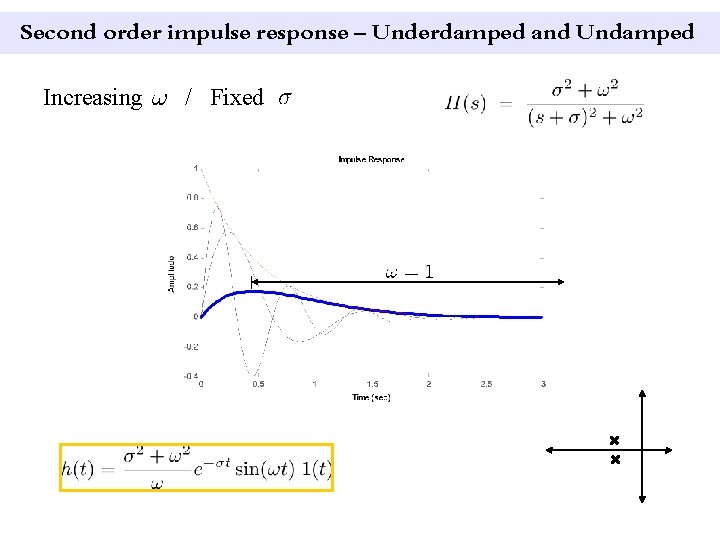
Second order impulse response – Underdamped and Undamped Increasing / Fixed
Second order impulse response – Underdamped and Undamped Increasing / Fixed
Second order impulse response – Underdamped and Undamped Increasing / Fixed
Second order impulse response – Underdamped and Undamped Increasing / Fixed
Second order impulse response – Underdamped and Undamped Increasing / Fixed
Second order impulse response – Underdamped and Undamped Increasing / Fixed
Second order impulse response – Underdamped and Undamped Increasing / Fixed
Second order impulse response – Underdamped and Undamped Increasing / Fixed
Second order impulse response – Underdamped and Undamped Increasing / Fixed
Second order impulse response – Underdamped and Undamped Increasing / Fixed
Second order impulse response – Underdamped and Undamped Increasing / Fixed
Second order impulse response – Underdamped and Undamped Increasing / Fixed
Second order impulse response – Underdamped and Undamped Increasing / Fixed
Second order impulse response – Underdamped and Undamped Increasing / Fixed
Second order impulse response – Underdamped and Undamped Increasing / Fixed
Second order impulse response – Underdamped and Undamped Increasing / Fixed
Second order step response – Underdamped and Undamped
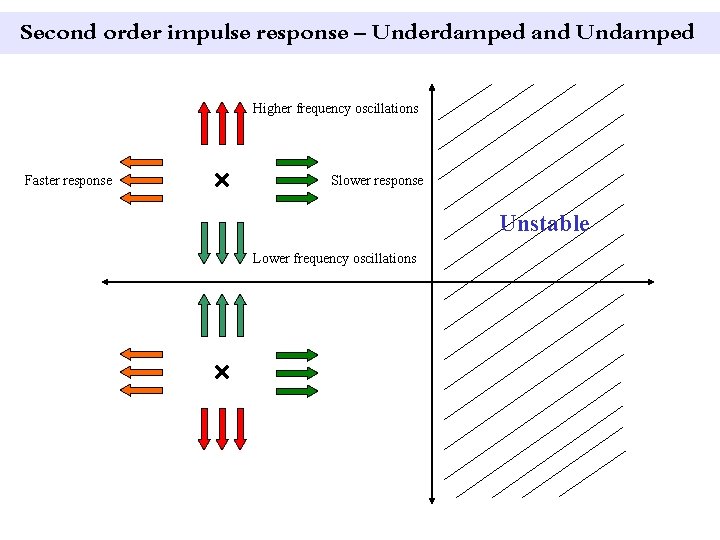
Second order impulse response – Underdamped and Undamped Higher frequency oscillations Faster response Slower response Unstable Lower frequency oscillations
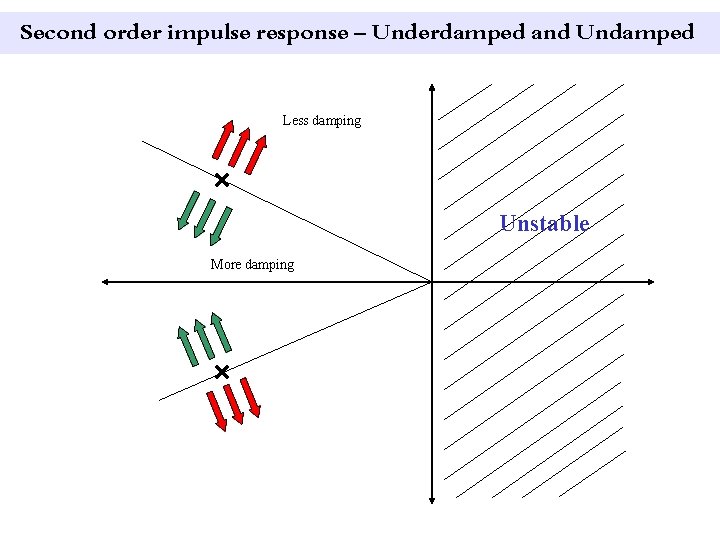
Second order impulse response – Underdamped and Undamped Less damping Unstable More damping
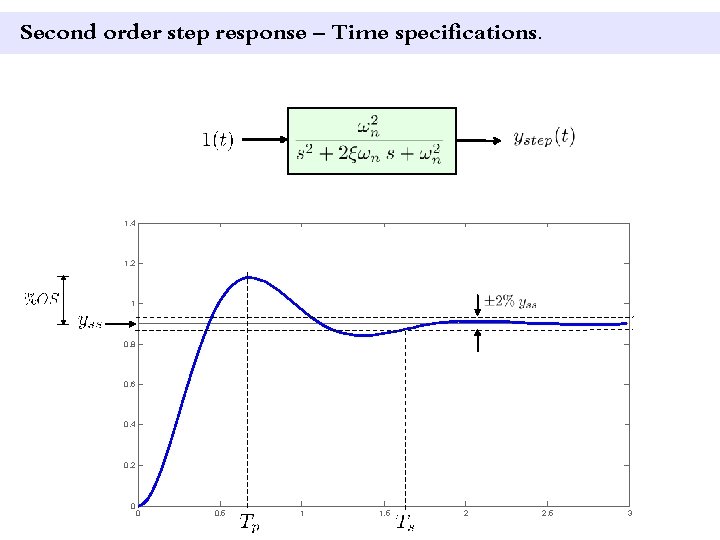
Second order step response – Time specifications. 1. 4 1. 2 1 0. 8 0. 6 0. 4 0. 2 0 0 0. 5 1 1. 5 2 2. 5 3
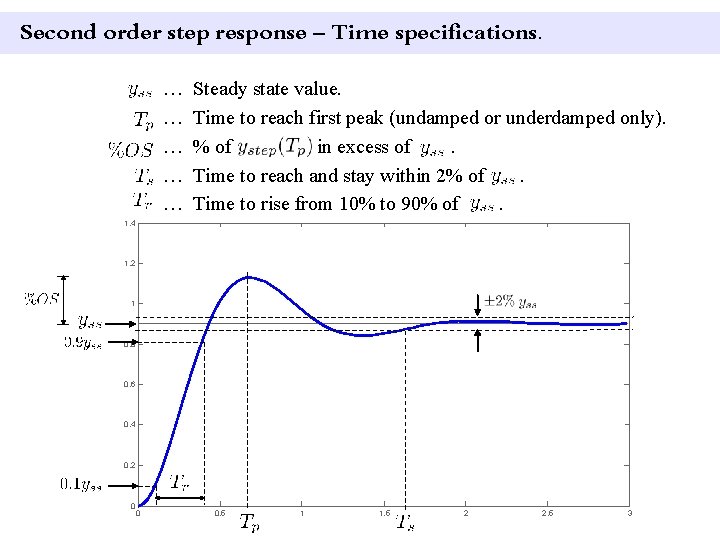
Second order step response – Time specifications. … … … Steady state value. Time to reach first peak (undamped or underdamped only). % of in excess of. Time to reach and stay within 2% of. Time to rise from 10% to 90% of. 1. 4 1. 2 1 0. 8 0. 6 0. 4 0. 2 0 0 0. 5 1 1. 5 2 2. 5 3
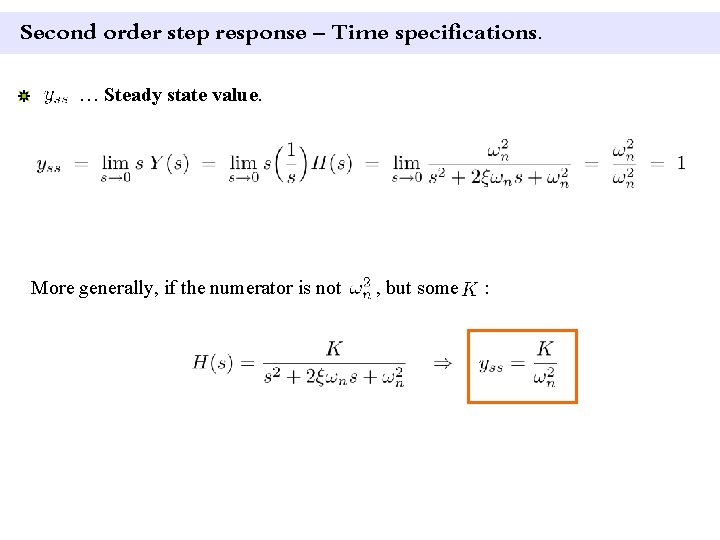
Second order step response – Time specifications. … Steady state value. More generally, if the numerator is not , but some :
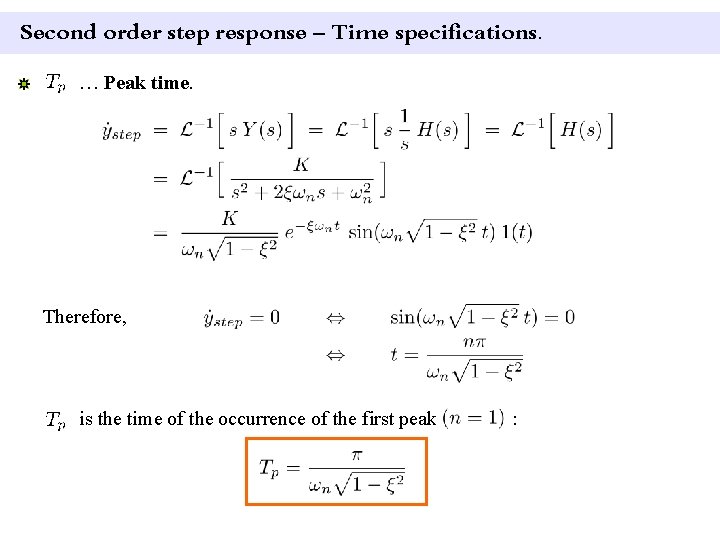
Second order step response – Time specifications. … Peak time. Therefore, is the time of the occurrence of the first peak :
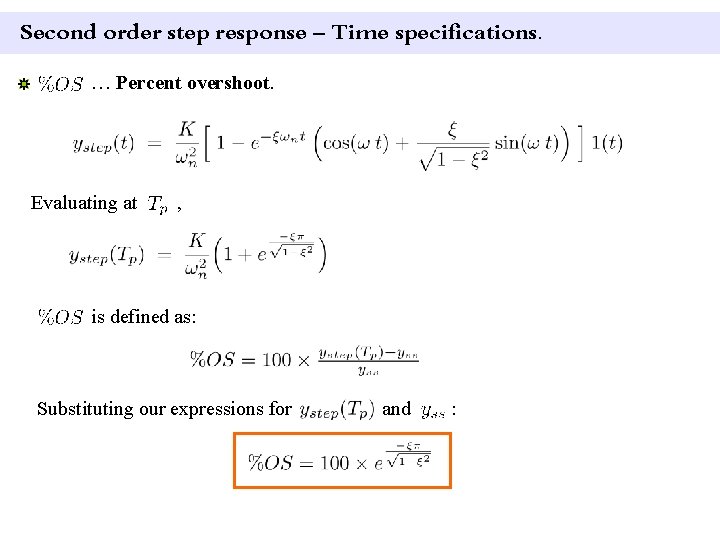
Second order step response – Time specifications. … Percent overshoot. Evaluating at , is defined as: Substituting our expressions for and :
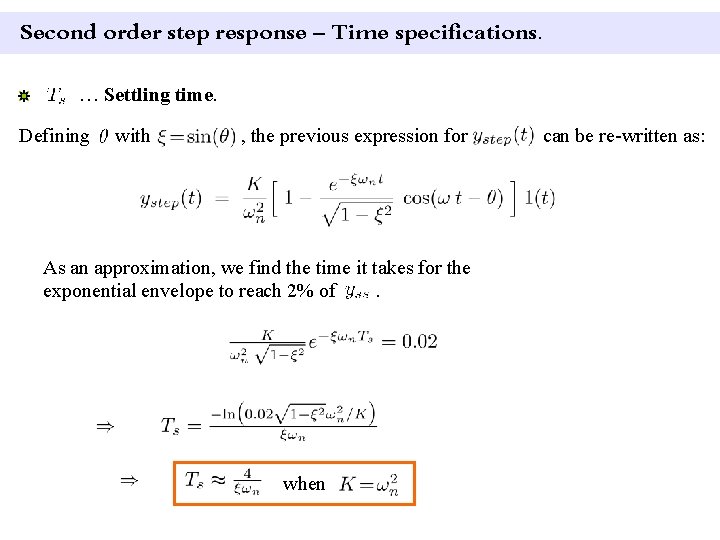
Second order step response – Time specifications. … Settling time. Defining with , the previous expression for As an approximation, we find the time it takes for the exponential envelope to reach 2% of. when can be re-written as:
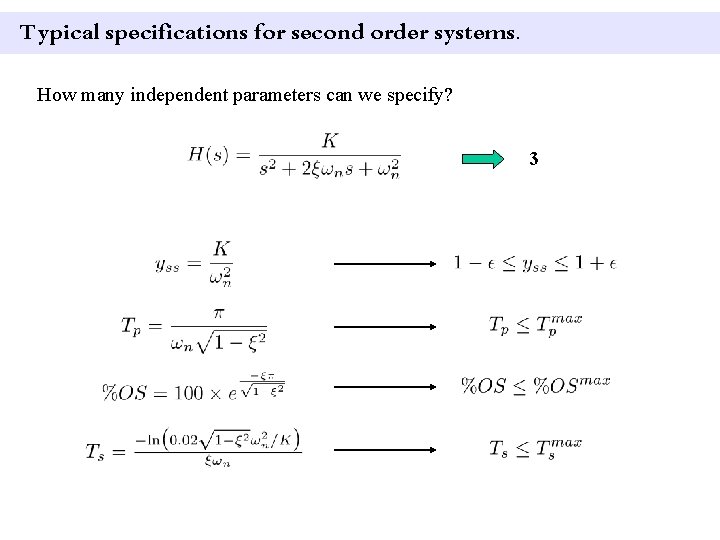
Typical specifications for second order systems. How many independent parameters can we specify? 3