Islamic University of Gaza Faculty of Engineering Electrical
- Slides: 52
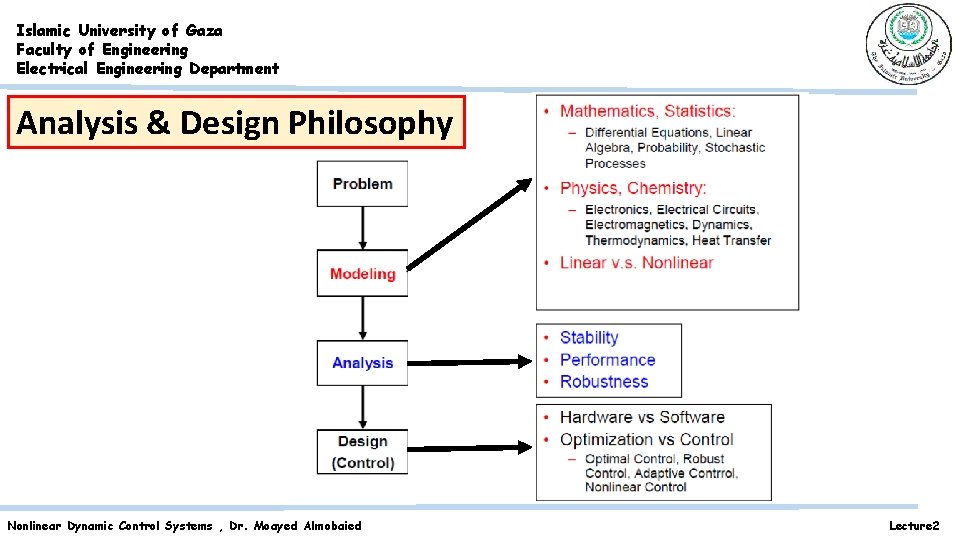
Islamic University of Gaza Faculty of Engineering Electrical Engineering Department Analysis & Design Philosophy Nonlinear Dynamic Control Systems , Dr. Moayed Almobaied Lecture 2
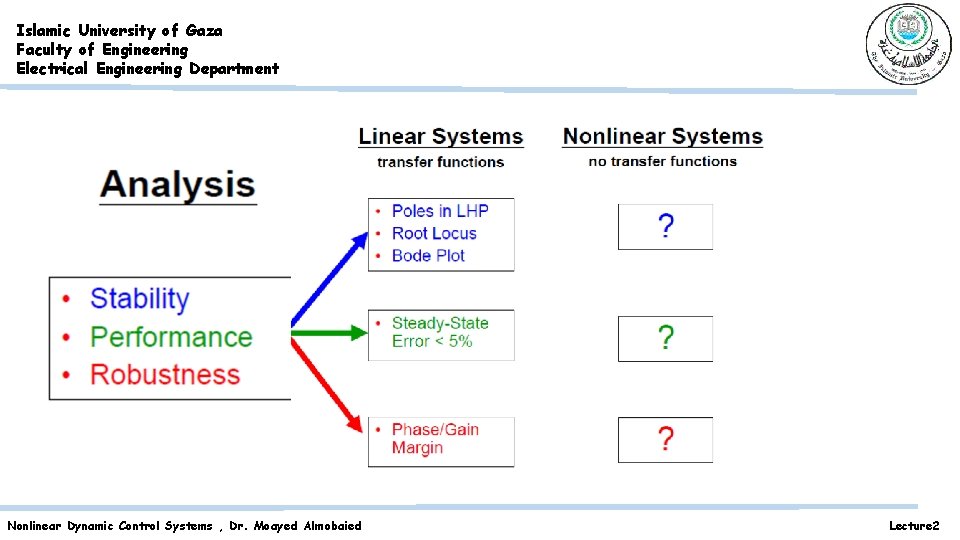
Islamic University of Gaza Faculty of Engineering Electrical Engineering Department Nonlinear Dynamic Control Systems , Dr. Moayed Almobaied Lecture 2
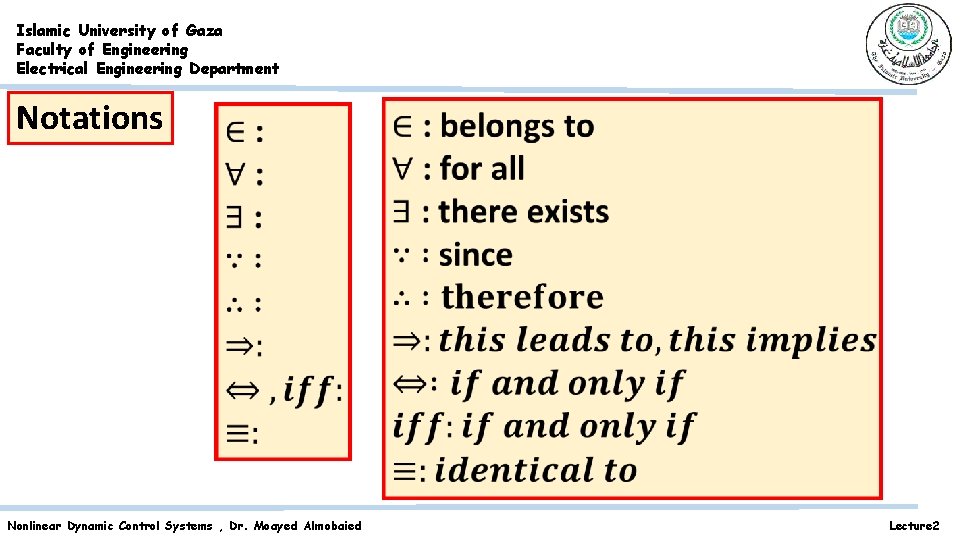
Islamic University of Gaza Faculty of Engineering Electrical Engineering Department Notations Nonlinear Dynamic Control Systems , Dr. Moayed Almobaied Lecture 2
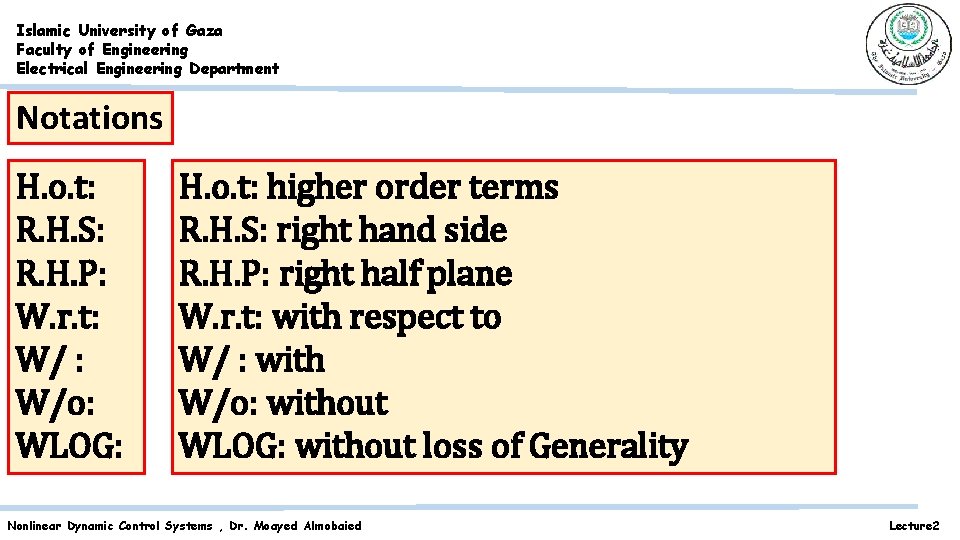
Islamic University of Gaza Faculty of Engineering Electrical Engineering Department Notations H. o. t: R. H. S: R. H. P: W. r. t: W/o: WLOG: H. o. t: higher order terms R. H. S: right hand side R. H. P: right half plane W. r. t: with respect to W/ : with W/o: without WLOG: without loss of Generality Nonlinear Dynamic Control Systems , Dr. Moayed Almobaied Lecture 2
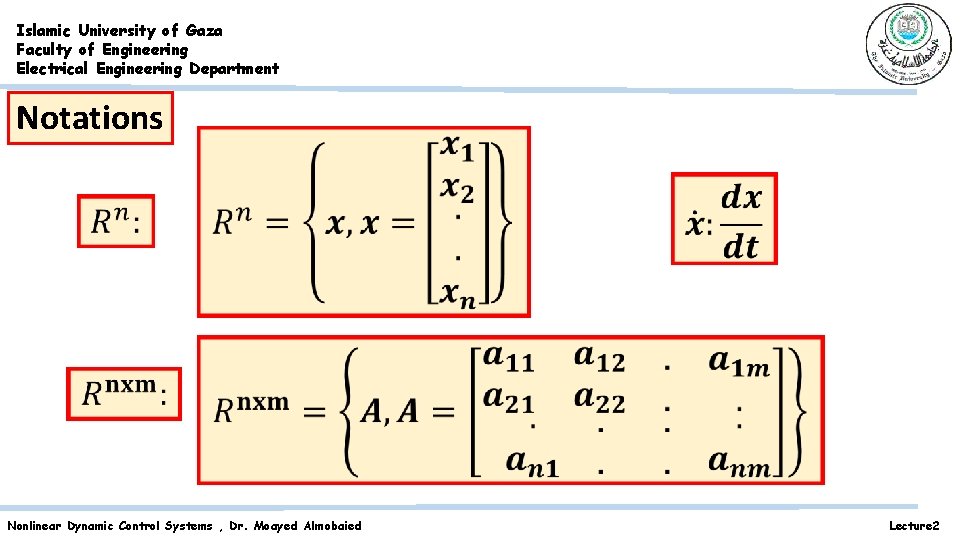
Islamic University of Gaza Faculty of Engineering Electrical Engineering Department Notations Nonlinear Dynamic Control Systems , Dr. Moayed Almobaied Lecture 2
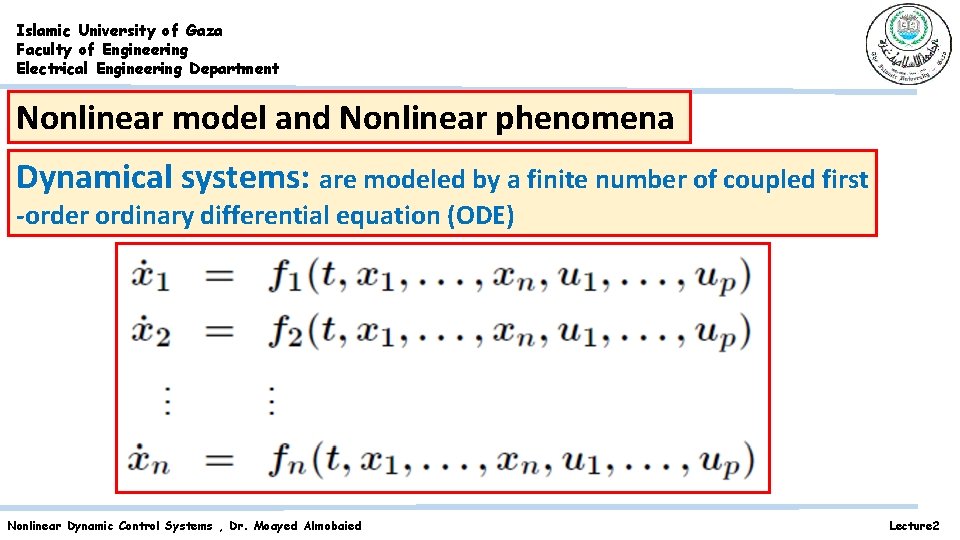
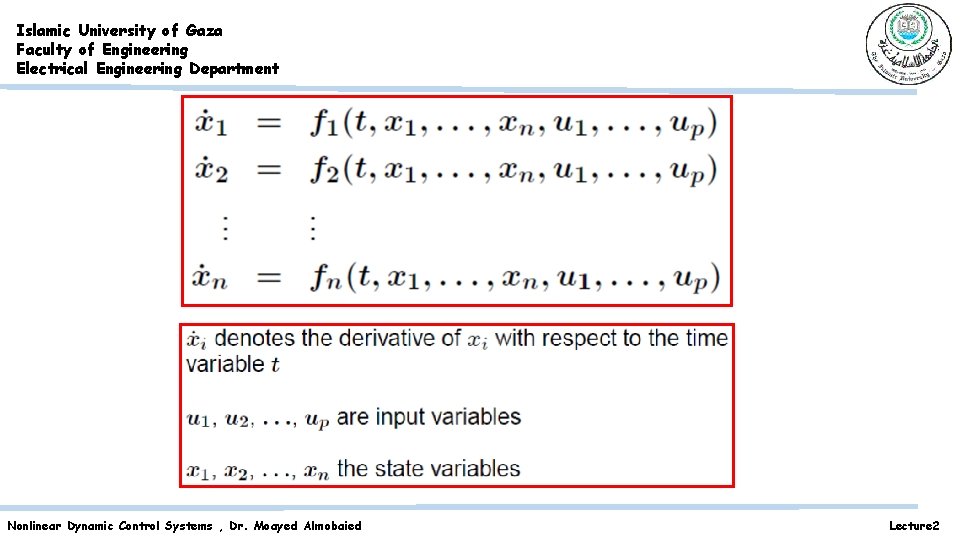
Islamic University of Gaza Faculty of Engineering Electrical Engineering Department Nonlinear model and Nonlinear phenomena Dynamical systems: are modeled by a finite number of coupled first -order ordinary differential equation (ODE) Nonlinear Dynamic Control Systems , Dr. Moayed Almobaied Lecture 2
Islamic University of Gaza Faculty of Engineering Electrical Engineering Department Nonlinear Dynamic Control Systems , Dr. Moayed Almobaied Lecture 2
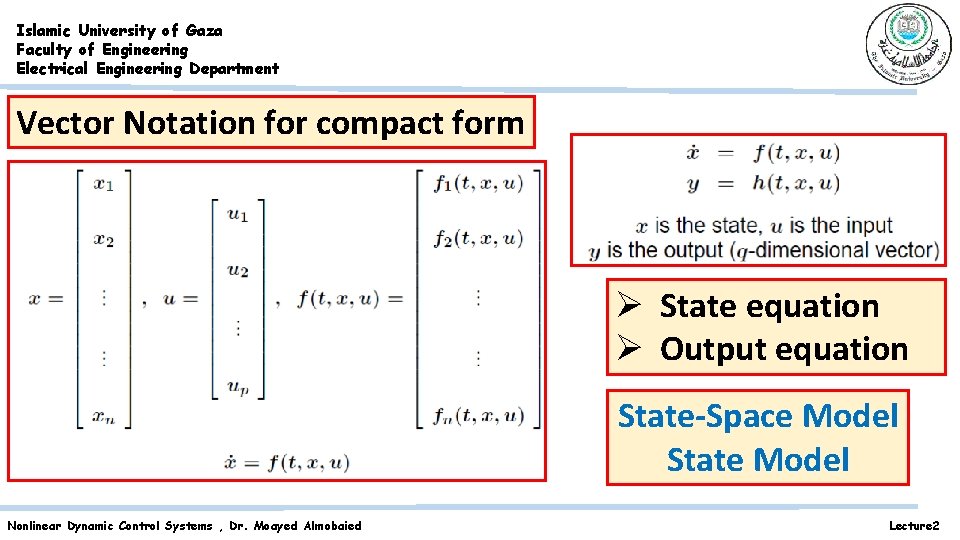
Islamic University of Gaza Faculty of Engineering Electrical Engineering Department Vector Notation for compact form Ø State equation Ø Output equation State-Space Model State Model Nonlinear Dynamic Control Systems , Dr. Moayed Almobaied Lecture 2
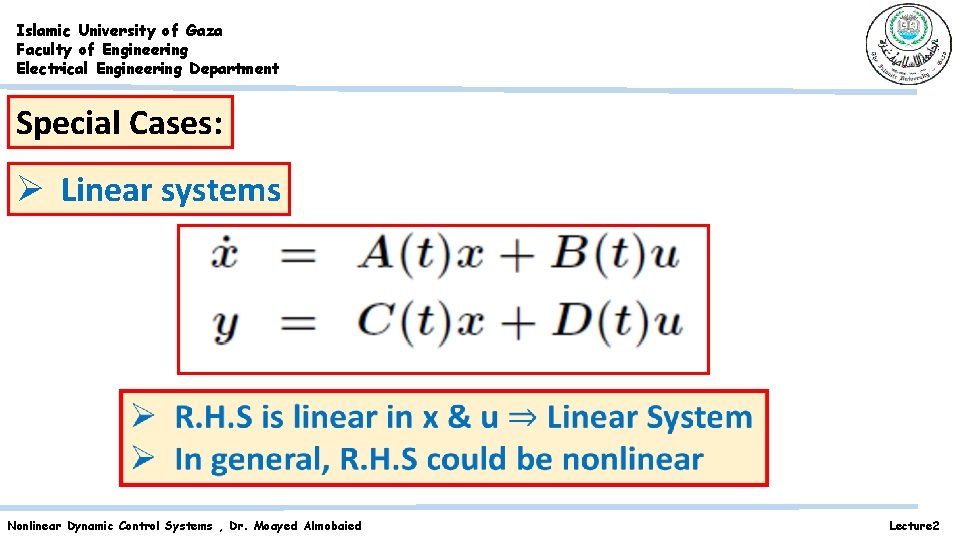
Islamic University of Gaza Faculty of Engineering Electrical Engineering Department Special Cases: Ø Linear systems Nonlinear Dynamic Control Systems , Dr. Moayed Almobaied Lecture 2
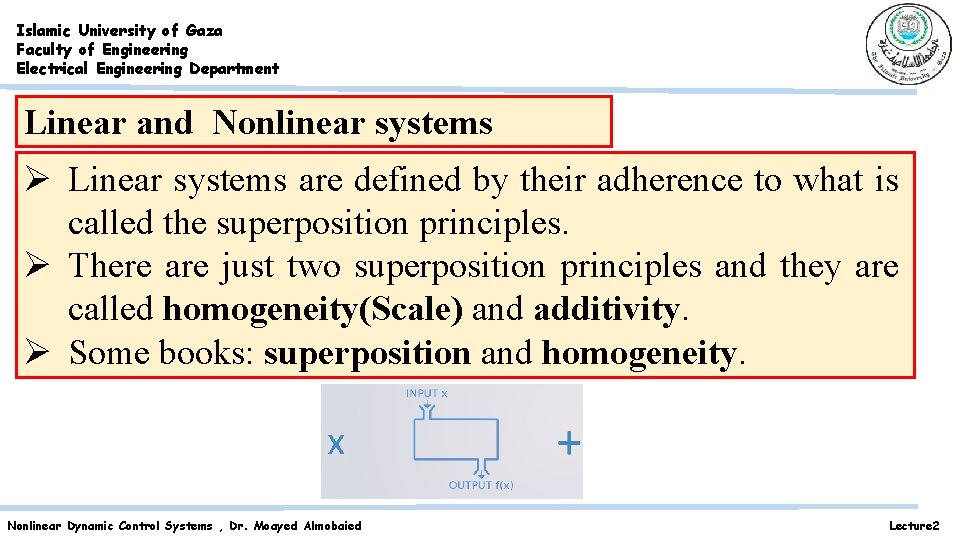
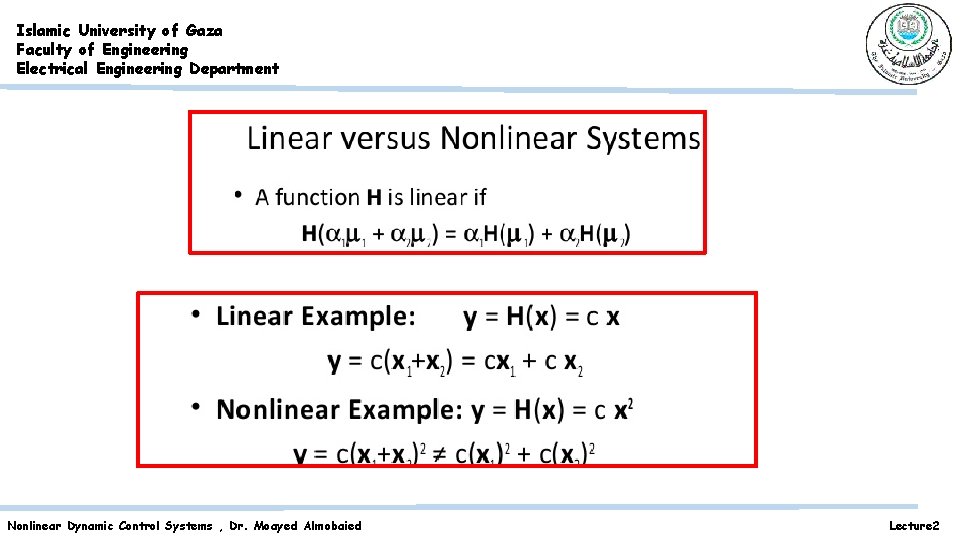
Islamic University of Gaza Faculty of Engineering Electrical Engineering Department Linear and Nonlinear systems Ø Linear systems are defined by their adherence to what is called the superposition principles. Ø There are just two superposition principles and they are called homogeneity(Scale) and additivity. Ø Some books: superposition and homogeneity. Nonlinear Dynamic Control Systems , Dr. Moayed Almobaied Lecture 2
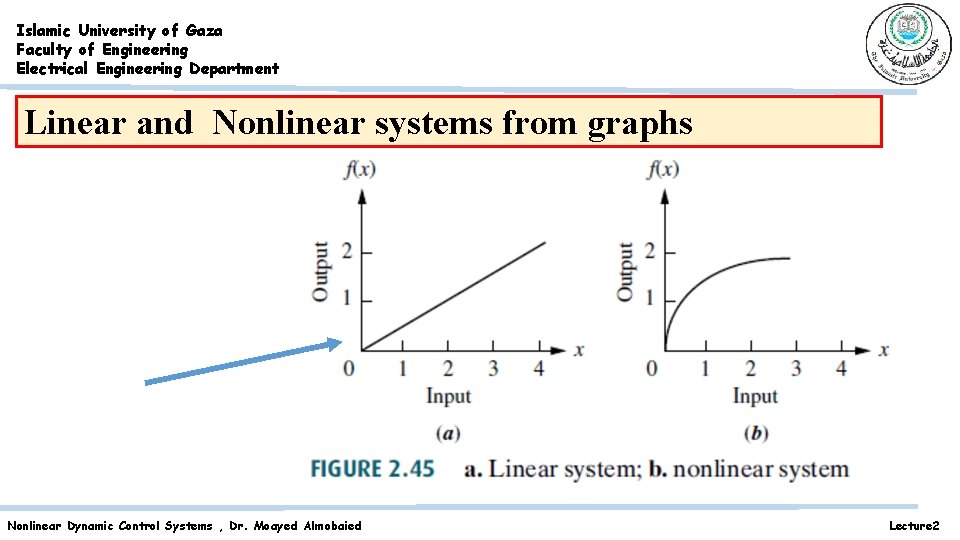
Islamic University of Gaza Faculty of Engineering Electrical Engineering Department Linear and Nonlinear systems from graphs Nonlinear Dynamic Control Systems , Dr. Moayed Almobaied Lecture 2
Islamic University of Gaza Faculty of Engineering Electrical Engineering Department Nonlinear Dynamic Control Systems , Dr. Moayed Almobaied Lecture 2
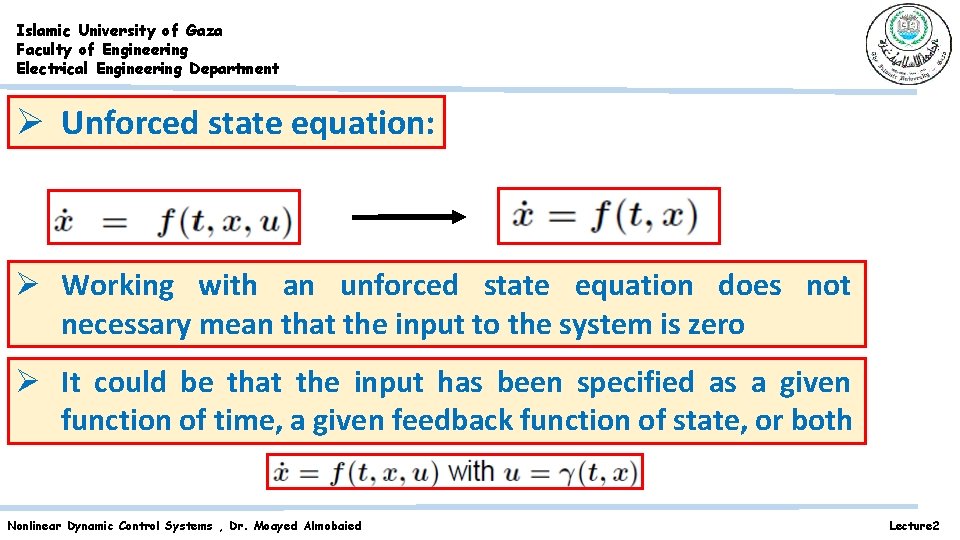
Islamic University of Gaza Faculty of Engineering Electrical Engineering Department Ø Unforced state equation: Ø Working with an unforced state equation does not necessary mean that the input to the system is zero Ø It could be that the input has been specified as a given function of time, a given feedback function of state, or both Nonlinear Dynamic Control Systems , Dr. Moayed Almobaied Lecture 2
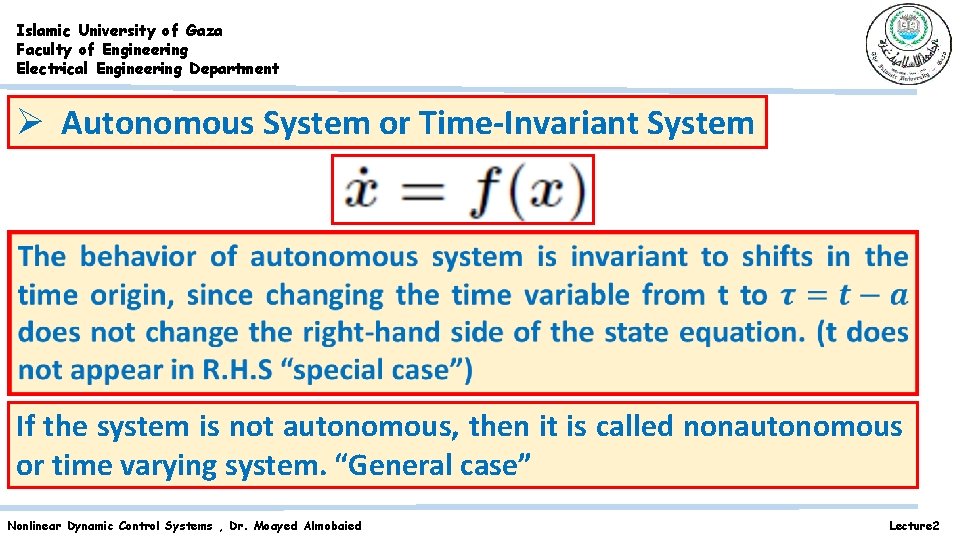
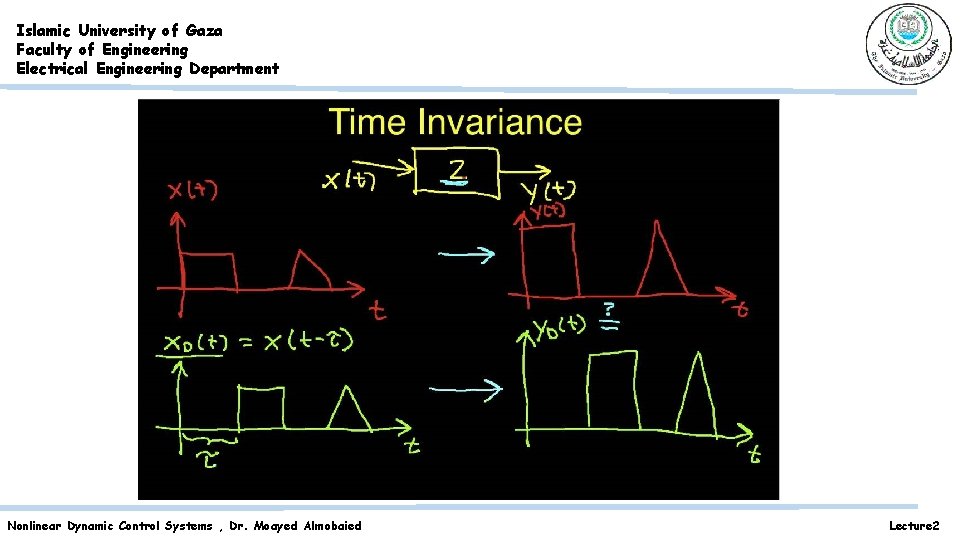
Islamic University of Gaza Faculty of Engineering Electrical Engineering Department Ø Autonomous System or Time-Invariant System If the system is not autonomous, then it is called nonautonomous or time varying system. “General case” Nonlinear Dynamic Control Systems , Dr. Moayed Almobaied Lecture 2
Islamic University of Gaza Faculty of Engineering Electrical Engineering Department Nonlinear Dynamic Control Systems , Dr. Moayed Almobaied Lecture 2
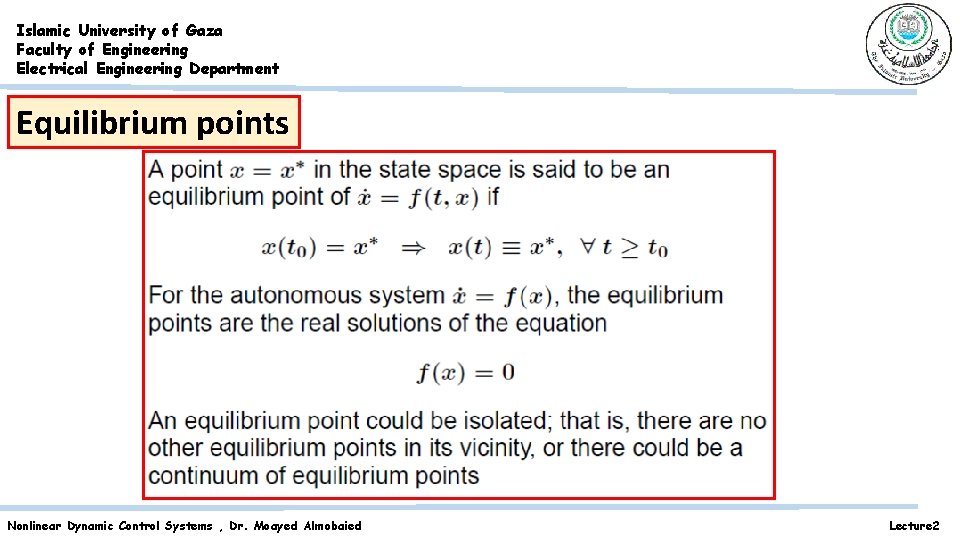
Islamic University of Gaza Faculty of Engineering Electrical Engineering Department Equilibrium points Nonlinear Dynamic Control Systems , Dr. Moayed Almobaied Lecture 2
Islamic University of Gaza Faculty of Engineering Electrical Engineering Department Nonlinear Dynamic Control Systems , Dr. Moayed Almobaied Lecture 2
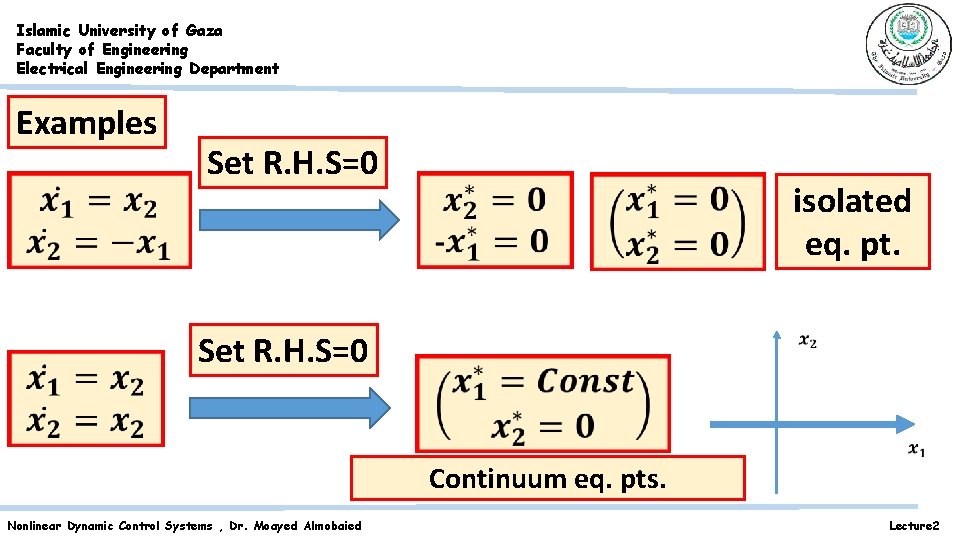
Islamic University of Gaza Faculty of Engineering Electrical Engineering Department Examples Set R. H. S=0 isolated eq. pt. Set R. H. S=0 Continuum eq. pts. Nonlinear Dynamic Control Systems , Dr. Moayed Almobaied Lecture 2
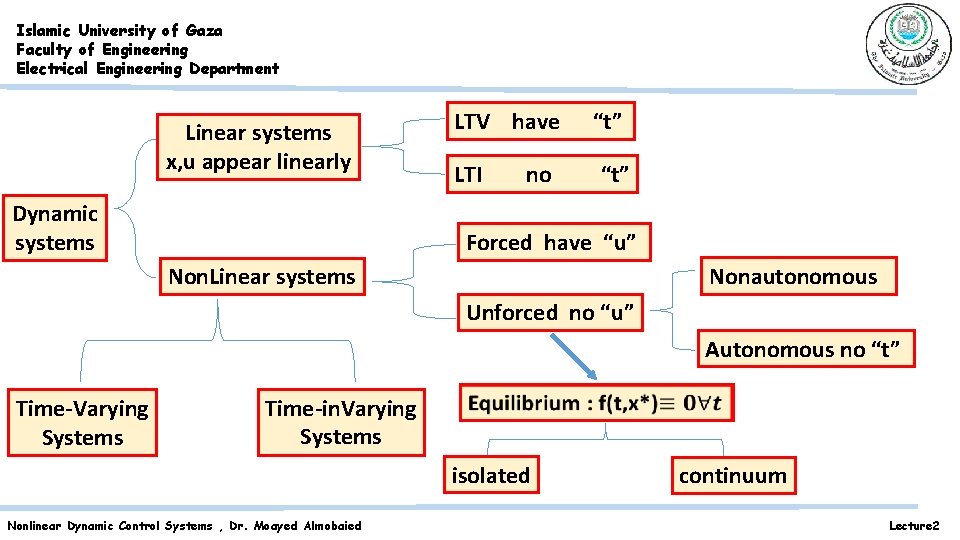
Islamic University of Gaza Faculty of Engineering Electrical Engineering Department Linear systems x, u appear linearly Dynamic systems LTV have LTI no “t” Forced have “u” Nonautonomous Non. Linear systems Unforced no “u” Autonomous no “t” Time-Varying Systems Time-in. Varying Systems isolated Nonlinear Dynamic Control Systems , Dr. Moayed Almobaied continuum Lecture 2
Islamic University of Gaza Faculty of Engineering Electrical Engineering Department Linearization A common engineering practice in analyzing a nonlinear system is to linearize it about some nominal operating point and analyze the resulting linear model. What are the limitations of linearization? Since linearization is an approximation in the neighborhood of an operating point, it can only predict the “local” behavior of the nonlinear system in the vicinity of that point. It cannot predict the “nonlocal” or “global” behavior. Ø There are “essentially nonlinear phenomena” that can take place only in the presence of nonlinearity. Nonlinear Dynamic Control Systems , Dr. Moayed Almobaied Lecture 2
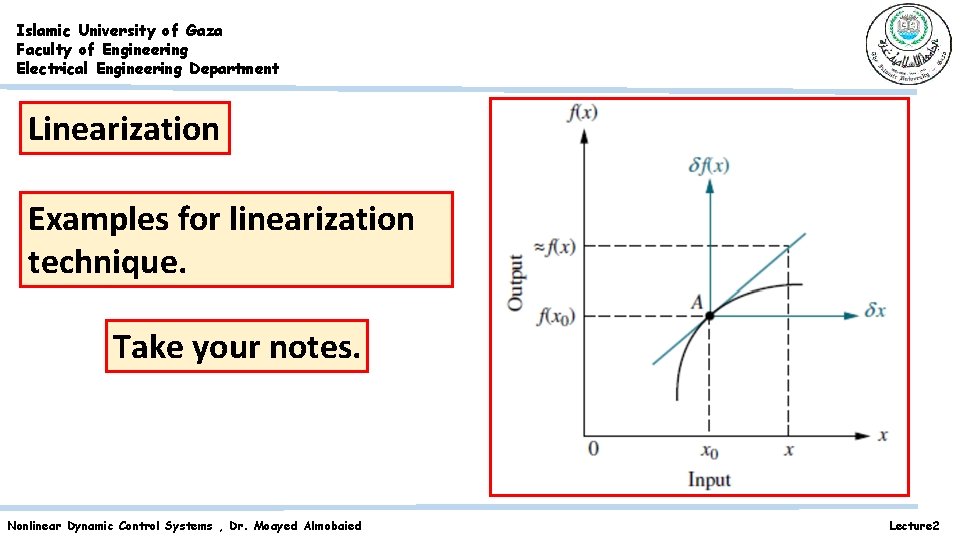
Islamic University of Gaza Faculty of Engineering Electrical Engineering Department Linearization Examples for linearization technique. Take your notes. Nonlinear Dynamic Control Systems , Dr. Moayed Almobaied Lecture 2
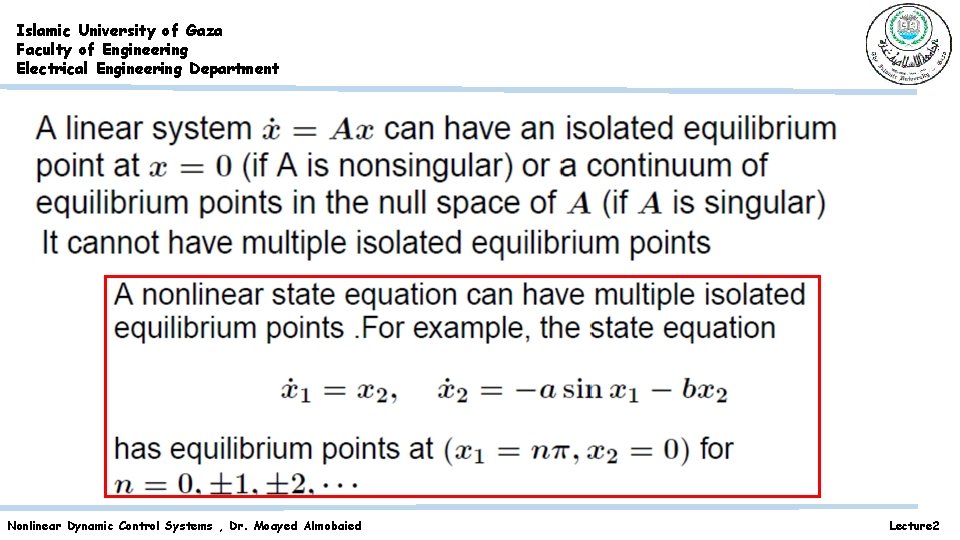
Islamic University of Gaza Faculty of Engineering Electrical Engineering Department Essentially Nonlinear Phenomena Ø Finite Escape Time State goes to infinity in finite time (Linear Systems ? ) Ø Multiple Isolated Equilibria Nonlinear systems has more than one isolated equilibrium points. . The state convergence depends on the initial conditions. (Linear Systems ? ) Nonlinear Dynamic Control Systems , Dr. Moayed Almobaied Lecture 2
Islamic University of Gaza Faculty of Engineering Electrical Engineering Department Ø Limit Cycles Go into an oscillation of fixed magnitude and frequency, irrespective of the initial state. (Linear Systems ? ) Ø Subharmonic, almost-periodic oscillations Oscillation frequencies are submultiples or multiples of the input frequency, it may even generate an almost-periodic oscillation. (Linear Systems ? ) Nonlinear Dynamic Control Systems , Dr. Moayed Almobaied Lecture 2
Islamic University of Gaza Faculty of Engineering Electrical Engineering Department Ø Chaos Complicated steady-state behavior focusing on the behavior of dynamical systems that are highly sensitive to initial conditions. (sometimes randomness despite the deterministic nature of the system) Ø Multiple modes of behavior • Unforced systems may have more than one limit cycle. • Forced systems with periodic excitation may exhibit harmonic, subharmonic, or complicated steady-state behavior, depending upon the amplitude and frequency of the input. • Exhibit discontinuity jump even though under smoothly changed input. Nonlinear Dynamic Control Systems , Dr. Moayed Almobaied Lecture 2
Islamic University of Gaza Faculty of Engineering Electrical Engineering Department In this book, we will encounter only the first three of these phenomena: Ø Finite Escape Time Ø Multiple Isolated Equilibria Ø Limit Cycles Nonlinear Dynamic Control Systems , Dr. Moayed Almobaied Lecture 2
Islamic University of Gaza Faculty of Engineering Electrical Engineering Department Nonlinear Dynamic Control Systems , Dr. Moayed Almobaied Lecture 2
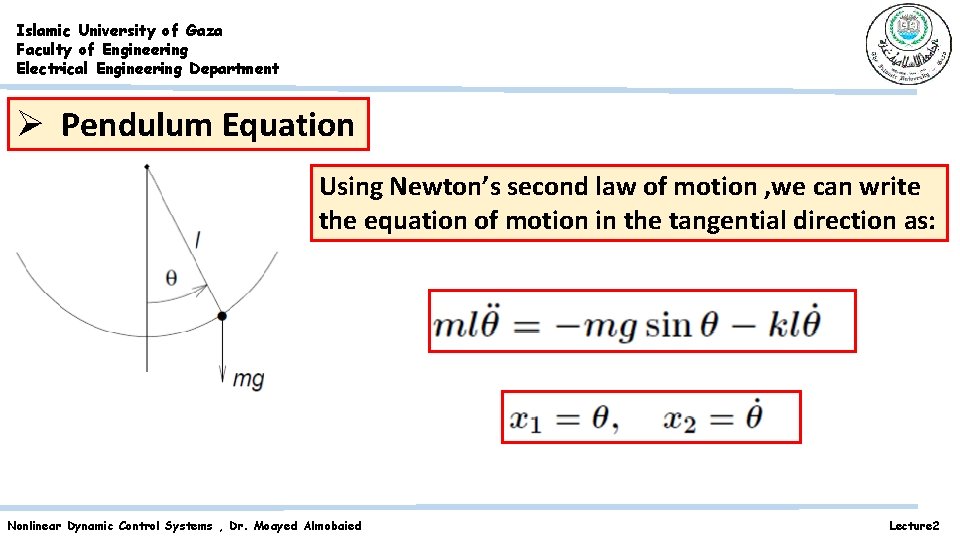
Islamic University of Gaza Faculty of Engineering Electrical Engineering Department Ø Pendulum Equation Using Newton’s second law of motion , we can write the equation of motion in the tangential direction as: Nonlinear Dynamic Control Systems , Dr. Moayed Almobaied Lecture 2
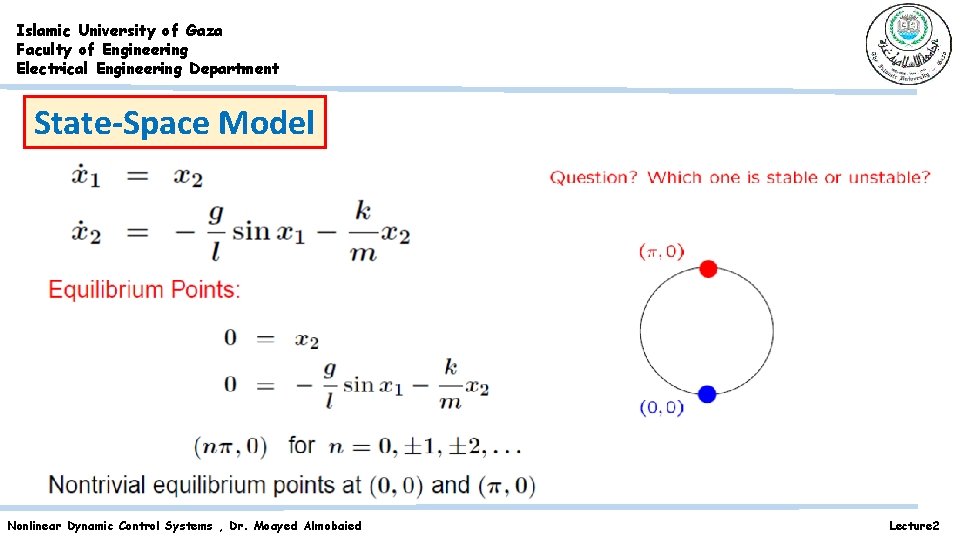
Islamic University of Gaza Faculty of Engineering Electrical Engineering Department State-Space Model Nonlinear Dynamic Control Systems , Dr. Moayed Almobaied Lecture 2
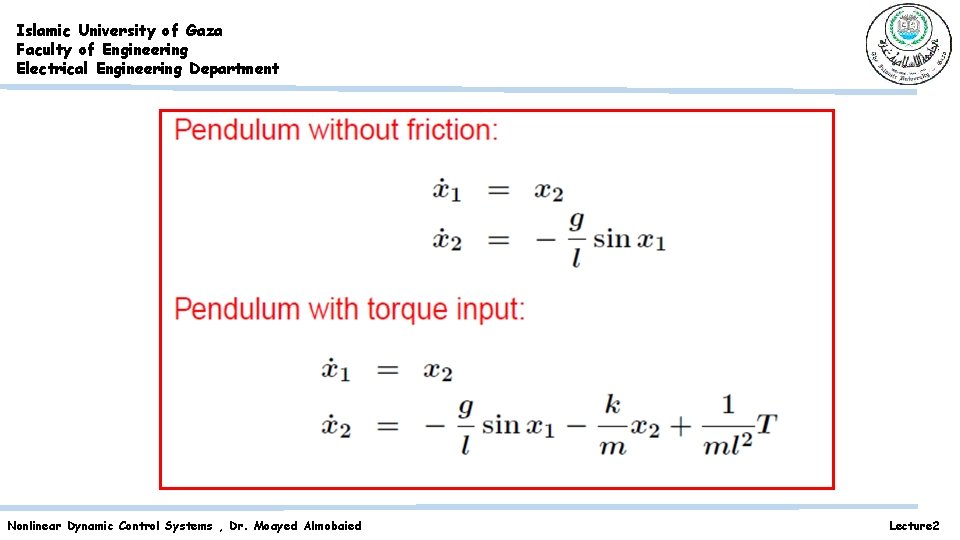
Islamic University of Gaza Faculty of Engineering Electrical Engineering Department Nonlinear Dynamic Control Systems , Dr. Moayed Almobaied Lecture 2
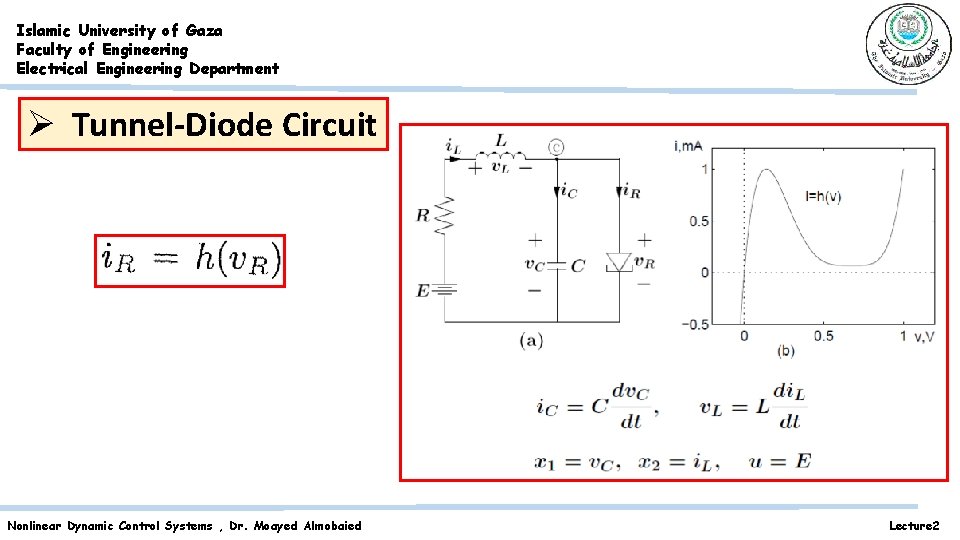
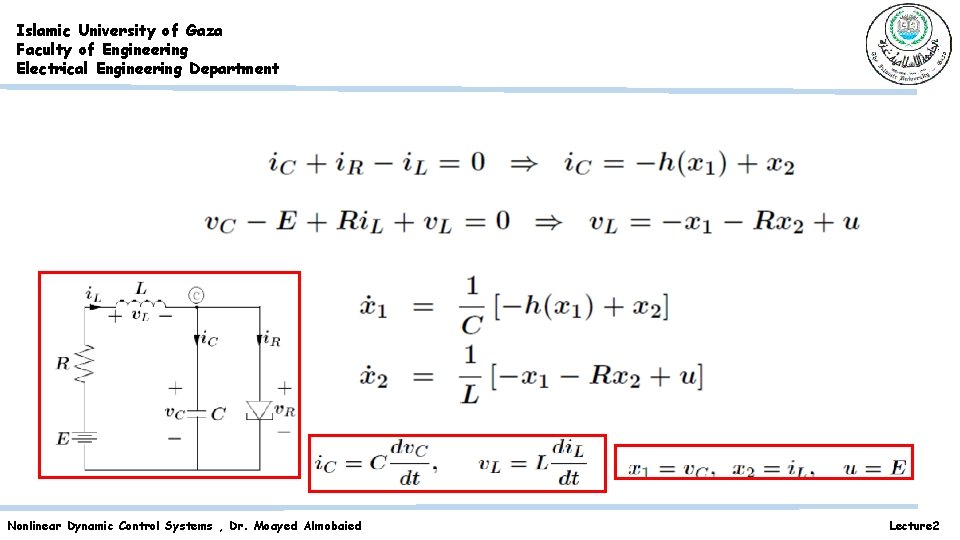
Islamic University of Gaza Faculty of Engineering Electrical Engineering Department Ø Tunnel-Diode Circuit Nonlinear Dynamic Control Systems , Dr. Moayed Almobaied Lecture 2
Islamic University of Gaza Faculty of Engineering Electrical Engineering Department Nonlinear Dynamic Control Systems , Dr. Moayed Almobaied Lecture 2
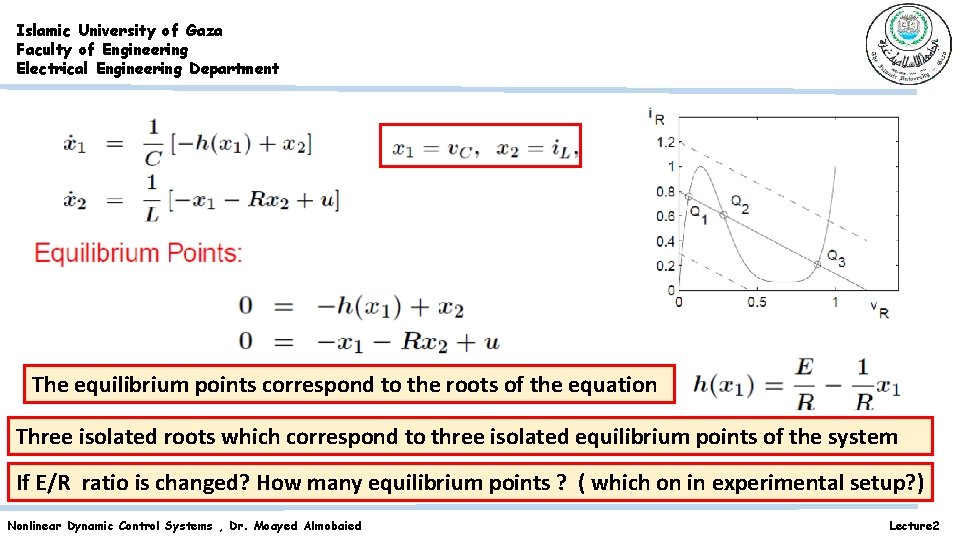
Islamic University of Gaza Faculty of Engineering Electrical Engineering Department The equilibrium points correspond to the roots of the equation Three isolated roots which correspond to three isolated equilibrium points of the system If E/R ratio is changed? How many equilibrium points ? ( which on in experimental setup? ) Nonlinear Dynamic Control Systems , Dr. Moayed Almobaied Lecture 2
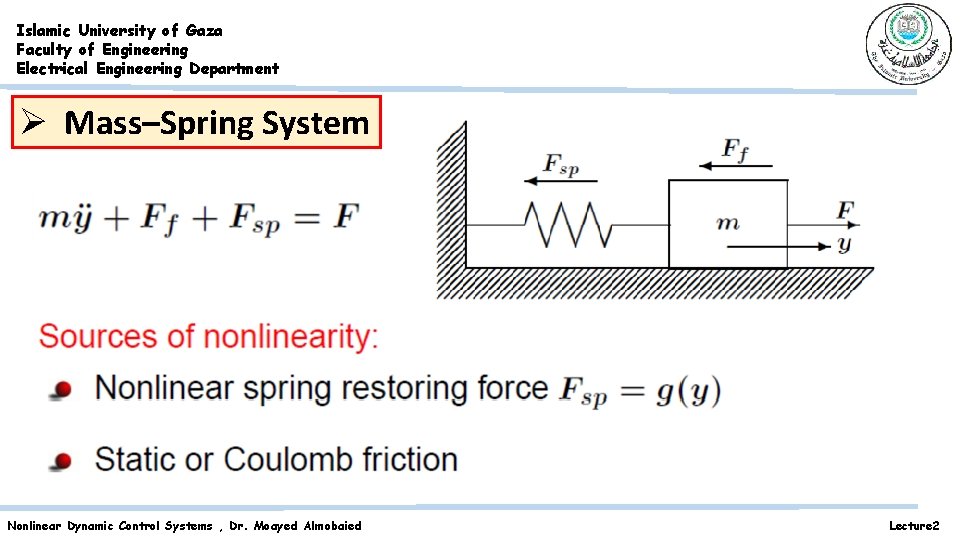
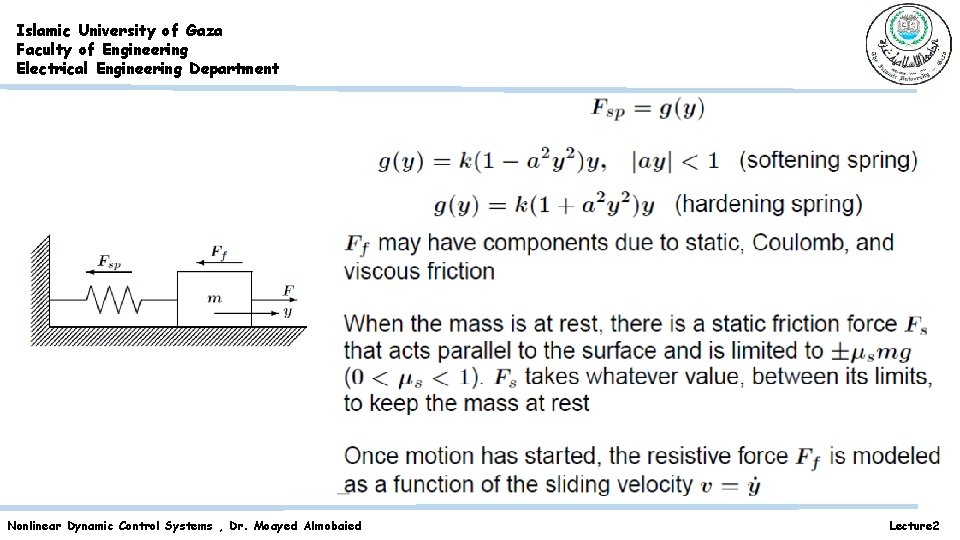
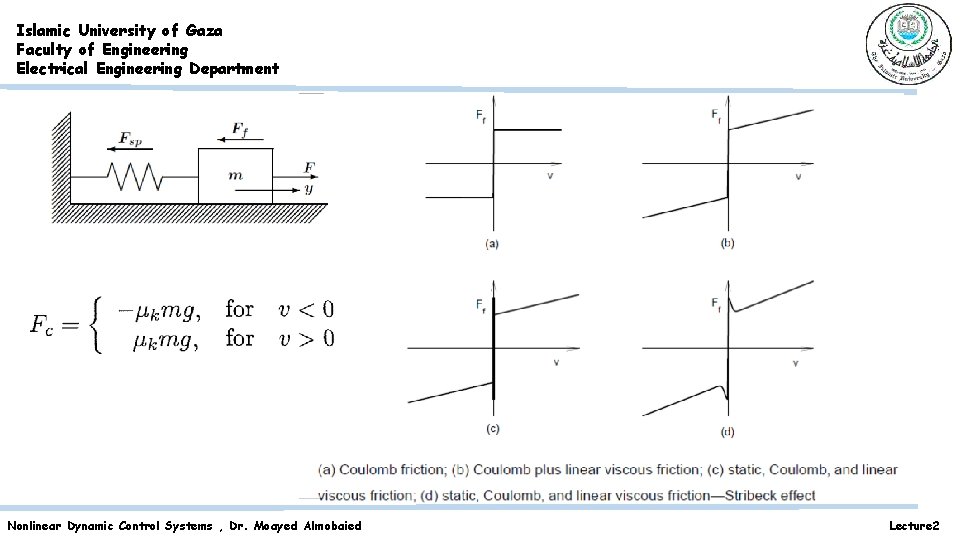
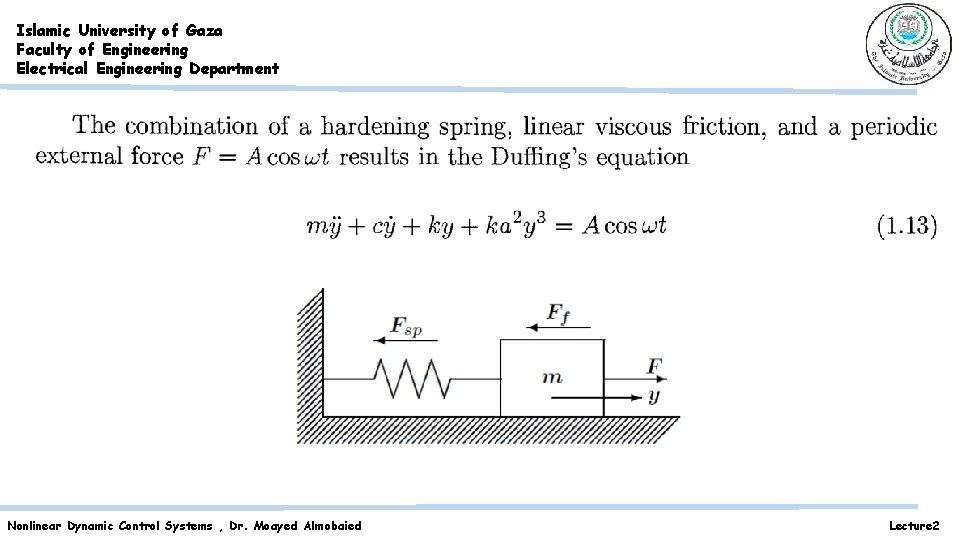
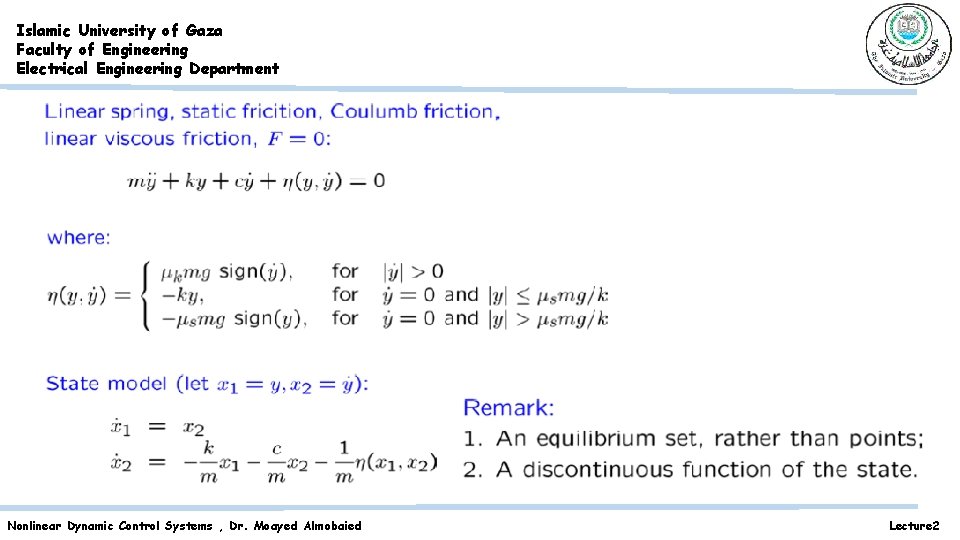
Islamic University of Gaza Faculty of Engineering Electrical Engineering Department Ø Mass–Spring System Nonlinear Dynamic Control Systems , Dr. Moayed Almobaied Lecture 2
Islamic University of Gaza Faculty of Engineering Electrical Engineering Department Nonlinear Dynamic Control Systems , Dr. Moayed Almobaied Lecture 2
Islamic University of Gaza Faculty of Engineering Electrical Engineering Department Nonlinear Dynamic Control Systems , Dr. Moayed Almobaied Lecture 2
Islamic University of Gaza Faculty of Engineering Electrical Engineering Department Nonlinear Dynamic Control Systems , Dr. Moayed Almobaied Lecture 2
Islamic University of Gaza Faculty of Engineering Electrical Engineering Department Nonlinear Dynamic Control Systems , Dr. Moayed Almobaied Lecture 2
Islamic University of Gaza Faculty of Engineering Electrical Engineering Department Nonlinear Dynamic Control Systems , Dr. Moayed Almobaied Lecture 2
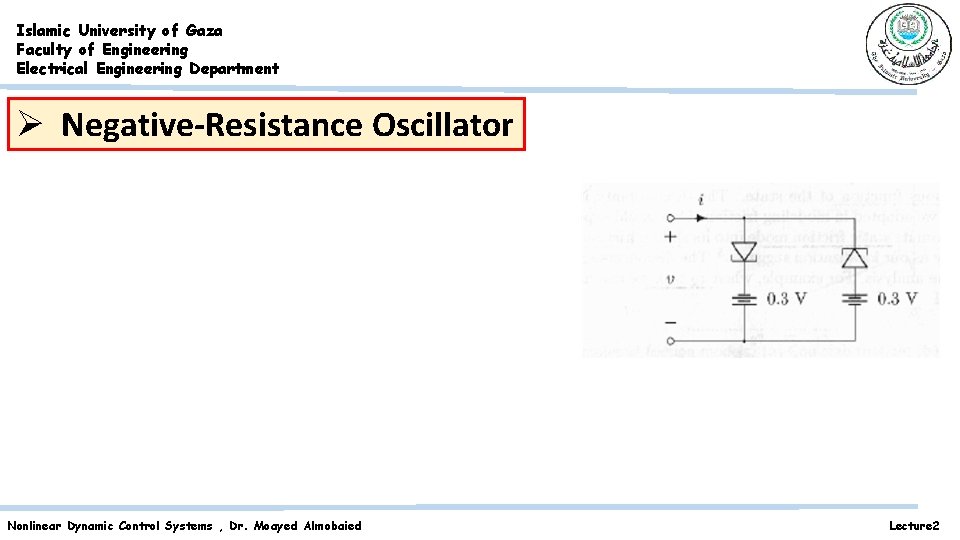
Islamic University of Gaza Faculty of Engineering Electrical Engineering Department Ø Negative-Resistance Oscillator Nonlinear Dynamic Control Systems , Dr. Moayed Almobaied Lecture 2
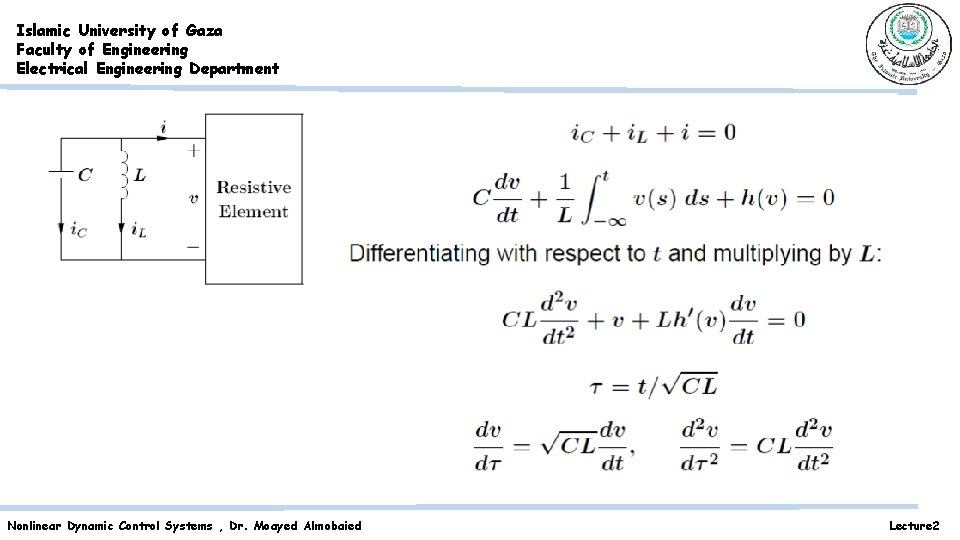
Islamic University of Gaza Faculty of Engineering Electrical Engineering Department Nonlinear Dynamic Control Systems , Dr. Moayed Almobaied Lecture 2
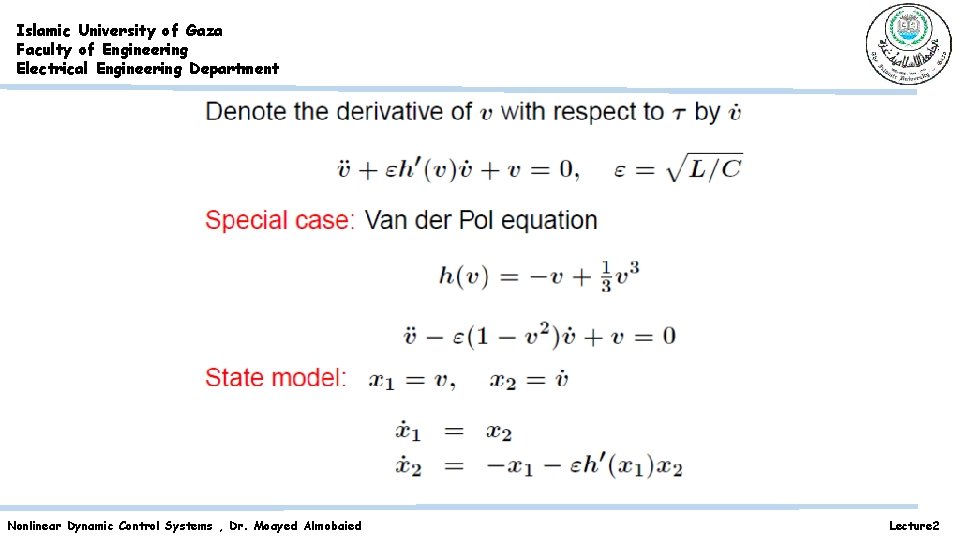
Islamic University of Gaza Faculty of Engineering Electrical Engineering Department Nonlinear Dynamic Control Systems , Dr. Moayed Almobaied Lecture 2
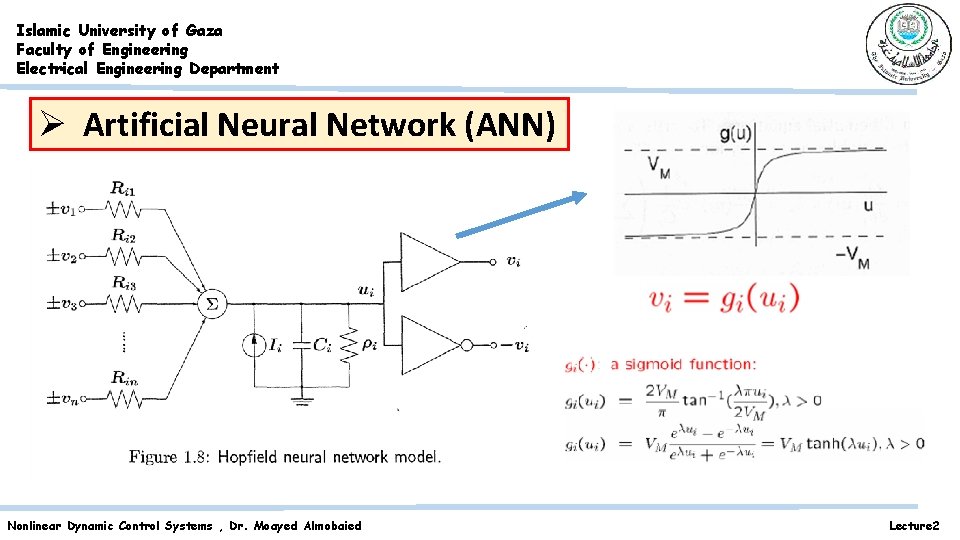
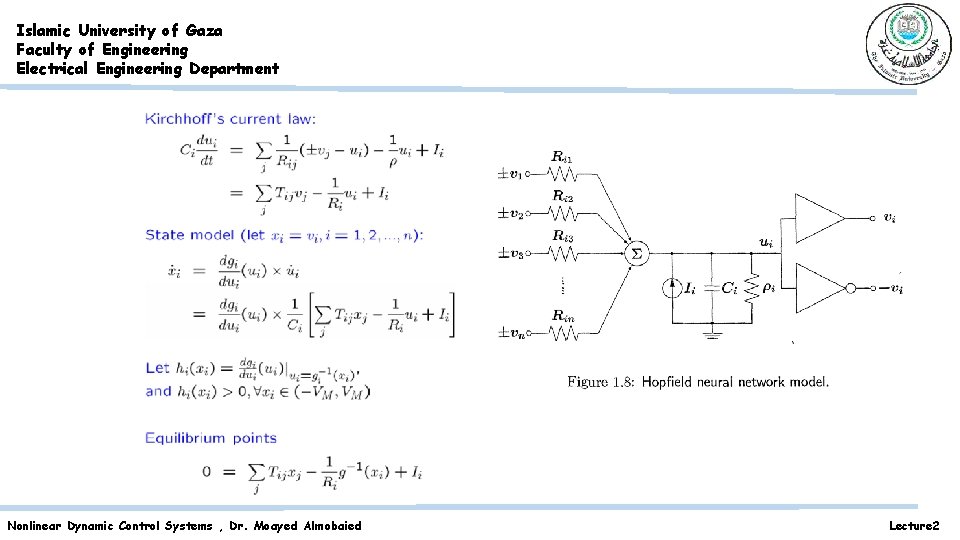
Islamic University of Gaza Faculty of Engineering Electrical Engineering Department Ø Artificial Neural Network (ANN) Nonlinear Dynamic Control Systems , Dr. Moayed Almobaied Lecture 2
Islamic University of Gaza Faculty of Engineering Electrical Engineering Department Nonlinear Dynamic Control Systems , Dr. Moayed Almobaied Lecture 2
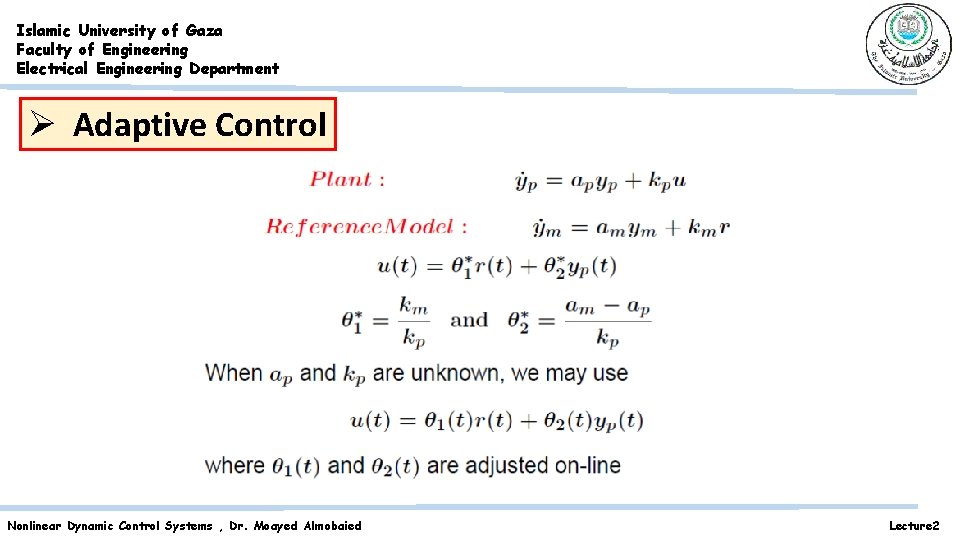
Islamic University of Gaza Faculty of Engineering Electrical Engineering Department Ø Adaptive Control Nonlinear Dynamic Control Systems , Dr. Moayed Almobaied Lecture 2
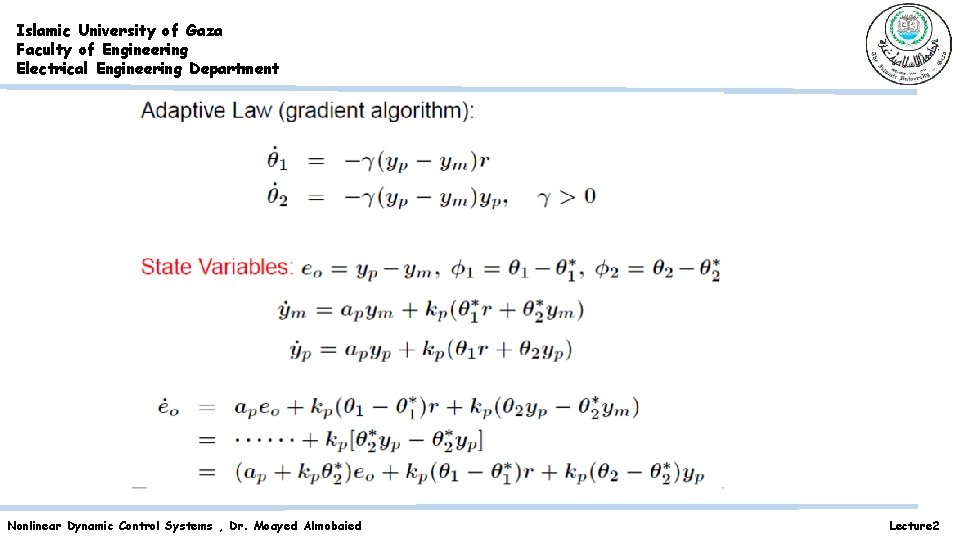
Islamic University of Gaza Faculty of Engineering Electrical Engineering Department Nonlinear Dynamic Control Systems , Dr. Moayed Almobaied Lecture 2
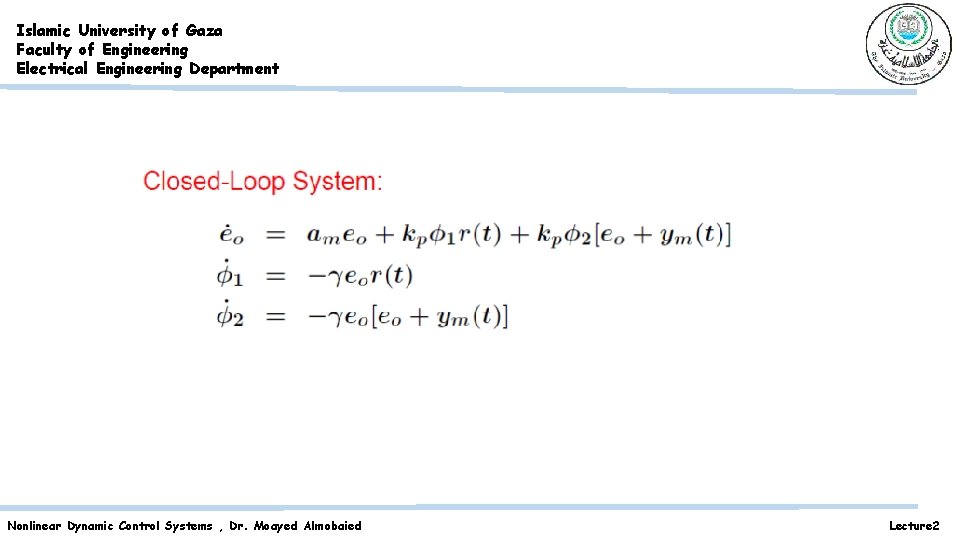
Islamic University of Gaza Faculty of Engineering Electrical Engineering Department Nonlinear Dynamic Control Systems , Dr. Moayed Almobaied Lecture 2
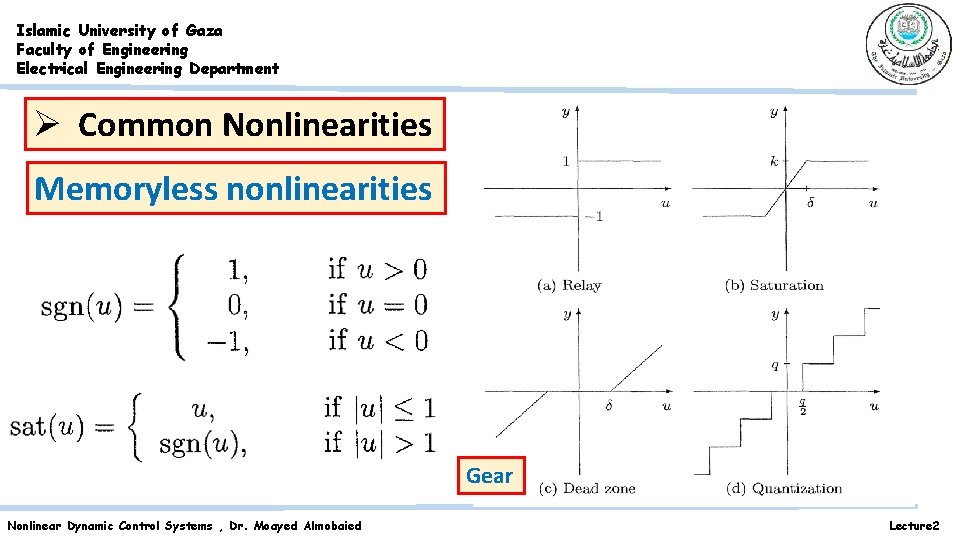
Islamic University of Gaza Faculty of Engineering Electrical Engineering Department Ø Common Nonlinearities Memoryless nonlinearities Gear Nonlinear Dynamic Control Systems , Dr. Moayed Almobaied Lecture 2
Islamic University of Gaza Faculty of Engineering Electrical Engineering Department Nonlinear Dynamic Control Systems , Dr. Moayed Almobaied Lecture 2
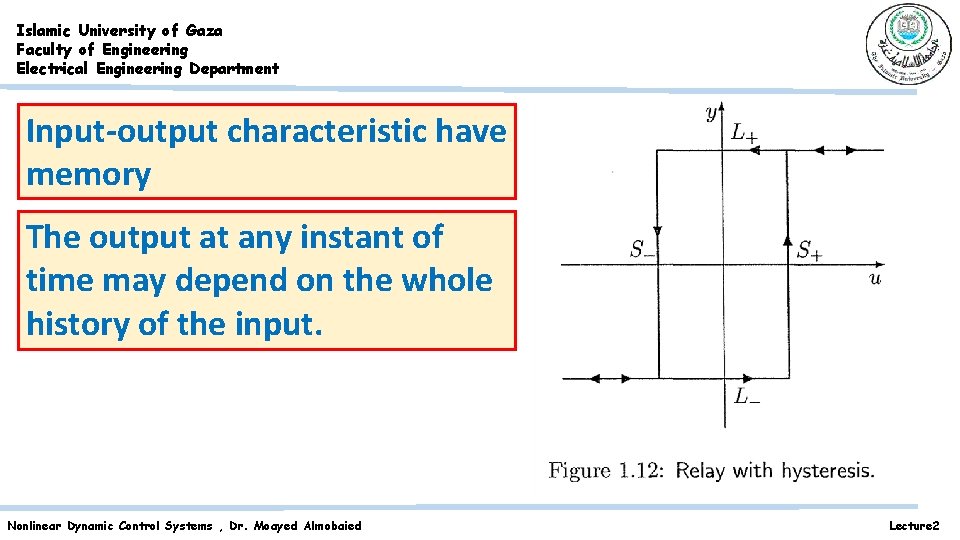
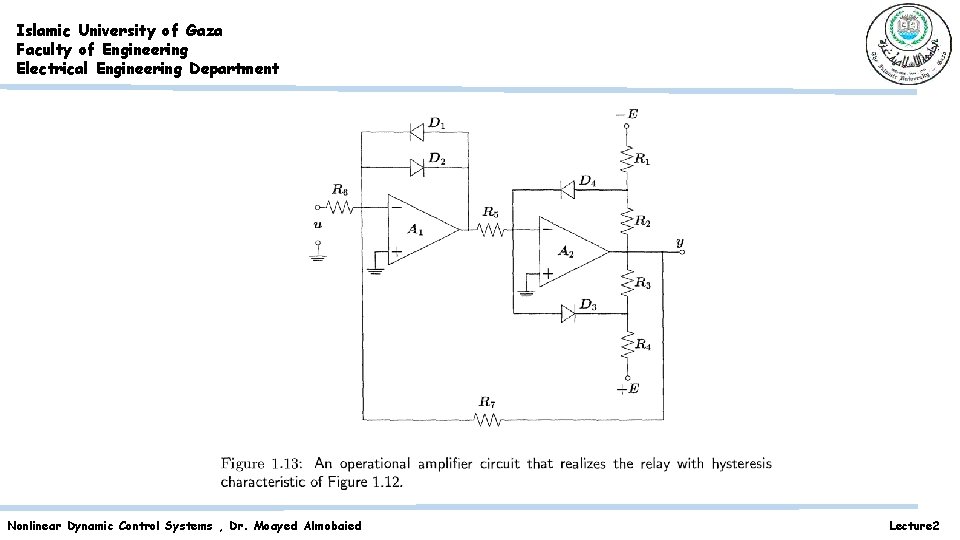
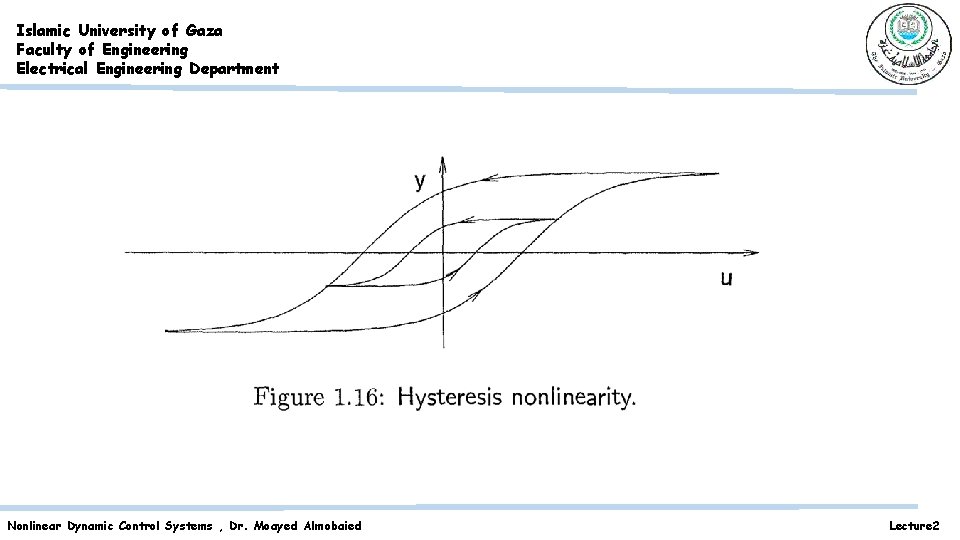
Islamic University of Gaza Faculty of Engineering Electrical Engineering Department Input-output characteristic have memory The output at any instant of time may depend on the whole history of the input. Nonlinear Dynamic Control Systems , Dr. Moayed Almobaied Lecture 2
Islamic University of Gaza Faculty of Engineering Electrical Engineering Department Nonlinear Dynamic Control Systems , Dr. Moayed Almobaied Lecture 2
Islamic University of Gaza Faculty of Engineering Electrical Engineering Department Nonlinear Dynamic Control Systems , Dr. Moayed Almobaied Lecture 2
Islamic University of Gaza Faculty of Engineering Electrical Engineering Department Ø H. W 1. 5, 1. 6, 1. 8, 1. 18 Ø Deadline : 10/10/2018 Nonlinear Dynamic Control Systems , Dr. Moayed Almobaied Lecture 2