TEL AVIV UNIVERSITY FACULTY OF ENGINEERING SCHOOL OF
- Slides: 18
TEL AVIV UNIVERSITY FACULTY OF ENGINEERING SCHOOL OF MECHANICAL ENGINEERING Deployable Tensegrity Robots Offer Shai Uri Ben Hanan Yefim Mor Michael Slovotin Leon Ginzburg Avner Bronfeld Itay Tehori
TENSEGRITY SYSTEMS
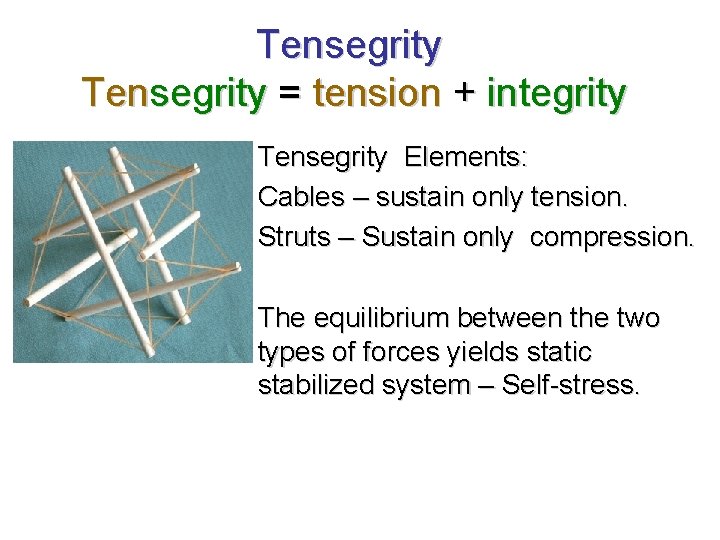
Tensegrity = tension + integrity Tensegrity Elements: Cables – sustain only tension. Struts – Sustain only compression. The equilibrium between the two types of forces yields static stabilized system – Self-stress.
We are looking for structures that: 1. In generic configuration the self-stress is in all the elements. 2. There are no failing joints. 3. Changing the position of any element can bring to a singular position.
Structures that satisfy the three conditions are Assur structures (graphs) and only them. 1. Recski A. and Shai O. , "Tensegrity Frameworks in the One. Dimensional Space", accepted for publication in European Journal of Combinatorics. 2. Servatius B. , Shai O. and Whiteley W. , “Combinatorial Characterization of the Assur Graphs from Engineering”, accepted for publication in European Journal of Combinatorics. 3. Servatius B. , Shai O. and Whiteley W. , “Geometric Properties of Assur Graphs”, submitted to the European Journal of Combinatorics
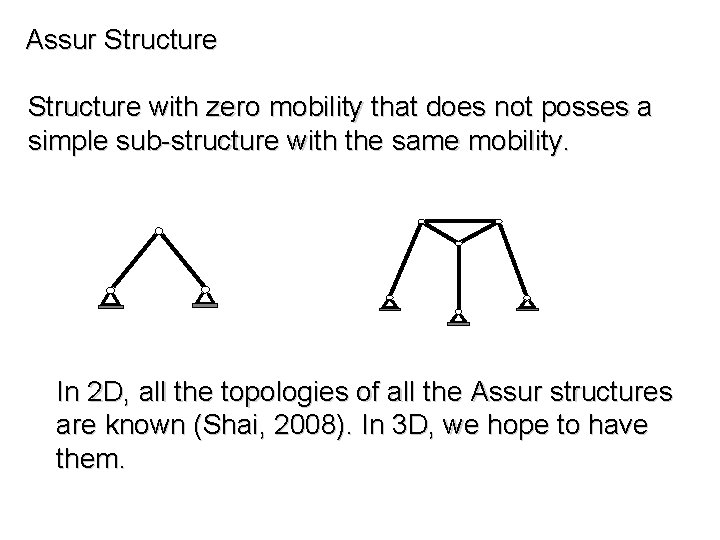
Assur Structure with zero mobility that does not posses a simple sub-structure with the same mobility. In 2 D, all the topologies of all the Assur structures are known (Shai, 2008). In 3 D, we hope to have them.
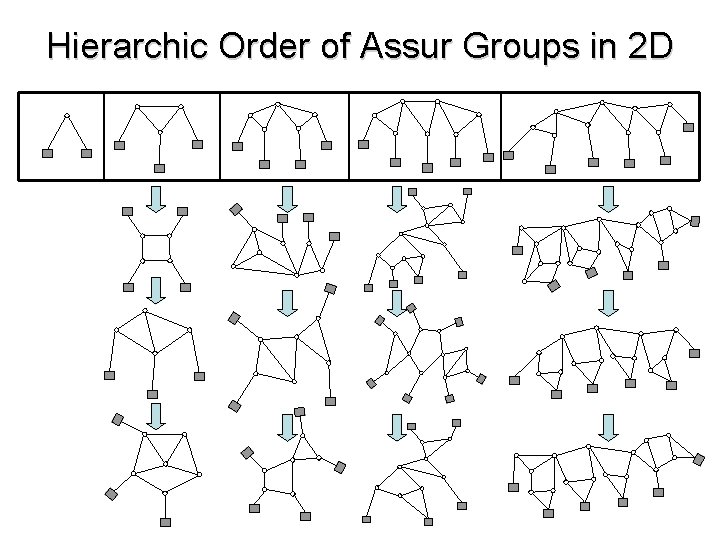
Hierarchic Order of Assur Groups in 2 D
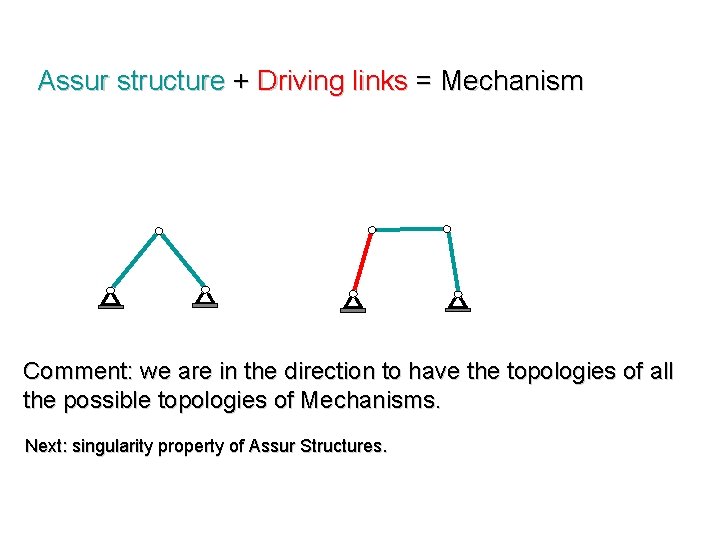
Assur structure + Driving links = Mechanism Comment: we are in the direction to have the topologies of all the possible topologies of Mechanisms. Next: singularity property of Assur Structures.
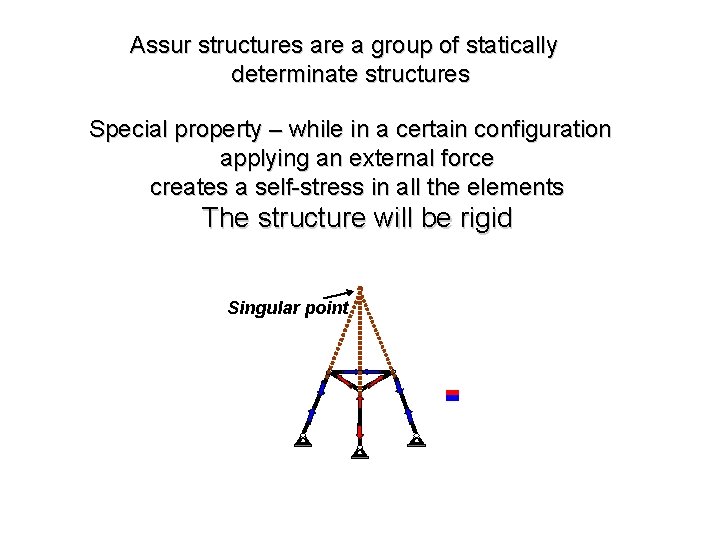
Assur structures are a group of statically determinate structures Special property – while in a certain configuration applying an external force creates a self-stress in all the elements The structure will be rigid Singular point
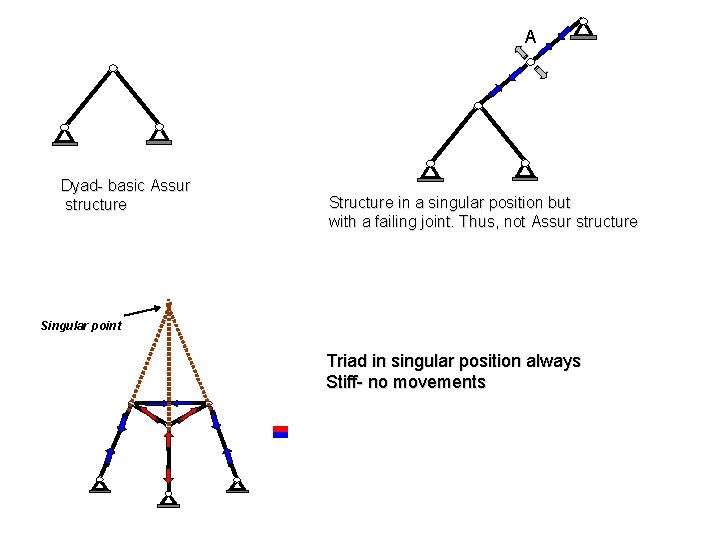
A Dyad- basic Assur structure Structure in a singular position but with a failing joint. Thus, not Assur structure Singular point Triad in singular position always Stiff- no movements
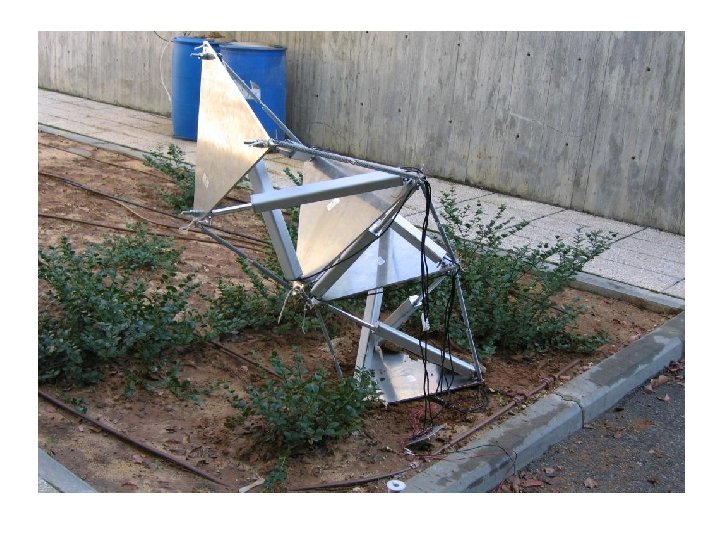
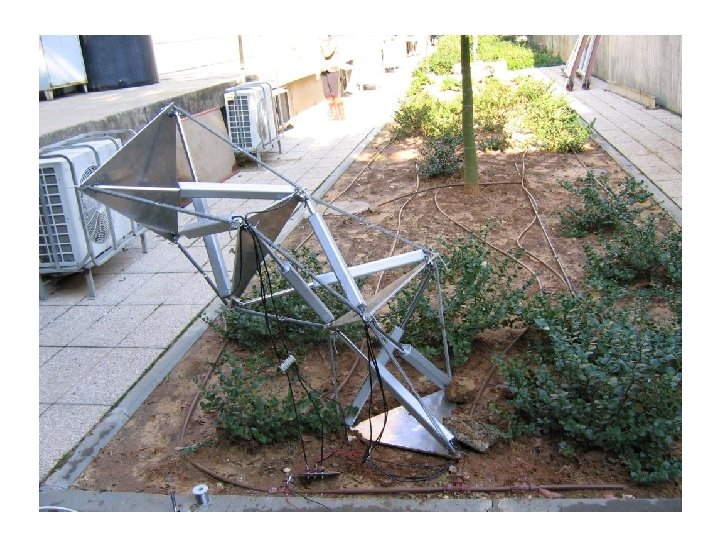
Deployable Tensegrity Structures (Assur) The device employs all the properties introduced before.
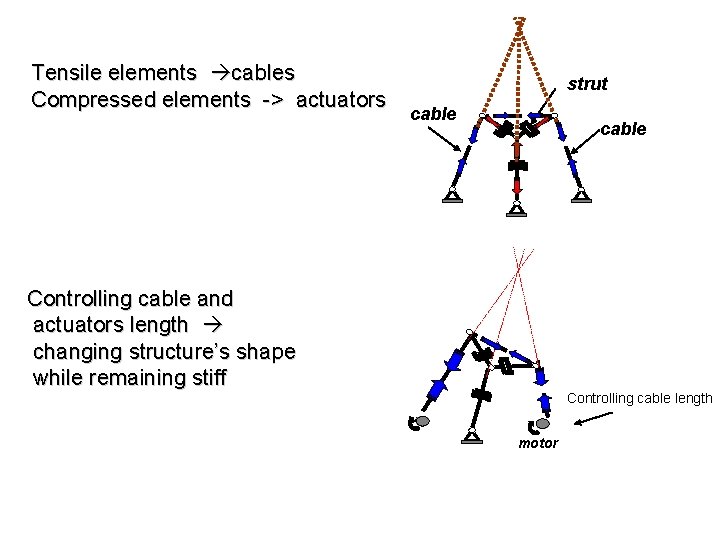
Tensile elements cables Compressed elements -> actuators strut cable Controlling cable and actuators length changing structure’s shape while remaining stiff Controlling cable length motor
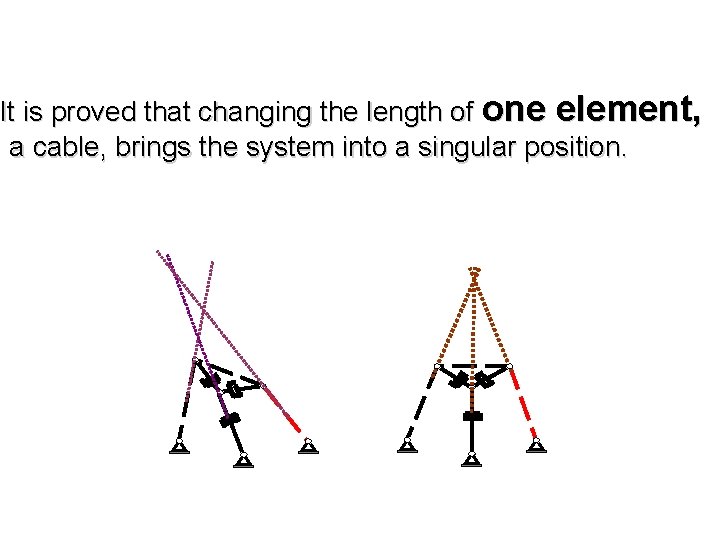
It is proved that changing the length of one element, a cable, brings the system into a singular position.
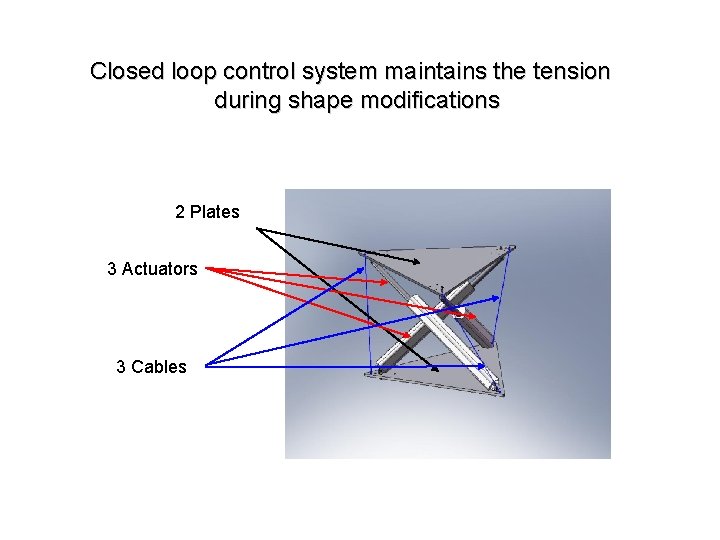
Closed loop control system maintains the tension during shape modifications 2 Plates 3 Actuators 3 Cables
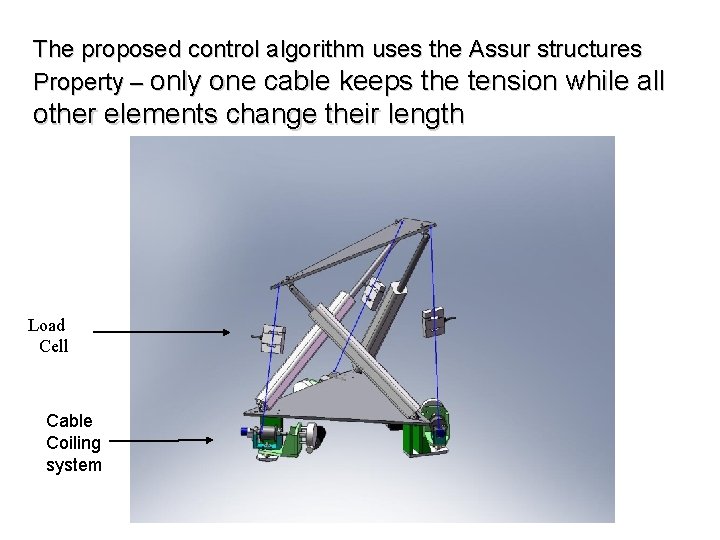
The proposed control algorithm uses the Assur structures Property – only one cable keeps the tension while all other elements change their length Load Cell Cable Coiling system
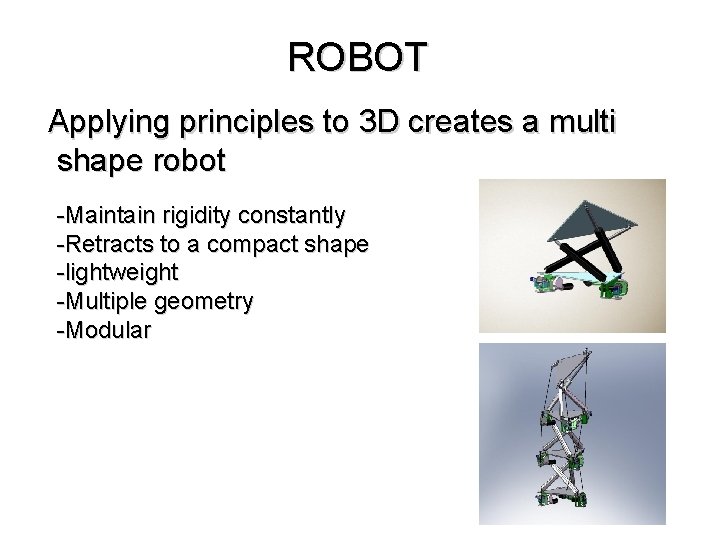
ROBOT Applying principles to 3 D creates a multi shape robot -Maintain rigidity constantly -Retracts to a compact shape -lightweight -Multiple geometry -Modular