System Modeling and Identification Lecture 2 Dr Ing
- Slides: 25
System Modeling and Identification Lecture 2 Dr. -Ing. Erwin Sitompul President University http: //zitompul. wordpress. com 2 0 1 7 President University Erwin Sitompul SMI 2/1
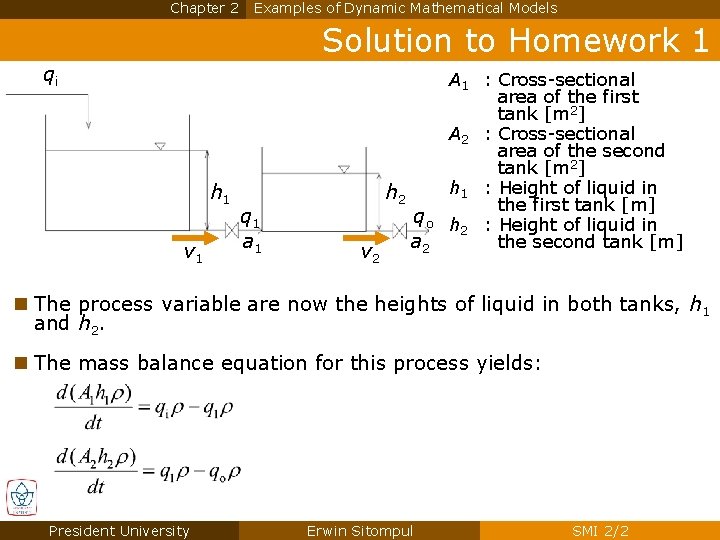
Chapter 2 Examples of Dynamic Mathematical Models Solution to Homework 1 qi h 1 v 1 q 1 a 1 h 2 v 2 qo a 2 A 1 : Cross-sectional area of the first tank [m 2] A 2 : Cross-sectional area of the second tank [m 2] h 1 : Height of liquid in the first tank [m] h 2 : Height of liquid in the second tank [m] n The process variable are now the heights of liquid in both tanks, h 1 and h 2. n The mass balance equation for this process yields: President University Erwin Sitompul SMI 2/2
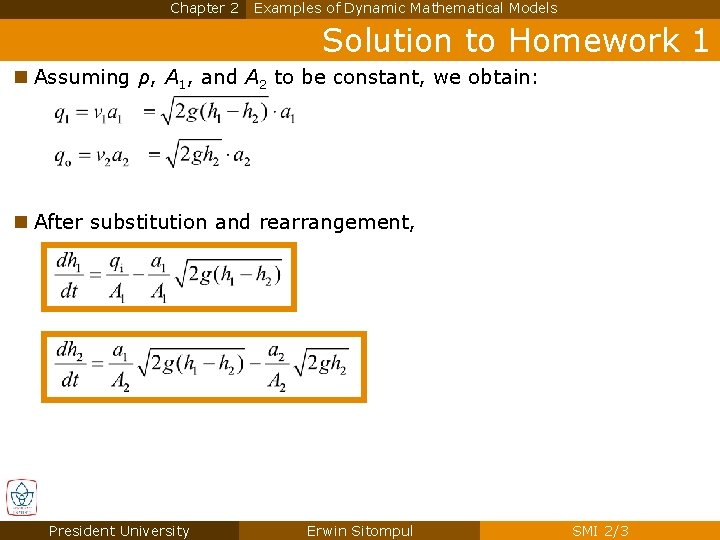
Chapter 2 Examples of Dynamic Mathematical Models Solution to Homework 1 n Assuming ρ, A 1, and A 2 to be constant, we obtain: n After substitution and rearrangement, President University Erwin Sitompul SMI 2/3
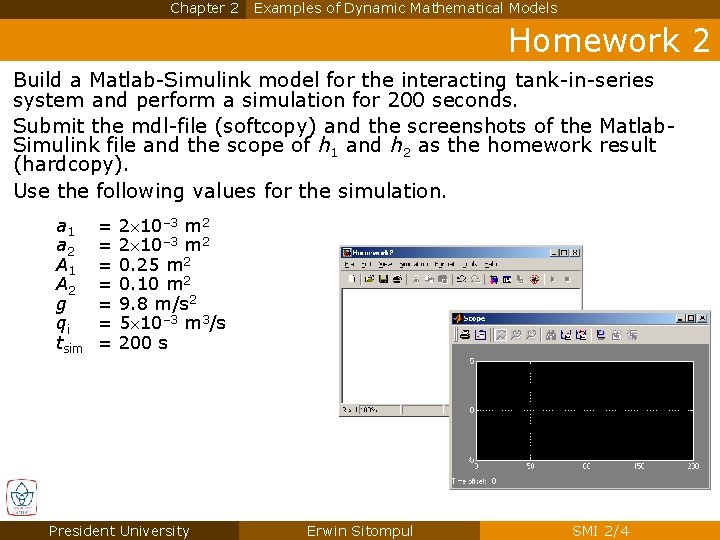
Chapter 2 Examples of Dynamic Mathematical Models Homework 2 Build a Matlab-Simulink model for the interacting tank-in-series system and perform a simulation for 200 seconds. Submit the mdl-file (softcopy) and the screenshots of the Matlab. Simulink file and the scope of h 1 and h 2 as the homework result (hardcopy). Use the following values for the simulation. a 1 a 2 A 1 A 2 g qi tsim = = = = 2 10– 3 m 2 0. 25 m 2 0. 10 m 2 9. 8 m/s 2 5 10– 3 m 3/s 200 s President University Erwin Sitompul SMI 2/4
Chapter 2 Examples of Dynamic Mathematical Models Homework 2 A Build a Matlab-Simulink model for the triangular-prism-shaped tank and perform a simulation for 200 seconds. Submit the mdl-file (softcopy) and the screenshots of the Matlab. Simulink file and the scope of h as the homework result (hardcopy). Use the following values for the simulation. a = 2 10– 3 m 2 Amax= 0. 5 m 2 hmax = 0. 7 m hinitial= 0. 05 m (inside the integrator!) g = 9. 8 m/s 2 qi 1 = 5 10– 3 m 3/s qi 2 = 1 10– 3 m 3/s tsim = 200 s n Deadline: Tuesday, 31 January 2017 President University Erwin Sitompul SMI 2/5
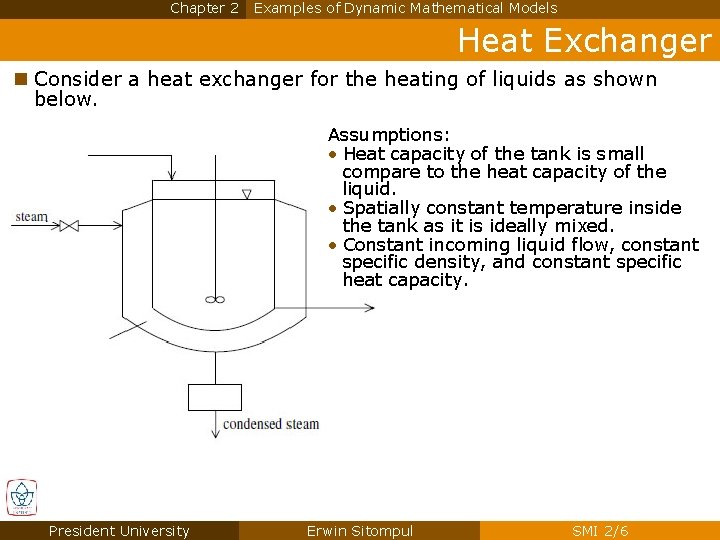
Chapter 2 Examples of Dynamic Mathematical Models Heat Exchanger n Consider a heat exchanger for the heating of liquids as shown below. Assumptions: • Heat capacity of the tank is small compare to the heat capacity of the liquid. • Spatially constant temperature inside the tank as it is ideally mixed. • Constant incoming liquid flow, constant specific density, and constant specific heat capacity. President University Erwin Sitompul SMI 2/6
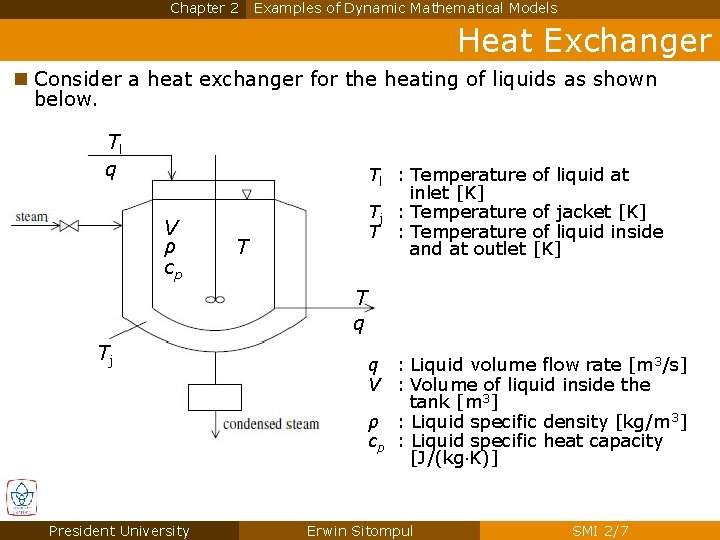
Chapter 2 Examples of Dynamic Mathematical Models Heat Exchanger n Consider a heat exchanger for the heating of liquids as shown below. Tl q V ρ cp Tl : Temperature inlet [K] Tj : Temperature T : Temperature and at outlet T of liquid at of jacket [K] of liquid inside [K] T q Tj President University q : Liquid volume flow rate [m 3/s] V : Volume of liquid inside the tank [m 3] ρ : Liquid specific density [kg/m 3] cp : Liquid specific heat capacity [J/(kg K)] Erwin Sitompul SMI 2/7
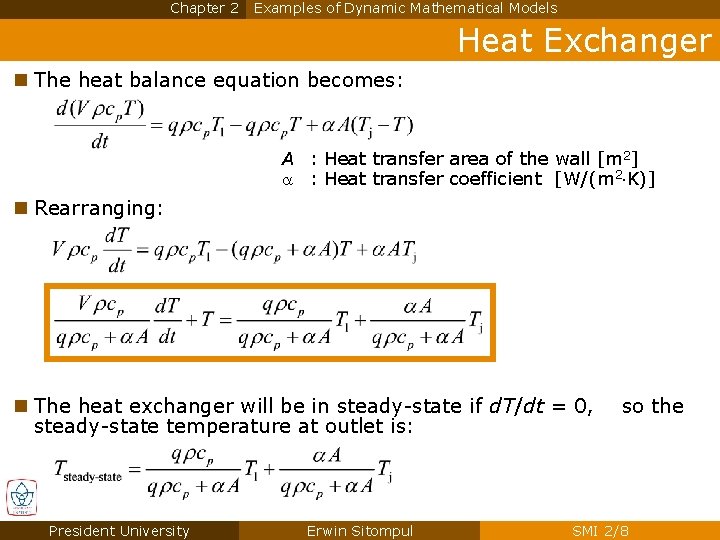
Chapter 2 Examples of Dynamic Mathematical Models Heat Exchanger n The heat balance equation becomes: A : Heat transfer area of the wall [m 2] a : Heat transfer coefficient [W/(m 2 K)] n Rearranging: n The heat exchanger will be in steady-state if d. T/dt = 0, steady-state temperature at outlet is: President University Erwin Sitompul so the SMI 2/8
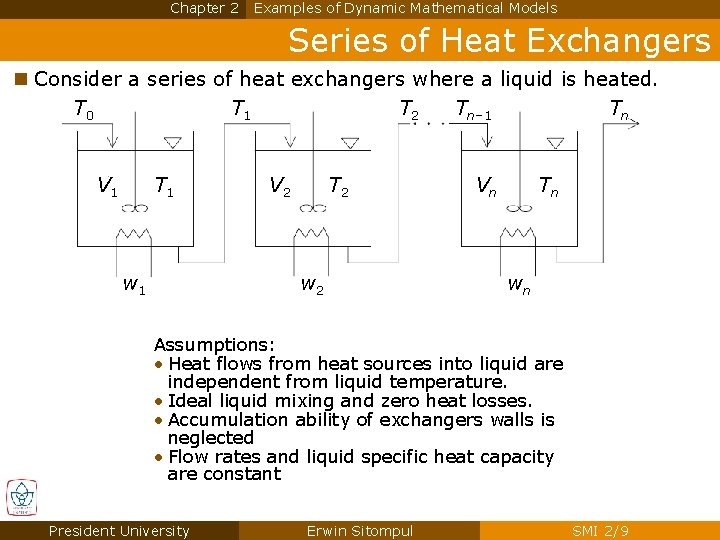
Chapter 2 Examples of Dynamic Mathematical Models Series of Heat Exchangers n Consider a series of heat exchangers where a liquid is heated. T 0 T 1 T 2 Tn– 1 Tn V 1 T 1 w 1 V 2 T 2 w 2 Vn Tn wn Assumptions: • Heat flows from heat sources into liquid are independent from liquid temperature. • Ideal liquid mixing and zero heat losses. • Accumulation ability of exchangers walls is neglected • Flow rates and liquid specific heat capacity are constant President University Erwin Sitompul SMI 2/9
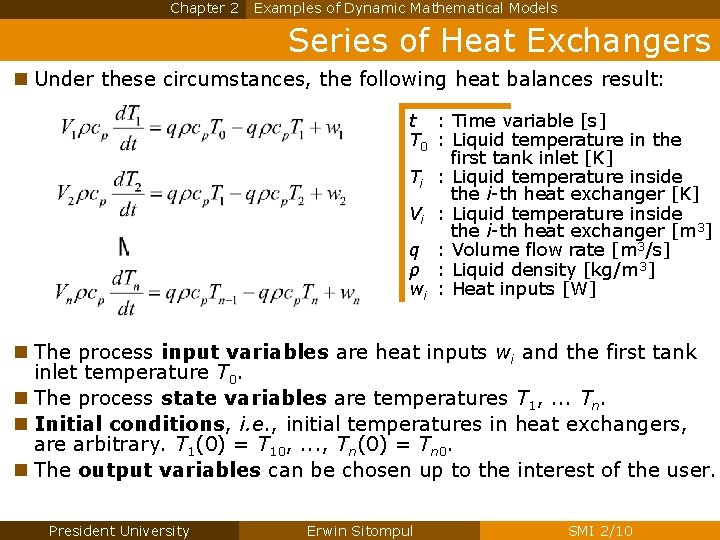
Chapter 2 Examples of Dynamic Mathematical Models Series of Heat Exchangers n Under these circumstances, the following heat balances result: t : Time variable [s] T 0 : Liquid temperature in the first tank inlet [K] Ti : Liquid temperature inside the i-th heat exchanger [K] Vi : Liquid temperature inside the i-th heat exchanger [m 3] q : Volume flow rate [m 3/s] ρ : Liquid density [kg/m 3] wi : Heat inputs [W] n The process input variables are heat inputs wi and the first tank inlet temperature T 0. n The process state variables are temperatures T 1, . . . Tn. n Initial conditions, i. e. , initial temperatures in heat exchangers, are arbitrary. T 1(0) = T 10, . . . , Tn(0) = Tn 0. n The output variables can be chosen up to the interest of the user. President University Erwin Sitompul SMI 2/10
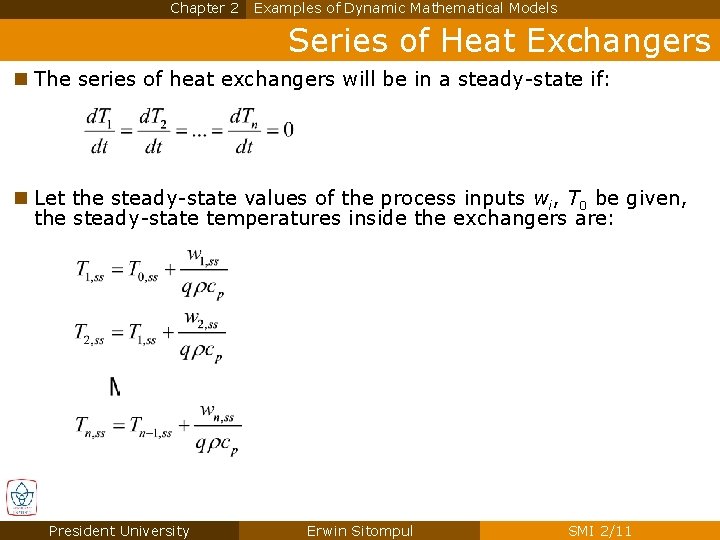
Chapter 2 Examples of Dynamic Mathematical Models Series of Heat Exchangers n The series of heat exchangers will be in a steady-state if: n Let the steady-state values of the process inputs wi, T 0 be given, the steady-state temperatures inside the exchangers are: President University Erwin Sitompul SMI 2/11
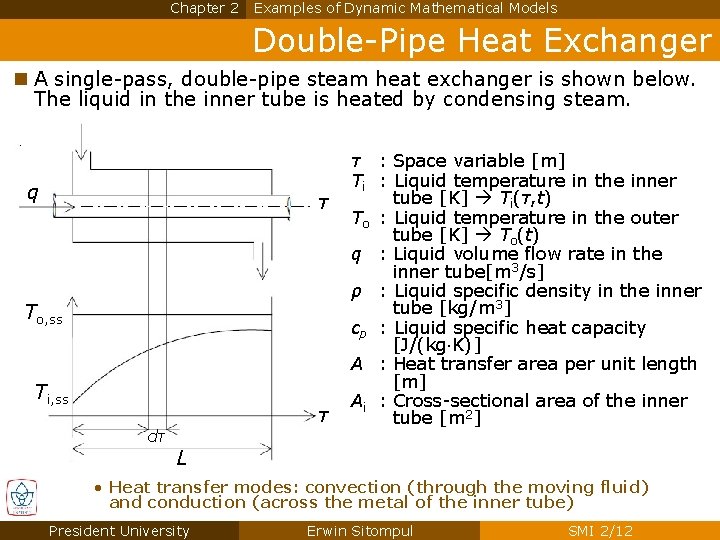
Chapter 2 Examples of Dynamic Mathematical Models Double-Pipe Heat Exchanger n A single-pass, double-pipe steam heat exchanger is shown below. The liquid in the inner tube is heated by condensing steam. q τ To, ss Ti, ss τ dτ τ : Space variable [m] Ti : Liquid temperature in the inner tube [K] Ti(τ, t) To : Liquid temperature in the outer tube [K] To(t) q : Liquid volume flow rate in the inner tube[m 3/s] ρ : Liquid specific density in the inner tube [kg/m 3] cp : Liquid specific heat capacity [J/(kg K)] A : Heat transfer area per unit length [m] Ai : Cross-sectional area of the inner tube [m 2] L • Heat transfer modes: convection (through the moving fluid) and conduction (across the metal of the inner tube) President University Erwin Sitompul SMI 2/12
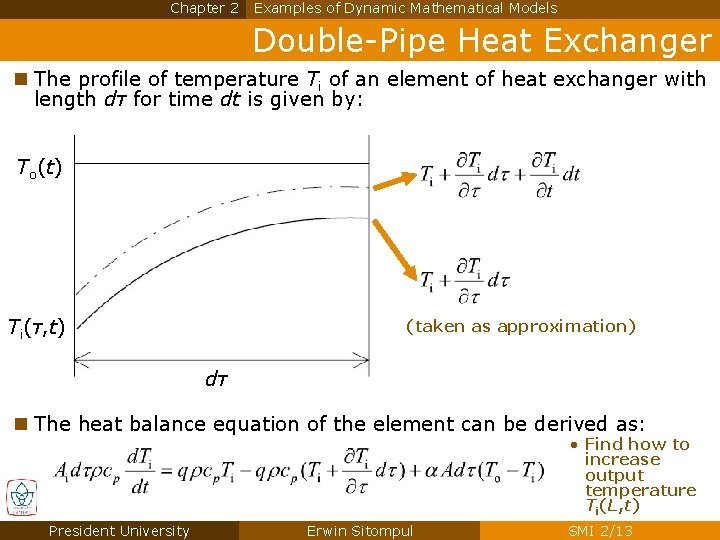
Chapter 2 Examples of Dynamic Mathematical Models Double-Pipe Heat Exchanger n The profile of temperature Ti of an element of heat exchanger with length dτ for time dt is given by: To(t) Ti(τ, t) (taken as approximation) dτ n The heat balance equation of the element can be derived as: • Find how to increase output temperature Ti(L, t) President University Erwin Sitompul SMI 2/13
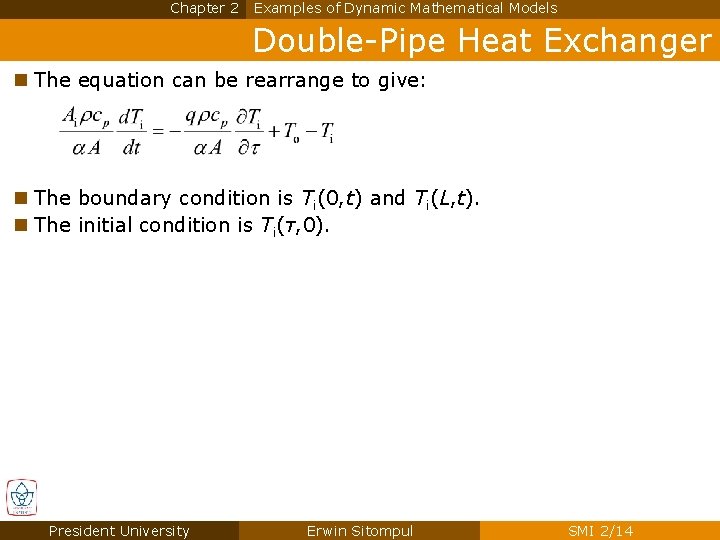
Chapter 2 Examples of Dynamic Mathematical Models Double-Pipe Heat Exchanger n The equation can be rearrange to give: n The boundary condition is Ti(0, t) and Ti(L, t). n The initial condition is Ti(τ, 0). President University Erwin Sitompul SMI 2/14
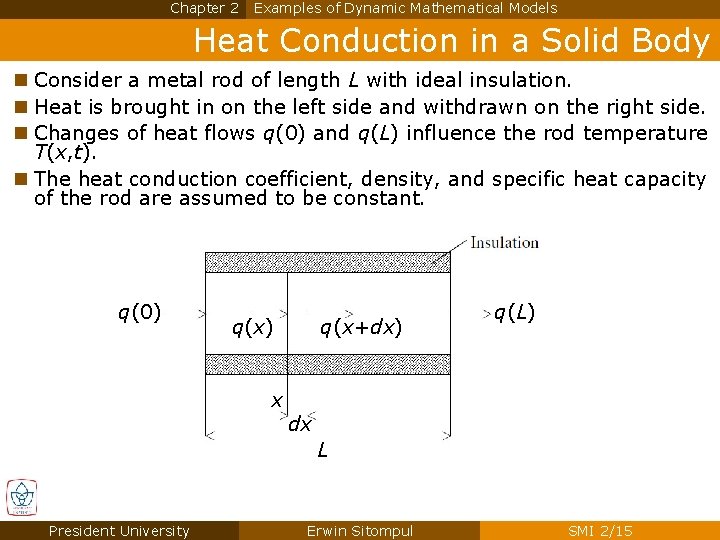
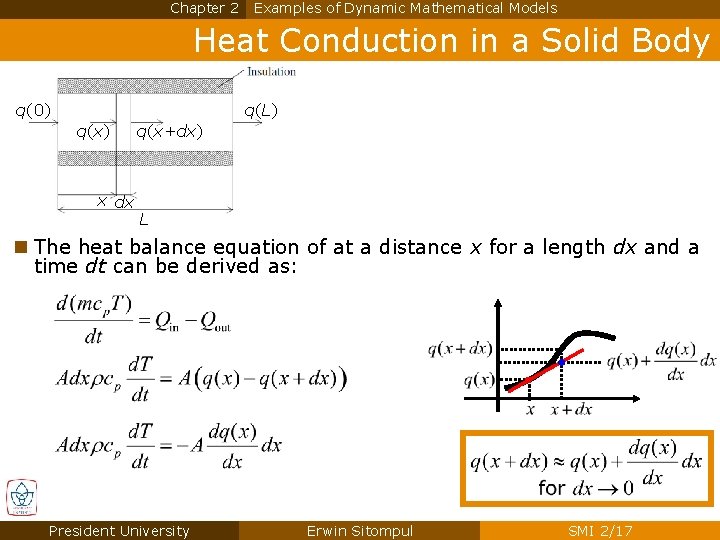
Chapter 2 Examples of Dynamic Mathematical Models Heat Conduction in a Solid Body n Consider a metal rod of length L with ideal insulation. n Heat is brought in on the left side and withdrawn on the right side. n Changes of heat flows q(0) and q(L) influence the rod temperature T(x, t). n The heat conduction coefficient, density, and specific heat capacity of the rod are assumed to be constant. q(0) q(x) x q(x+dx) q(L) dx L President University Erwin Sitompul SMI 2/15
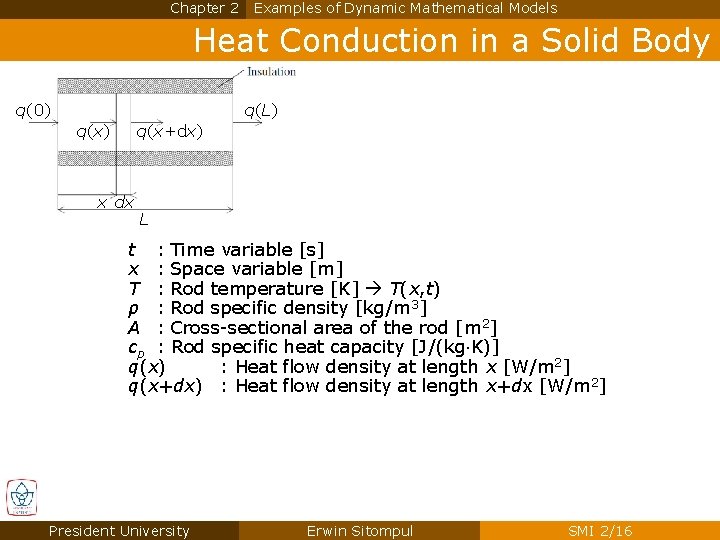
Chapter 2 Examples of Dynamic Mathematical Models Heat Conduction in a Solid Body q(0) q(L) q(x+dx) x dx L t : Time variable [s] x : Space variable [m] T : Rod temperature [K] T(x, t) ρ : Rod specific density [kg/m 3] A : Cross-sectional area of the rod [m 2] cp : Rod specific heat capacity [J/(kg K)] q(x) : Heat flow density at length x [W/m 2] q(x+dx) : Heat flow density at length x+dx [W/m 2] President University Erwin Sitompul SMI 2/16
Chapter 2 Examples of Dynamic Mathematical Models Heat Conduction in a Solid Body q(0) q(L) q(x) x dx q(x+dx) L n The heat balance equation of at a distance x for a length dx and a time dt can be derived as: President University Erwin Sitompul SMI 2/17
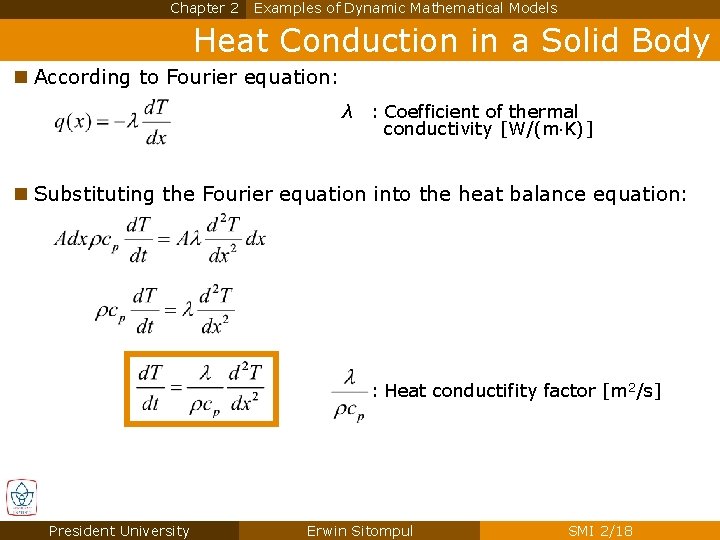
Chapter 2 Examples of Dynamic Mathematical Models Heat Conduction in a Solid Body n According to Fourier equation: λ : Coefficient of thermal conductivity [W/(m K)] n Substituting the Fourier equation into the heat balance equation: : Heat conductifity factor [m 2/s] President University Erwin Sitompul SMI 2/18
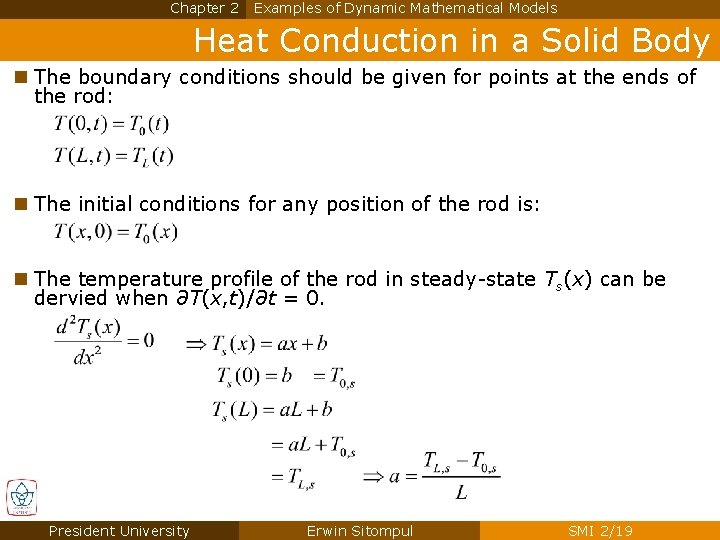
Chapter 2 Examples of Dynamic Mathematical Models Heat Conduction in a Solid Body n The boundary conditions should be given for points at the ends of the rod: n The initial conditions for any position of the rod is: n The temperature profile of the rod in steady-state Ts(x) can be dervied when ∂T(x, t)/∂t = 0. President University Erwin Sitompul SMI 2/19
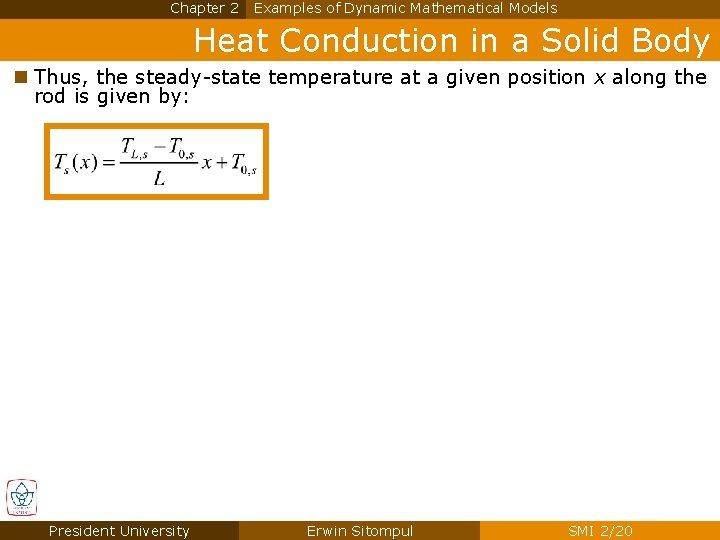
Chapter 2 Examples of Dynamic Mathematical Models Heat Conduction in a Solid Body n Thus, the steady-state temperature at a given position x along the rod is given by: President University Erwin Sitompul SMI 2/20
Chapter 2 General Process Models n A general process model can be described by a set of ordinary differential and algebraic equations, or in matrix-vector form. n The set of ordinary differential equations that constructs a model is called a state space model, consisting of state equations and output equations. n For control purposes, linearized mathematical models are used, to maintain the simplicity of the control design. n Later in this section, the conversion from partial differential equations that describes processes into models with ordinary differential equations will be shown. President University Erwin Sitompul SMI 2/21
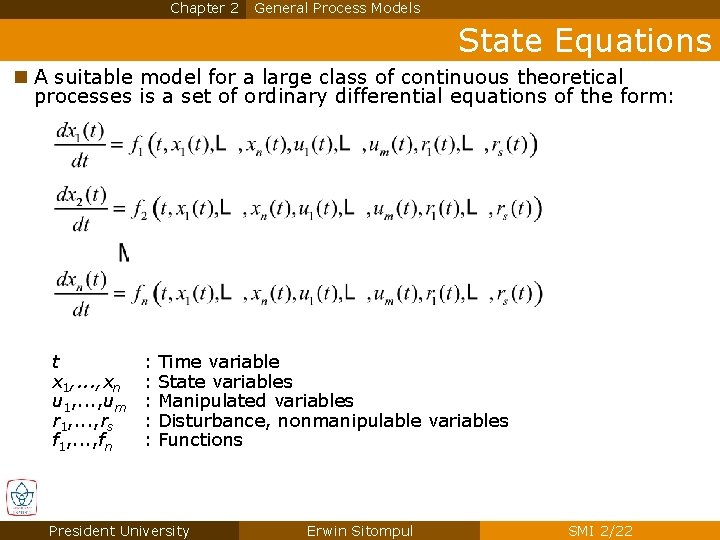
Chapter 2 General Process Models State Equations n A suitable model for a large class of continuous theoretical processes is a set of ordinary differential equations of the form: t x 1, . . . , xn u 1, . . . , um r 1, . . . , rs f 1, . . . , fn : : : Time variable State variables Manipulated variables Disturbance, nonmanipulable variables Functions President University Erwin Sitompul SMI 2/22
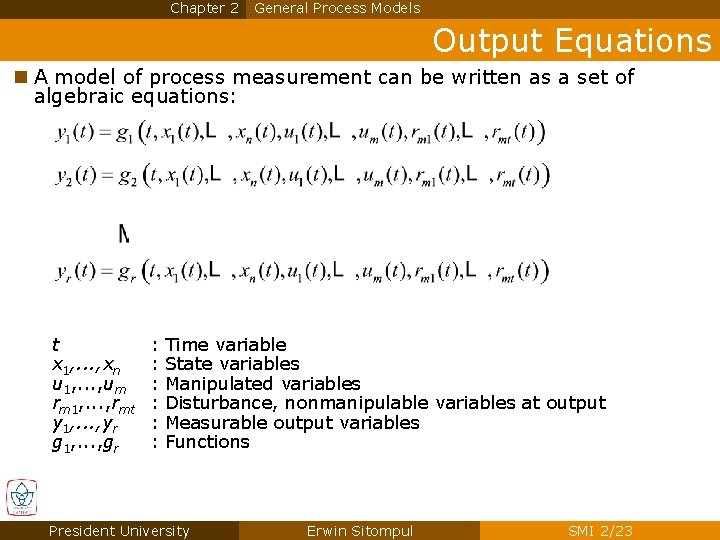
Chapter 2 General Process Models Output Equations n A model of process measurement can be written as a set of algebraic equations: t x 1, . . . , xn u 1, . . . , um rm 1, . . . , rmt y 1, . . . , yr g 1, . . . , gr : : : Time variable State variables Manipulated variables Disturbance, nonmanipulable variables at output Measurable output variables Functions President University Erwin Sitompul SMI 2/23
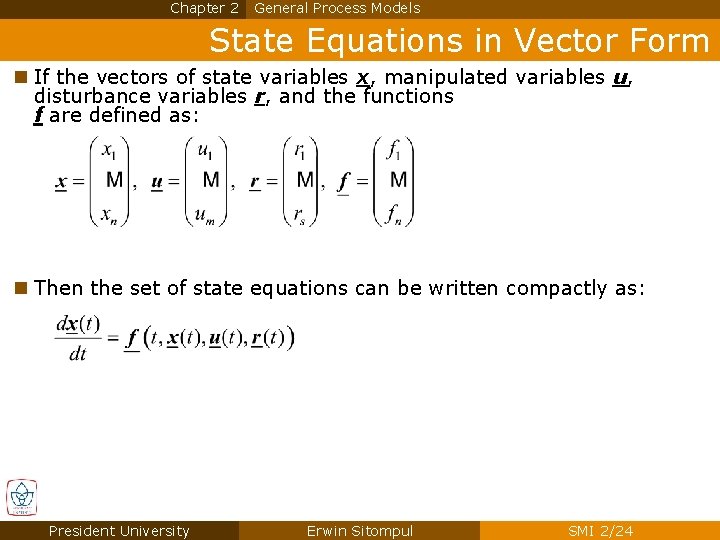
Chapter 2 General Process Models State Equations in Vector Form n If the vectors of state variables x, manipulated variables u, disturbance variables r, and the functions f are defined as: n Then the set of state equations can be written compactly as: President University Erwin Sitompul SMI 2/24
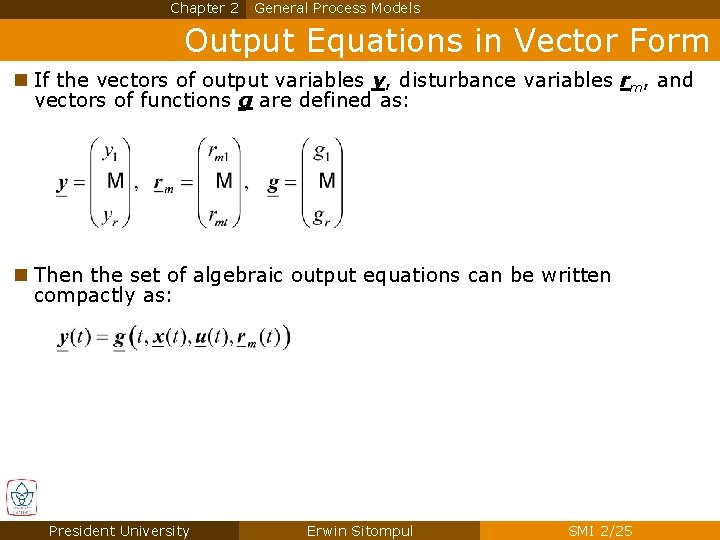
Chapter 2 General Process Models Output Equations in Vector Form n If the vectors of output variables y, disturbance variables rm, and vectors of functions g are defined as: n Then the set of algebraic output equations can be written compactly as: President University Erwin Sitompul SMI 2/25