Rigid Origami Simulation Tomohiro Tachi The University of
- Slides: 18
Rigid Origami Simulation Tomohiro Tachi The University of Tokyo http: //www. tsg. ne. jp/TT/
About this presentation For details, please refer to – Tomohiro Tachi, "Simulation of Rigid Origami" in Origami^4 : proceedings of 4 OSME (to appear)
1 Introduction
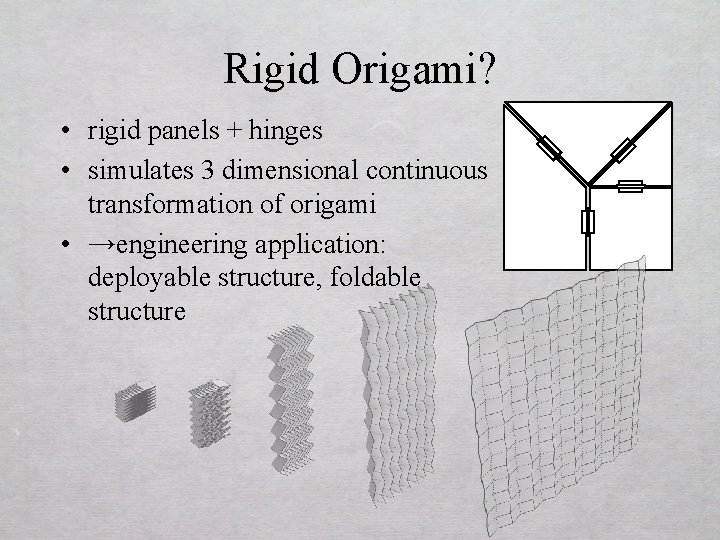
Rigid Origami? • rigid panels + hinges • simulates 3 dimensional continuous transformation of origami • →engineering application: deployable structure, foldable structure
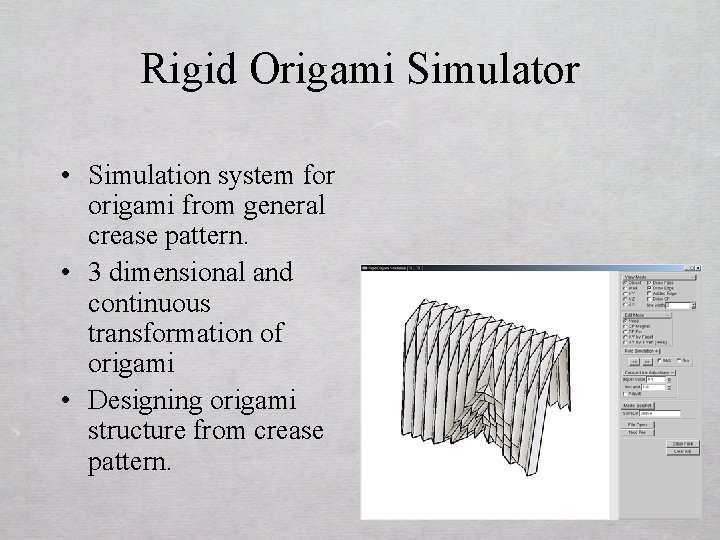
Rigid Origami Simulator • Simulation system for origami from general crease pattern. • 3 dimensional and continuous transformation of origami • Designing origami structure from crease pattern.
Software and galleries Software is available: http: //www. tsg. ne. jp/TT/software/ flickr: tactom You. Tube: tactom
2 Kinematics • Single-vertex model • Constraints • Kinematics
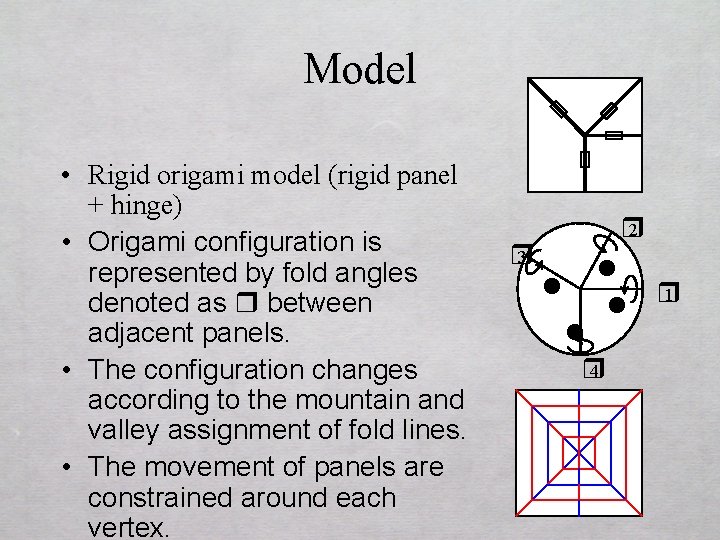
Model • Rigid origami model (rigid panel + hinge) • Origami configuration is represented by fold angles denoted as r between adjacent panels. • The configuration changes according to the mountain and valley assignment of fold lines. • The movement of panels are constrained around each vertex. 2 r 3 r l 3 l 2 l 1 l 4 4 r 1 r
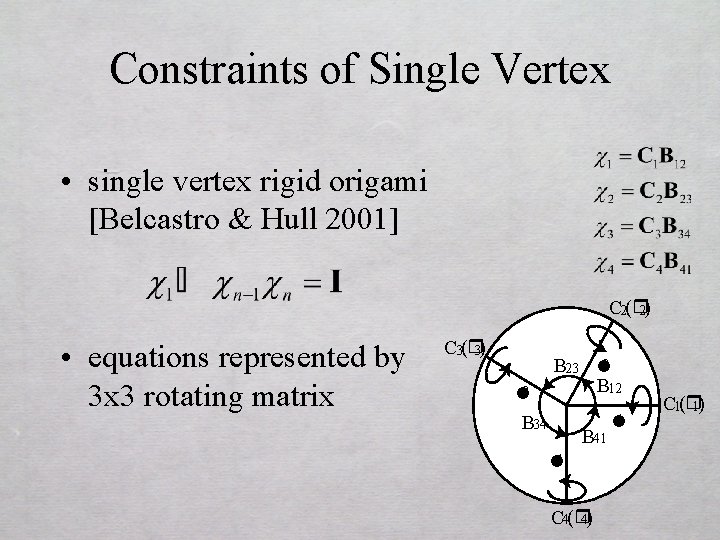
Constraints of Single Vertex • single vertex rigid origami [Belcastro & Hull 2001] C 2(r 2) • equations represented by 3 x 3 rotating matrix C 3(r 3) l 3 B 34 B 23 l 2 B 12 B 41 l 4 C 4(r 4) l 1 C 1(r 1)
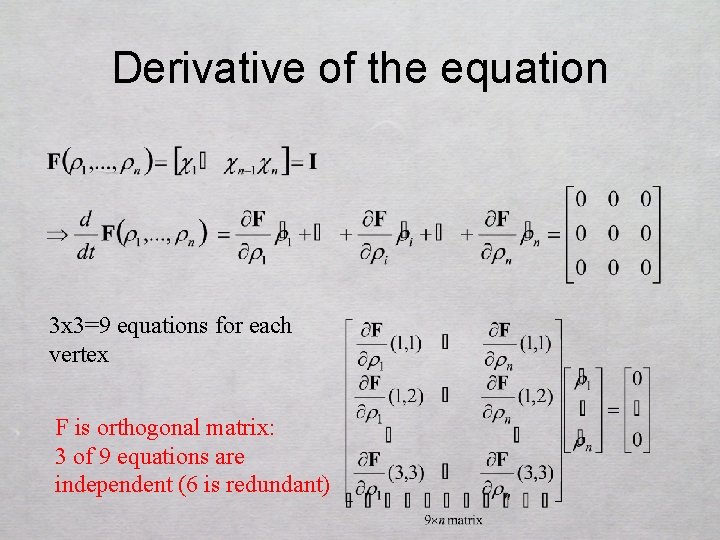
Derivative of the equation 3 x 3=9 equations for each vertex F is orthogonal matrix: 3 of 9 equations are independent (6 is redundant)
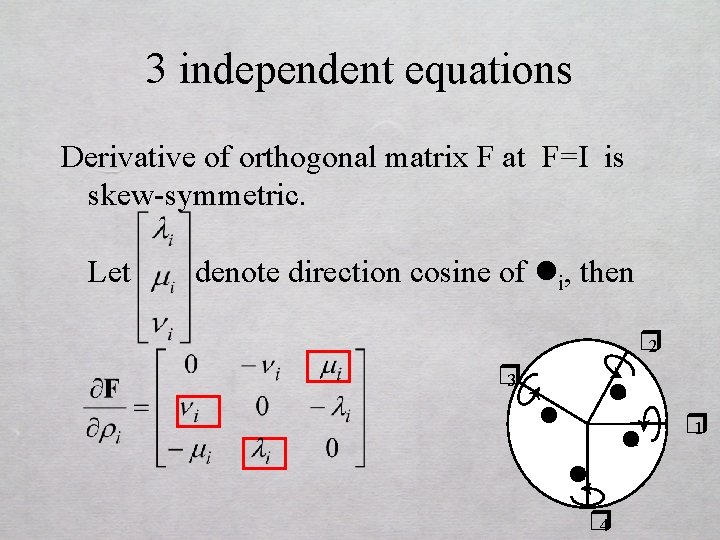
3 independent equations Derivative of orthogonal matrix F at F=I is skew-symmetric. Let denote direction cosine of li, then r 2 r 3 l 2 l 3 l 1 l 4 r 1
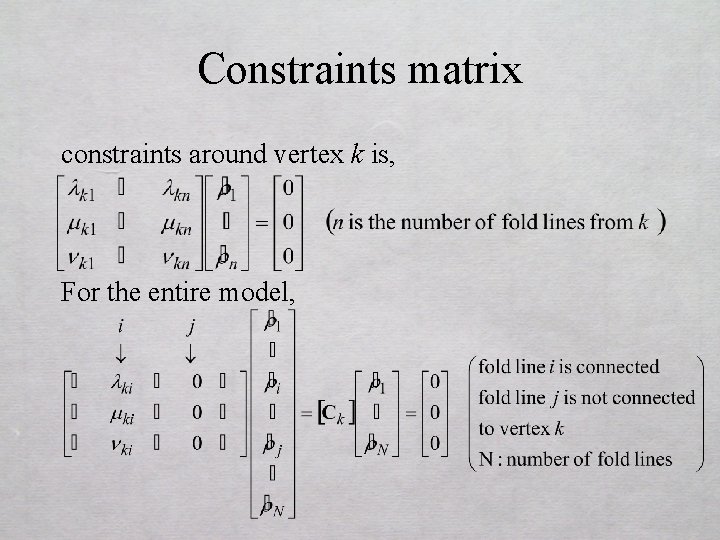
Constraints matrix constraints around vertex k is, For the entire model,
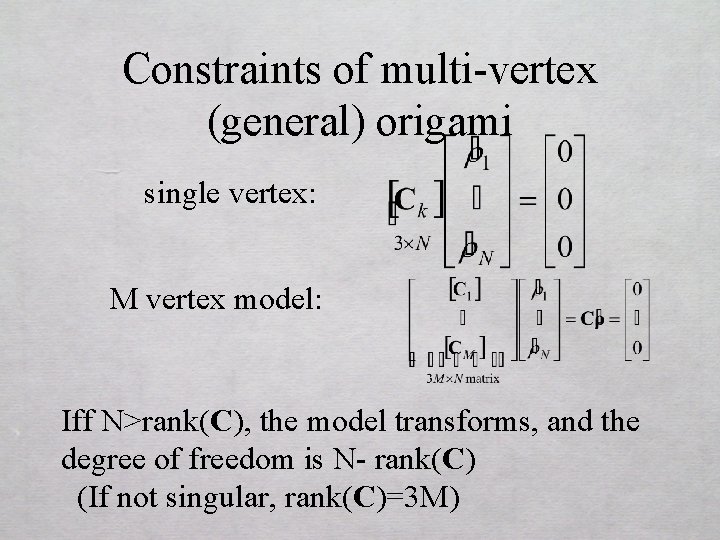
Constraints of multi-vertex (general) origami single vertex: M vertex model: Iff N>rank(C), the model transforms, and the degree of freedom is N- rank(C) (If not singular, rank(C)=3 M)
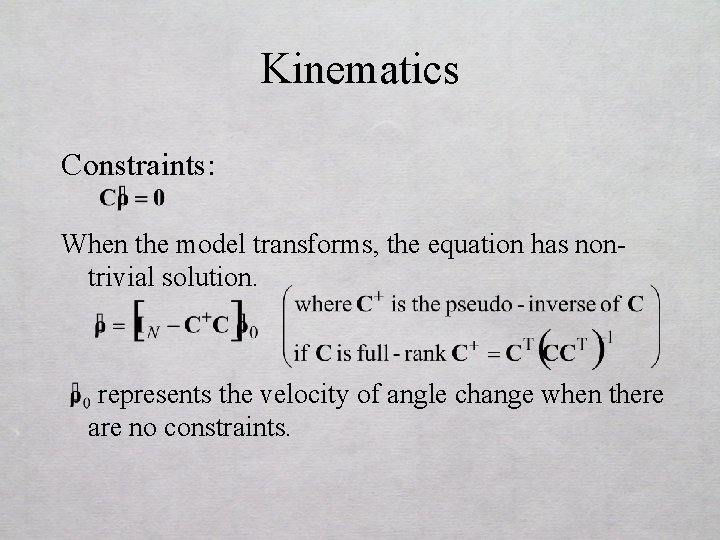
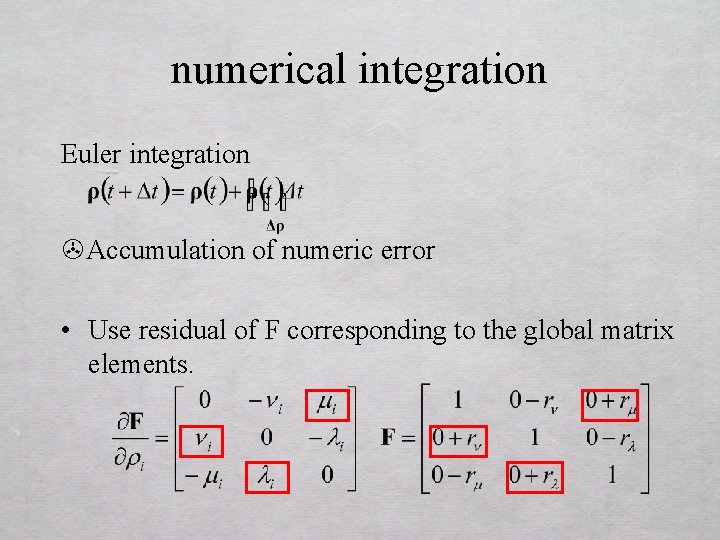
Kinematics Constraints: When the model transforms, the equation has nontrivial solution. represents the velocity of angle change when there are no constraints.
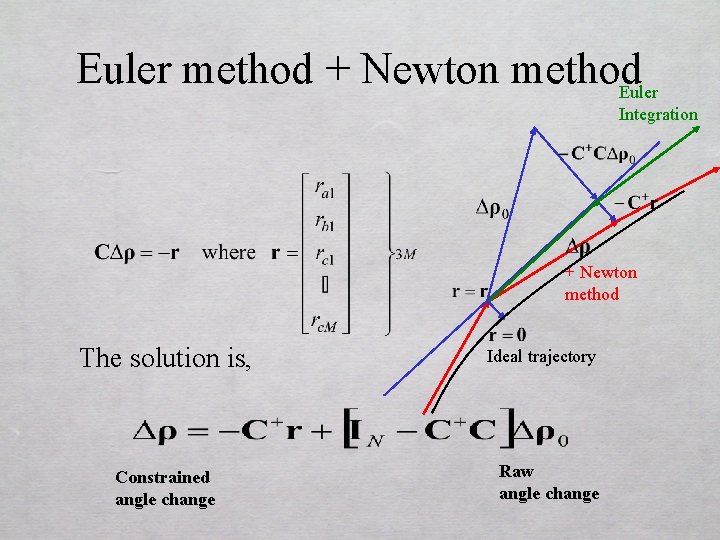
numerical integration Euler integration >Accumulation of numeric error • Use residual of F corresponding to the global matrix elements.
Euler method + Newton method Euler Integration + Newton method The solution is, Constrained angle change Ideal trajectory Raw angle change
3 System
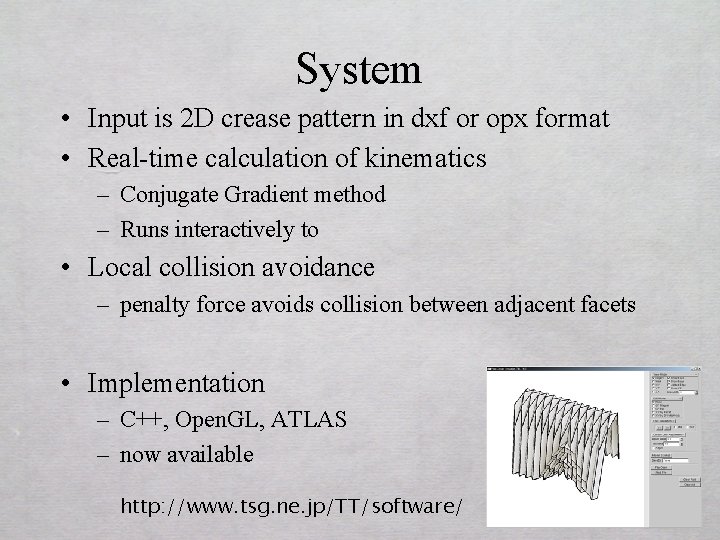
System • Input is 2 D crease pattern in dxf or opx format • Real-time calculation of kinematics – Conjugate Gradient method – Runs interactively to • Local collision avoidance – penalty force avoids collision between adjacent facets • Implementation – C++, Open. GL, ATLAS – now available http: //www. tsg. ne. jp/TT/software/