No Need to War Drive Unsupervised Indoor Localization
- Slides: 33
No Need to War. Drive … Unsupervised Indoor Localization Duke University, USA E-JUST, Egypt
Where am I in a hotel, mall, office, cruise ship? 2
GPS satellite Why not outdoor localization technology? 3
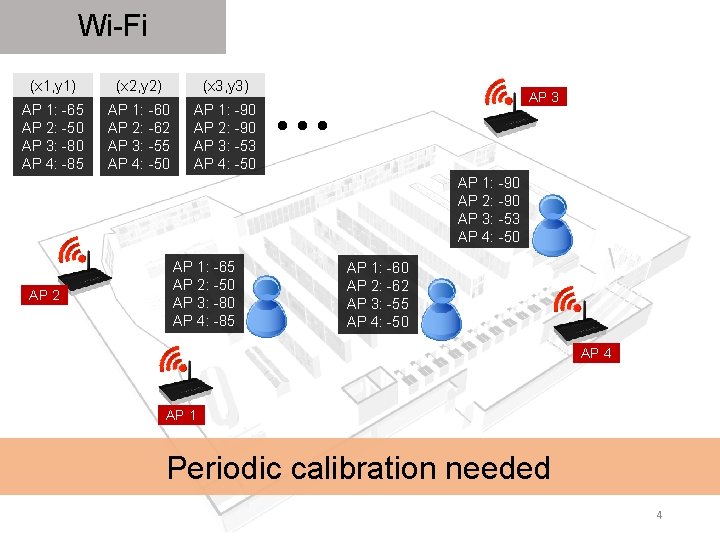
Wi-Fi (x 1, y 1) (x 2, y 2) (x 3, y 3) AP 1: -65 AP 2: -50 AP 3: -80 AP 4: -85 AP 1: -60 AP 2: -62 AP 3: -55 AP 4: -50 AP 1: -90 AP 2: -90 AP 3: -53 AP 4: -50 AP 3 AP 1: -90 AP 2: -90 AP 3: -53 AP 4: -50 AP 2 AP 1: -65 AP 2: -50 AP 3: -80 AP 4: -85 AP 1: -60 AP 2: -62 AP 3: -55 AP 4: -50 AP 4 AP 1 Periodic calibration needed 4
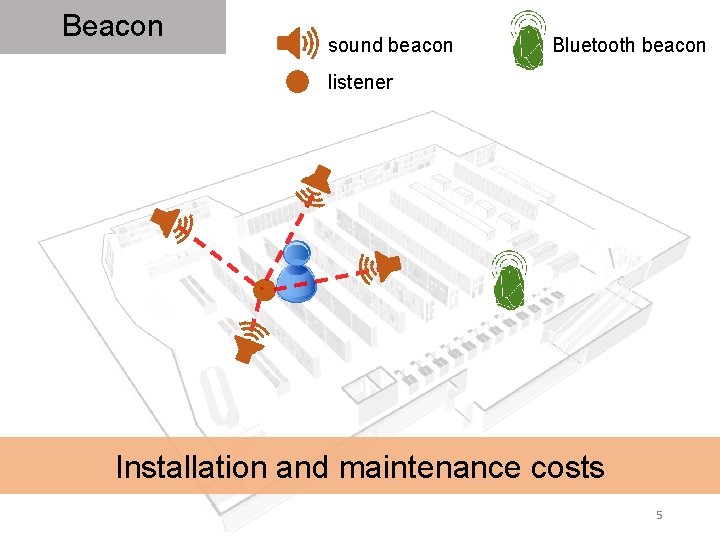
Beacon sound beacon Bluetooth beacon listener Installation and maintenance costs 5
We do not want to rely on infrastructure We want a scalable software solution 6
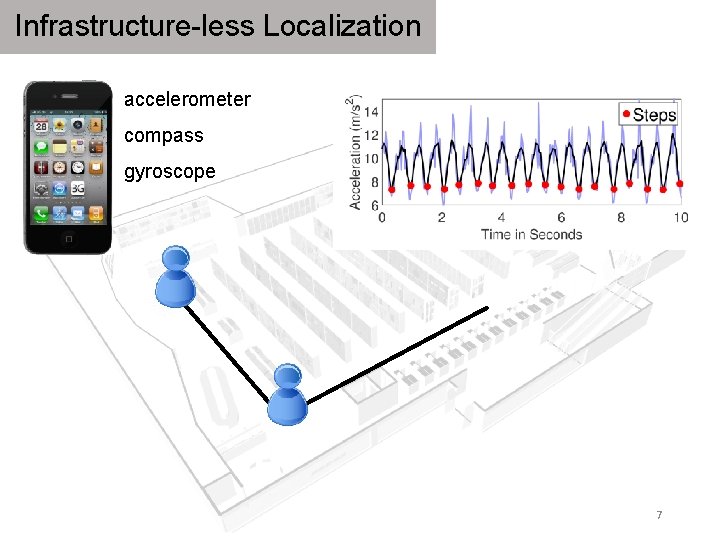
Infrastructure-less Localization accelerometer compass gyroscope 7
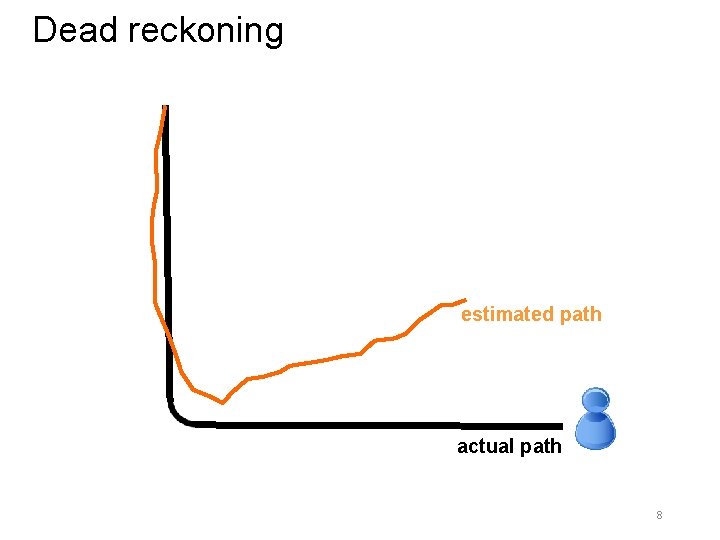
Dead reckoning estimated path actual path 8
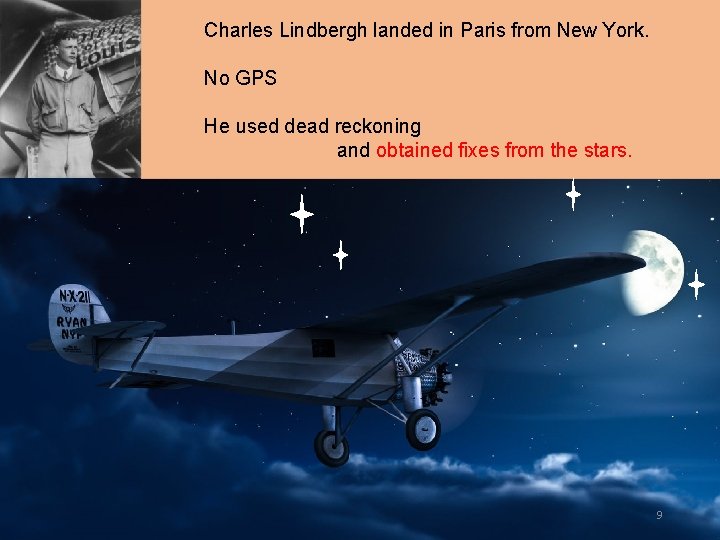
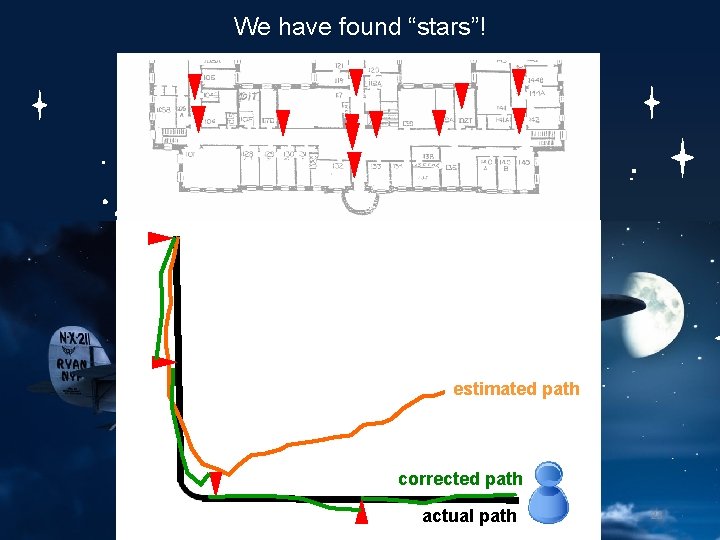
Charles Lindbergh landed in Paris from New York. No GPS He used dead reckoning and obtained fixes from the stars. 9
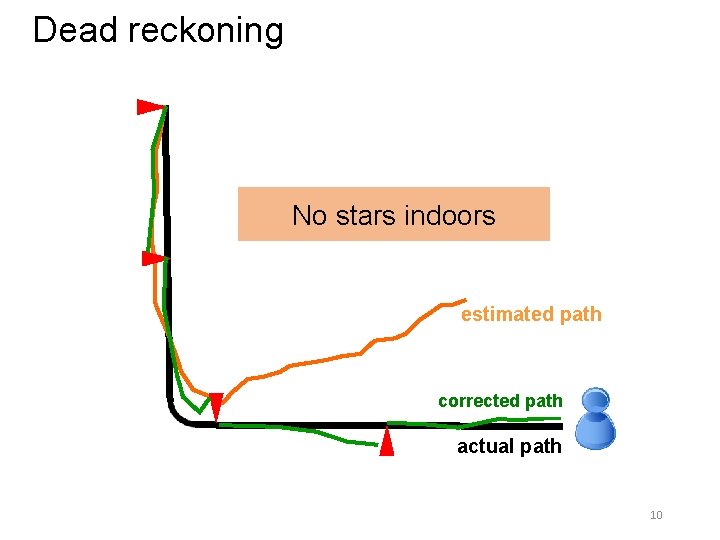
Dead reckoning No stars indoors estimated path corrected path actual path 10
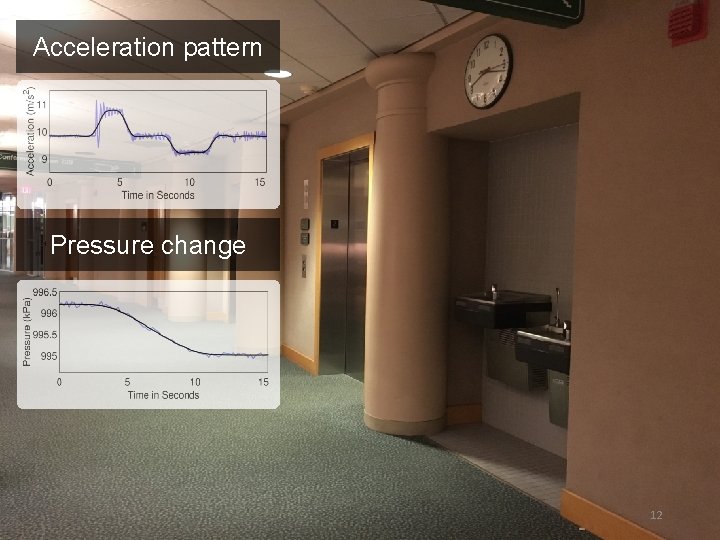
Magnetic fluctuation What if we “see” through sensors? At first, we could not see any … 11
Acceleration pattern Pressure change 12
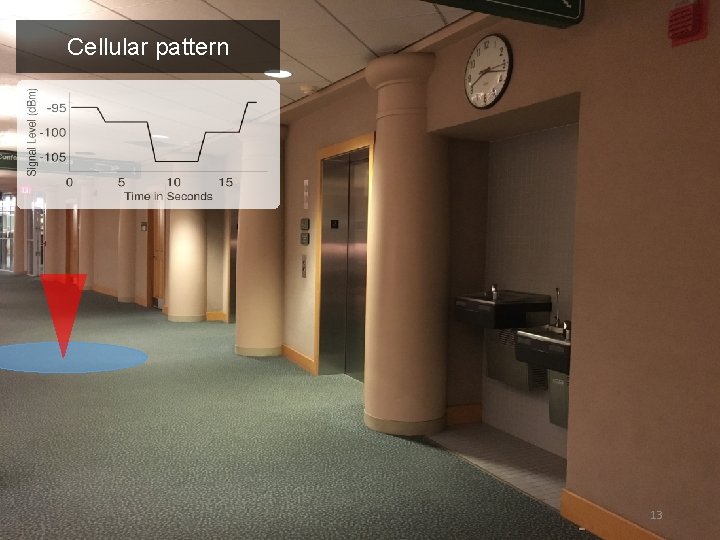
Cellular pattern 13
We use this core idea to design Un. Loc: Unsupervised Indoor Localization 14
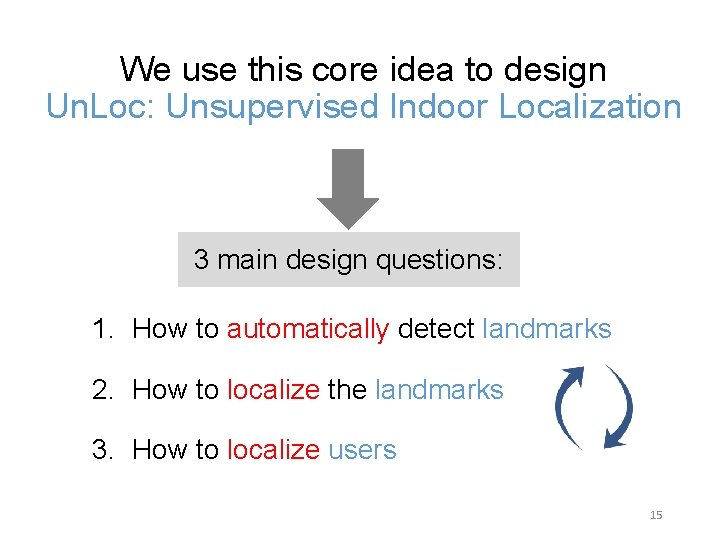
We use this core idea to design Un. Loc: Unsupervised Indoor Localization 3 main design questions: 1. How to automatically detect landmarks 2. How to localize the landmarks 3. How to localize users 15
1. How to automatically detect landmarks 16
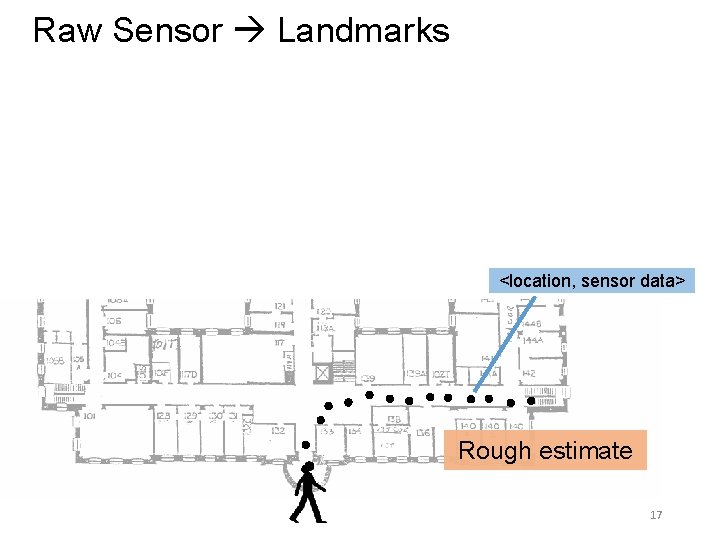
Raw Sensor Landmarks <location, sensor data> Rough estimate 17
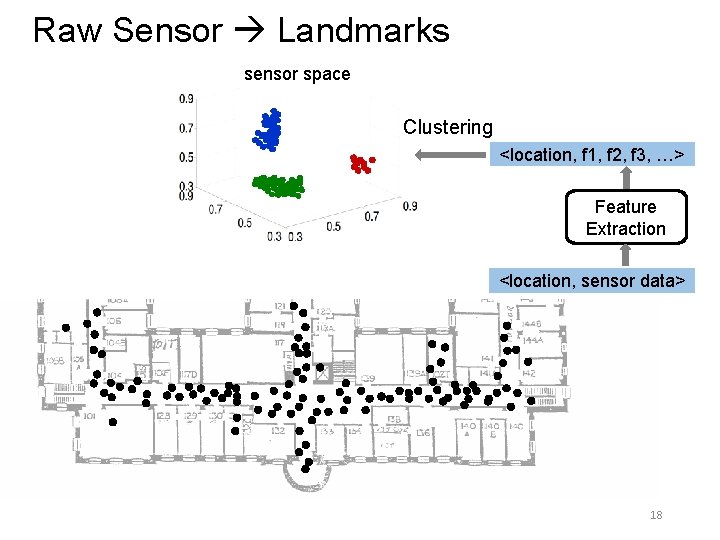
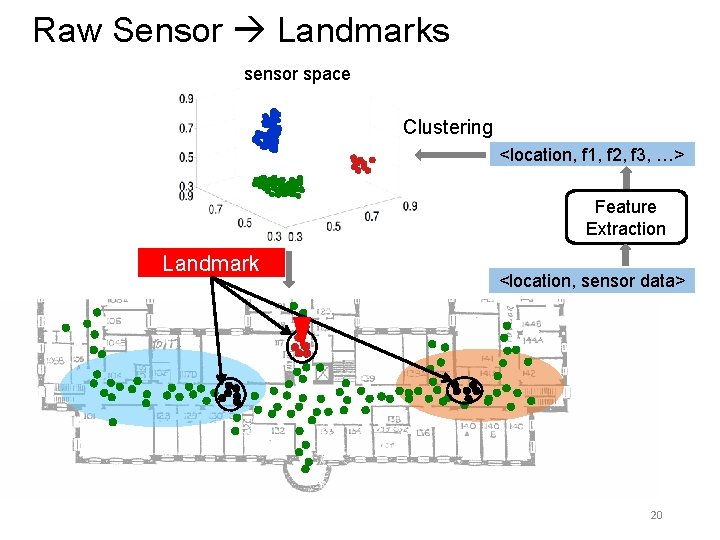
Raw Sensor Landmarks sensor space Clustering <location, f 1, f 2, f 3, …> Feature Extraction <location, sensor data> 18
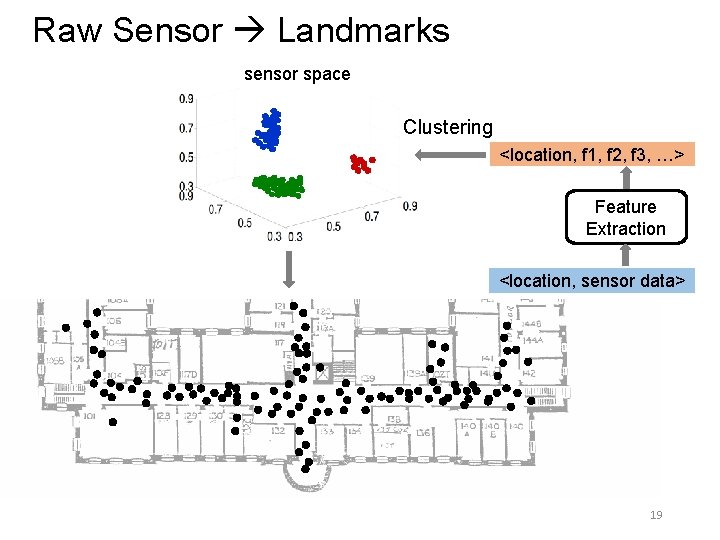
Raw Sensor Landmarks sensor space Clustering <location, f 1, f 2, f 3, …> Feature Extraction <location, sensor data> 19
Raw Sensor Landmarks sensor space Clustering <location, f 1, f 2, f 3, …> Feature Extraction Landmark <location, sensor data> 20
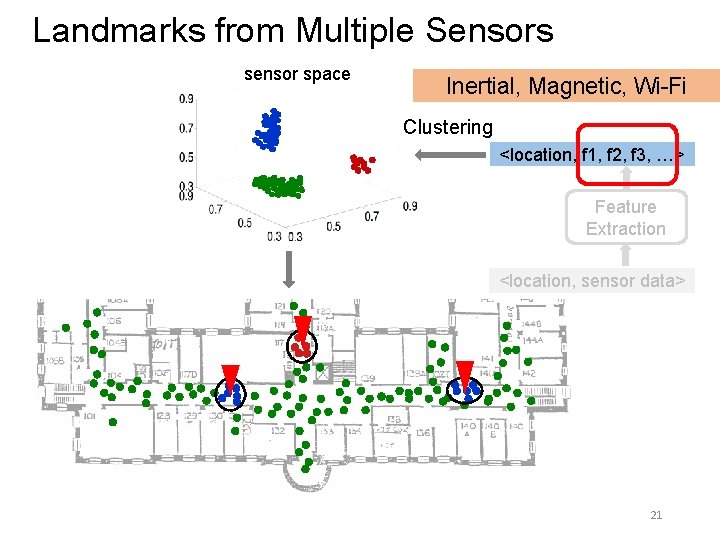
Landmarks from Multiple Sensors sensor space Inertial, Magnetic, Wi-Fi Clustering <location, f 1, f 2, f 3, …> Feature Extraction <location, sensor data> 21
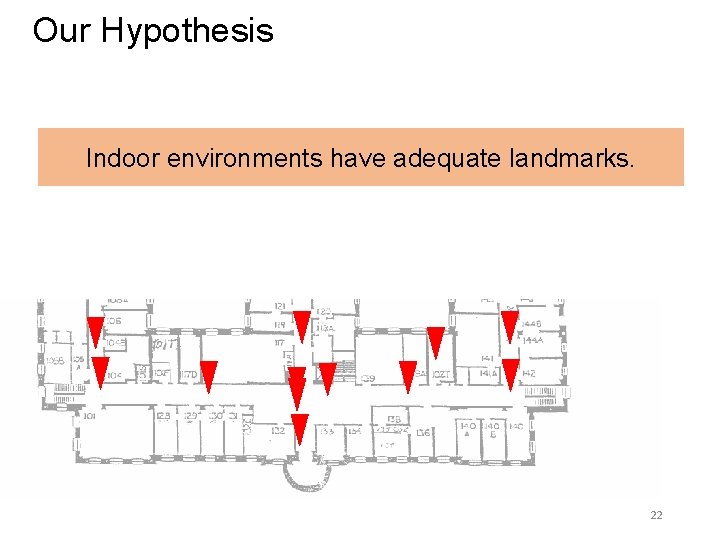
Our Hypothesis Indoor environments have adequate landmarks. 22
We have found “stars”! estimated path corrected path actual path 23
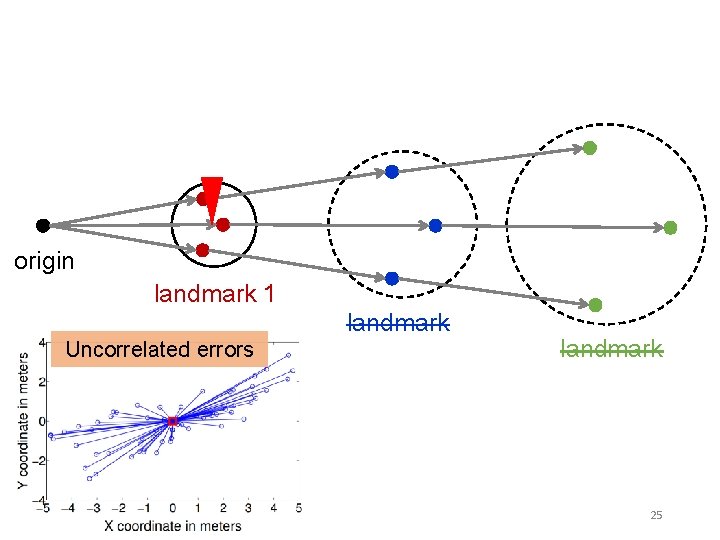
But, wait … We assumed dead reckoning is not too bad … But in reality it diverges poorly. What happens then? 24
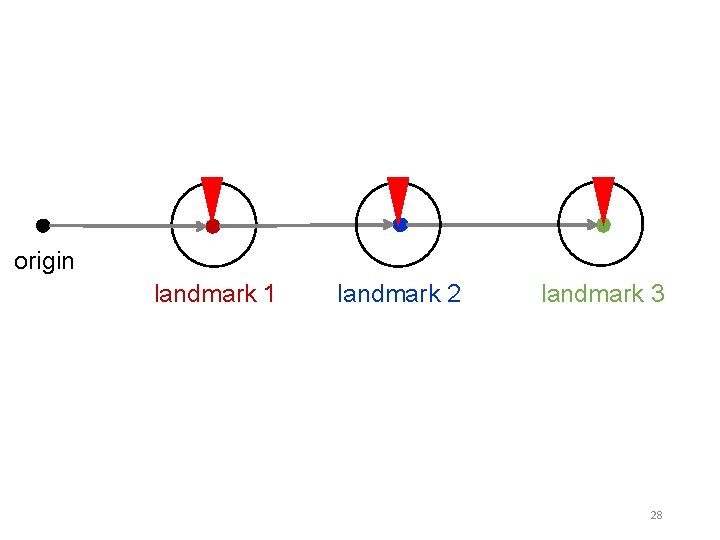
origin landmark 1 landmark Uncorrelated errors landmark 25
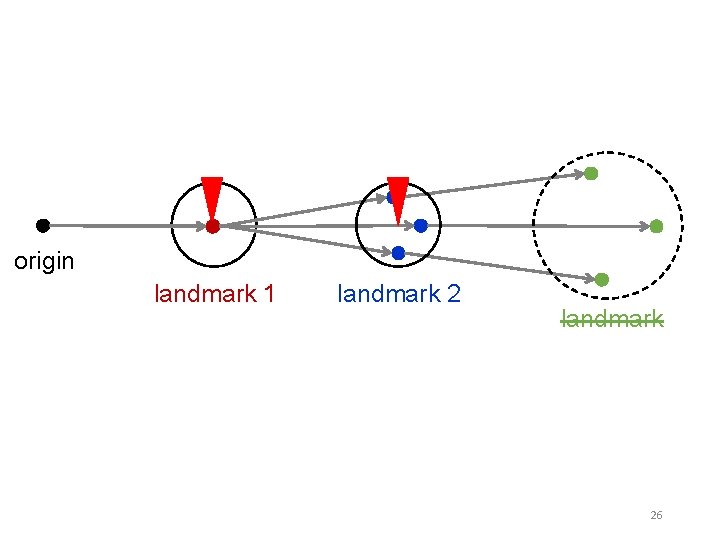
origin landmark 1 landmark 26
origin landmark 1 landmark 2 landmark 3 27
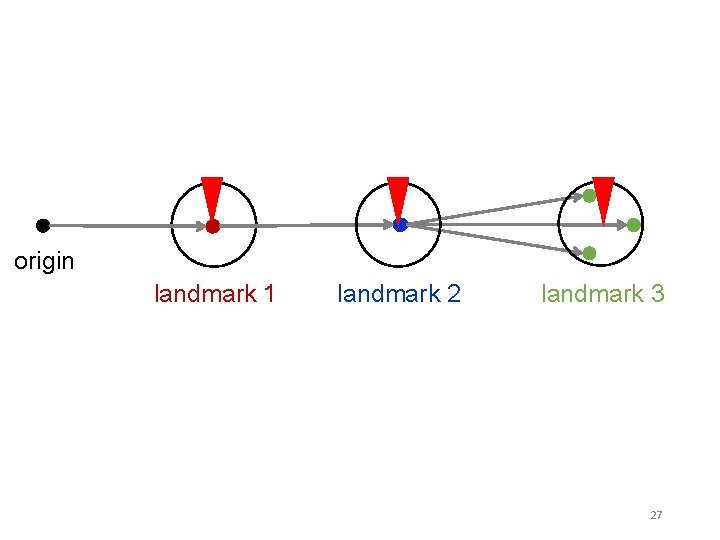
origin landmark 1 landmark 2 landmark 3 28
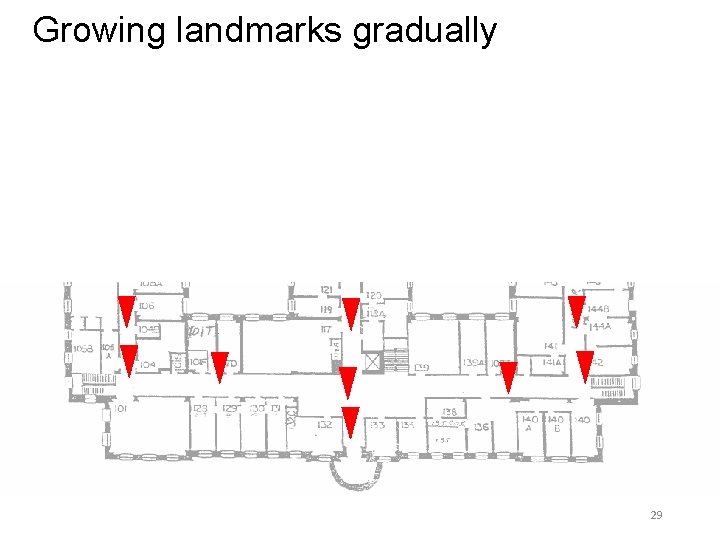
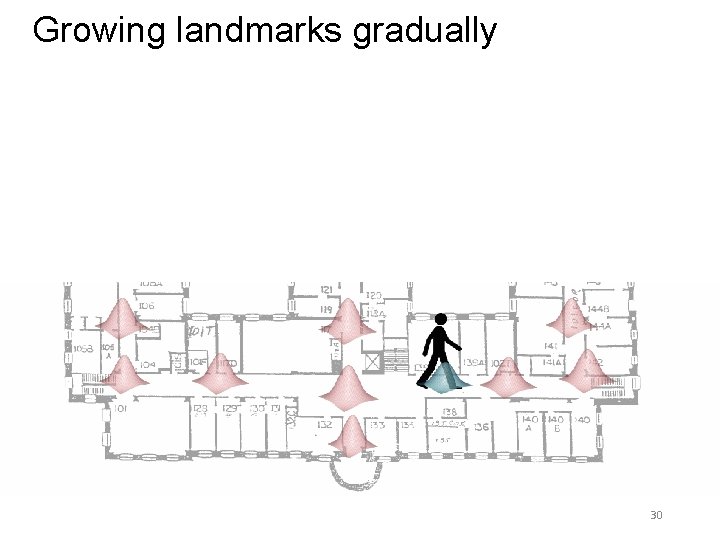
Growing landmarks gradually 29
Growing landmarks gradually 30
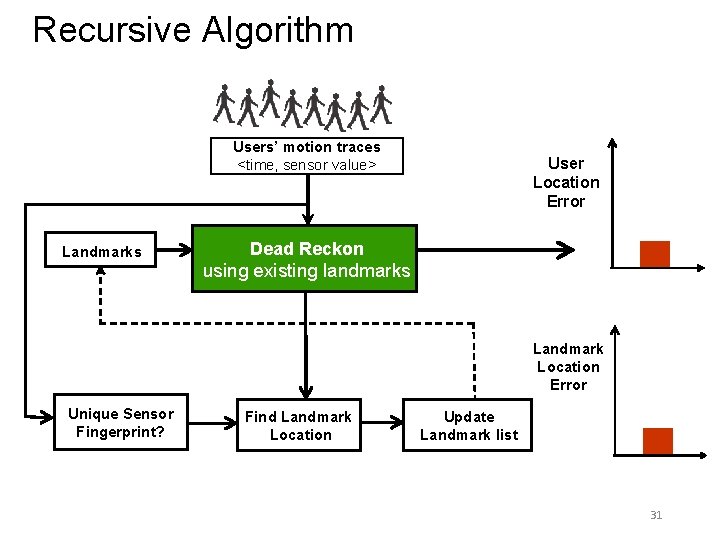
Recursive Algorithm Users’ motion traces <time, sensor value> Landmarks User Location Error Dead Reckon using existing landmarks Landmark Location Error Unique Sensor Fingerprint? Find Landmark Location Update Landmark list 31
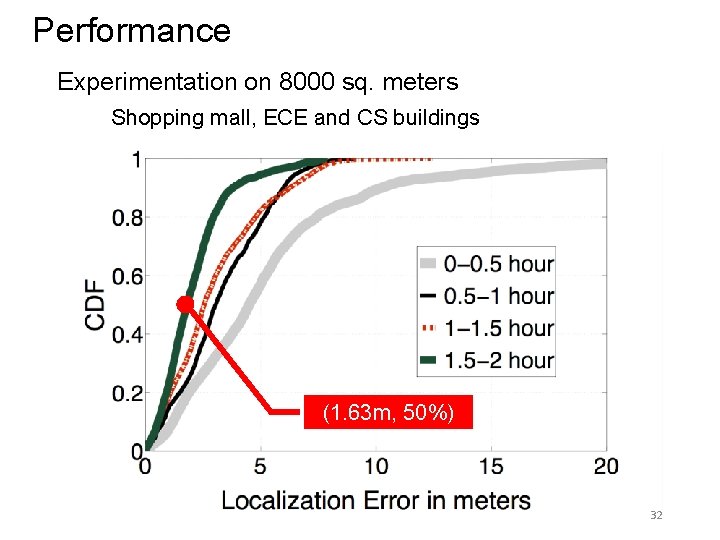
Performance Experimentation on 8000 sq. meters Shopping mall, ECE and CS buildings (1. 63 m, 50%) 32
Indoor environments rich in landmarks 1. 63 m accuracy No infrastructure cost No calibration needed 33