Visual Odometry Chris Moore Mark Huetsch Firouzeh Jalilian
- Slides: 6
Visual Odometry Chris Moore Mark Huetsch Firouzeh Jalilian
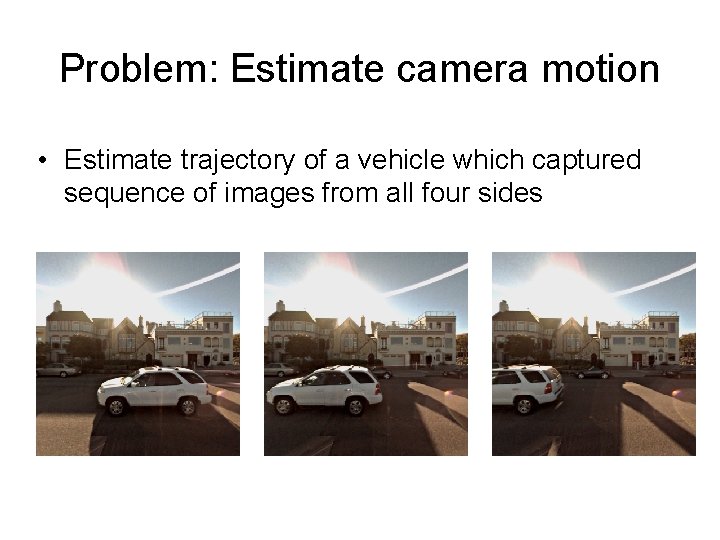
Problem: Estimate camera motion • Estimate trajectory of a vehicle which captured sequence of images from all four sides
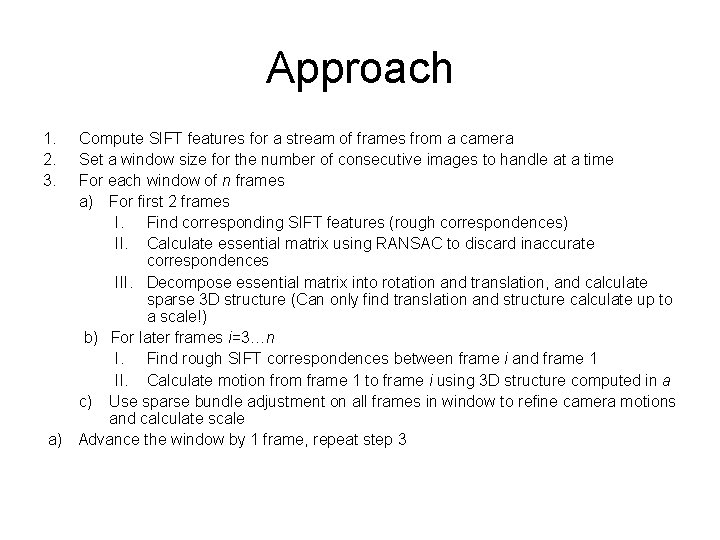
Approach 1. 2. 3. Compute SIFT features for a stream of frames from a camera Set a window size for the number of consecutive images to handle at a time For each window of n frames a) For first 2 frames I. Find corresponding SIFT features (rough correspondences) II. Calculate essential matrix using RANSAC to discard inaccurate correspondences III. Decompose essential matrix into rotation and translation, and calculate sparse 3 D structure (Can only find translation and structure calculate up to a scale!) b) For later frames i=3…n I. Find rough SIFT correspondences between frame i and frame 1 II. Calculate motion from frame 1 to frame i using 3 D structure computed in a c) Use sparse bundle adjustment on all frames in window to refine camera motions and calculate scale a) Advance the window by 1 frame, repeat step 3
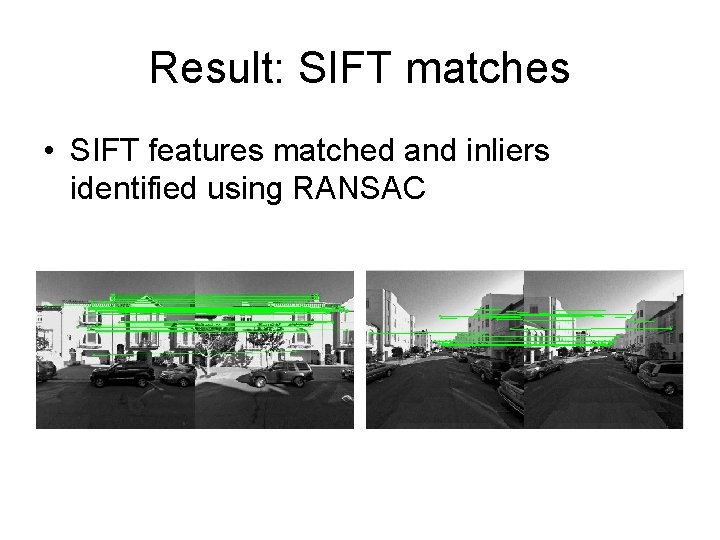
Result: SIFT matches • SIFT features matched and inliers identified using RANSAC
Improvements • Gaussian convolution of produced datapoints • Self-tuning of RANSAC parameters • More intelligent sliding window for bundle adjustment
Hidden Slide • Chris 40% • Mark 30% • Firouzeh 30%