
VEX Arms Roberts ARL robot in 2006 J
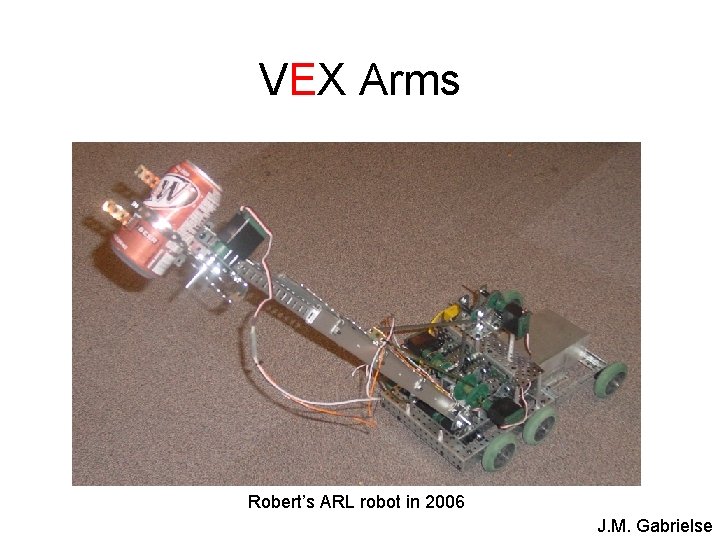
VEX Arms Robert’s ARL robot in 2006 J. M. Gabrielse
Outline • • • Rotating Arms Torque Power Multi-Jointed Arms Challenge Limit Switches J. M. Gabrielse
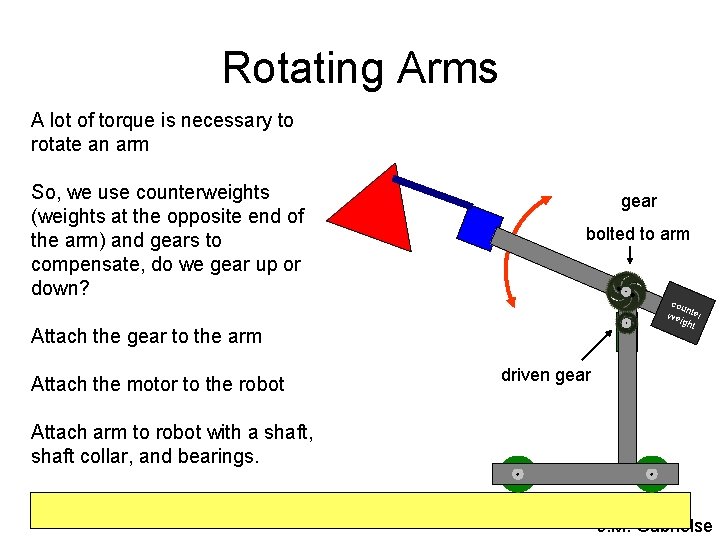
Rotating Arms A lot of torque is necessary to rotate an arm gear bolted to arm motor So, we use counterweights (weights at the opposite end of the arm) and gears to compensate, do we gear up or down? Attach the gear to the arm Attach the motor to the robot cou n we ter igh t driven gear Attach arm to robot with a shaft, shaft collar, and bearings. J. M. Gabrielse
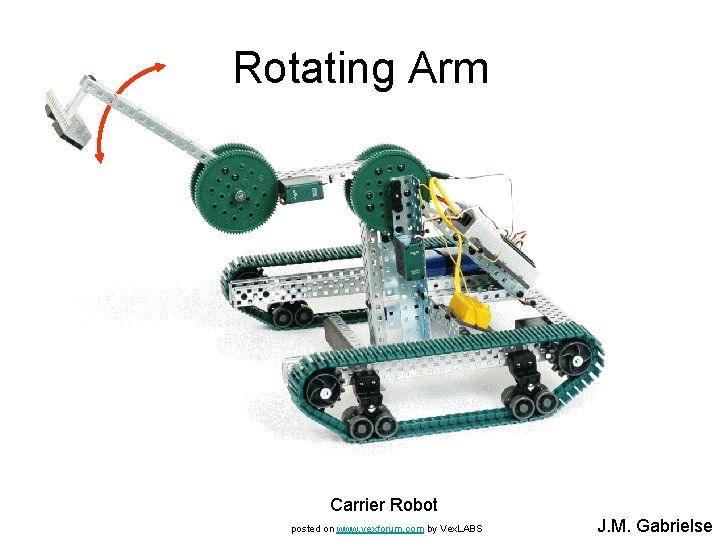
Rotating Arm Carrier Robot posted on www. vexforum. com by Vex. LABS J. M. Gabrielse
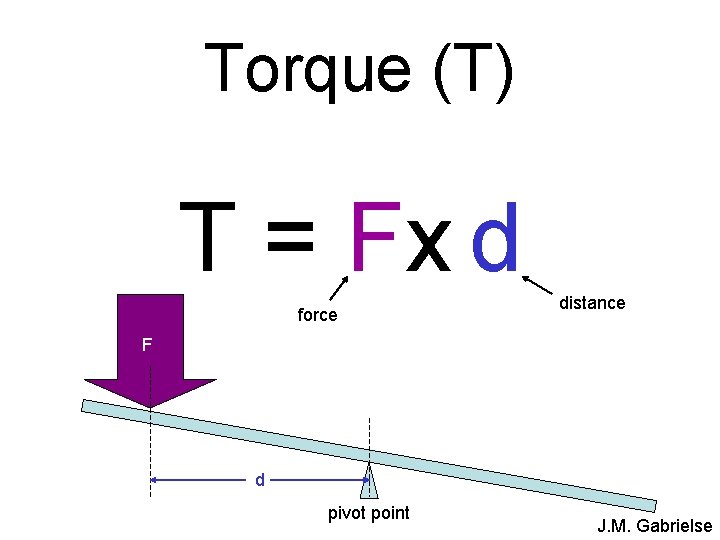
Torque (T) T = Fx d force distance F d pivot point J. M. Gabrielse
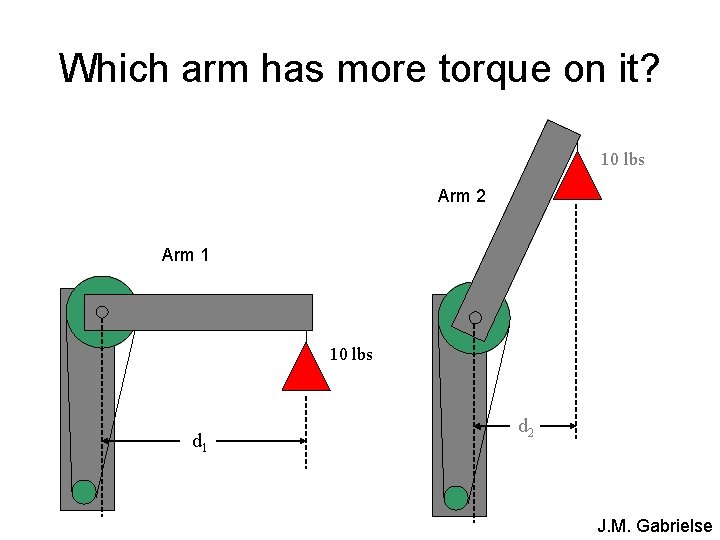
Which arm has more torque on it? 10 lbs Arm 2 Arm 1 10 lbs d 1 d 2 J. M. Gabrielse
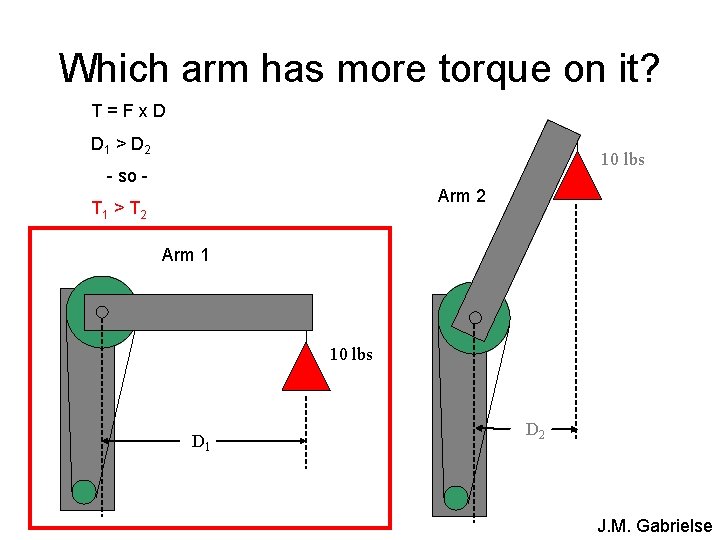
Which arm has more torque on it? T=Fx. D D 1 > D 2 10 lbs - so Arm 2 T 1 > T 2 Arm 1 10 lbs D 1 D 2 J. M. Gabrielse
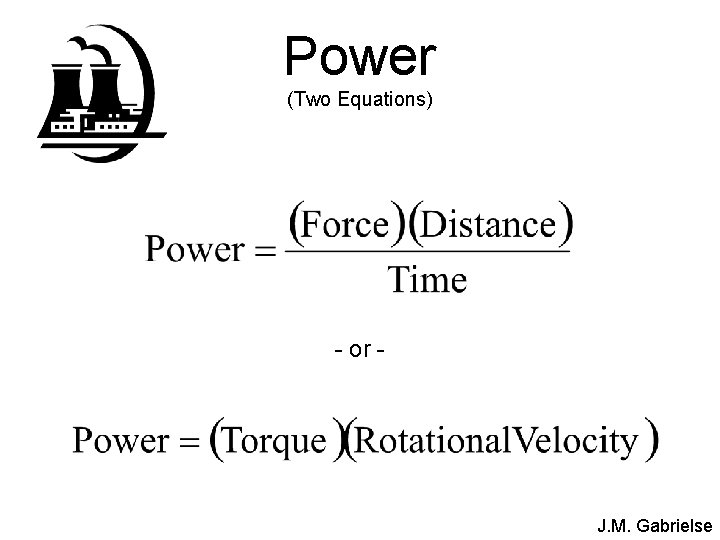
Power (Two Equations) - or - J. M. Gabrielse
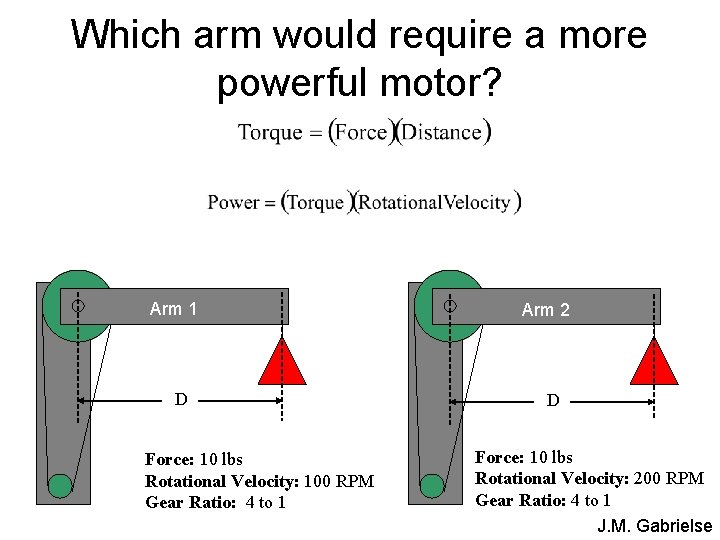
Which arm would require a more powerful motor? Arm 1 D Force: 10 lbs Rotational Velocity: 100 RPM Gear Ratio: 4 to 1 Arm 2 D Force: 10 lbs Rotational Velocity: 200 RPM Gear Ratio: 4 to 1 J. M. Gabrielse
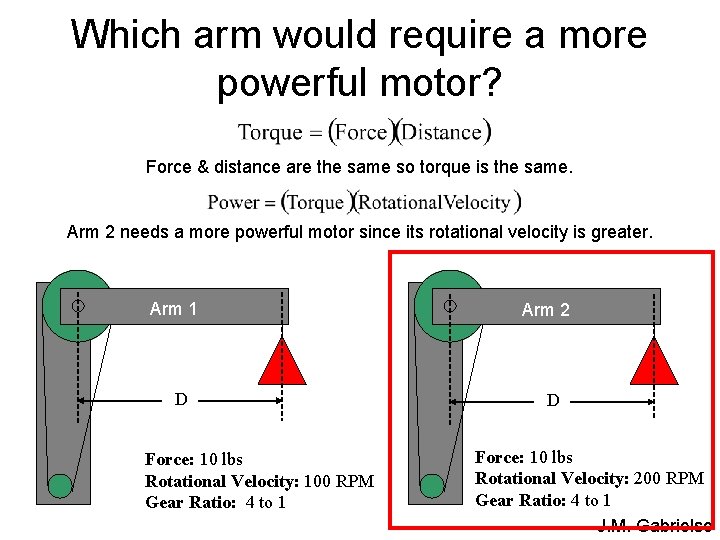
Which arm would require a more powerful motor? Force & distance are the same so torque is the same. Arm 2 needs a more powerful motor since its rotational velocity is greater. Arm 1 D Force: 10 lbs Rotational Velocity: 100 RPM Gear Ratio: 4 to 1 Arm 2 D Force: 10 lbs Rotational Velocity: 200 RPM Gear Ratio: 4 to 1 J. M. Gabrielse
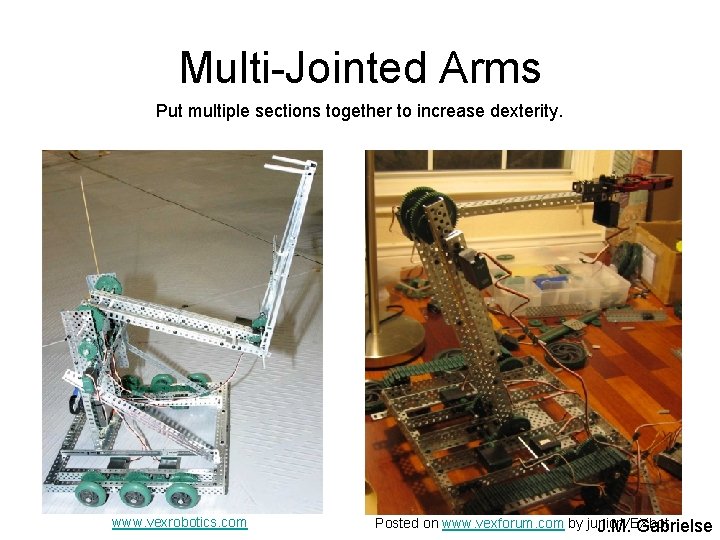
Multi-Jointed Arms Put multiple sections together to increase dexterity. www. vexrobotics. com Posted on www. vexforum. com by junior. VEXbot J. M. Gabrielse
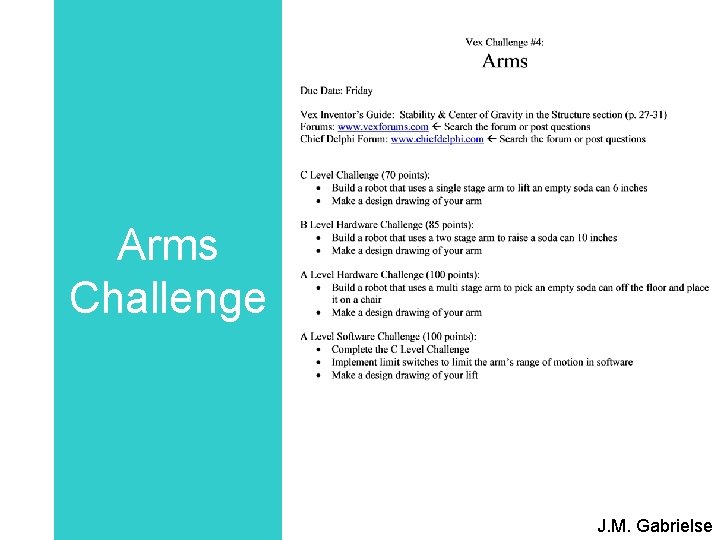
Arms Challenge J. M. Gabrielse
Advice • Balance arms with counterweights – not always possible • Use gears to get extra torque – not always necessary with balanced arms • Use sensors – limit switches to stop arms from over rotating – potentiometers or encoders to control location J. M. Gabrielse
Limit Switches Limit switches tell the robot controller when a device has gone far enough. Software can stop the servos and motors moving the device. J. M. Gabrielse
use limit switches & stop arms mechanically mechanical stop: something the arm hits to physically stop it J. M. Gabrielse
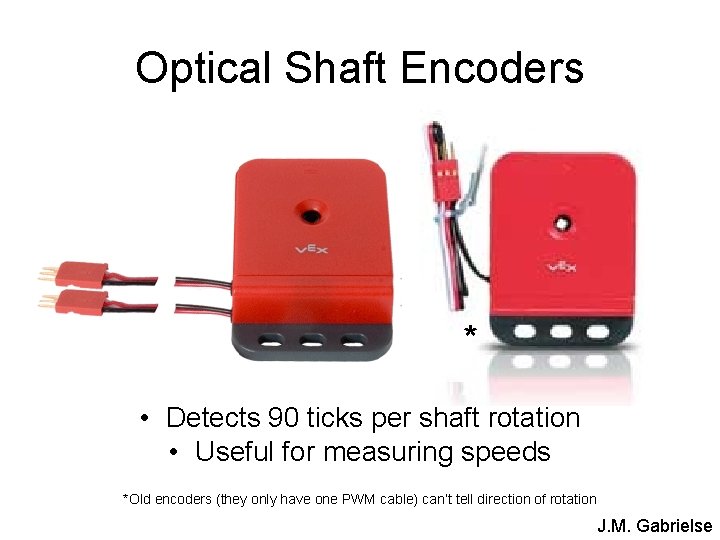
Optical Shaft Encoders * • Detects 90 ticks per shaft rotation • Useful for measuring speeds *Old encoders (they only have one PWM cable) can’t tell direction of rotation J. M. Gabrielse
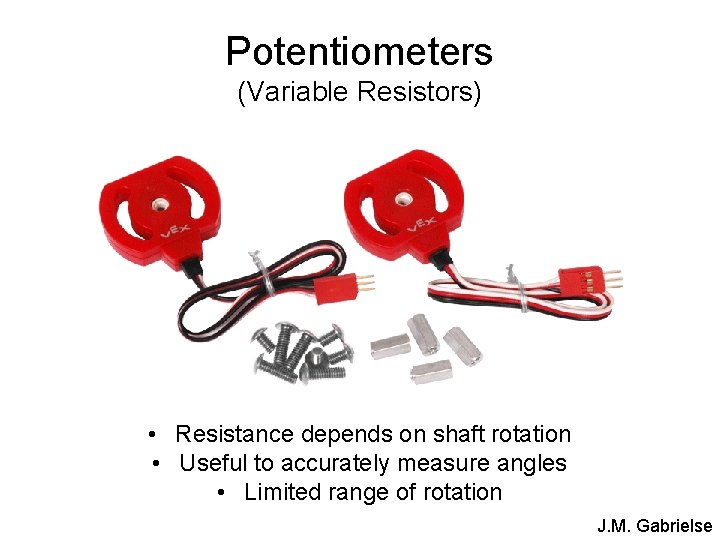
Potentiometers (Variable Resistors) • Resistance depends on shaft rotation • Useful to accurately measure angles • Limited range of rotation J. M. Gabrielse
Thanks/Resources • Designing Competitive Manipulators: The Mechanics & Strategy by Greg Needel (www. robogreg. com) J. M. Gabrielse
- Slides: 18