
University of Aarhus Research Centre Bygholm U N
University of Aarhus, Research Centre Bygholm U N I V E R S I T Y OF A A R H U S Faculty of Agricultural Sciences Institute of Agricultural Engineering, Bygholm
U N I V E R S I T Y OF A A R H U S Faculty of Agricultural Sciences Institute of Agricultural Engineering, Bygholm
Faculties 1. 2. 3. 4. 5. 6. 7. 8. Faculty of Humanities Faculty of Health Sciences Faculty of Social Sciences Faculty of Theology Faculty of Science Faculty of Agricultural Sciences National Environmental Research Institute Aarhus School of Business, University of Aarhus U N I V E R S I T Y OF A A R H U S Faculty of Agricultural Sciences Institute of Agricultural Engineering, Bygholm
Faculty of Agricultural Sciences § § § § Institute of Agricultural Engineering Institute of Genetics and Biotechnology Institue of Horticulture Institute of Animal Health, Welfare and Nutrition Institute of Agroecology Institute of Integrated Pest Management Institute of Food Science U N I V E R S I T Y OF A A R H U S Faculty of Agricultural Sciences Institute of Agricultural Engineering, Bygholm
Institut of Agricultural Engineering Automation and System Engineering Focus areas technology Agrobots- and sensor Innovative tools and technologies farming Environmental and Climate Technology for organic Engineering Focus areas Odour and air quality Ventilation and indoor climate U N I V E R S I T Y OF A A R H U S Faculty of Agricultural Sciences Institute of Agricultural Engineering, Bygholm Animal manure
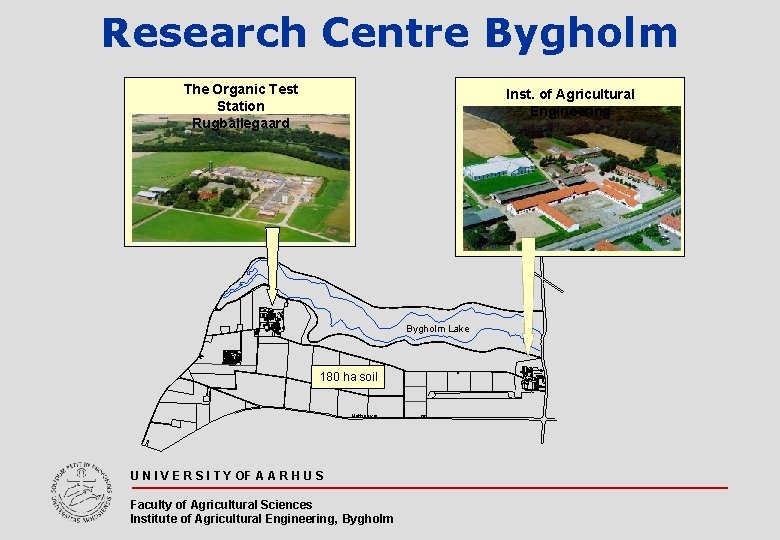
Research Centre Bygholm The Organic Test Station Rugballegaard Inst. of Agricultural Engineering Bygholm Lake 180 ha soil Hattingvej U N I V E R S I T Y OF A A R H U S Faculty of Agricultural Sciences Institute of Agricultural Engineering, Bygholm
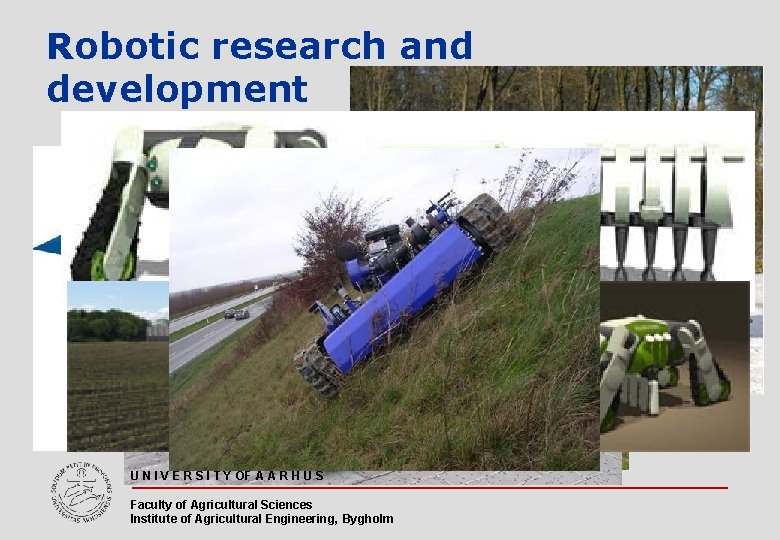
Robotic research and development U N I V E R S I T Y OF A A R H U S Faculty of Agricultural Sciences Institute of Agricultural Engineering, Bygholm
Perspective of auto steering in agriculture Auto Steering – 2005 § In field spring 2005 § John Deere: 7 tractors U N I V E R S I T Y OF A A R H U S Faculty of Agricultural Sciences Institute of Agricultural Engineering, Bygholm 10 cm
Perspective of auto steering in agriculture Auto Steering – 2006 § In field spring 2006 § John Deere: 40 tractors § Auto. Farm: 10 tractors U N I V E R S I T Y OF A A R H U S Faculty of Agricultural Sciences Institute of Agricultural Engineering, Bygholm 10 cm 2 cm
Perspective of auto steering in agriculture Auto Steering – 2007 § In field spring 2007 § § John Deere: Auto. Farm: Trimble: Agco: 170 tractors 40 tractors 5+ tractors 5 tractors U N I V E R S I T Y OF A A R H U S Faculty of Agricultural Sciences Institute of Agricultural Engineering, Bygholm 10 cm 2 cm (95%) (no RTK) (1 RTK)
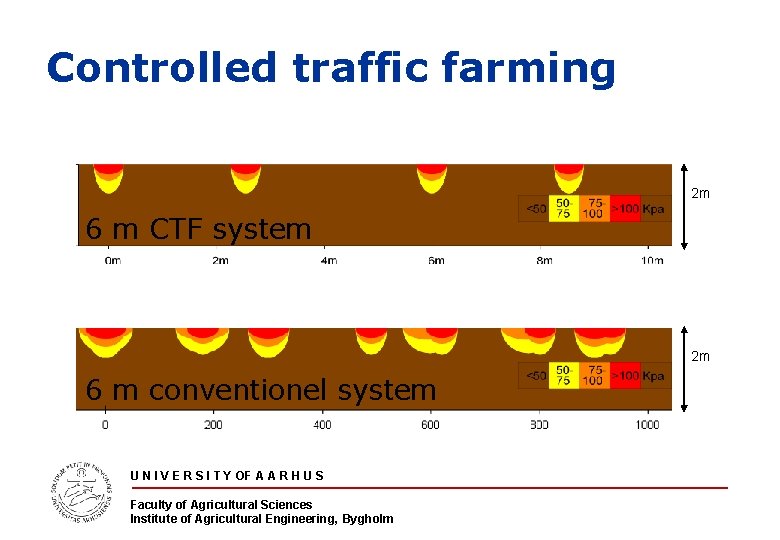
Controlled traffic farming 2 m 6 m CTF system 2 m 6 m conventionel system U N I V E R S I T Y OF A A R H U S Faculty of Agricultural Sciences Institute of Agricultural Engineering, Bygholm
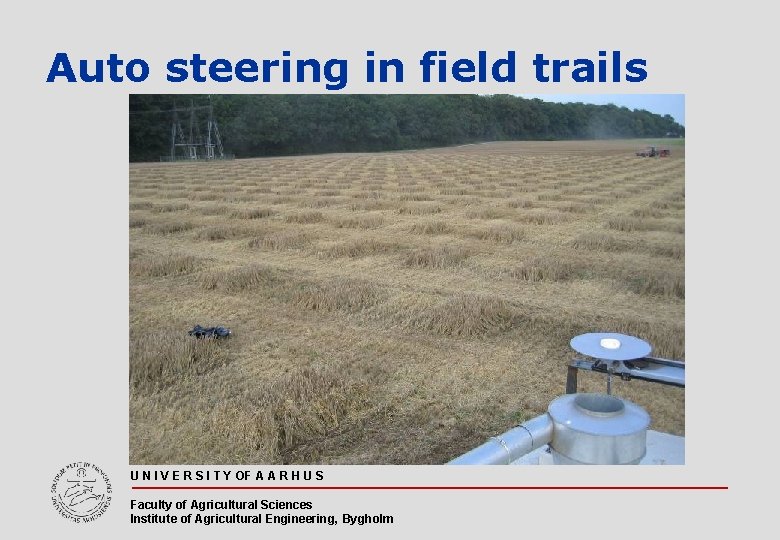
Auto steering in field trails U N I V E R S I T Y OF A A R H U S Faculty of Agricultural Sciences Institute of Agricultural Engineering, Bygholm
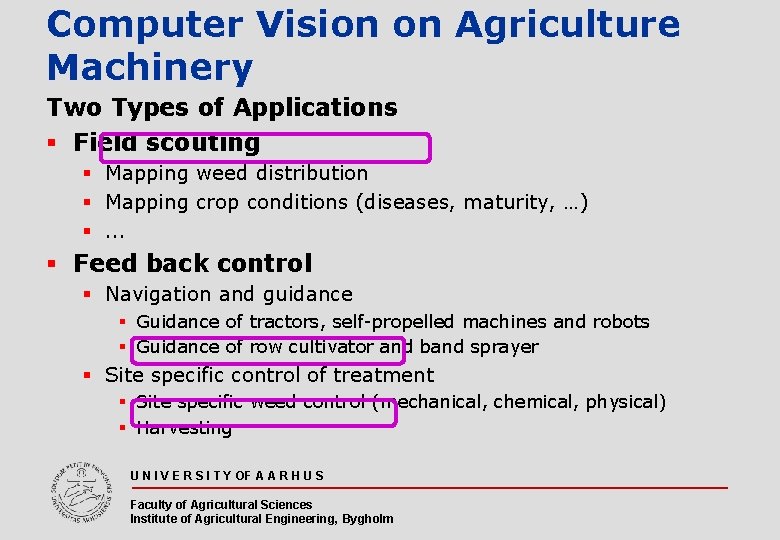
Computer Vision on Agriculture Machinery Two Types of Applications § Field scouting § Mapping weed distribution § Mapping crop conditions (diseases, maturity, …) §. . . § Feed back control § Navigation and guidance § Guidance of tractors, self-propelled machines and robots § Guidance of row cultivator and band sprayer § Site specific control of treatment § Site specific weed control (mechanical, chemical, physical) § Harvesting U N I V E R S I T Y OF A A R H U S Faculty of Agricultural Sciences Institute of Agricultural Engineering, Bygholm
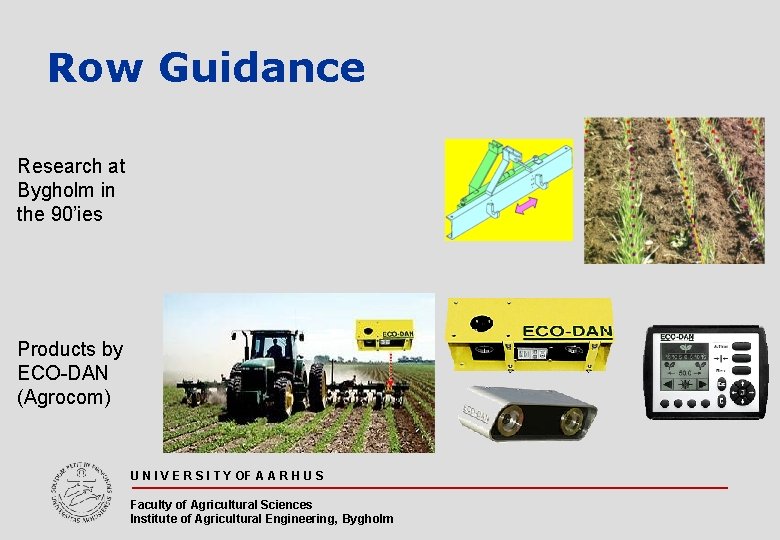
Row Guidance Research at Bygholm in the 90’ies Products by ECO-DAN (Agrocom) U N I V E R S I T Y OF A A R H U S Faculty of Agricultural Sciences Institute of Agricultural Engineering, Bygholm
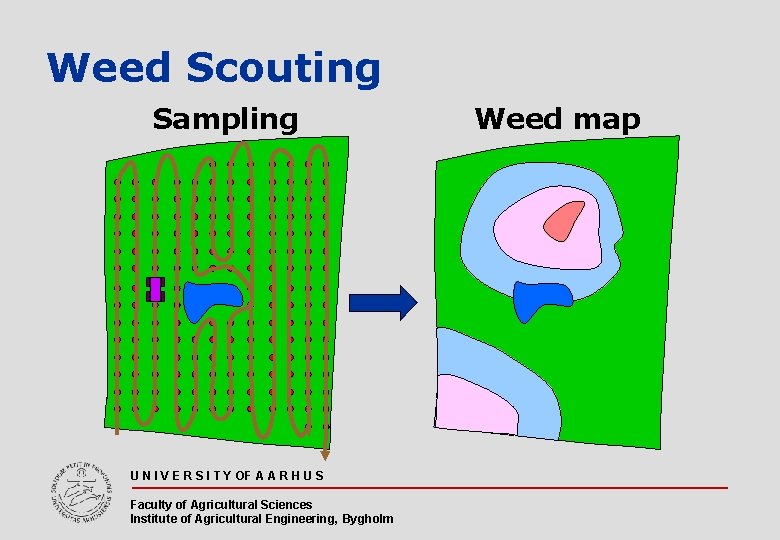
Weed Scouting Sampling U N I V E R S I T Y OF A A R H U S Faculty of Agricultural Sciences Institute of Agricultural Engineering, Bygholm Weed map
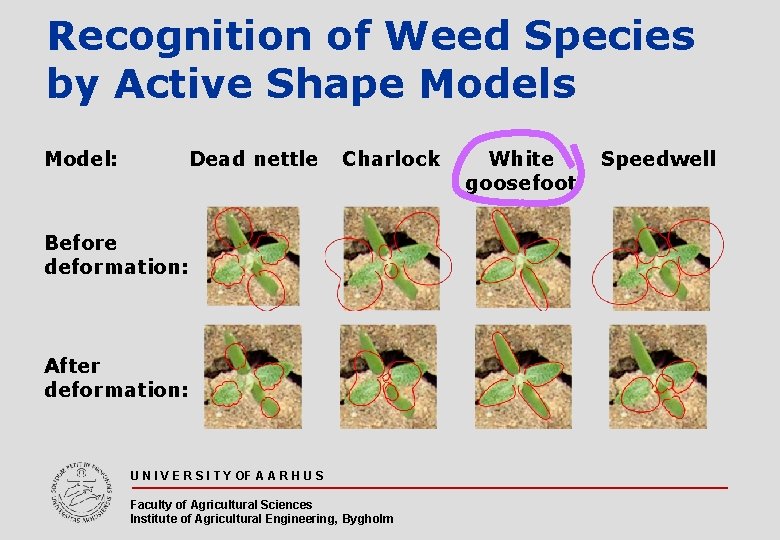
Recognition of Weed Species by Active Shape Models Model: Dead nettle Charlock Before deformation: After deformation: U N I V E R S I T Y OF A A R H U S Faculty of Agricultural Sciences Institute of Agricultural Engineering, Bygholm White goosefoot Speedwell
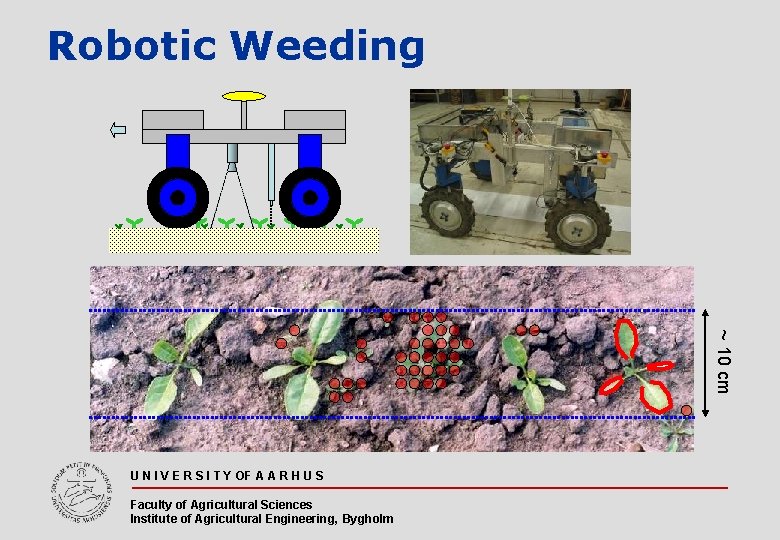
Robotic Weeding ~ 10 cm U N I V E R S I T Y OF A A R H U S Faculty of Agricultural Sciences Institute of Agricultural Engineering, Bygholm
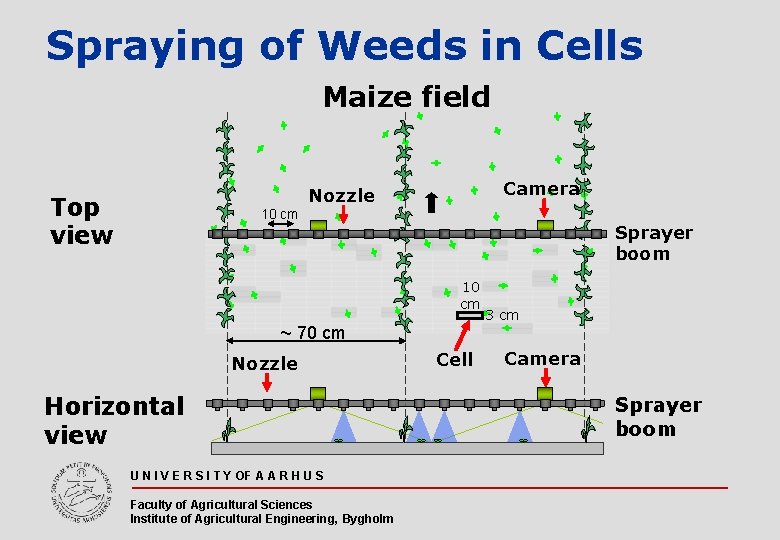
Spraying of Weeds in Cells Maize field Top view 10 cm Camera Nozzle Sprayer boom 10 cm ~ 70 cm Nozzle Horizontal view U N I V E R S I T Y OF A A R H U S Faculty of Agricultural Sciences Institute of Agricultural Engineering, Bygholm Cell 3 cm Camera Sprayer boom
ICT and mobile work units U N I V E R S I T Y OF A A R H U S Faculty of Agricultural Sciences Institute of Agricultural Engineering, Bygholm
Source: Info. XT project U N I V E R S I T Y OF A A R H U S Faculty of Agricultural Sciences Institute of Agricultural Engineering, Bygholm
Use of information/data § Documentation in the food chain § Process planning and controlling § Input to decision support models § Input to automated control loop U N I V E R S I T Y OF A A R H U S Faculty of Agricultural Sciences Institute of Agricultural Engineering, Bygholm
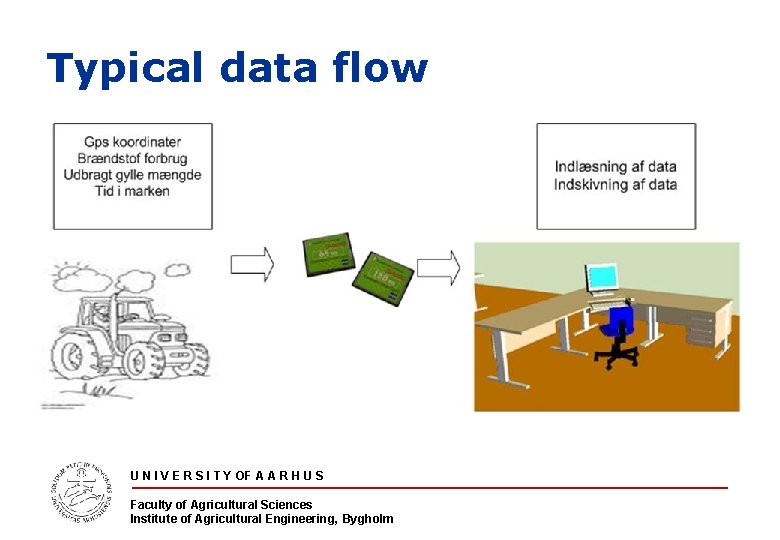
Typical data flow U N I V E R S I T Y OF A A R H U S Faculty of Agricultural Sciences Institute of Agricultural Engineering, Bygholm
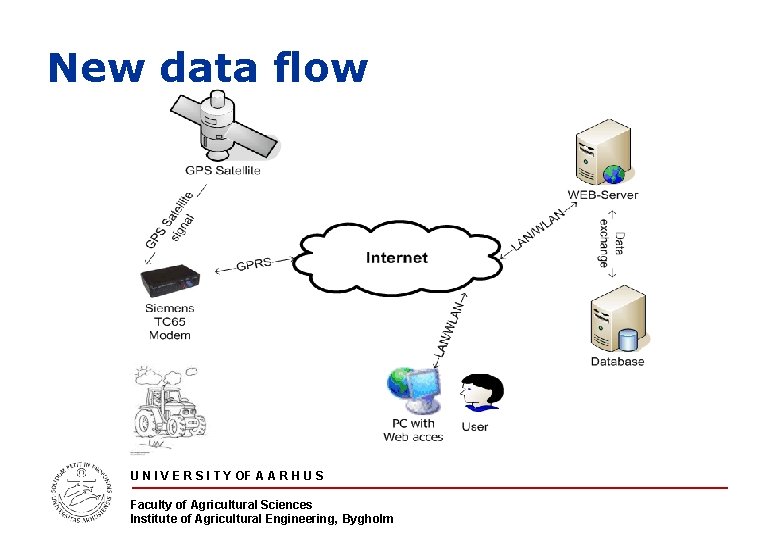
New data flow U N I V E R S I T Y OF A A R H U S Faculty of Agricultural Sciences Institute of Agricultural Engineering, Bygholm
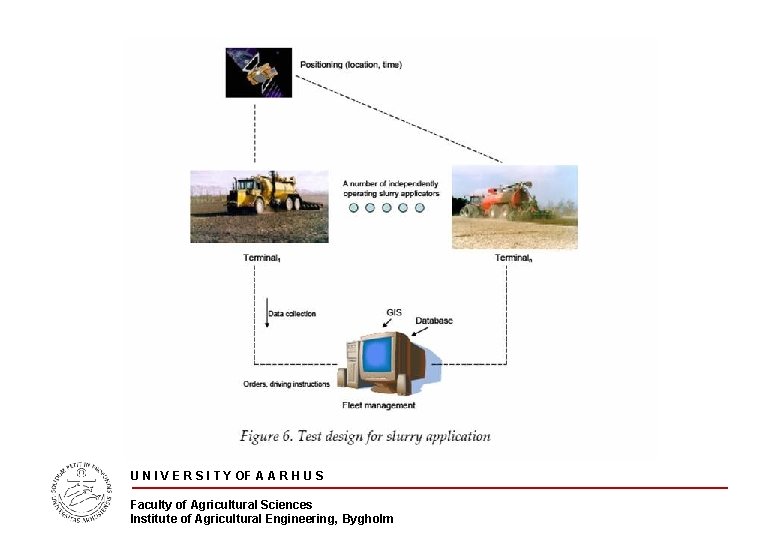
Idea § Use a mobile computer to log data from a traktor (e. g. gps data). § Transmit data wireless to a database. Analyse data and optimise the operation in order to reach an improved field efficiency § Present the received data on a web-server. U N I V E R S I T Y OF A A R H U S Faculty of Agricultural Sciences Institute of Agricultural Engineering, Bygholm
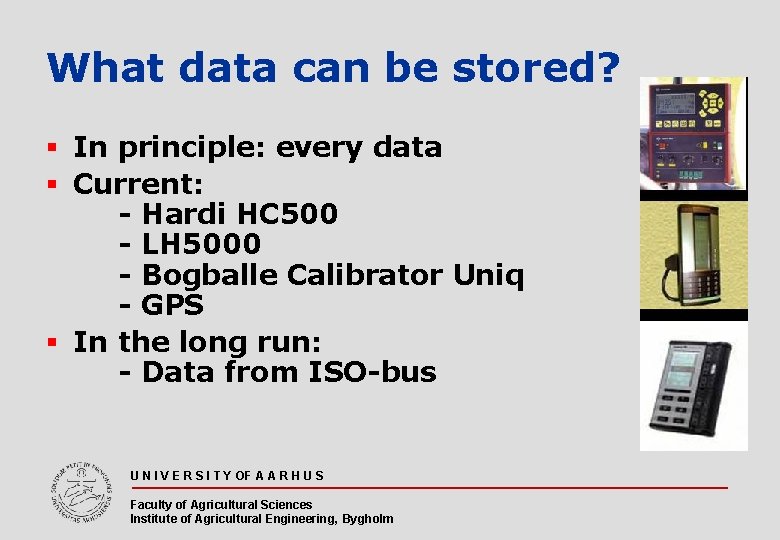
What data can be stored? § In principle: every data § Current: - Hardi HC 500 - LH 5000 - Bogballe Calibrator Uniq - GPS § In the long run: - Data from ISO-bus U N I V E R S I T Y OF A A R H U S Faculty of Agricultural Sciences Institute of Agricultural Engineering, Bygholm
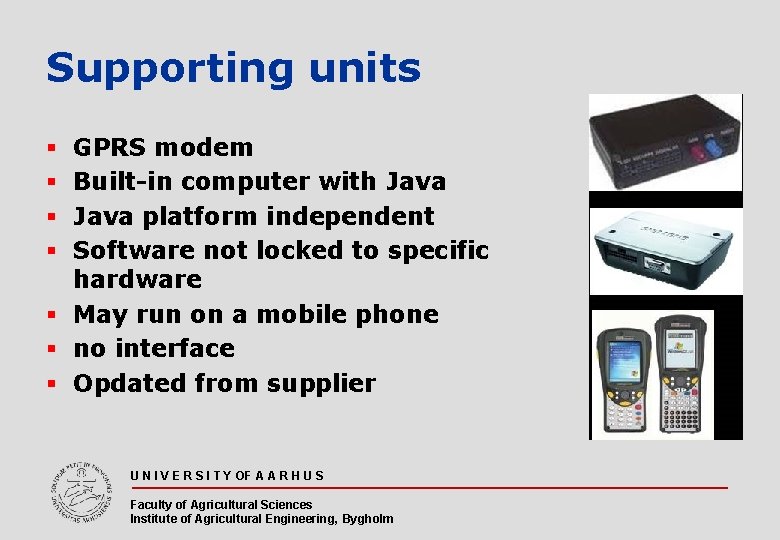
Supporting units GPRS modem Built-in computer with Java platform independent Software not locked to specific hardware § May run on a mobile phone § no interface § Opdated from supplier § § U N I V E R S I T Y OF A A R H U S Faculty of Agricultural Sciences Institute of Agricultural Engineering, Bygholm
Information intensive arable farming § Automatic data acquisition and process control (legislation and progressive farmers) § Fleet management systems (contractors) § Automatic guidance systems (progressive farmers) § Site specific treatment (require more sophisticated economic and ecologic evaluation) U N I V E R S I T Y OF A A R H U S Faculty of Agricultural Sciences Institute of Agricultural Engineering, Bygholm
U N I V E R S I T Y OF A A R H U S Faculty of Agricultural Sciences Institute of Agricultural Engineering, Bygholm
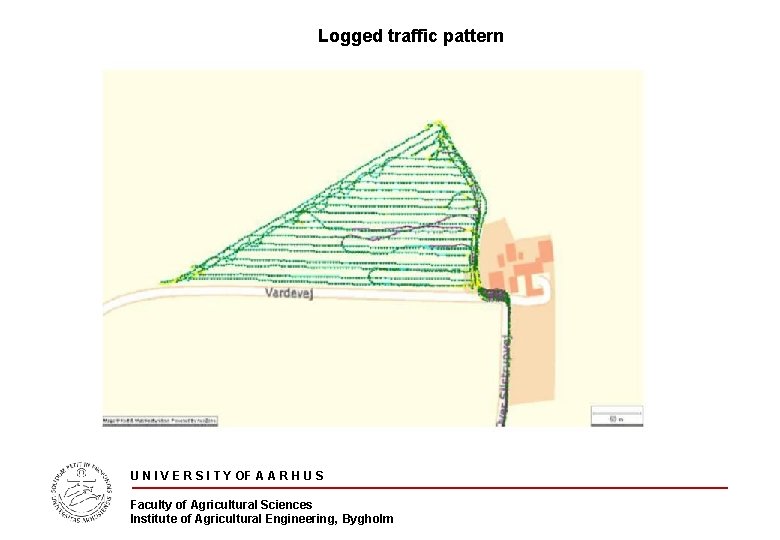
Logged traffic pattern U N I V E R S I T Y OF A A R H U S Faculty of Agricultural Sciences Institute of Agricultural Engineering, Bygholm
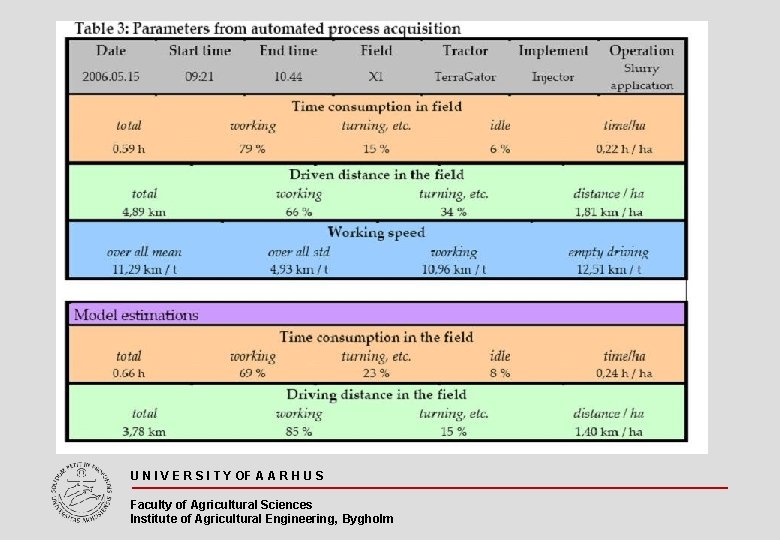
U N I V E R S I T Y OF A A R H U S Faculty of Agricultural Sciences Institute of Agricultural Engineering, Bygholm
Information intensive arable farming § Automatic data acquisition and process controlling (legislation and progressive farmers) § Fleet management systems (contractors) § Automatic guidance systems (progressive farmers) § Site specific treatment (progressive farmers, require more sophisticated economic and ecologic evaluation) U N I V E R S I T Y OF A A R H U S Faculty of Agricultural Sciences Institute of Agricultural Engineering, Bygholm
Current activities § Automatic data acquisition § Mobile internet services for on-line support of agricultural machinery § User-centric information management in automated plant production § Design and evaluation of ICT systems U N I V E R S I T Y OF A A R H U S Faculty of Agricultural Sciences Institute of Agricultural Engineering, Bygholm
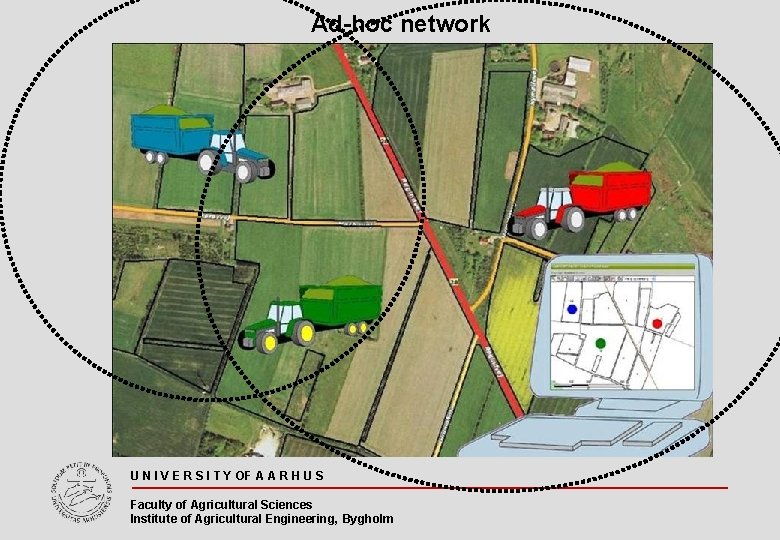
Ad-hoc network U N I V E R S I T Y OF A A R H U S Faculty of Agricultural Sciences Institute of Agricultural Engineering, Bygholm
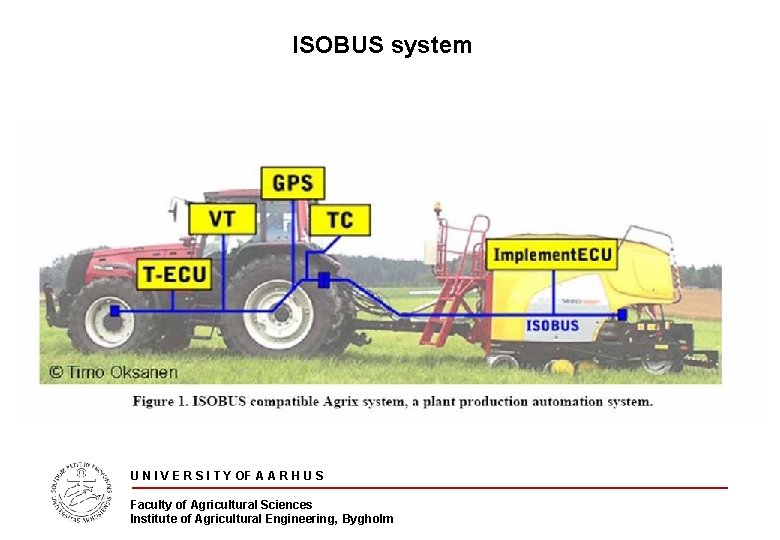
ISOBUS system U N I V E R S I T Y OF A A R H U S Faculty of Agricultural Sciences Institute of Agricultural Engineering, Bygholm
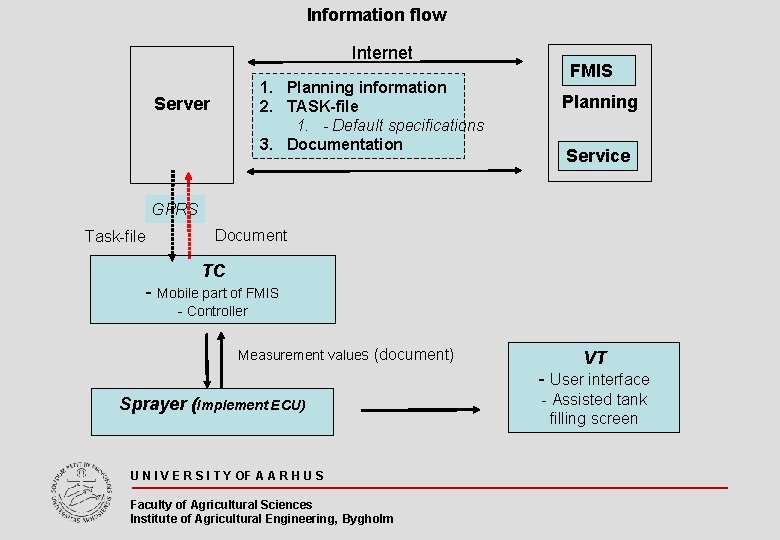
Information flow Internet 1. Planning information 2. TASK-file 1. - Default specifications - Default 3. Documentation Server FMIS Planning Service GPRS Task-file Document TC - Mobile part of FMIS - Controller Measurement values (document) VT - User interface Sprayer (Implement ECU) U N I V E R S I T Y OF A A R H U S Faculty of Agricultural Sciences Institute of Agricultural Engineering, Bygholm - Assisted tank filling screen
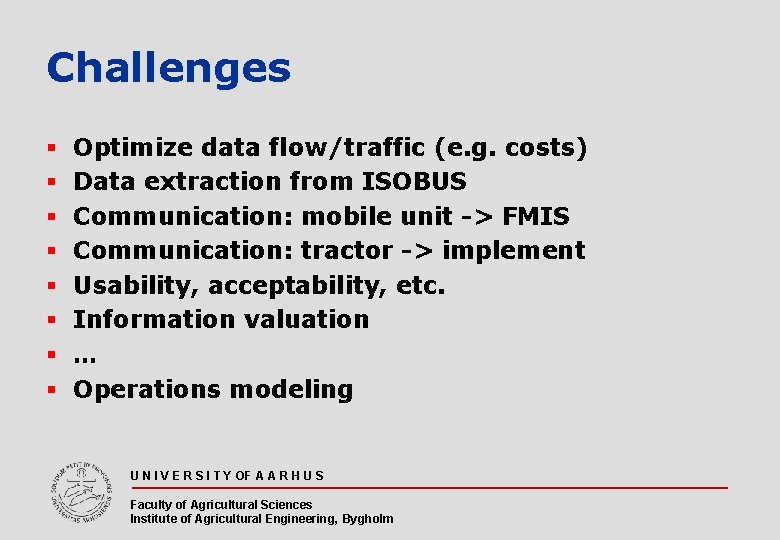
Challenges § § § § Optimize data flow/traffic (e. g. costs) Data extraction from ISOBUS Communication: mobile unit -> FMIS Communication: tractor -> implement Usability, acceptability, etc. Information valuation … Operations modeling U N I V E R S I T Y OF A A R H U S Faculty of Agricultural Sciences Institute of Agricultural Engineering, Bygholm
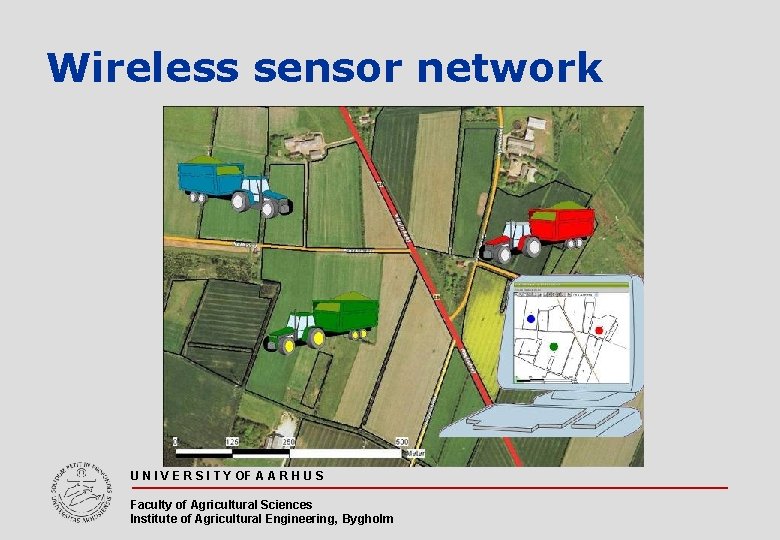
Wireless sensor network U N I V E R S I T Y OF A A R H U S Faculty of Agricultural Sciences Institute of Agricultural Engineering, Bygholm
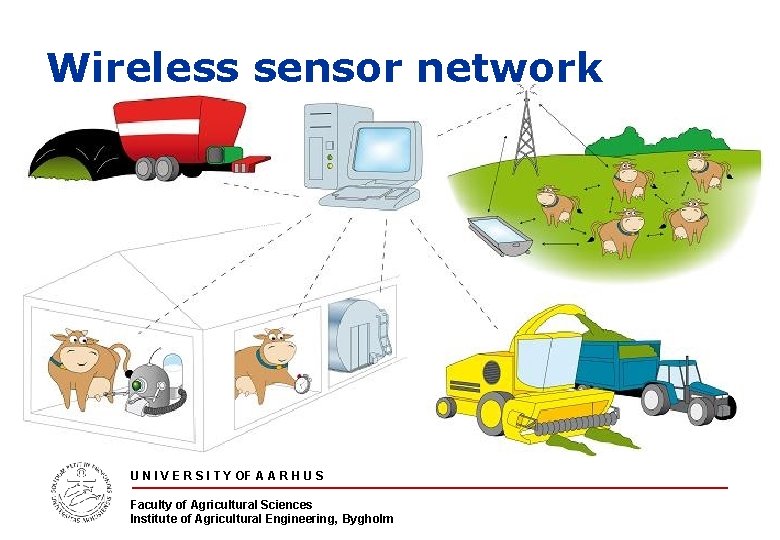
Wireless sensor network U N I V E R S I T Y OF A A R H U S Faculty of Agricultural Sciences Institute of Agricultural Engineering, Bygholm
- Slides: 38