
The Secrets of Mr Roboto BY CHRIS WAN
The Secrets of Mr. Roboto BY CHRIS WAN JESSICA GIMA
Goals of Project To develop an understanding of how a robot arm moves (in 2 -D) To cover the linear systems topics of transformations (rotation and translation matrix) and homogeneous coordinates.
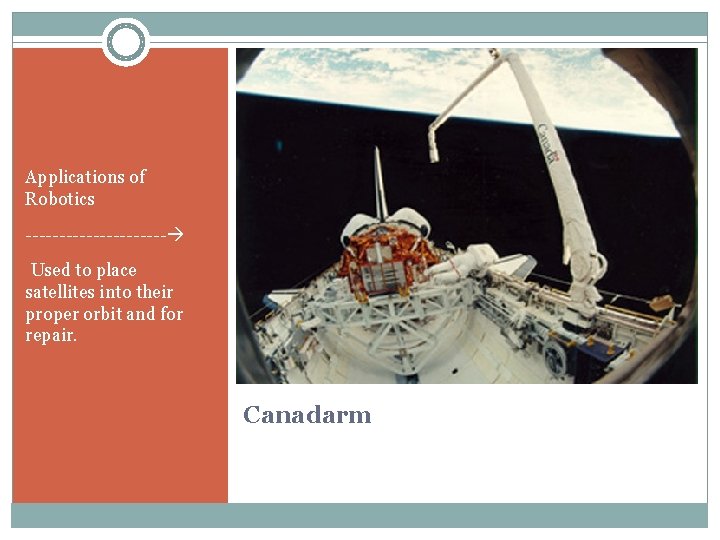
Applications of Robotics ----------- • Used to place satellites into their proper orbit and for repair. Canadarm
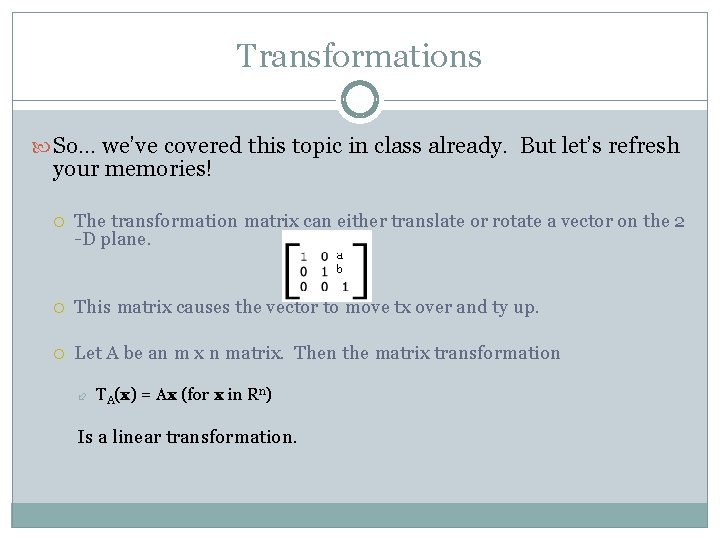
Transformations So… we’ve covered this topic in class already. But let’s refresh your memories! The transformation matrix can either translate or rotate a vector on the 2 -D plane. This matrix causes the vector to move tx over and ty up. Let A be an m x n matrix. Then the matrix transformation TA(x) = Ax (for x in Rn) Is a linear transformation.
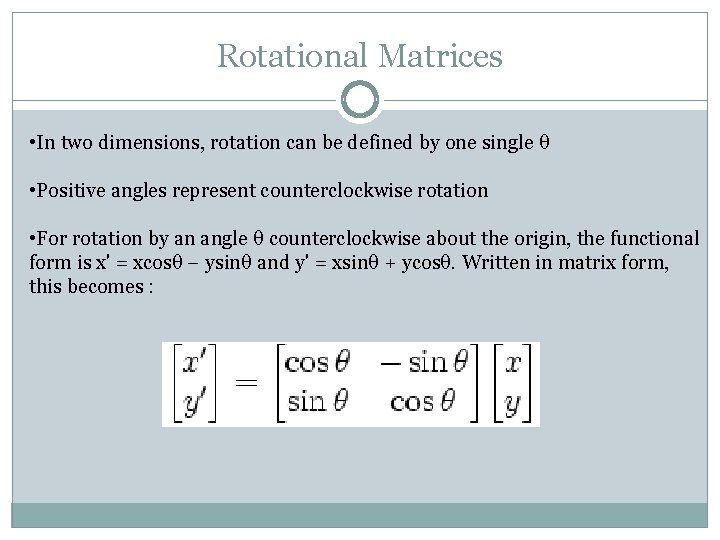
Rotational Matrices • In two dimensions, rotation can be defined by one single θ • Positive angles represent counterclockwise rotation • For rotation by an angle θ counterclockwise about the origin, the functional form is x' = xcosθ − ysinθ and y' = xsinθ + ycosθ. Written in matrix form, this becomes :
Translations are not a linear transformation because T(0) ≠ 0 If x = [x ; y] & v = [a ; b], then a translation along v is the transformation T(x) = x + v T[x ; y] = [(x+a) ; (y+b)]
Homogeneous Coordinates Affine transformation – any transformation that preserves co-linearity. It can be a combo of translation and rotation matrices (this pertains to our project). Homogeneous coordinates allow affine transformations to be easily represented by a matrix. Homogeneous coordinates - points in 2 D space that may be viewed as projections of points in 3 D space, all being multiples of each other. The coordinates of any of these points are the homogeneous coordinates of the given point.
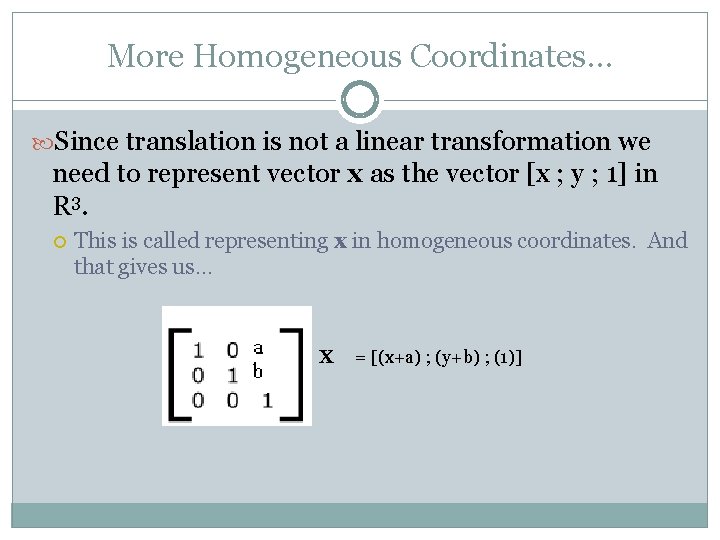
More Homogeneous Coordinates… Since translation is not a linear transformation we need to represent vector x as the vector [x ; y ; 1] in R 3. This is called representing x in homogeneous coordinates. And that gives us… X = [(x+a) ; (y+b) ; (1)]
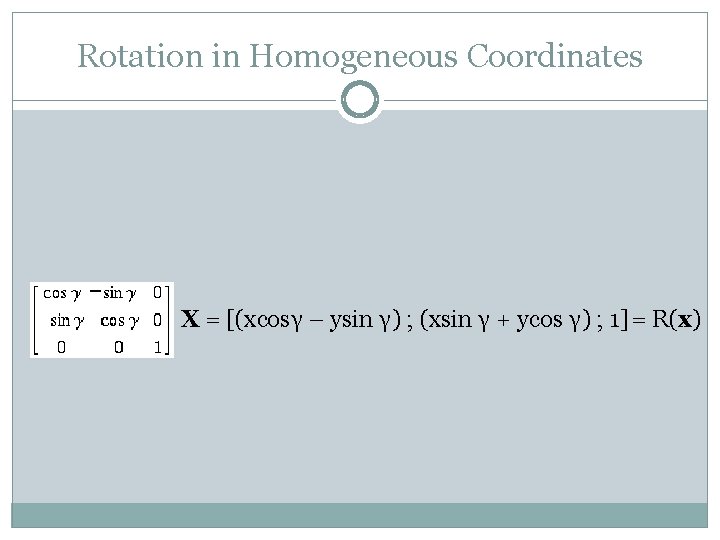
Rotation in Homogeneous Coordinates X = [(xcosγ – ysin γ) ; (xsin γ + ycos γ) ; 1]= R(x)
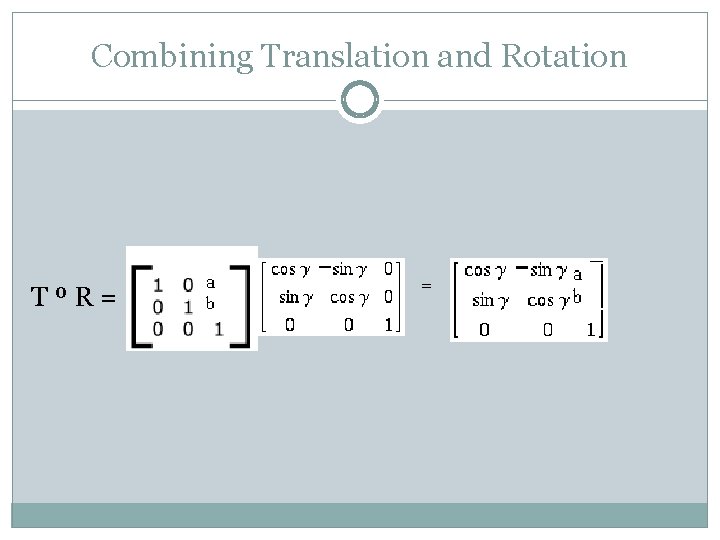
Combining Translation and Rotation T º R = =
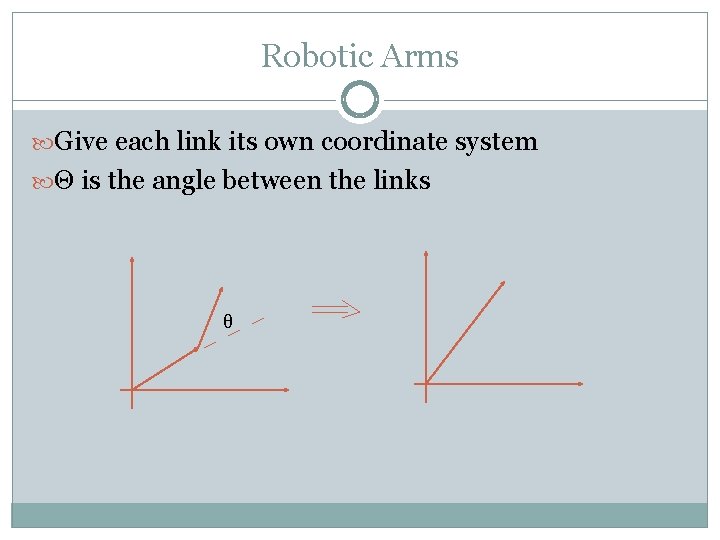
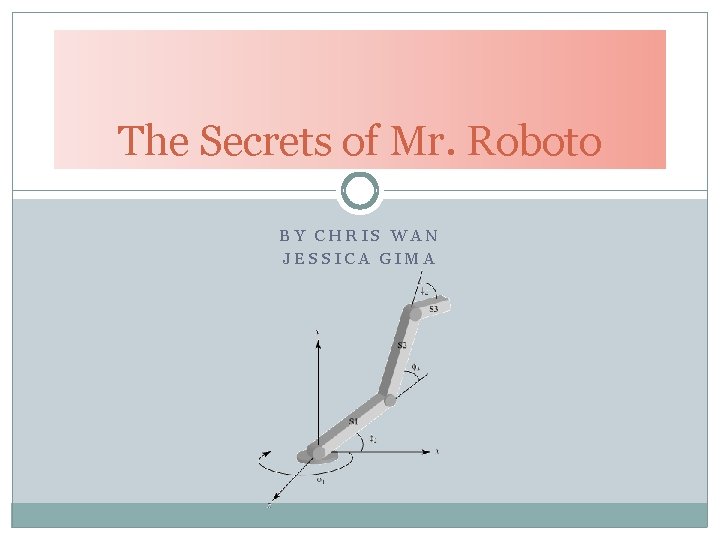
Robotic Arms Give each link its own coordinate system Θ is the angle between the links θ
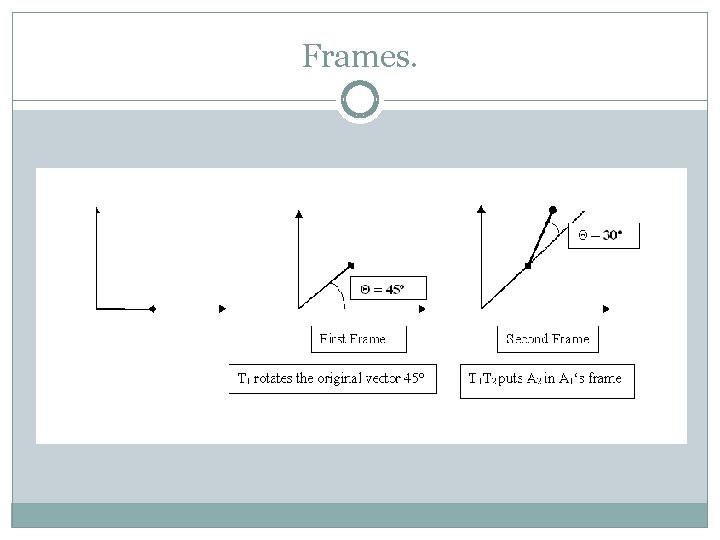
Frames.
Bibliography Weisstein, Eric W. "Rotation Matrix. " From Math. World--A Wolfram Web Resource. http: //mathworld. wolfram. com/Rotation. Matrix. html Poole, David. Linear Algebra. 2 nd ed. Ontario: Thompson Brooks/Cole, 2006. 224 -227. Farin, Gerald, and Dianne Hansford. Practical Linear Algebra - a Geometry Toolbook. 2 nd ed. Haverford: AK Peters, Ltd. , 2005. 1 -4. "Transformation Matrix. " Wikipedia Foundation Inc. , 2006. Wikipedia. 26 Apr. 2007. http: //en. wikipedia. org/wiki/Transformation_Matrices
- Slides: 13