
The CISST Software Package Peter Kazanzides Johns Hopkins
- Slides: 25
The CISST Software Package Peter Kazanzides Johns Hopkins University www. cisst. org November 16, 2005 Copyright © CISST ERC, 2005 NSF Engineering Research Center for Computer Integrated Surgical Systems and Technology
Outline • Background and Motivation • Where are we going? • CISST Libraries – Foundation libraries – Real time support • Development process and tools • Tour of web site Copyright © CISST ERC, 2005 NSF Engineering Research Center for Computer Integrated Surgical Systems and Technology
Historical Background • ERC-developed software was captured in: – CIS library • • Common tools, such as logging Vectors, matrices, transformations Interface to tracking systems Numerical methods, registration, … – MRC library • Common interface to different robots • Essentially a “wrapper” around API for hardware that provides low-level control Copyright © CISST ERC, 2005 NSF Engineering Research Center for Computer Integrated Surgical Systems and Technology
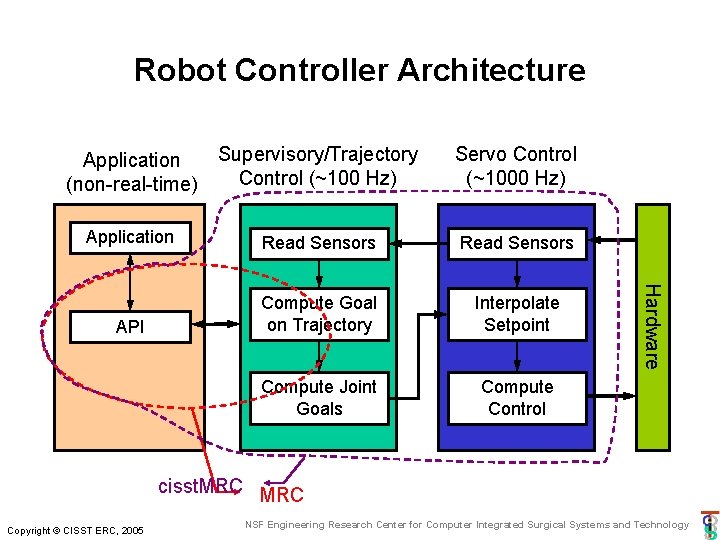
Robot Controller Architecture Supervisory/Trajectory Control (~100 Hz) Servo Control (~1000 Hz) Application Read Sensors API Compute Goal on Trajectory Interpolate Setpoint Compute Joint Goals Compute Control Hardware Application (non-real-time) cisst. MRC Copyright © CISST ERC, 2005 NSF Engineering Research Center for Computer Integrated Surgical Systems and Technology
Motivation for CISST Package • Improve process, design, testing, portability, maintainability for open source release and to facilitate clinical use: – – – Programming standards Design reviews Portable build tools Automated testing User documentation • Enable the development of real-time software for physical devices such as robots and trackers Copyright © CISST ERC, 2005 NSF Engineering Research Center for Computer Integrated Surgical Systems and Technology
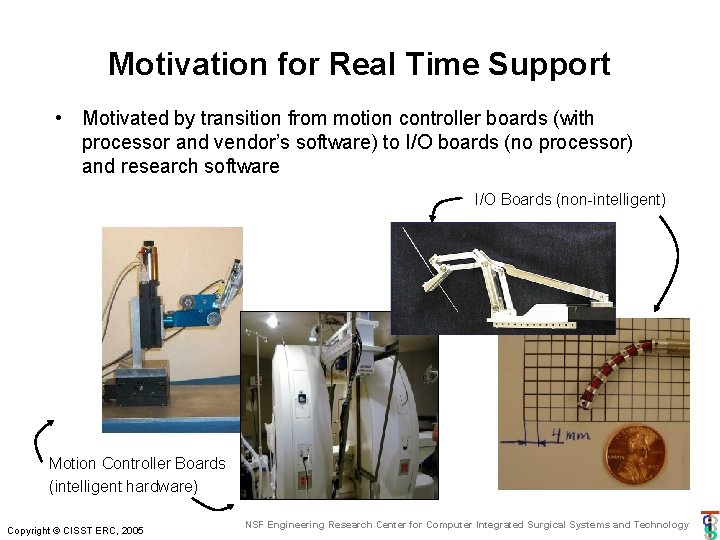
Motivation for Real Time Support • Motivated by transition from motion controller boards (with processor and vendor’s software) to I/O boards (no processor) and research software I/O Boards (non-intelligent) Motion Controller Boards (intelligent hardware) Copyright © CISST ERC, 2005 NSF Engineering Research Center for Computer Integrated Surgical Systems and Technology
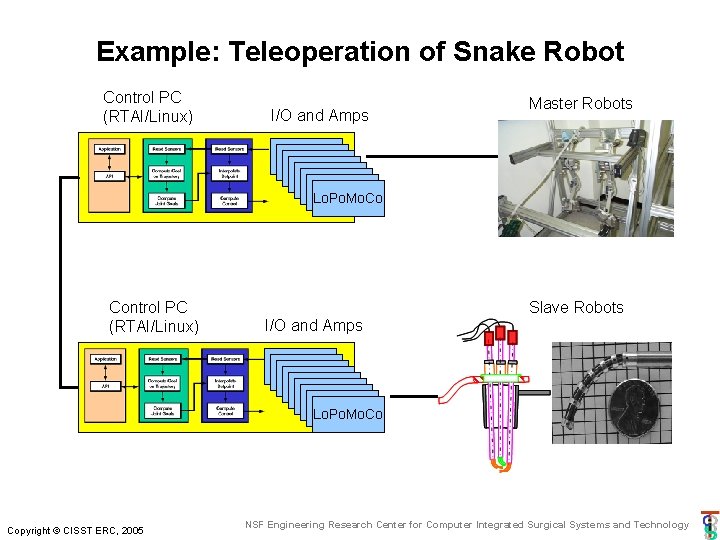
Example: Teleoperation of Snake Robot Control PC (RTAI/Linux) I/O and Amps Master Robots Lo. Po. Mo. Co Control PC (RTAI/Linux) Slave Robots I/O and Amps Lo. Po. Mo. Co Copyright © CISST ERC, 2005 NSF Engineering Research Center for Computer Integrated Surgical Systems and Technology
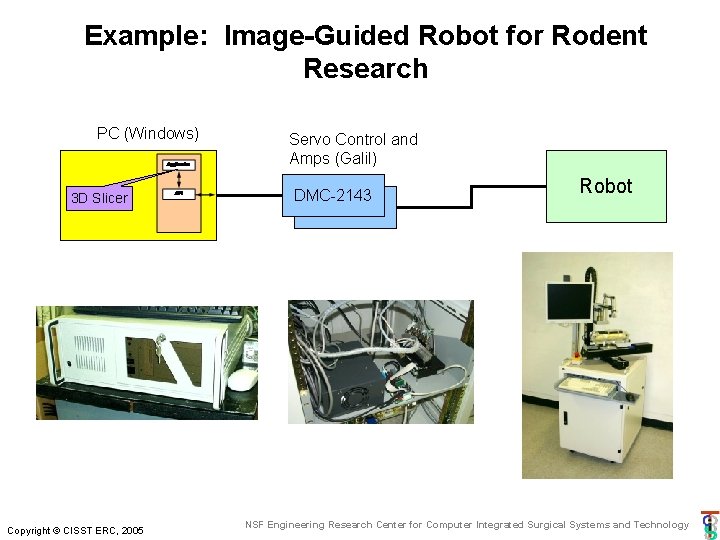
Example: Image-Guided Robot for Rodent Research PC (Windows) 3 D Slicer Copyright © CISST ERC, 2005 Servo Control and Amps (Galil) DMC-2143 Robot NSF Engineering Research Center for Computer Integrated Surgical Systems and Technology
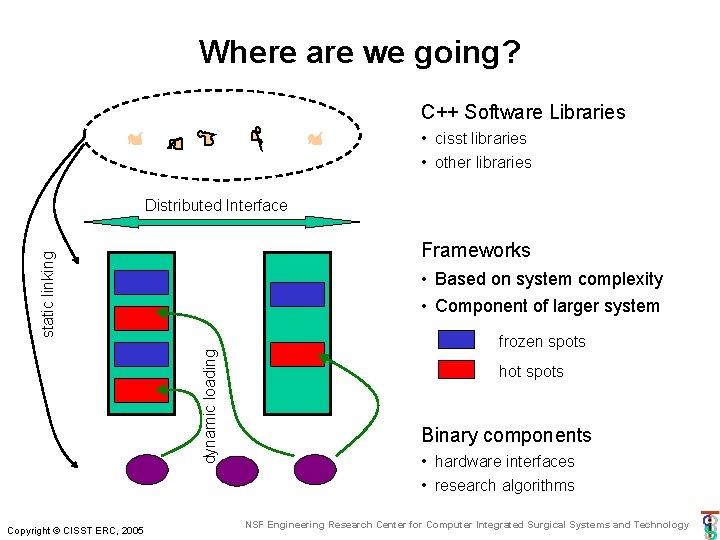
Where are we going? C++ Software Libraries • cisst libraries • other libraries Distributed Interface static linking Frameworks dynamic loading • Based on system complexity • Component of larger system Copyright © CISST ERC, 2005 frozen spots hot spots Binary components • hardware interfaces • research algorithms NSF Engineering Research Center for Computer Integrated Surgical Systems and Technology
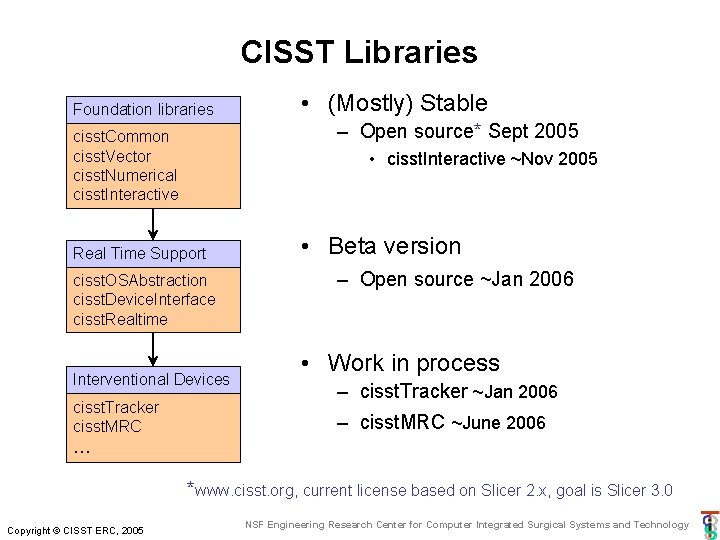
CISST Libraries Foundation libraries – Open source* Sept 2005 cisst. Common cisst. Vector cisst. Numerical cisst. Interactive • cisst. Interactive ~Nov 2005 Real Time Support cisst. OSAbstraction cisst. Device. Interface cisst. Realtime Interventional Devices cisst. Tracker cisst. MRC • (Mostly) Stable • Beta version – Open source ~Jan 2006 • Work in process – cisst. Tracker ~Jan 2006 – cisst. MRC ~June 2006 … *www. cisst. org, current license based on Slicer 2. x, goal is Slicer 3. 0 Copyright © CISST ERC, 2005 NSF Engineering Research Center for Computer Integrated Surgical Systems and Technology
cisst. Vector • Vectors, Matrices and Transformations • Extensive use of C++ templates (metaprogramming) • Fixed size and dynamic – Fixed size especially suited for real-time code • Operations on slices and sub-regions • References to vectors and matrices – Improves interoperability with other libraries • Matrices in row-major or column-major format • C++ wrapping of Net. Lib (numerical methods, including CLAPACK, MINPACK) Copyright © CISST ERC, 2005 NSF Engineering Research Center for Computer Integrated Surgical Systems and Technology
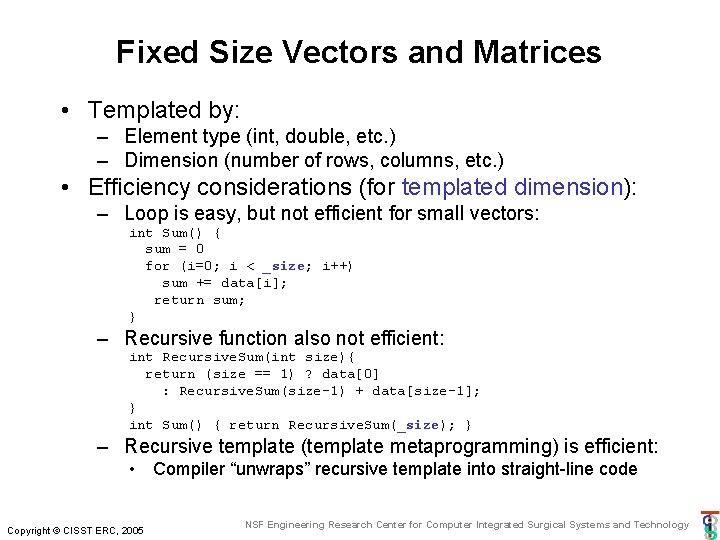
Fixed Size Vectors and Matrices • Templated by: – Element type (int, double, etc. ) – Dimension (number of rows, columns, etc. ) • Efficiency considerations (for templated dimension): – Loop is easy, but not efficient for small vectors: int Sum() { sum = 0 for (i=0; i < _size; i++) sum += data[i]; return sum; } – Recursive function also not efficient: int Recursive. Sum(int size){ return (size == 1) ? data[0] : Recursive. Sum(size-1) + data[size-1]; } int Sum() { return Recursive. Sum(_size); } – Recursive template (template metaprogramming) is efficient: • Compiler “unwraps” recursive template into straight-line code Copyright © CISST ERC, 2005 NSF Engineering Research Center for Computer Integrated Surgical Systems and Technology
Fixed Size Vectors and Matrices • Operations provided by “recursive engines”: – Classify operations by: • • Number of operands Type of result Storage location for result – Small number of engines handle all operations • Example: same engine for addition, subtraction, … Copyright © CISST ERC, 2005 NSF Engineering Research Center for Computer Integrated Surgical Systems and Technology
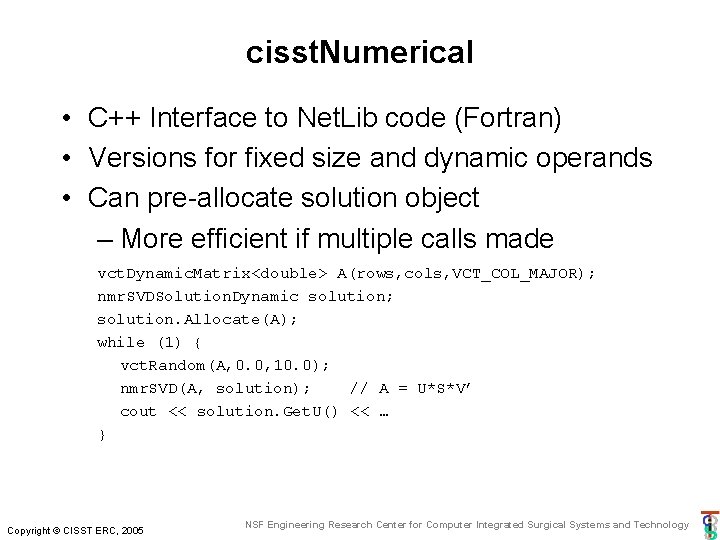
cisst. Numerical • C++ Interface to Net. Lib code (Fortran) • Versions for fixed size and dynamic operands • Can pre-allocate solution object – More efficient if multiple calls made vct. Dynamic. Matrix<double> A(rows, cols, VCT_COL_MAJOR); nmr. SVDSolution. Dynamic solution; solution. Allocate(A); while (1) { vct. Random(A, 0. 0, 10. 0); nmr. SVD(A, solution); // A = U*S*V’ cout << solution. Get. U() << … } Copyright © CISST ERC, 2005 NSF Engineering Research Center for Computer Integrated Surgical Systems and Technology
cisst vs. VNL • cisst. Vector/cisst. Numerical benefits: – More efficient fixed size vectors (few loops) – Stride allows operations on slices (e. g. , can access matrix columns as vectors) – Matrices can be in column-major format (more efficient with Net. Lib) • VNL benefits: – Mature package, larger development community – More features (polynomials, Matlab file I/O, …) – Support for more compilers Copyright © CISST ERC, 2005 NSF Engineering Research Center for Computer Integrated Surgical Systems and Technology
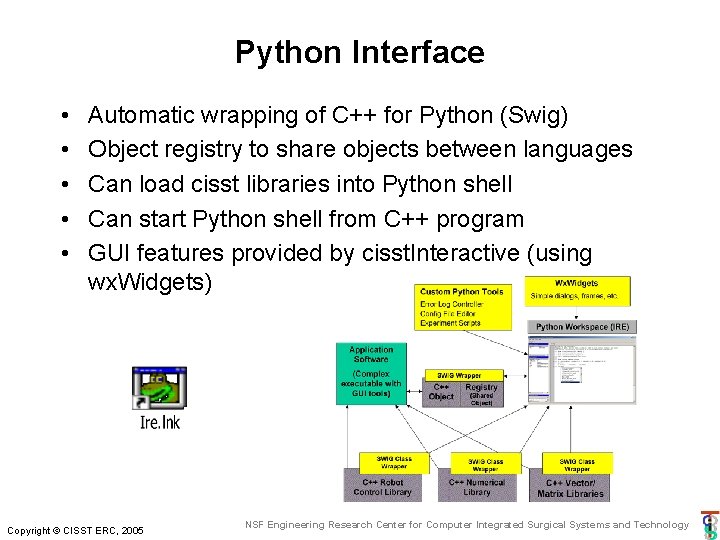
Python Interface • • • Automatic wrapping of C++ for Python (Swig) Object registry to share objects between languages Can load cisst libraries into Python shell Can start Python shell from C++ program GUI features provided by cisst. Interactive (using wx. Widgets) Copyright © CISST ERC, 2005 NSF Engineering Research Center for Computer Integrated Surgical Systems and Technology
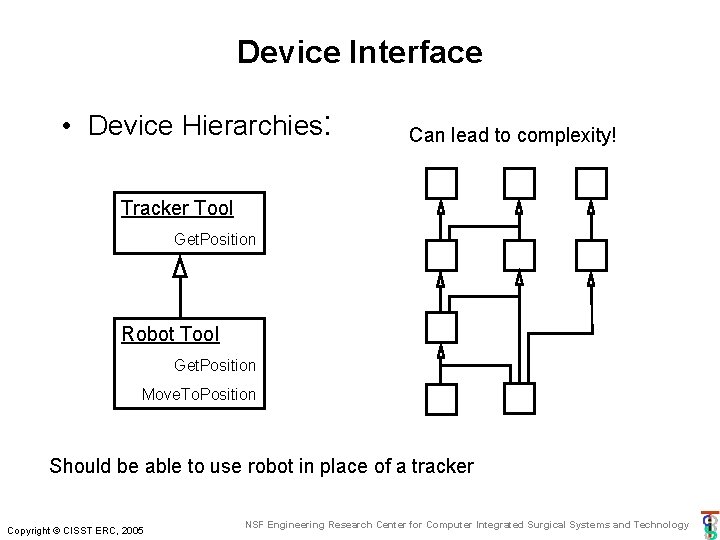
Device Interface • Device Hierarchies: Can lead to complexity! Tracker Tool Get. Position Robot Tool Get. Position Move. To. Position Should be able to use robot in place of a tracker Copyright © CISST ERC, 2005 NSF Engineering Research Center for Computer Integrated Surgical Systems and Technology
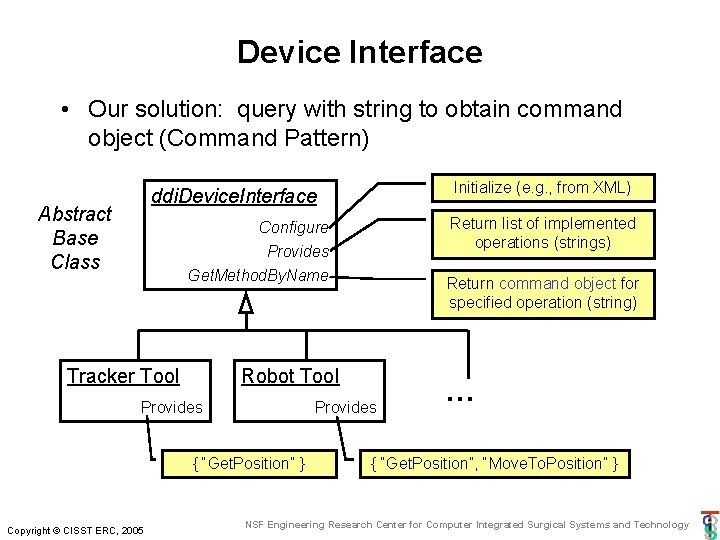
Device Interface • Our solution: query with string to obtain command object (Command Pattern) Initialize (e. g. , from XML) ddi. Device. Interface Abstract Base Class Return list of implemented operations (strings) Configure Provides Get. Method. By. Name Tracker Tool Robot Tool Provides { “Get. Position” } Copyright © CISST ERC, 2005 Return command object for specified operation (string) … { “Get. Position”, “Move. To. Position” } NSF Engineering Research Center for Computer Integrated Surgical Systems and Technology
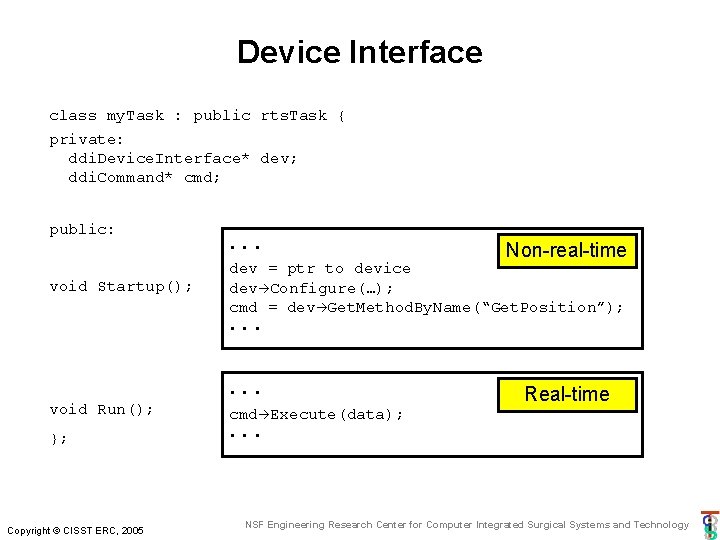
Device Interface class my. Task : public rts. Task { private: ddi. Device. Interface* dev; ddi. Command* cmd; public: void Startup(); ··· Non-real-time dev = ptr to device dev Configure(…); cmd = dev Get. Method. By. Name(“Get. Position”); ··· void Run(); }; Copyright © CISST ERC, 2005 ··· cmd Execute(data); Real-time ··· NSF Engineering Research Center for Computer Integrated Surgical Systems and Technology
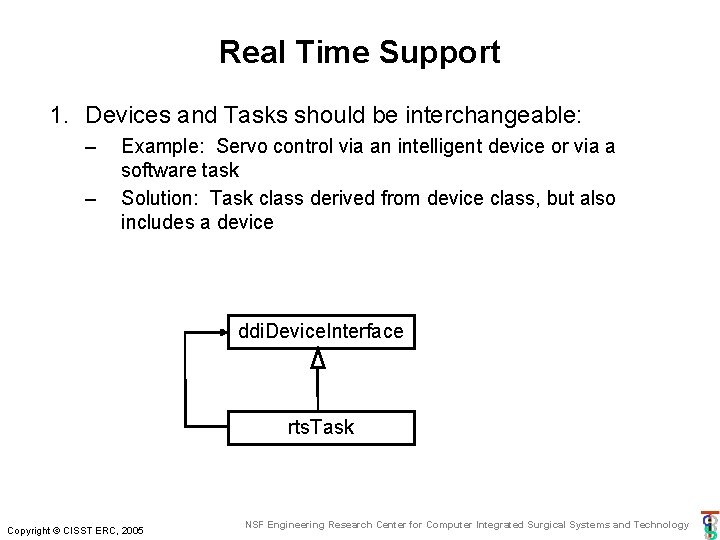
Real Time Support 1. Devices and Tasks should be interchangeable: – – Example: Servo control via an intelligent device or via a software task Solution: Task class derived from device class, but also includes a device ddi. Device. Interface rts. Task Copyright © CISST ERC, 2005 NSF Engineering Research Center for Computer Integrated Surgical Systems and Technology
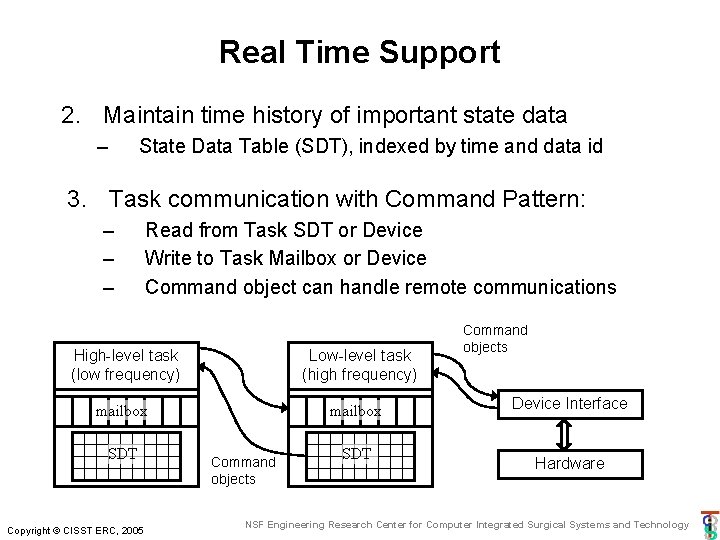
Real Time Support 2. Maintain time history of important state data – State Data Table (SDT), indexed by time and data id 3. Task communication with Command Pattern: – – – Read from Task SDT or Device Write to Task Mailbox or Device Command object can handle remote communications High-level task (low frequency) Low-level task (high frequency) mailbox SDT Copyright © CISST ERC, 2005 Command objects SDT Command objects Device Interface Hardware NSF Engineering Research Center for Computer Integrated Surgical Systems and Technology
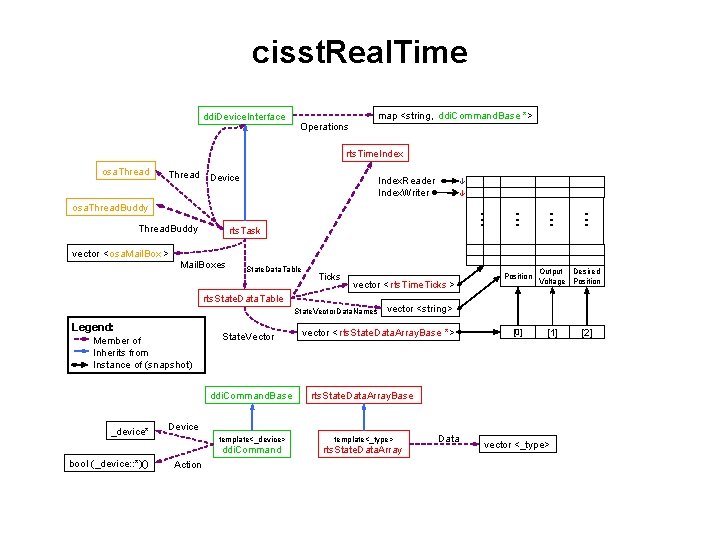
cisst. Real. Time ddi. Device. Interface map <string, ddi. Command. Base *> Operations rts. Time. Index osa. Thread Device Index. Reader Index. Writer â â State. Data. Table Ticks vector < rts. Time. Ticks > rts. State. Data. Table State. Vector. Data. Names Legend: Member of Inherits from Instance of (snapshot) State. Vector ddi. Command. Base _device* bool (_device: : *)() Copyright © CISST ERC, 2005 Position Mail. Boxes vector <osa. Mail. Box > rts. Task Thread. Buddy osa. Thread. Buddy Output Desired Voltage Position vector <string> vector < rts. State. Data. Array. Base *> [0] [1] [2] rts. State. Data. Array. Base Device template<_device> template<_type> ddi. Command rts. State. Data. Array Data vector <_type> Action NSF Engineering Research Center for Computer Integrated Surgical Systems and Technology
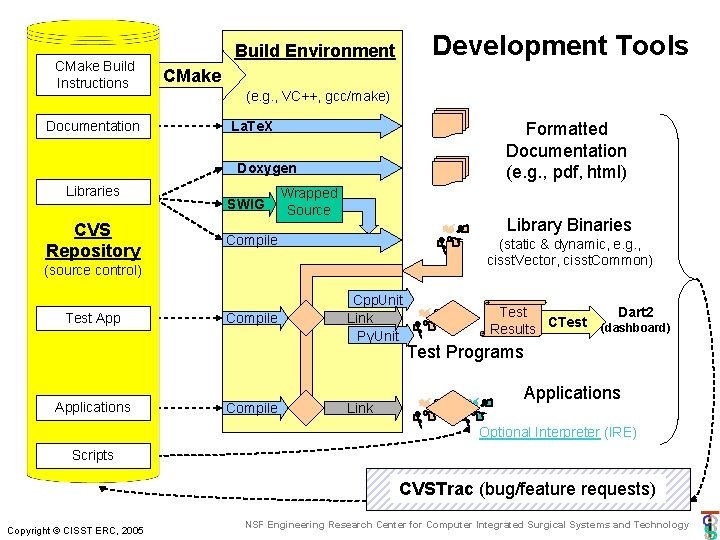
CMake Build Instructions Documentation Development Tools Build Environment CMake (e. g. , VC++, gcc/make) La. Te. X Formatted Documentation (e. g. , pdf, html) Doxygen Libraries CVS Repository SWIG Wrapped Source Library Binaries Compile (static & dynamic, e. g. , cisst. Vector, cisst. Common) (source control) Test Applications Compile Cpp. Unit Link Py. Unit Link Test Results CTest Dart 2 (dashboard) Test Programs Applications Optional Interpreter (IRE) Scripts CVSTrac (bug/feature requests) Copyright © CISST ERC, 2005 NSF Engineering Research Center for Computer Integrated Surgical Systems and Technology
Quick Tour of the Web Site www. cisst. org/resources/software Copyright © CISST ERC, 2005 NSF Engineering Research Center for Computer Integrated Surgical Systems and Technology
Development Summary • Tools adequately manage implementation, (unit) testing and maintenance phases of development – Automated testing will be hard for physical devices • Much documentation is manually created (not enforced by the process) – Requirements, risk analysis, (high-level) design, validation – User guide, tutorial, quickstart • We needed Dart sooner than we expected! – gcc is getting pickier! – Windows static/shared libraries (dll export) Copyright © CISST ERC, 2005 NSF Engineering Research Center for Computer Integrated Surgical Systems and Technology