
Telecentric Measurement System Laboratory of Optoelectronics University of
Telecentric Measurement System Laboratory of Optoelectronics, University of Brescia 2 D Vision Course Pietro Craighero
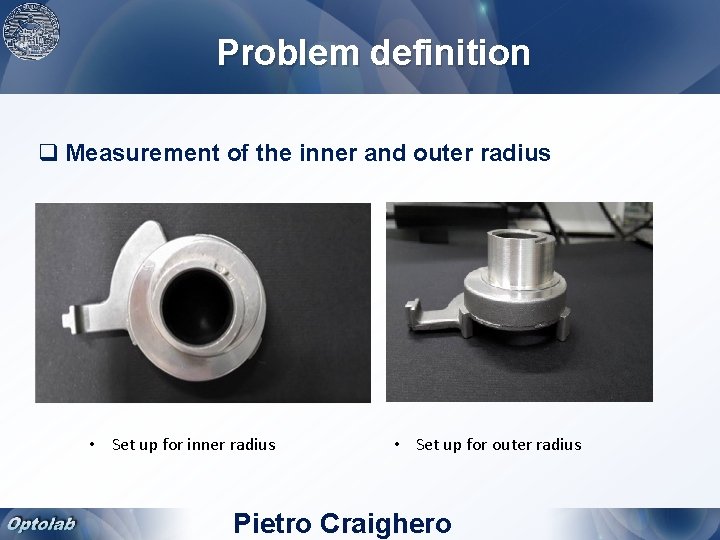
Problem definition q Measurement of the inner and outer radius • Set up for inner radius • Set up for outer radius Pietro Craighero
System Engineers vision have to face these problems: 1. Alteration of the magnification (due to object displacement) 2. Image distortion 3. Perspective errors 4. Low image resolution 5. Uncertainty of the position of the boundary (due to lighting geometry) Pietro Craighero
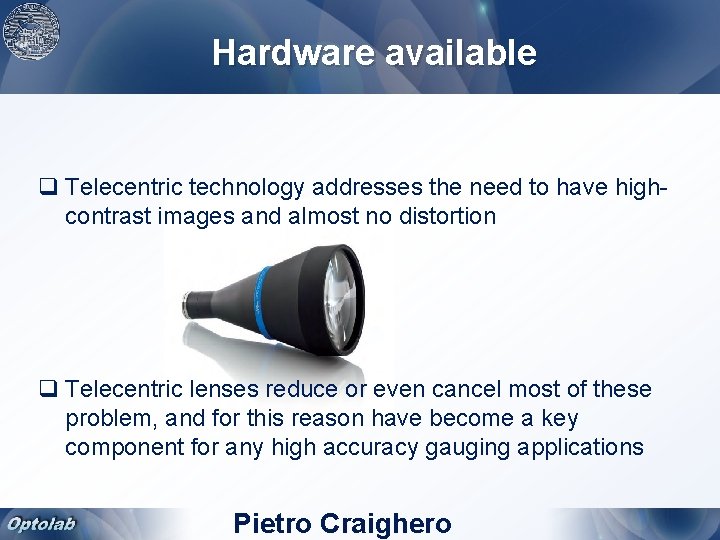
Hardware available q Telecentric technology addresses the need to have highcontrast images and almost no distortion q Telecentric lenses reduce or even cancel most of these problem, and for this reason have become a key component for any high accuracy gauging applications Pietro Craighero
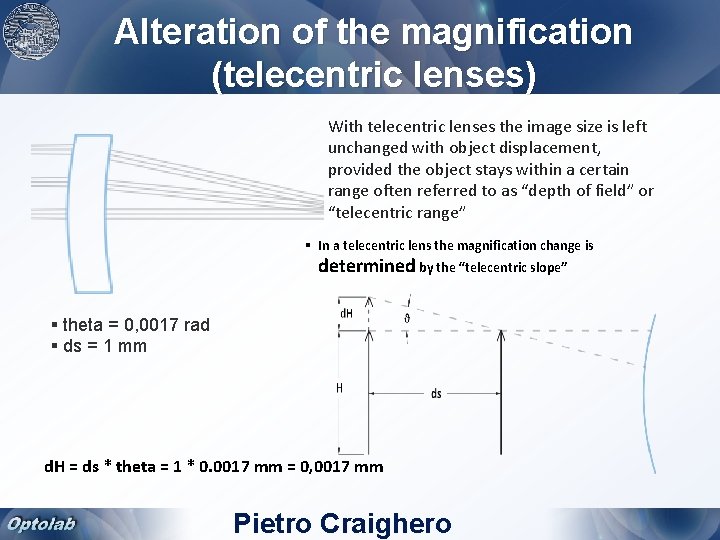
Alteration of the magnification (telecentric lenses) With telecentric lenses the image size is left unchanged with object displacement, provided the object stays within a certain range often referred to as “depth of field” or “telecentric range” § In a telecentric lens the magnification change is determined by the “telecentric slope” § theta = 0, 0017 rad § ds = 1 mm d. H = ds * theta = 1 * 0. 0017 mm = 0, 0017 mm Pietro Craighero
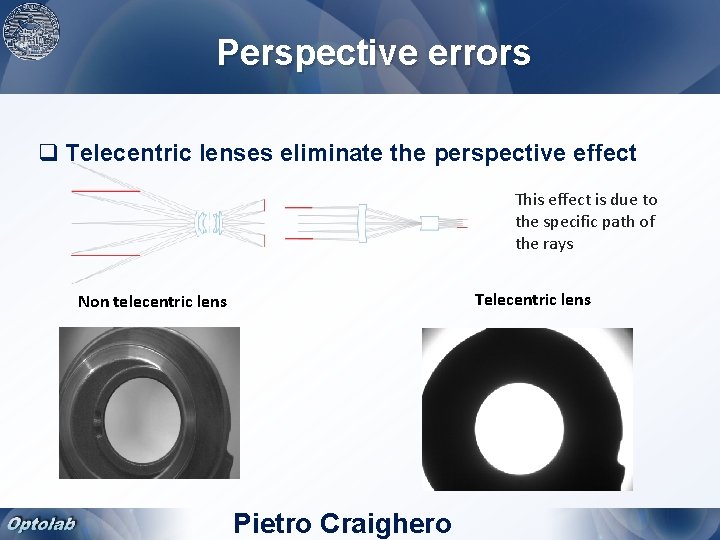
Perspective errors q Telecentric lenses eliminate the perspective effect This effect is due to the specific path of the rays Telecentric lens Non telecentric lens Pietro Craighero
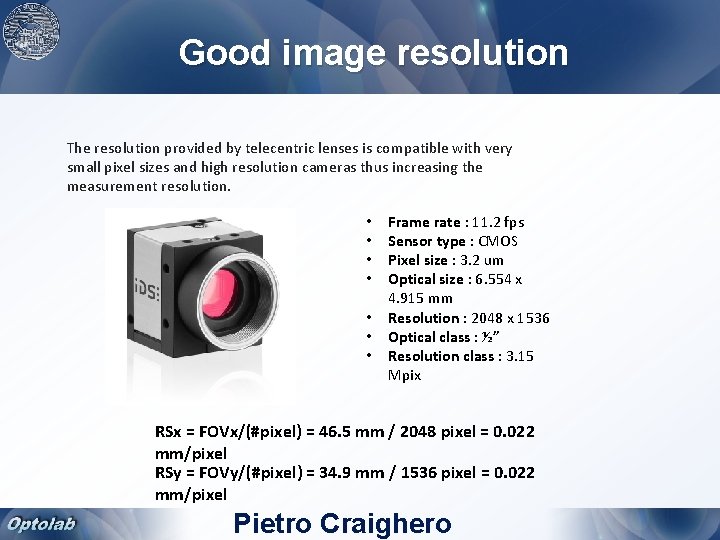
Good image resolution The resolution provided by telecentric lenses is compatible with very small pixel sizes and high resolution cameras thus increasing the measurement resolution. • • Frame rate : 11. 2 fps Sensor type : CMOS Pixel size : 3. 2 um Optical size : 6. 554 x 4. 915 mm Resolution : 2048 x 1536 Optical class : ½” Resolution class : 3. 15 Mpix RSx = FOVx/(#pixel) = 46. 5 mm / 2048 pixel = 0. 022 mm/pixel RSy = FOVy/(#pixel) = 34. 9 mm / 1536 pixel = 0. 022 mm/pixel Pietro Craighero
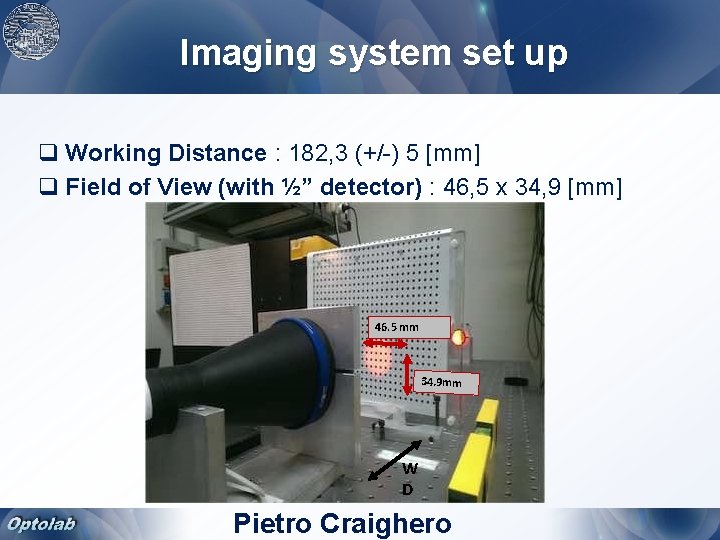
Imaging system set up q Working Distance : 182, 3 (+/-) 5 [mm] q Field of View (with ½” detector) : 46, 5 x 34, 9 [mm] 46. 5 mm 34. 9 mm W D Pietro Craighero
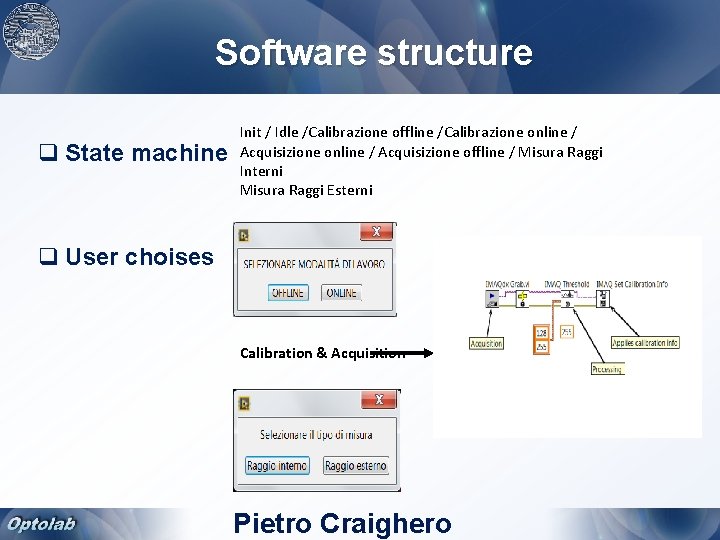
Software structure q State machine Init / Idle /Calibrazione offline /Calibrazione online / Acquisizione offline / Misura Raggi Interni Misura Raggi Esterni q User choises Calibration & Acquisition Pietro Craighero
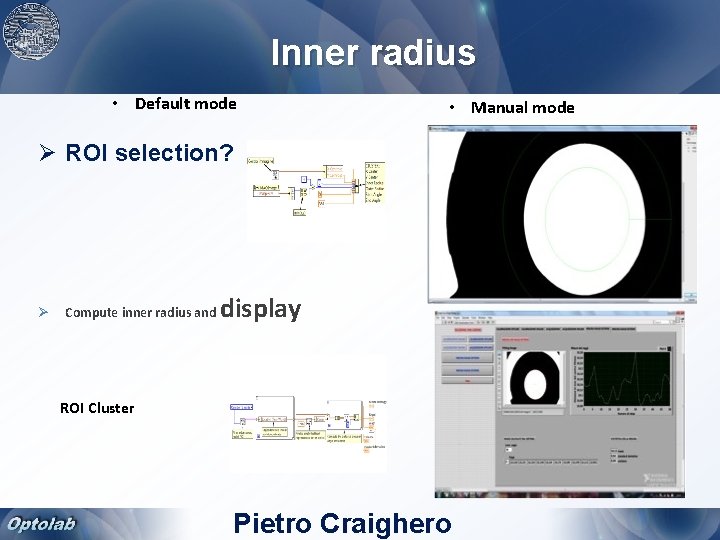
Inner radius • Default mode • Manual mode Ø ROI selection? Ø Compute inner radius and display ROI Cluster Pietro Craighero
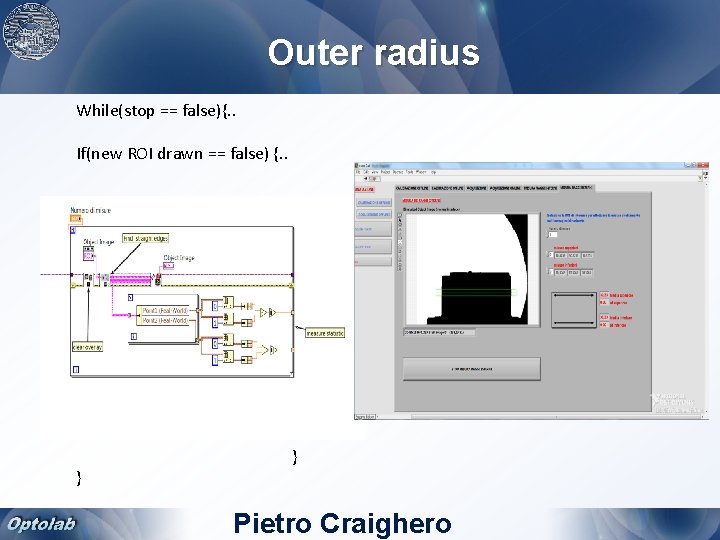
Outer radius While(stop == false){. . If(new ROI drawn == false) {. . } } Pietro Craighero
Outer radius While(stop == false){. . If(new ROI drawn == false) {. . 30, 33 mm } } Pietro Craighero
Conclusion • set and choose the right hardware • friendly interface design • Thank you for your attention Pietro Craighero
- Slides: 13