
TEAM 28 S P O C Solar Power
- Slides: 34
TEAM 28 (S. P. O. C. ) Solar Power Optimized Cart
TEAM MEMBERS Cameron Boozarjomehri Computer Engineer Team Mentor Team Leader Consultant (Supreme Overlord) Jacob Bitterman Electrical Engineer Hardware Lead (Leader of away team) William Ellett Computer Engineer Software Lead (redshirt 1) Dr. Richie Zaza Soriano Being a Swell Guy Sponsor Duke Energy
Desire to work with Solar Technology Interested in transportation project Environmental conservation interests Have an excuse to drive a golf cart to and from campus MOTIVATION
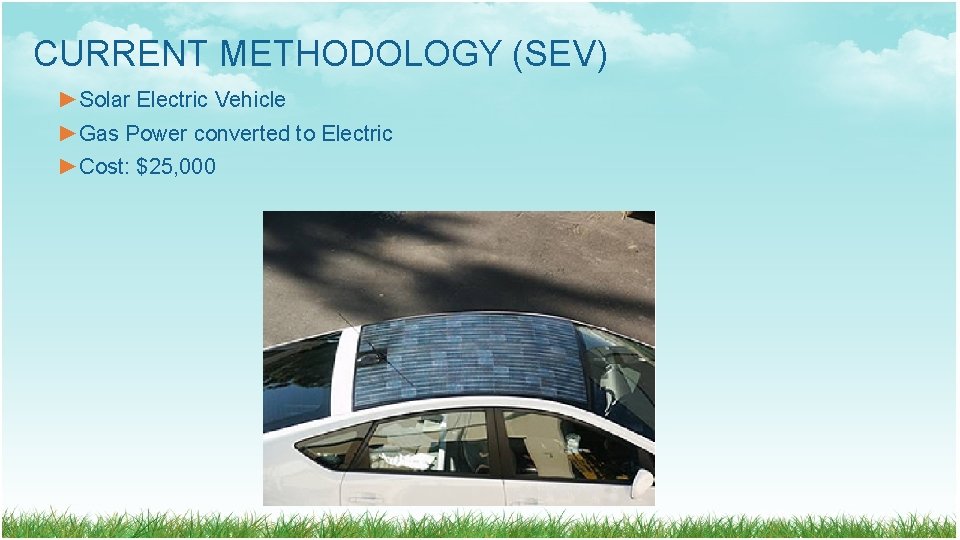
CURRENT METHODOLOGY (SEV) ►Solar Electric Vehicle ►Gas Power converted to Electric ►Cost: $25, 000
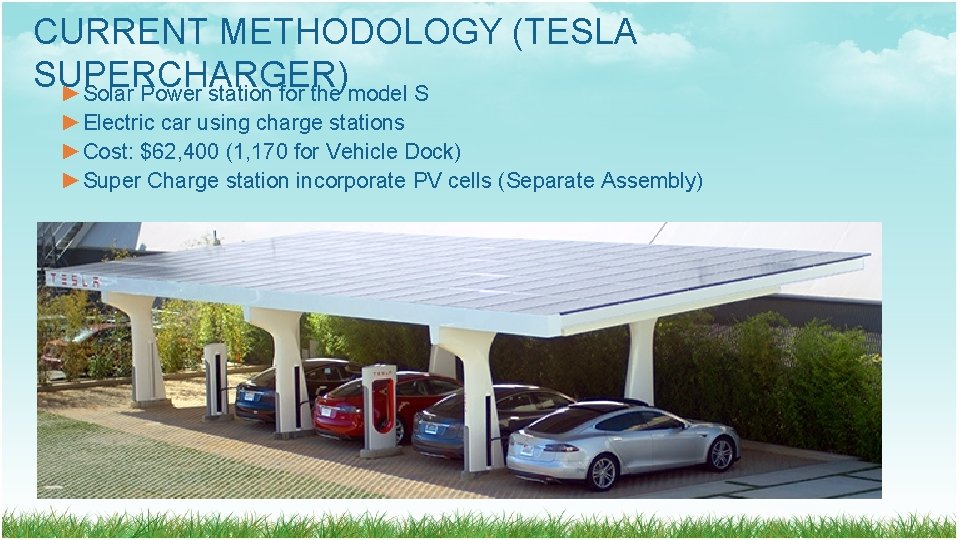
CURRENT METHODOLOGY (TESLA SUPERCHARGER) ►Solar Power station for the model S ►Electric car using charge stations ►Cost: $62, 400 (1, 170 for Vehicle Dock) ►Super Charge station incorporate PV cells (Separate Assembly)
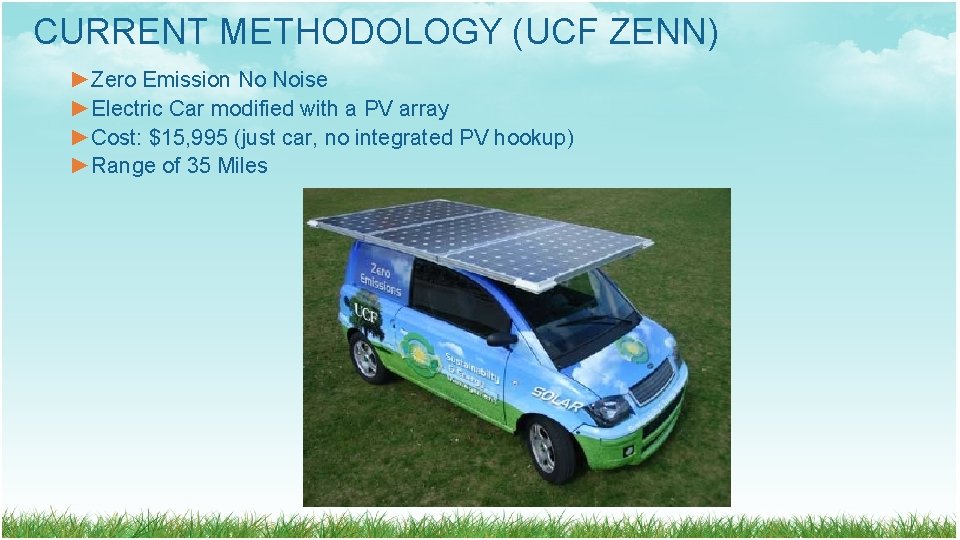
CURRENT METHODOLOGY (UCF ZENN) ►Zero Emission No Noise ►Electric Car modified with a PV array ►Cost: $15, 995 (just car, no integrated PV hookup) ►Range of 35 Miles
GOALS Electric vehicle Powered solely by photovoltaic cells Able to drive as long as possible given adequate sunlight Able to charge while driving Vehicle drive modes to control performance Performance mode Balanced mode Eco mode Clearly Demonstrate vehicle information to user Battery life/longevity Vehicle current mode Charge time Range
SPECIFICATIONS Cart can reach top speeds in excess of 10 miles per hour Considered normal for this model cart Cart will have parallel charging circuits Vehicle load capacity of 700 lbs (including passengers and all components) Charge from no energy in 6 hours during optimal sunlight exposure
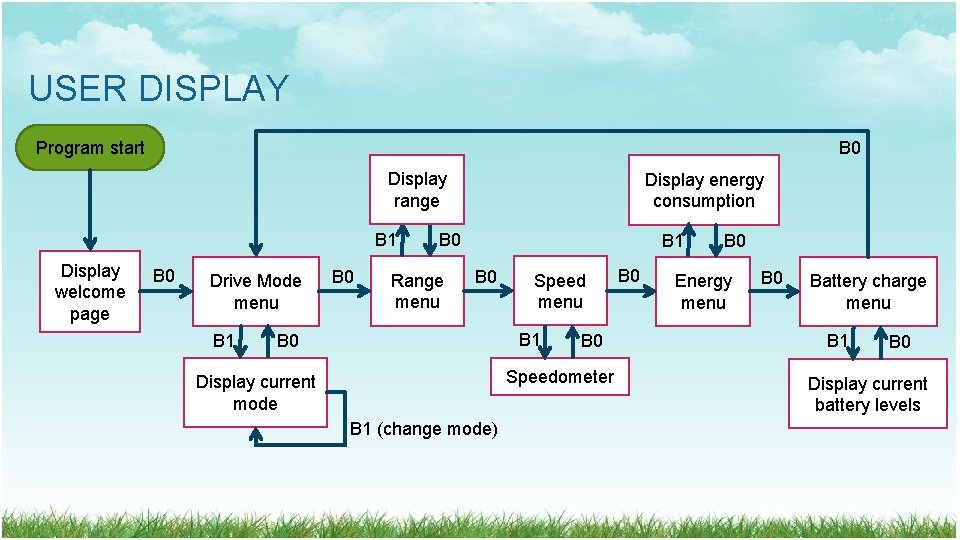
SPECIFICATION CONT. Rear panel adjustable with 80º of freedom to optimize solar energy collection Optimization system that suggests best panel angle to within 5º User Interface Displays current drive mode (Performance, Balanced, Eco Boost) Display current maximum range in miles +/- 1 mile Display speed in mph to nearest 1/10 th of a mile Display energy absorption rate in watts to nearest watt Battery charge percentage accurate to nearest whole percent
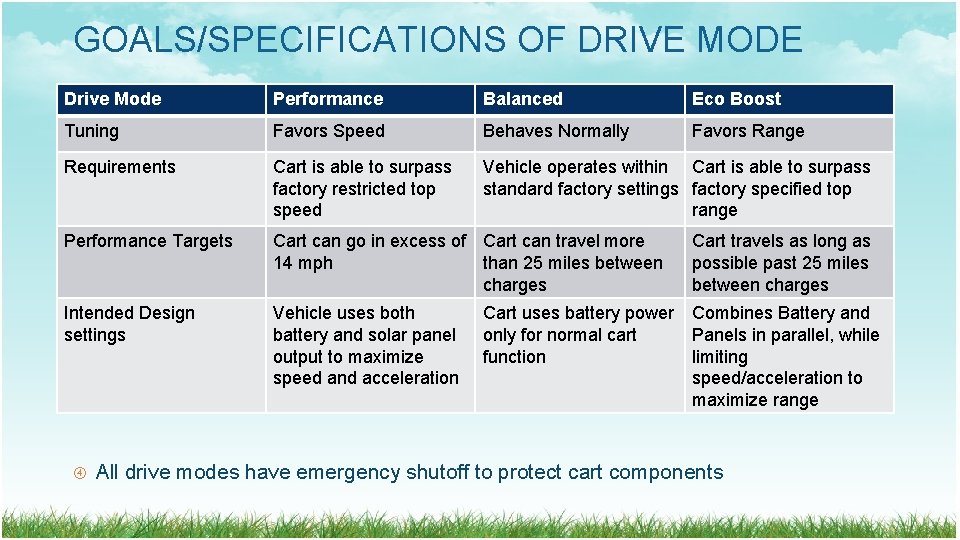
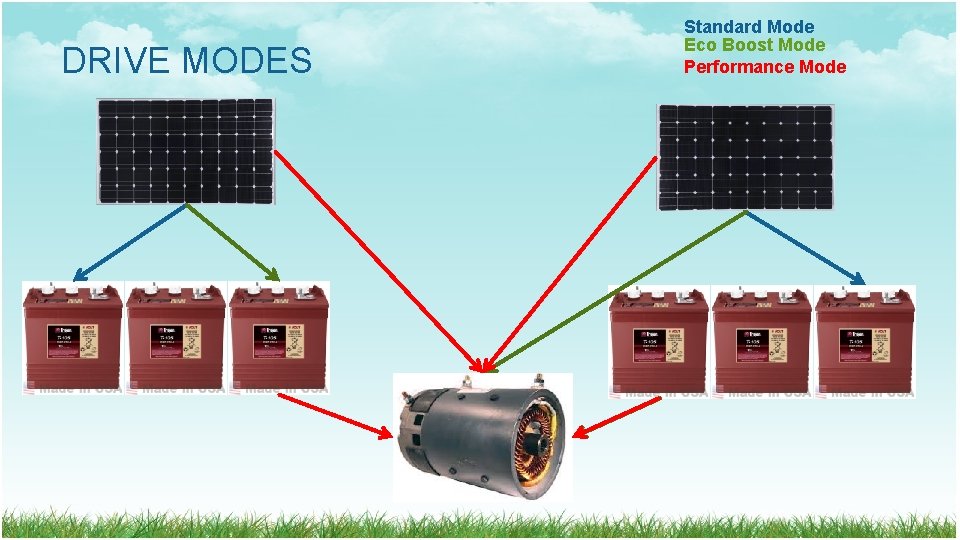
GOALS/SPECIFICATIONS OF DRIVE MODE Drive Mode Performance Balanced Eco Boost Tuning Favors Speed Behaves Normally Favors Range Requirements Cart is able to surpass factory restricted top speed Vehicle operates within Cart is able to surpass standard factory settings factory specified top range Performance Targets Cart can go in excess of Cart can travel more 14 mph than 25 miles between charges Cart travels as long as possible past 25 miles between charges Intended Design settings Vehicle uses both battery and solar panel output to maximize speed and acceleration Combines Battery and Panels in parallel, while limiting speed/acceleration to maximize range Cart uses battery power only for normal cart function All drive modes have emergency shutoff to protect cart components
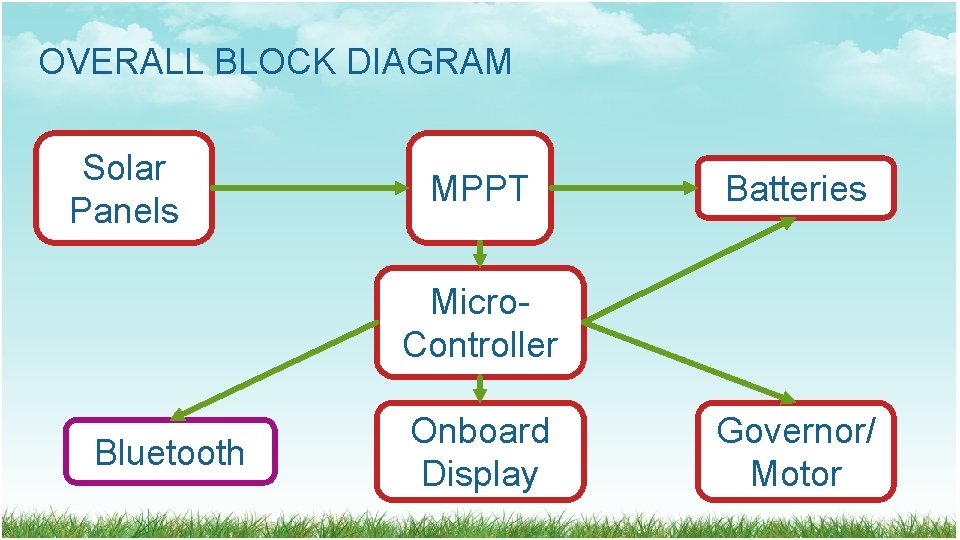
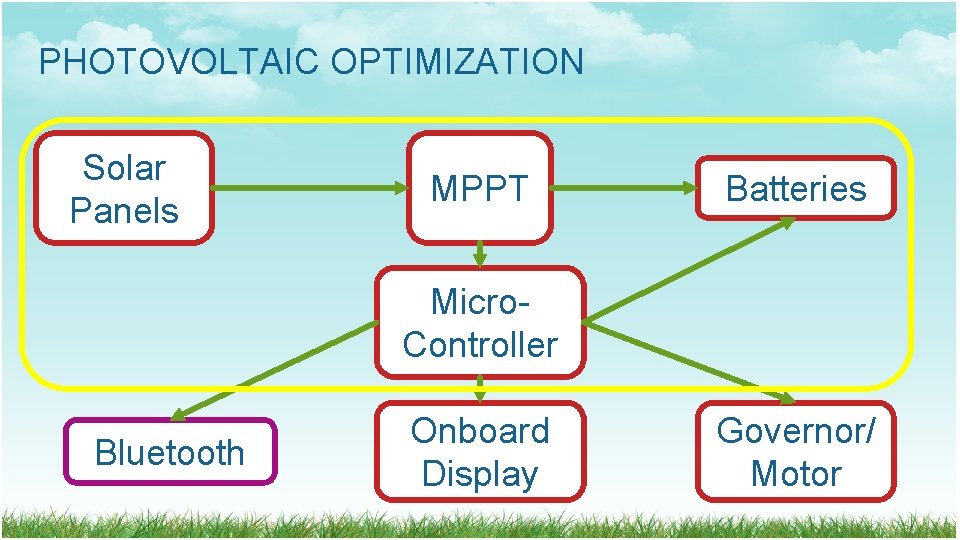
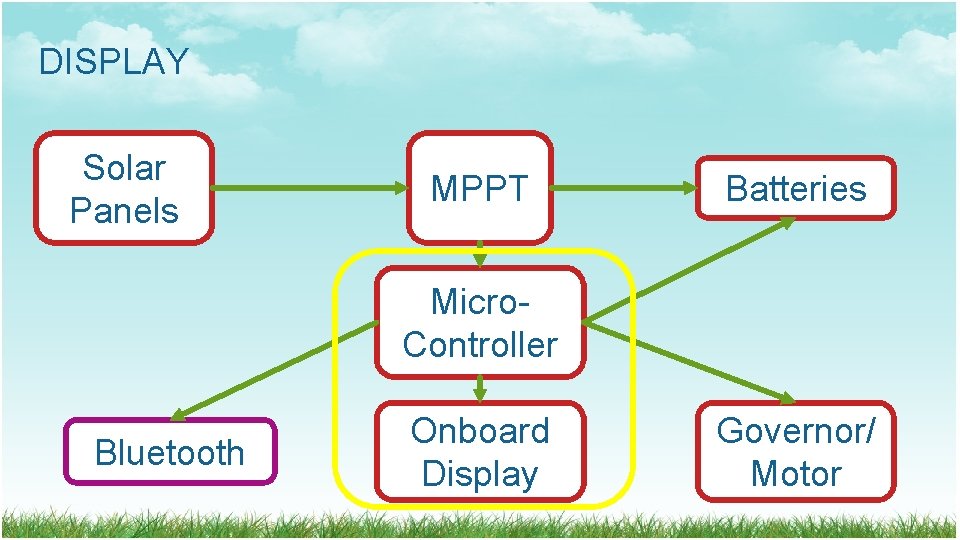
OVERALL BLOCK DIAGRAM Solar Panels MPPT Batteries Micro. Controller Bluetooth Onboard Display Governor/ Motor
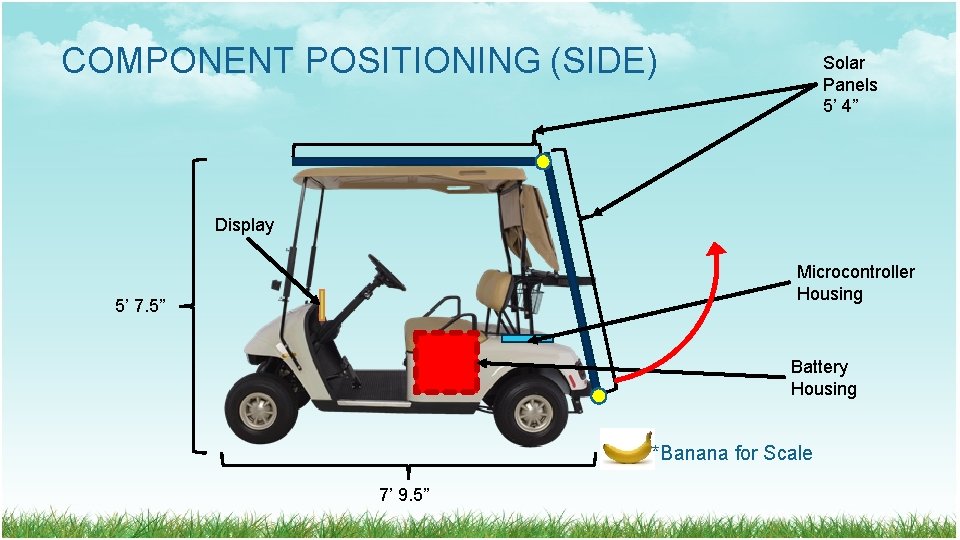
COMPONENT POSITIONING (SIDE) Solar Panels 5’ 4” Display Microcontroller Housing 5’ 7. 5” Battery Housing *Banana for Scale 7’ 9. 5”
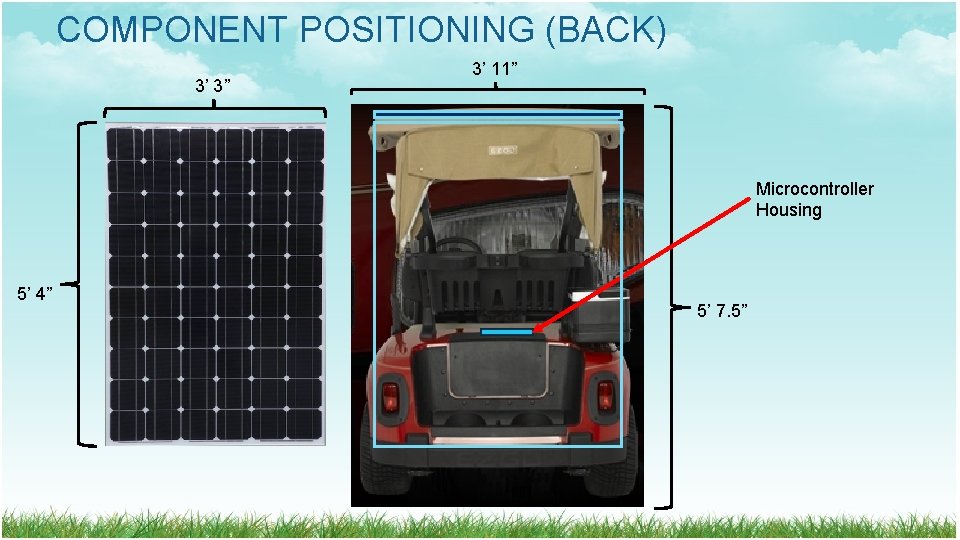
COMPONENT POSITIONING (BACK) 3’ 3” 3’ 11” Microcontroller Housing 5’ 4” 5’ 7. 5”
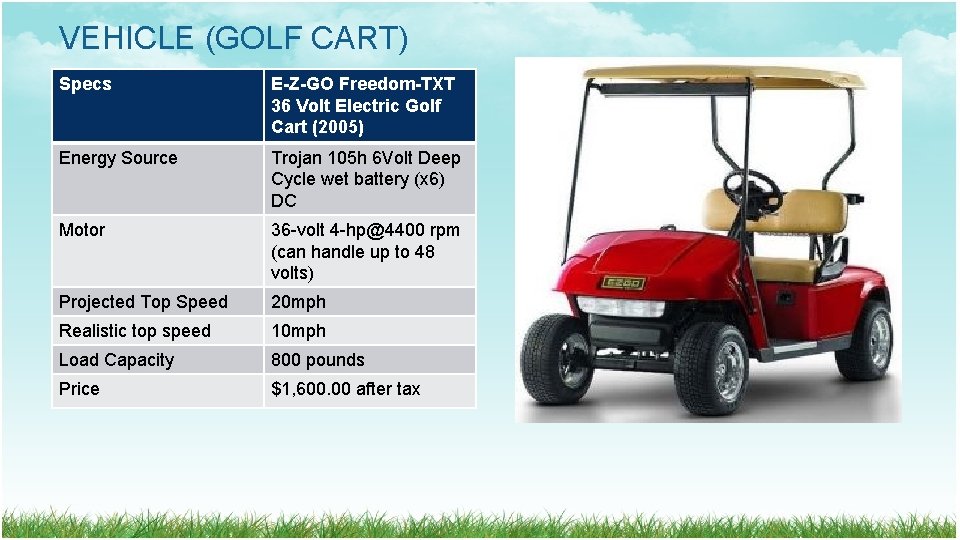
VEHICLE (GOLF CART) Specs E-Z-GO Freedom-TXT 36 Volt Electric Golf Cart (2005) Energy Source Trojan 105 h 6 Volt Deep Cycle wet battery (x 6) DC Motor 36 -volt 4 -hp@4400 rpm (can handle up to 48 volts) Projected Top Speed 20 mph Realistic top speed 10 mph Load Capacity 800 pounds Price $1, 600. 00 after tax
PHOTOVOLTAIC OPTIMIZATION Solar Panels MPPT Batteries Micro. Controller Bluetooth Onboard Display Governor/ Motor
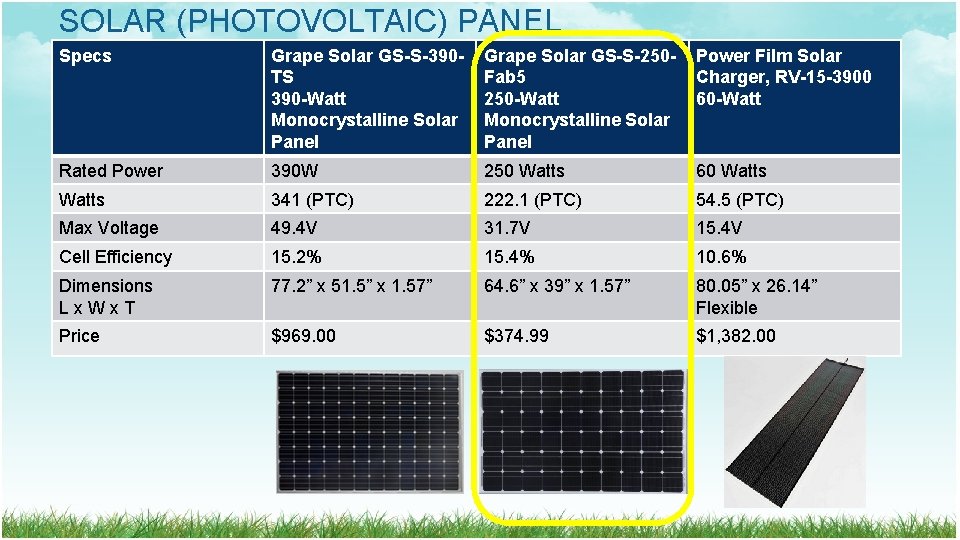
SOLAR (PHOTOVOLTAIC) PANEL Specs Grape Solar GS-S-390 TS 390 -Watt Monocrystalline Solar Panel Grape Solar GS-S-250 Fab 5 250 -Watt Monocrystalline Solar Panel Power Film Solar Charger, RV-15 -3900 60 -Watt Rated Power 390 W 250 Watts 60 Watts 341 (PTC) 222. 1 (PTC) 54. 5 (PTC) Max Voltage 49. 4 V 31. 7 V 15. 4 V Cell Efficiency 15. 2% 15. 4% 10. 6% Dimensions Lx. Wx. T 77. 2” x 51. 5” x 1. 57” 64. 6” x 39” x 1. 57” 80. 05” x 26. 14” Flexible Price $969. 00 $374. 99 $1, 382. 00
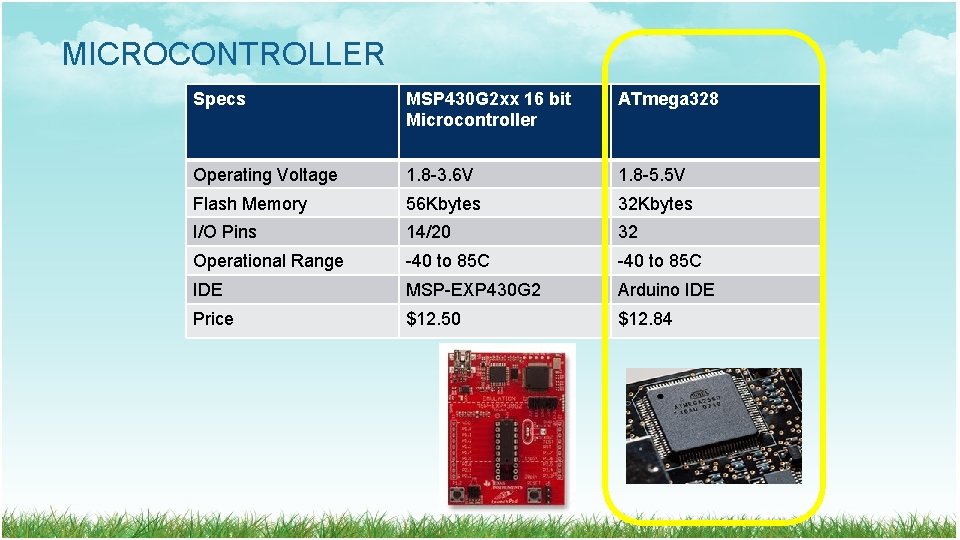
MICROCONTROLLER Specs MSP 430 G 2 xx 16 bit Microcontroller ATmega 328 Operating Voltage 1. 8 -3. 6 V 1. 8 -5. 5 V Flash Memory 56 Kbytes 32 Kbytes I/O Pins 14/20 32 Operational Range -40 to 85 C IDE MSP-EXP 430 G 2 Arduino IDE Price $12. 50 $12. 84
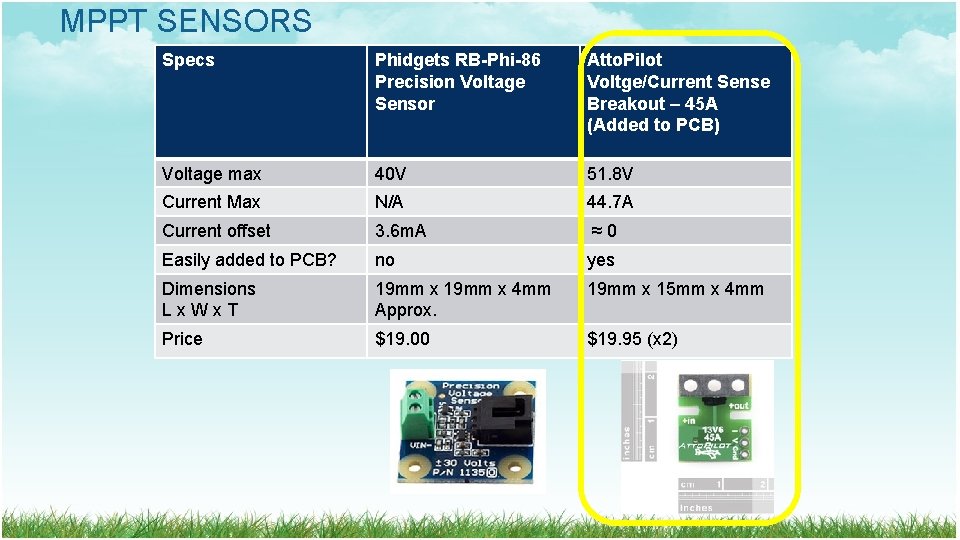
MPPT SENSORS Specs Phidgets RB-Phi-86 Precision Voltage Sensor Atto. Pilot Voltge/Current Sense Breakout – 45 A (Added to PCB) Voltage max 40 V 51. 8 V Current Max N/A 44. 7 A Current offset 3. 6 m. A ≈0 Easily added to PCB? no yes Dimensions Lx. Wx. T 19 mm x 4 mm Approx. 19 mm x 15 mm x 4 mm Price $19. 00 $19. 95 (x 2)
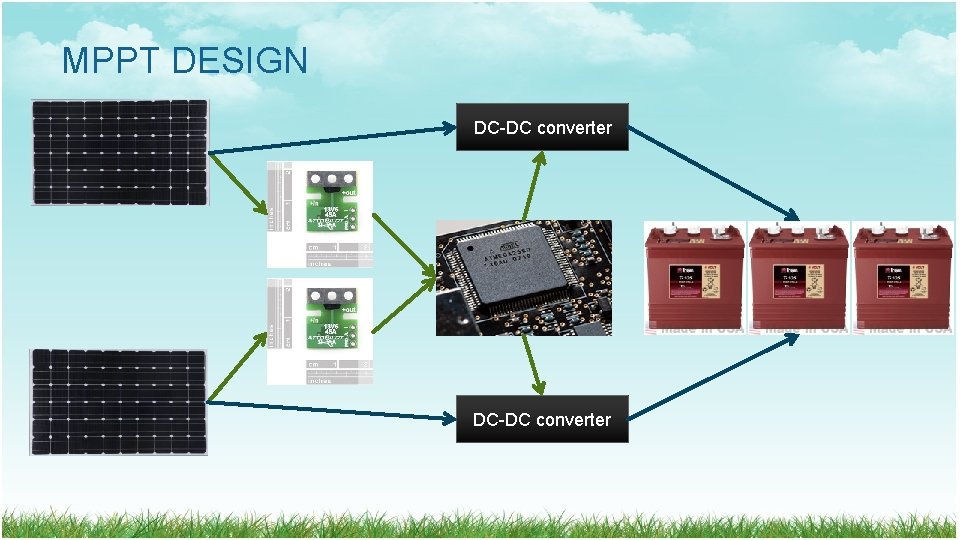
MPPT DESIGN DC-DC converter
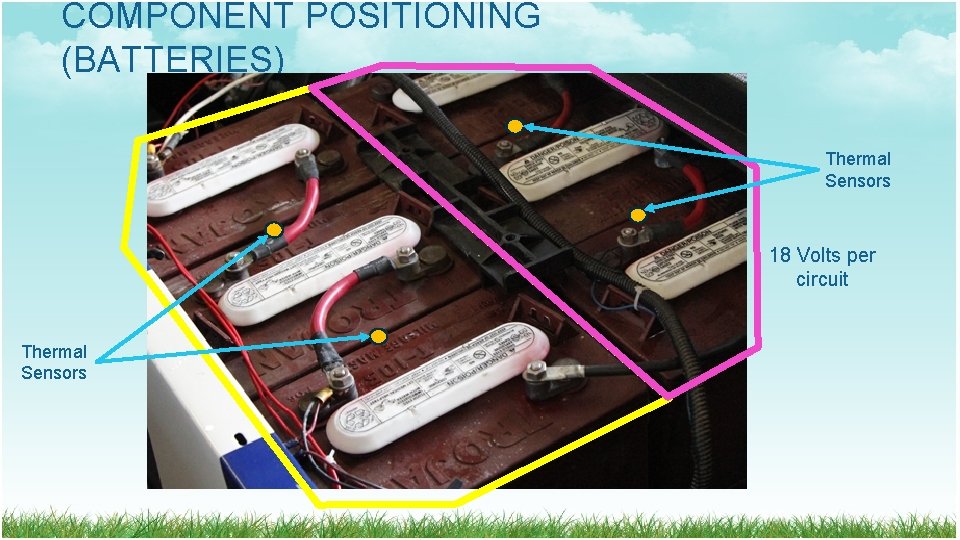
COMPONENT POSITIONING (BATTERIES) Thermal Sensors 18 Volts per circuit Thermal Sensors
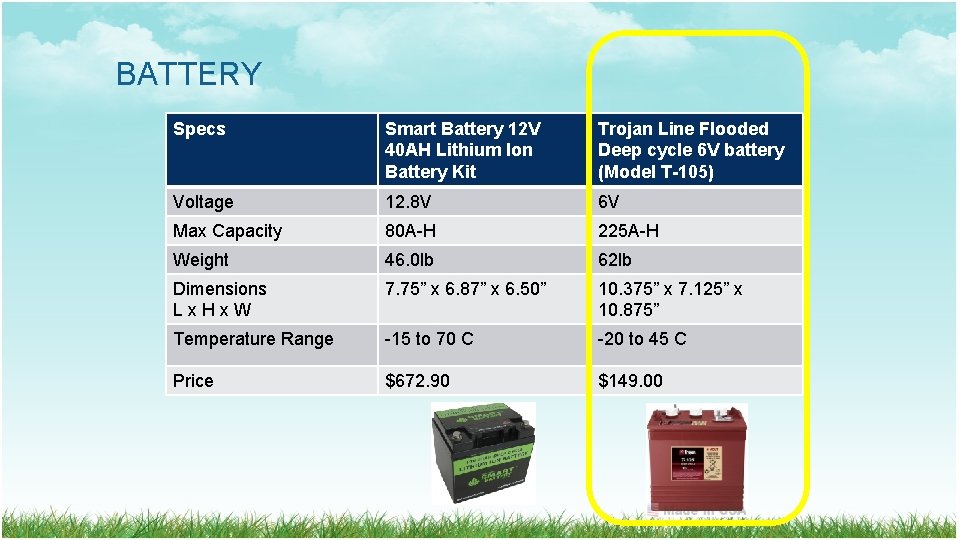
BATTERY Specs Smart Battery 12 V 40 AH Lithium Ion Battery Kit Trojan Line Flooded Deep cycle 6 V battery (Model T-105) Voltage 12. 8 V 6 V Max Capacity 80 A-H 225 A-H Weight 46. 0 lb 62 lb Dimensions Lx. Hx. W 7. 75” x 6. 87” x 6. 50” 10. 375” x 7. 125” x 10. 875” Temperature Range -15 to 70 C -20 to 45 C Price $672. 90 $149. 00
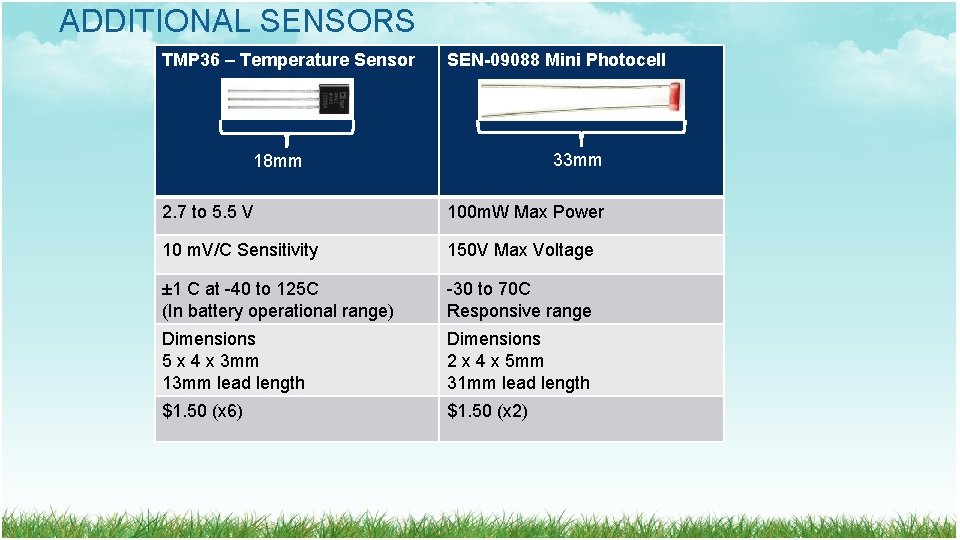
ADDITIONAL SENSORS TMP 36 – Temperature Sensor SEN-09088 Mini Photocell 33 mm 18 mm 2. 7 to 5. 5 V 100 m. W Max Power 10 m. V/C Sensitivity 150 V Max Voltage ± 1 C at -40 to 125 C (In battery operational range) -30 to 70 C Responsive range Dimensions 5 x 4 x 3 mm 13 mm lead length Dimensions 2 x 4 x 5 mm 31 mm lead length $1. 50 (x 6) $1. 50 (x 2)
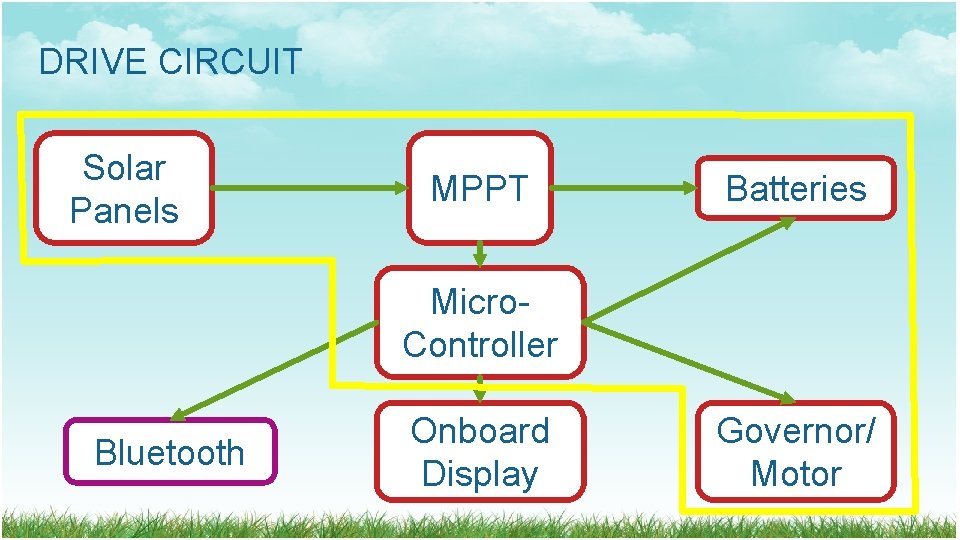
DRIVE CIRCUIT Solar Panels MPPT Batteries Micro. Controller Bluetooth Onboard Display Governor/ Motor
DRIVE MODES Standard Mode Eco Boost Mode Performance Mode
DISPLAY Solar Panels MPPT Batteries Micro. Controller Bluetooth Onboard Display Governor/ Motor
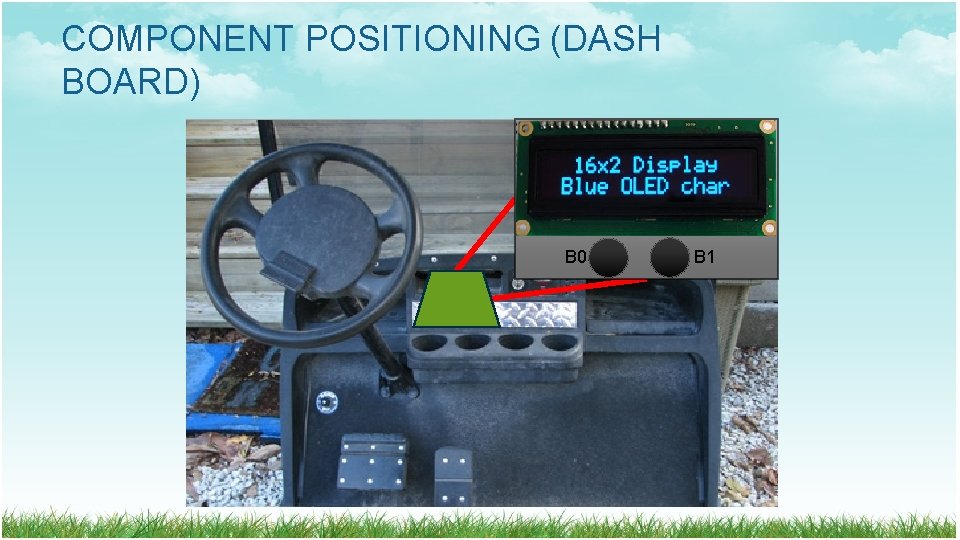
COMPONENT POSITIONING (DASH BOARD) B 0 B 1
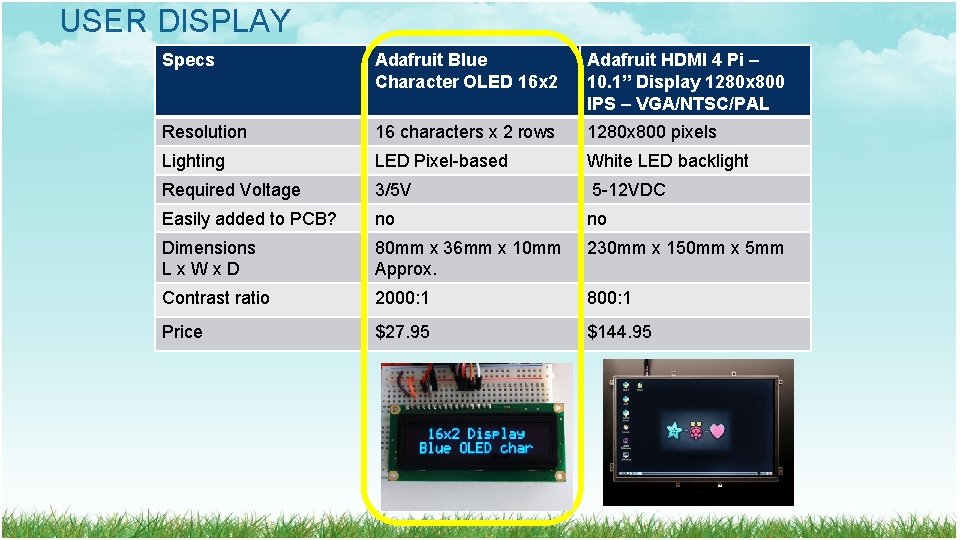
USER DISPLAY Specs Adafruit Blue Character OLED 16 x 2 Adafruit HDMI 4 Pi – 10. 1” Display 1280 x 800 IPS – VGA/NTSC/PAL Resolution 16 characters x 2 rows 1280 x 800 pixels Lighting LED Pixel-based White LED backlight Required Voltage 3/5 V 5 -12 VDC Easily added to PCB? no no Dimensions Lx. Wx. D 80 mm x 36 mm x 10 mm Approx. 230 mm x 150 mm x 5 mm Contrast ratio 2000: 1 800: 1 Price $27. 95 $144. 95
USER DISPLAY Program start B 0 Display range B 1 Display welcome page B 0 Drive Mode menu B 1 B 0 Display energy consumption B 0 Range menu B 1 B 0 Speedometer Display current mode B 1 (change mode) B 0 Energy menu B 0 Battery charge menu B 1 B 0 Display current battery levels
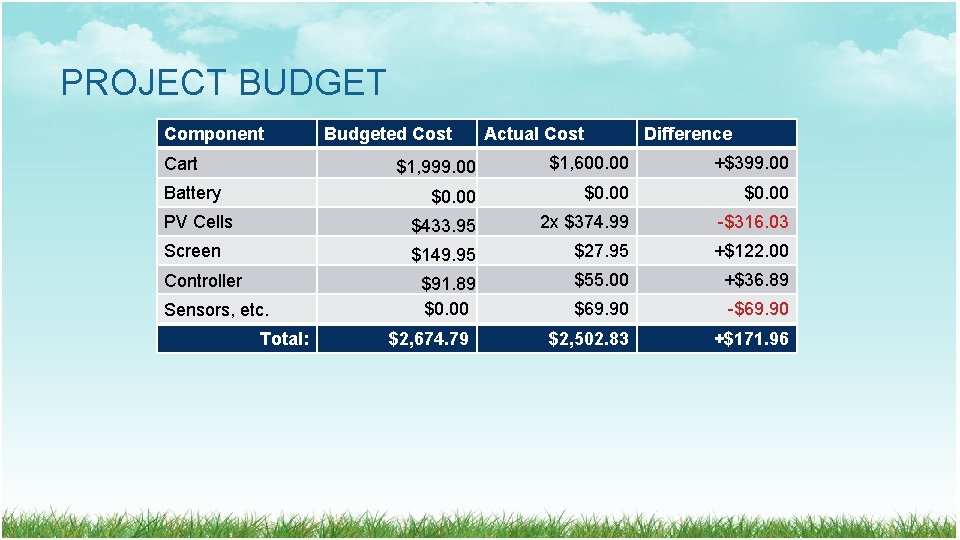
PROJECT BUDGET Component Budgeted Cost Actual Cost Difference $1, 999. 00 $1, 600. 00 +$399. 00 $0. 00 PV Cells $433. 95 2 x $374. 99 -$316. 03 Screen $149. 95 $27. 95 +$122. 00 $91. 89 $0. 00 $55. 00 +$36. 89 $69. 90 -$69. 90 $2, 502. 83 +$171. 96 Cart Battery Controller Sensors, etc. Total: $2, 674. 79
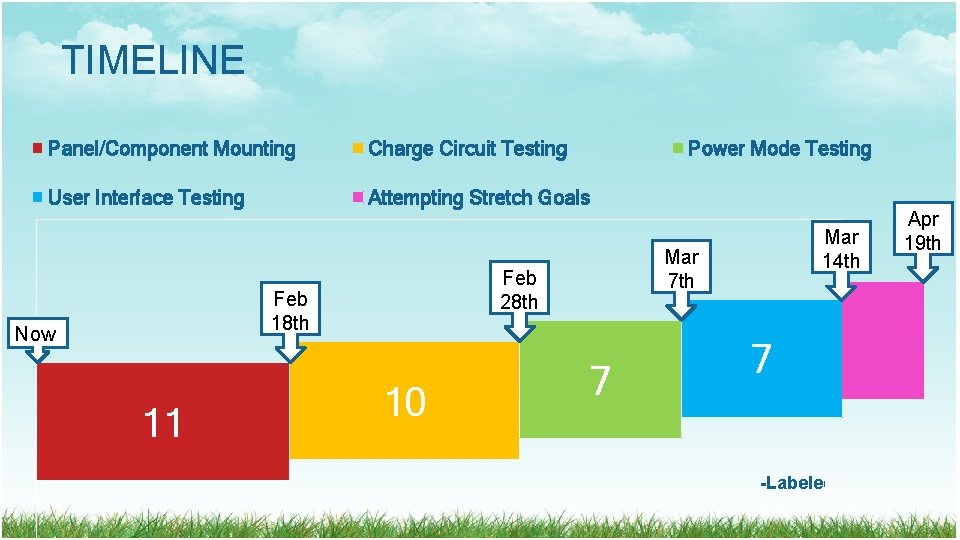
TIMELINE Panel/Component Mounting Charge Circuit Testing User Interface Testing Attempting Stretch Goals 11 10 Mar 14 th Mar 7 th Feb 28 th Feb 18 th Now Power Mode Testing 7 7 -Labeled in Days Apr 19 th
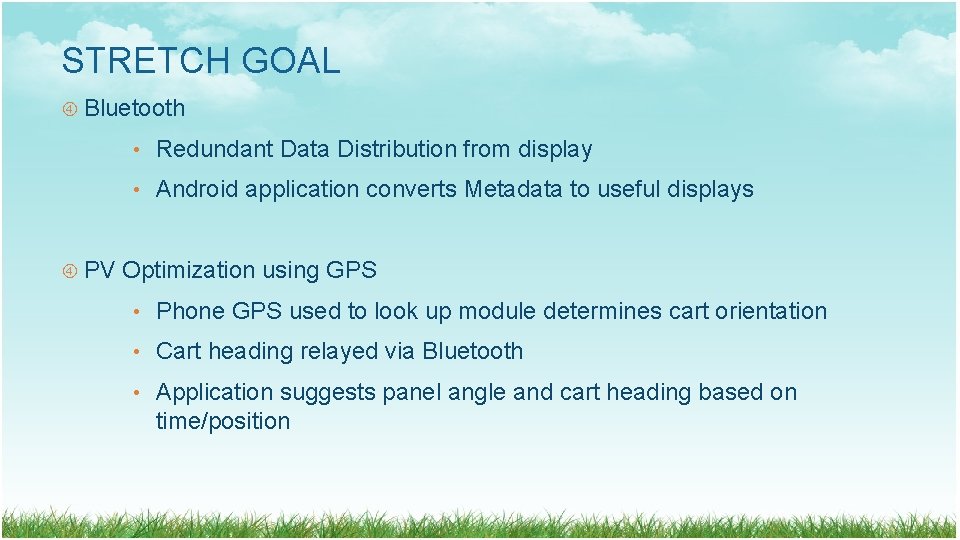
STRETCH GOAL Bluetooth PV • Redundant Data Distribution from display • Android application converts Metadata to useful displays Optimization using GPS • Phone GPS used to look up module determines cart orientation • Cart heading relayed via Bluetooth • Application suggests panel angle and cart heading based on time/position
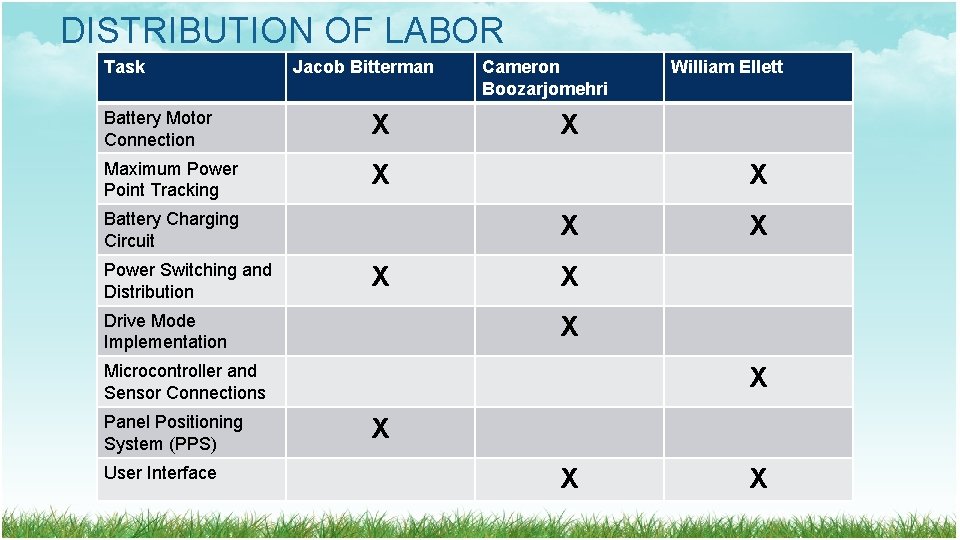
DISTRIBUTION OF LABOR Task Jacob Bitterman Battery Motor Connection X Maximum Power Point Tracking X Battery Charging Circuit Power Switching and Distribution Cameron Boozarjomehri X X Drive Mode Implementation User Interface X X X Microcontroller and Sensor Connections Panel Positioning System (PPS) William Ellett X X
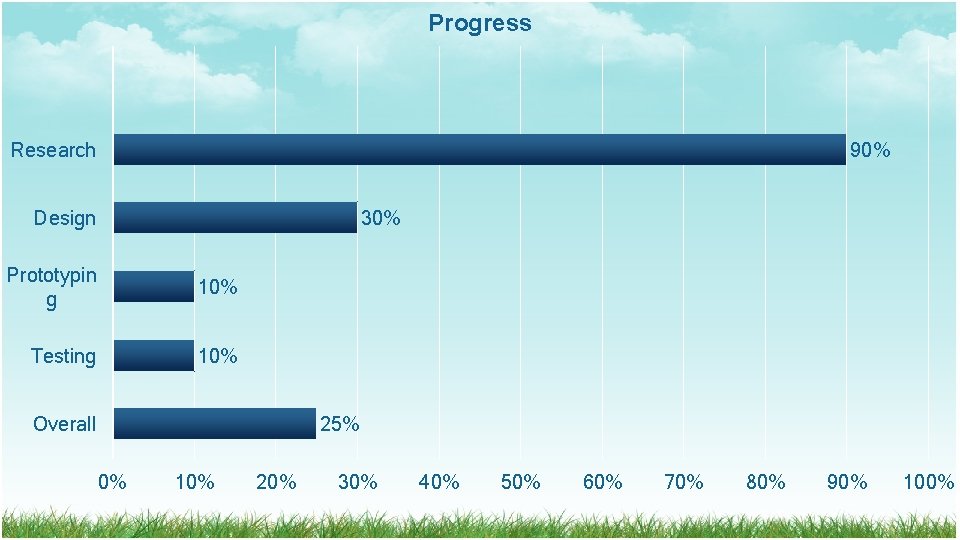
Progress Research 90% Design 30% Prototypin g 10% Testing 10% 25% Overall 0% 10% 20% 30% 40% 50% 60% 70% 80% 90% 100%
QUESTIONS ?