
Suggestive Contours for Conveying Shape CS 174 Robert
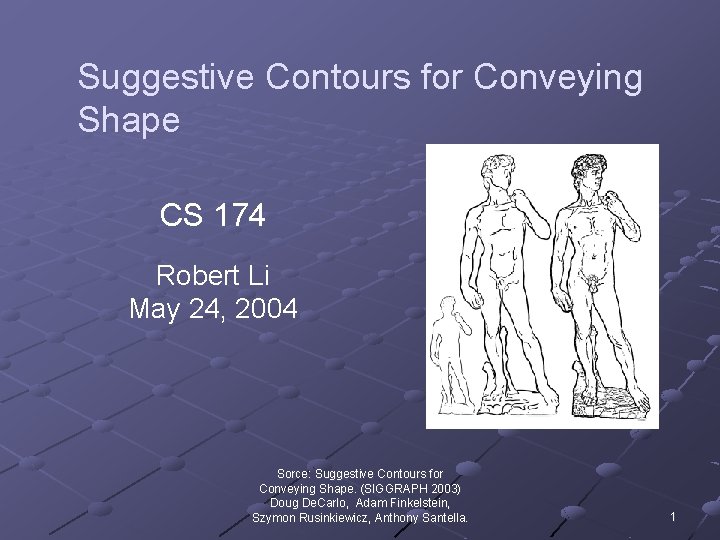
Suggestive Contours for Conveying Shape CS 174 Robert Li May 24, 2004 Sorce: Suggestive Contours for Conveying Shape. (SIGGRAPH 2003) Doug De. Carlo, Adam Finkelstein, Szymon Rusinkiewicz, Anthony Santella. 1
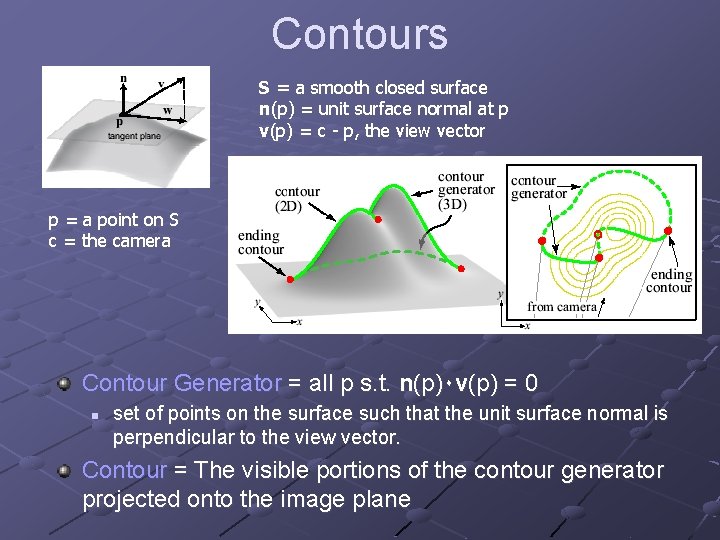
Contours S = a smooth closed surface n(p) = unit surface normal at p v(p) = c - p, the view vector p = a point on S c = the camera Contour Generator = all p s. t. n(p)٠ v(p) = 0 n set of points on the surface such that the unit surface normal is perpendicular to the view vector. Contour = The visible portions of the contour generator projected onto the image plane
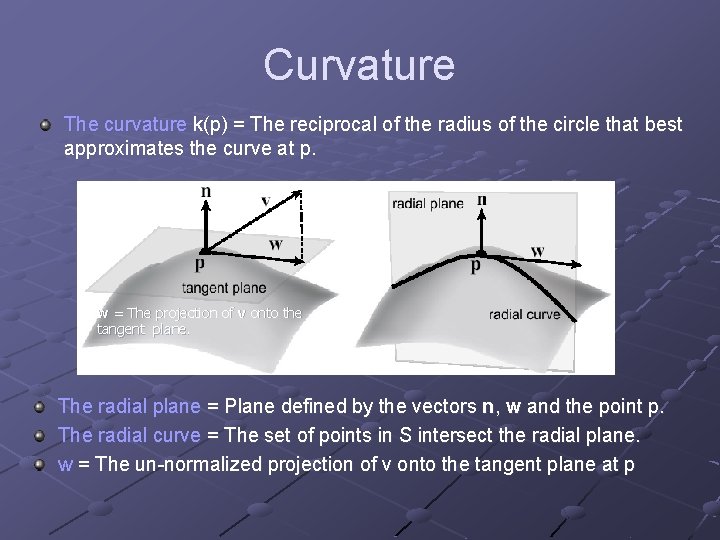
Curvature The curvature k(p) = The reciprocal of the radius of the circle that best approximates the curve at p. w = The projection of v onto the tangent plane. The radial plane = Plane defined by the vectors n, w and the point p. The radial curve = The set of points in S intersect the radial plane. w = The un-normalized projection of v onto the tangent plane at p
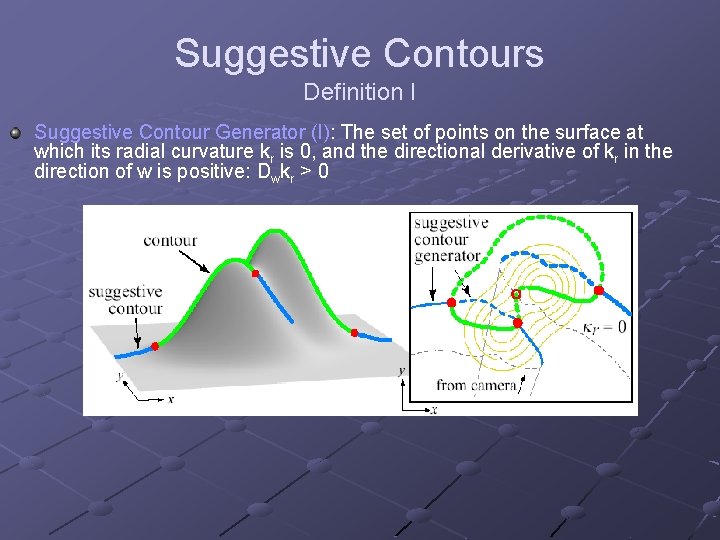
Suggestive Contours Definition I Suggestive Contour Generator (I): The set of points on the surface at which its radial curvature kr is 0, and the directional derivative of kr in the direction of w is positive: Dwkr > 0
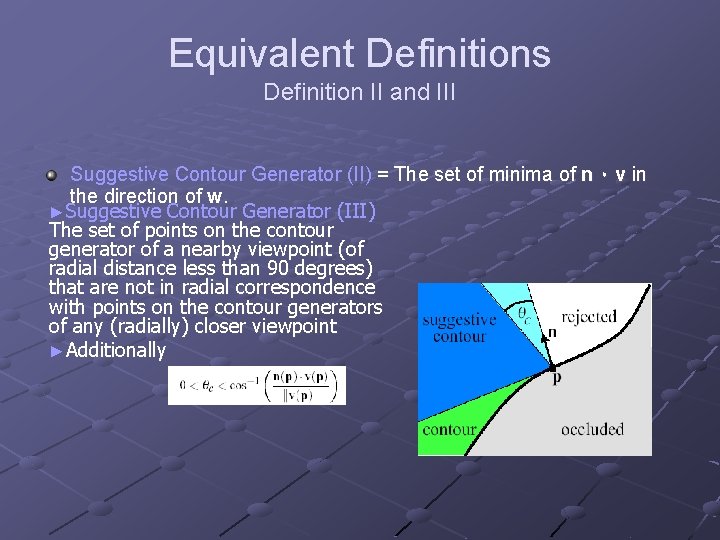
Equivalent Definitions Definition II and III Suggestive Contour Generator (II) = The set of minima of n ٠ v in the direction of w. ►Suggestive Contour Generator (III) The set of points on the contour generator of a nearby viewpoint (of radial distance less than 90 degrees) that are not in radial correspondence with points on the contour generators of any (radially) closer viewpoint ►Additionally
Object Space Algorithm Test each triangle for two vertices whose sign of n dot v is different. Interpolate to get the zero crossing (Hertzmann zero crossing algorithm for smooth surfaces) Find kr(p) = k 1(p) cos 2 Φ+ k 2(p) sin 2 Φ for each point. k 1 and k 2 are the principle curvatures of the face and Φ is the angle between w(p) and the principle curvature direction corresponding to k 1 Find the zeros of kr(p) using the zero crossing algorithm These should be loops on the surface Calculate Dwkr and make sure it is positive Handle numerical errors
Image Space Algorithm Approximate n ٠ v by placing a diffuse light source at the camera origin. Search image for valleys in intensity by finding stable minima of (n ٠ v) /||v|| : n n For pixel i with intensity pi, define the pixel of the greatest intensity in a radius r around pi to be pmax. Label i a valley if two conditions are met: no more than a certain percentage s of the pixels in this disk are strictly darker than pi; and pmax - pi exceeds a fixed threshold d. Remove small irregularities with a median filter of radius r.
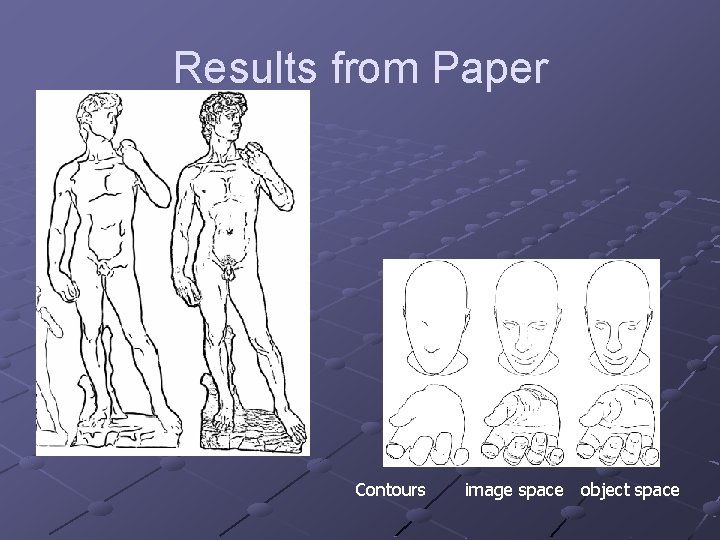
Results from Paper Contours image space object space
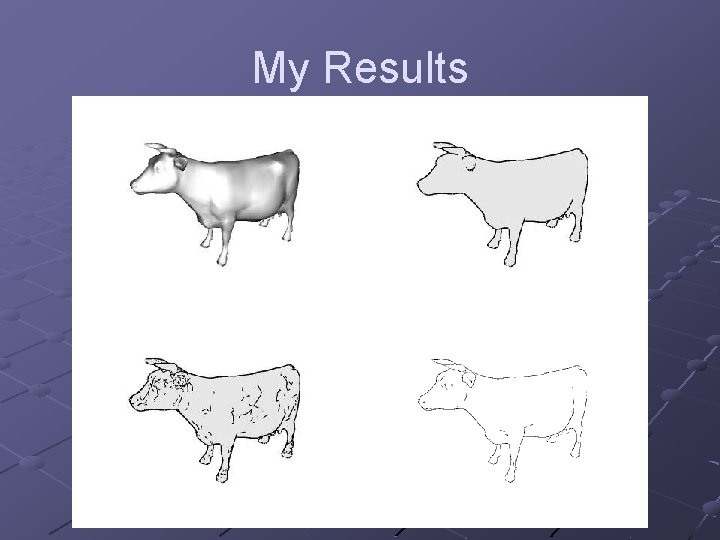
My Results
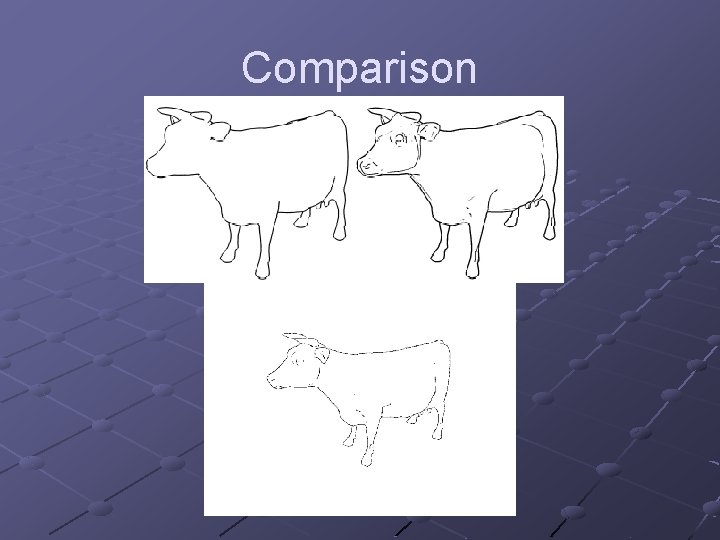
Comparison
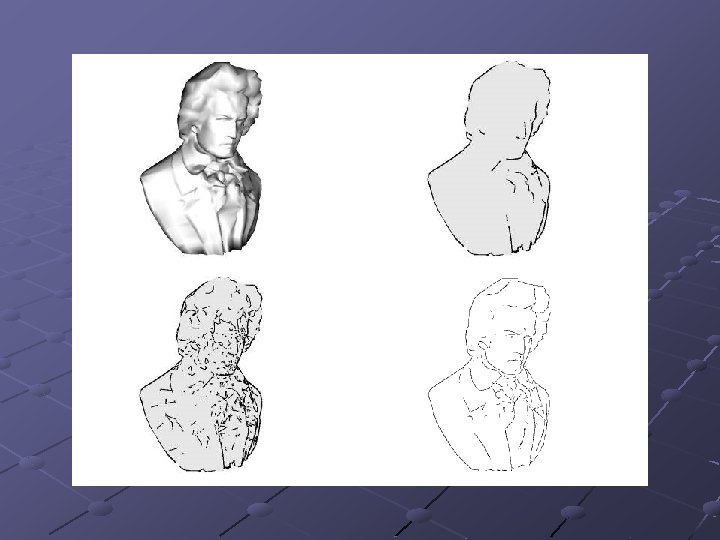
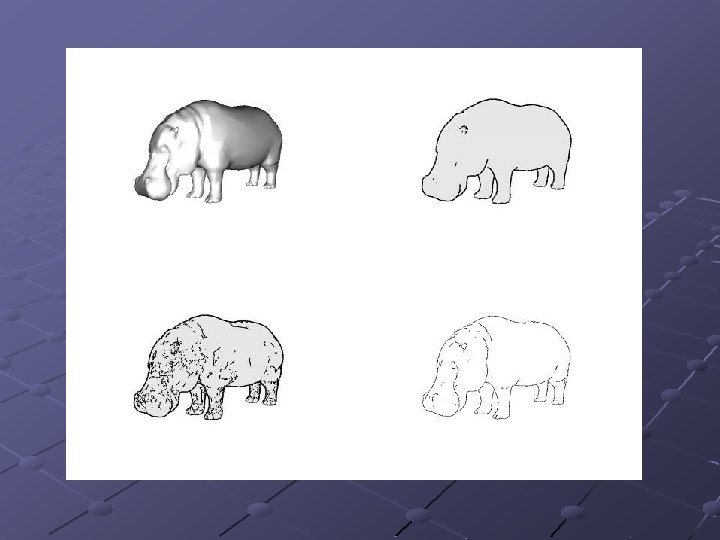
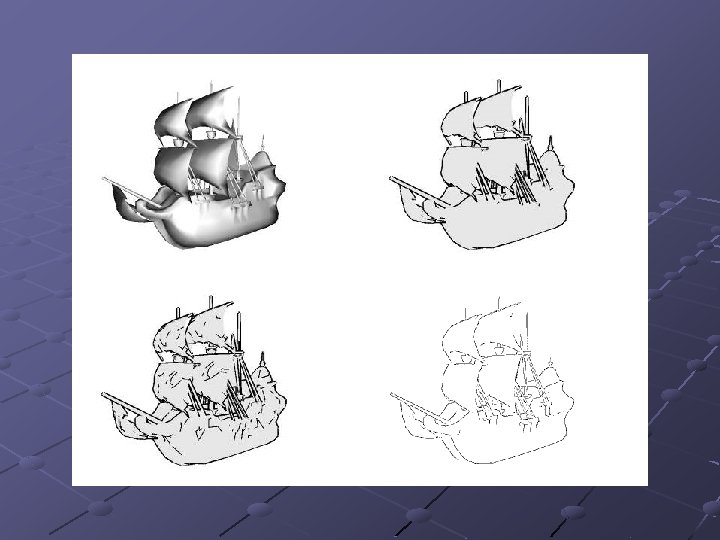
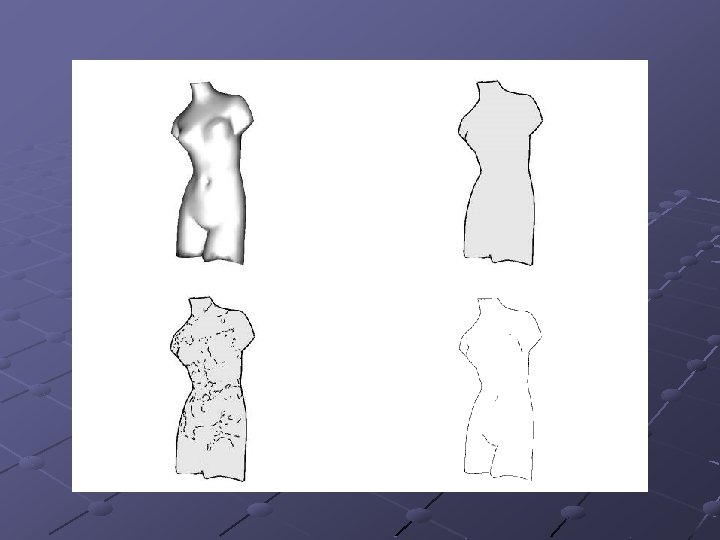
Comparison Between Algorithms Image: n n n Slower Good results Very easy to implement - < 50 lines of code Object: n n n Faster Theoretically better results Much harder to implement – several hundred lines of code
Future Directions Improve object space algorithm. Need less parameters. Implement algorithms on the GPU by using vertex and pixel shaders. Work better with smooth surfaces
- Slides: 16