
Stanford CS 223 B Computer Vision Winter 2005
Stanford CS 223 B Computer Vision, Winter 2005 Lecture 13: Learning Large Environment Models Sebastian Thrun, Stanford Rick Szeliski, Microsoft Hendrik Dahlkamp and Dan Morris, Stanford
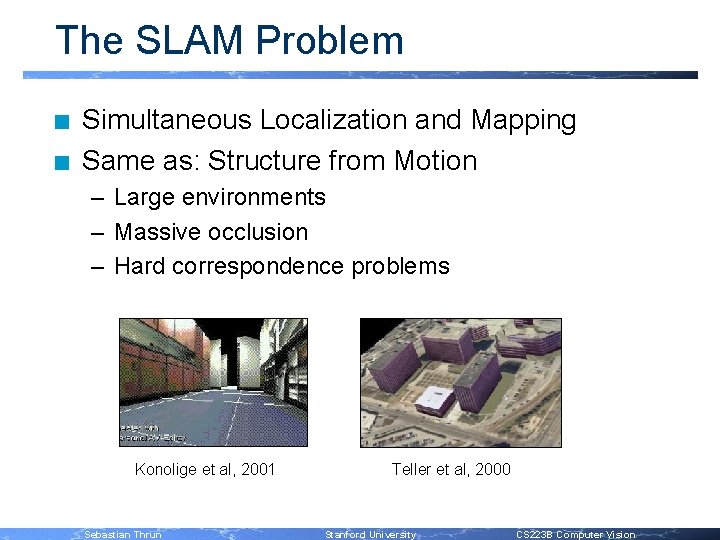
The SLAM Problem n n Simultaneous Localization and Mapping Same as: Structure from Motion – Large environments – Massive occlusion – Hard correspondence problems Konolige et al, 2001 Sebastian Thrun Teller et al, 2000 Stanford University CS 223 B Computer Vision
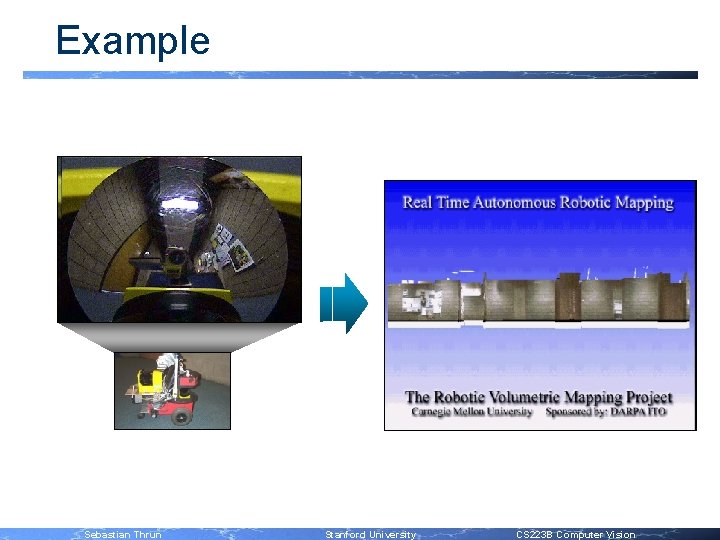
Example Sebastian Thrun Stanford University CS 223 B Computer Vision
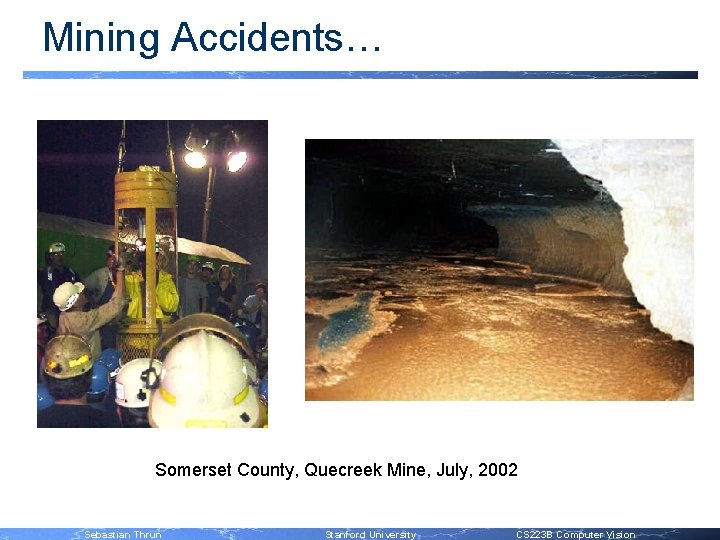
Mining Accidents… Somerset County, Quecreek Mine, July, 2002 Sebastian Thrun Stanford University CS 223 B Computer Vision
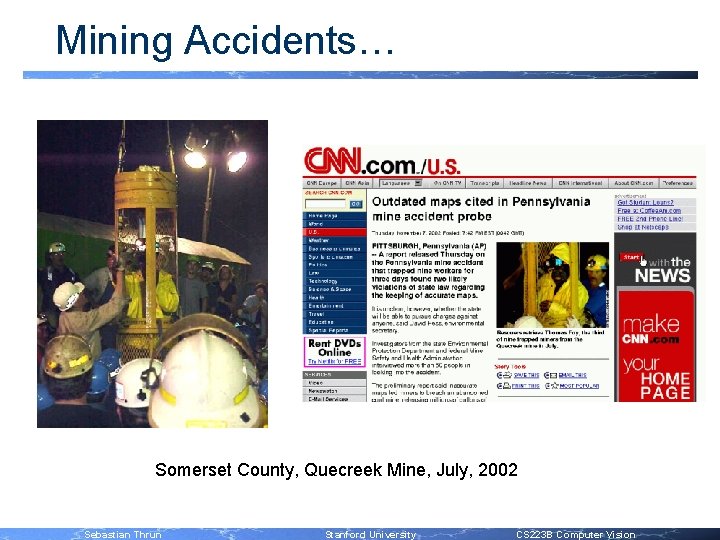
Mining Accidents… Somerset County, Quecreek Mine, July, 2002 Sebastian Thrun Stanford University CS 223 B Computer Vision
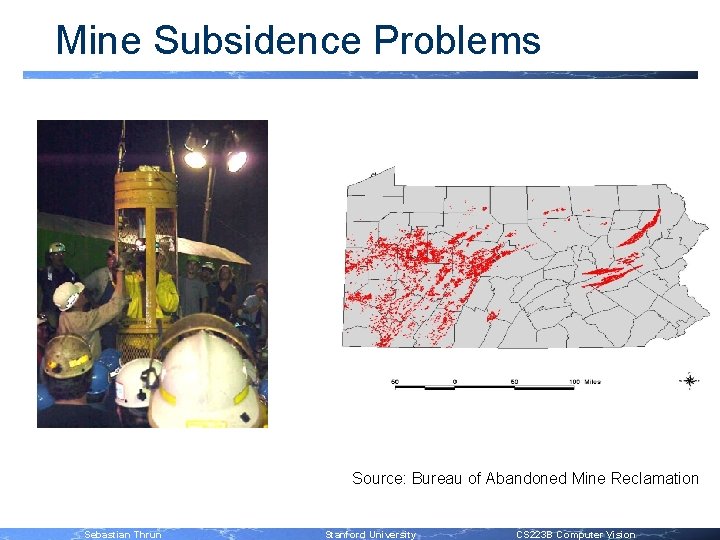
Mine Subsidence Problems Source: Bureau of Abandoned Mine Reclamation Sebastian Thrun Stanford University CS 223 B Computer Vision
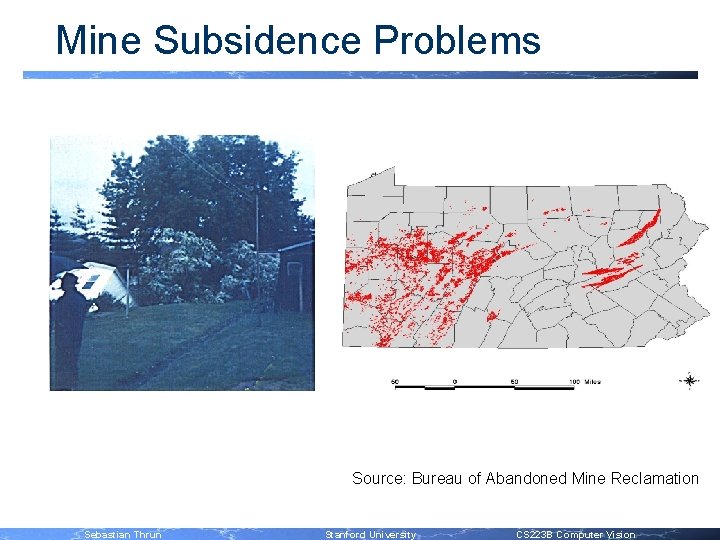
Mine Subsidence Problems Source: Bureau of Abandoned Mine Reclamation Sebastian Thrun Stanford University CS 223 B Computer Vision
Course: CMU RI 16 -894 with Red Whittaker, Scott Thayer, 10+ students Sebastian Thrun Stanford University CS 223 B Computer Vision
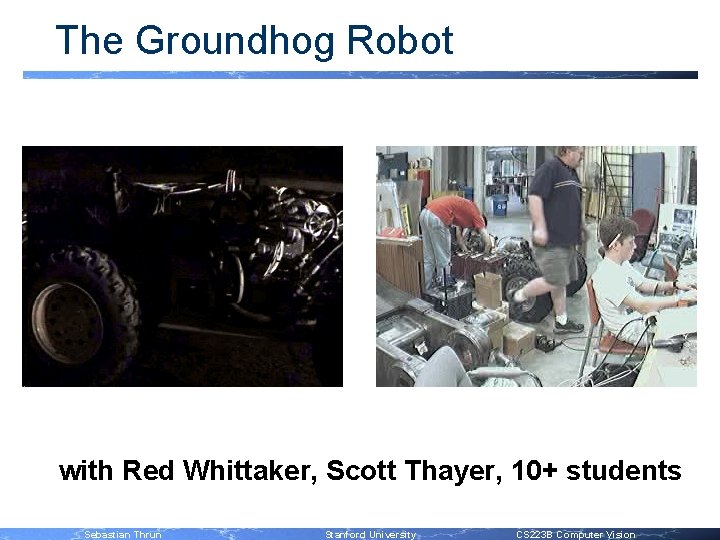
The Groundhog Robot with Red Whittaker, Scott Thayer, 10+ students Sebastian Thrun Stanford University CS 223 B Computer Vision
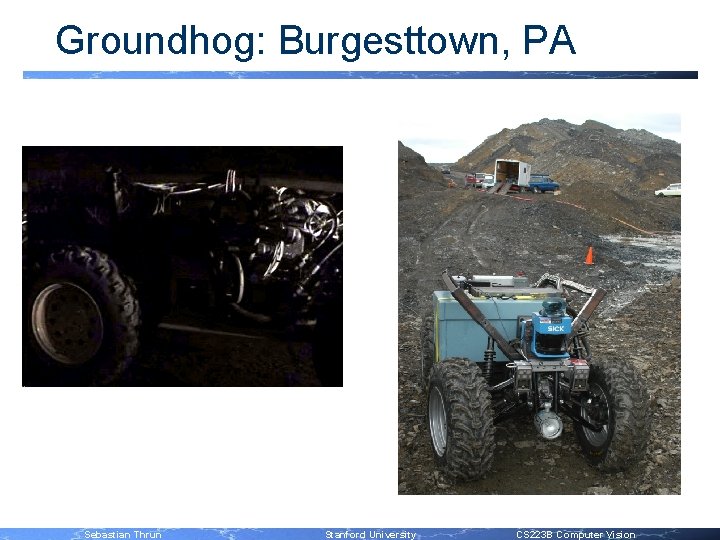
Groundhog: Burgesttown, PA Sebastian Thrun Stanford University CS 223 B Computer Vision
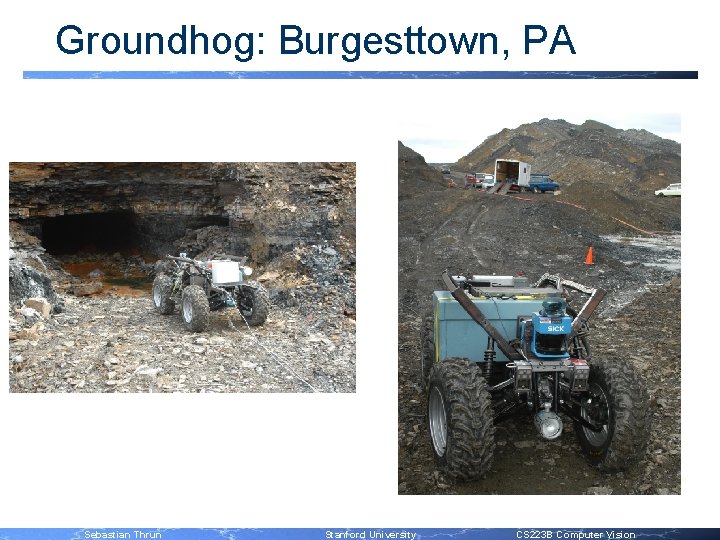
Groundhog: Burgesttown, PA Sebastian Thrun Stanford University CS 223 B Computer Vision
Groundhog: Burgesttown, PA Sebastian Thrun Stanford University CS 223 B Computer Vision
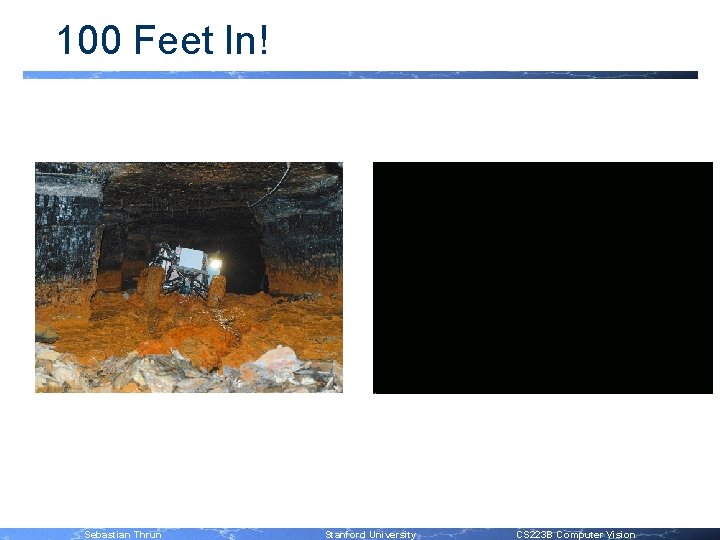
100 Feet In! Sebastian Thrun Stanford University CS 223 B Computer Vision
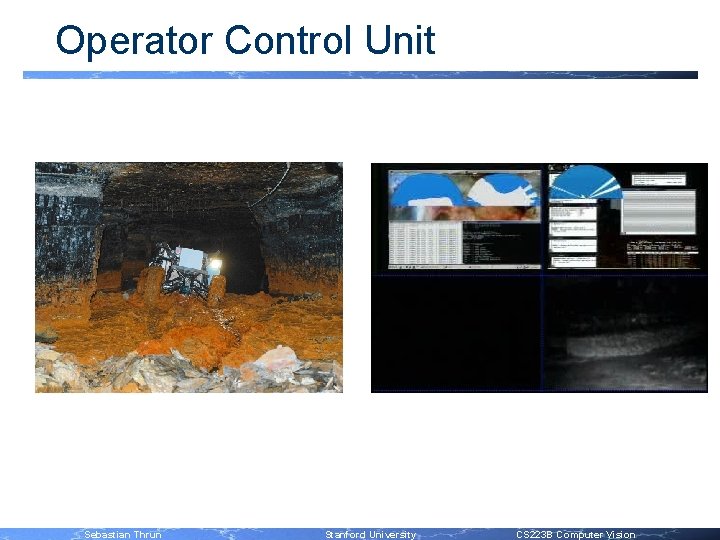
Operator Control Unit Sebastian Thrun Stanford University CS 223 B Computer Vision
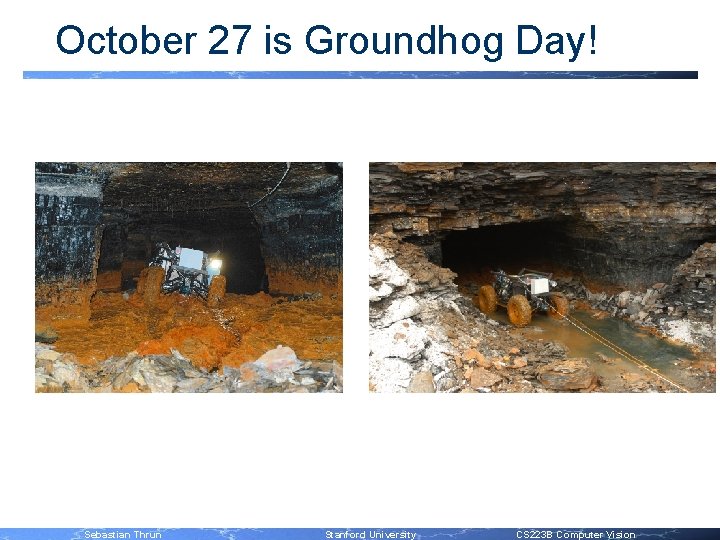
October 27 is Groundhog Day! Sebastian Thrun Stanford University CS 223 B Computer Vision
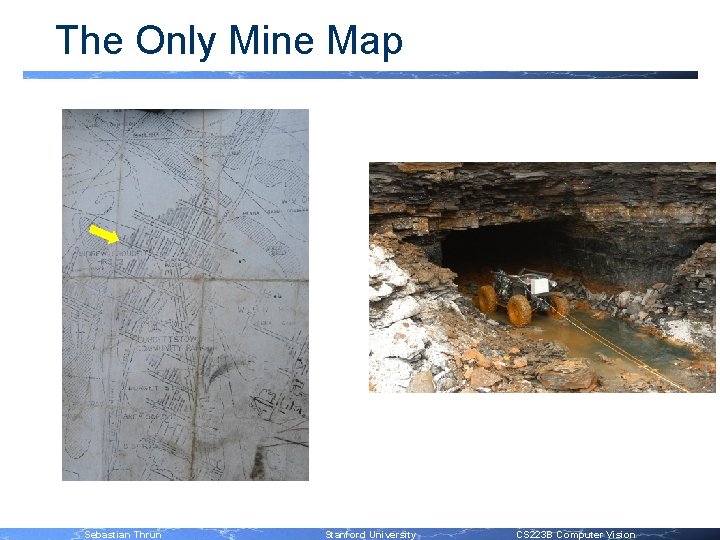
The Only Mine Map Sebastian Thrun Stanford University CS 223 B Computer Vision
The Basic Problem n Mapping Mines – Very large environments, many cycles – Volumes, centimeter accuracy – Real-time – Autonomous (no communication) n Is instance of: SLAM Problem (Simultaneous Localization and Mapping) – Hundreds of millions of features – Massive data association Sebastian Thrun Stanford University CS 223 B Computer Vision
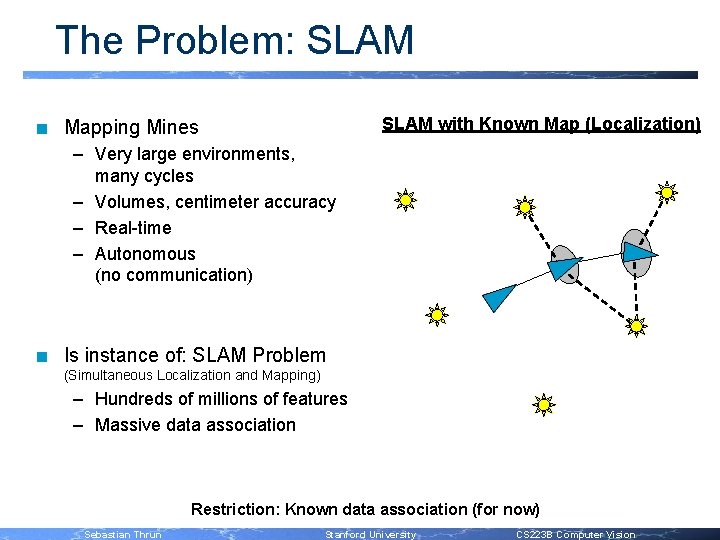
The Problem: SLAM n SLAM with Known Map (Localization) Mapping Mines – Very large environments, many cycles – Volumes, centimeter accuracy – Real-time – Autonomous (no communication) n Is instance of: SLAM Problem (Simultaneous Localization and Mapping) – Hundreds of millions of features – Massive data association Restriction: Known data association (for now) Sebastian Thrun Stanford University CS 223 B Computer Vision
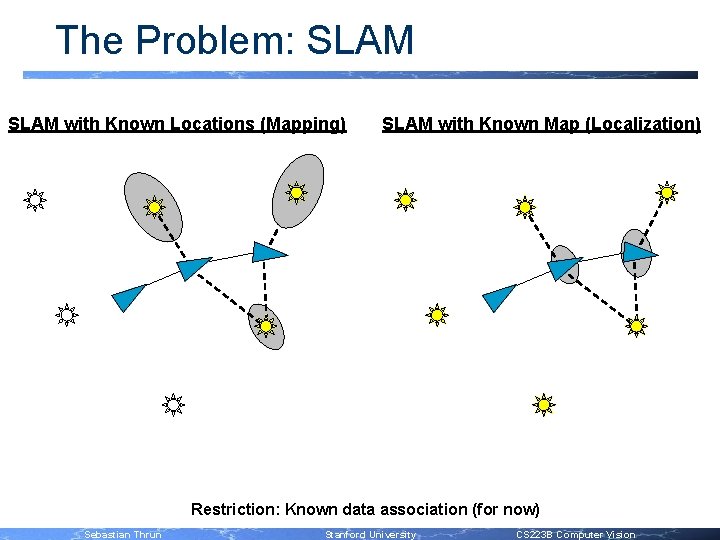
The Problem: SLAM with Known Locations (Mapping) SLAM with Known Map (Localization) Restriction: Known data association (for now) Sebastian Thrun Stanford University CS 223 B Computer Vision
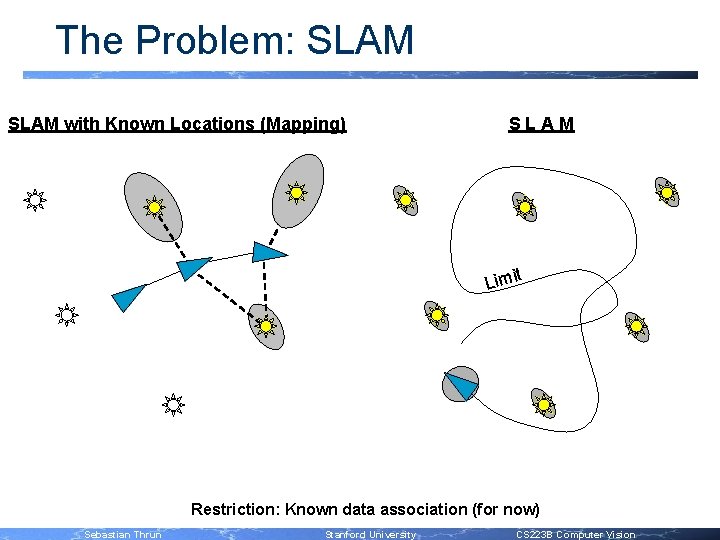
The Problem: SLAM with Known Locations (Mapping) SLAM t Limi Restriction: Known data association (for now) Sebastian Thrun Stanford University CS 223 B Computer Vision
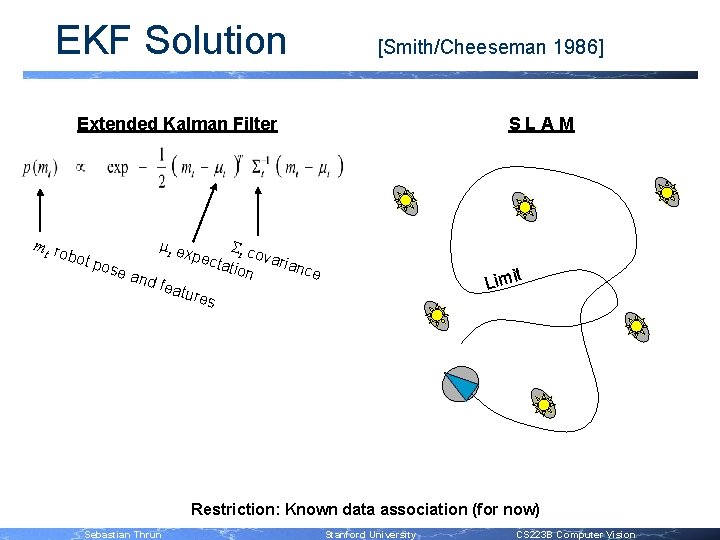
EKF Solution [Smith/Cheeseman 1986] Extended Kalman Filter SLAM mt ro mt ex S bot pect t covari pose ance ation and feat ures t Limi Restriction: Known data association (for now) Sebastian Thrun Stanford University CS 223 B Computer Vision
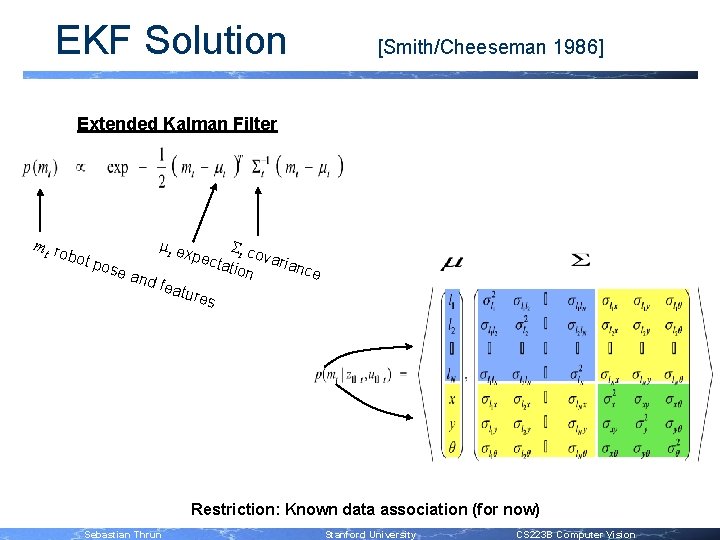
EKF Solution [Smith/Cheeseman 1986] Extended Kalman Filter mt ro mt ex S bot pect t covari pose ance ation and feat ures Restriction: Known data association (for now) Sebastian Thrun Stanford University CS 223 B Computer Vision
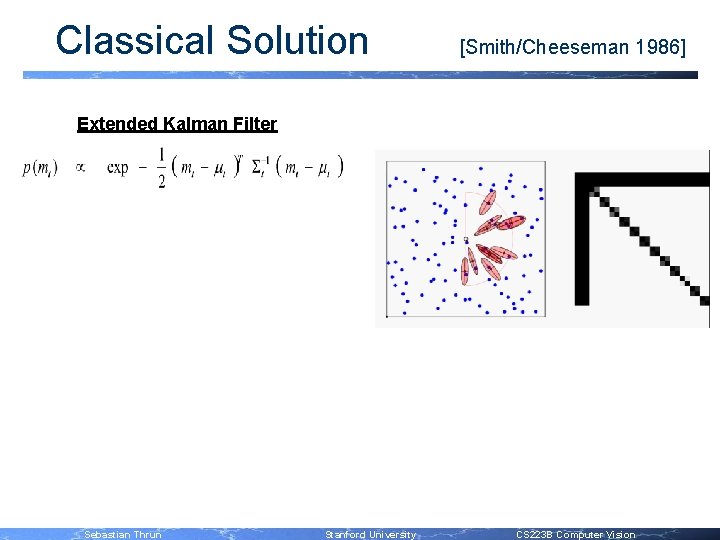
Classical Solution [Smith/Cheeseman 1986] Extended Kalman Filter Sebastian Thrun Stanford University CS 223 B Computer Vision
Evolution Robotics Sebastian Thrun Stanford University CS 223 B Computer Vision
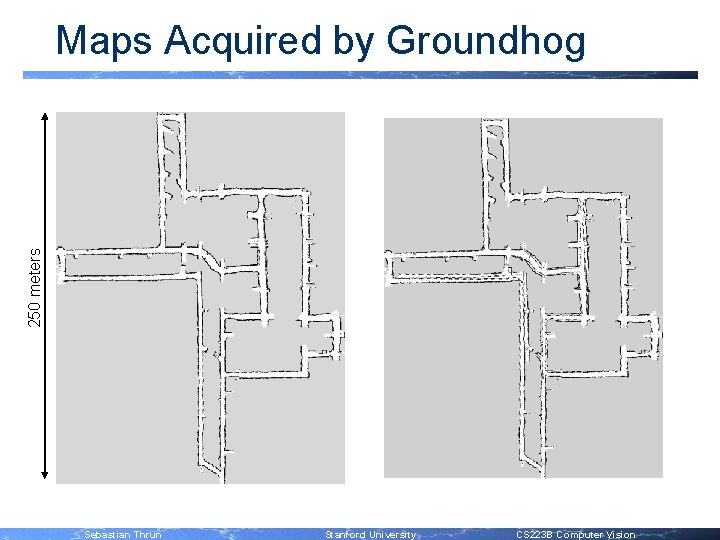
250 meters Maps Acquired by Groundhog Sebastian Thrun Stanford University CS 223 B Computer Vision
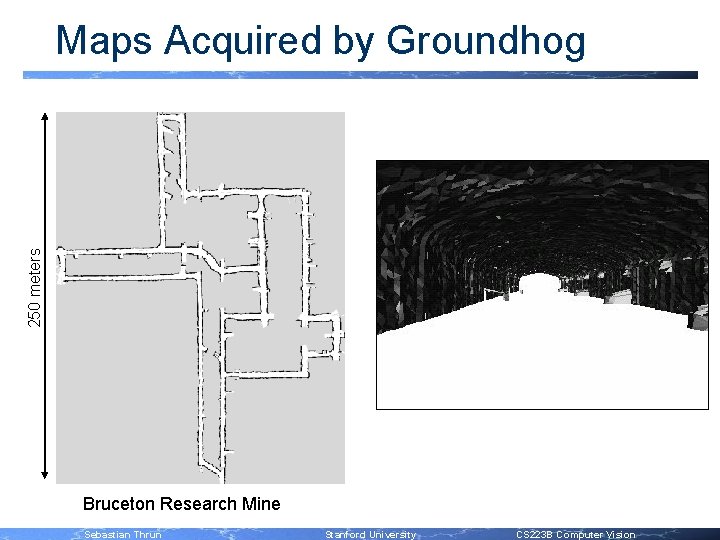
250 meters Maps Acquired by Groundhog Bruceton Research Mine Sebastian Thrun Stanford University CS 223 B Computer Vision
Summary SLAM n Is a Hybrid Tracking Problem – Camera pose (robot) – Large number of environmental features – Large number of data association variables n Solution Kalman Filter (very high dimensional) Sebastian Thrun Stanford University CS 223 B Computer Vision
- Slides: 27