
Slovak university of technology in Bratislava Faculty of
Slovak university of technology in Bratislava Faculty of chemical and food technology Institute of information, automation and mathematics Convex-lifting-based robust control of chemical reactor Bc. Michaela Horváthová Supervisor: Ing. Juraj Oravec, Ph. D.
Slovak university of technology in Bratislava Faculty of chemical and food technology Institute of information, automation and mathematics Convex-lifting-based robust control of chemical reactor Bc. Michaela Horváthová Supervisor: Ing. Juraj Oravec, Ph. D.
Motivation 3
Goals • Reduction of model conservativeness, • design of control for chemical reactor based on convex lifting. 4
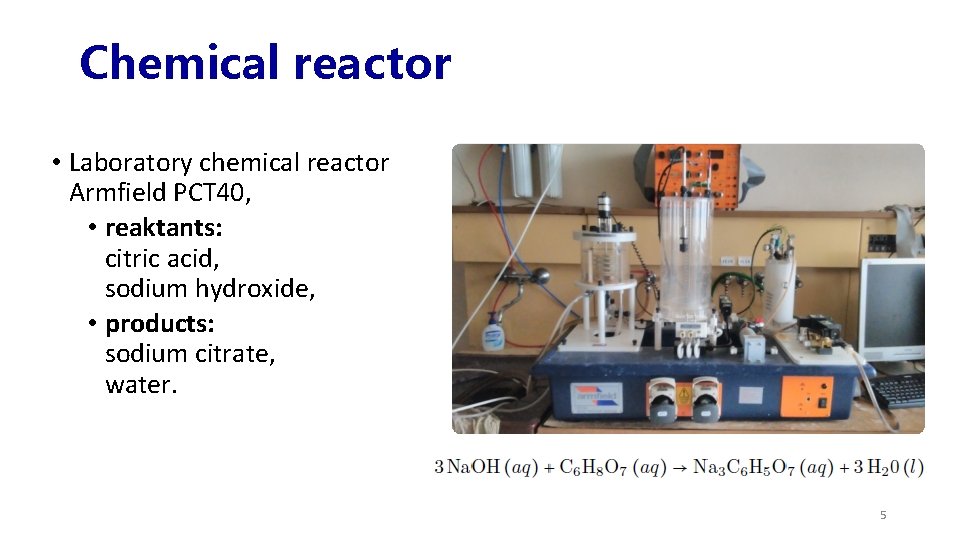
Chemical reactor • Laboratory chemical reactor Armfield PCT 40, • reaktants: citric acid, sodium hydroxide, • products: sodium citrate, water. 5
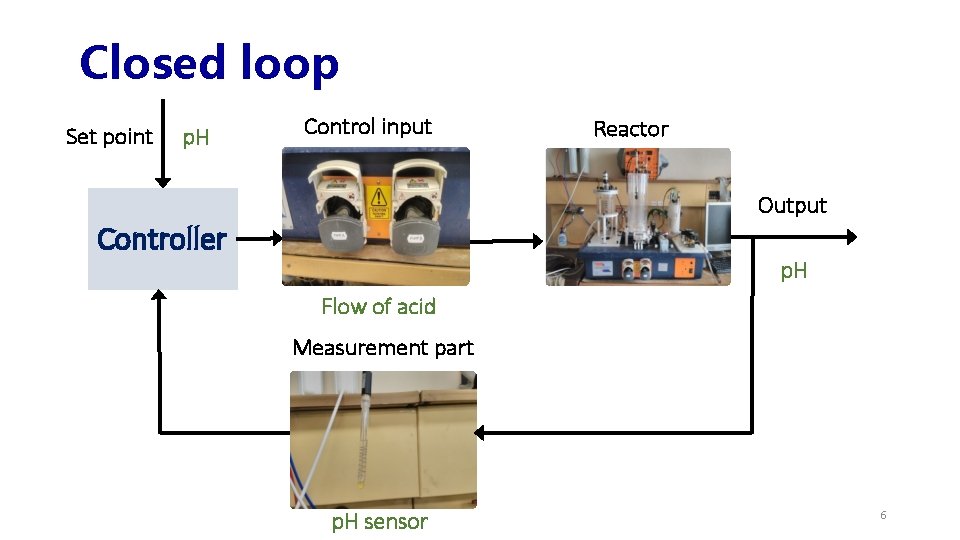
Closed loop Set point p. H Control input Reactor Controller Output p. H Flow of acid Measurement part p. H sensor 6
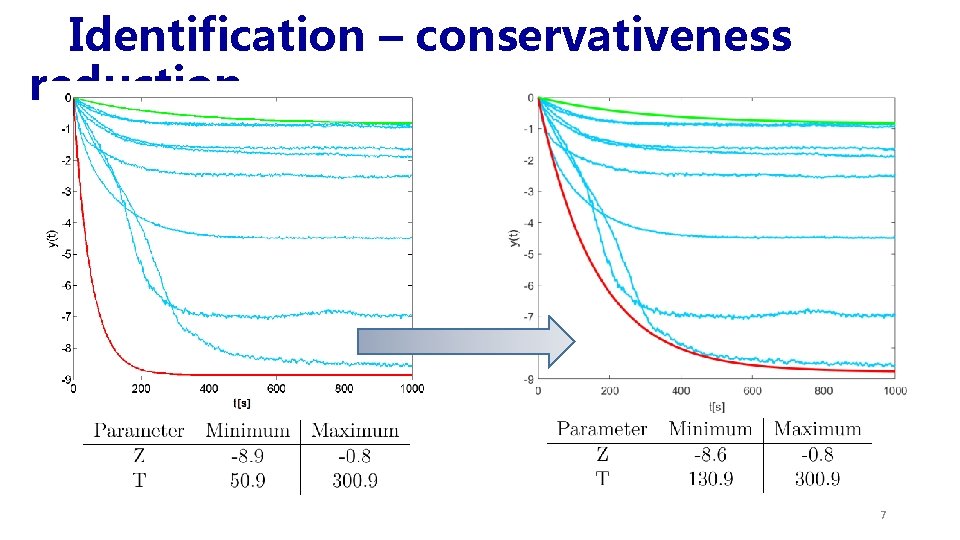
Identification – conservativeness reduction 7
Robust MPC ü Ability to control nonlinear uncertain systems, ü respects constrains on inputs and outputs, ü optimizes control signal at each sampling time, ü predicts future behavior of the system. 8
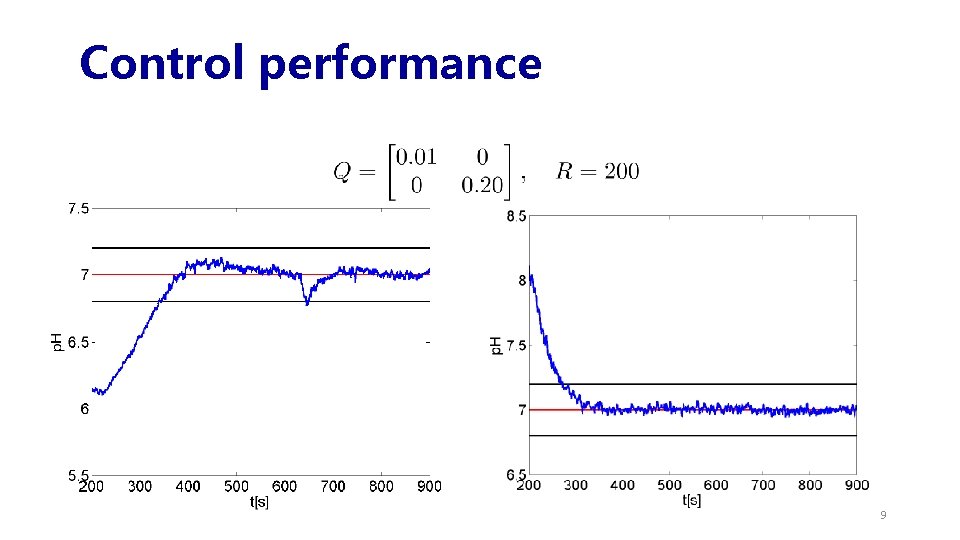
Control performance 9
Control based on convex lifting + All advantages of robust MPC, + solves complex optimization problem before actual control (offline), + decreases computational complexity during control (online), + respects influence of measurment noise, – overall computational complexity increases with number of states. N. A. Nguyen, S. Olaru, P. Rodriguez-Ayerbe, M. Kvasnica: Convex liftings-based Robust Control Design, Automatica, 2016. 10
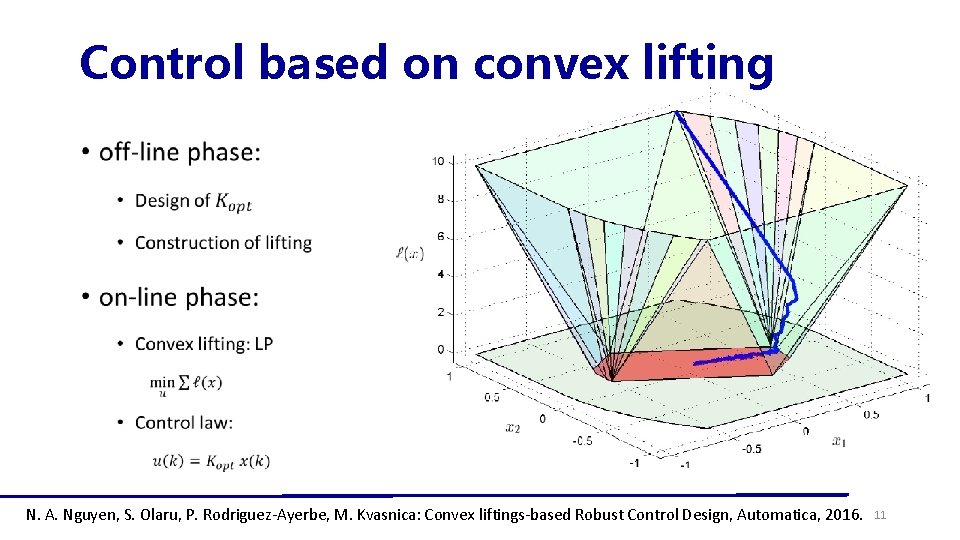
Control based on convex lifting • N. A. Nguyen, S. Olaru, P. Rodriguez-Ayerbe, M. Kvasnica: Convex liftings-based Robust Control Design, Automatica, 2016. 11
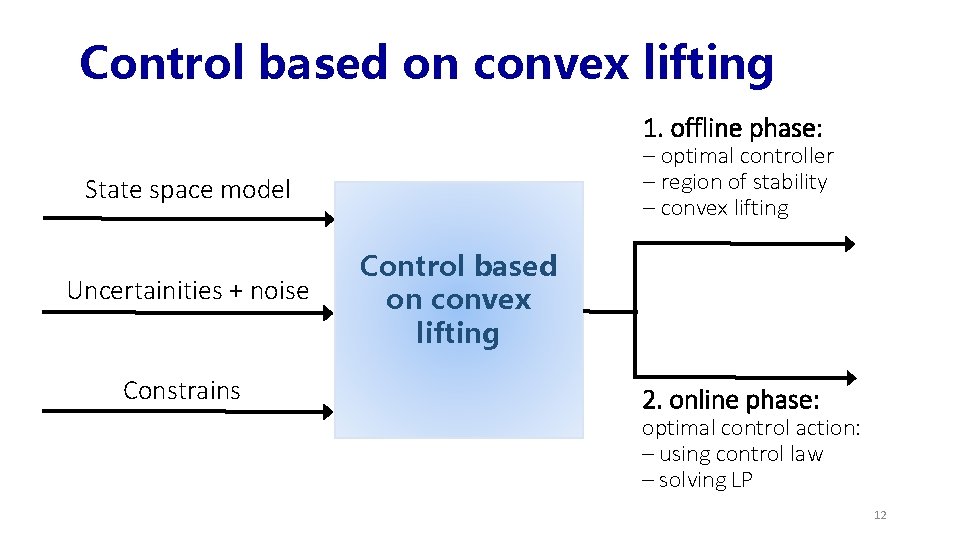
Control based on convex lifting 1. offline phase: – optimal controller – region of stability – convex lifting State space model Uncertainities + noise Constrains Control based on convex lifting 2. online phase: optimal control action: – using control law – solving LP 12
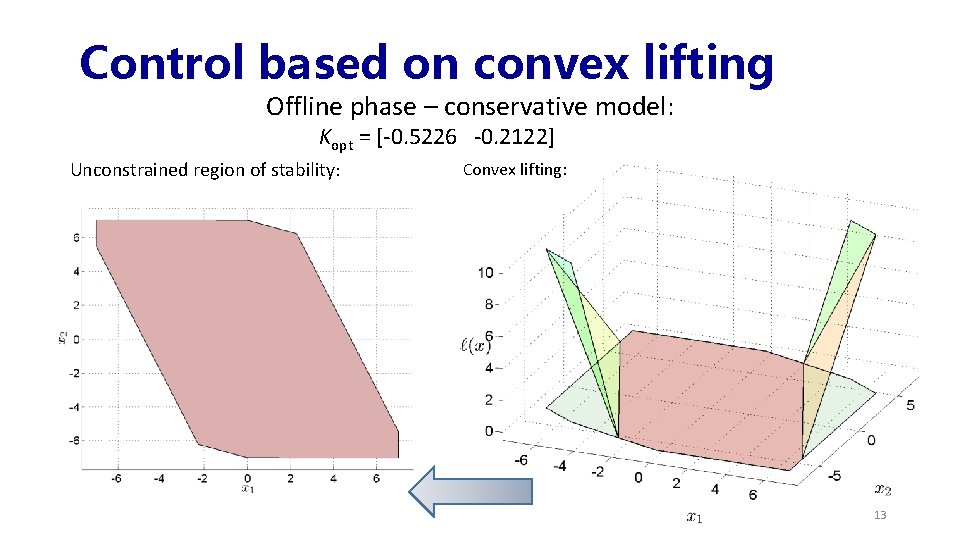
Control based on convex lifting Offline phase – conservative model: Kopt = [-0. 5226 -0. 2122] Unconstrained region of stability: Convex lifting: 13
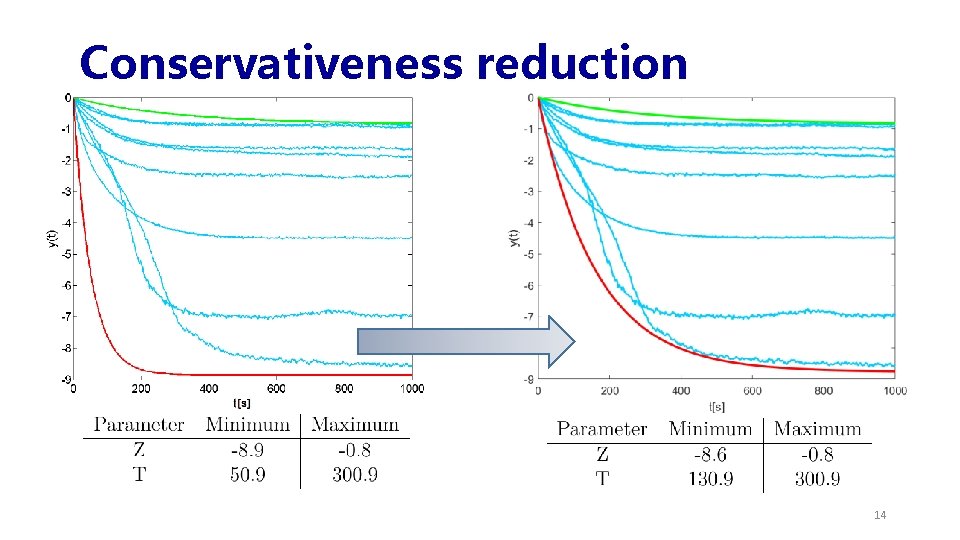
Conservativeness reduction 14
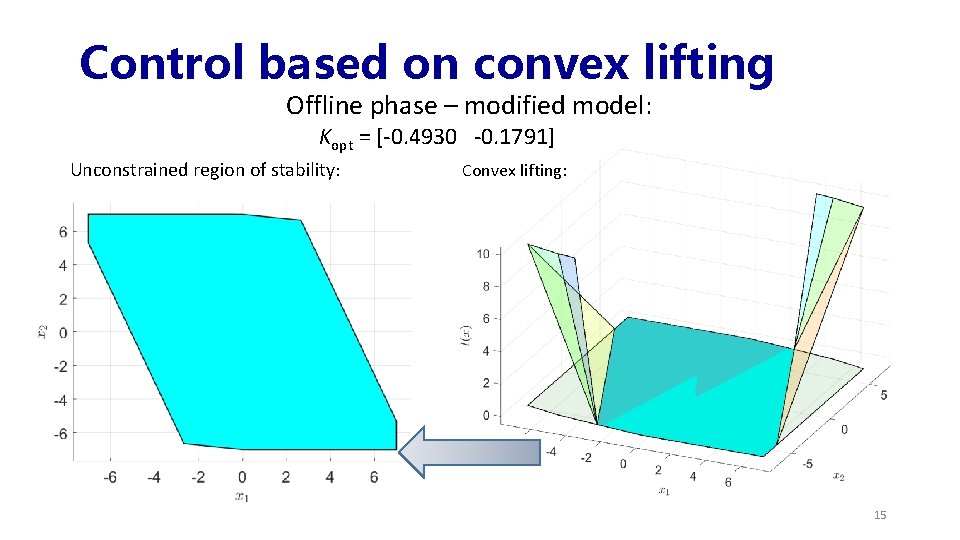
Control based on convex lifting Offline phase – modified model: Kopt = [-0. 4930 -0. 1791] Unconstrained region of stability: Convex lifting: 15
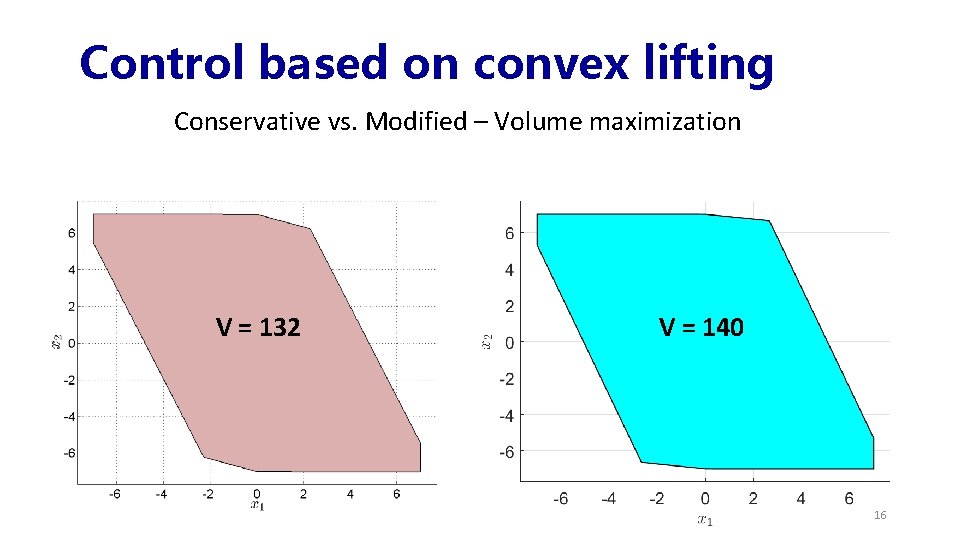
Control based on convex lifting Conservative vs. Modified – Volume maximization V = 132 V = 140 16
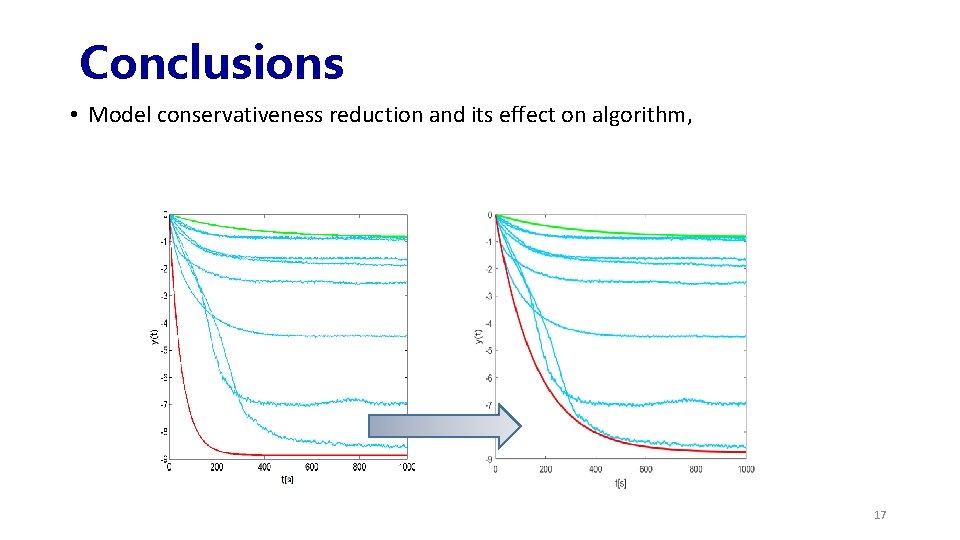
Conclusions • Model conservativeness reduction and its effect on algorithm, 17
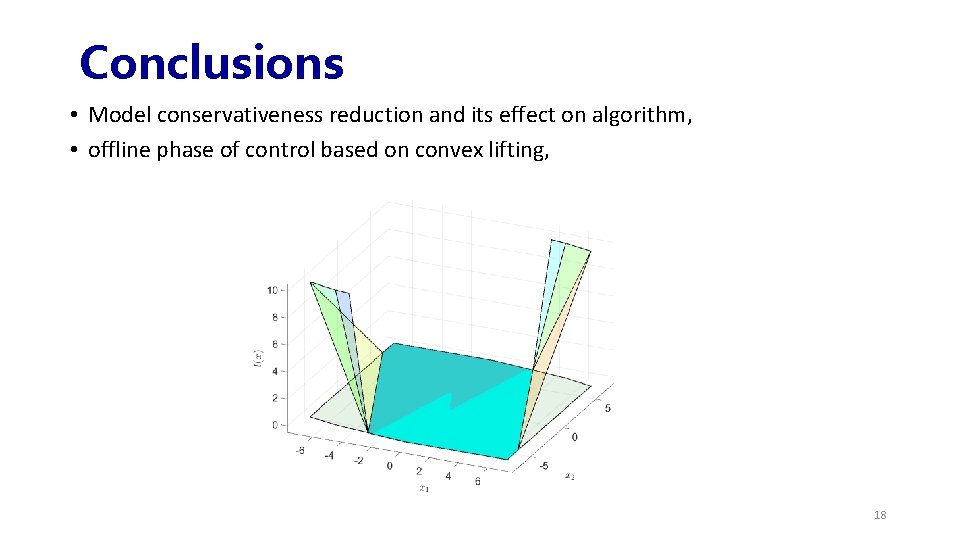
Conclusions • Model conservativeness reduction and its effect on algorithm, • offline phase of control based on convex lifting, 18
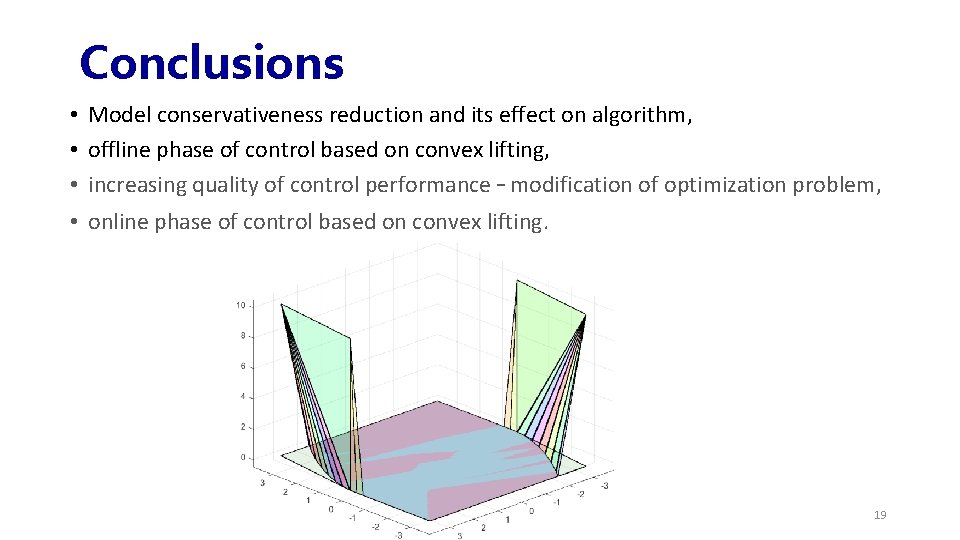
Conclusions • Model conservativeness reduction and its effect on algorithm, • offline phase of control based on convex lifting, • increasing quality of control performance – modification of optimization problem, • online phase of control based on convex lifting. 19
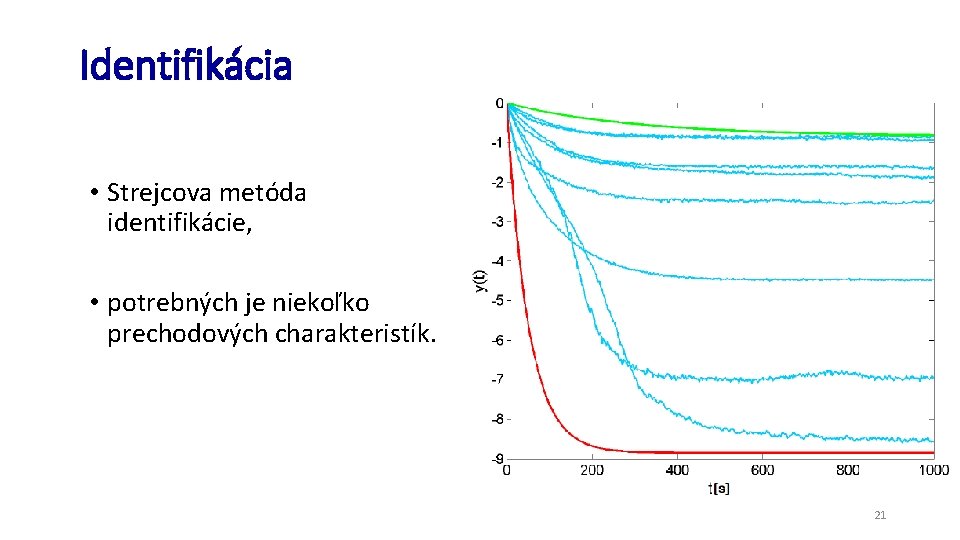
Identifikácia • Strejcova metóda identifikácie, • potrebných je niekoľko prechodových charakteristík. 21
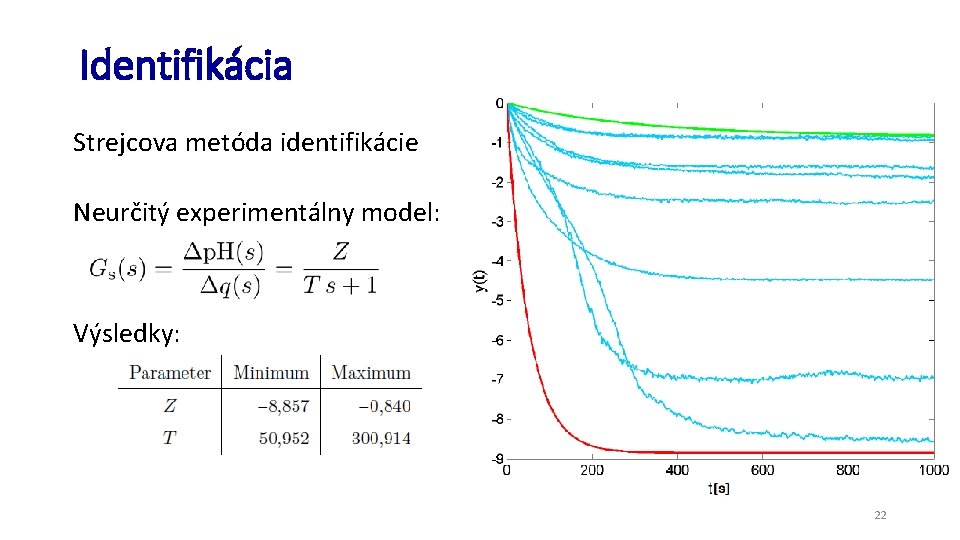
Identifikácia Strejcova metóda identifikácie Neurčitý experimentálny model: Výsledky: 22
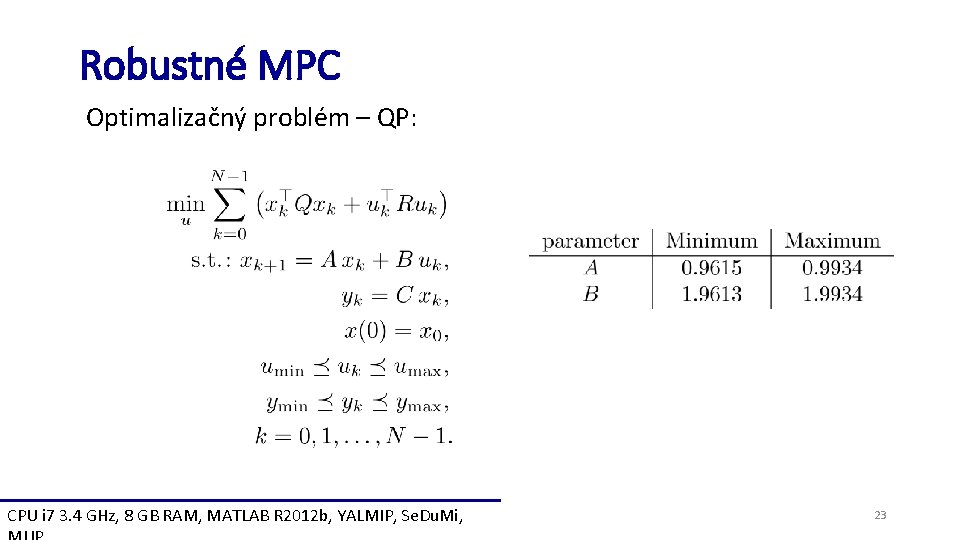
Robustné MPC Optimalizačný problém – QP: CPU i 7 3. 4 GHz, 8 GB RAM, MATLAB R 2012 b, YALMIP, Se. Du. Mi, 23
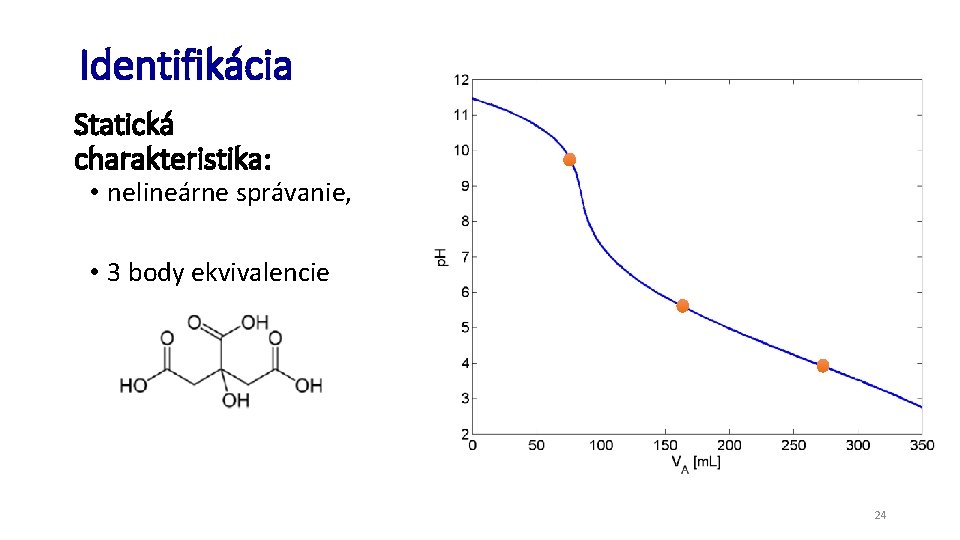
Identifikácia Statická charakteristika: • nelineárne správanie, • 3 body ekvivalencie Bez názvu. png 24
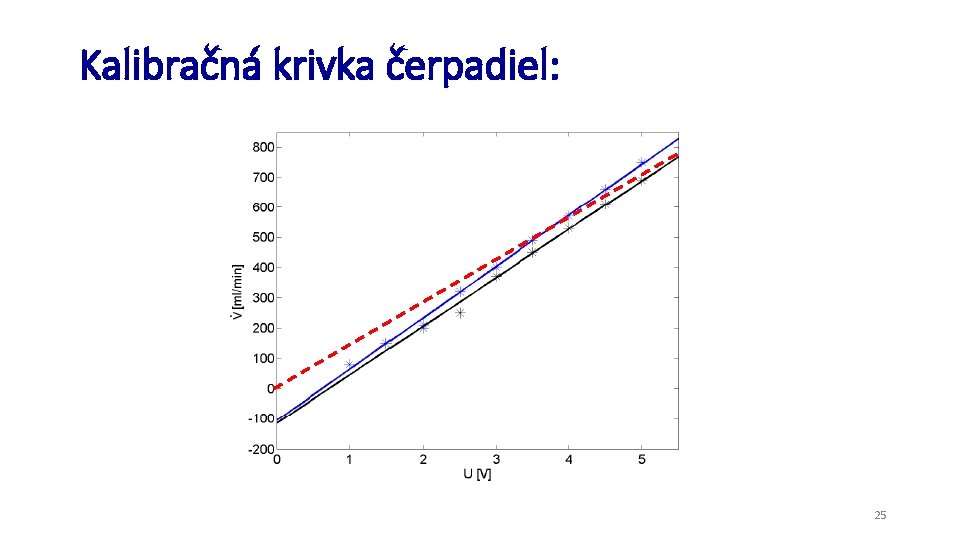
Kalibračná krivka čerpadiel: 25
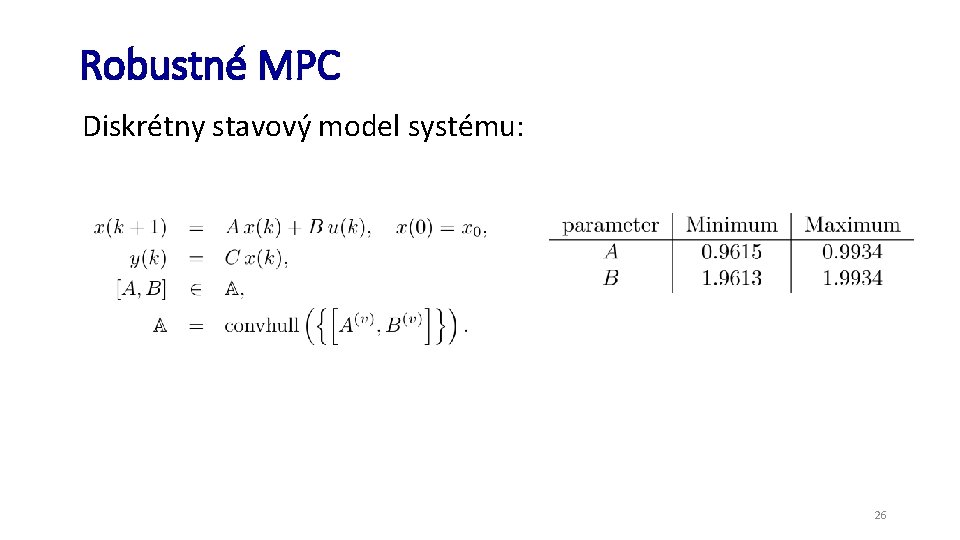
Robustné MPC Diskrétny stavový model systému: 26
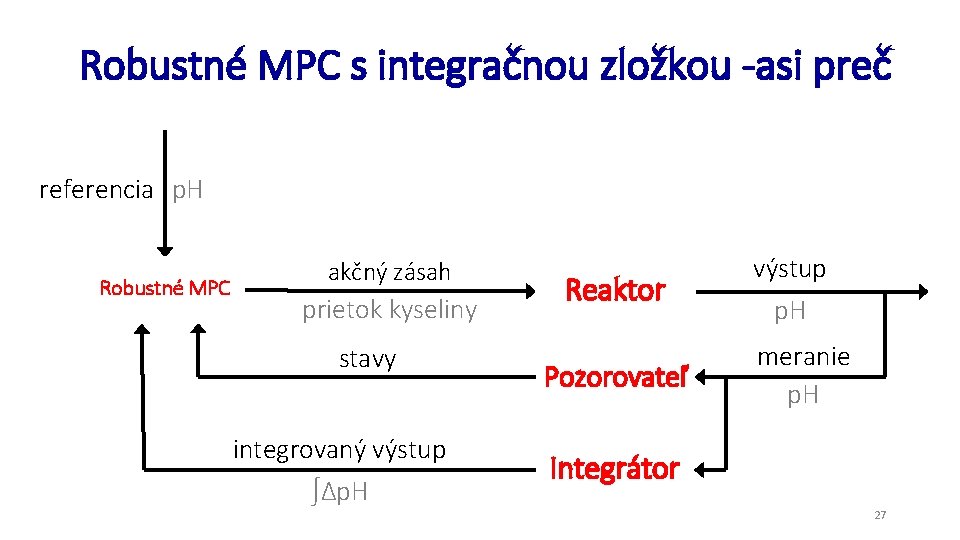
Robustné MPC s integračnou zložkou -asi preč referencia p. H Robustné MPC akčný zásah prietok kyseliny stavy integrovaný výstup ∫Δp. H Reaktor Pozorovateľ výstup p. H meranie p. H Integrátor 27
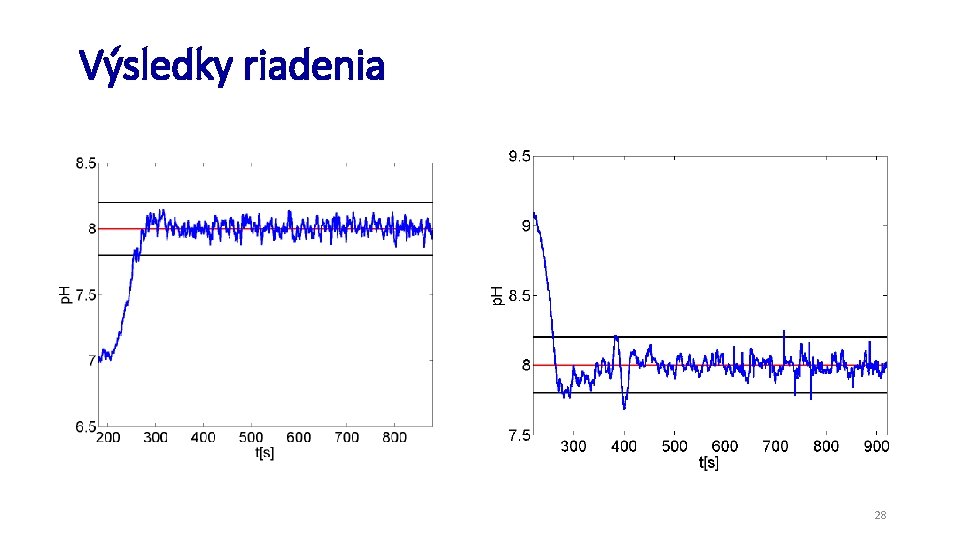
Výsledky riadenia 28
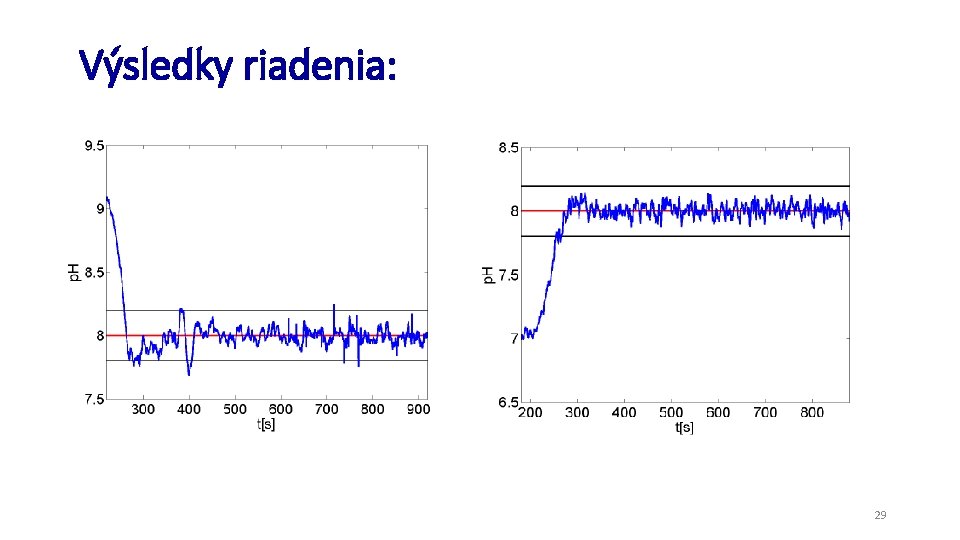
Výsledky riadenia: 29
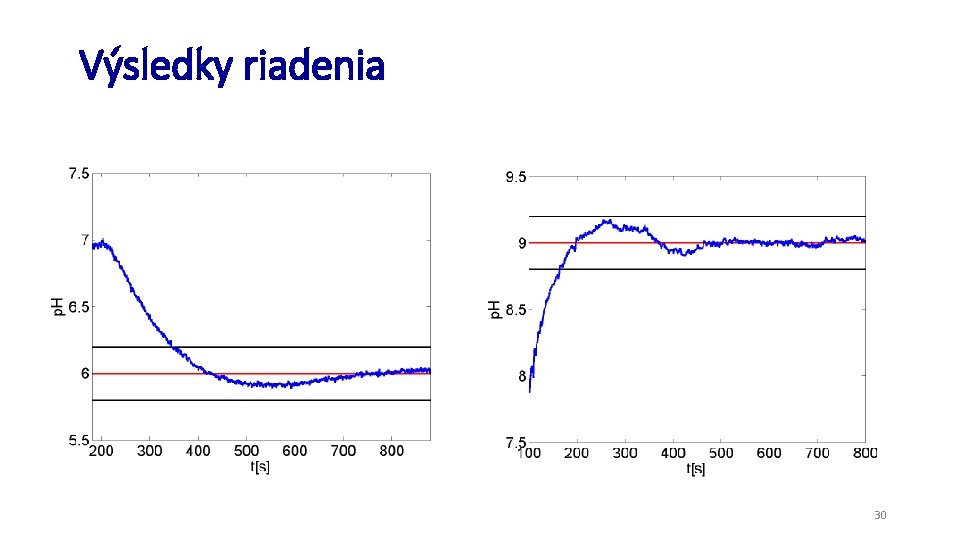
Výsledky riadenia 30
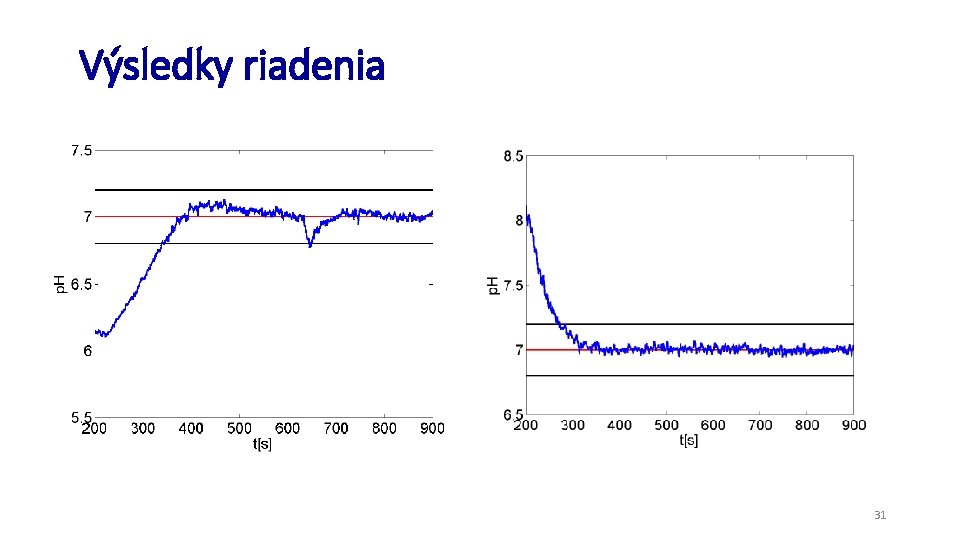
Výsledky riadenia 31
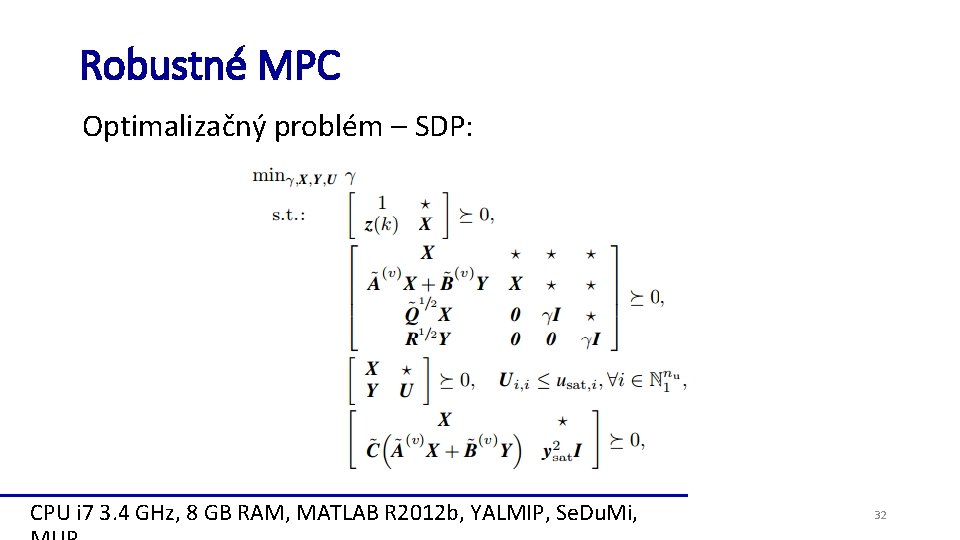
Robustné MPC Optimalizačný problém – SDP: CPU i 7 3. 4 GHz, 8 GB RAM, MATLAB R 2012 b, YALMIP, Se. Du. Mi, 32
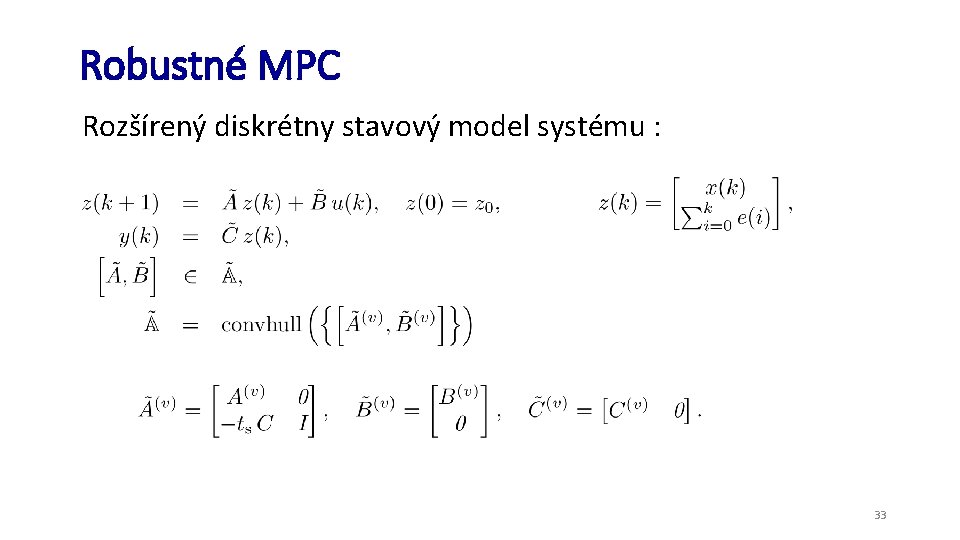
Robustné MPC Rozšírený diskrétny stavový model systému : 33
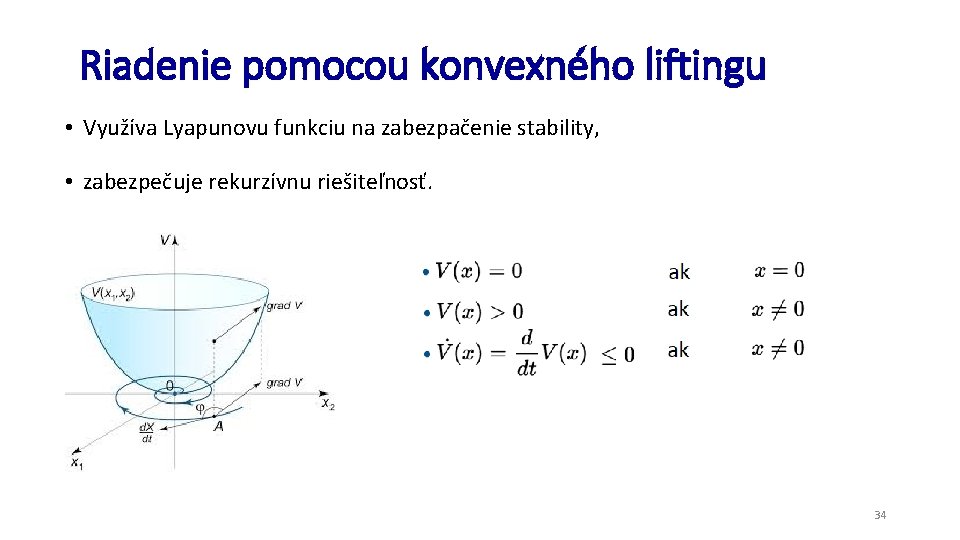
Riadenie pomocou konvexného liftingu • Využíva Lyapunovu funkciu na zabezpačenie stability, • zabezpečuje rekurzívnu riešiteľnosť. 34
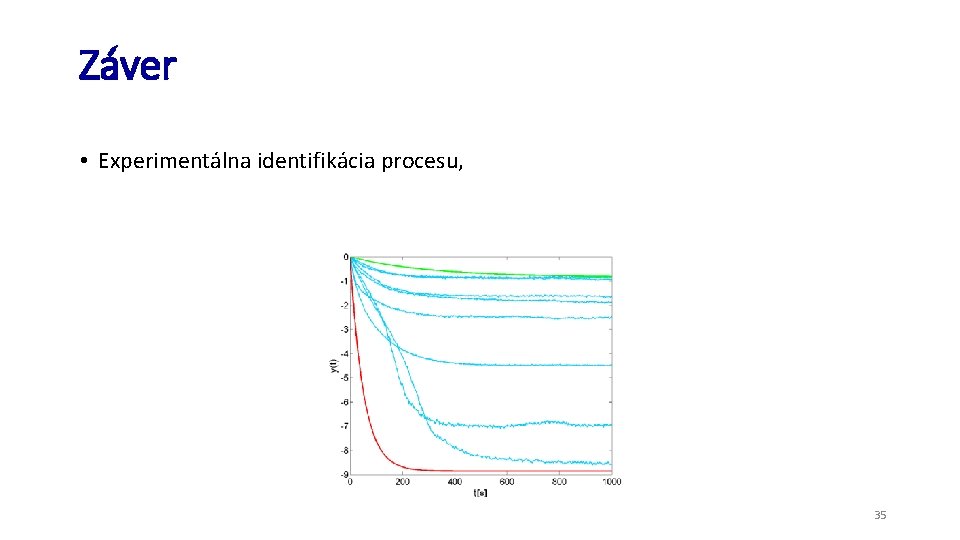
Záver • Experimentálna identifikácia procesu, 35
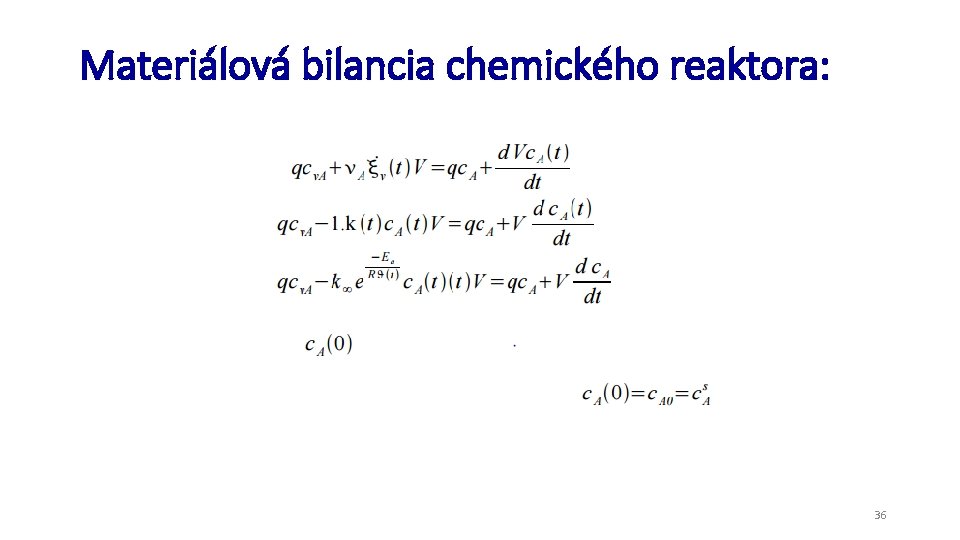
Materiálová bilancia chemického reaktora: 36
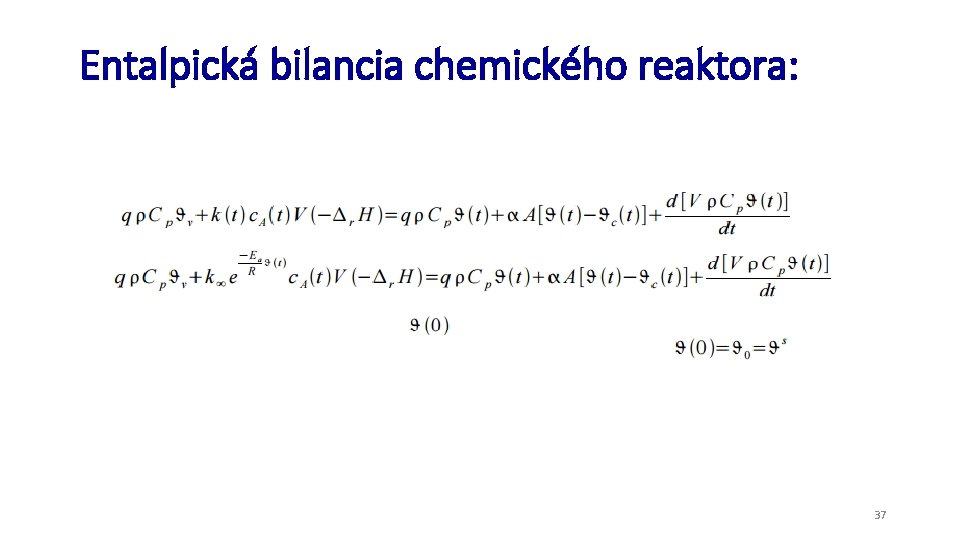
Entalpická bilancia chemického reaktora: 37
- Slides: 37