
Scale Invariant Feature Transform SIFT Outline What is
- Slides: 24
Scale Invariant Feature Transform (SIFT)
Outline What is SIFT Algorithm overview Object Detection Summary
Overview 1999 Generates image features, “keypoints” – invariant to image scaling and rotation – partially invariant to change in illumination and 3 D camera viewpoint – many can be extracted from typical images – highly distinctive
Algorithm overview Scale-space extrema detection – Uses difference-of-Gaussian function Keypoint localization – Sub-pixel location and scale fit to a model Orientation assignment – 1 or more for each keypoint Keypoint descriptor – Created from local image gradients
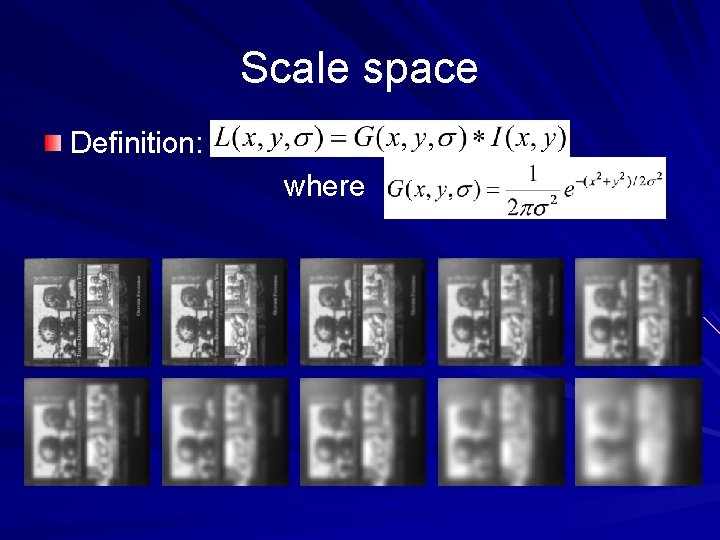
Scale space Definition: where
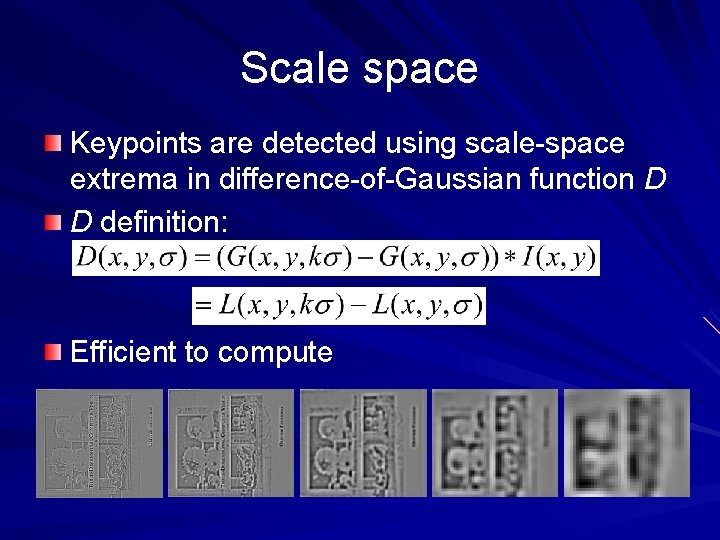
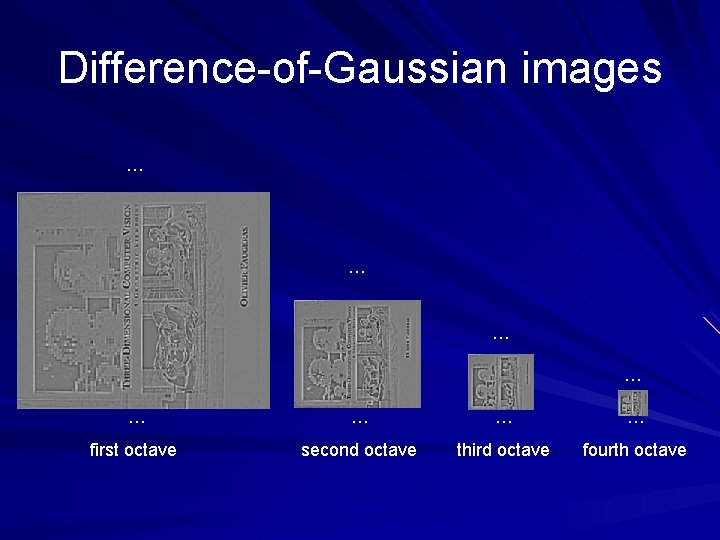
Scale space Keypoints are detected using scale-space extrema in difference-of-Gaussian function D D definition: Efficient to compute
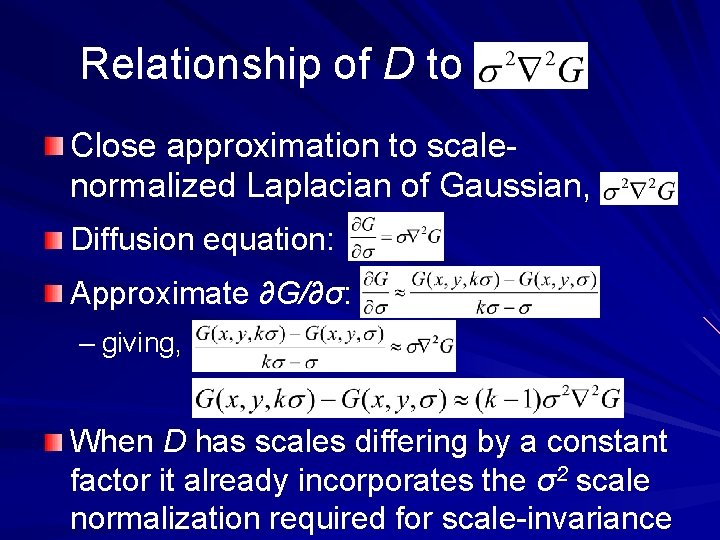
Relationship of D to Close approximation to scalenormalized Laplacian of Gaussian, Diffusion equation: Approximate ∂G/∂σ: – giving, When D has scales differing by a constant factor it already incorporates the σ2 scale normalization required for scale-invariance
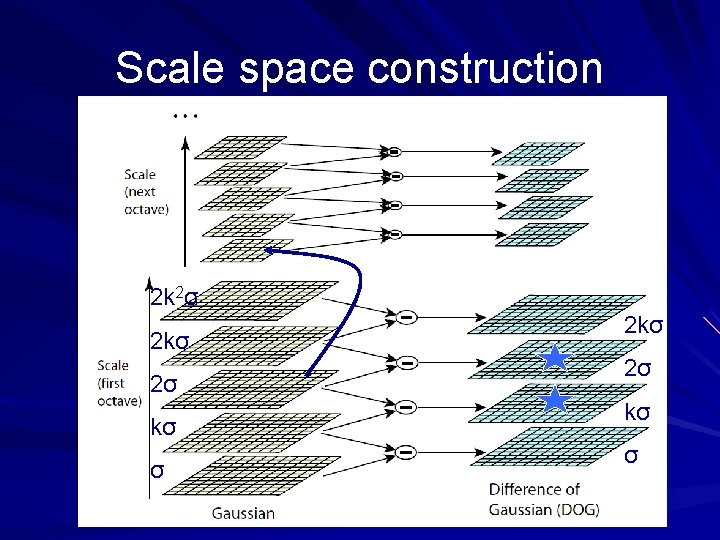
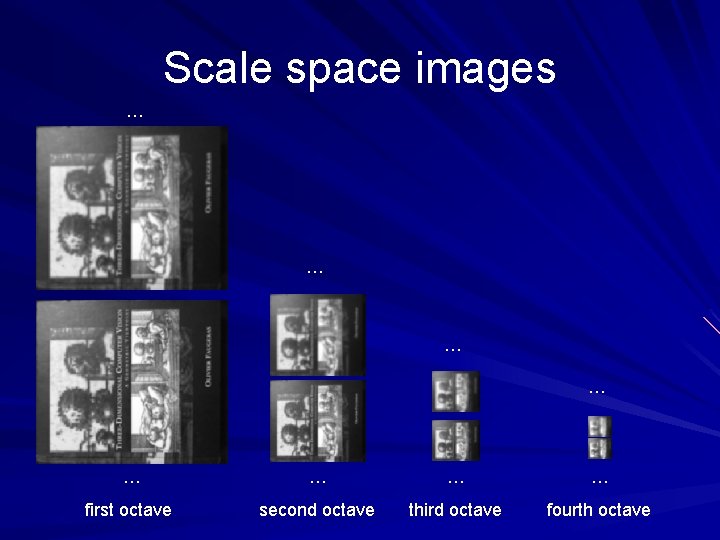
Scale space construction 2 k 2σ 2 kσ 2σ kσ σ
Scale space images … … … … first octave second octave third octave fourth octave
Difference-of-Gaussian images … … … … first octave second octave third octave fourth octave
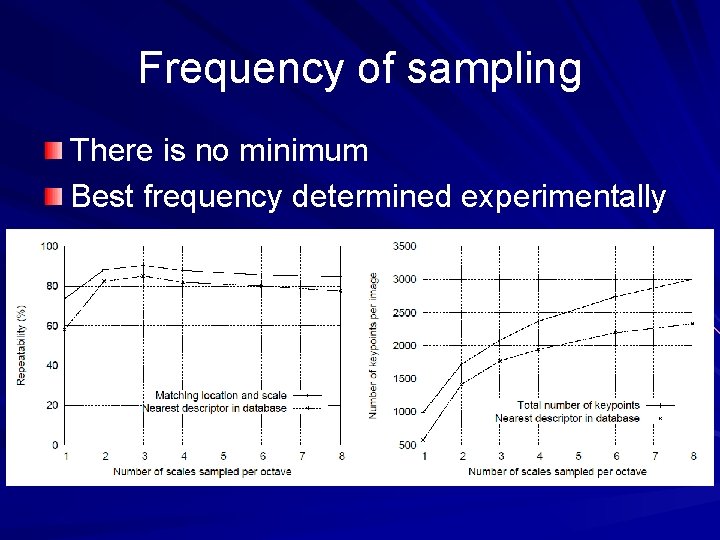
Frequency of sampling There is no minimum Best frequency determined experimentally
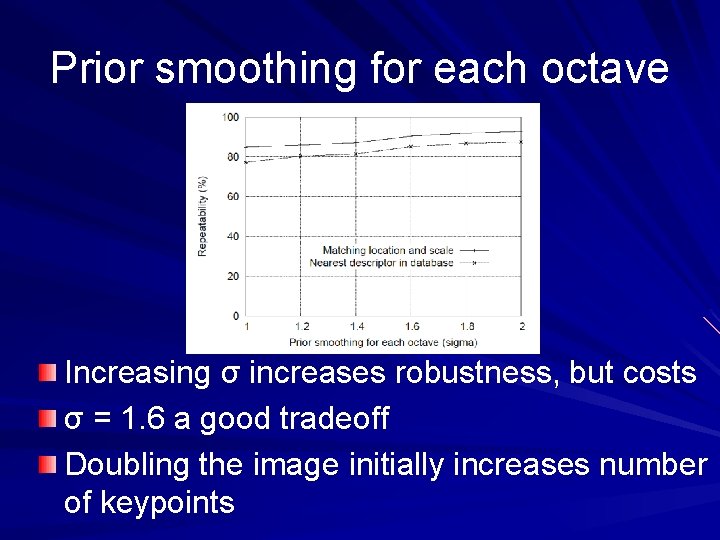
Prior smoothing for each octave Increasing σ increases robustness, but costs σ = 1. 6 a good tradeoff Doubling the image initially increases number of keypoints
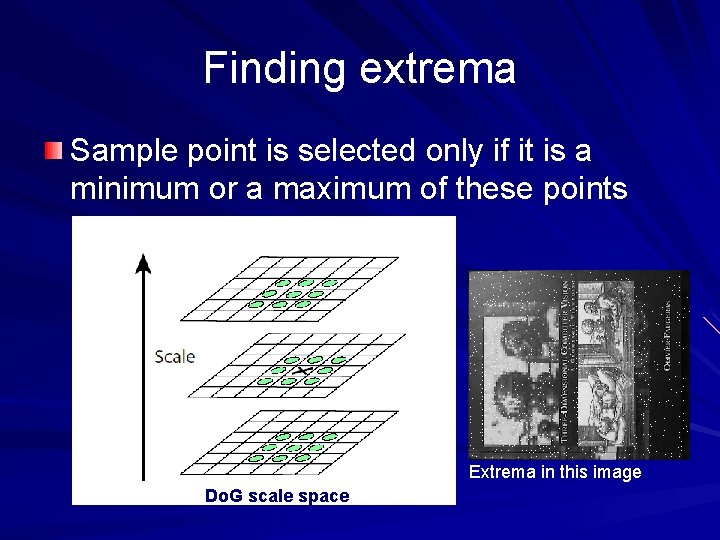
Finding extrema Sample point is selected only if it is a minimum or a maximum of these points Extrema in this image Do. G scale space
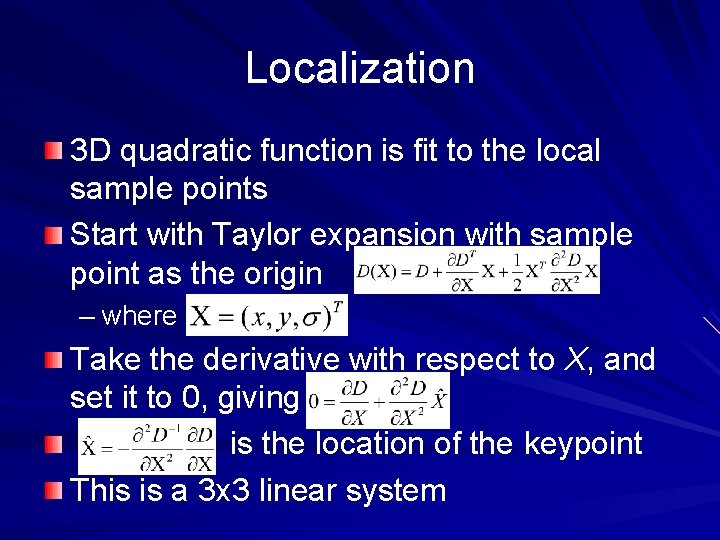
Localization 3 D quadratic function is fit to the local sample points Start with Taylor expansion with sample point as the origin – where Take the derivative with respect to X, and set it to 0, giving is the location of the keypoint This is a 3 x 3 linear system
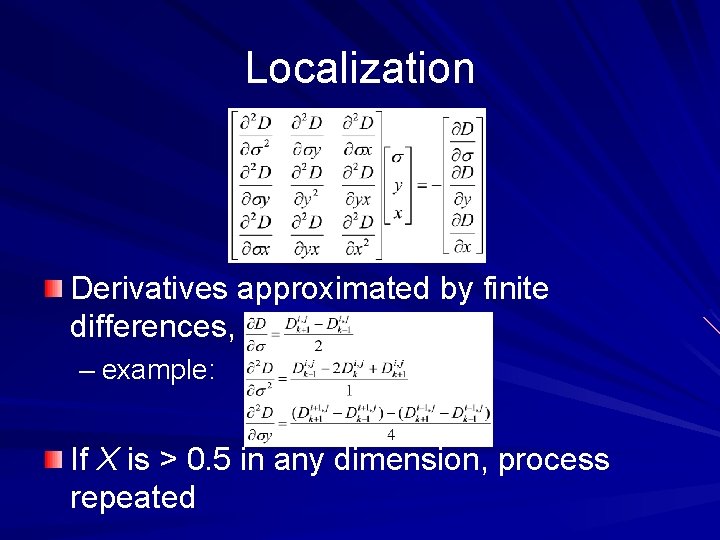
Localization Derivatives approximated by finite differences, – example: If X is > 0. 5 in any dimension, process repeated
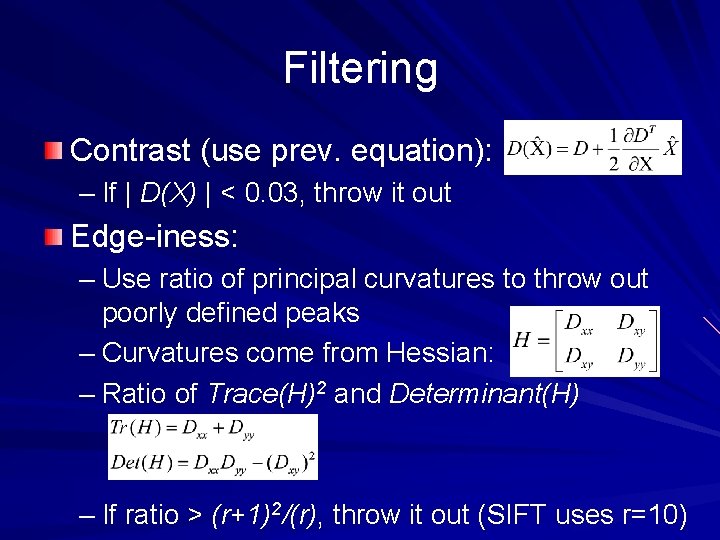
Filtering Contrast (use prev. equation): – If | D(X) | < 0. 03, throw it out Edge-iness: – Use ratio of principal curvatures to throw out poorly defined peaks – Curvatures come from Hessian: – Ratio of Trace(H)2 and Determinant(H) – If ratio > (r+1)2/(r), throw it out (SIFT uses r=10)
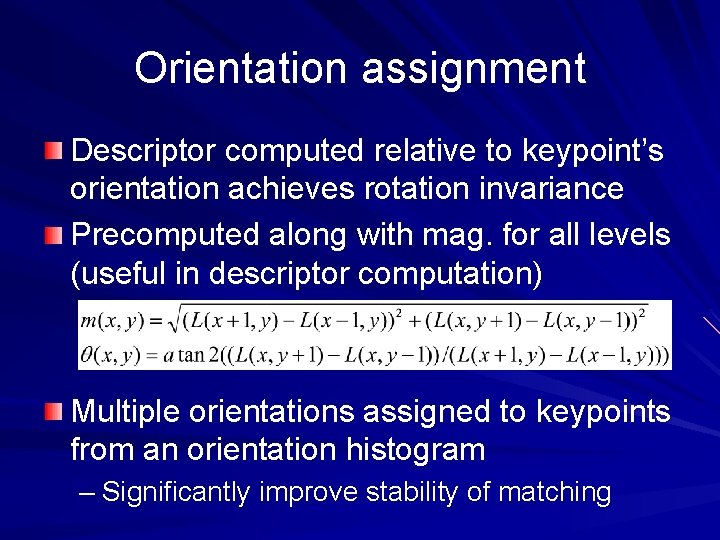
Orientation assignment Descriptor computed relative to keypoint’s orientation achieves rotation invariance Precomputed along with mag. for all levels (useful in descriptor computation) Multiple orientations assigned to keypoints from an orientation histogram – Significantly improve stability of matching
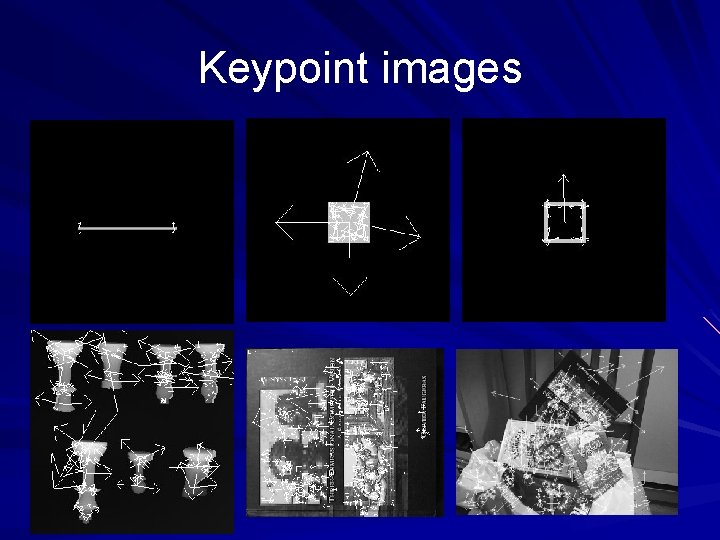
Keypoint images
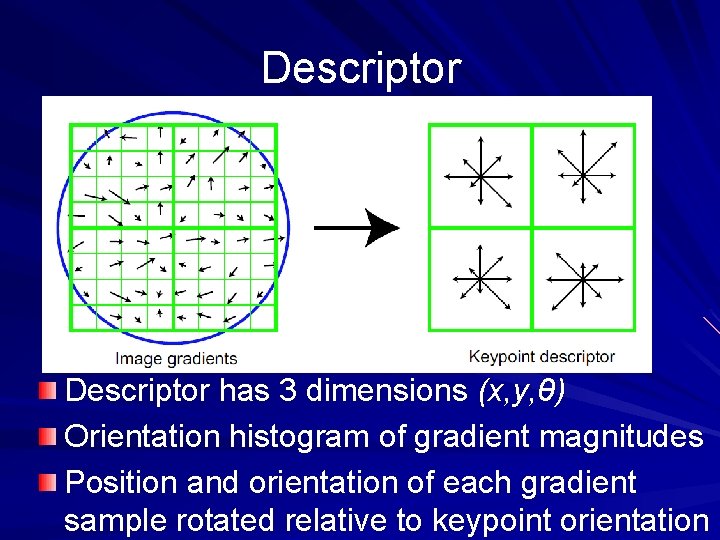
Descriptor has 3 dimensions (x, y, θ) Orientation histogram of gradient magnitudes Position and orientation of each gradient sample rotated relative to keypoint orientation
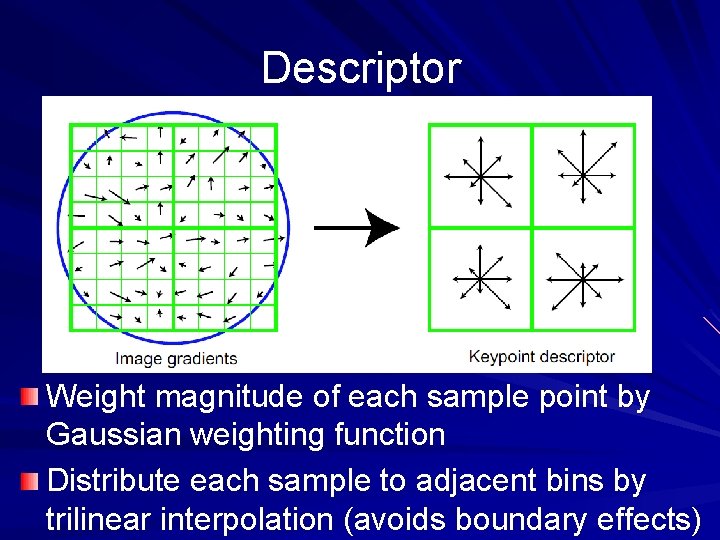
Descriptor Weight magnitude of each sample point by Gaussian weighting function Distribute each sample to adjacent bins by trilinear interpolation (avoids boundary effects)
Descriptor Best results achieved with 4 x 4 x 8 = 128 descriptor size Normalize to unit length – Reduces effect of illumination change Cap each element to 0. 2, normalize again – Reduces non-linear illumination changes – 0. 2 determined experimentally
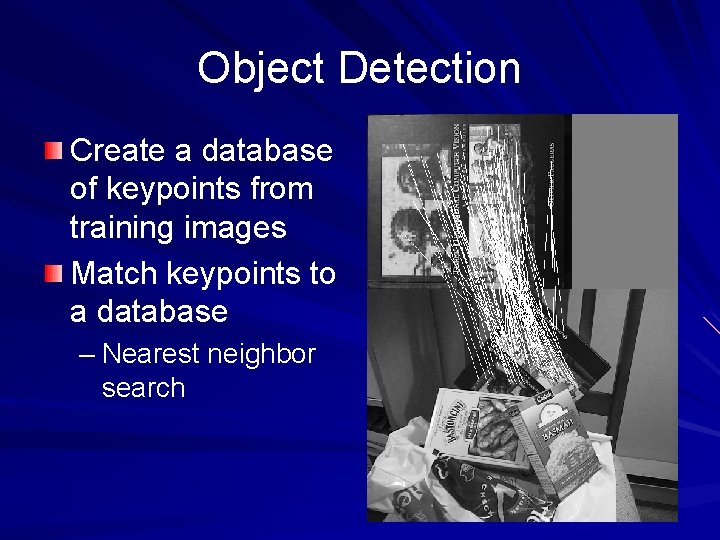
Object Detection Create a database of keypoints from training images Match keypoints to a database – Nearest neighbor search
PCA-SIFT Different descriptor (same keypoints) Apply PCA to the gradient patch Descriptor size is 20 (instead of 128) More robust, faster
Summary Scale space Difference-of-Gaussian Localization Filtering Orientation assignment Descriptor, 128 elements