
Samplingbased MP for Defending the Flag MEAM 620
Sampling-based MP for “Defending the Flag” MEAM 620 Project Gilad Buchman MEAM 620 Gilad Buchman
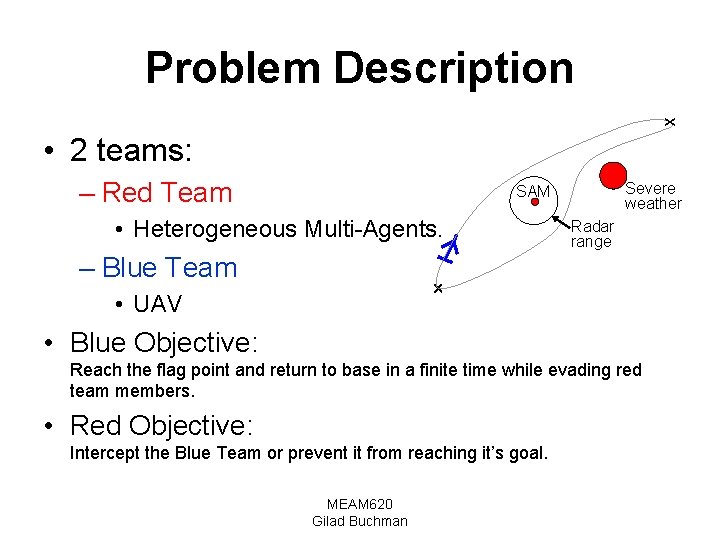
Problem Description x • 2 teams: – Red Team Severe weather SAM • Heterogeneous Multi-Agents. – Blue Team Radar range • UAV • Blue Objective: Reach the flag point and return to base in a finite time while evading red team members. • Red Objective: Intercept the Blue Team or prevent it from reaching it’s goal. MEAM 620 Gilad Buchman
Motion Planning problem • Trajectories and States – Blue Team trajectory Xb(t) – Red Team trajectory Xr(t) • Unsafe Region for Blue Team – g(Xb(t), Xr(t)) ≤ 0 • Find Xr(t) such that: – g(Xb(t), Xr(t)) ≤ 0 MEAM 620 Gilad Buchman
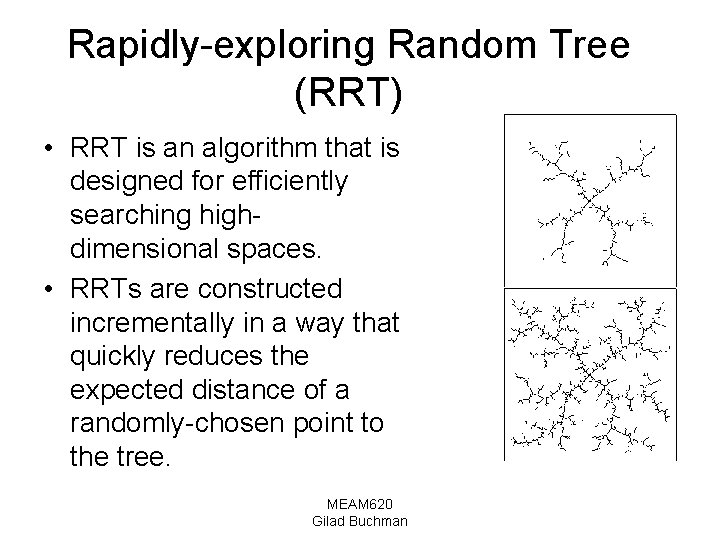
Rapidly-exploring Random Tree (RRT) • RRT is an algorithm that is designed for efficiently searching highdimensional spaces. • RRTs are constructed incrementally in a way that quickly reduces the expected distance of a randomly-chosen point to the tree. MEAM 620 Gilad Buchman
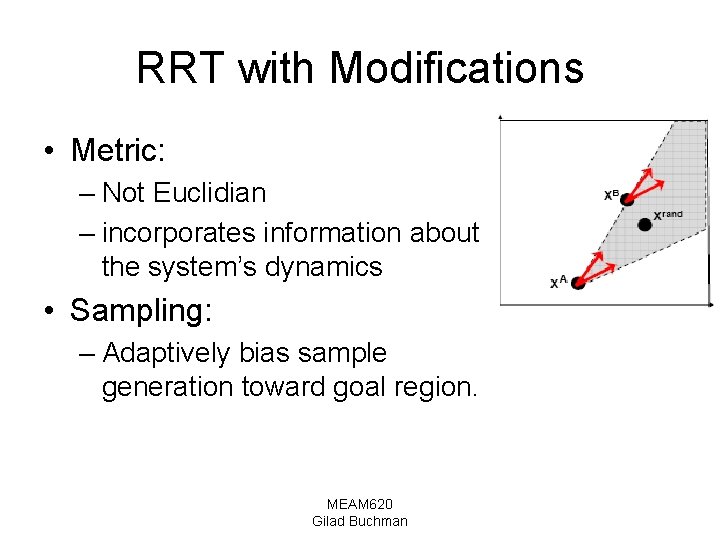
RRT with Modifications • Metric: – Not Euclidian – incorporates information about the system’s dynamics • Sampling: – Adaptively bias sample generation toward goal region. MEAM 620 Gilad Buchman
Multi agents collaboration • One state for all – Emerging Collaboration – Special metrics to keep agents apart • Specific state per agent – Higher-level coordinator assign specific metric, goal region. MEAM 620 Gilad Buchman
Summary • Use Modified RRT for collaborative motion planning of multi-agents with a dynamic objective • Part of a work with Vijay Kumar, Peng Cheng and Jongwoo Kim on the Popper project. • References: – Jongwoo Kim, Joel M. Esposito, and Vijay Kumar, "An RRTbased Algorithm for Testing and Validating Multi-Robot Controllers, " Robotics: Science and Systems, Cambridge, MA, June 2005. (pdf) – The Rapidly-Exploring Random Tree (RRT) Page – Popper - Sampling-based Verification and Falsification for Unmanned Vehicles. MEAM 620 Gilad Buchman
- Slides: 7