
Robotic Needle End Effector for Integration with CT
Robotic Needle End Effector for Integration with CT Scan Team Members: David Sun Xuan Truong Chris Willingham Advisor: Dr. Bradford Wood
CT Fluoroscopy Advantages n Disadvantages Ø Real time Ø Radiation Ø Faster - 2 m. Gy/procedure Ø Guidance for - annual limit 500 interventional procedures Ø Better success rate
Robotic System Radiation exposure reduced n Greater precision and accuracy n Lack tremor n No direct contact with patient n
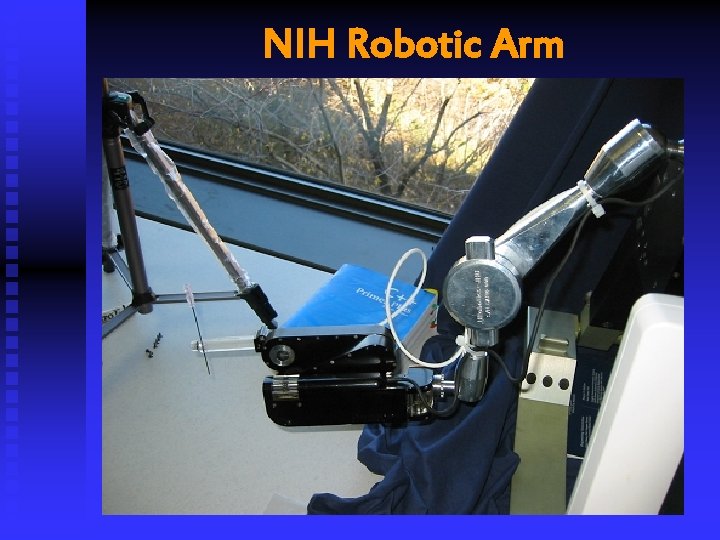
NIH Robotic Arm
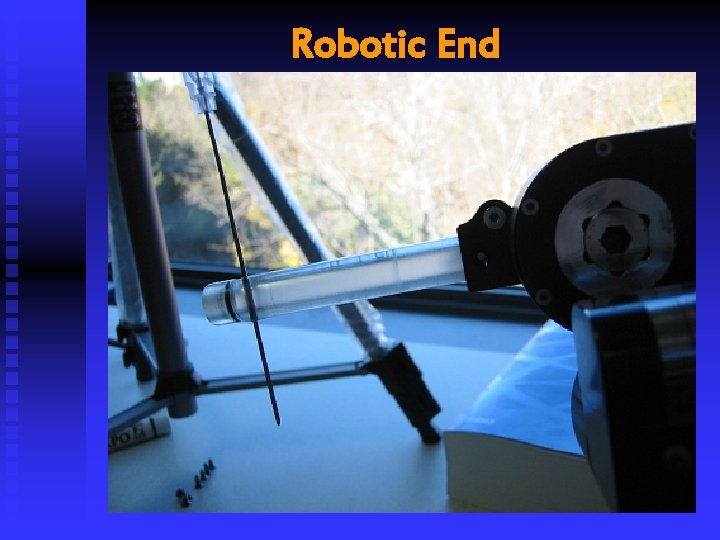
Robotic End
Objectives Design an end-effector Ø Degrees of freedom n Needle driver Ø Different needle gauges Ø Rapid unlock Ø Relocation n
Problems Primary—respiratory movement Variable grips Multiple needle attachment at a common interface Degrees of freedom Rapid release of the needle driver Visualization of the insertion point Electrical interface of the needle driver with the robotic arm
Possible Solutions Potential for a feedback control system Modification of current heart stabilizers Variable grip driver Design of a single interface CAD interface Pneumatic gripper from Kawasaki Infrared camera in close proximity to needle driver
Market Potential Improve surgical procedures (article from Computer Aided Surgery) Increased cost efficiency Safety concerns addressed by prototype construction & testing Effectiveness of the system improved by building on current design Rapidly advancing An end arm effector that addresses all these concerns is likely to be effectively marketed as the field advances
Progress Made Discussed goals with Dr. Wood n Completed NCIIA proposal n Obtained information & images n Contacted Dr. Lee Gorden & Dr. Ron Price n
Current Status Researching and brainstorming n Investigating potential materials n Reviewing surgical robots n Learning and Installing Solidedge n Scheduling, requirement definition, work breakdown assignment n
Future Work Conference call with Dr. Wood n Set up an appointment with a VU surgeon n Conduct a patent search n Continue researching possible solutions n Begin designing prototype n
References Robotically Drive Intervention: A method of Using CT Fluoroscopy without Radiation Exposure to the Physician. Radiology 2002. Volume 225 -Number 1. Acu. Bot: A Robot for Radiological Interventions. IEEE-TR&A. State of the Art in Surgical Robotics: Clinical Applications and Technology Challenges. Computer Aided Surgery, August 2001.
Contact David Sun david. d. sun@vanderbilt. edu n Xuan Truong xuan. t. truong@vanderbilt. edu n Chris Willingham jc. willin@vanderbilt. edu n
- Slides: 14