
Robocup Junior Rescue Maze Hardware BY Alex Lisenko
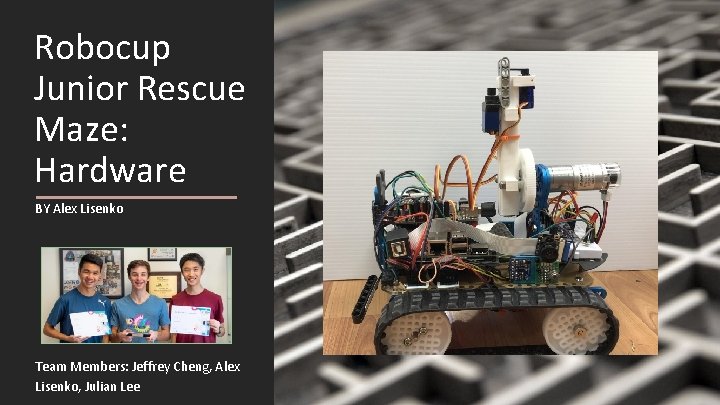
Robocup Junior Rescue Maze: Hardware BY Alex Lisenko Team Members: Jeffrey Cheng, Alex Lisenko, Julian Lee
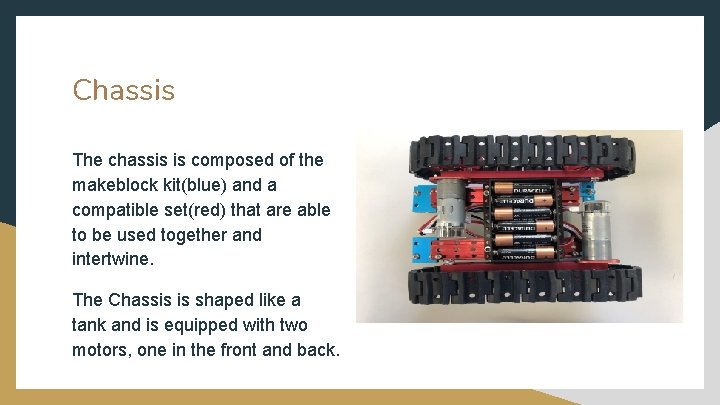
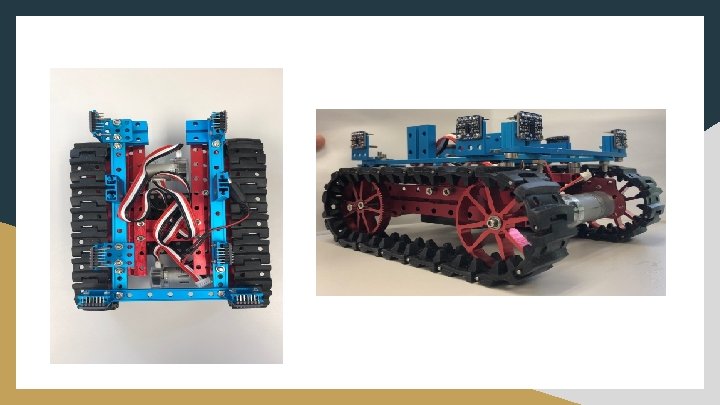
Chassis The chassis is composed of the makeblock kit(blue) and a compatible set(red) that are able to be used together and intertwine. The Chassis is shaped like a tank and is equipped with two motors, one in the front and back.
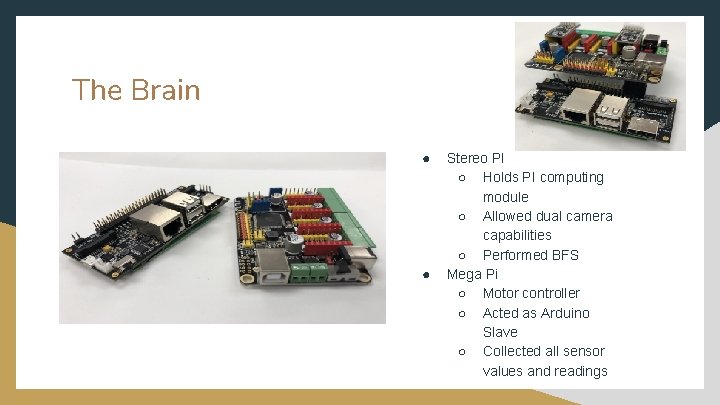
The Brain ● ● Stereo PI ○ Holds PI computing module ○ Allowed dual camera capabilities ○ Performed BFS Mega Pi ○ Motor controller ○ Acted as Arduino Slave ○ Collected all sensor values and readings
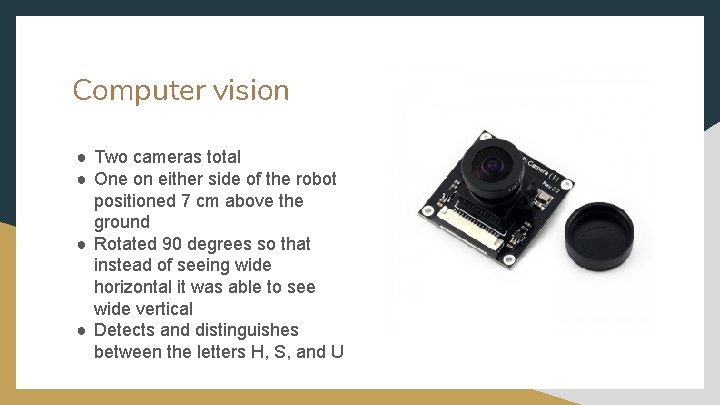
Computer vision ● Two cameras total ● One on either side of the robot positioned 7 cm above the ground ● Rotated 90 degrees so that instead of seeing wide horizontal it was able to see wide vertical ● Detects and distinguishes between the letters H, S, and U
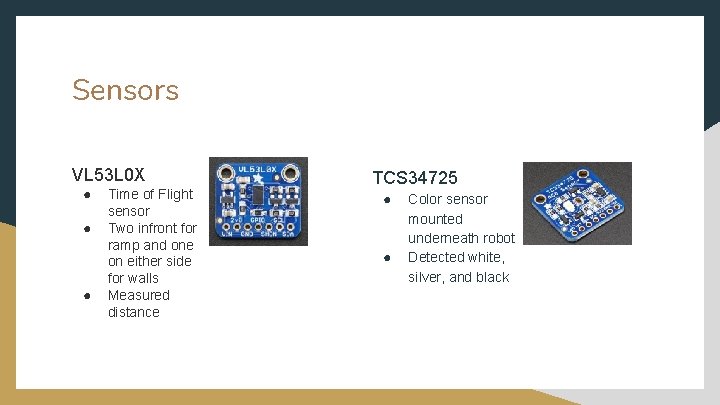
Sensors VL 53 L 0 X ● ● ● Time of Flight sensor Two infront for ramp and one on either side for walls Measured distance TCS 34725 ● ● Color sensor mounted underneath robot Detected white, silver, and black
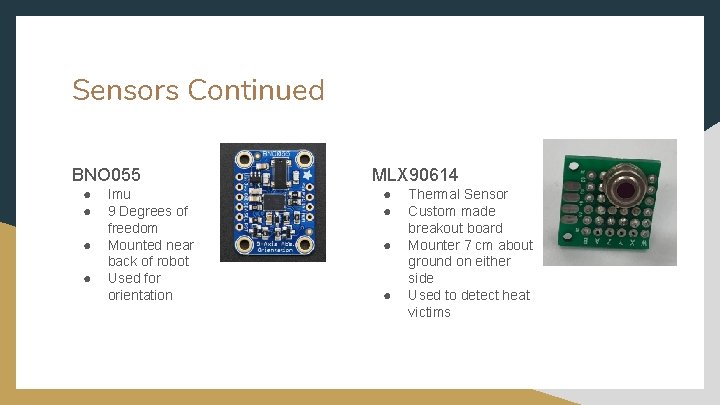
Sensors Continued BNO 055 ● ● Imu 9 Degrees of freedom Mounted near back of robot Used for orientation MLX 90614 ● ● Thermal Sensor Custom made breakout board Mounter 7 cm about ground on either side Used to detect heat victims
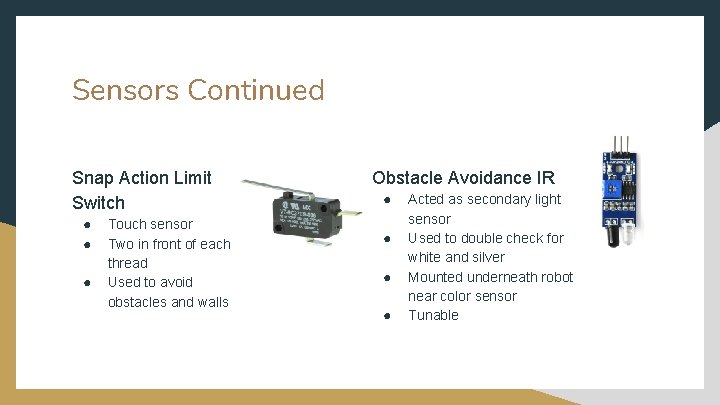
Sensors Continued Snap Action Limit Switch ● ● ● Touch sensor Two in front of each thread Used to avoid obstacles and walls Obstacle Avoidance IR ● ● Acted as secondary light sensor Used to double check for white and silver Mounted underneath robot near color sensor Tunable
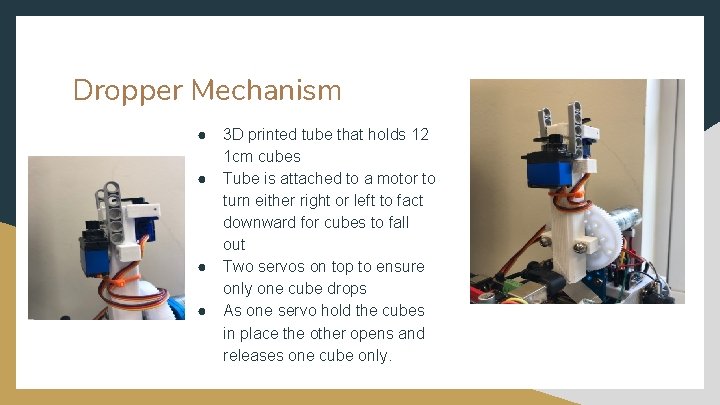
Dropper Mechanism ● ● 3 D printed tube that holds 12 1 cm cubes Tube is attached to a motor to turn either right or left to fact downward for cubes to fall out Two servos on top to ensure only one cube drops As one servo hold the cubes in place the other opens and releases one cube only.
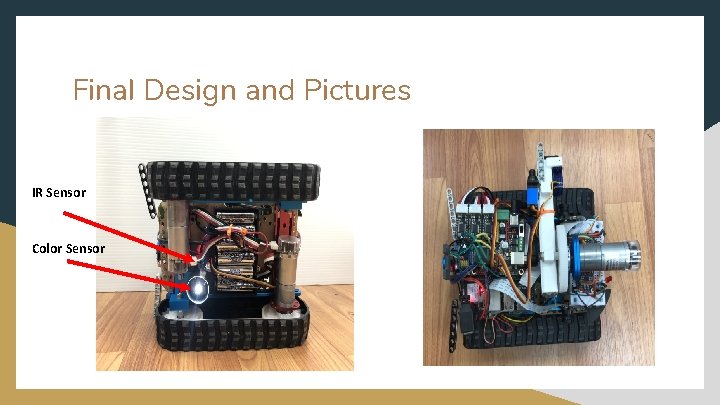
Final Design and Pictures IR Sensor Color Sensor
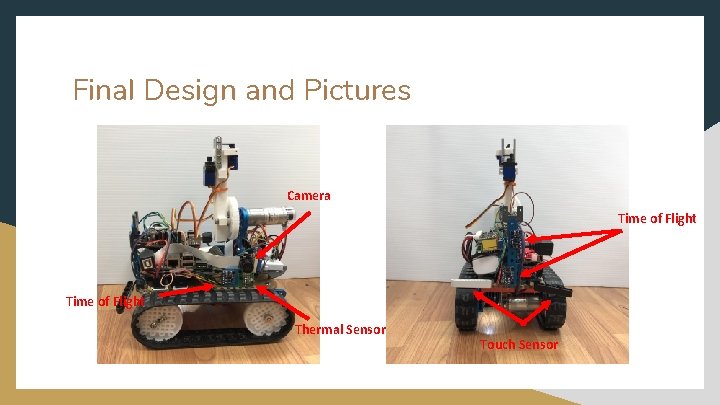
Final Design and Pictures Camera Time of Flight Thermal Sensor Touch Sensor
- Slides: 11