
Representation of scene motion Stefano Soatto UCLA S
- Slides: 17
Representation of scene motion Stefano Soatto, UCLA S. Soatto, UCLA
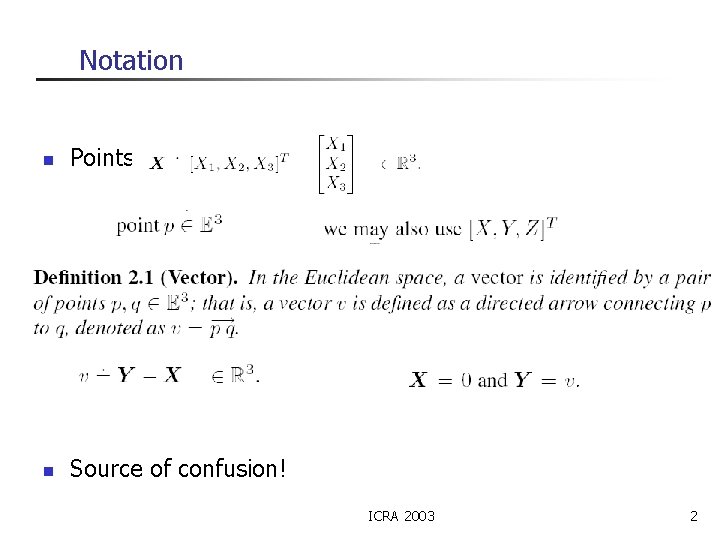
Notation n Points and vectors are different! n Source of confusion! ICRA 2003 2
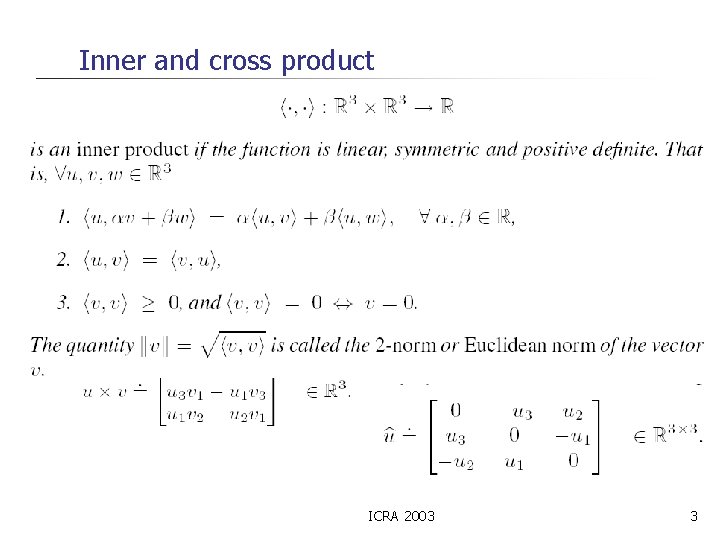
Inner and cross product ICRA 2003 3
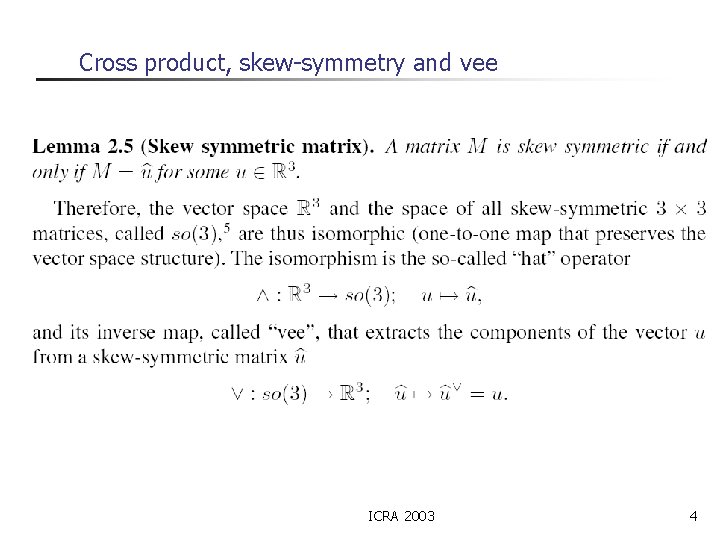
Cross product, skew-symmetry and vee ICRA 2003 4
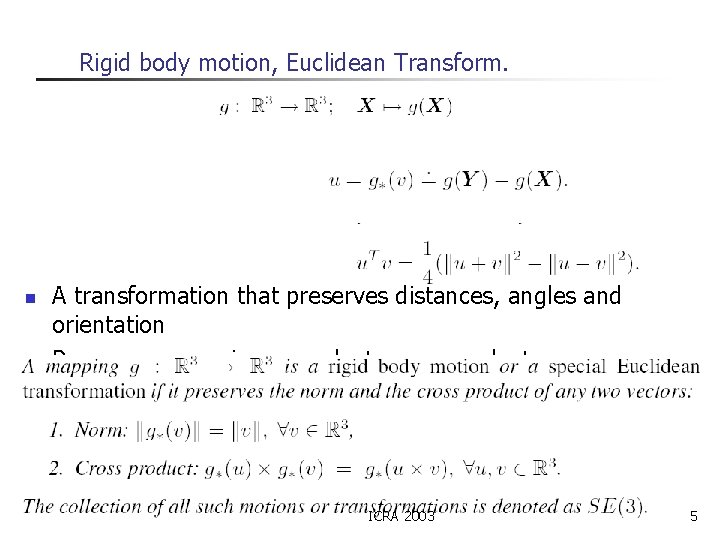
Rigid body motion, Euclidean Transform. n A transformation that preserves distances, angles and orientation Preserves norm, inner product, cross product Polarization identity n Preserve norm and cross product n n ICRA 2003 5
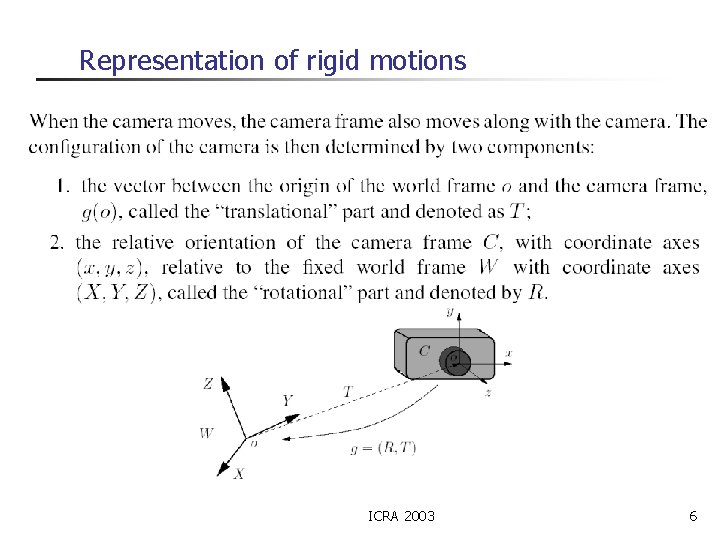
Representation of rigid motions ICRA 2003 6
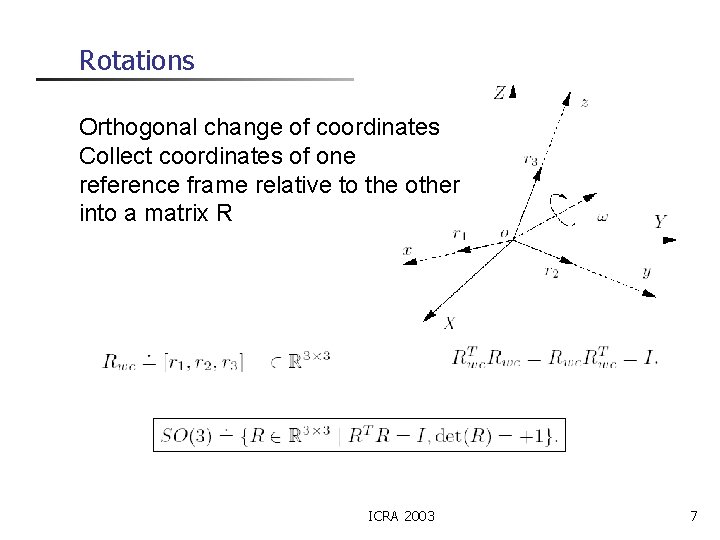
Rotations Orthogonal change of coordinates Collect coordinates of one reference frame relative to the other into a matrix R ICRA 2003 7
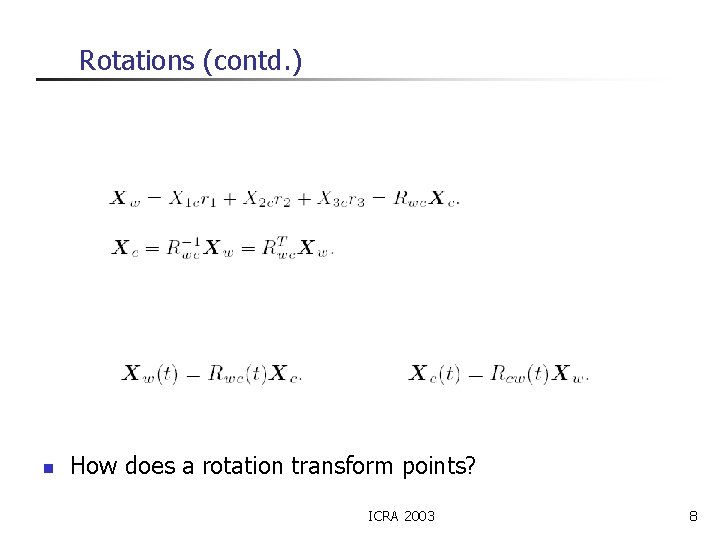
Rotations (contd. ) n How does a rotation transform points? ICRA 2003 8
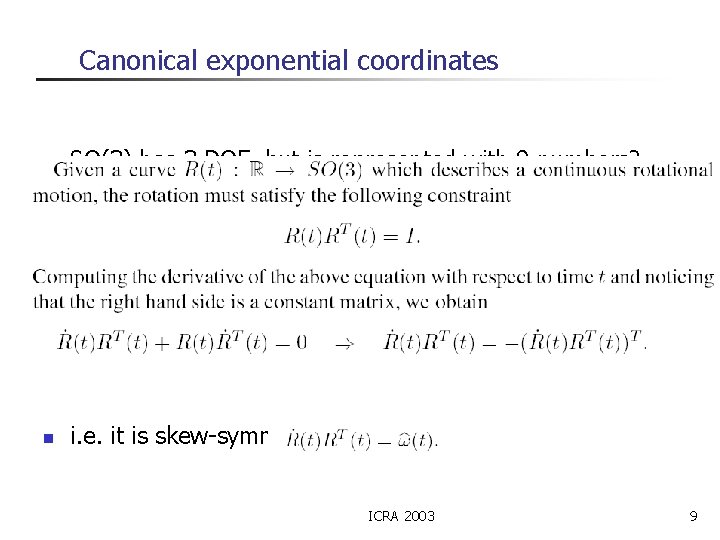
Canonical exponential coordinates n SO(3) has 3 DOF, but is represented with 9 numbers? n i. e. it is skew-symmetric! ICRA 2003 9
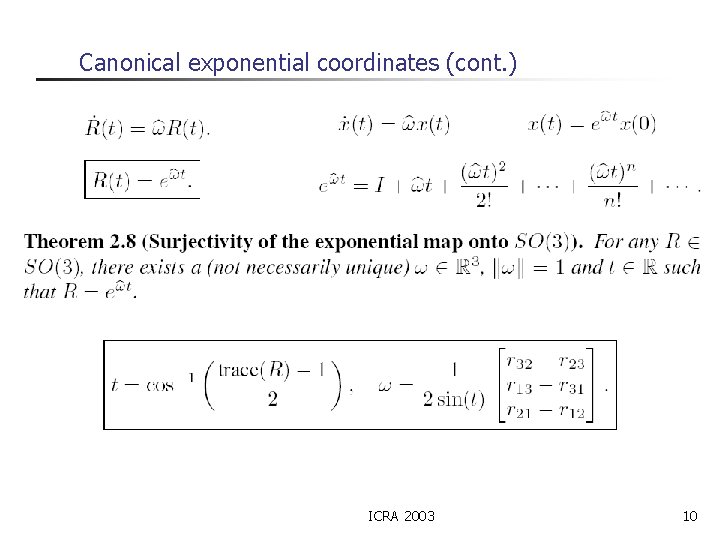
Canonical exponential coordinates (cont. ) ICRA 2003 10
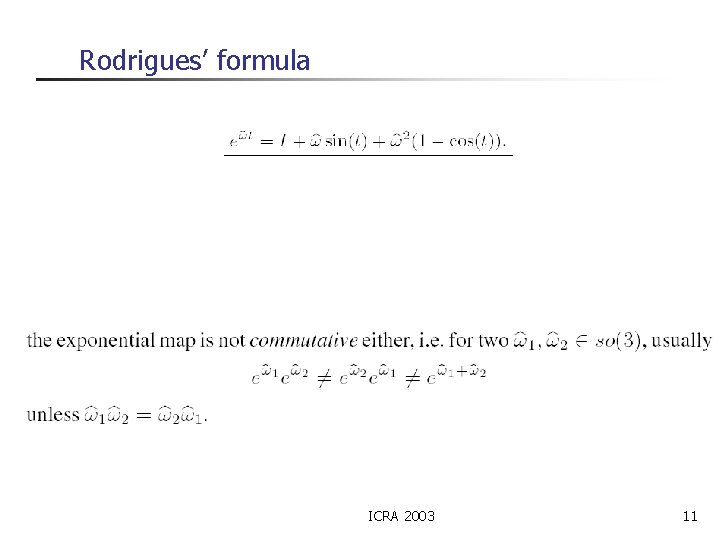
Rodrigues’ formula n n Beautiful! Toss Euler angles, Y-P-R, quaternions etc. ICRA 2003 11
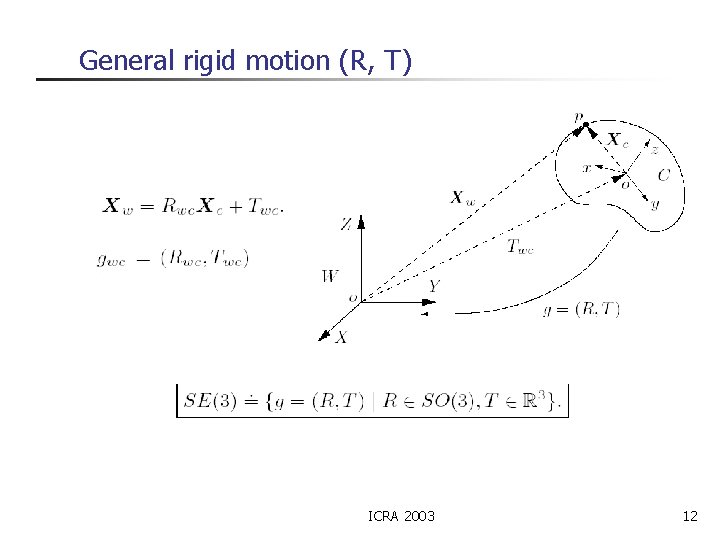
General rigid motion (R, T) ICRA 2003 12
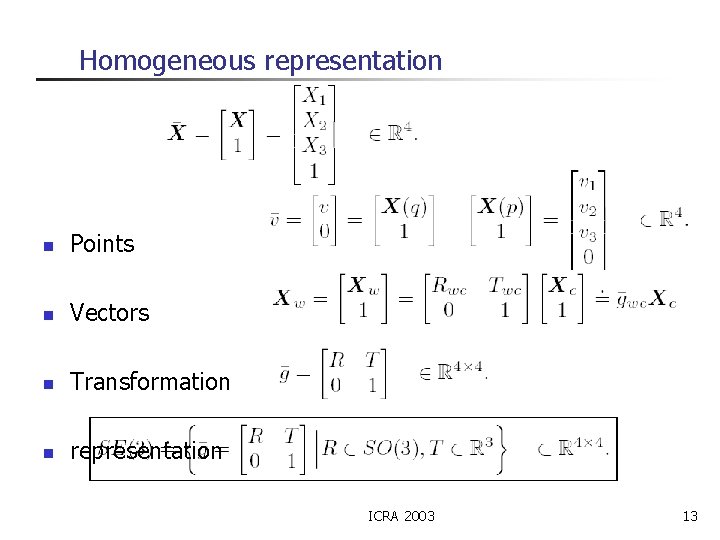
Homogeneous representation n Points n Vectors n Transformation n representation ICRA 2003 13
Questions: n n What is the action of a rigid body motion on a vector? What is the representation of the inverse action? ICRA 2003 14
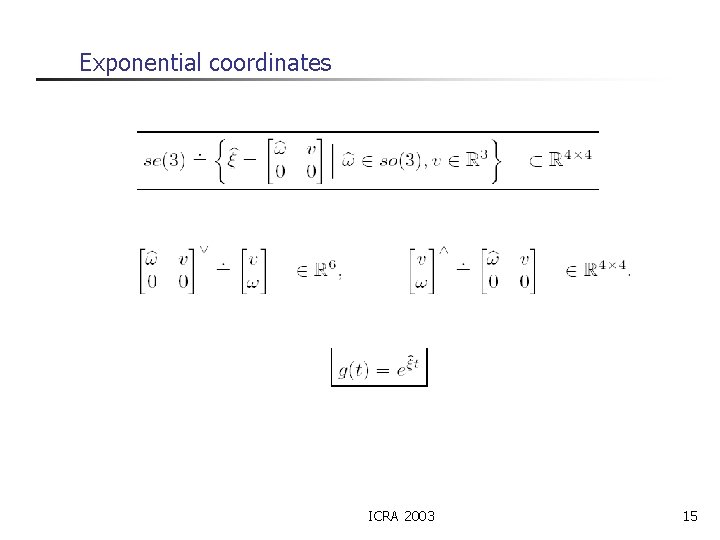
Exponential coordinates ICRA 2003 15
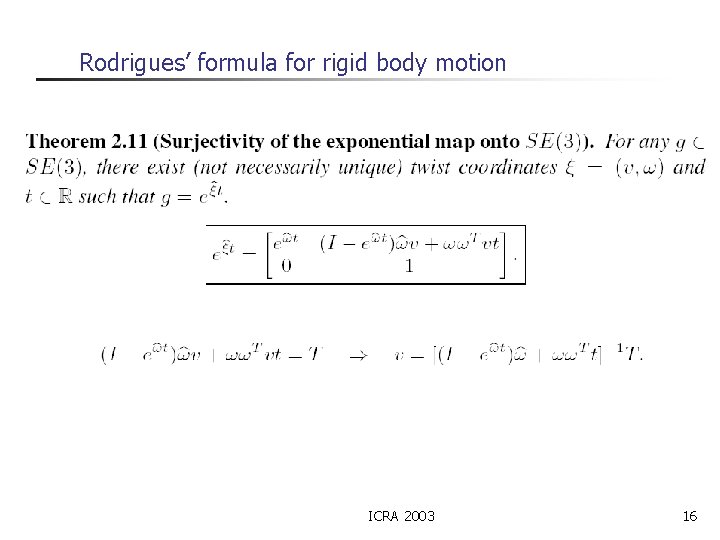
Rodrigues’ formula for rigid body motion ICRA 2003 16
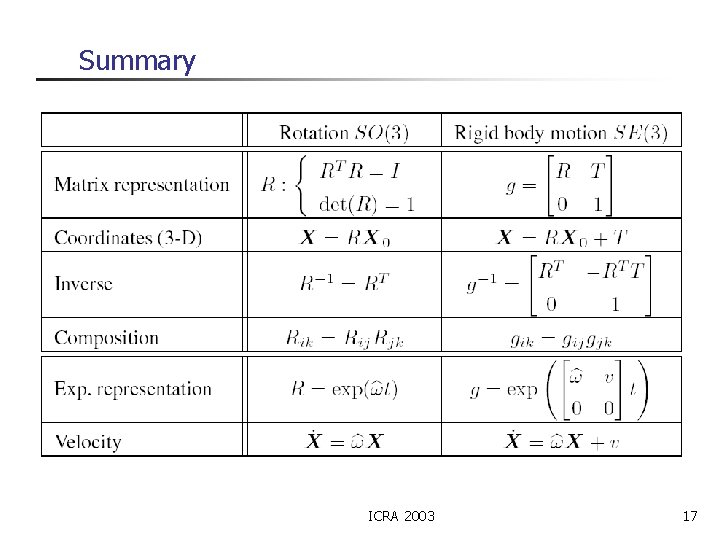
Summary ICRA 2003 17