
Quaternions and Complex Numbers Dr Scott Schaefer 1
Quaternions and Complex Numbers Dr. Scott Schaefer 1
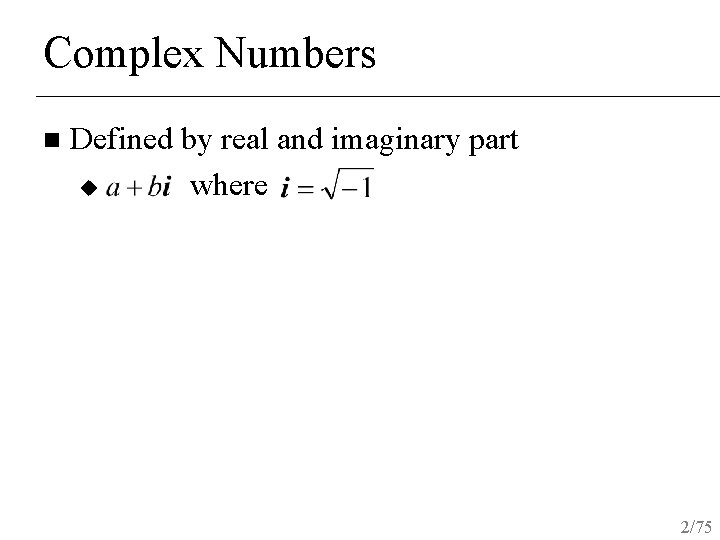
Complex Numbers n Defined by real and imaginary part u where 2/75
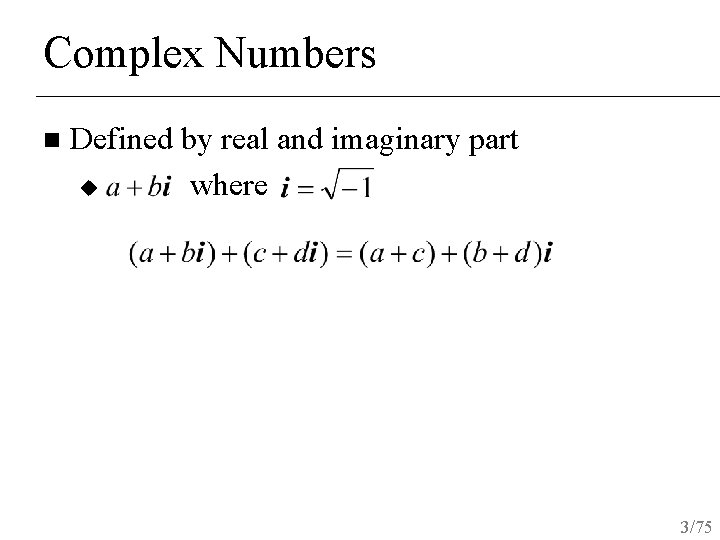
Complex Numbers n Defined by real and imaginary part u where 3/75
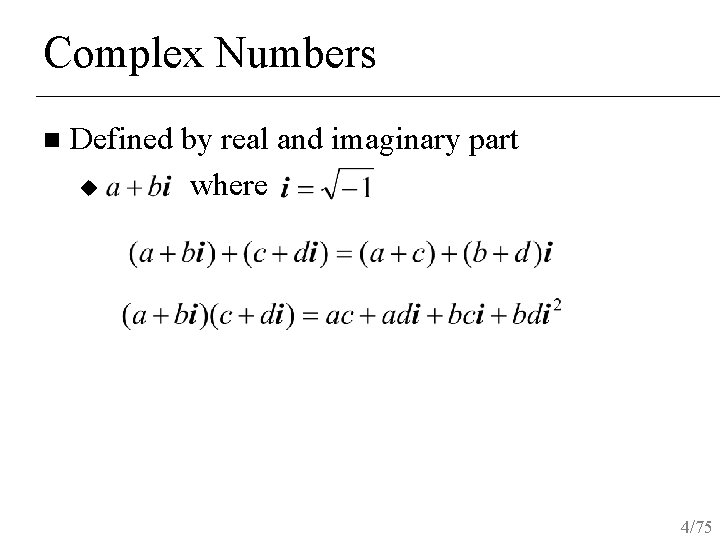
Complex Numbers n Defined by real and imaginary part u where 4/75
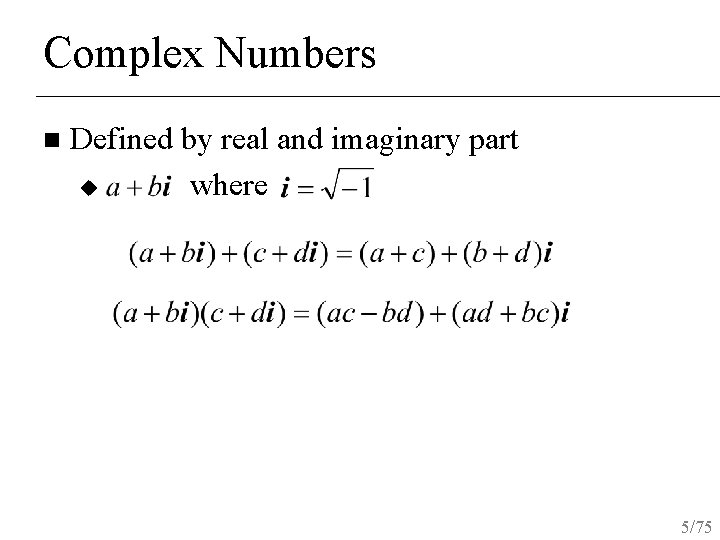
Complex Numbers n Defined by real and imaginary part u where 5/75
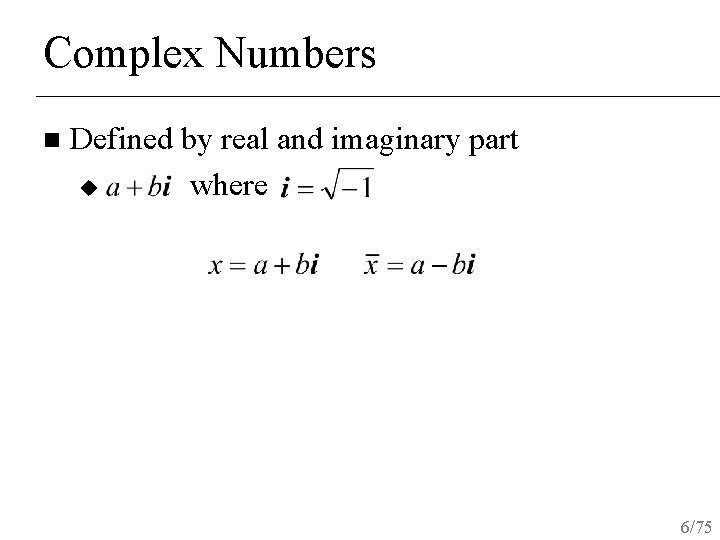
Complex Numbers n Defined by real and imaginary part u where 6/75
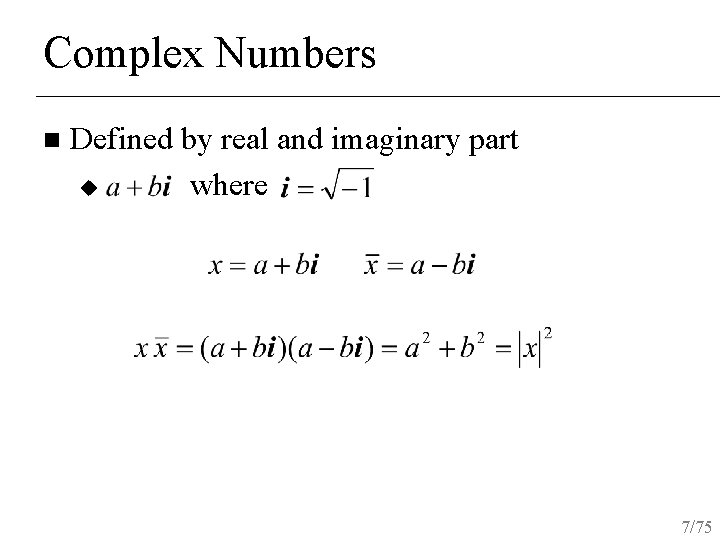
Complex Numbers n Defined by real and imaginary part u where 7/75
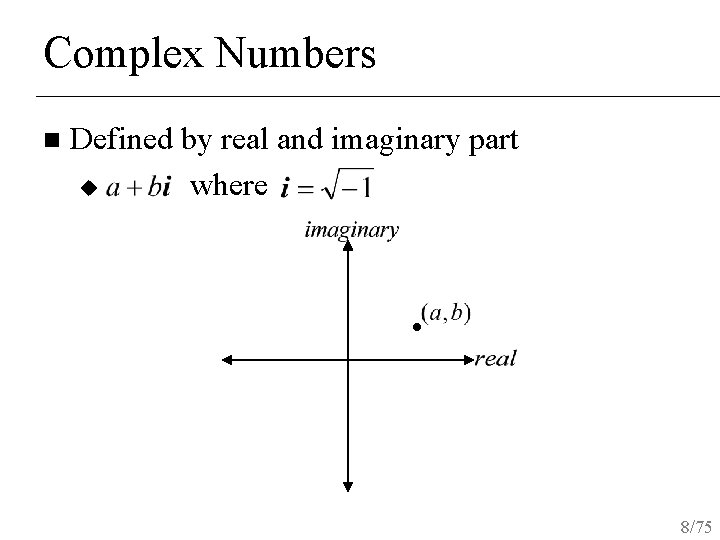
Complex Numbers n Defined by real and imaginary part u where 8/75
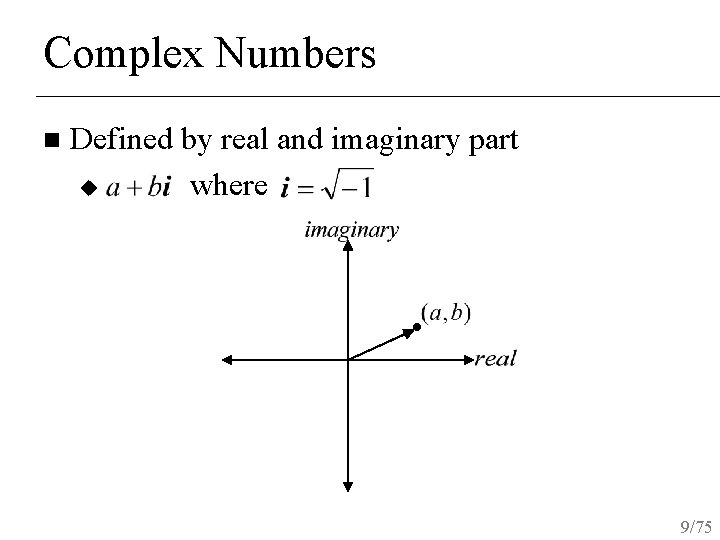
Complex Numbers n Defined by real and imaginary part u where 9/75
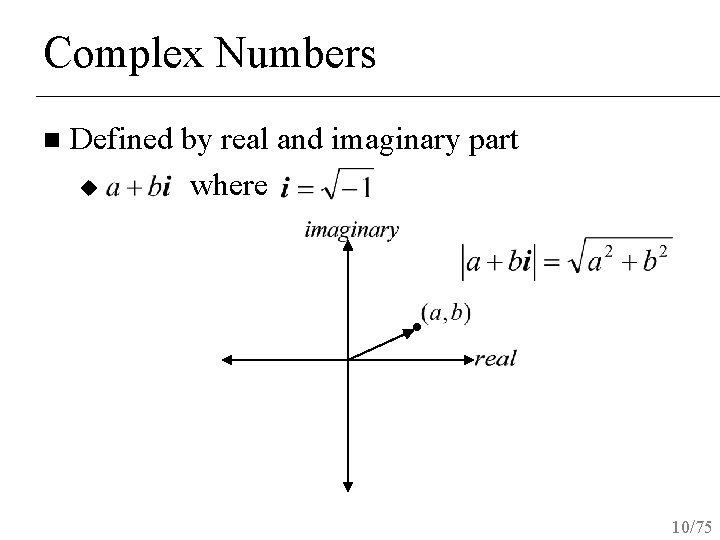
Complex Numbers n Defined by real and imaginary part u where 10/75
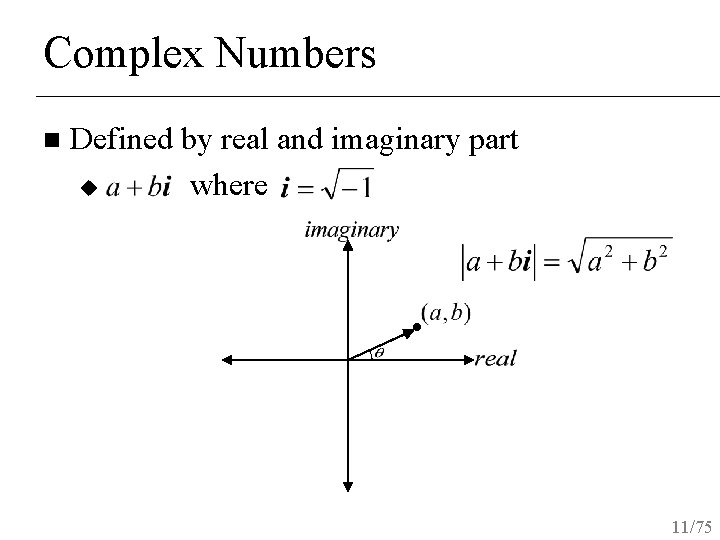
Complex Numbers n Defined by real and imaginary part u where 11/75
Complex Numbers and Rotations n Given a point (x, y), rotate that point about the origin by 12/75
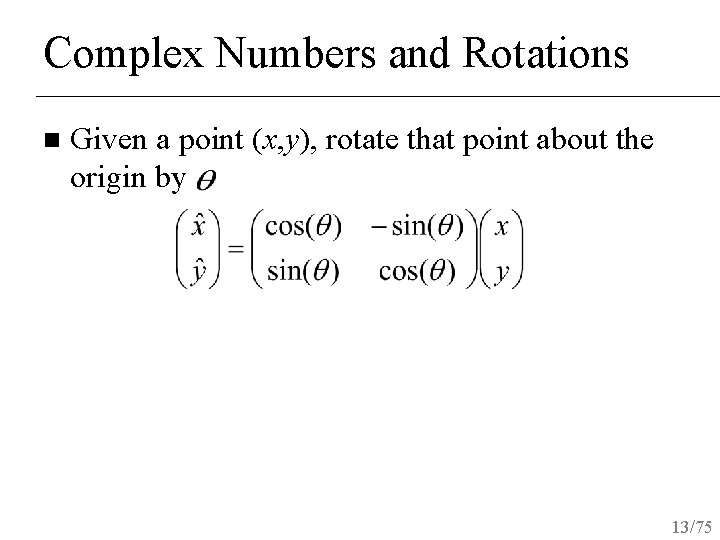
Complex Numbers and Rotations n Given a point (x, y), rotate that point about the origin by 13/75
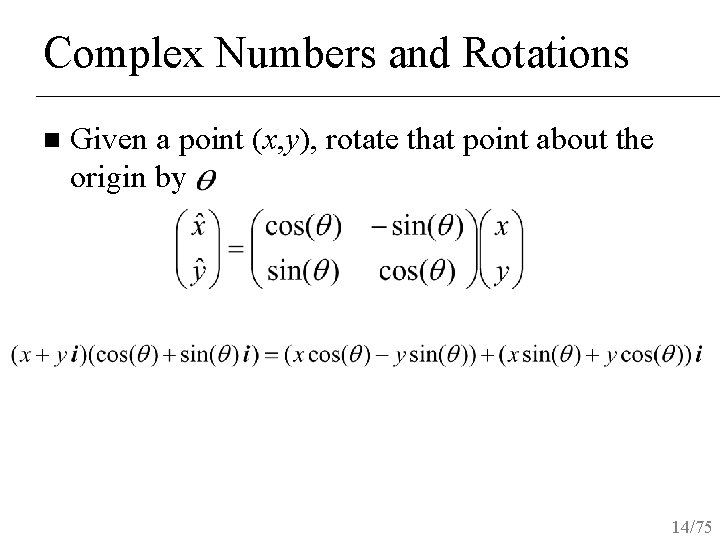
Complex Numbers and Rotations n Given a point (x, y), rotate that point about the origin by 14/75
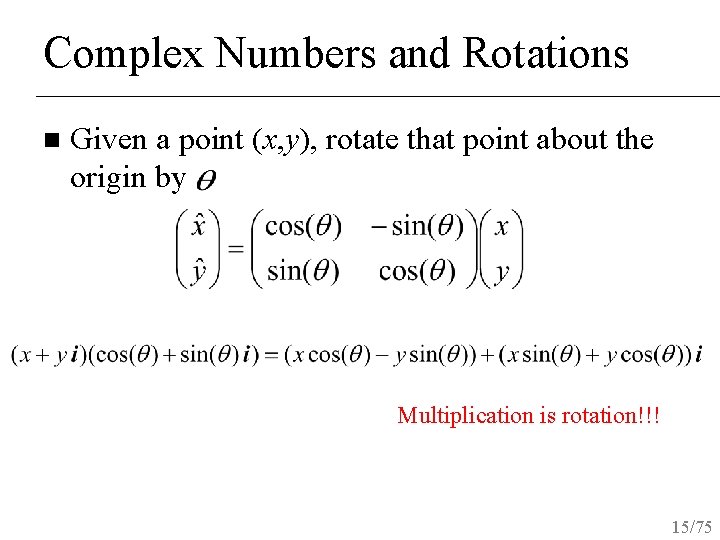
Complex Numbers and Rotations n Given a point (x, y), rotate that point about the origin by Multiplication is rotation!!! 15/75
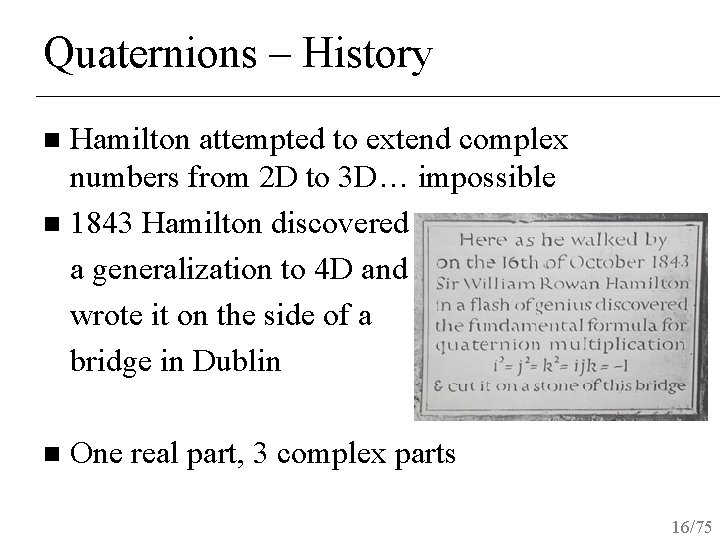
Quaternions – History Hamilton attempted to extend complex numbers from 2 D to 3 D… impossible n 1843 Hamilton discovered a generalization to 4 D and wrote it on the side of a bridge in Dublin n n One real part, 3 complex parts 16/75
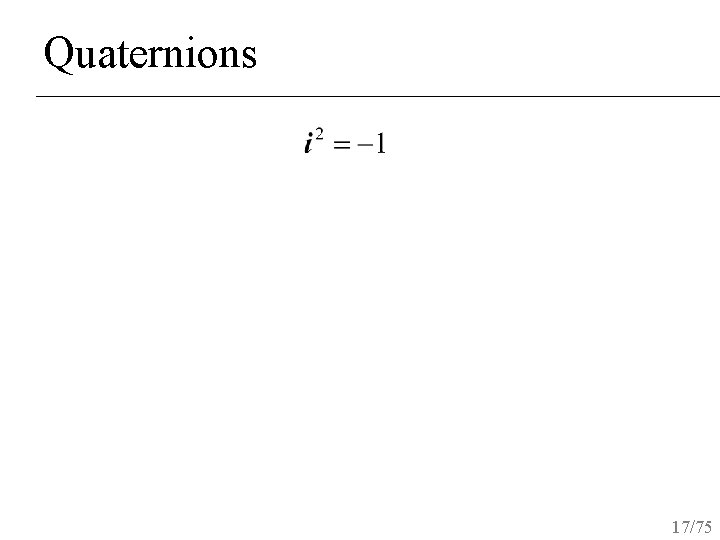
Quaternions 17/75
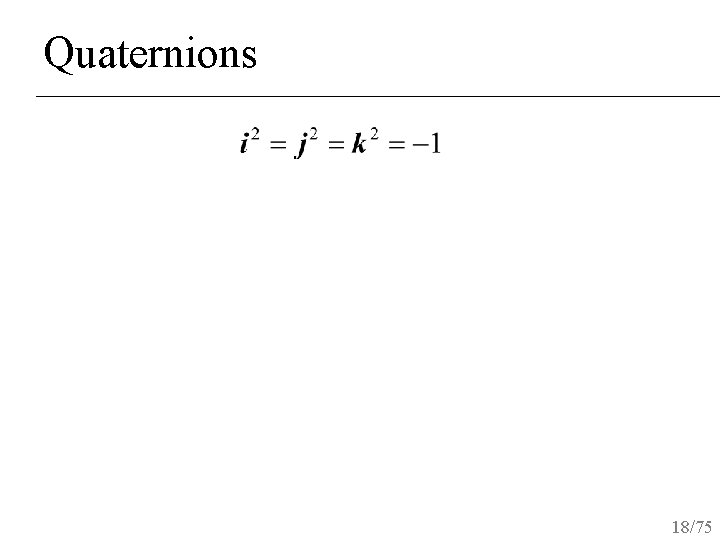
Quaternions 18/75
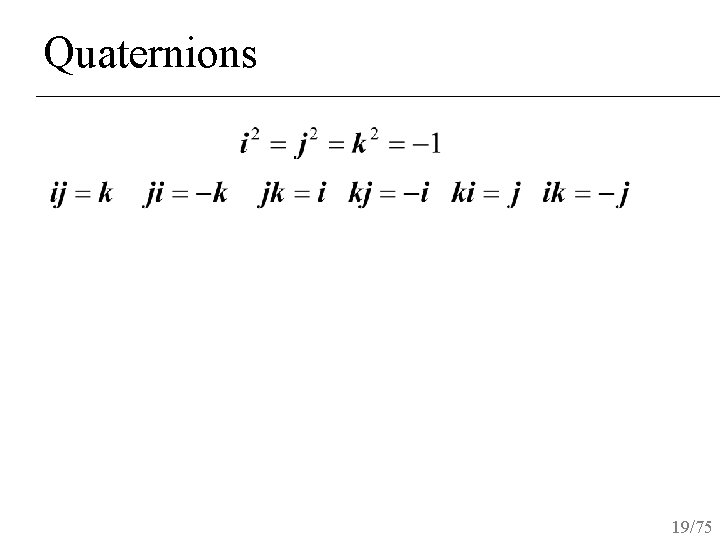
Quaternions 19/75
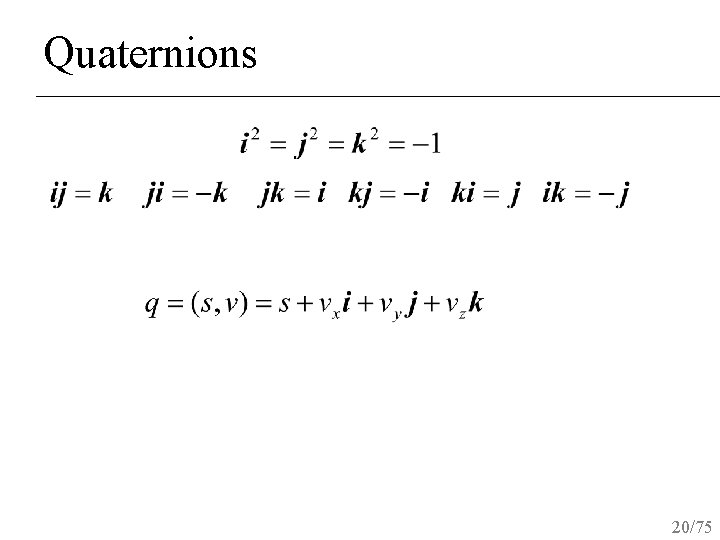
Quaternions 20/75

Quaternion Multiplication 21/75
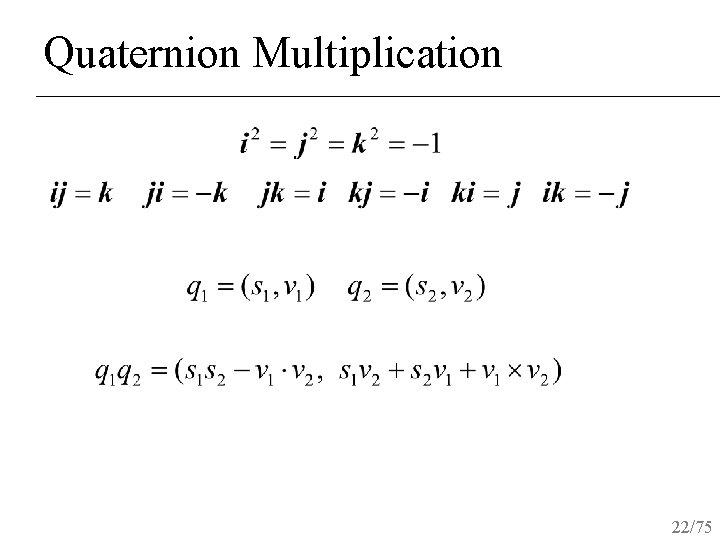
Quaternion Multiplication 22/75
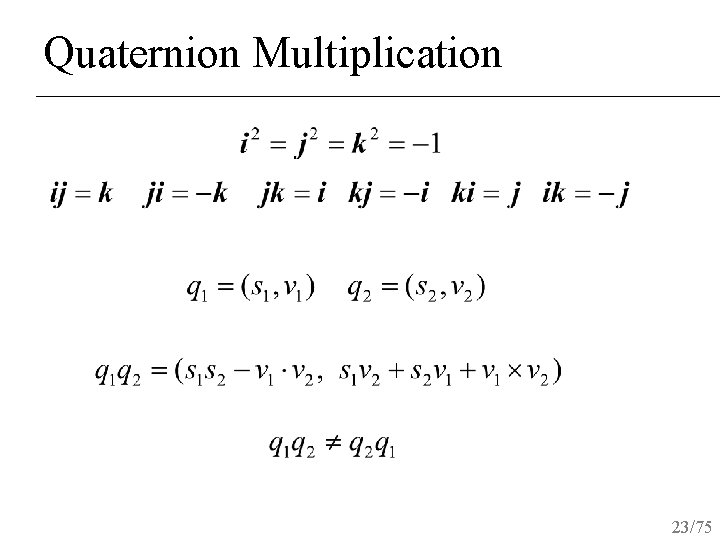
Quaternion Multiplication 23/75
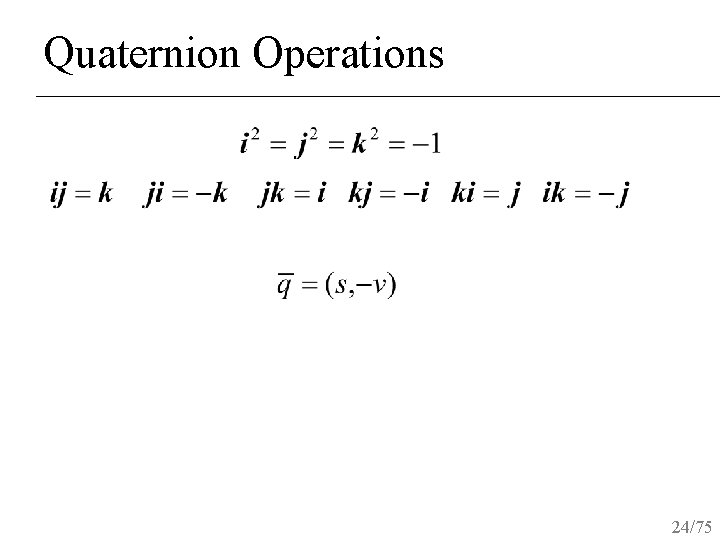
Quaternion Operations 24/75
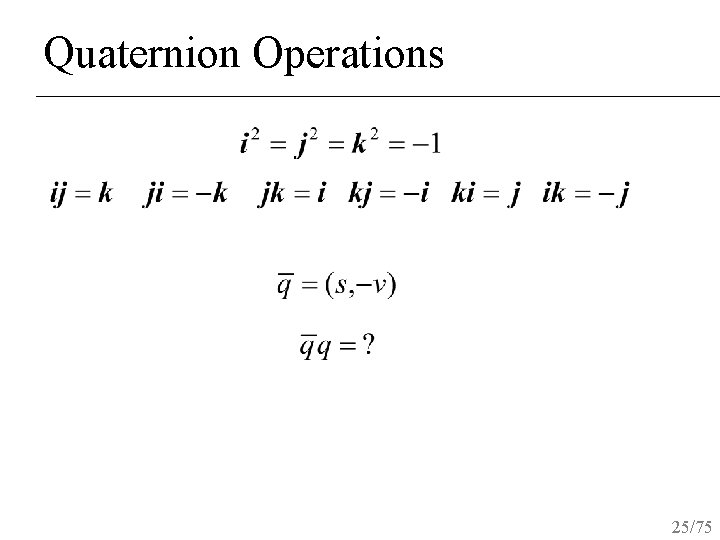
Quaternion Operations 25/75
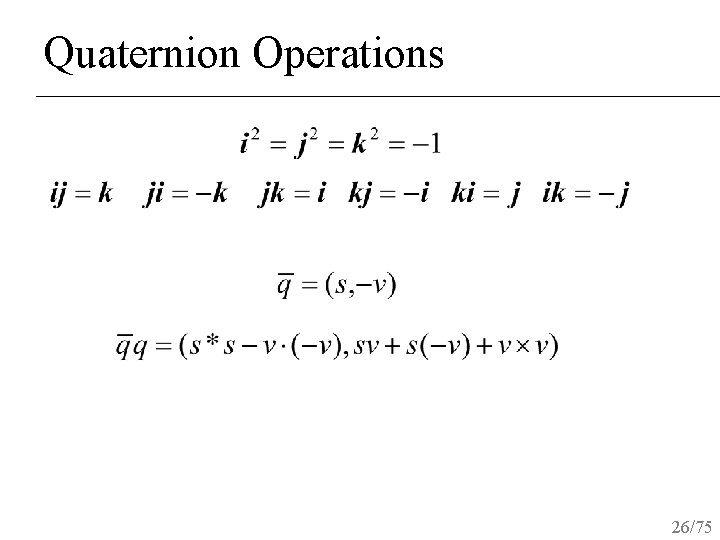
Quaternion Operations 26/75
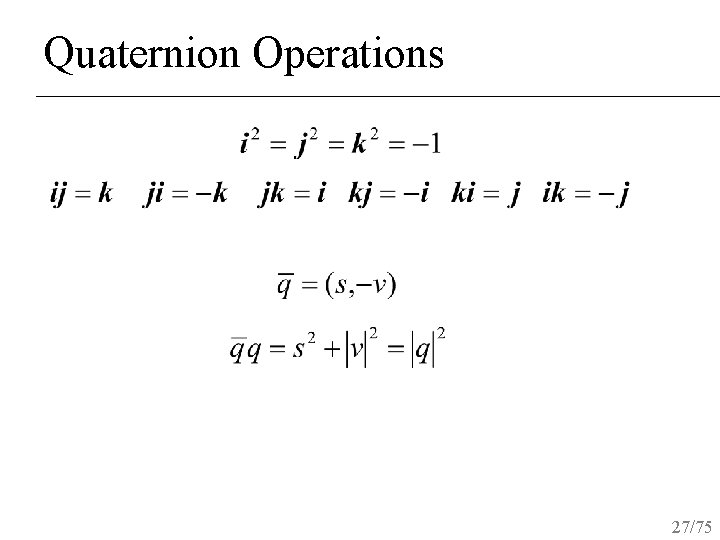
Quaternion Operations 27/75
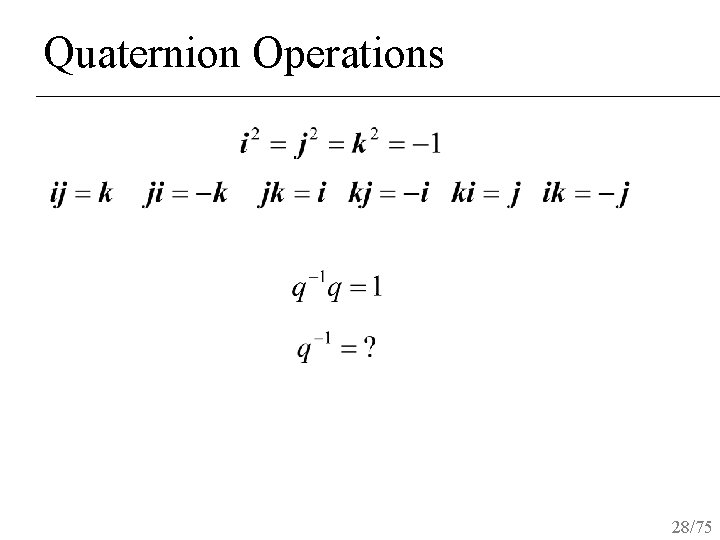
Quaternion Operations 28/75
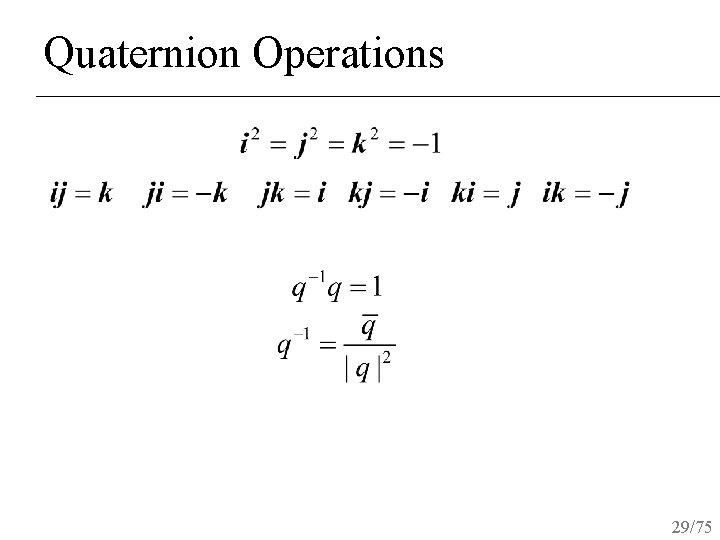
Quaternion Operations 29/75
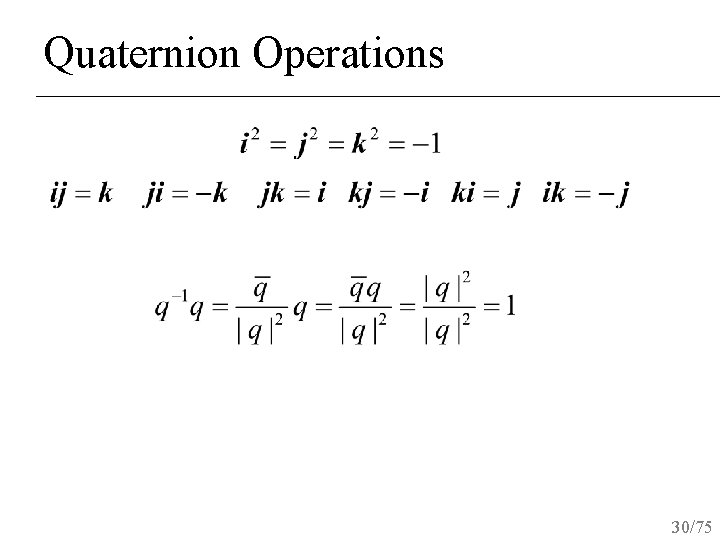
Quaternion Operations 30/75
Quaternions and Rotations n Claim: unit quaternions represent 3 D rotation 31/75
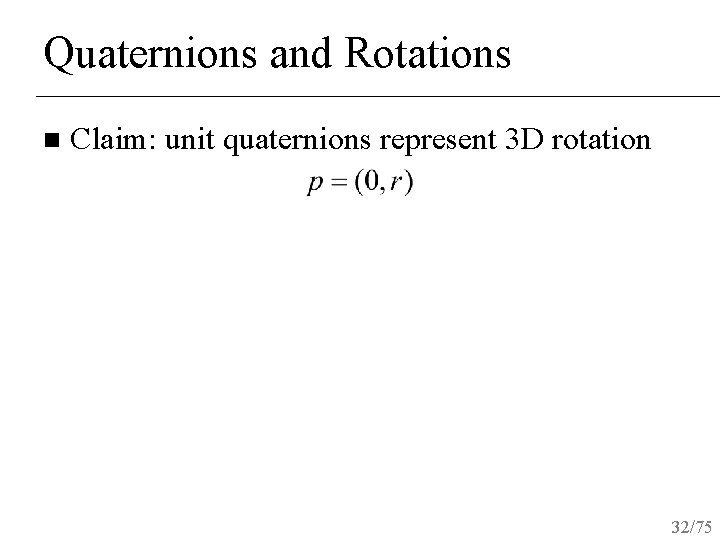
Quaternions and Rotations n Claim: unit quaternions represent 3 D rotation 32/75
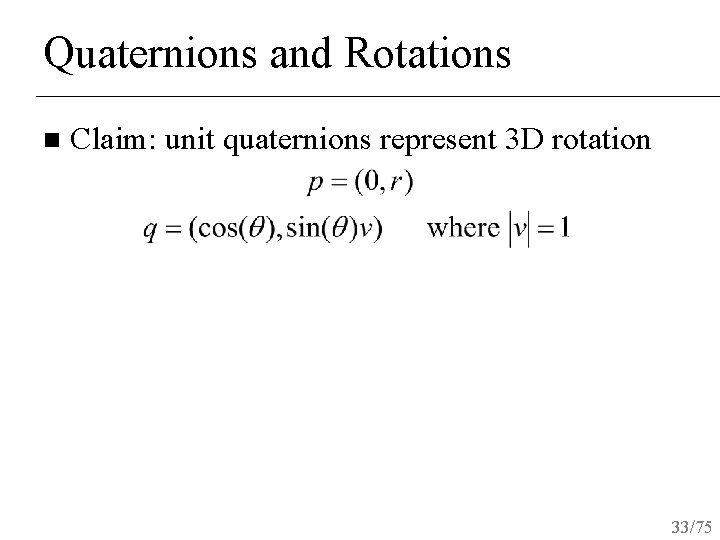
Quaternions and Rotations n Claim: unit quaternions represent 3 D rotation 33/75
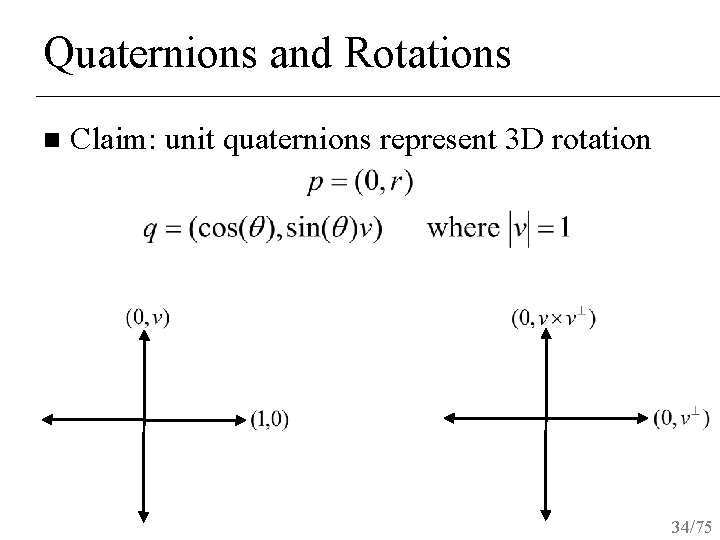
Quaternions and Rotations n Claim: unit quaternions represent 3 D rotation 34/75
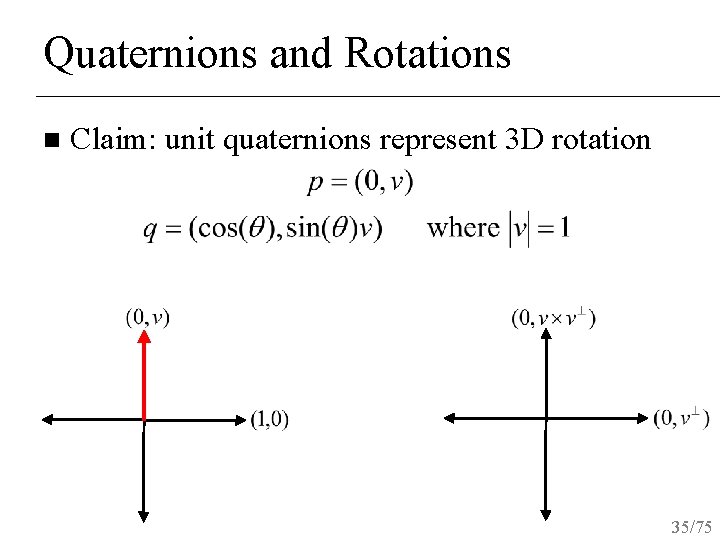
Quaternions and Rotations n Claim: unit quaternions represent 3 D rotation 35/75
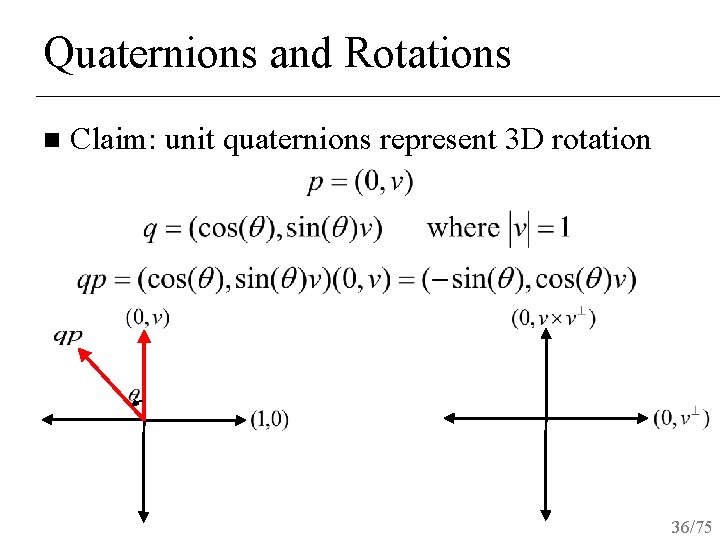
Quaternions and Rotations n Claim: unit quaternions represent 3 D rotation 36/75
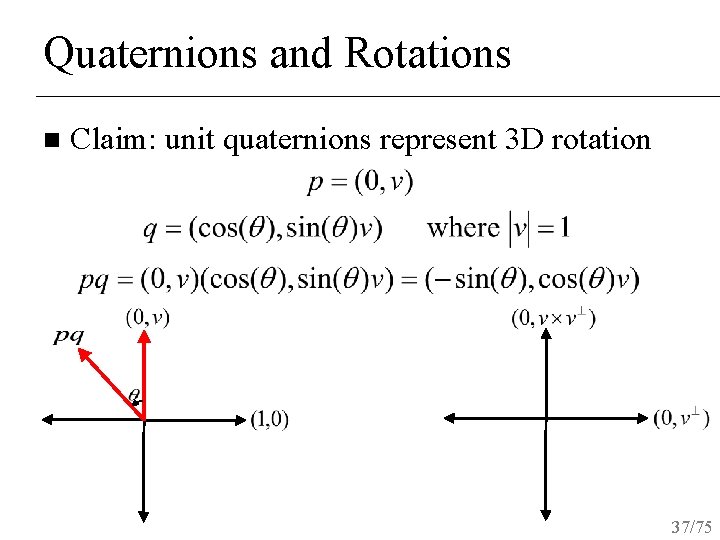
Quaternions and Rotations n Claim: unit quaternions represent 3 D rotation 37/75
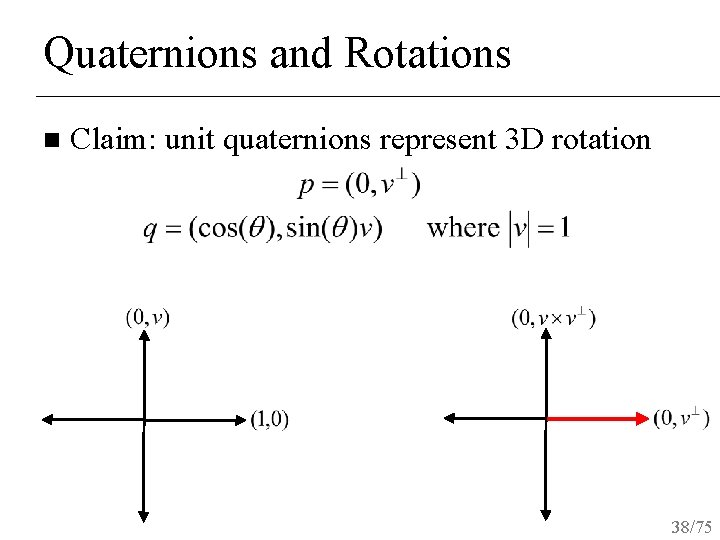
Quaternions and Rotations n Claim: unit quaternions represent 3 D rotation 38/75
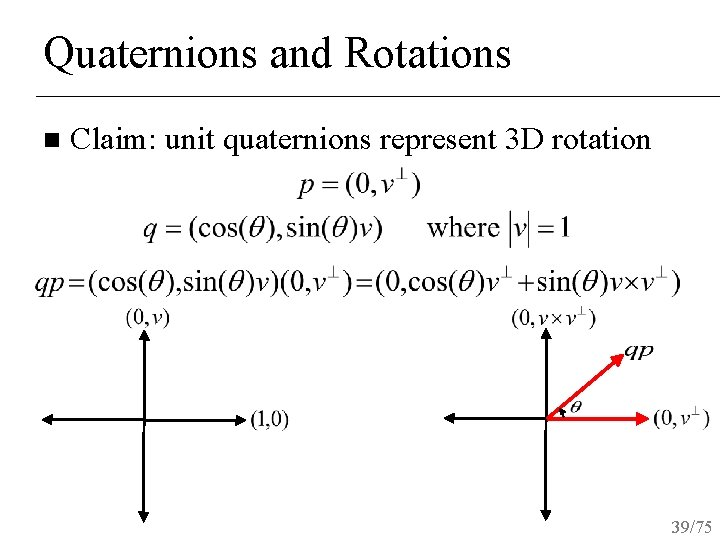
Quaternions and Rotations n Claim: unit quaternions represent 3 D rotation 39/75
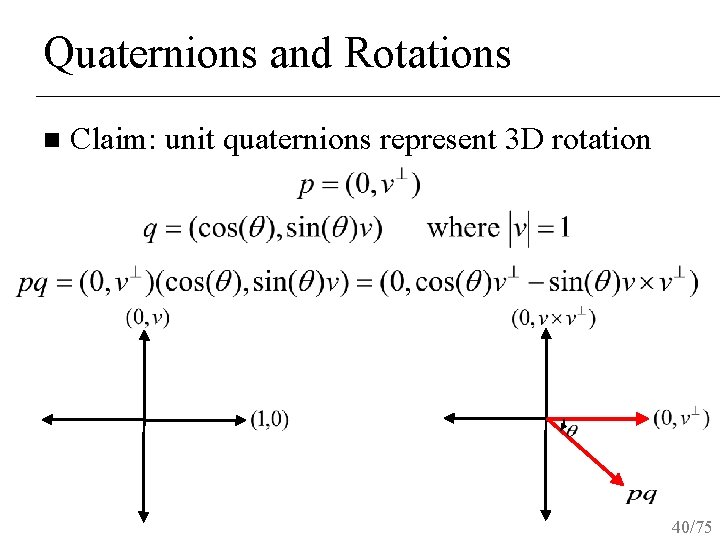
Quaternions and Rotations n Claim: unit quaternions represent 3 D rotation 40/75
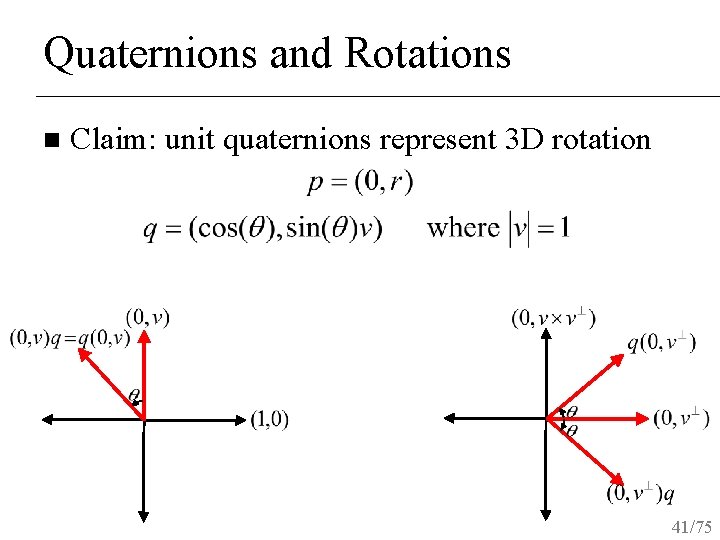
Quaternions and Rotations n Claim: unit quaternions represent 3 D rotation 41/75
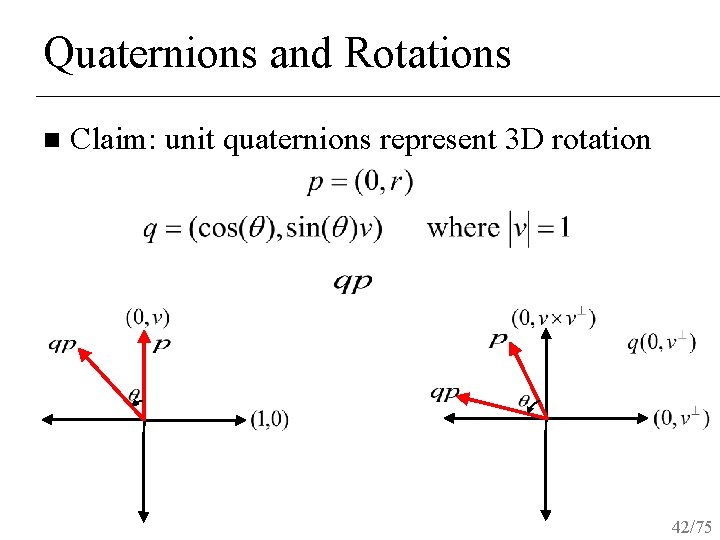
Quaternions and Rotations n Claim: unit quaternions represent 3 D rotation 42/75
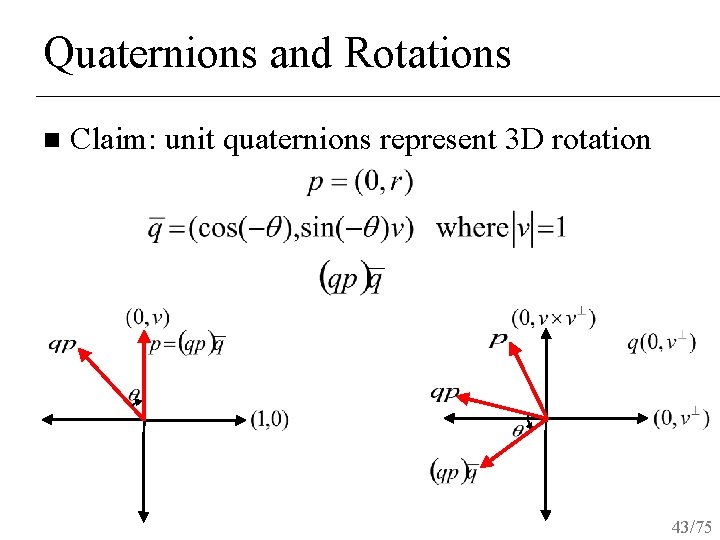
Quaternions and Rotations n Claim: unit quaternions represent 3 D rotation 43/75
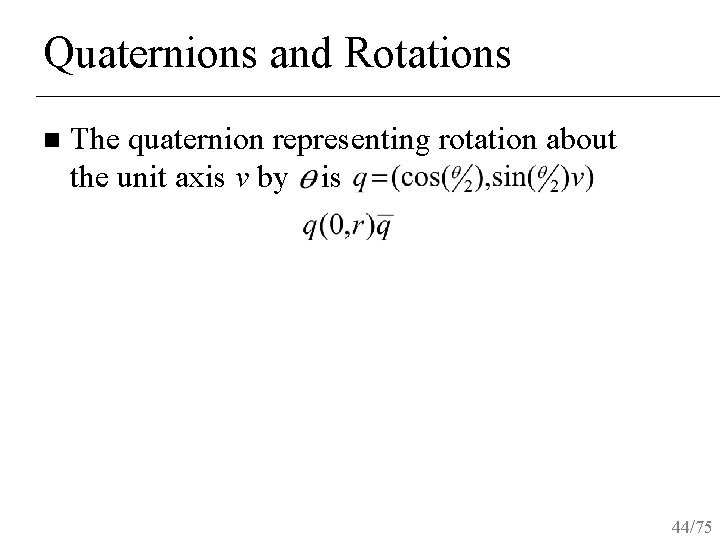
Quaternions and Rotations n The quaternion representing rotation about the unit axis v by is 44/75
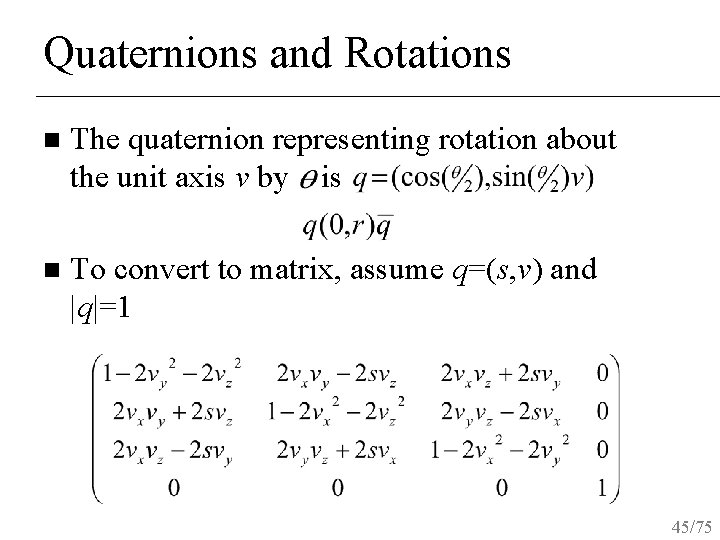
Quaternions and Rotations n The quaternion representing rotation about the unit axis v by is n To convert to matrix, assume q=(s, v) and |q|=1 45/75
Quaternions vs. Matrices Quaternions take less space (4 numbers vs. 9 for matrices) n Rotating a vector requires 28 multiplications using quaternions vs. 9 for matrices n Composing two rotations using quaternions q 1 q 2 requires 16 multiples vs. 27 for matrices n n Quaternions are typically not hardware accelerated whereas matrices are 46/75
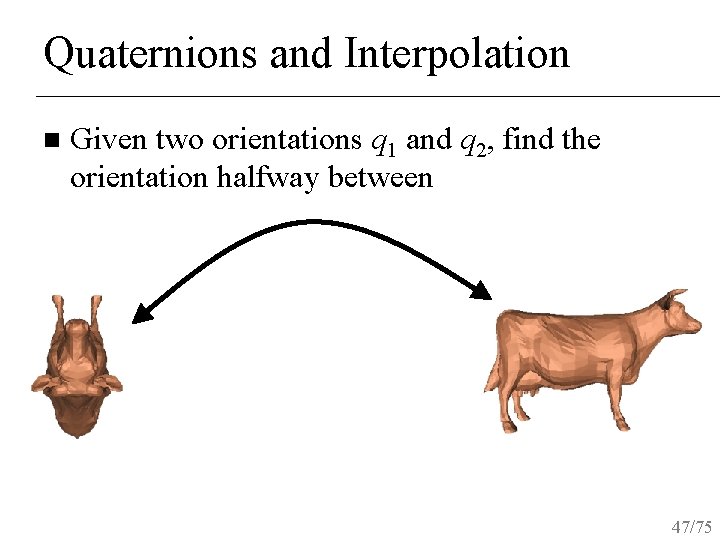
Quaternions and Interpolation n Given two orientations q 1 and q 2, find the orientation halfway between 47/75
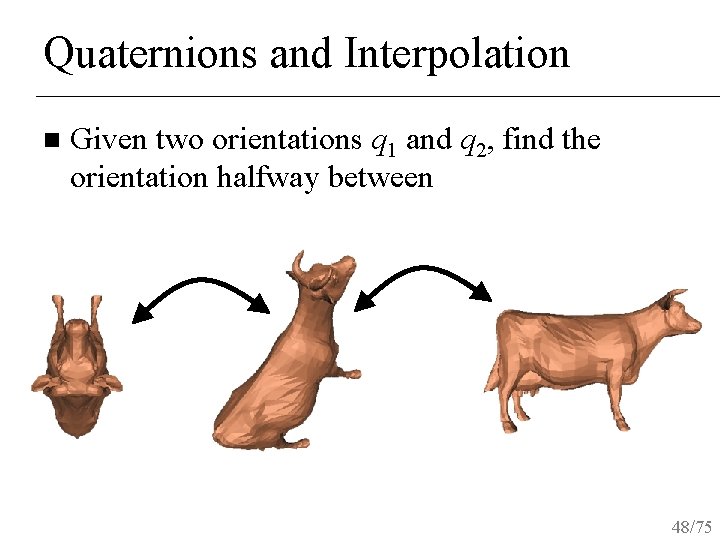
Quaternions and Interpolation n Given two orientations q 1 and q 2, find the orientation halfway between 48/75
Quaternions and Interpolation Unit quaternions represent points on a 4 D hyper-sphere n Interpolation on the sphere gives rotations that bend the least n 49/75
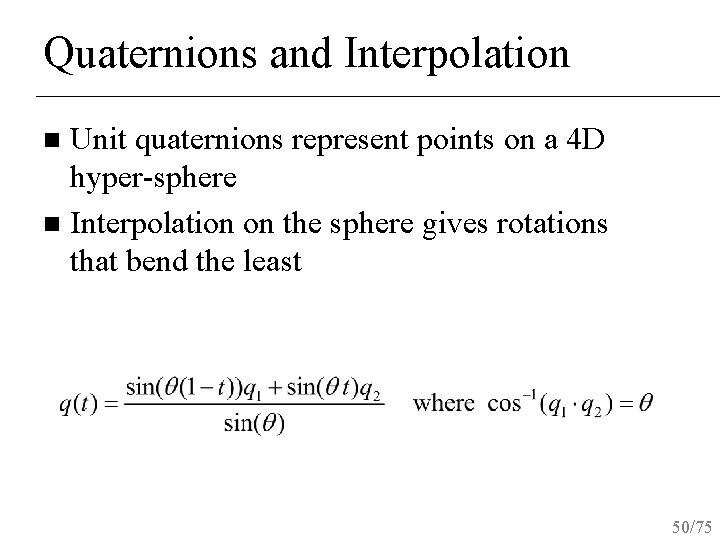
Quaternions and Interpolation Unit quaternions represent points on a 4 D hyper-sphere n Interpolation on the sphere gives rotations that bend the least n 50/75
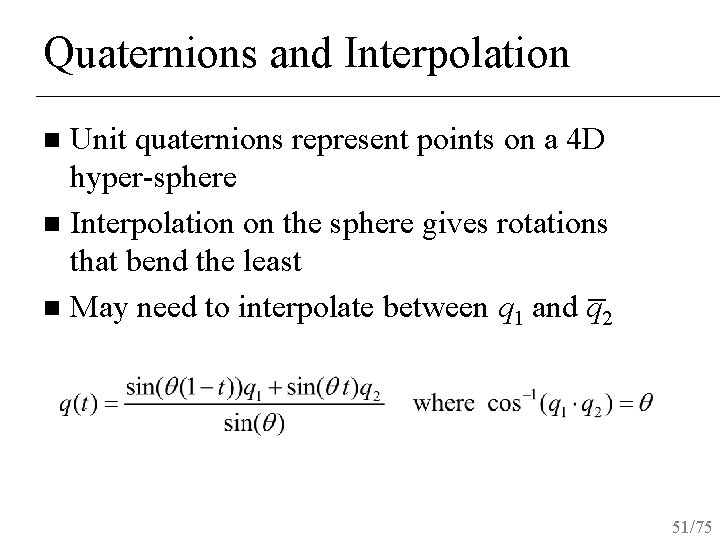
Quaternions and Interpolation Unit quaternions represent points on a 4 D hyper-sphere n Interpolation on the sphere gives rotations that bend the least n May need to interpolate between q 1 and q 2 n 51/75
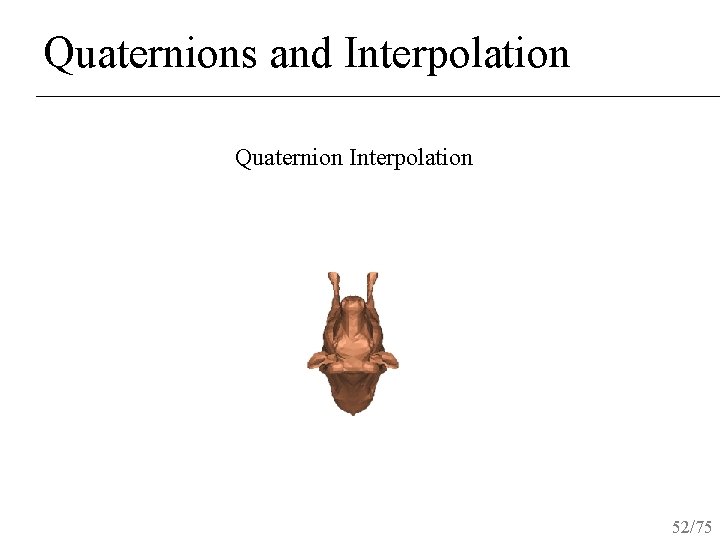
Quaternions and Interpolation Quaternion Interpolation 52/75
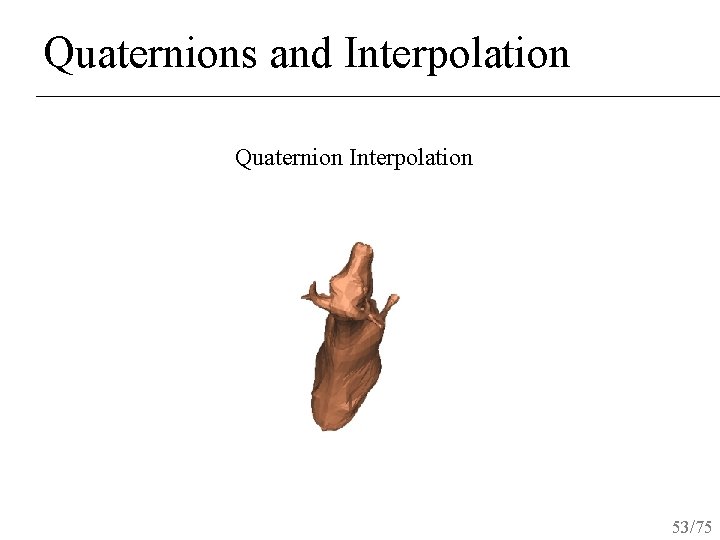
Quaternions and Interpolation Quaternion Interpolation 53/75
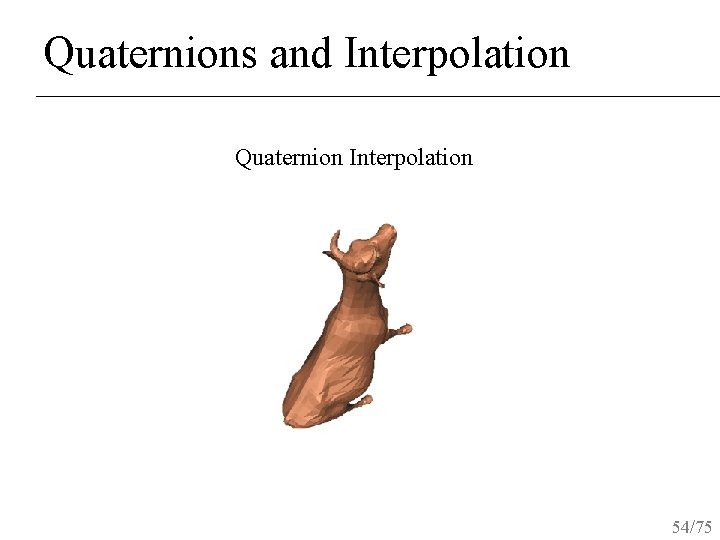
Quaternions and Interpolation Quaternion Interpolation 54/75
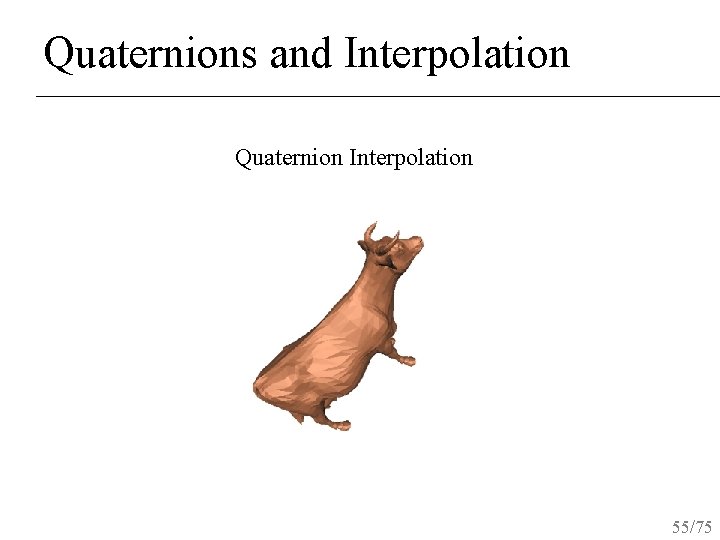
Quaternions and Interpolation Quaternion Interpolation 55/75
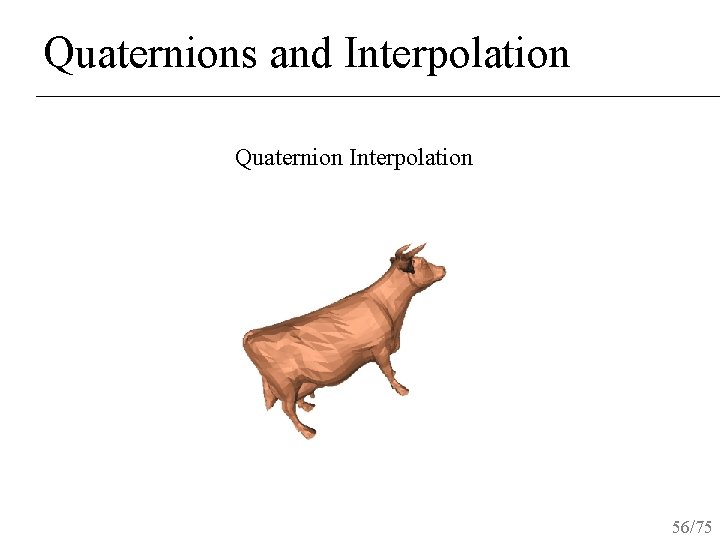
Quaternions and Interpolation Quaternion Interpolation 56/75
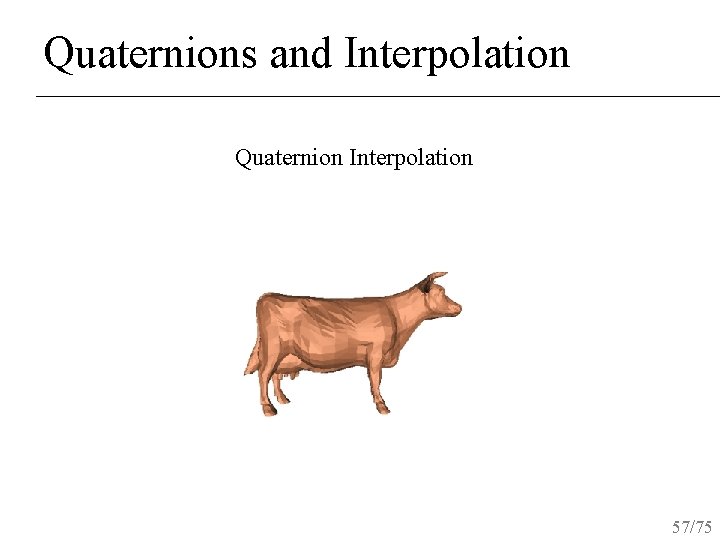
Quaternions and Interpolation Quaternion Interpolation 57/75
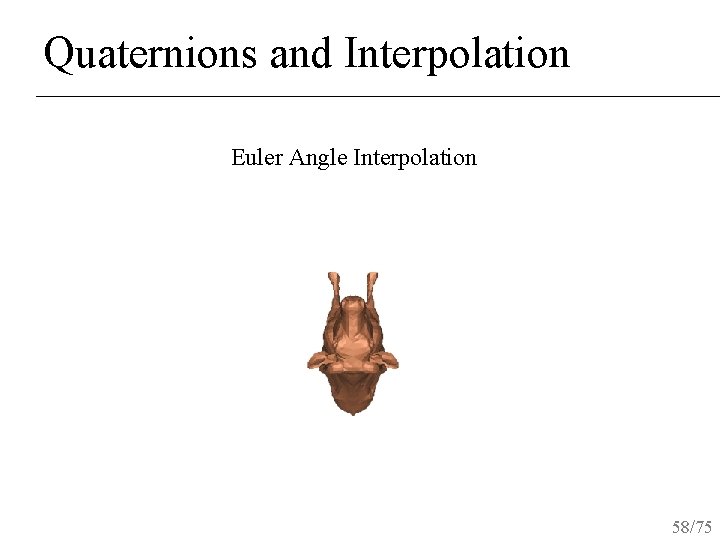
Quaternions and Interpolation Euler Angle Interpolation 58/75
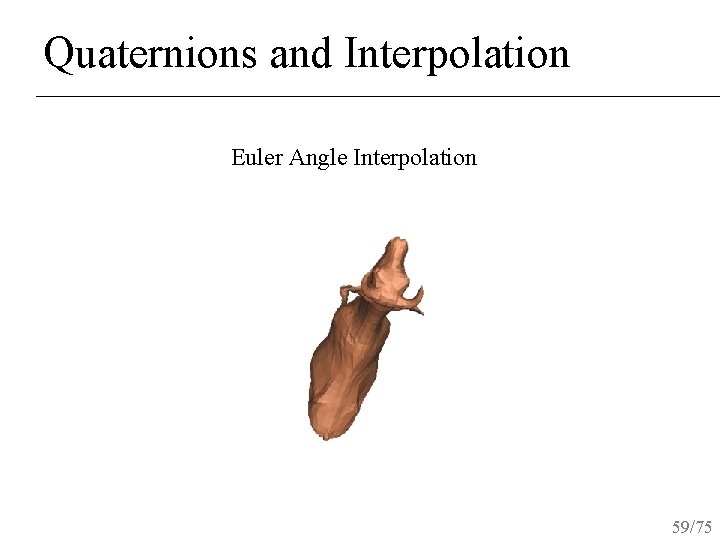
Quaternions and Interpolation Euler Angle Interpolation 59/75
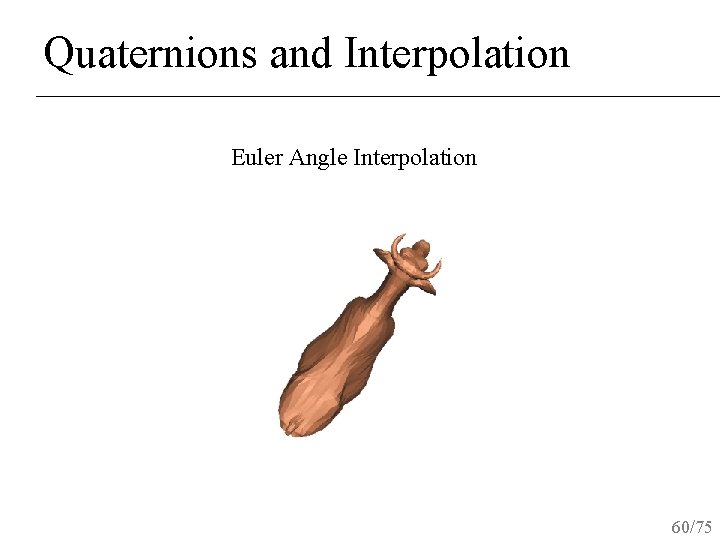
Quaternions and Interpolation Euler Angle Interpolation 60/75
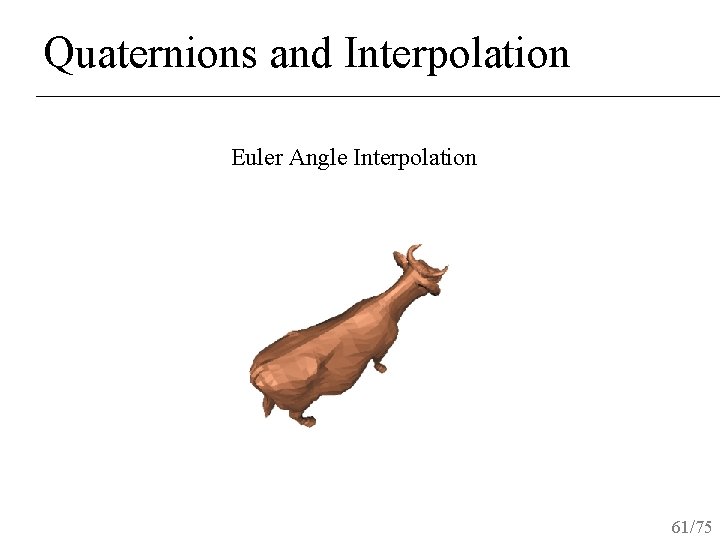
Quaternions and Interpolation Euler Angle Interpolation 61/75
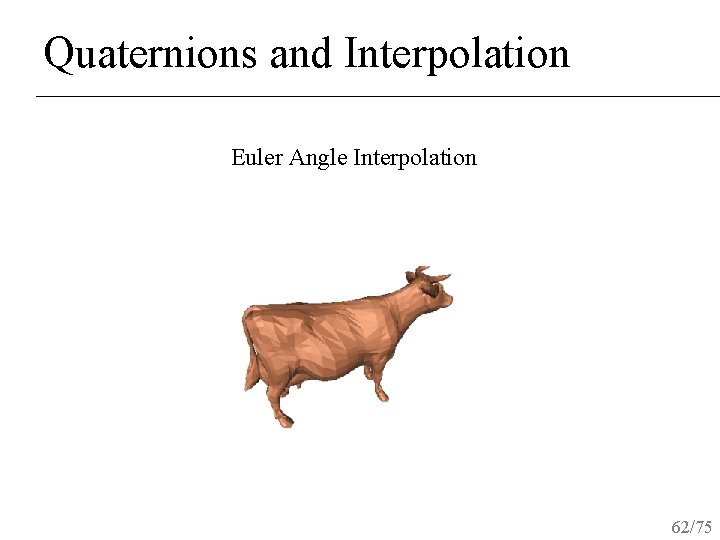
Quaternions and Interpolation Euler Angle Interpolation 62/75
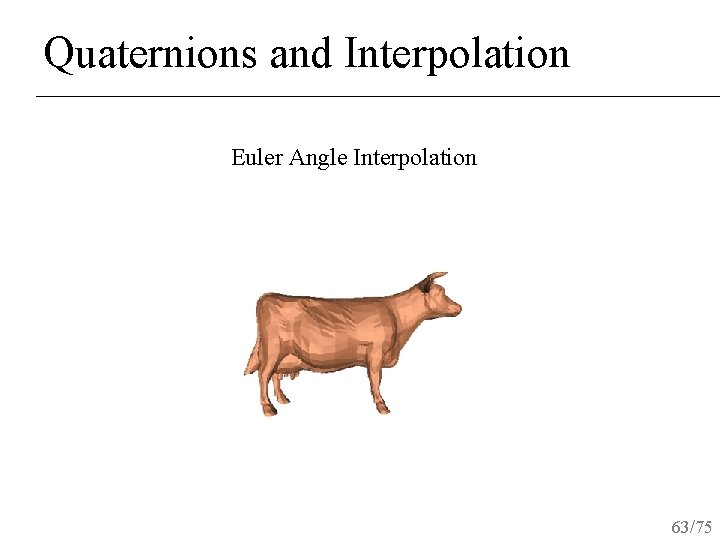
Quaternions and Interpolation Euler Angle Interpolation 63/75
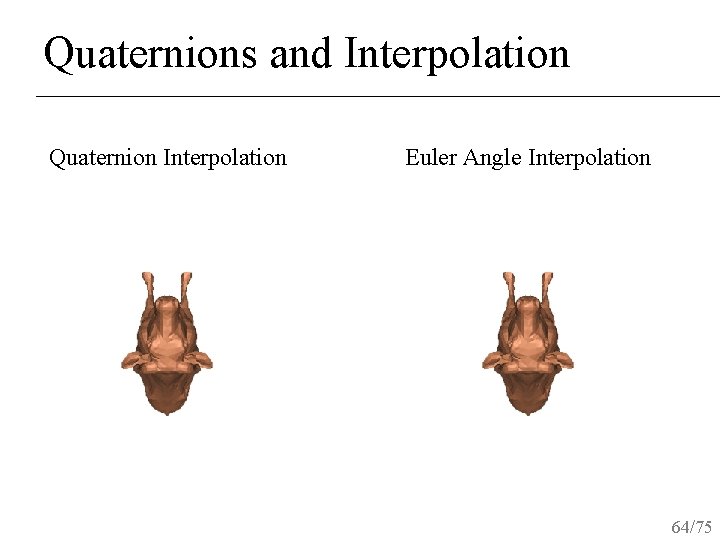
Quaternions and Interpolation Quaternion Interpolation Euler Angle Interpolation 64/75
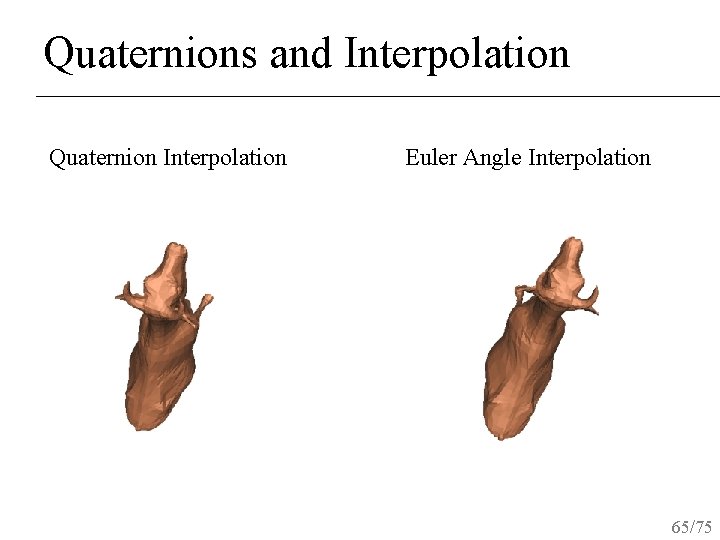
Quaternions and Interpolation Quaternion Interpolation Euler Angle Interpolation 65/75
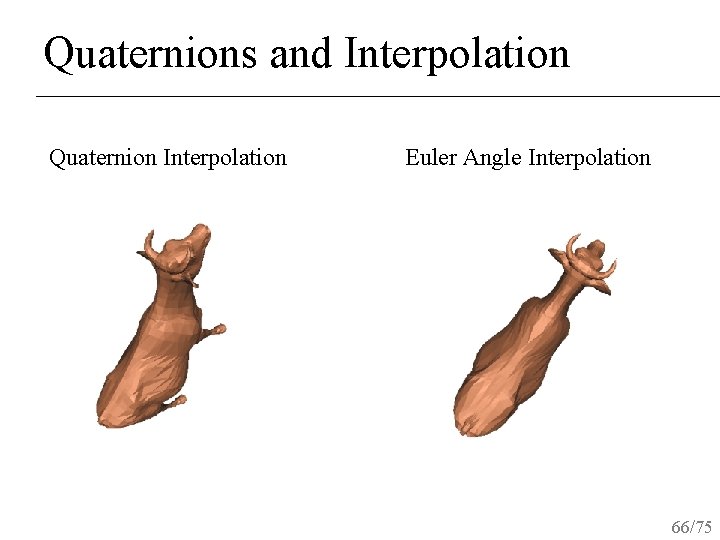
Quaternions and Interpolation Quaternion Interpolation Euler Angle Interpolation 66/75
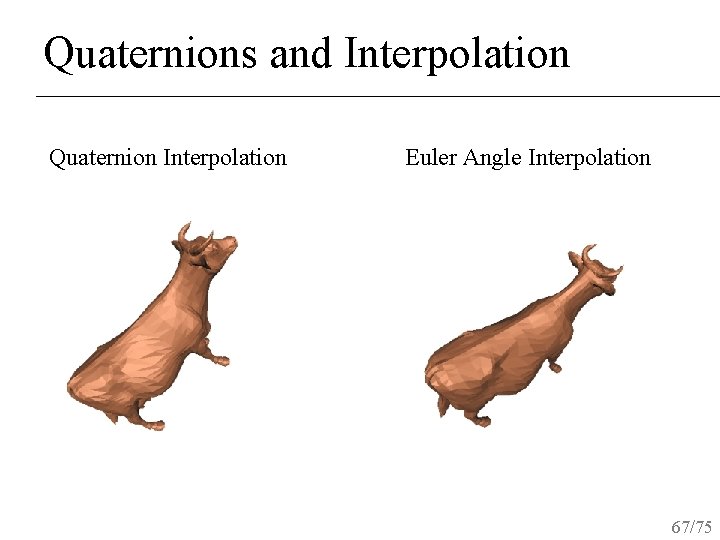
Quaternions and Interpolation Quaternion Interpolation Euler Angle Interpolation 67/75
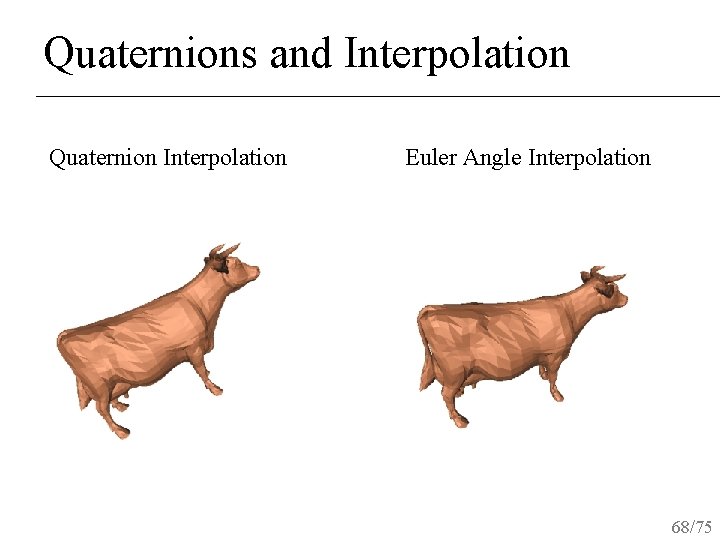
Quaternions and Interpolation Quaternion Interpolation Euler Angle Interpolation 68/75
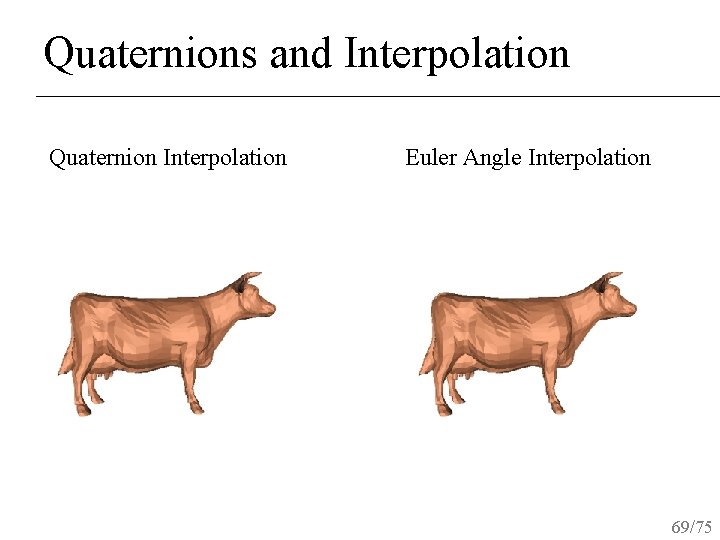
Quaternions and Interpolation Quaternion Interpolation Euler Angle Interpolation 69/75
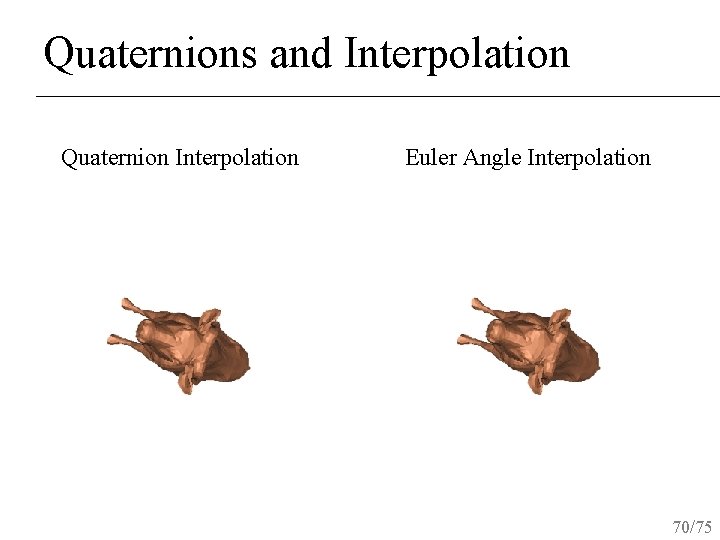
Quaternions and Interpolation Quaternion Interpolation Euler Angle Interpolation 70/75
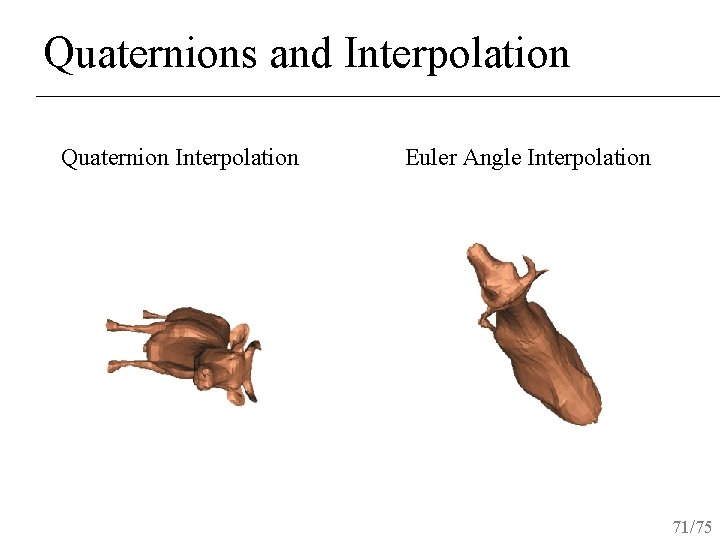
Quaternions and Interpolation Quaternion Interpolation Euler Angle Interpolation 71/75
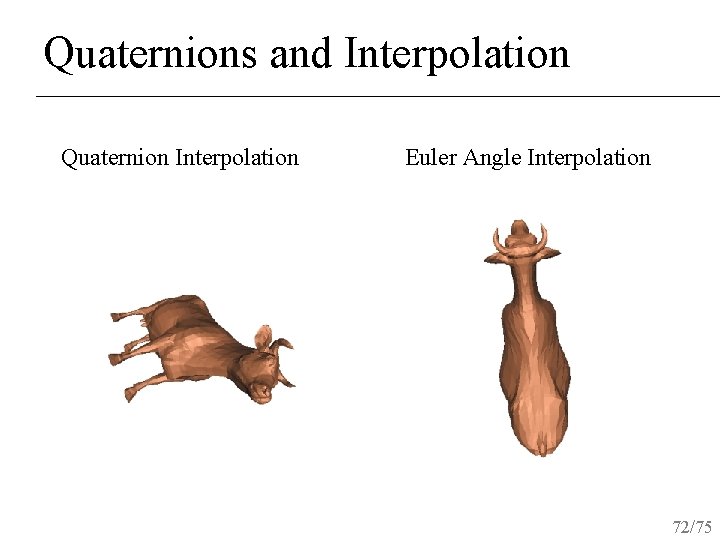
Quaternions and Interpolation Quaternion Interpolation Euler Angle Interpolation 72/75
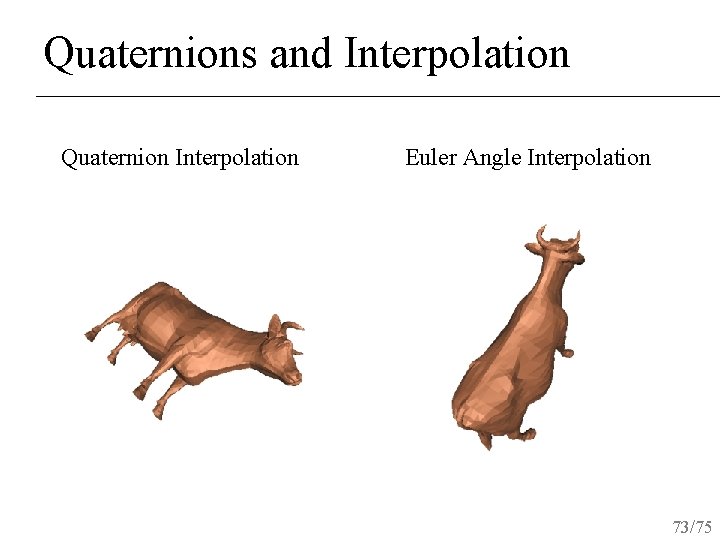
Quaternions and Interpolation Quaternion Interpolation Euler Angle Interpolation 73/75
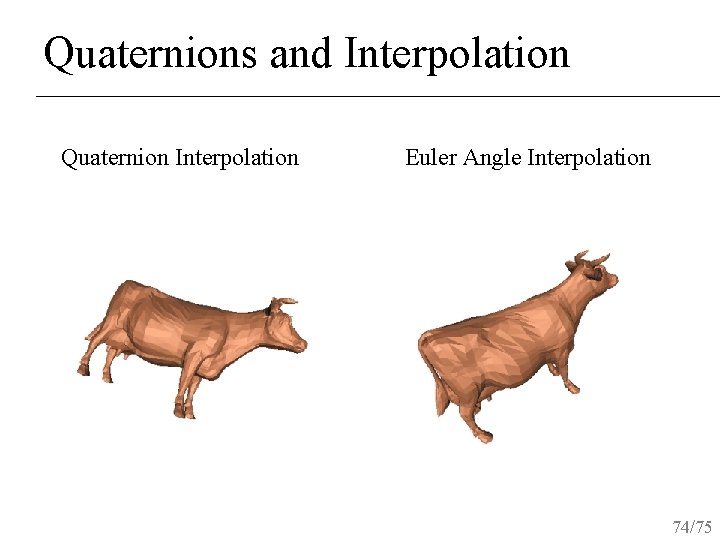
Quaternions and Interpolation Quaternion Interpolation Euler Angle Interpolation 74/75
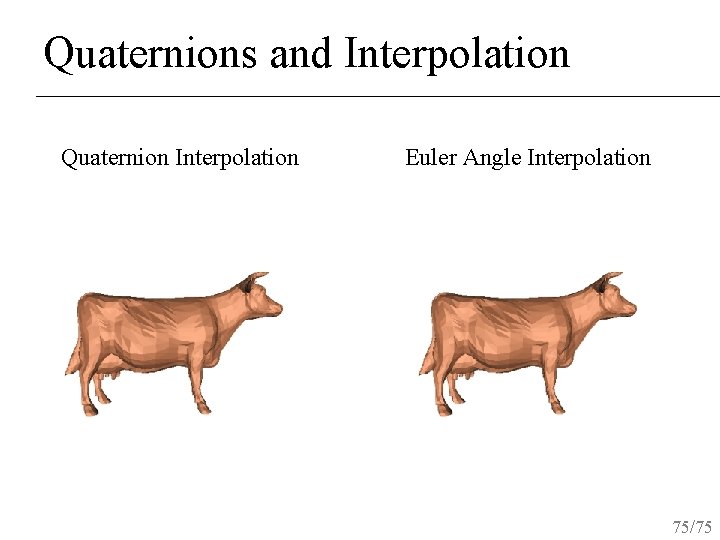
Quaternions and Interpolation Quaternion Interpolation Euler Angle Interpolation 75/75
76/75
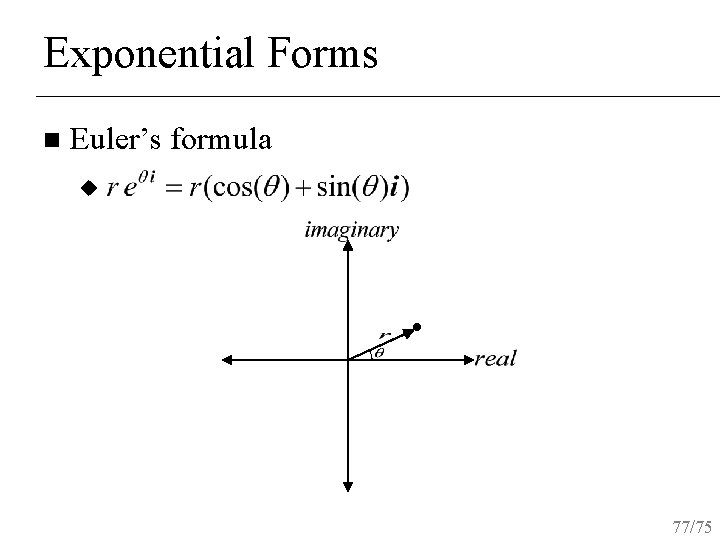
Exponential Forms n Euler’s formula u 77/75
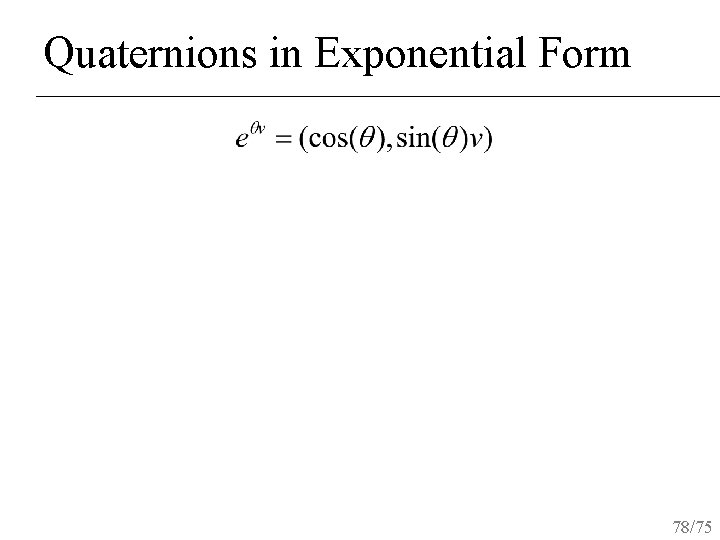
Quaternions in Exponential Form 78/75
- Slides: 78