
Progress Report Yoonsang Lee Movement Research Lab Seoul
Progress Report Yoonsang Lee, Movement Research Lab. , Seoul National University
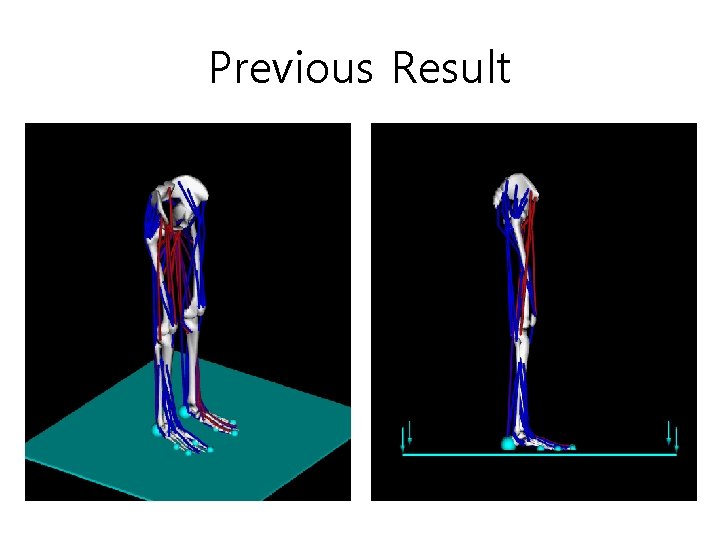
Previous Result
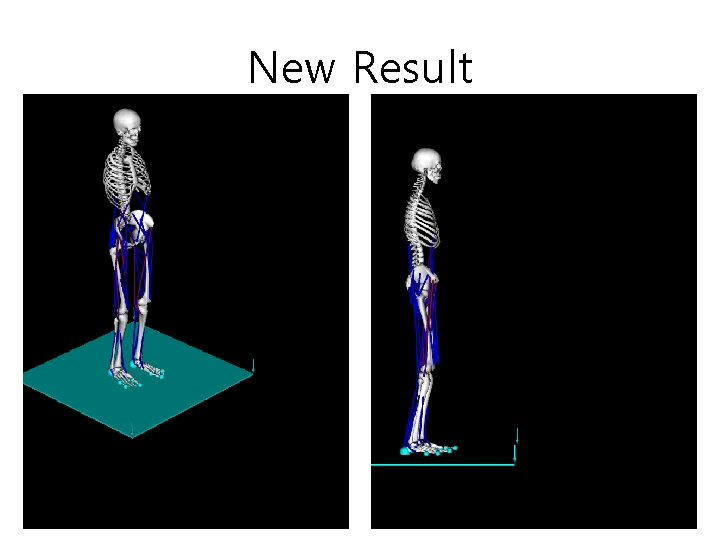
New Result
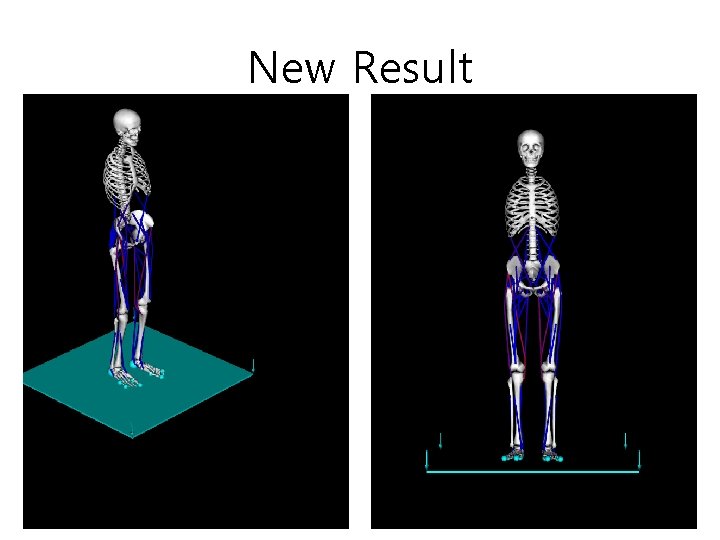
New Result
Joint Constraint • Ligament – “passive muscle” – Meaningful with contact based joint modeling • Coordinate. Limit. Force – Penalty method – Parameter : stiffness, damping, transition • Parameters for each person?
Joint Range • Joint range for each person?
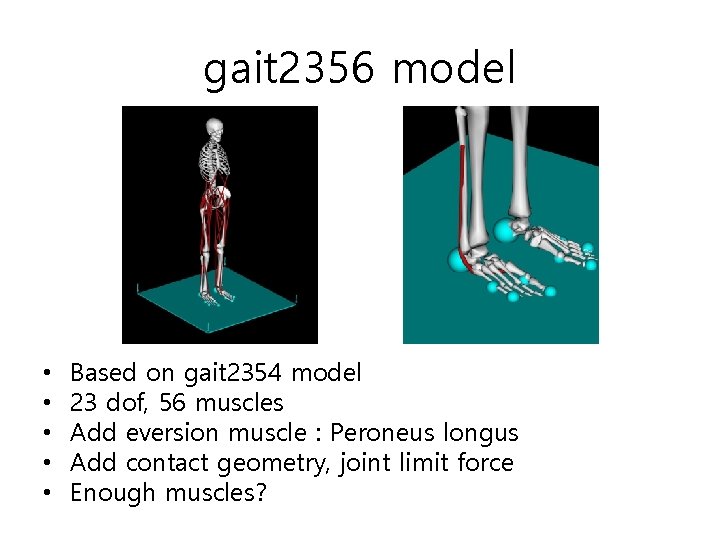
gait 2356 model • • • Based on gait 2354 model 23 dof, 56 muscles Add eversion muscle : Peroneus longus Add contact geometry, joint limit force Enough muscles?
Upper Body • We don’t have motion data of upper body now. • Just lower body model? • Additional markers for upper body?
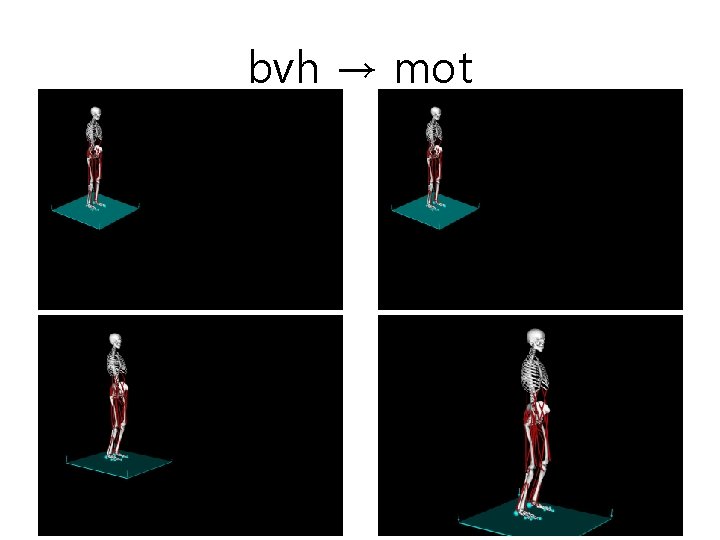
bvh → mot
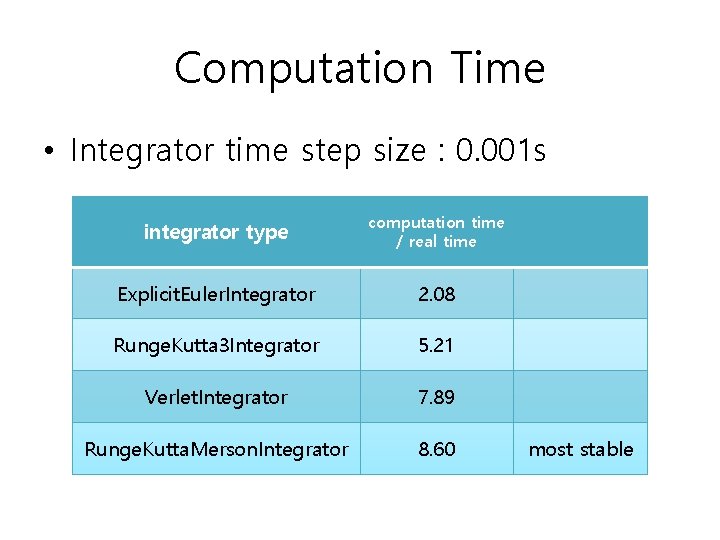
Computation Time • Integrator time step size : 0. 001 s integrator type computation time / real time Explicit. Euler. Integrator 2. 08 Runge. Kutta 3 Integrator 5. 21 Verlet. Integrator 7. 89 Runge. Kutta. Merson. Integrator 8. 60 most stable
Walking Controller • Yoonsang Lee, Sungeun Kim, Jehee Lee, Data. Driven Biped Control, ACM Transactions on Graphics (SIGGRAPH 2010), Vol. 29, No. 4, Article 129, July 2010
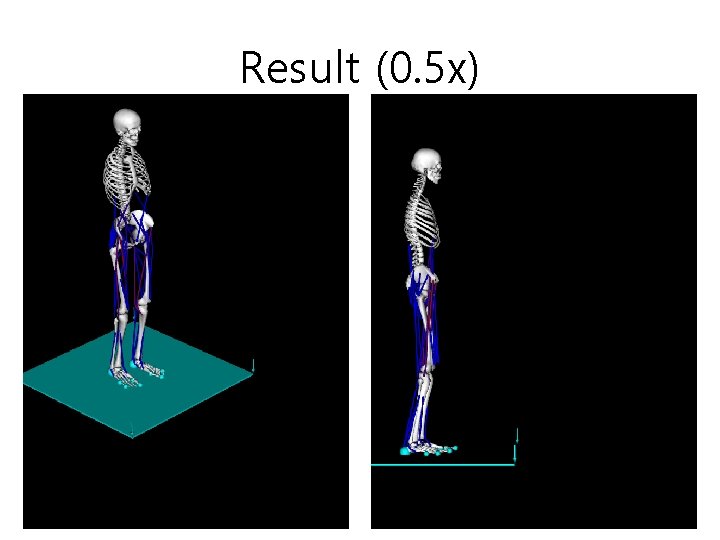
Result (0. 5 x)
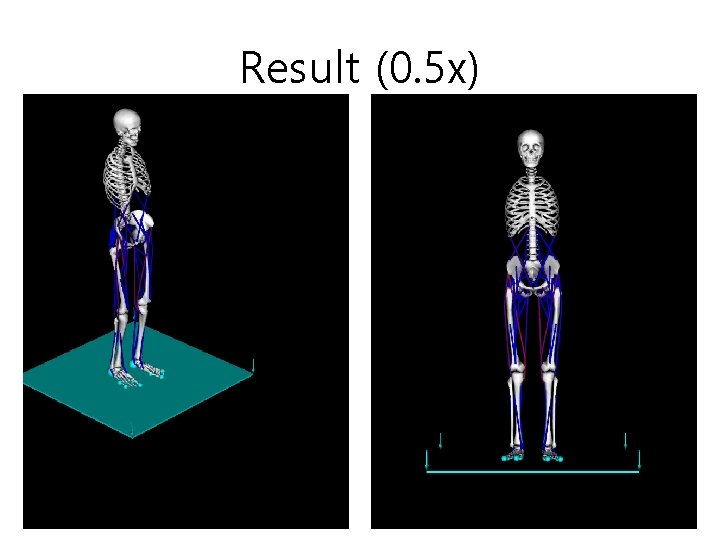
Result (0. 5 x)
Dicussion • Model customizing – Bone : shape, COM, mass, inertia – Joint : position, axis, range, constraint force parameter – Muscle : origin & insertion point, parameters
Next. . • Improve tracking algorithm – dynamic states → joint torques → muscle forces → muscle activations – (current : muscle states → muscle forces → muscle activations) • • Normal gait tracking of normal model Build basic pathologic model Normal gait tracking of pathologic model Pathologic gait tracking of pathologic model
Thank you
- Slides: 16