
POWER ELECTRONICS EPE 550 CIRCUITS DEVICES AND APPLICATIONS
- Slides: 123
POWER ELECTRONICS EPE 550 CIRCUITS, DEVICES, AND APPLICATIONS ELECTRICAL DRIVES: An Application of Power Electronics Eng. Mohammed Alsumady
CONTENTS Power Electronic Systems Modern Electrical Drive Systems Power Electronic Converters in Electrical Drives : : DC and AC Drives Modeling and Control of Electrical Drives : : Current controlled Converters : : Modeling of Power Converters : : Scalar control of IM
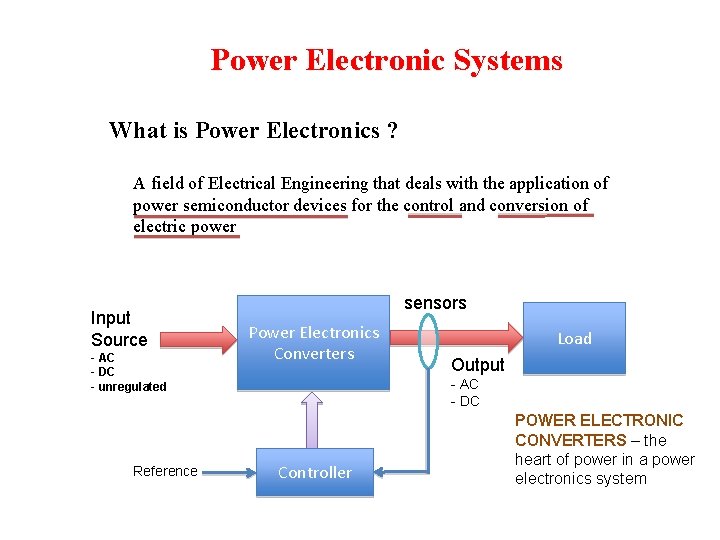
Power Electronic Systems What is Power Electronics ? A field of Electrical Engineering that deals with the application of power semiconductor devices for the control and conversion of electric power Input Source - AC - DC - unregulated Reference sensors Power Electronics Converters Load Output - AC - DC Controller POWER ELECTRONIC CONVERTERS – the heart of power in a power electronics system
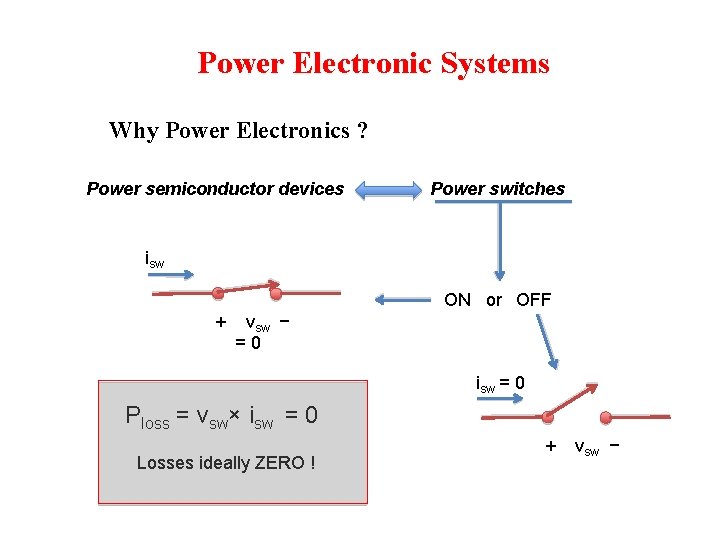
Power Electronic Systems Why Power Electronics ? Power semiconductor devices Power switches isw ON or OFF + vsw − =0 isw = 0 Ploss = vsw× isw = 0 Losses ideally ZERO ! + vsw −
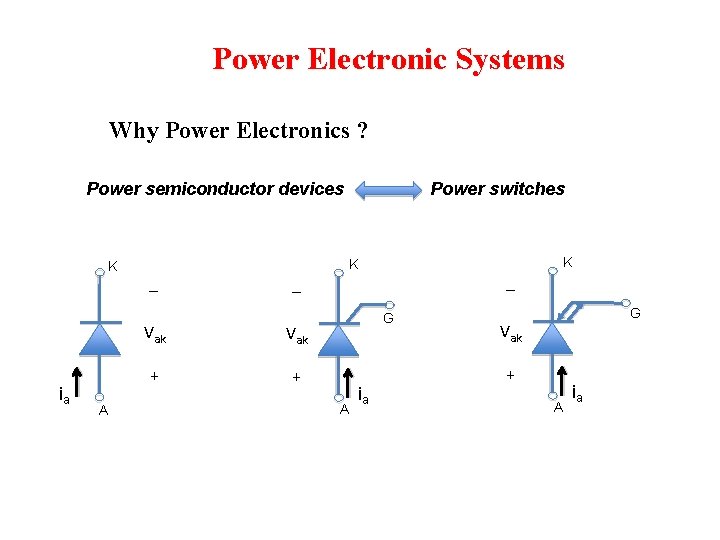
Power Electronic Systems Why Power Electronics ? Power semiconductor devices A K K K ia Power switches Vak + + G A ia G Vak + A ia
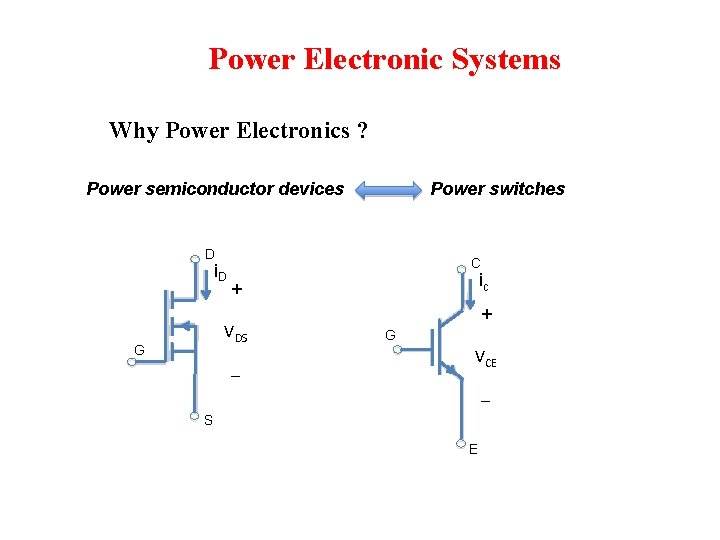
Power Electronic Systems Why Power Electronics ? Power semiconductor devices Power switches D i. D C VDS G ic + + G VCE S E
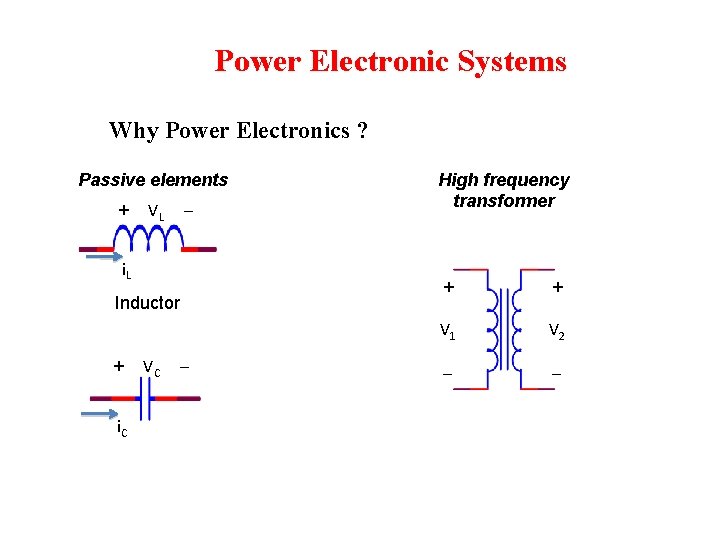
Power Electronic Systems Why Power Electronics ? Passive elements + VL i. L Inductor + i. C VC High frequency transformer + + V 1 V 2
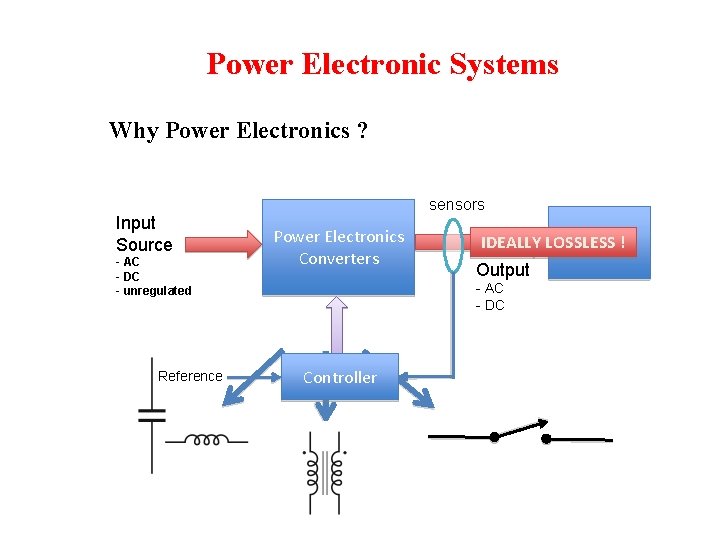
Power Electronic Systems Why Power Electronics ? Input Source - AC - DC - unregulated Reference sensors Power Electronics Converters IDEALLY LOSSLESS Load ! Output - AC - DC Controller
Power Electronic Systems Why Power Electronics ? Other factors: • Improvements in power semiconductors fabrication • Power Integrated Module (PIM), Intelligent Power Modules (IPM) • Decline cost in power semiconductor • Advancement in semiconductor fabrication • ASICs • FPGA • DSPs • Faster and cheaper to implement complex algorithm
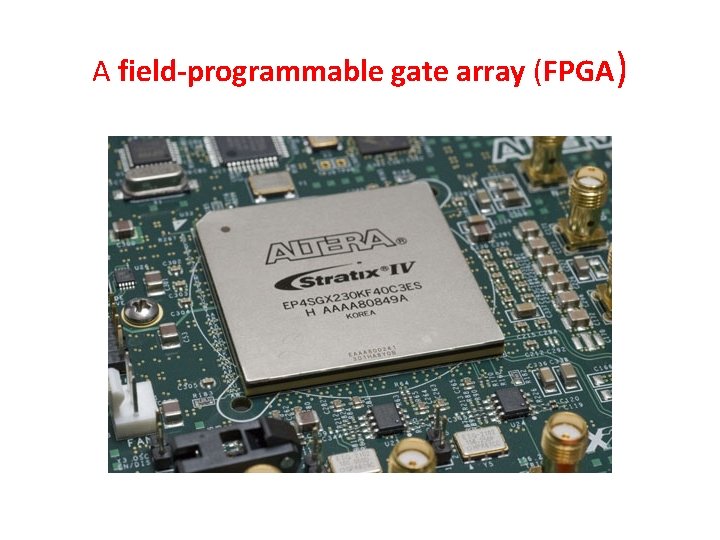
Advancement in semiconductor fabrication • • • A field-programmable gate array (FPGA) is an integrated circuit designed to be configured by the customer or designer after manufacturing—hence "field-programmable". The FPGA configuration is generally specified using a hardware description language (HDL), similar to that used for an application-specific integrated circuit (ASIC) circuit diagrams were previously used to specify the configuration, as they were for ASICs, but this is increasingly rare). FPGAs can be used to implement any logical function that an ASIC could perform. The ability to update the functionality after shipping, partial re-configuration of the portion of the design and the low non-recurring engineering costs relative to an ASIC design (notwithstanding the generally higher unit cost), offer advantages for many applications. FPGAs contain programmable logic components called "logic blocks", and a hierarchy of reconfigurable interconnects that allow the blocks to be "wired together"—somewhat like many (changeable) logic gates that can be inter-wired in (many) different configurations. Logic blocks can be configured to perform complex combinational functions, or merely simple logic gates like AND and XOR. In most FPGAs, the logic blocks also include memory elements, which may be simple flip-flops or more complete blocks of memory. In addition to digital functions, some FPGAs have analog features. The most common analog feature is programmable slew rate and drive strength on each output pin, allowing the engineer to set slow rates on lightly loaded pins that would otherwise ring unacceptably, and to set stronger, faster rates on heavily loaded pins on high-speed channels that would otherwise run too slow. Another relatively common analog feature is differential comparators on input pins designed to be connected to differential signaling channels.
A field-programmable gate array (FPGA) • The FPGA industry sprouted from programmable read-only memory (PROM) and programmable logic devices (PLDs). PROMs and PLDs both had the option of being programmed in batches in a factory or in the field (field programmable), however programmable logic was hard-wired between logic gates. • A recent trend has been to take the coarse-grained architectural approach a step further by combining the logic blocks and interconnects of traditional FPGAs with embedded microprocessors and related peripherals to form a complete "system on a programmable chip“.
A field-programmable gate array (FPGA)
Power Electronic Systems Some Applications of Power Electronics : Typically used in systems requiring efficient control and conversion of electric energy: Domestic and Commercial Applications Industrial Applications Telecommunications Transportation Generation, Transmission and Distribution of electrical energy Power rating of < 1 W (portable equipment) Tens or hundreds Watts (Power supplies for computers /office equipment) k. W to MW : drives Hundreds of MW in DC transmission system (HVDC)
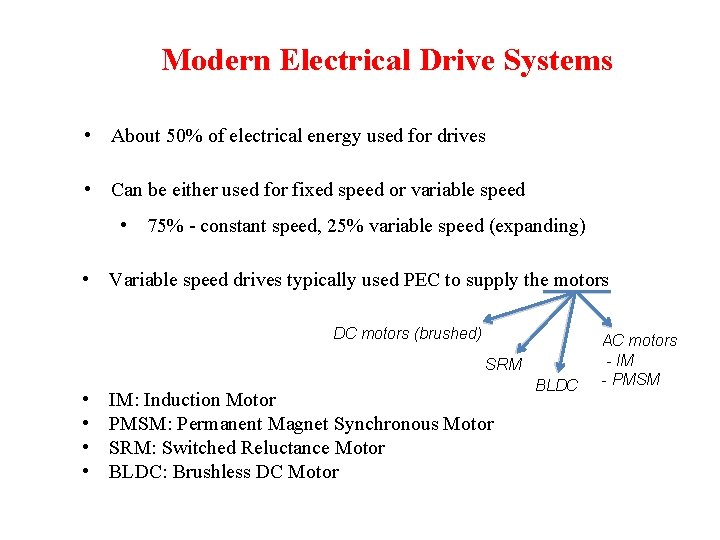
Modern Electrical Drive Systems • About 50% of electrical energy used for drives • Can be either used for fixed speed or variable speed • 75% - constant speed, 25% variable speed (expanding) • Variable speed drives typically used PEC to supply the motors DC motors (brushed) SRM • • IM: Induction Motor PMSM: Permanent Magnet Synchronous Motor SRM: Switched Reluctance Motor BLDC: Brushless DC Motor BLDC AC motors - IM - PMSM
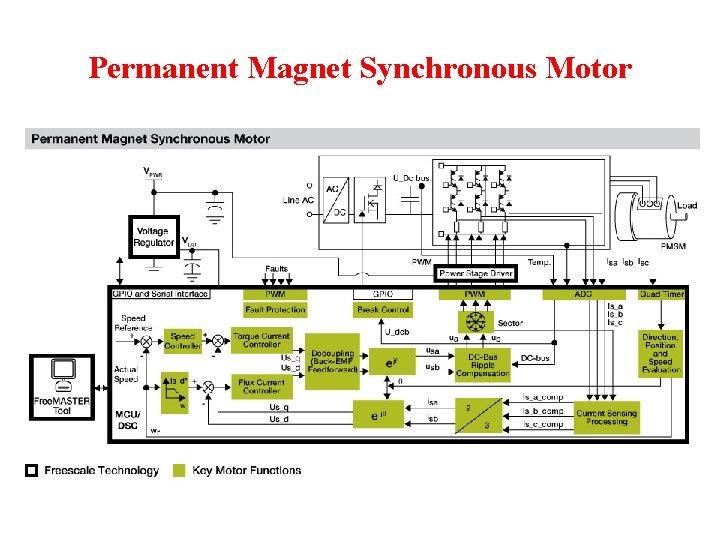
Permanent Magnet Synchronous Motor Ø The Permanent Magnet Synchronous motor is a rotating electric machine where the stator is a classic three phase stator like that of an induction motor and the rotor has permanent magnets. In this respect, the PM Synchronous motor is equivalent to an induction motor, except the rotor magnetic field in case of PMSM is produced by permanent magnets. The use of a permanent magnet to generate a substantial air gap magnetic flux makes it possible to design highly efficient PM motors. Medium construction complexity, multiple fields, delicate magnets • High reliability (no brush wear), even at very high achievable speeds • High efficiency • Low EMI • Driven by multi-phase Inverter controllers • Sensorless speed control possible • Higher total system cost than for DC motors • Smooth rotation - without torque ripple • Appropriate for position control
Permanent Magnet Synchronous Motor
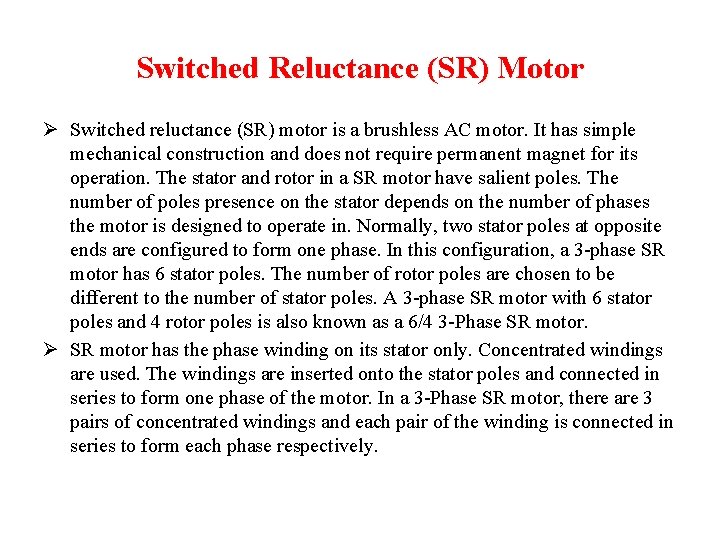
Switched Reluctance (SR) Motor Ø Switched reluctance (SR) motor is a brushless AC motor. It has simple mechanical construction and does not require permanent magnet for its operation. The stator and rotor in a SR motor have salient poles. The number of poles presence on the stator depends on the number of phases the motor is designed to operate in. Normally, two stator poles at opposite ends are configured to form one phase. In this configuration, a 3 -phase SR motor has 6 stator poles. The number of rotor poles are chosen to be different to the number of stator poles. A 3 -phase SR motor with 6 stator poles and 4 rotor poles is also known as a 6/4 3 -Phase SR motor. Ø SR motor has the phase winding on its stator only. Concentrated windings are used. The windings are inserted onto the stator poles and connected in series to form one phase of the motor. In a 3 -Phase SR motor, there are 3 pairs of concentrated windings and each pair of the winding is connected in series to form each phase respectively.
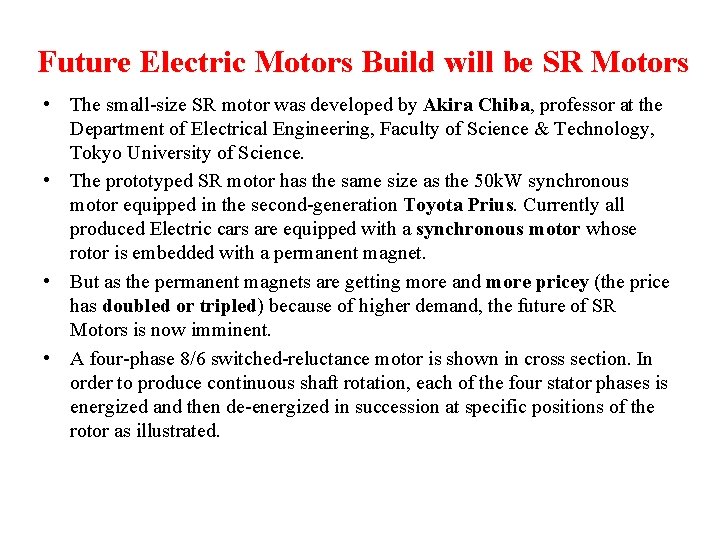
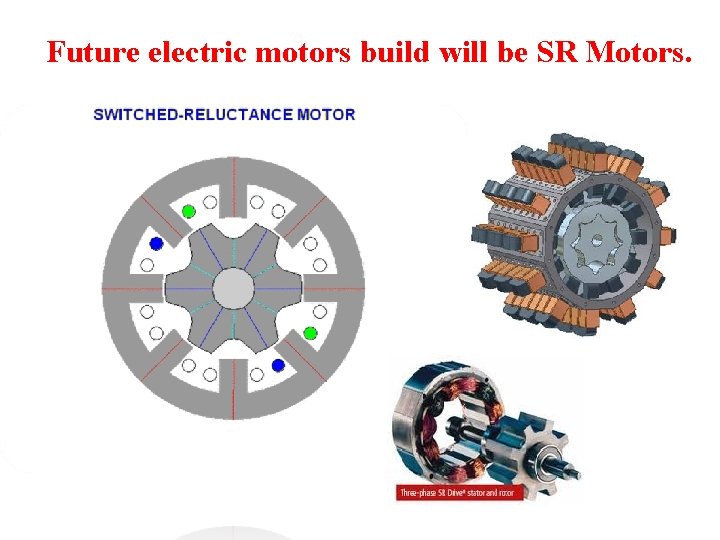
Future Electric Motors Build will be SR Motors • The small-size SR motor was developed by Akira Chiba, professor at the Department of Electrical Engineering, Faculty of Science & Technology, Tokyo University of Science. • The prototyped SR motor has the same size as the 50 k. W synchronous motor equipped in the second-generation Toyota Prius. Currently all produced Electric cars are equipped with a synchronous motor whose rotor is embedded with a permanent magnet. • But as the permanent magnets are getting more and more pricey (the price has doubled or tripled) because of higher demand, the future of SR Motors is now imminent. • A four-phase 8/6 switched-reluctance motor is shown in cross section. In order to produce continuous shaft rotation, each of the four stator phases is energized and then de-energized in succession at specific positions of the rotor as illustrated.
Future electric motors build will be SR Motors.
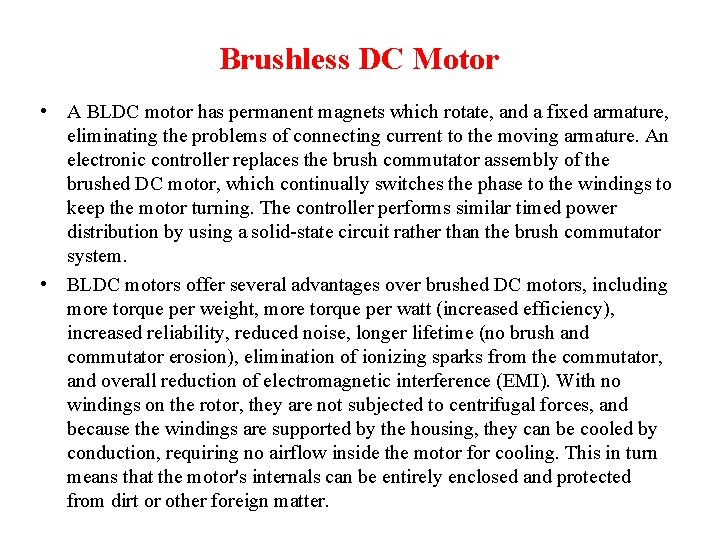
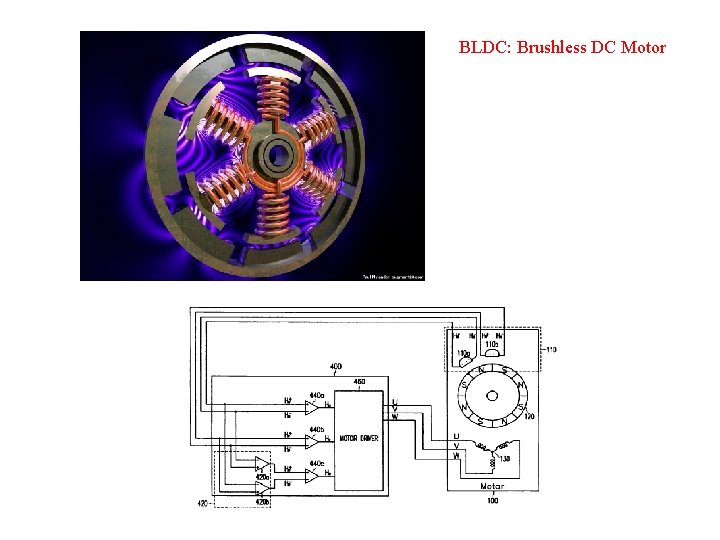
Brushless DC Motor • A BLDC motor has permanent magnets which rotate, and a fixed armature, eliminating the problems of connecting current to the moving armature. An electronic controller replaces the brush commutator assembly of the brushed DC motor, which continually switches the phase to the windings to keep the motor turning. The controller performs similar timed power distribution by using a solid-state circuit rather than the brush commutator system. • BLDC motors offer several advantages over brushed DC motors, including more torque per weight, more torque per watt (increased efficiency), increased reliability, reduced noise, longer lifetime (no brush and commutator erosion), elimination of ionizing sparks from the commutator, and overall reduction of electromagnetic interference (EMI). With no windings on the rotor, they are not subjected to centrifugal forces, and because the windings are supported by the housing, they can be cooled by conduction, requiring no airflow inside the motor for cooling. This in turn means that the motor's internals can be entirely enclosed and protected from dirt or other foreign matter.
BLDC: Brushless DC Motor
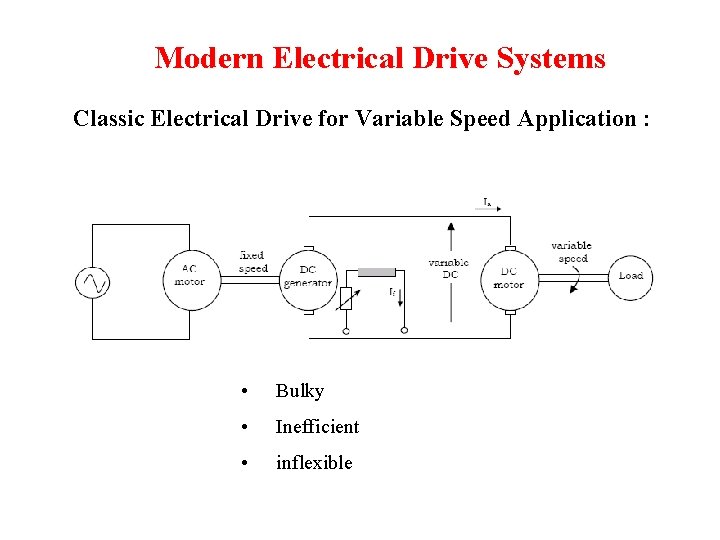
Modern Electrical Drive Systems Classic Electrical Drive for Variable Speed Application : • Bulky • Inefficient • inflexible
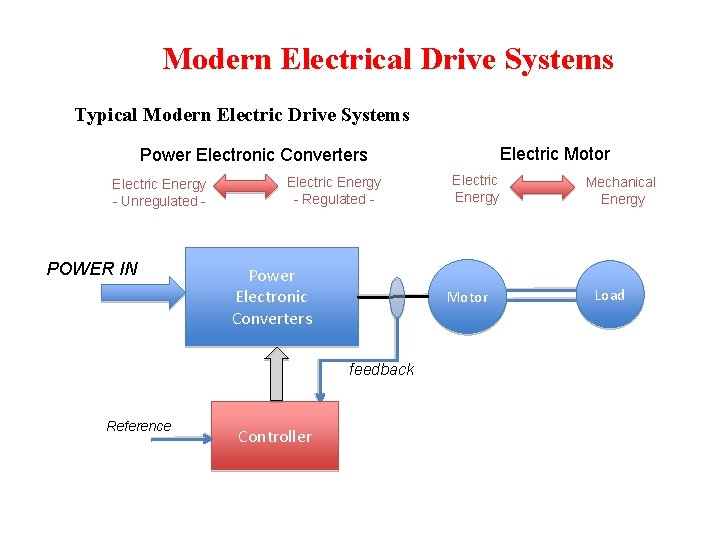
Modern Electrical Drive Systems Typical Modern Electric Drive Systems Electric Motor Power Electronic Converters Electric Energy - Unregulated - POWER IN Electric Energy - Regulated - Power Electronic Converters Motor feedback Reference Controller Electric Energy Mechanical Energy Load
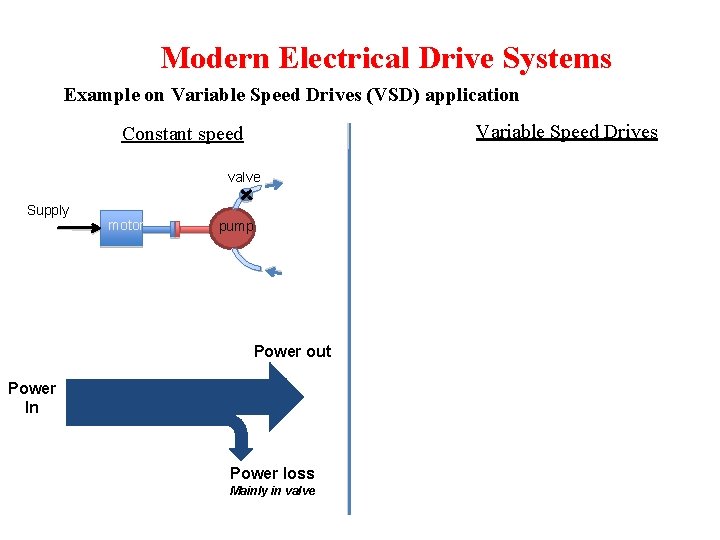
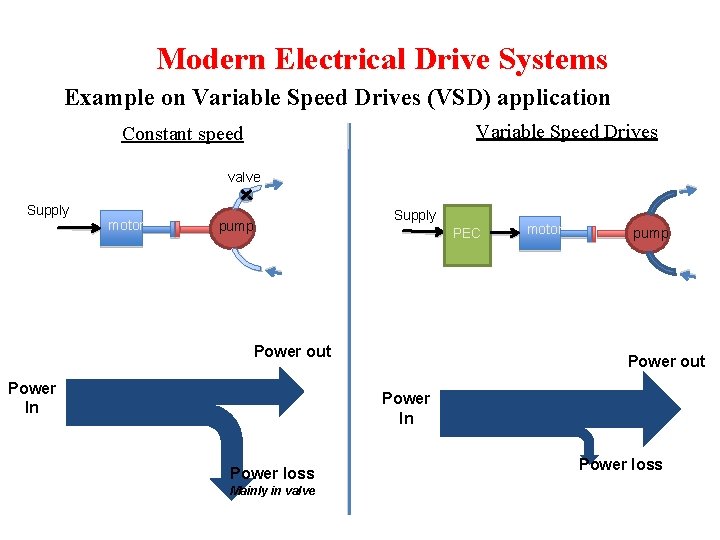
Modern Electrical Drive Systems Example on Variable Speed Drives (VSD) application Variable Speed Drives Constant speed valve Supply motor pump Power out Power In Power loss Mainly in valve
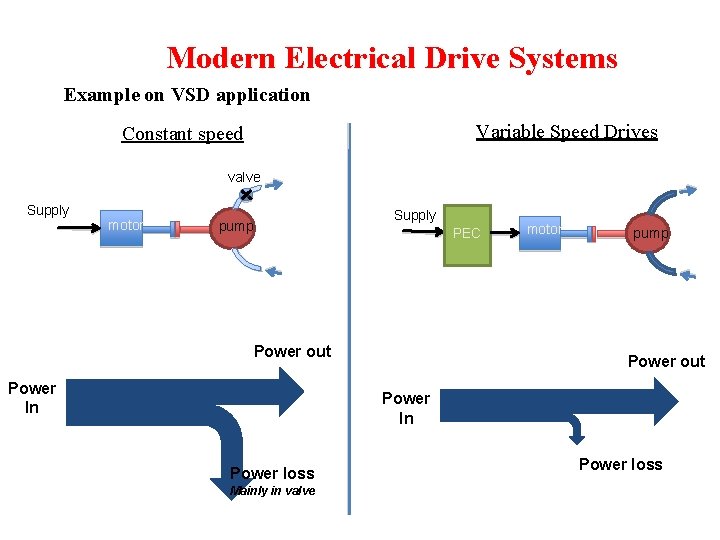
Modern Electrical Drive Systems Example on Variable Speed Drives (VSD) application Variable Speed Drives Constant speed valve Supply motor Supply pump PEC Power out Power In motor pump Power out Power In Power loss Mainly in valve Power loss
Modern Electrical Drive Systems Example on VSD application Variable Speed Drives Constant speed valve Supply motor Supply pump PEC Power out Power In motor pump Power out Power In Power loss Mainly in valve Power loss
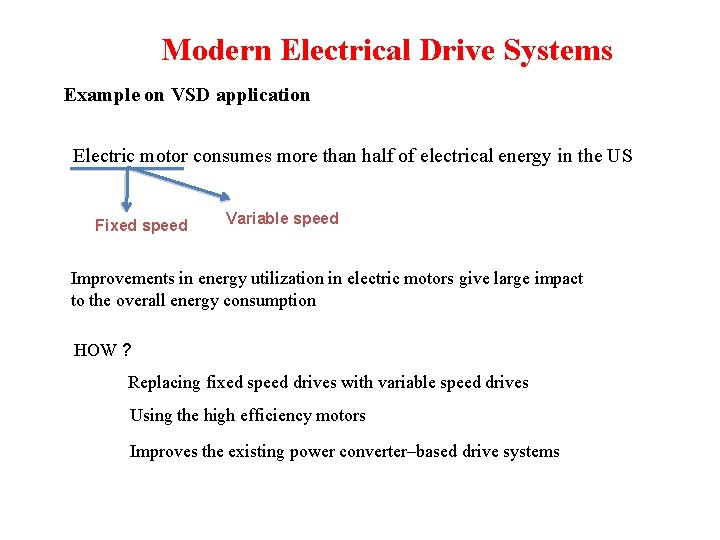
Modern Electrical Drive Systems Example on VSD application Electric motor consumes more than half of electrical energy in the US Fixed speed Variable speed Improvements in energy utilization in electric motors give large impact to the overall energy consumption HOW ? Replacing fixed speed drives with variable speed drives Using the high efficiency motors Improves the existing power converter–based drive systems
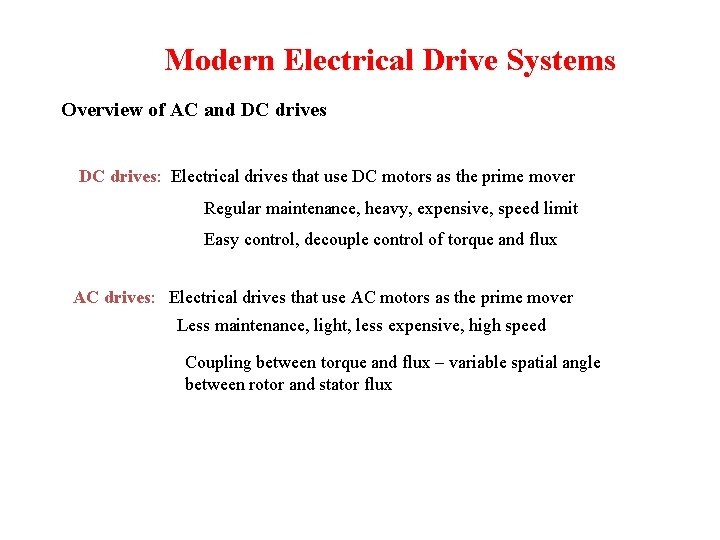
Modern Electrical Drive Systems Overview of AC and DC drives: Electrical drives that use DC motors as the prime mover Regular maintenance, heavy, expensive, speed limit Easy control, decouple control of torque and flux AC drives: Electrical drives that use AC motors as the prime mover Less maintenance, light, less expensive, high speed Coupling between torque and flux – variable spatial angle between rotor and stator flux
Modern Electrical Drive Systems Overview of AC and DC drives Before semiconductor devices were introduced (<1950) • AC motors for fixed speed applications • DC motors for variable speed applications After semiconductor devices were introduced (1960 s) • Variable frequency sources available – AC motors in variable speed applications • Coupling between flux and torque control • Application limited to medium performance applications – fans, blowers, compressors – scalar control • High performance applications dominated by DC motors – tractions, elevators, servos, etc
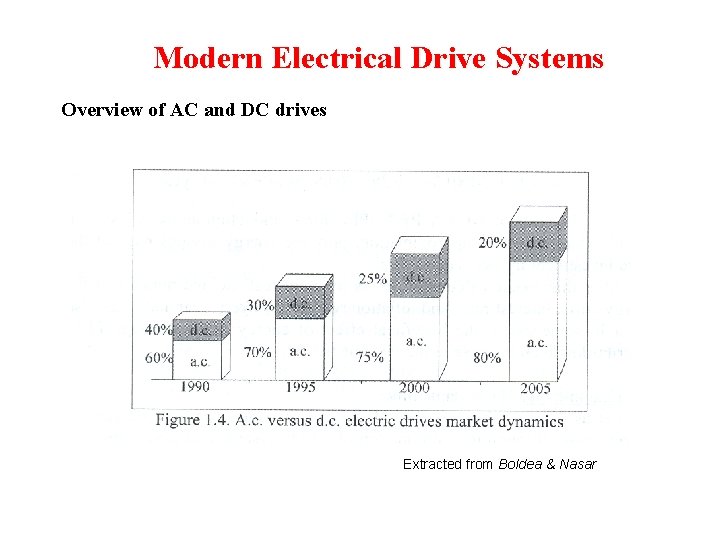
Modern Electrical Drive Systems Overview of AC and DC drives After vector control drives were introduced (1980 s) • AC motors used in high performance applications – elevators, tractions, servos • AC motors favorable than DC motors – however control is complex hence expensive • Cost of microprocessor/semiconductors decreasing –predicted 30 years ago AC motors would take over DC motors
Modern Electrical Drive Systems Overview of AC and DC drives Extracted from Boldea & Nasar
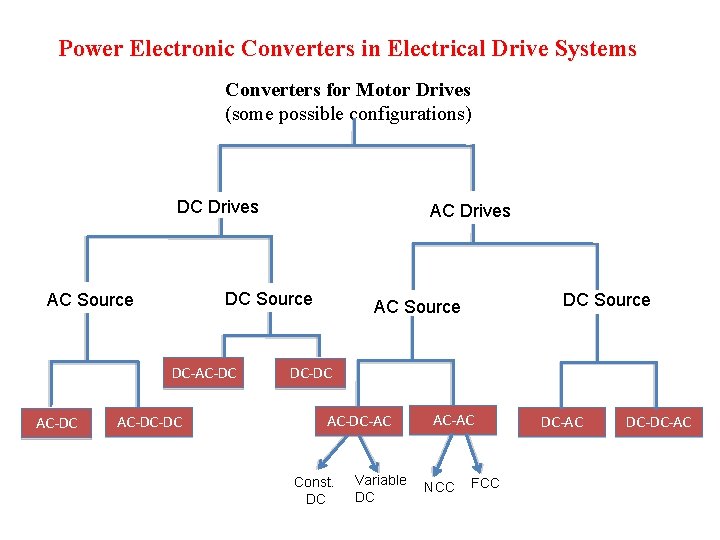
Power Electronic Converters in Electrical Drive Systems Converters for Motor Drives (some possible configurations) DC Drives DC Source AC Source DC-AC-DC AC Drives AC-DC-DC DC Source AC Source DC-DC AC-DC-AC Const. DC Variable DC AC-AC NCC FCC DC-AC DC-DC-AC
Power Electronic Converters in ED Systems Converters for Motor Drives Configurations of Power Electronic Converters depend on: Sources available Type of Motors Drive Performance - applications - Braking - Response - Ratings
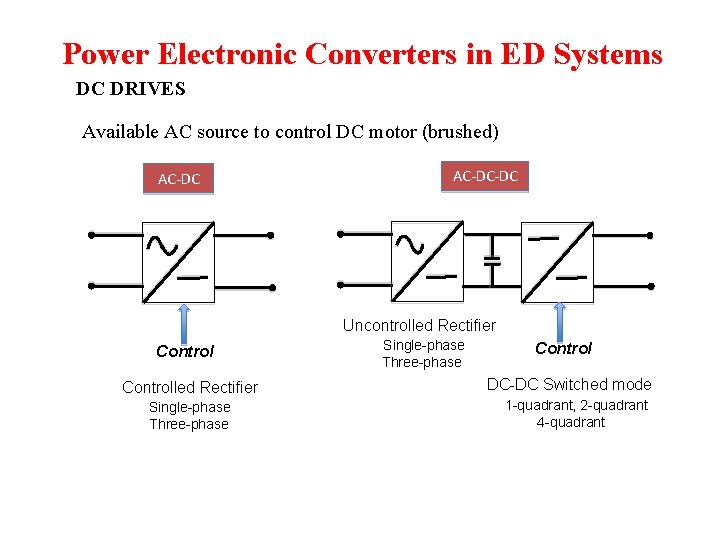
Power Electronic Converters in ED Systems DC DRIVES Available AC source to control DC motor (brushed) AC-DC-DC Uncontrolled Rectifier Controlled Rectifier Single-phase Three-phase Control DC-DC Switched mode 1 -quadrant, 2 -quadrant 4 -quadrant
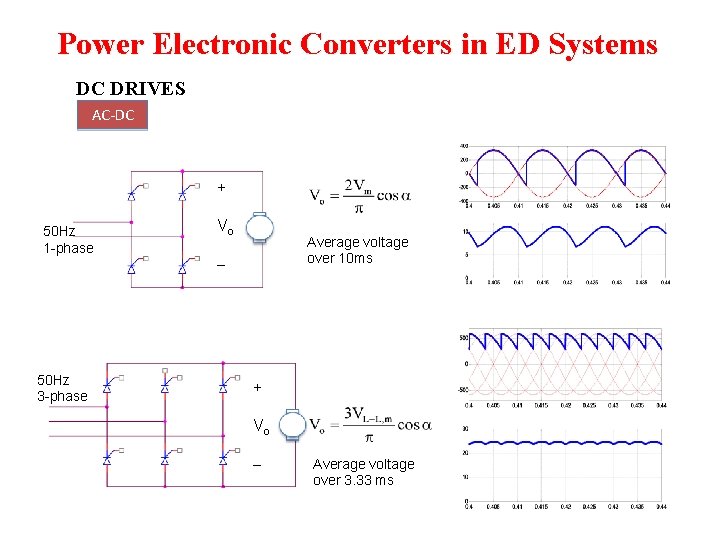
Power Electronic Converters in ED Systems DC DRIVES AC-DC + 50 Hz 1 -phase 50 Hz 3 -phase Vo Average voltage over 10 ms + Vo Average voltage over 3. 33 ms
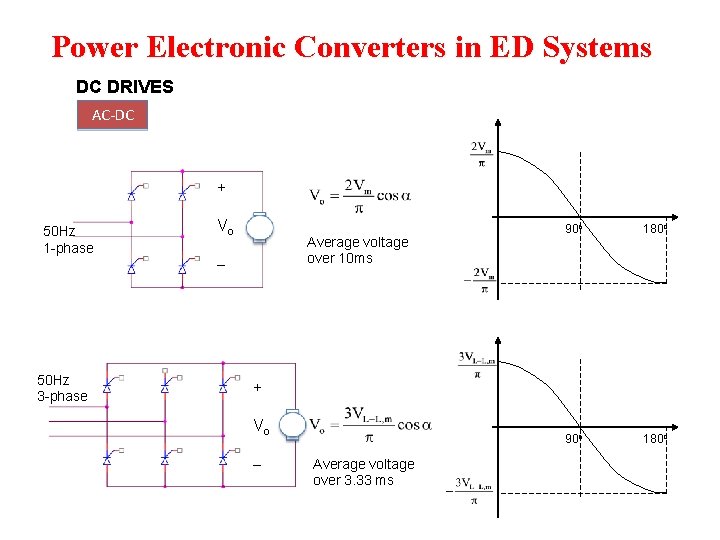
Power Electronic Converters in ED Systems DC DRIVES AC-DC + 50 Hz 1 -phase 50 Hz 3 -phase Vo Average voltage over 10 ms 90 o 180 o + Vo Average voltage over 3. 33 ms
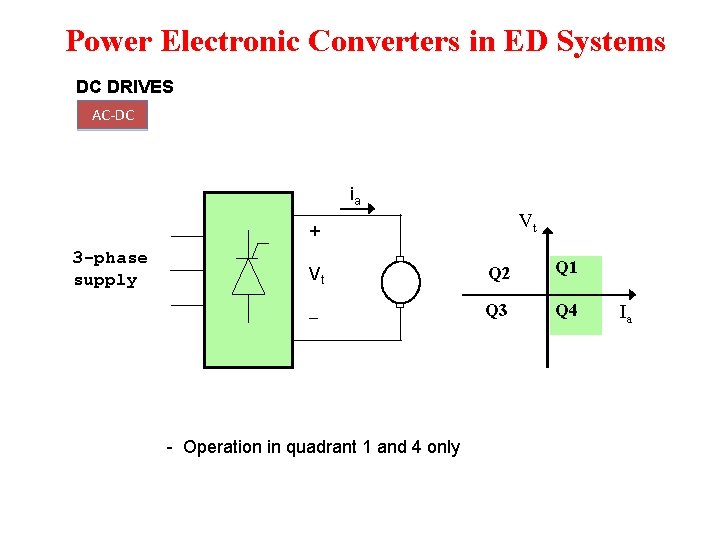
Power Electronic Converters in ED Systems DC DRIVES AC-DC ia Vt + 3 -phase supply Vt Q 2 Q 1 Q 3 Q 4 - Operation in quadrant 1 and 4 only Ia
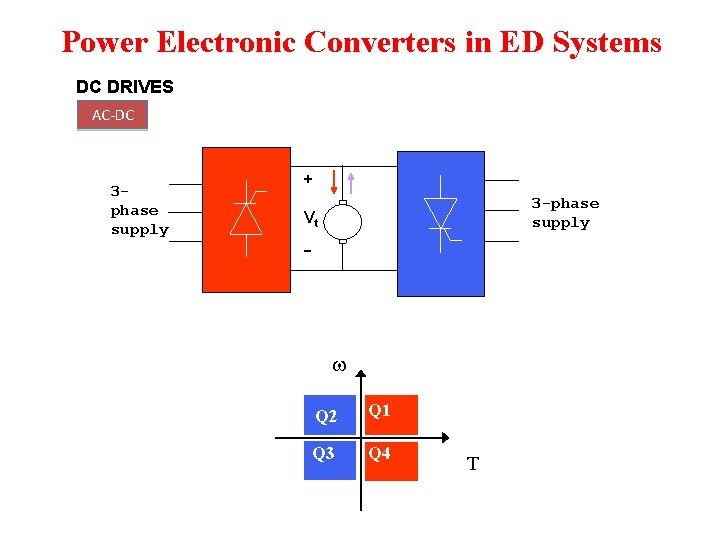
Power Electronic Converters in ED Systems DC DRIVES AC-DC 3 phase supply + 3 -phase supply Vt Q 2 Q 1 Q 3 Q 4 T
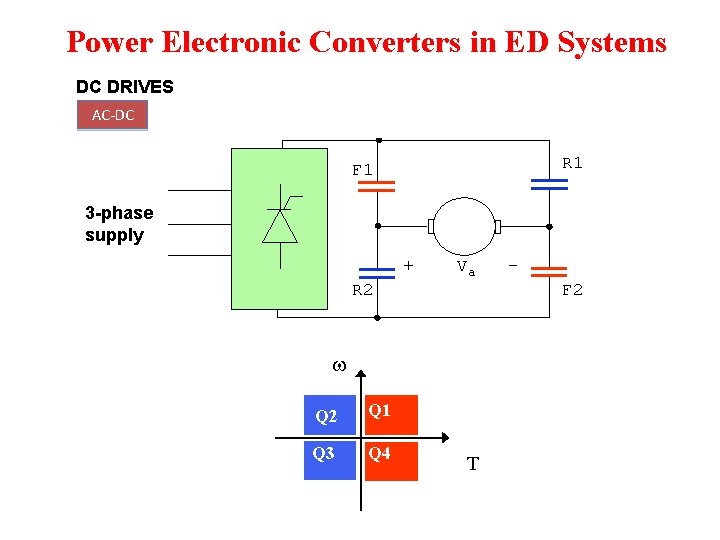
Power Electronic Converters in ED Systems DC DRIVES AC-DC R 1 F 1 3 -phase supply + Va F 2 R 2 Q 2 Q 1 Q 3 Q 4 - T
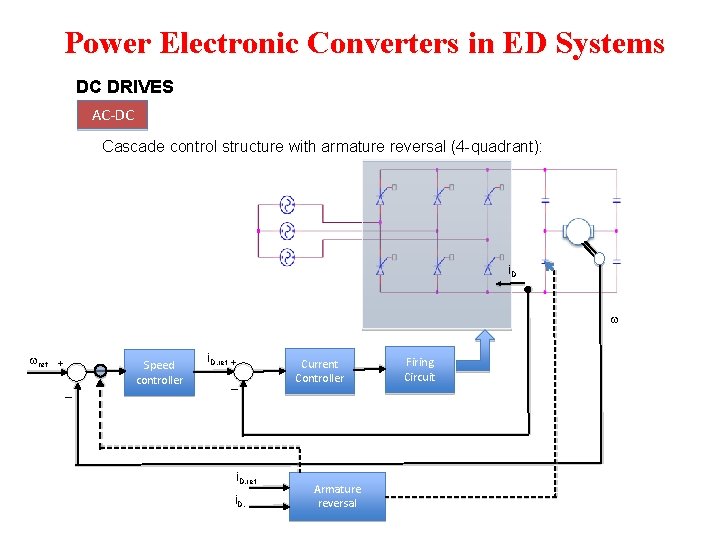
Power Electronic Converters in ED Systems DC DRIVES AC-DC Cascade control structure with armature reversal (4 -quadrant): i. D ref + _ Speed controller i. D, ref + _ i. D, ref i. D, Current Controller Armature reversal Firing Circuit
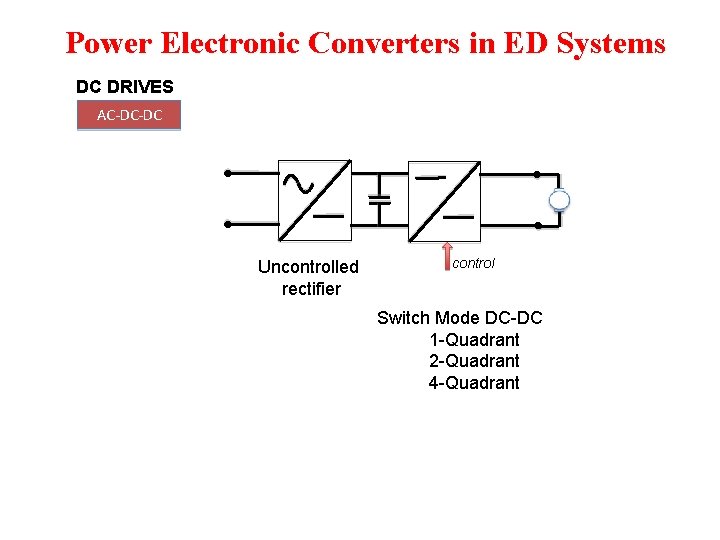
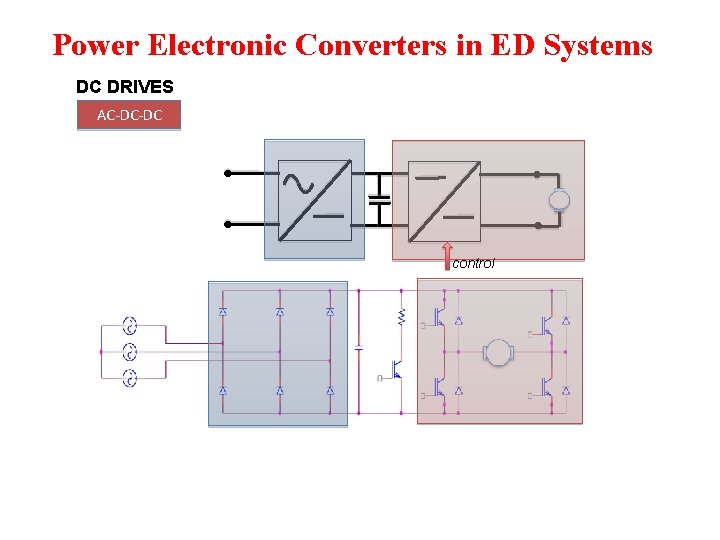
Power Electronic Converters in ED Systems DC DRIVES AC-DC-DC Uncontrolled rectifier control Switch Mode DC-DC 1 -Quadrant 2 -Quadrant 4 -Quadrant
Power Electronic Converters in ED Systems DC DRIVES AC-DC-DC control
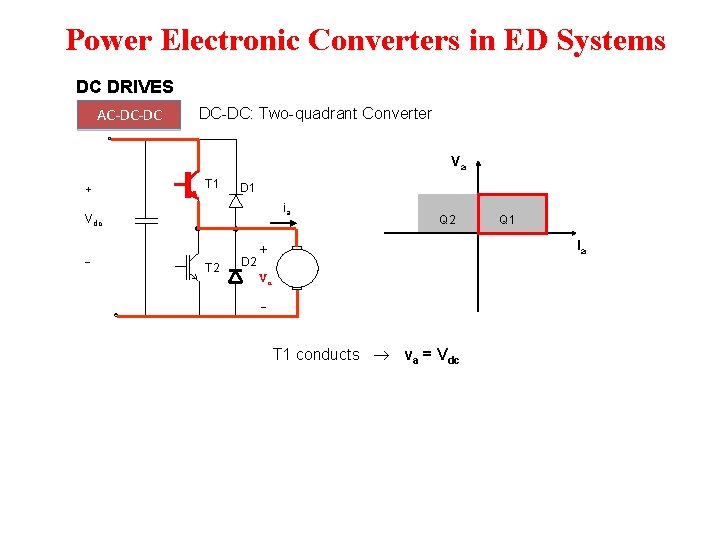
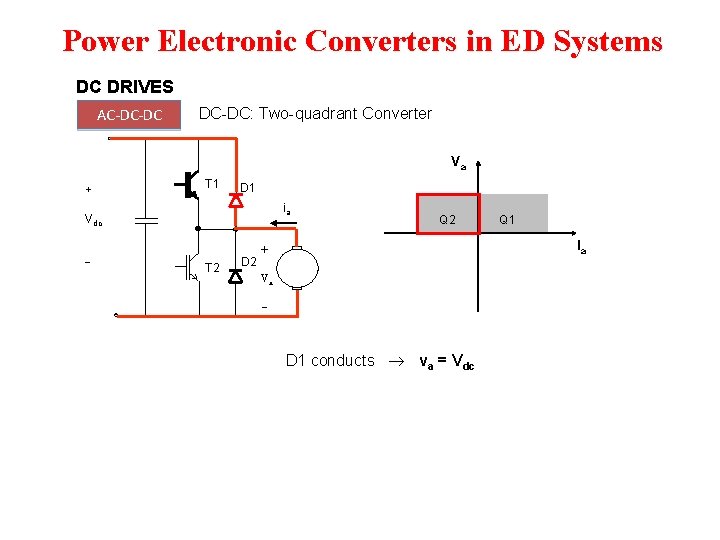
Power Electronic Converters in ED Systems DC DRIVES AC-DC-DC: Two-quadrant Converter Va + T 1 D 1 ia Vdc T 2 D 2 Q 1 Ia + Va - T 1 conducts va = Vdc
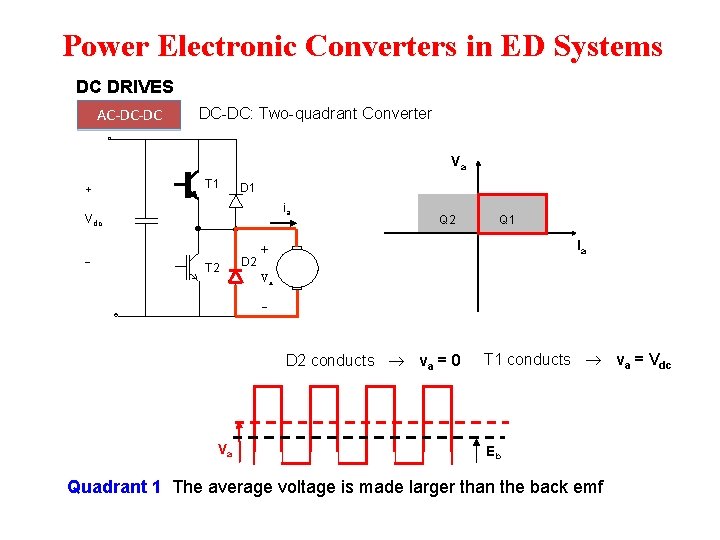
Power Electronic Converters in ED Systems DC DRIVES AC-DC-DC: Two-quadrant Converter Va + T 1 D 1 ia Vdc T 2 D 2 Q 1 Ia + Va - D 2 conducts va = 0 Va T 1 conducts va = Vdc Eb Quadrant 1 The average voltage is made larger than the back emf
Power Electronic Converters in ED Systems DC DRIVES AC-DC-DC: Two-quadrant Converter Va + T 1 D 1 ia Vdc T 2 D 2 Q 1 Ia + Va - D 1 conducts va = Vdc
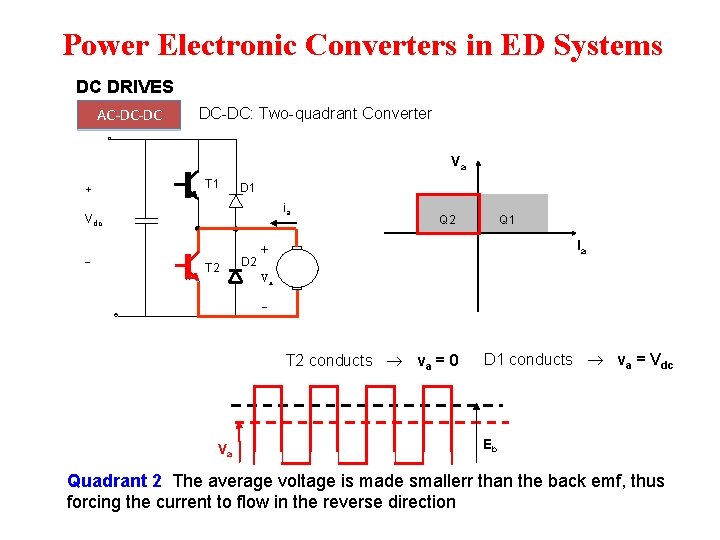
Power Electronic Converters in ED Systems DC DRIVES AC-DC-DC: Two-quadrant Converter Va + T 1 D 1 ia Vdc T 2 D 2 Q 1 Ia + Va - T 2 conducts va = 0 Va D 1 conducts va = Vdc Eb Quadrant 2 The average voltage is made smallerr than the back emf, thus forcing the current to flow in the reverse direction
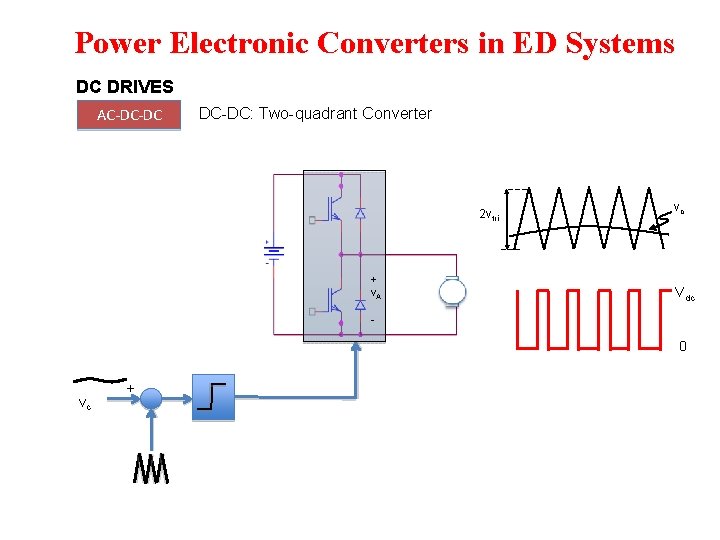
Power Electronic Converters in ED Systems DC DRIVES AC-DC-DC: Two-quadrant Converter 2 vtri + v. A vc Vdc - 0 vc +
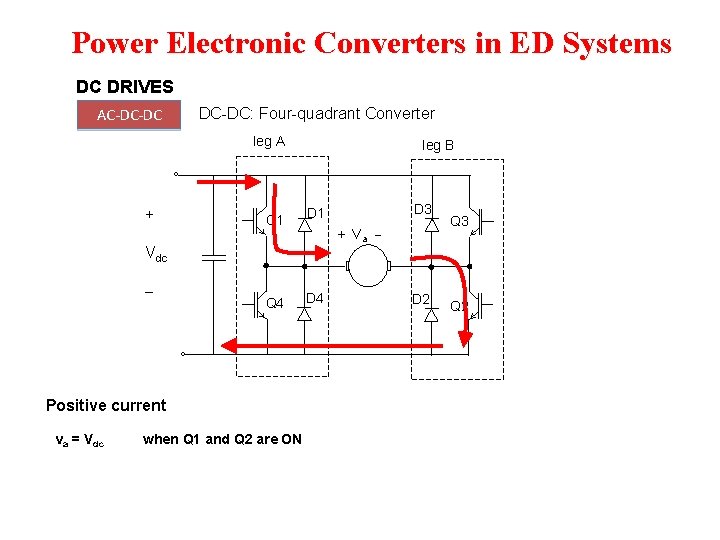
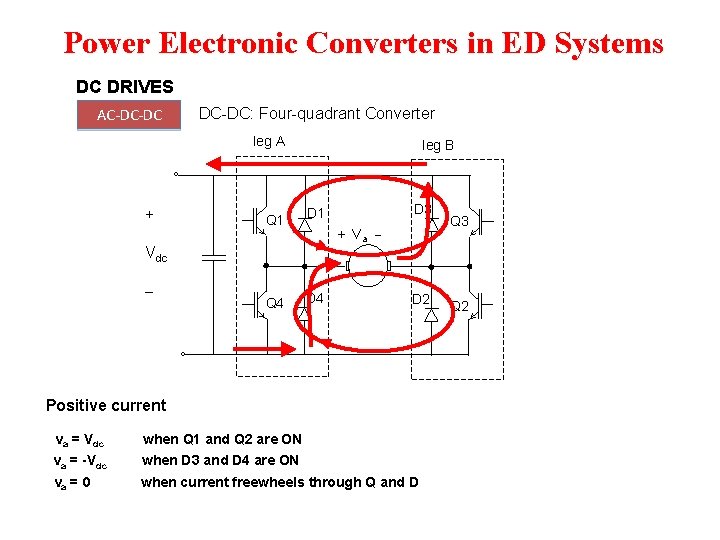
Power Electronic Converters in ED Systems DC DRIVES AC-DC-DC: Four-quadrant Converter leg A + Q 1 leg B + Va Vdc Q 4 Positive current va = Vdc when Q 1 and Q 2 are ON D 3 D 1 D 4 D 2 Q 3 Q 2
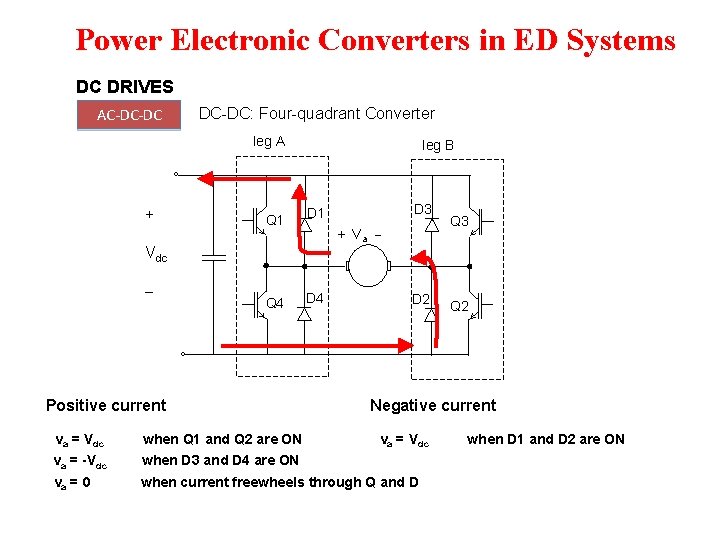
Power Electronic Converters in ED Systems DC DRIVES AC-DC-DC: Four-quadrant Converter leg A + Q 1 leg B + Va Vdc Q 4 D 3 D 1 D 4 D 2 Positive current va = Vdc when Q 1 and Q 2 are ON va = -Vdc when D 3 and D 4 are ON va = 0 when current freewheels through Q and D Q 3 Q 2
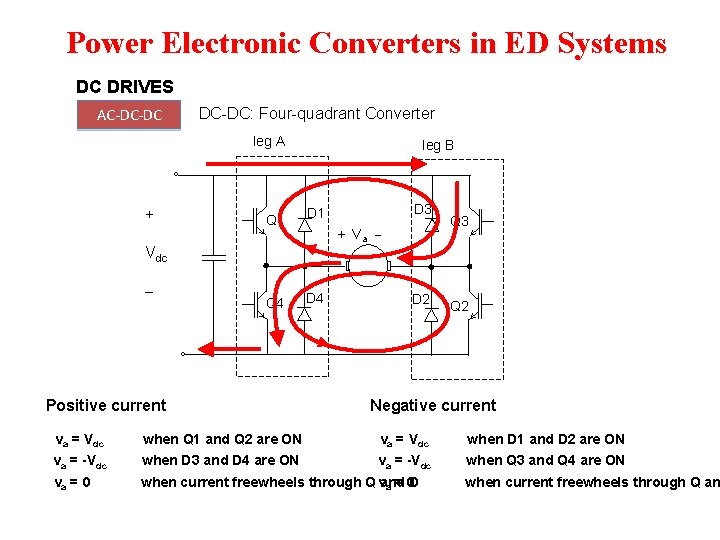
Power Electronic Converters in ED Systems DC DRIVES AC-DC-DC: Four-quadrant Converter leg A + Q 1 leg B + Va Vdc Q 4 Positive current D 3 D 1 D 4 D 2 Q 3 Q 2 Negative current va = Vdc when Q 1 and Q 2 are ON va = Vdc va = -Vdc when D 3 and D 4 are ON va = 0 when current freewheels through Q and D when D 1 and D 2 are ON
Power Electronic Converters in ED Systems DC DRIVES AC-DC-DC: Four-quadrant Converter leg A + Q 1 leg B + Va Vdc Q 4 Positive current D 3 D 1 D 4 D 2 Q 3 Q 2 Negative current va = Vdc when Q 1 and Q 2 are ON va = Vdc when D 1 and D 2 are ON va = -Vdc when D 3 and D 4 are ON va = -Vdc when Q 3 and Q 4 are ON va = 0 when current freewheels through Q vand D a = 0 when current freewheels through Q an
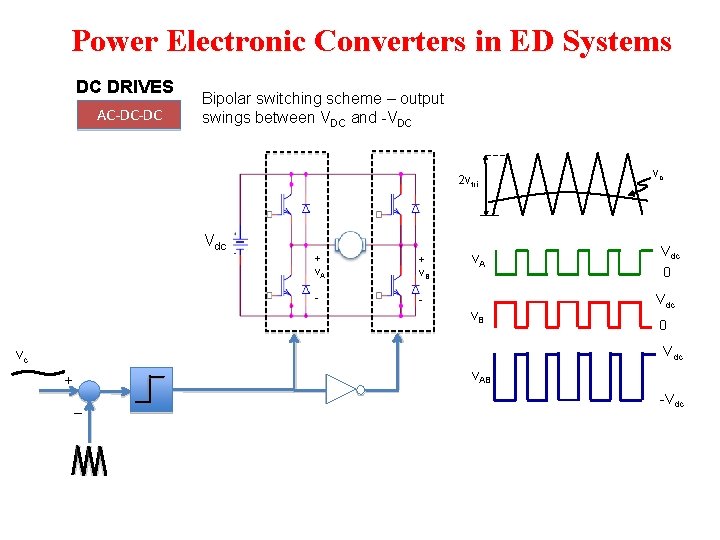
Power Electronic Converters in ED Systems DC DRIVES AC-DC-DC Bipolar switching scheme – output swings between VDC and -VDC 2 vtri Vdc + v. A + v. B - - v. A v. B vc Vdc 0 Vdc vc v. AB + _ -Vdc
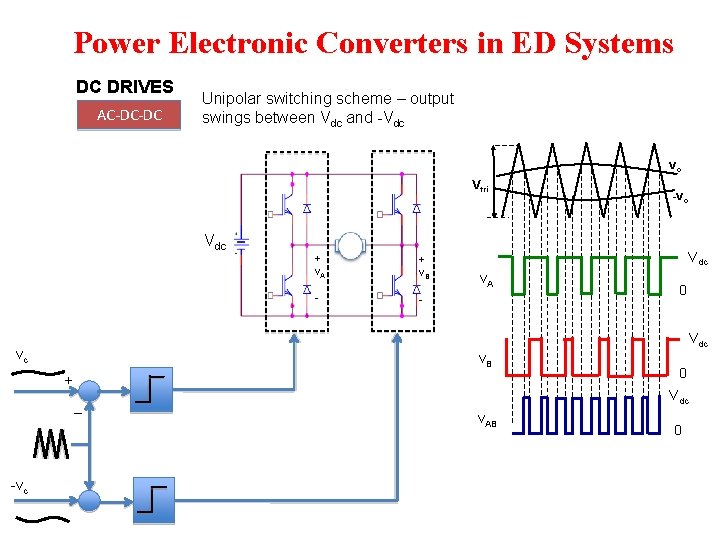
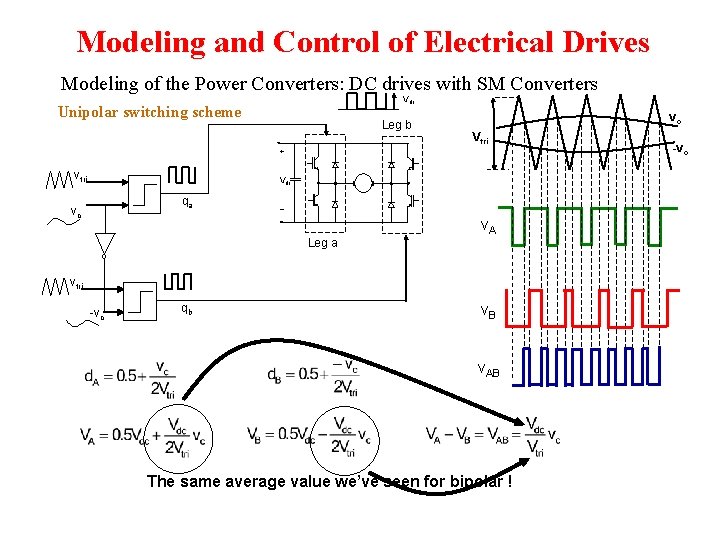
Power Electronic Converters in ED Systems DC DRIVES AC-DC-DC Unipolar switching scheme – output swings between Vdc and -Vdc vc Vtri Vdc + v. A + v. B - - Vdc v. A 0 Vdc vc v. B + _ -vc 0 Vdc v. AB 0
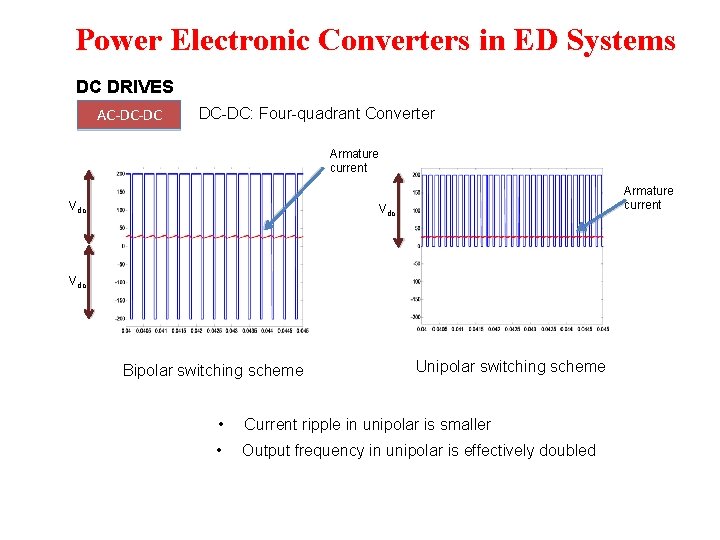
Power Electronic Converters in ED Systems DC DRIVES AC-DC-DC: Four-quadrant Converter Armature current Vdc Vdc Bipolar switching scheme Unipolar switching scheme • Current ripple in unipolar is smaller • Output frequency in unipolar is effectively doubled
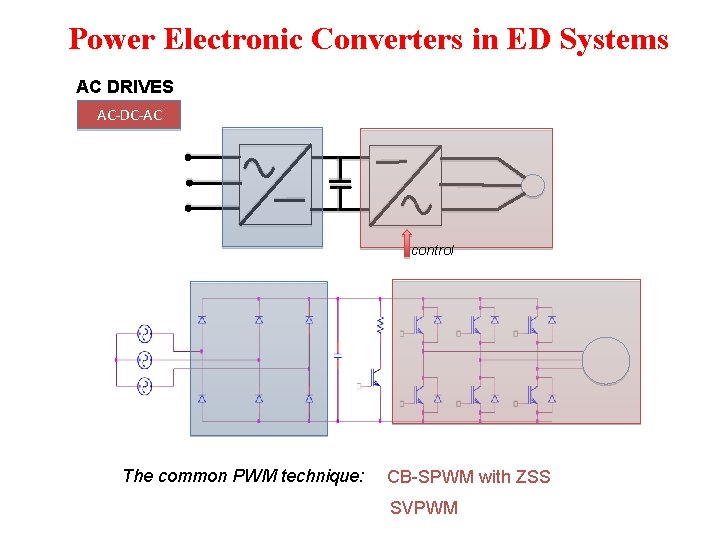
Power Electronic Converters in ED Systems AC DRIVES AC-DC-AC control The common PWM technique: CB-SPWM with ZSS SVPWM
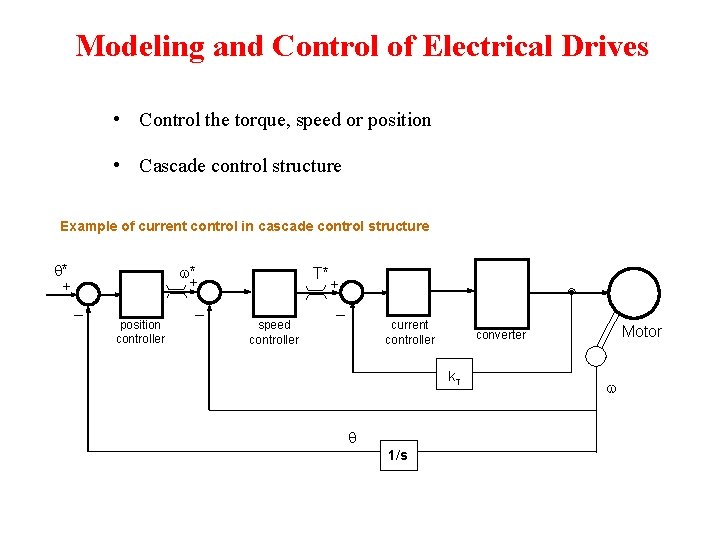
Modeling and Control of Electrical Drives • Control the torque, speed or position • Cascade control structure Example of current control in cascade control structure * + position controller T* speed controller + current controller k. T 1/s Motor converter
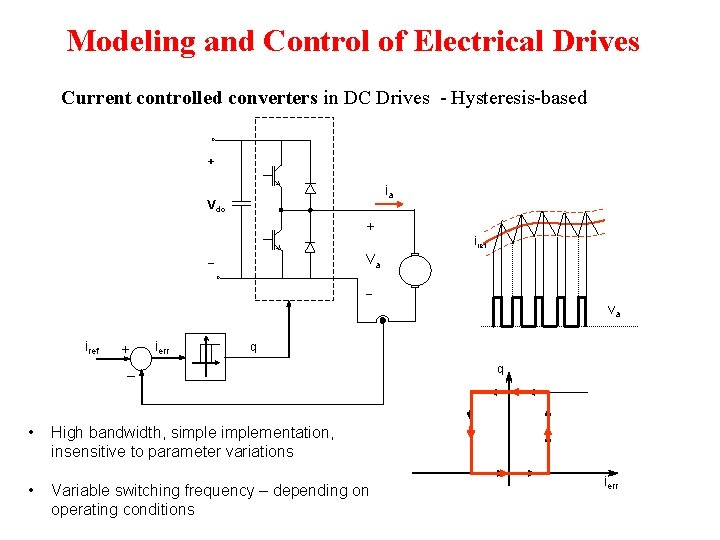
Modeling and Control of Electrical Drives Current controlled converters in DC Drives - Hysteresis-based + ia Vdc + iref Va − iref + _ ierr va q • High bandwidth, simplementation, insensitive to parameter variations • Variable switching frequency – depending on operating conditions q ierr
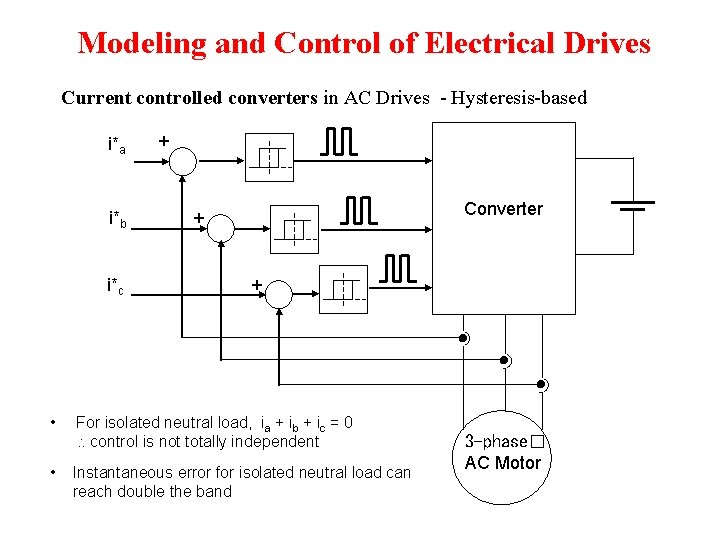
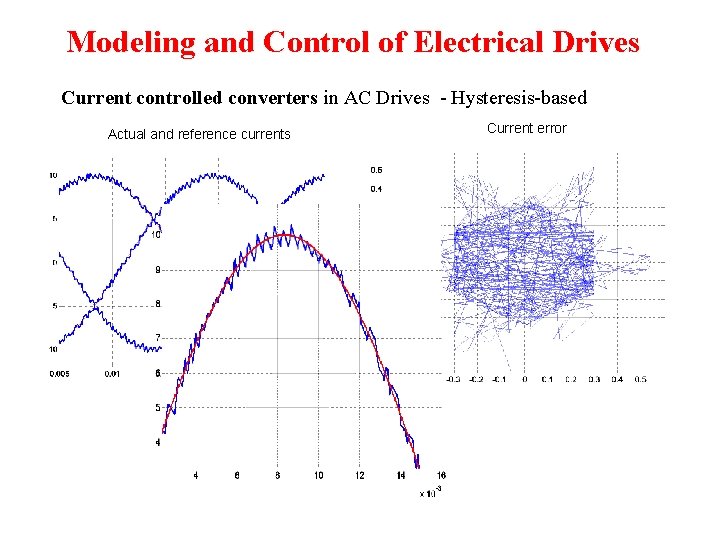
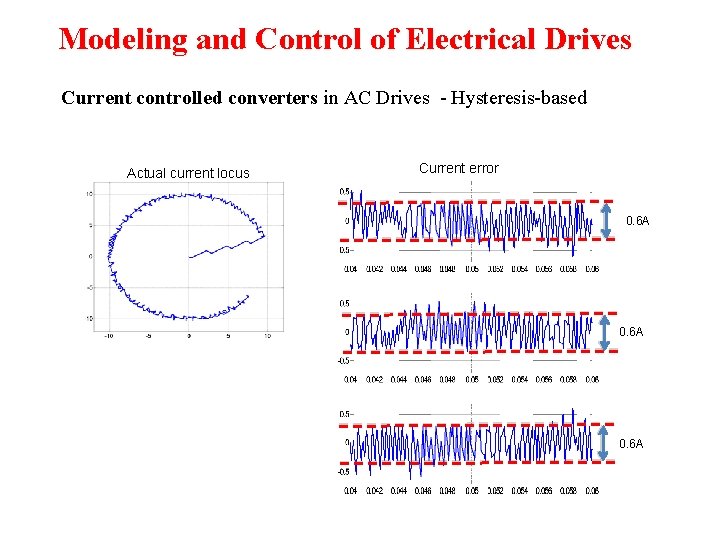
Modeling and Control of Electrical Drives Current controlled converters in AC Drives - Hysteresis-based i*a i*b i*c • • + Converter + + For isolated neutral load, ia + ib + ic = 0 control is not totally independent Instantaneous error for isolated neutral load can reach double the band 3 -phase� AC Motor
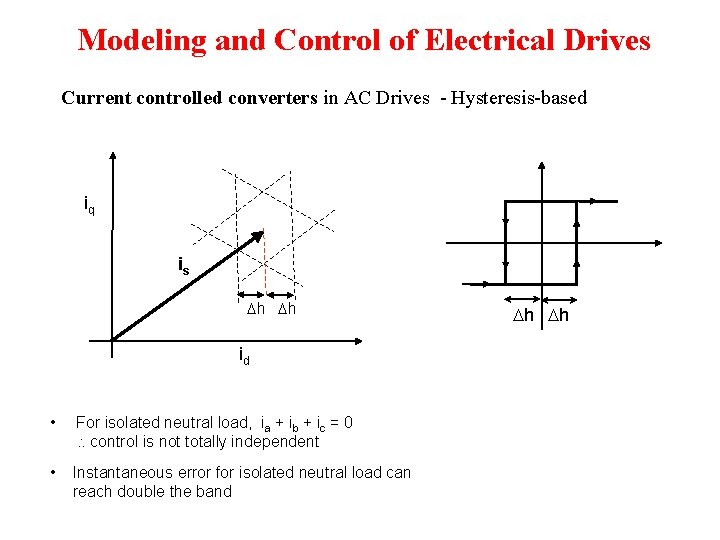
Modeling and Control of Electrical Drives Current controlled converters in AC Drives - Hysteresis-based iq is Dh Dh id • For isolated neutral load, ia + ib + ic = 0 control is not totally independent • Instantaneous error for isolated neutral load can reach double the band Dh Dh
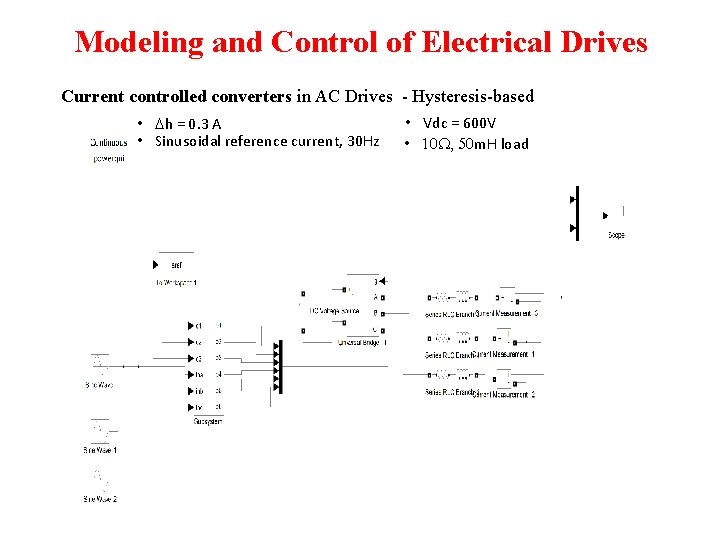
Modeling and Control of Electrical Drives Current controlled converters in AC Drives - Hysteresis-based • Dh = 0. 3 A • Sinusoidal reference current, 30 Hz • Vdc = 600 V • 10 , 50 m. H load
Modeling and Control of Electrical Drives Current controlled converters in AC Drives - Hysteresis-based Actual and reference currents Current error
Modeling and Control of Electrical Drives Current controlled converters in AC Drives - Hysteresis-based Actual current locus Current error 0. 6 A
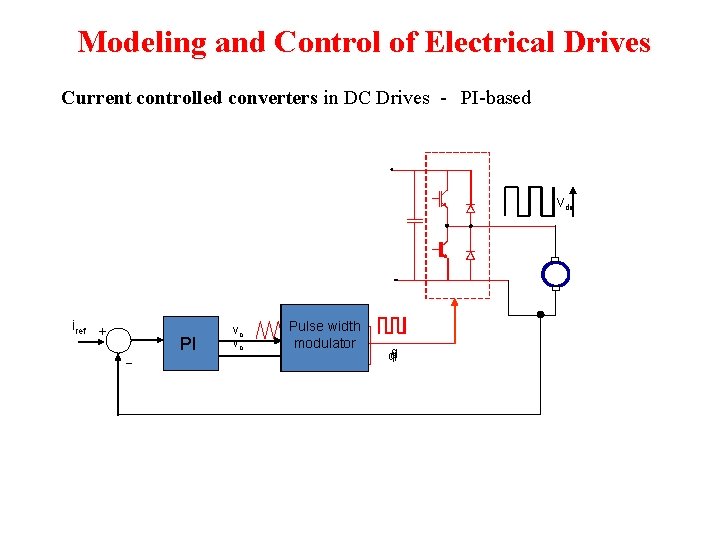
Modeling and Control of Electrical Drives Current controlled converters in DC Drives - PI-based Vdc iref + PI vc vc v. Pulse width tri modulator qqq
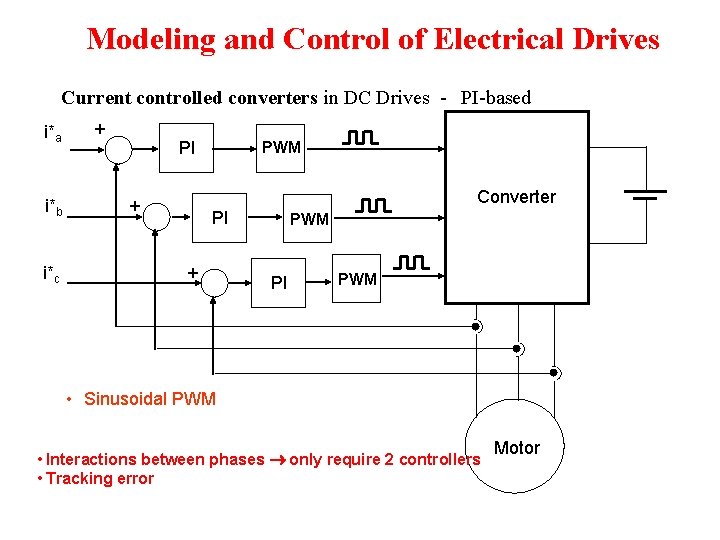
Modeling and Control of Electrical Drives Current controlled converters in DC Drives - PI-based i*a i*b i*c + PI PWM Converter + PI + PWM PI PWM • Sinusoidal PWM • Interactions between phases only require 2 controllers • Tracking error Motor
Modeling and Control of Electrical Drives Current controlled converters in DC Drives - PI-based • Perform the 3 -phase to 2 -phase transformation - only two controllers (instead of 3) are used • Perform the control in synchronous frame - the current will appear as DC • Interactions between phases only require 2 controllers • Tracking error
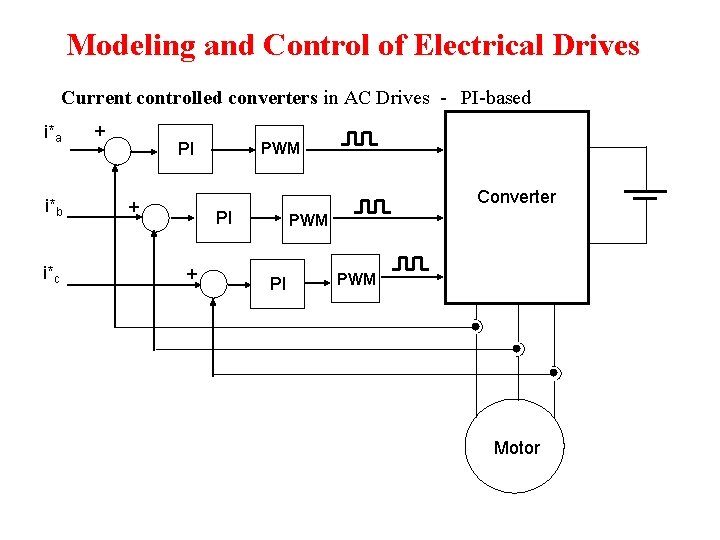
Modeling and Control of Electrical Drives Current controlled converters in AC Drives - PI-based i*a i*b i*c + PI PWM Converter + PI + PWM PI PWM Motor
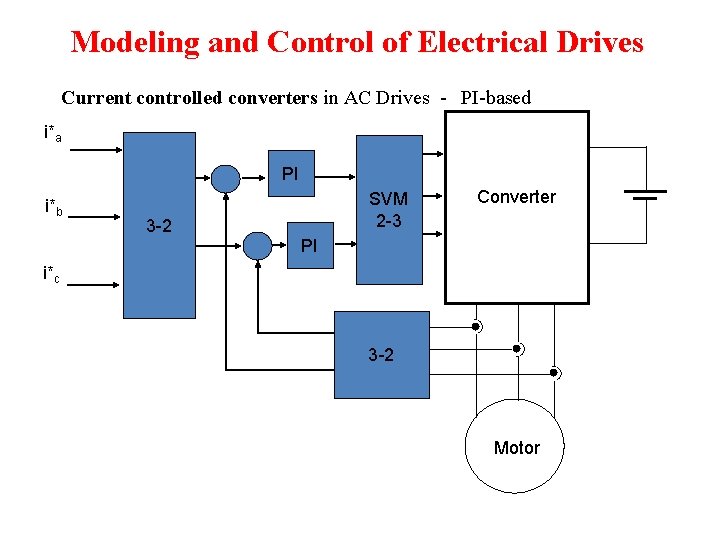
Modeling and Control of Electrical Drives Current controlled converters in AC Drives - PI-based i*a PI i*b 3 -2 SVM 2 -3 Converter PI i*c 3 -2 Motor
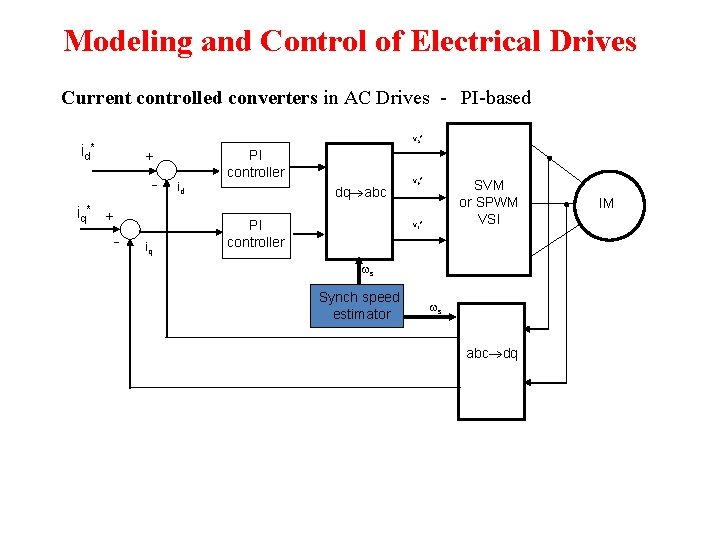
Modeling and Control of Electrical Drives Current controlled converters in AC Drives - PI-based va* id * PI controller + iq * + iq id dq abc PI controller vb* SVM or SPWM VSI vc* s Synch speed estimator s abc dq IM
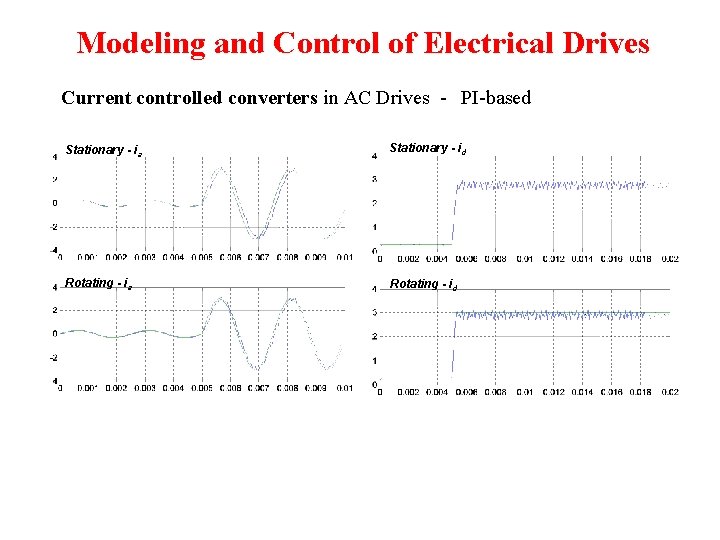
Modeling and Control of Electrical Drives Current controlled converters in AC Drives - PI-based Stationary - ia Stationary - id Rotating - ia Rotating - id
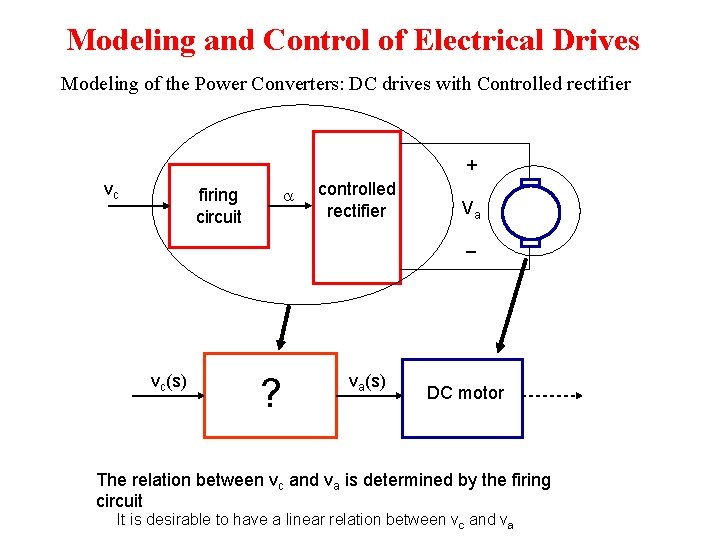
Modeling and Control of Electrical Drives Modeling of the Power Converters: DC drives with Controlled rectifier + vc firing circuit controlled rectifier Va – vc(s) ? va(s) DC motor The relation between vc and va is determined by the firing circuit It is desirable to have a linear relation between vc and va
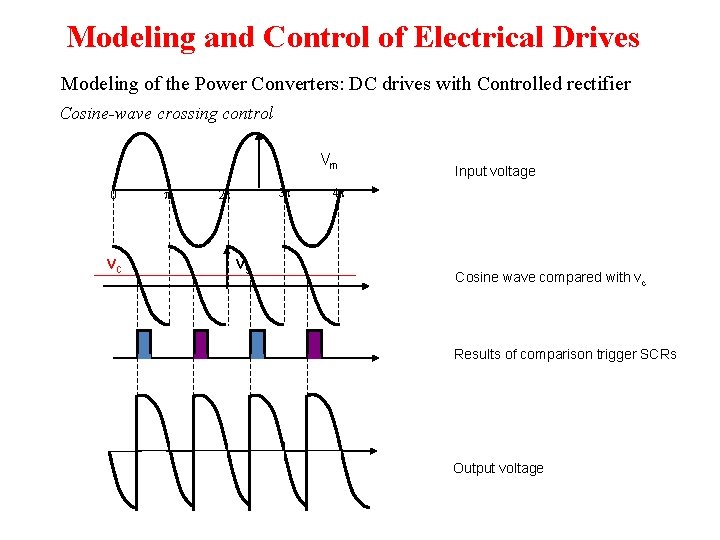
Modeling and Control of Electrical Drives Modeling of the Power Converters: DC drives with Controlled rectifier Cosine-wave crossing control Vm 0 vc 3 2 vs Input voltage 4 Cosine wave compared with vc Results of comparison trigger SCRs Output voltage
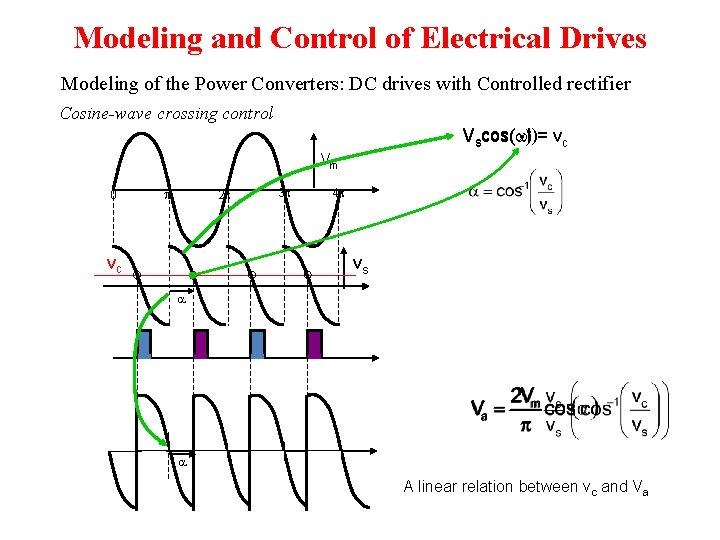
Modeling and Control of Electrical Drives Modeling of the Power Converters: DC drives with Controlled rectifier Cosine-wave crossing control cos( t)= vc Vscos( ) Vm 0 2 vc 3 4 vs A linear relation between vc and Va
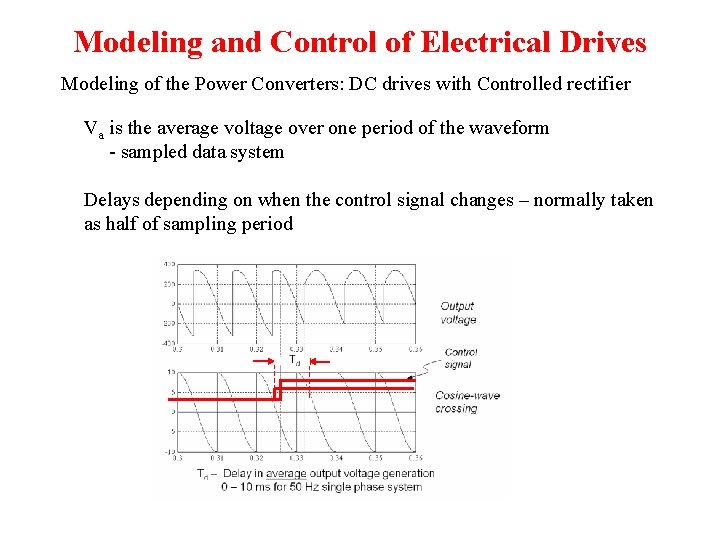
Modeling and Control of Electrical Drives Modeling of the Power Converters: DC drives with Controlled rectifier Va is the average voltage over one period of the waveform - sampled data system Delays depending on when the control signal changes – normally taken as half of sampling period
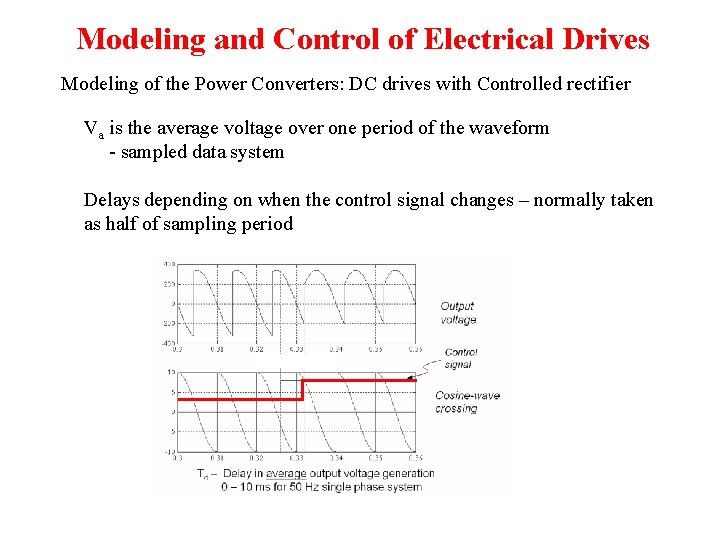
Modeling and Control of Electrical Drives Modeling of the Power Converters: DC drives with Controlled rectifier Va is the average voltage over one period of the waveform - sampled data system Delays depending on when the control signal changes – normally taken as half of sampling period
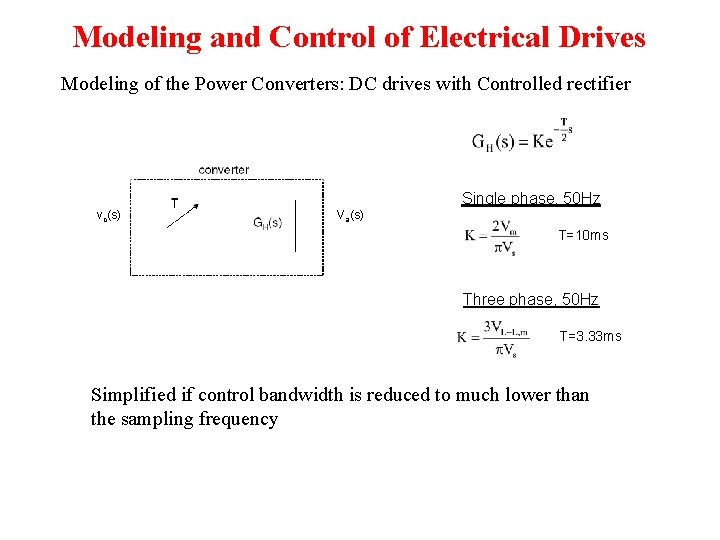
Modeling and Control of Electrical Drives Modeling of the Power Converters: DC drives with Controlled rectifier Single phase, 50 Hz vc(s) Va(s) T=10 ms Three phase, 50 Hz T=3. 33 ms Simplified if control bandwidth is reduced to much lower than the sampling frequency
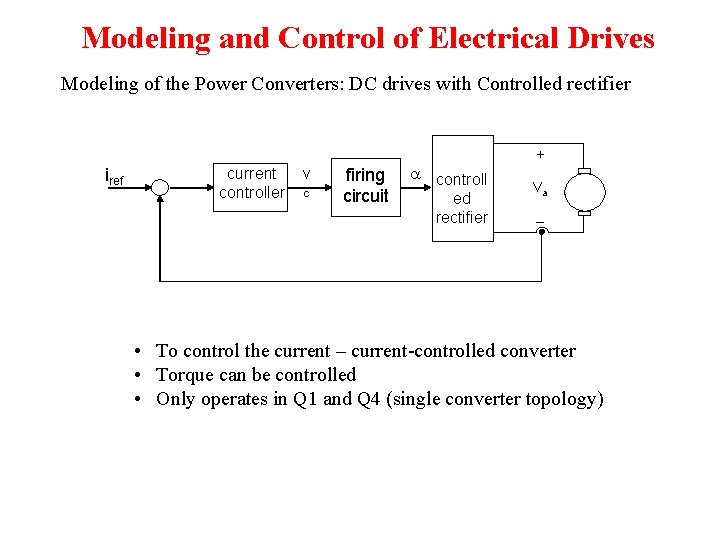
Modeling and Control of Electrical Drives Modeling of the Power Converters: DC drives with Controlled rectifier + iref current controller v c firing circuit controll ed rectifier Va – • To control the current – current-controlled converter • Torque can be controlled • Only operates in Q 1 and Q 4 (single converter topology)
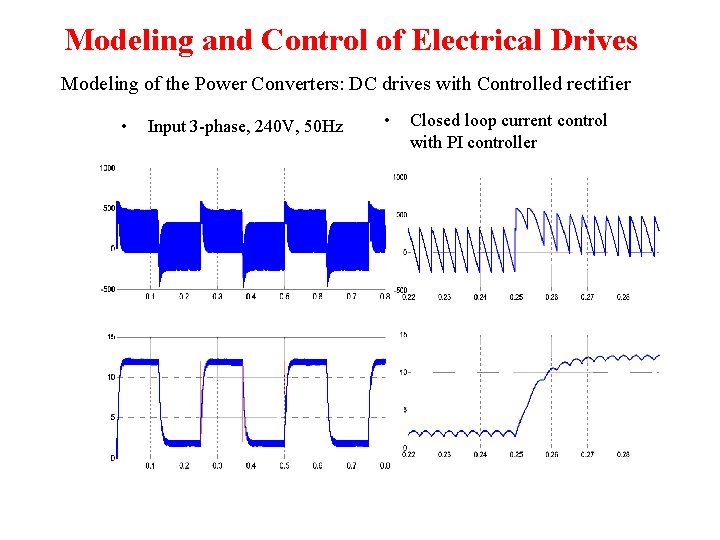
Modeling and Control of Electrical Drives Modeling of the Power Converters: DC drives with Controlled rectifier • Input 3 -phase, 240 V, 50 Hz • Closed loop current control with PI controller
Modeling and Control of Electrical Drives Modeling of the Power Converters: DC drives with Controlled rectifier • Input 3 -phase, 240 V, 50 Hz • Closed loop current control with PI controller Voltage Current
Modeling and Control of Electrical Drives Modeling of the Power Converters: DC drives with SM Converters
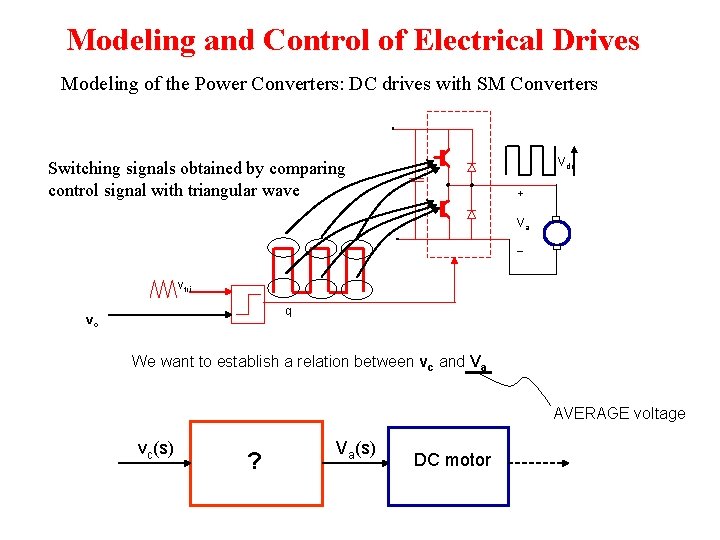
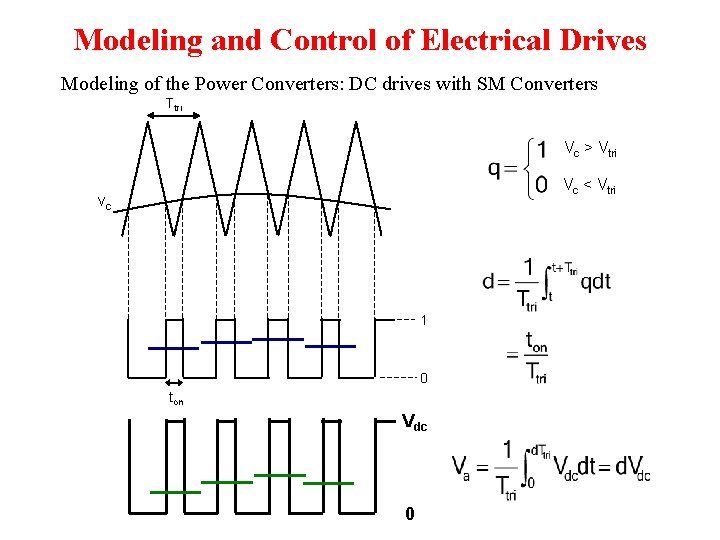
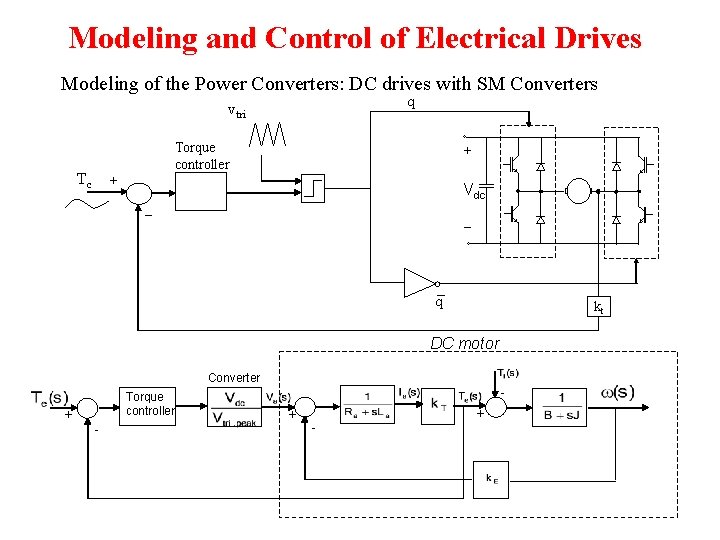
Modeling and Control of Electrical Drives Modeling of the Power Converters: DC drives with SM Converters Vdc Switching signals obtained by comparing control signal with triangular wave + Va − vtri q vc We want to establish a relation between vc and Va AVERAGE voltage vc(s) ? Va(s) DC motor
Modeling and Control of Electrical Drives Modeling of the Power Converters: DC drives with SM Converters Ttri Vc > Vtri Vc < Vtri vc 1 0 ton Vdc 0
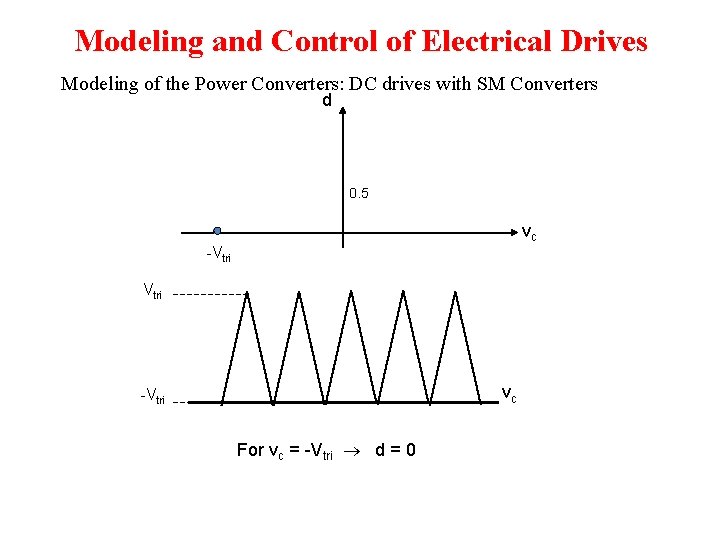
Modeling and Control of Electrical Drives Modeling of the Power Converters: DC drives with SM Converters d 0. 5 vc -Vtri For vc = -Vtri d = 0
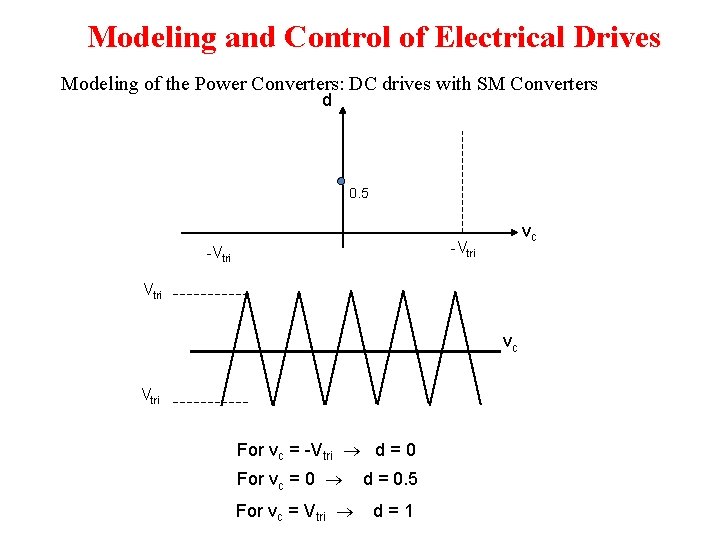
Modeling and Control of Electrical Drives Modeling of the Power Converters: DC drives with SM Converters d 0. 5 vc -Vtri vc Vtri For vc = -Vtri d = 0 For vc = 0 d = 0. 5 For vc = Vtri d=1
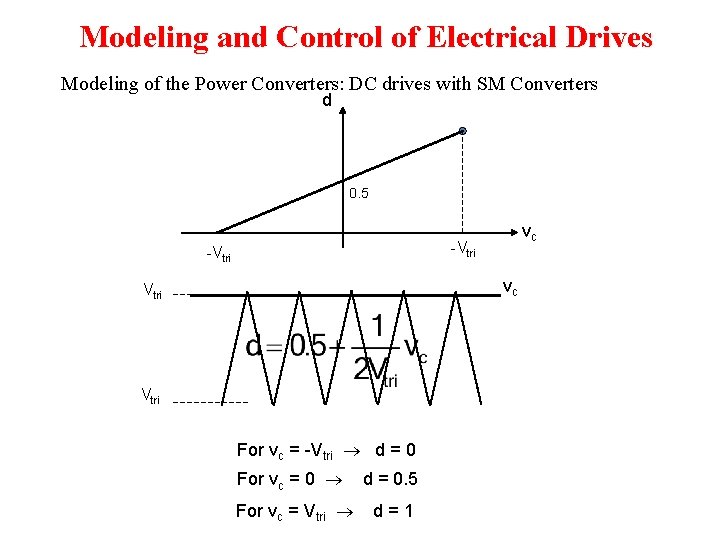
Modeling and Control of Electrical Drives Modeling of the Power Converters: DC drives with SM Converters d 0. 5 vc -Vtri vc Vtri For vc = -Vtri d = 0 For vc = 0 d = 0. 5 For vc = Vtri d=1
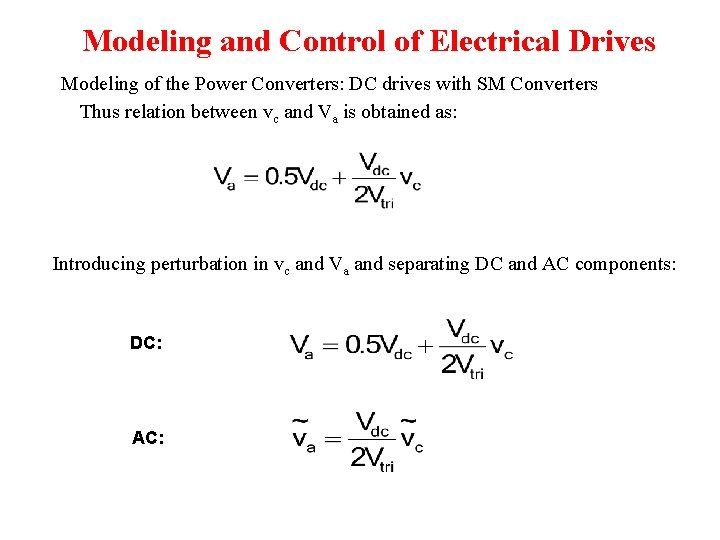
Modeling and Control of Electrical Drives Modeling of the Power Converters: DC drives with SM Converters Thus relation between vc and Va is obtained as: Introducing perturbation in vc and Va and separating DC and AC components: DC: AC:
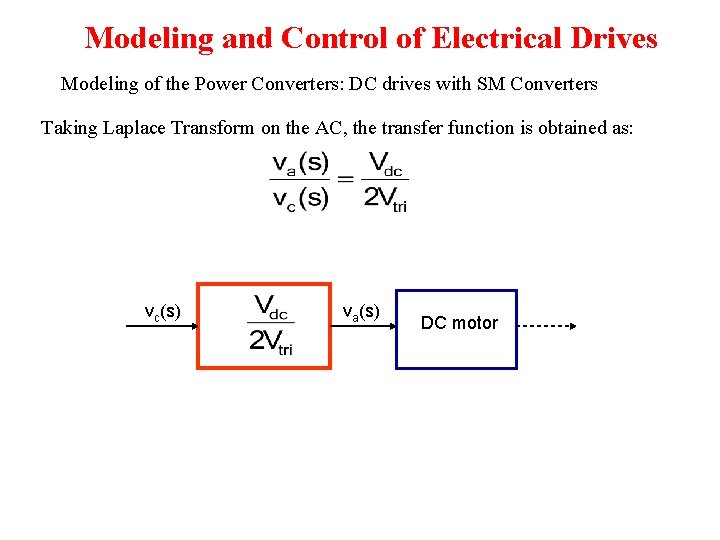
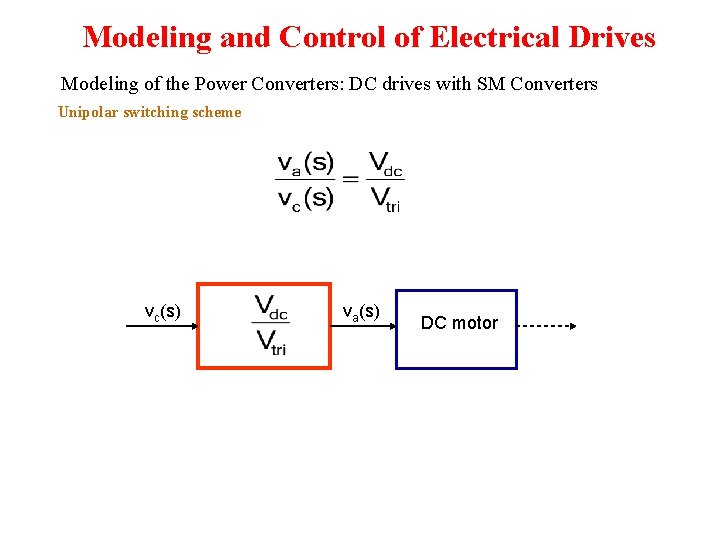
Modeling and Control of Electrical Drives Modeling of the Power Converters: DC drives with SM Converters Taking Laplace Transform on the AC, the transfer function is obtained as: vc(s) va(s) DC motor
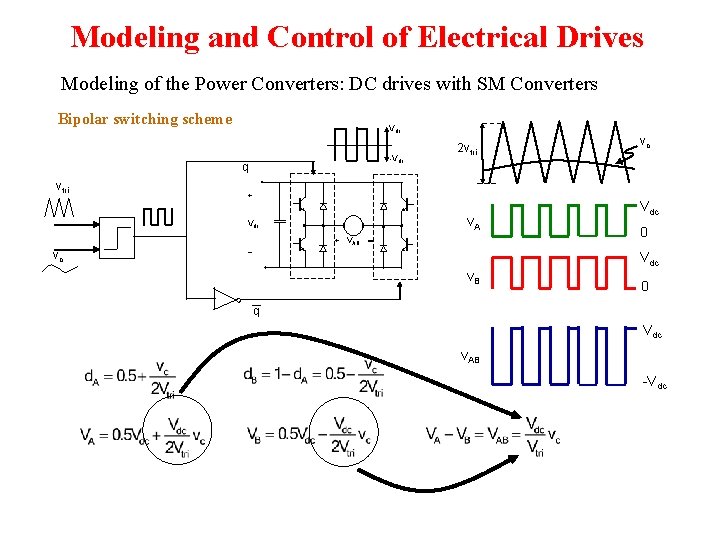
Modeling and Control of Electrical Drives Modeling of the Power Converters: DC drives with SM Converters Bipolar switching scheme Vdc -Vdc q vtri + v. A Vdc + VAB vc 2 vtri − vc Vdc 0 Vdc v. B 0 q Vdc v. AB -Vdc
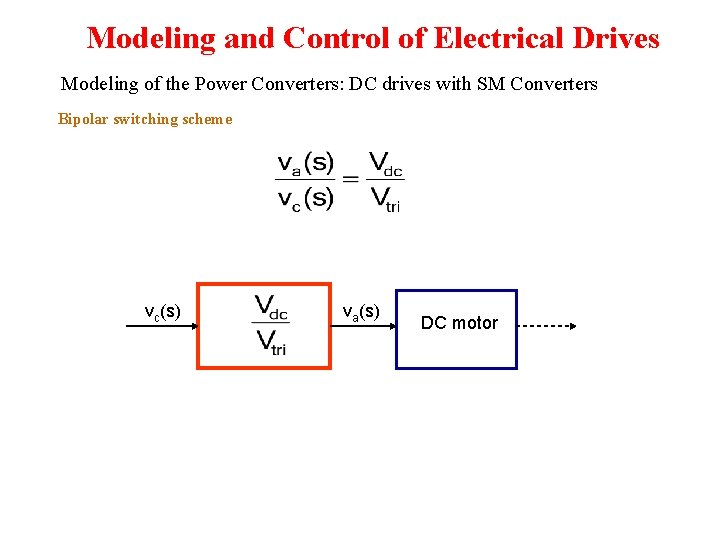
Modeling and Control of Electrical Drives Modeling of the Power Converters: DC drives with SM Converters Bipolar switching scheme vc(s) va(s) DC motor
Modeling and Control of Electrical Drives Modeling of the Power Converters: DC drives with SM Converters Vdc Unipolar switching scheme Leg b vc Vtri + vtri Vdc qa vc − Leg a v. A vtri -vc qb v. B v. AB The same average value we’ve seen for bipolar ! -vc
Modeling and Control of Electrical Drives Modeling of the Power Converters: DC drives with SM Converters Unipolar switching scheme vc(s) va(s) DC motor
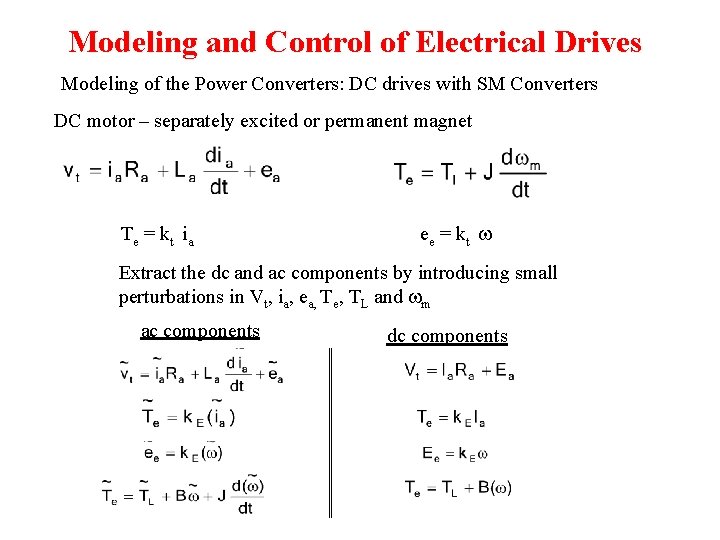
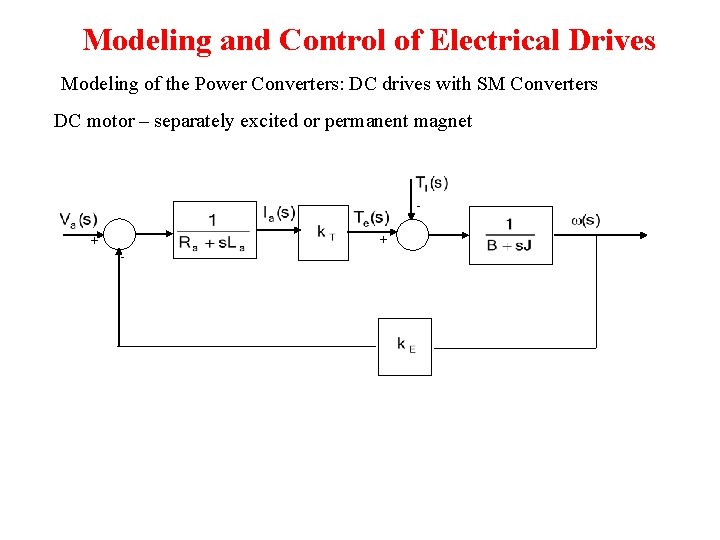
Modeling and Control of Electrical Drives Modeling of the Power Converters: DC drives with SM Converters DC motor – separately excited or permanent magnet Te = kt ia ee = kt Extract the dc and ac components by introducing small perturbations in Vt, ia, ea, Te, TL and m ac components dc components
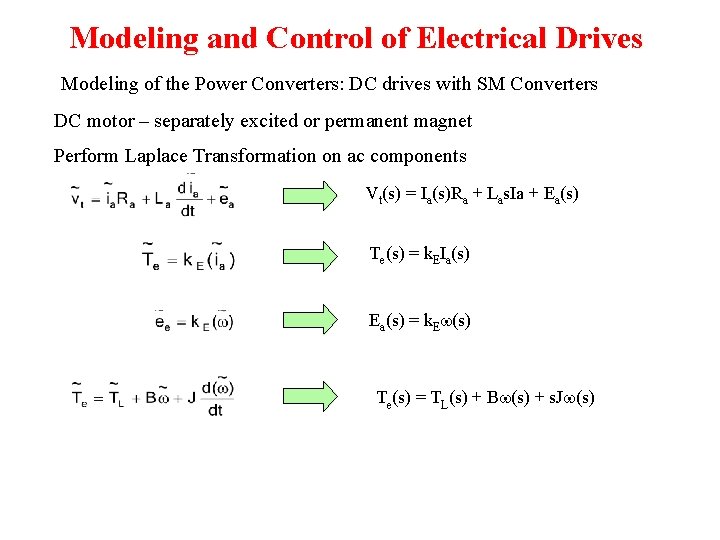
Modeling and Control of Electrical Drives Modeling of the Power Converters: DC drives with SM Converters DC motor – separately excited or permanent magnet Perform Laplace Transformation on ac components Vt(s) = Ia(s)Ra + Las. Ia + Ea(s) Te(s) = k. EIa(s) Ea(s) = k. E (s) Te(s) = TL(s) + B (s) + s. J (s)
Modeling and Control of Electrical Drives Modeling of the Power Converters: DC drives with SM Converters DC motor – separately excited or permanent magnet + + -
Modeling and Control of Electrical Drives Modeling of the Power Converters: DC drives with SM Converters q vtri Torque controller Tc + + Vdc – − q kt DC motor Converter Torque controller + - +
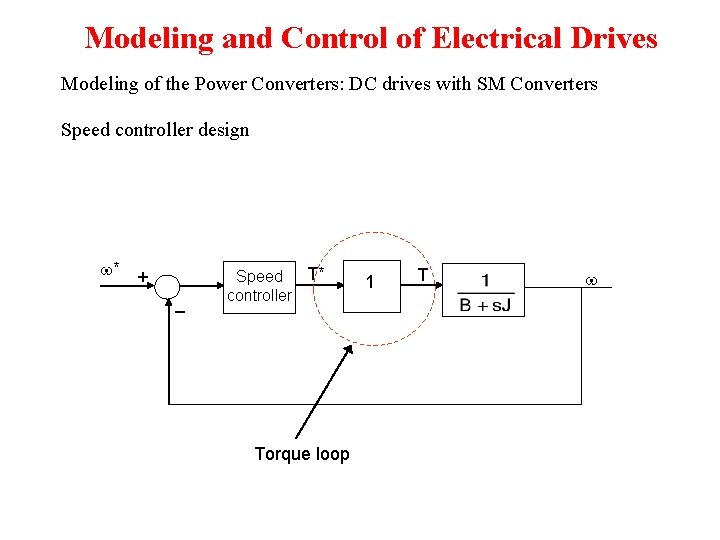
Modeling and Control of Electrical Drives Modeling of the Power Converters: DC drives with SM Converters Closed-loop speed control – an example Design procedure in cascade control structure • Inner loop (current or torque loop) the fastest – largest bandwidth • The outer most loop (position loop) the slowest – smallest bandwidth • Design starts from torque loop proceed towards outer loops
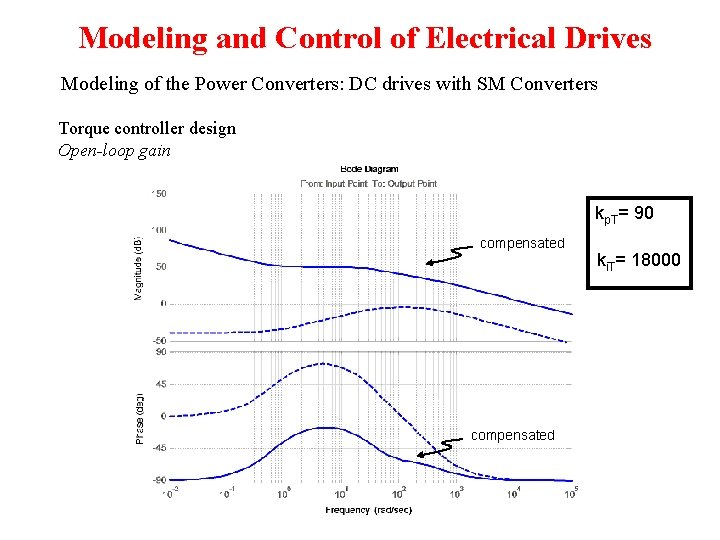
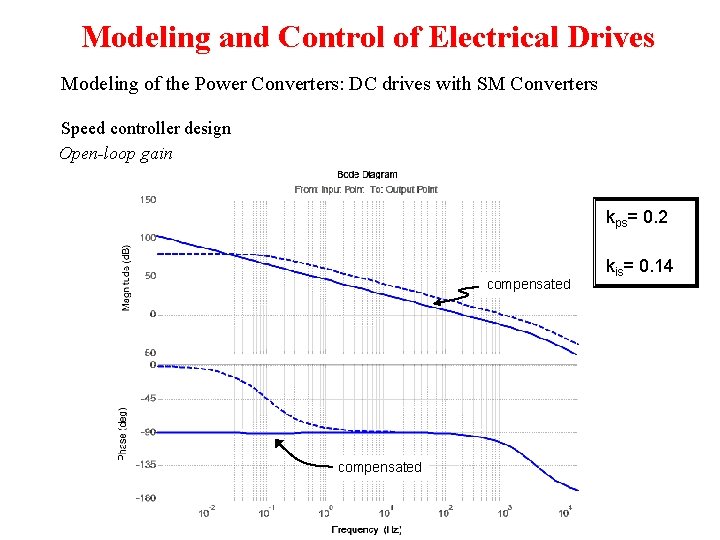
Modeling and Control of Electrical Drives Modeling of the Power Converters: DC drives with SM Converters Closed-loop speed control – an example OBJECTIVES: • Fast response – large bandwidth • Minimum overshoot good phase margin (>65 o) BODE PLOTS • Zero steady state error – very large DC gain METHOD • Obtain linear small signal model • Design controllers based on linear small signal model • Perform large signal simulation for controllers verification
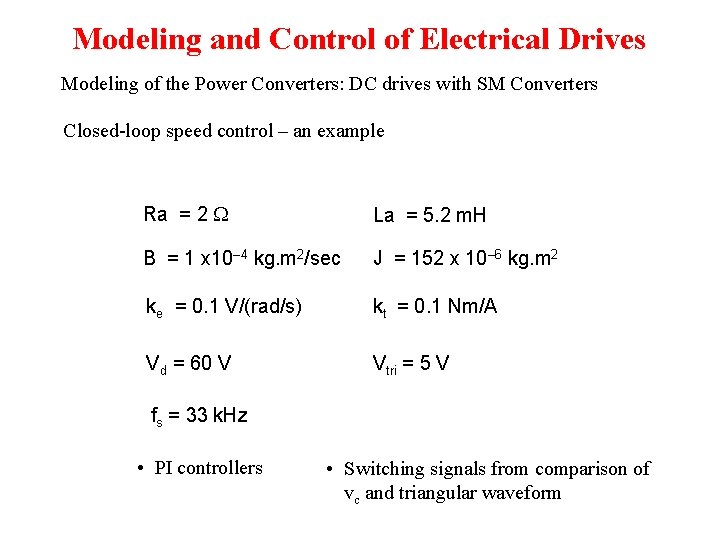
Modeling and Control of Electrical Drives Modeling of the Power Converters: DC drives with SM Converters Closed-loop speed control – an example Ra = 2 La = 5. 2 m. H B = 1 x 10– 4 kg. m 2/sec J = 152 x 10– 6 kg. m 2 ke = 0. 1 V/(rad/s) kt = 0. 1 Nm/A Vd = 60 V Vtri = 5 V fs = 33 k. Hz • PI controllers • Switching signals from comparison of vc and triangular waveform
Modeling and Control of Electrical Drives Modeling of the Power Converters: DC drives with SM Converters Torque controller design Open-loop gain kp. T= 90 compensated ki. T= 18000
Modeling and Control of Electrical Drives Modeling of the Power Converters: DC drives with SM Converters Speed controller design * + – T* Speed controller Torque loop 1 T
Modeling and Control of Electrical Drives Modeling of the Power Converters: DC drives with SM Converters Speed controller design Open-loop gain kps= 0. 2 compensated kis= 0. 14
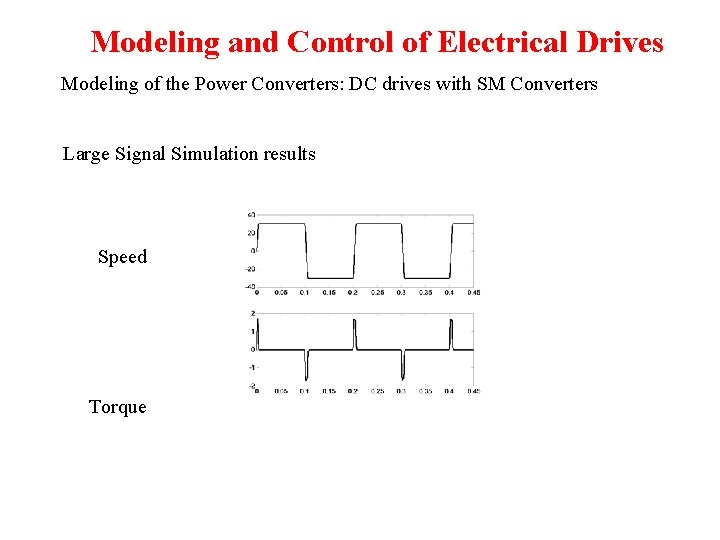
Modeling and Control of Electrical Drives Modeling of the Power Converters: DC drives with SM Converters Large Signal Simulation results Speed Torque
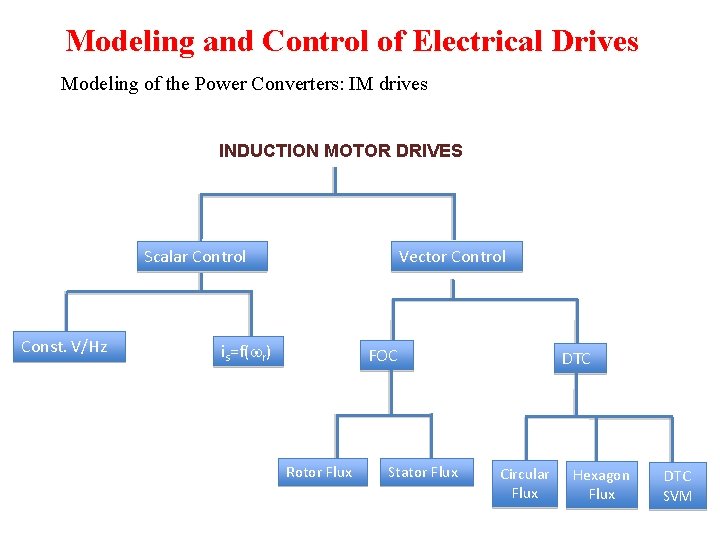
Modeling and Control of Electrical Drives Modeling of the Power Converters: IM drives INDUCTION MOTOR DRIVES Scalar Control Const. V/Hz Vector Control is=f( r) FOC Rotor Flux Stator Flux DTC Circular Flux Hexagon Flux DTC SVM
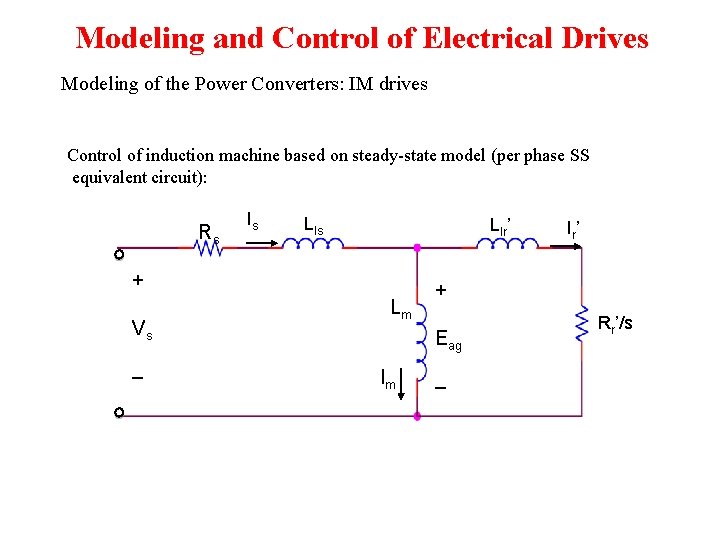
Modeling and Control of Electrical Drives Modeling of the Power Converters: IM drives Control of induction machine based on steady-state model (per phase SS equivalent circuit): Rs Is Llr’ + Vs – Lm + Eag Im Ir ’ – Rr’/s
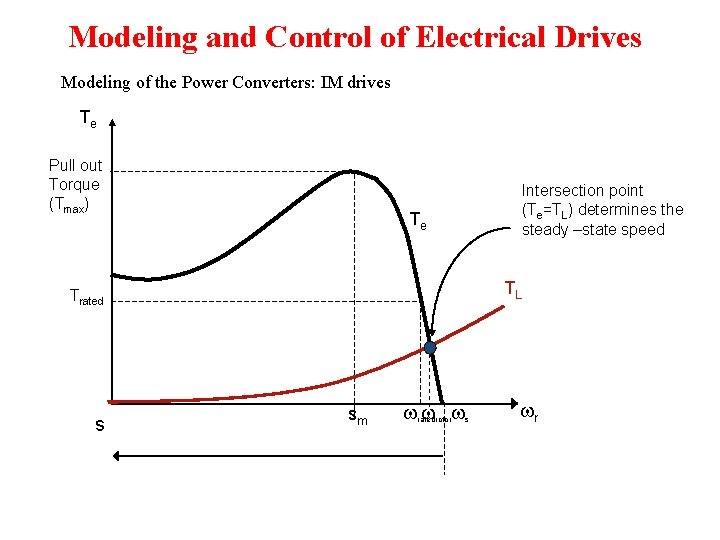
Modeling and Control of Electrical Drives Modeling of the Power Converters: IM drives Te Pull out Torque (Tmax) Intersection point (Te=TL) determines the steady –state speed Te TL Trated s sm ratedrotor s r
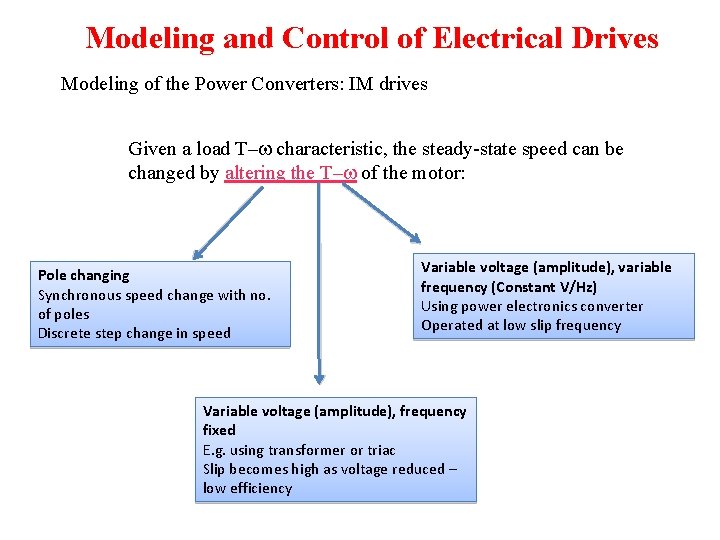
Modeling and Control of Electrical Drives Modeling of the Power Converters: IM drives Given a load T– characteristic, the steady-state speed can be changed by altering the T– of the motor: Pole changing Synchronous speed change with no. of poles Discrete step change in speed Variable voltage (amplitude), variable frequency (Constant V/Hz) Using power electronics converter Operated at low slip frequency Variable voltage (amplitude), frequency fixed E. g. using transformer or triac Slip becomes high as voltage reduced – low efficiency
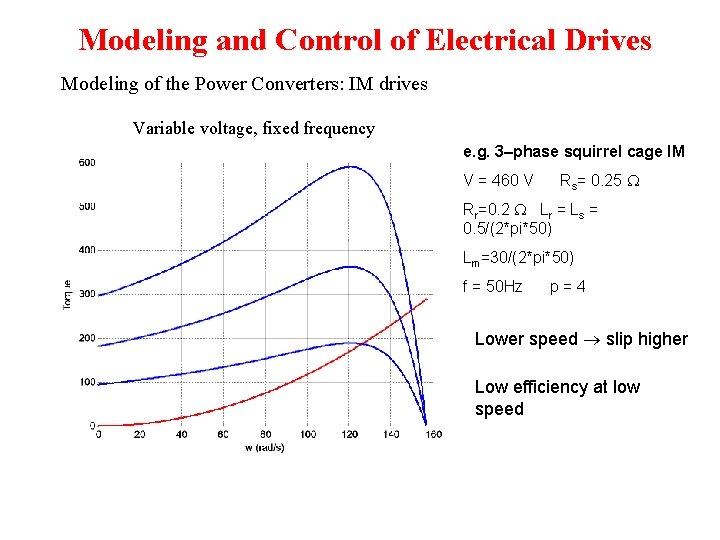
Modeling and Control of Electrical Drives Modeling of the Power Converters: IM drives Variable voltage, fixed frequency e. g. 3–phase squirrel cage IM V = 460 V Rs= 0. 25 Rr=0. 2 Lr = Ls = 0. 5/(2*pi*50) Lm=30/(2*pi*50) f = 50 Hz p=4 Lower speed slip higher Low efficiency at low speed
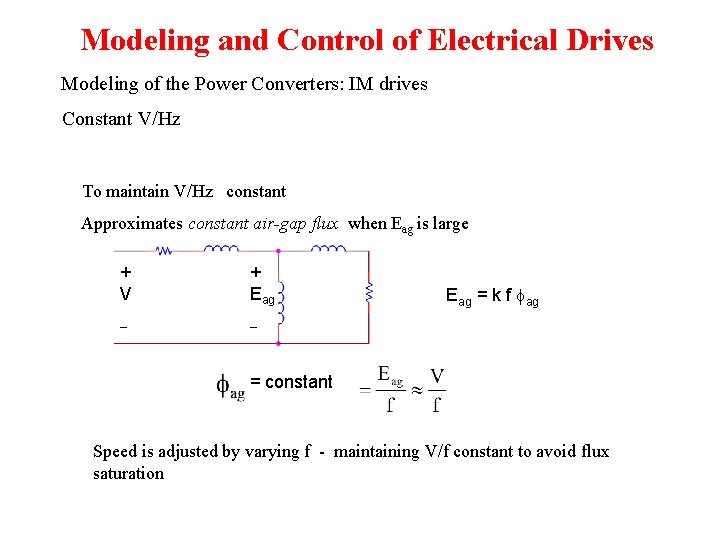
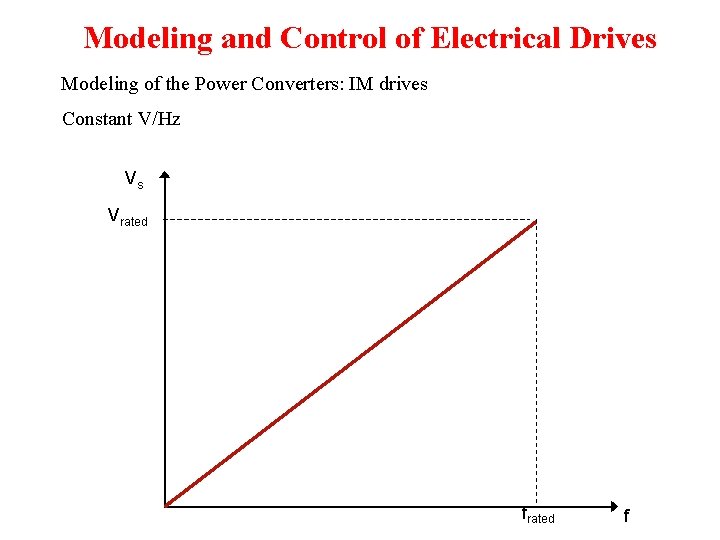
Modeling and Control of Electrical Drives Modeling of the Power Converters: IM drives Constant V/Hz To maintain V/Hz constant Approximates constant air-gap flux when Eag is large + V + Eag _ _ Eag = k f ag = constant Speed is adjusted by varying f - maintaining V/f constant to avoid flux saturation
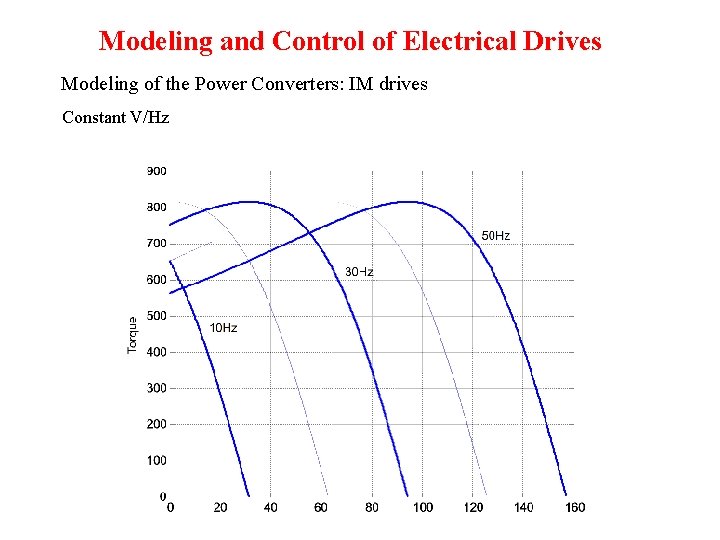
Modeling and Control of Electrical Drives Modeling of the Power Converters: IM drives Constant V/Hz
Modeling and Control of Electrical Drives Modeling of the Power Converters: IM drives Constant V/Hz Vs Vrated f
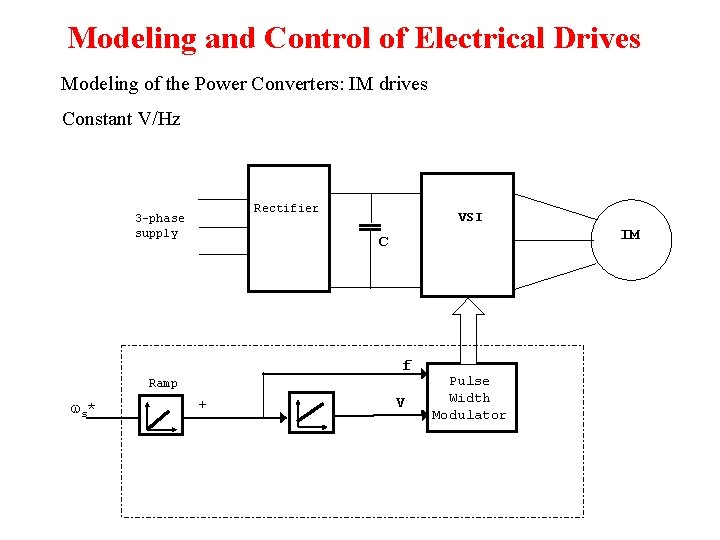
Modeling and Control of Electrical Drives Modeling of the Power Converters: IM drives Constant V/Hz Rectifier 3 -phase supply VSI IM C f Ramp s * + V Pulse Width Modulator
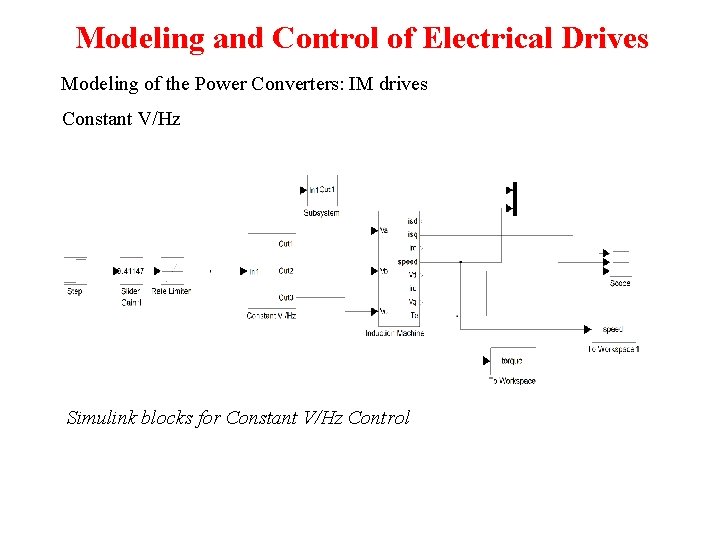
Modeling and Control of Electrical Drives Modeling of the Power Converters: IM drives Constant V/Hz Simulink blocks for Constant V/Hz Control
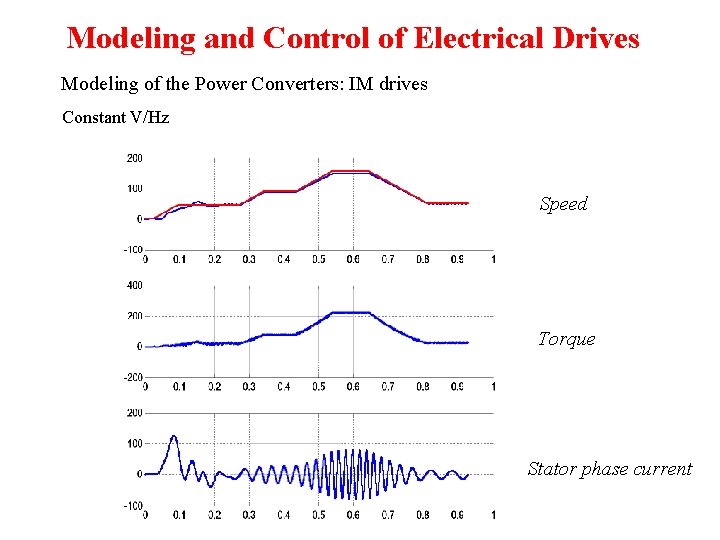
Modeling and Control of Electrical Drives Modeling of the Power Converters: IM drives Constant V/Hz Speed Torque Stator phase current
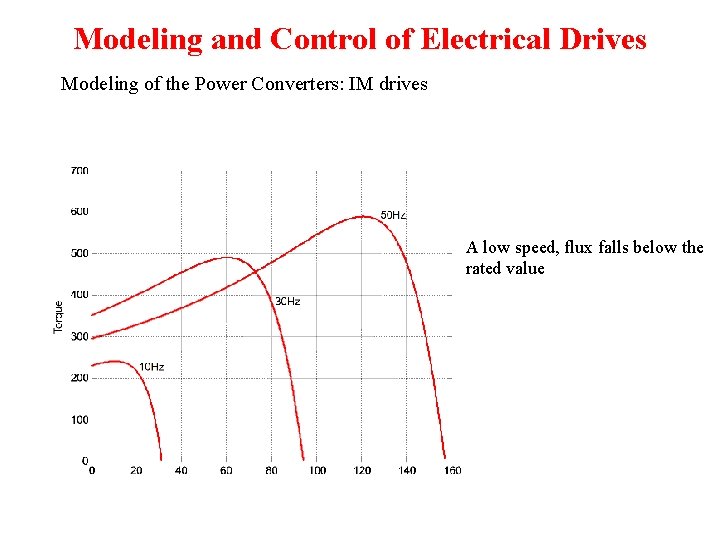
Modeling and Control of Electrical Drives 1 Modeling of the Power Converters: IM drives Problems with open-loop constant V/f At low speed, voltage drop across stator impedance is significant compared to airgap voltage - poor torque capability at low speed Solution: 1. Boost voltage at low speed 2. Maintain Im constant – constant ag
Modeling and Control of Electrical Drives Modeling of the Power Converters: IM drives A low speed, flux falls below the rated value
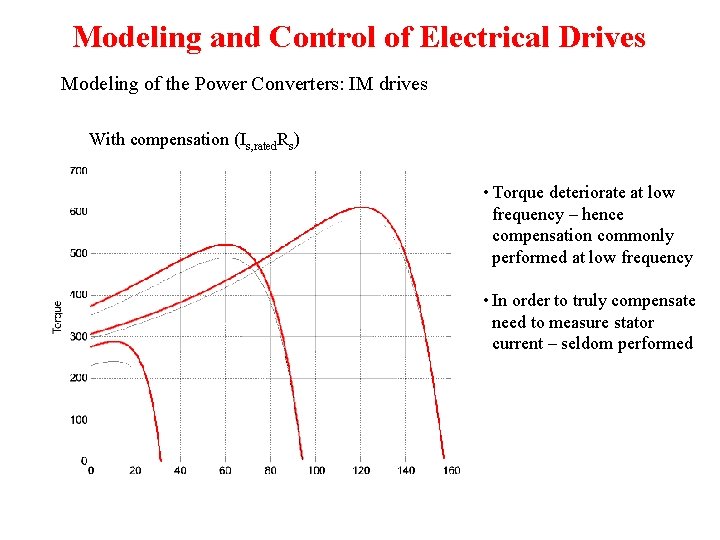
Modeling and Control of Electrical Drives Modeling of the Power Converters: IM drives With compensation (Is, rated. Rs) • Torque deteriorate at low frequency – hence compensation commonly performed at low frequency • In order to truly compensate need to measure stator current – seldom performed
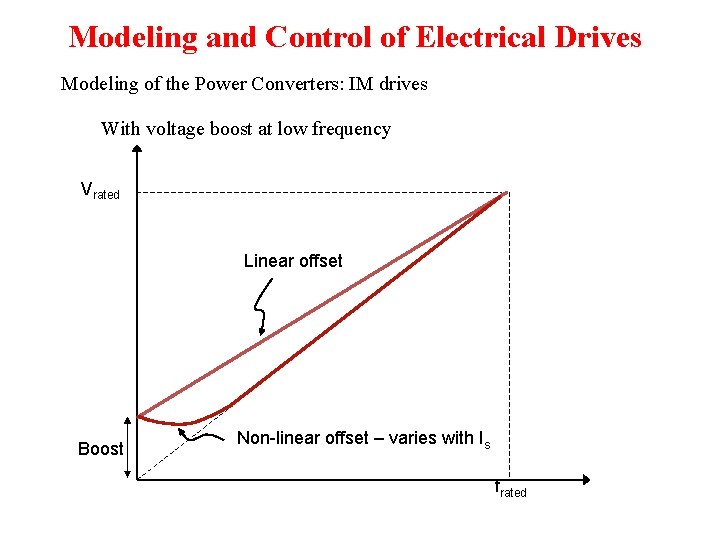
Modeling and Control of Electrical Drives Modeling of the Power Converters: IM drives With voltage boost at low frequency Vrated Linear offset Boost Non-linear offset – varies with Is frated
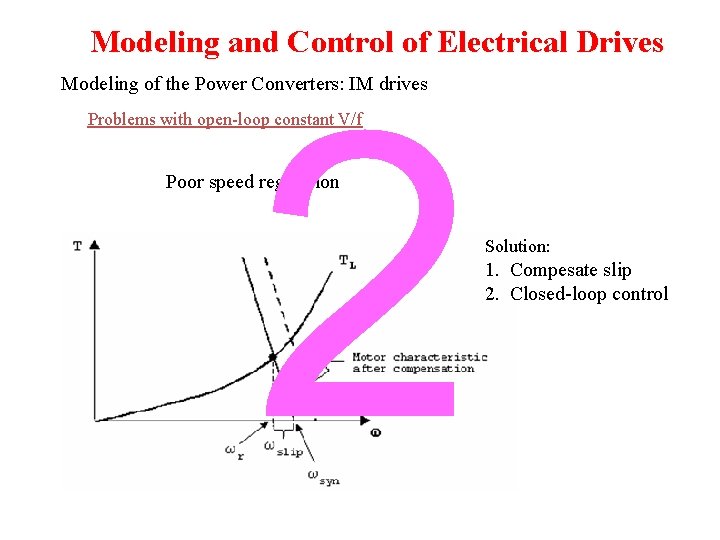
Modeling and Control of Electrical Drives 2 Modeling of the Power Converters: IM drives Problems with open-loop constant V/f Poor speed regulation Solution: 1. Compesate slip 2. Closed-loop control
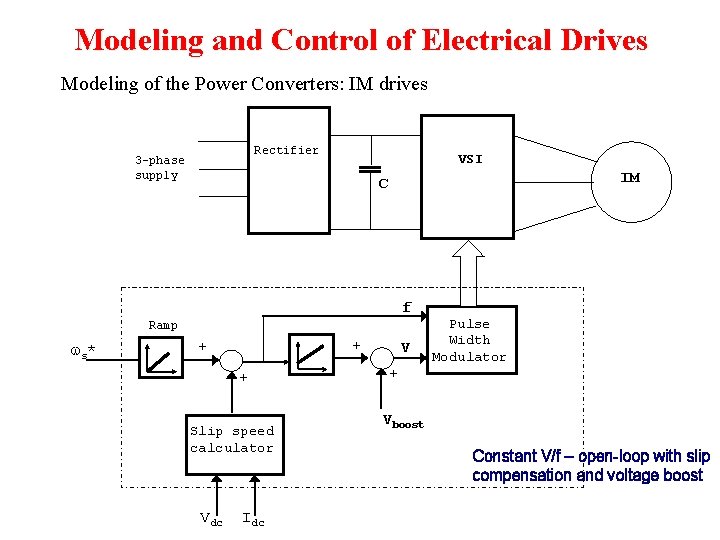
Modeling and Control of Electrical Drives Modeling of the Power Converters: IM drives Rectifier 3 -phase supply VSI IM C f Ramp s * + + + Slip speed calculator Vdc Idc V Pulse Width Modulator + Vboost Constant V/f – open-loop with slip compensation and voltage boost
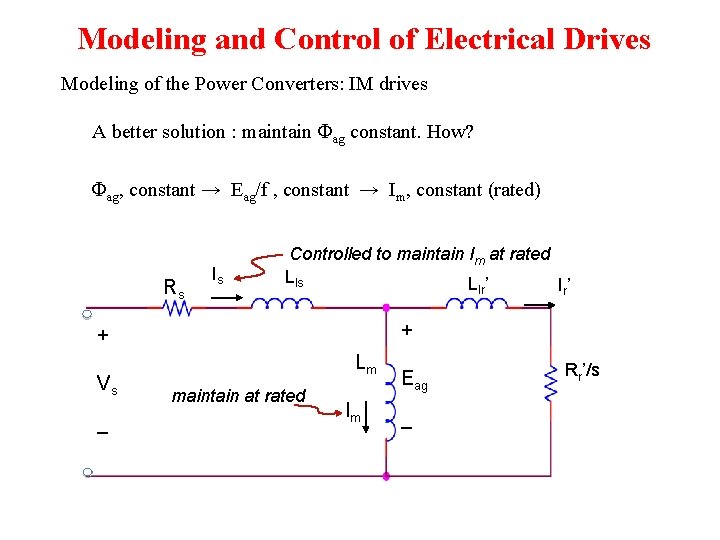
Modeling and Control of Electrical Drives Modeling of the Power Converters: IM drives A better solution : maintain ag constant. How? ag, constant → Eag/f , constant → Im, constant (rated) Rs Is Controlled to maintain Im at rated Lls Llr’ Ir ’ + + Vs – Lm maintain at rated Im Eag – Rr’/s
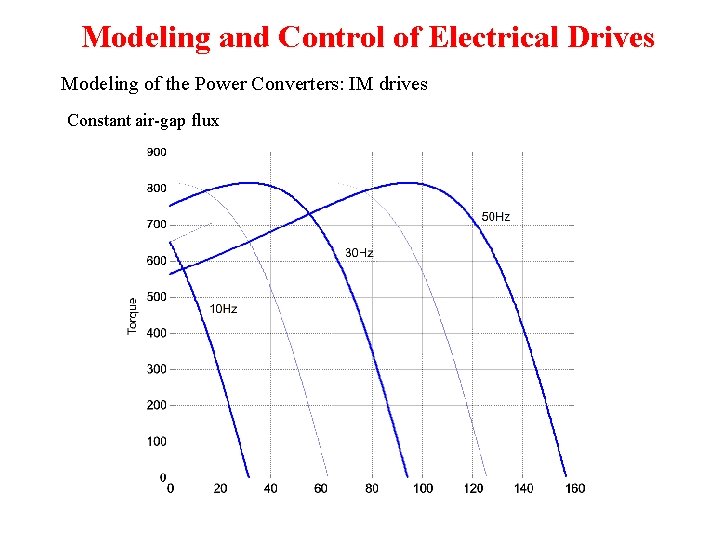
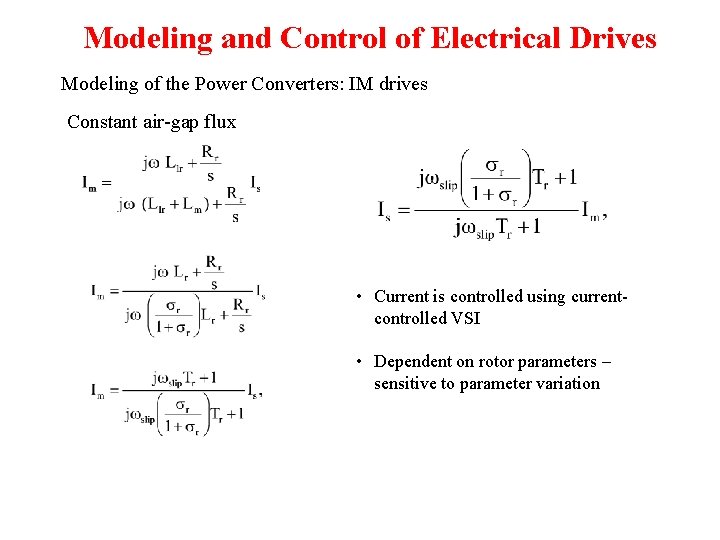
Modeling and Control of Electrical Drives Modeling of the Power Converters: IM drives Constant air-gap flux
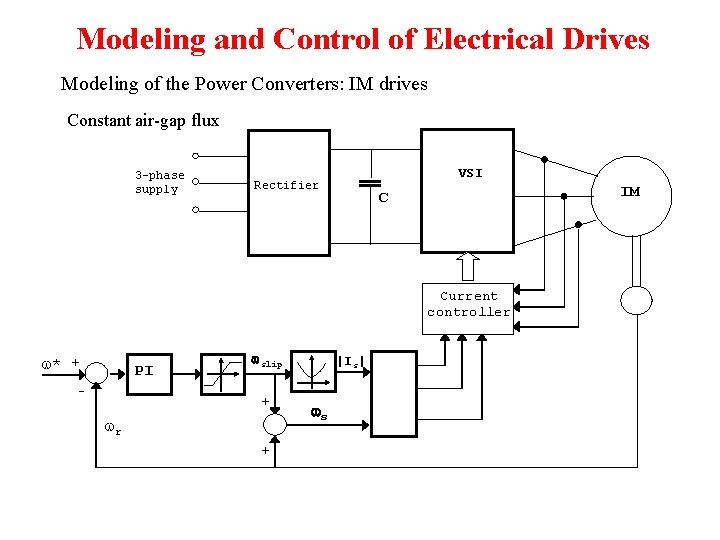
Modeling and Control of Electrical Drives Modeling of the Power Converters: IM drives Constant air-gap flux • Current is controlled using currentcontrolled VSI • Dependent on rotor parameters – sensitive to parameter variation
Modeling and Control of Electrical Drives Modeling of the Power Converters: IM drives Constant air-gap flux 3 -phase supply VSI Rectifier IM C Current controller * + PI - slip + r + |Is| s
THANK YOU