
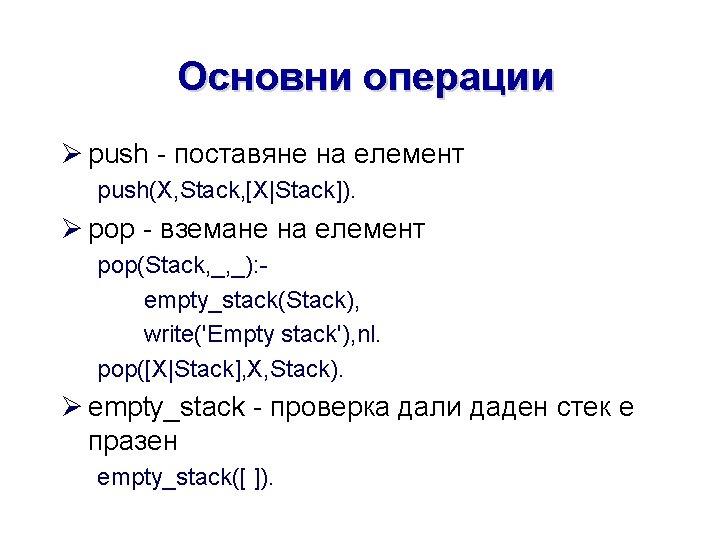
pop push pop push push pushX Queue New
![% Graph g([ [a, [e, c]], [b, [d, a]], [c, [ ]], [d, [a]],](https://slidetodoc.com/presentation_image_h/1491a137573cef86f1db50392ad3e128/image-12.jpg "% Graph g([ [a, [e, c]], [b, [d, a]], [c, [ ]], [d, [a]],")
- Slides: 120
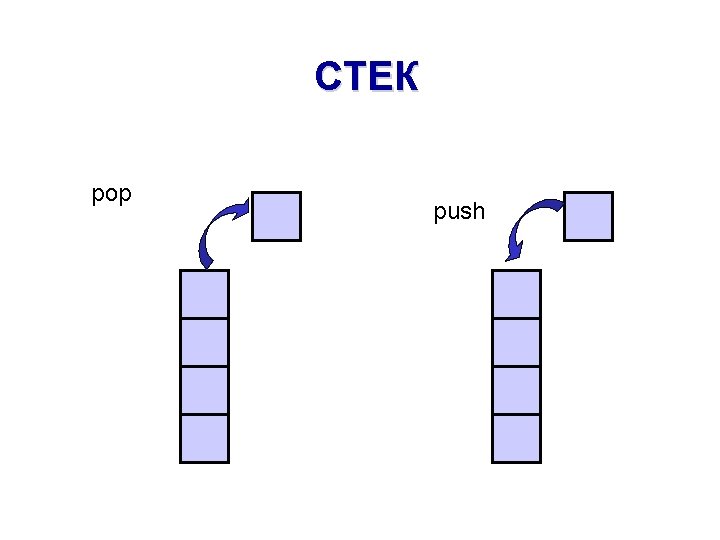
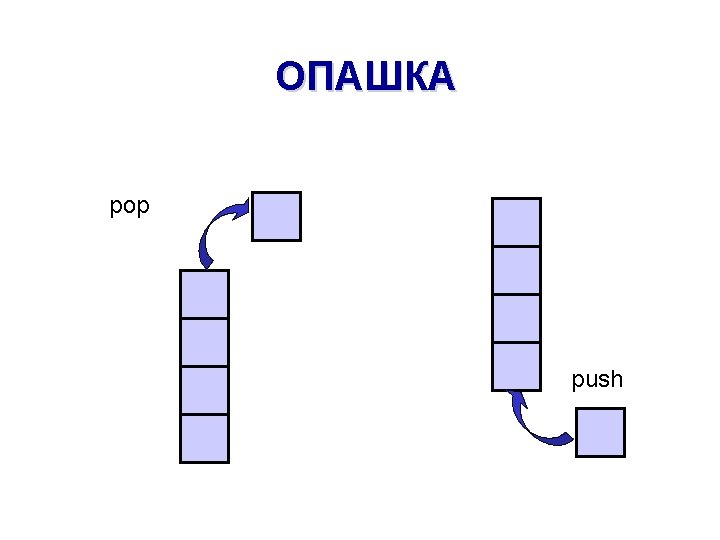
СТЕК pop push
ОПАШКА pop push
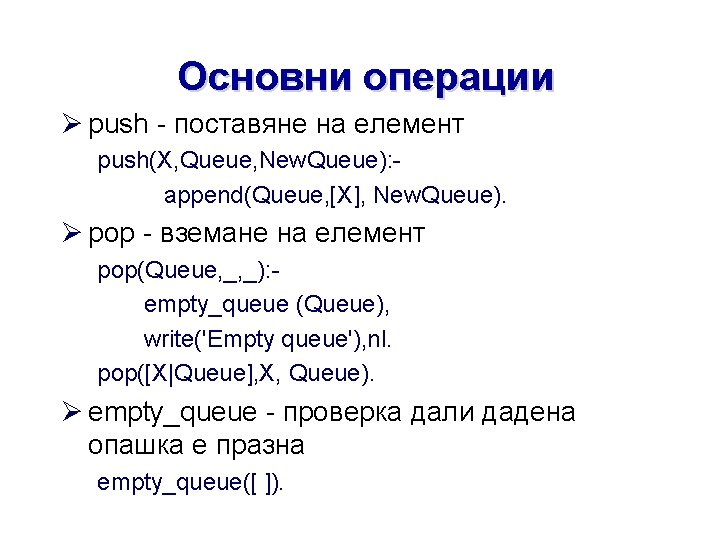
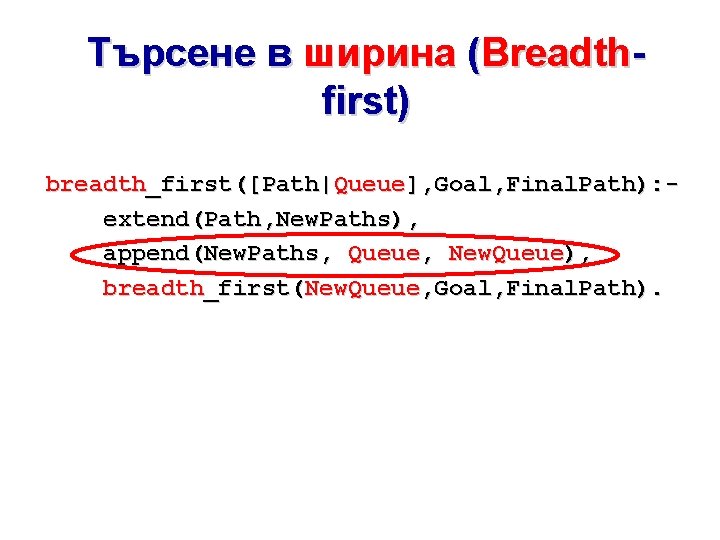
Основни операции Ø push - поставяне на елемент push(X, Queue, New. Queue): append(Queue, [X], New. Queue). Ø pop - вземане на елемент pop(Queue, _, _): empty_queue (Queue), write('Empty queue'), nl. pop([X|Queue], X, Queue). Ø empty_queue - проверка дали дадена опашка е празна empty_queue([ ]).
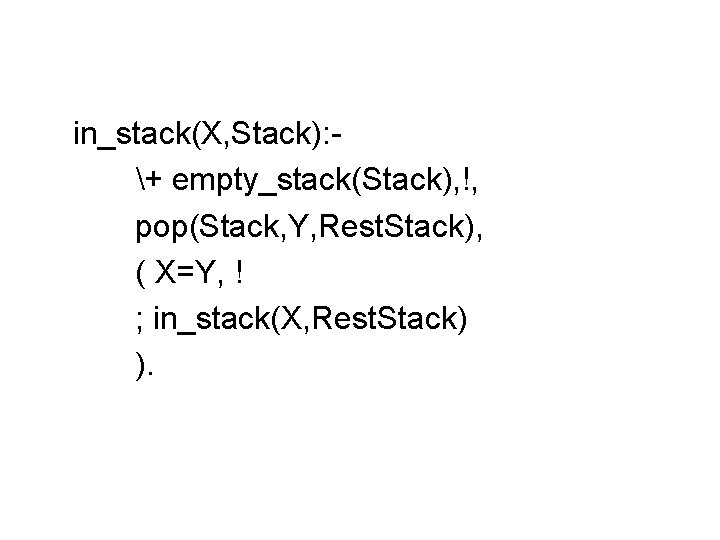
in_stack(X, Stack): + empty_stack(Stack), !, pop(Stack, Y, Rest. Stack), ( X=Y, ! ; in_stack(X, Rest. Stack) ).
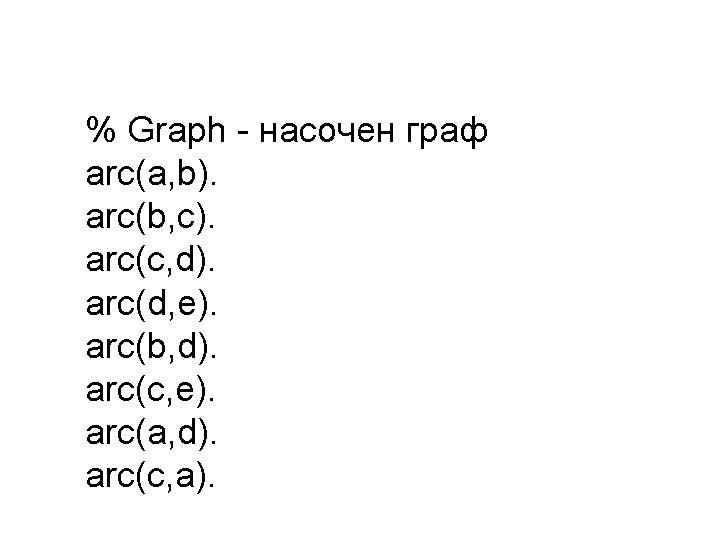
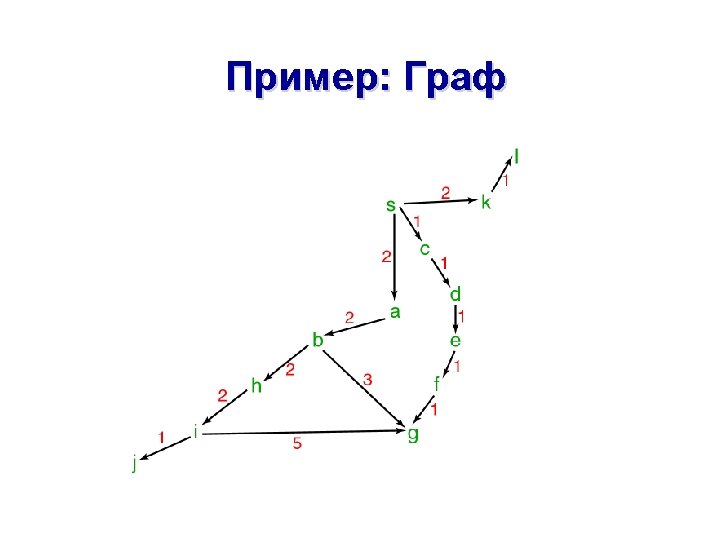
% Graph - насочен граф arc(a, b). arc(b, c). arc(c, d). arc(d, e). arc(b, d). arc(c, e). arc(a, d). arc(c, a).
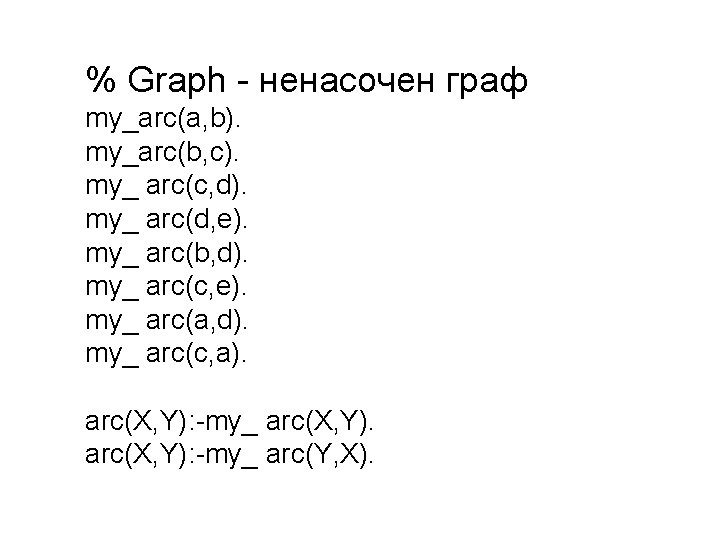
% Graph - ненасочен граф my_arc(a, b). my_arc(b, c). my_ arc(c, d). my_ arc(d, e). my_ arc(b, d). my_ arc(c, e). my_ arc(a, d). my_ arc(c, a). arc(X, Y): -my_ arc(Y, X).
% Graph g([ [a, [e, c]], [b, [d, a]], [c, [ ]], [d, [a]], [e, [c]]]). arc(X, Y): g(Graph), member([X, Nodes], Graph), member(Y, Nodes).
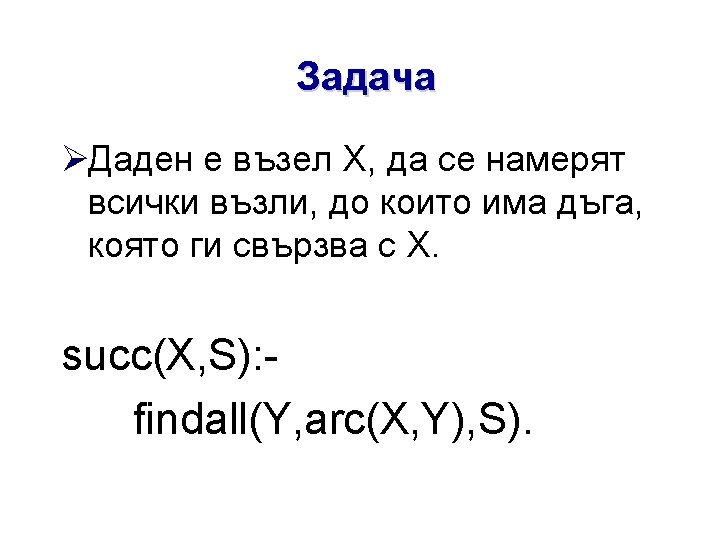
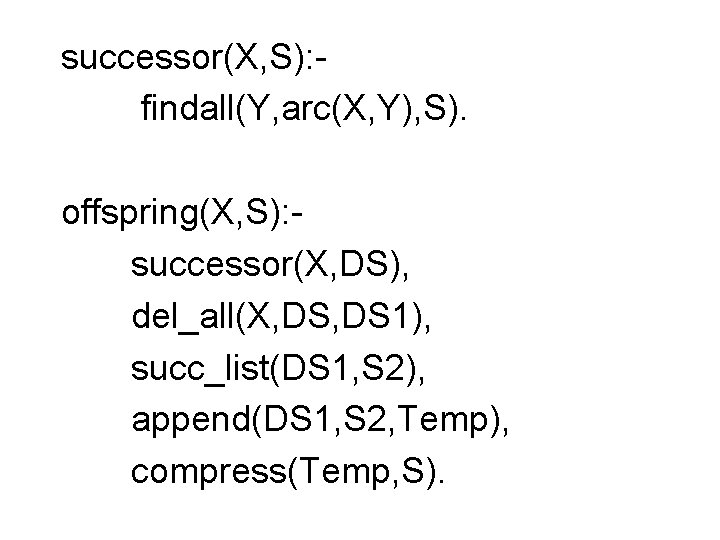
successor(X, S): findall(Y, arc(X, Y), S). offspring(X, S): successor(X, DS), del_all(X, DS 1), succ_list(DS 1, S 2), append(DS 1, S 2, Temp), compress(Temp, S).
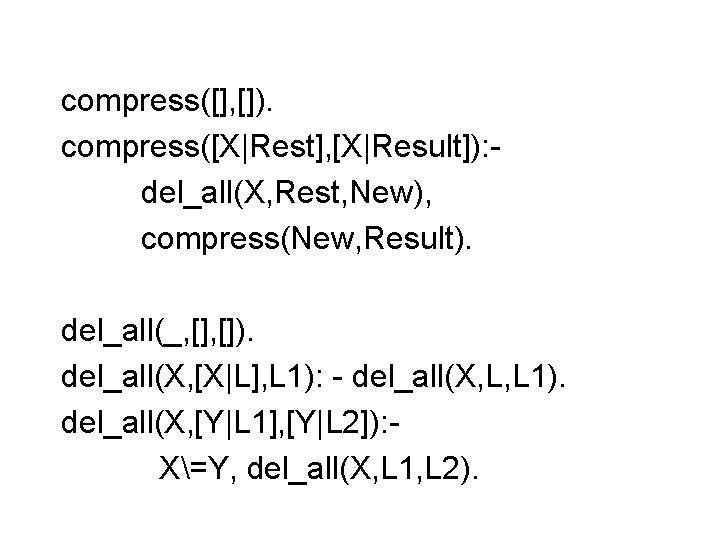
compress([], []). compress([X|Rest], [X|Result]): del_all(X, Rest, New), compress(New, Result). del_all(_, []). del_all(X, [X|L], L 1): - del_all(X, L, L 1). del_all(X, [Y|L 1], [Y|L 2]): X=Y, del_all(X, L 1, L 2).
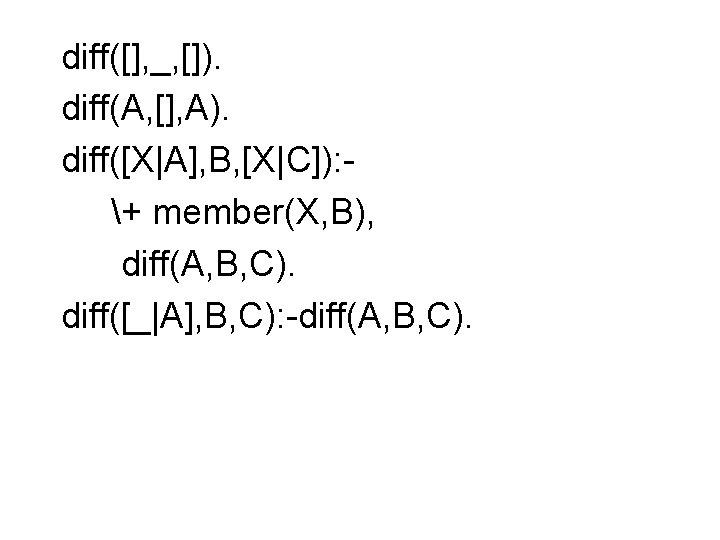
diff([], _, []). diff(A, [], A). diff([X|A], B, [X|C]): + member(X, B), diff(A, B, C). diff([_|A], B, C): -diff(A, B, C).
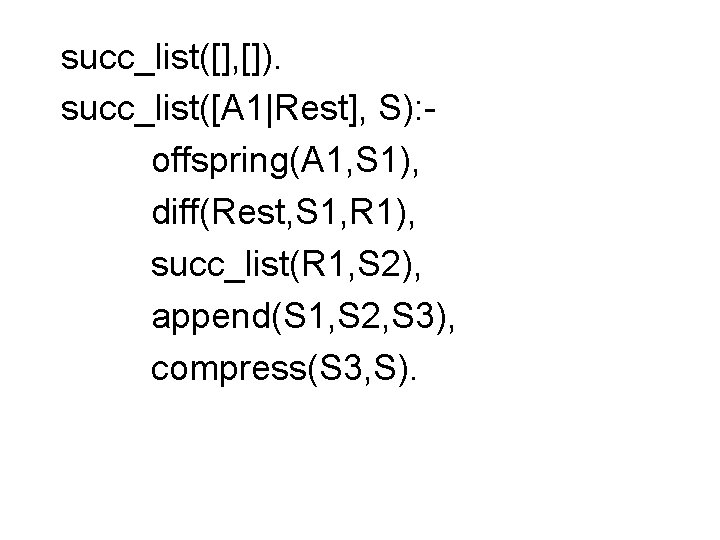
succ_list([], []). succ_list([A 1|Rest], S): offspring(A 1, S 1), diff(Rest, S 1, R 1), succ_list(R 1, S 2), append(S 1, S 2, S 3), compress(S 3, S).
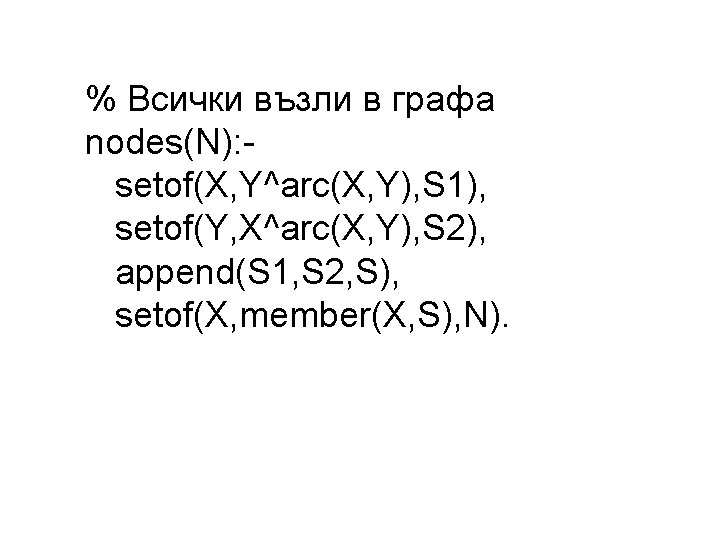
% Всички възли в графа nodes(N): setof(X, Y^arc(X, Y), S 1), setof(Y, X^arc(X, Y), S 2), append(S 1, S 2, S), setof(X, member(X, S), N).
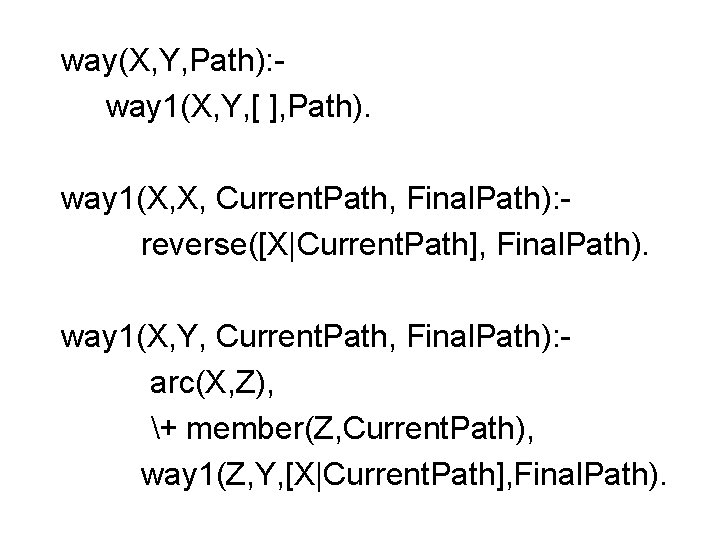
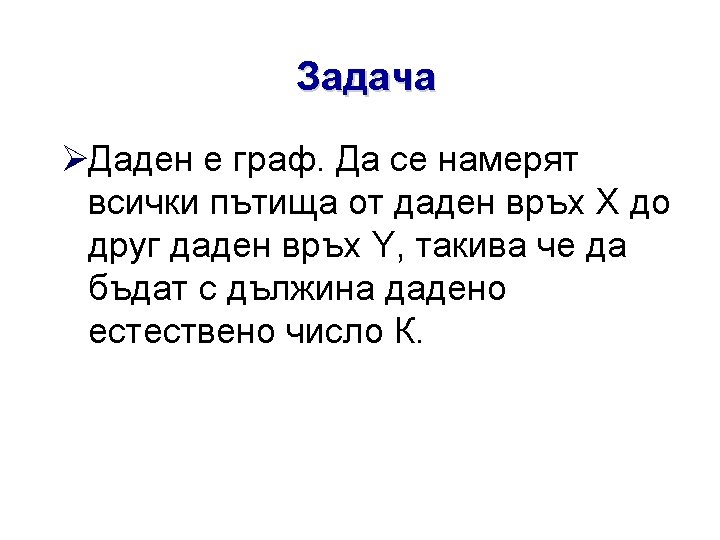
way(X, Y, Path): way 1(X, Y, [ ], Path). way 1(X, X, Current. Path, Final. Path): reverse([X|Current. Path], Final. Path). way 1(X, Y, Current. Path, Final. Path): arc(X, Z), + member(Z, Current. Path), way 1(Z, Y, [X|Current. Path], Final. Path).
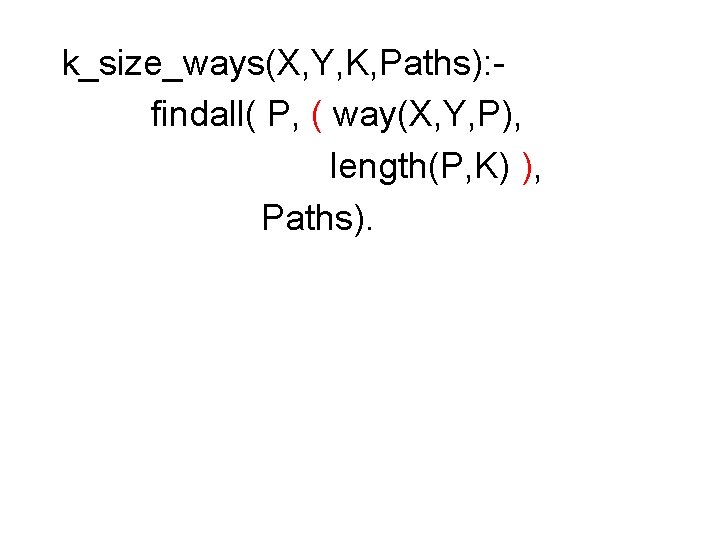
k_size_ways(X, Y, K, Paths): findall( P, ( way(X, Y, P), length(P, K) ), Paths).
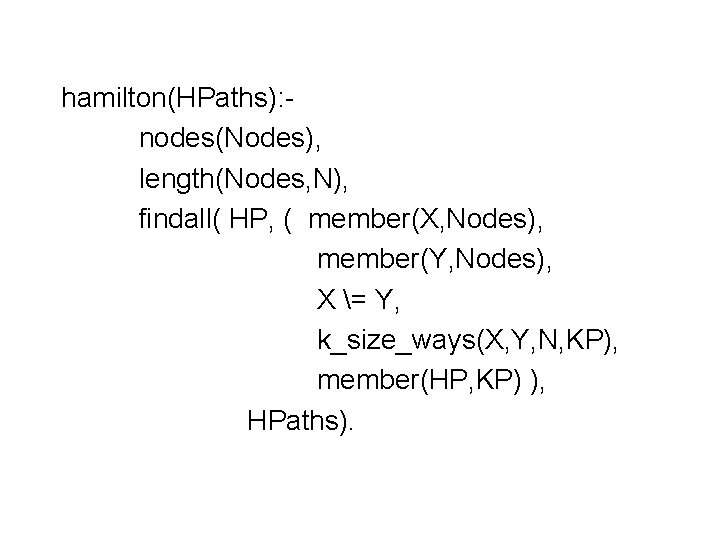
hamilton(HPaths): nodes(Nodes), length(Nodes, N), findall( HP, ( member(X, Nodes), member(Y, Nodes), X = Y, k_size_ways(X, Y, N, KP), member(HP, KP) ), HPaths).
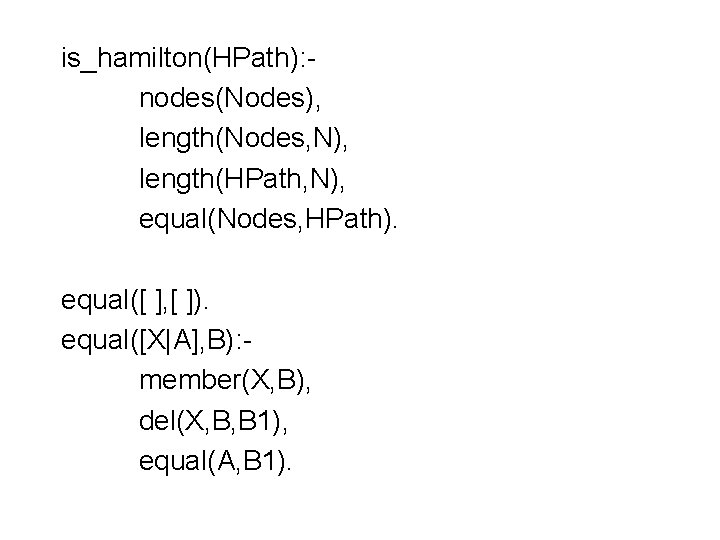
is_hamilton(HPath): nodes(Nodes), length(Nodes, N), length(HPath, N), equal(Nodes, HPath). equal([ ], [ ]). equal([X|A], B): member(X, B), del(X, B, B 1), equal(A, B 1).
% Graph arc(a, b). arc(b, c). arc(c, d). arc(d, e). arc(b, d). arc(c, e). arc(a, d). hamilton(HPaths): nodes(N), length(N, K), findall(P 1, (member(X, N), member(Y, N), X = Y, way(X, Y, [], P 1), length(P 1, K) ), HPaths).
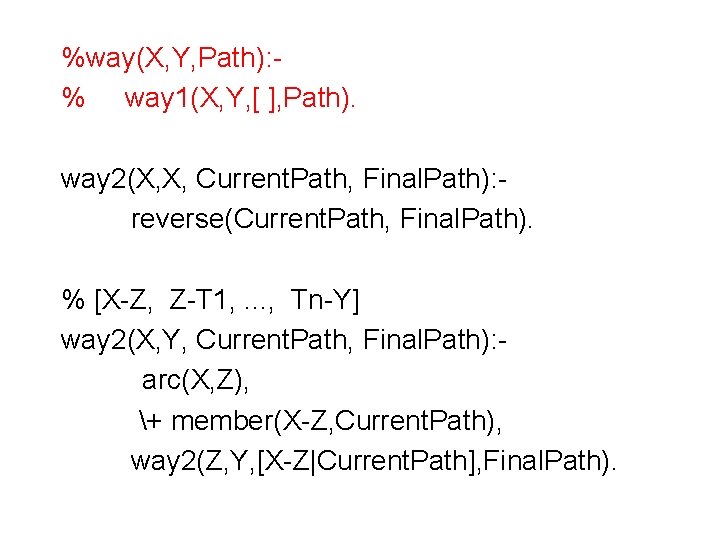
%way(X, Y, Path): % way 1(X, Y, [ ], Path). way 2(X, X, Current. Path, Final. Path): reverse(Current. Path, Final. Path). % [X-Z, Z-T 1, . . . , Tn-Y] way 2(X, Y, Current. Path, Final. Path): arc(X, Z), + member(X-Z, Current. Path), way 2(Z, Y, [X-Z|Current. Path], Final. Path).
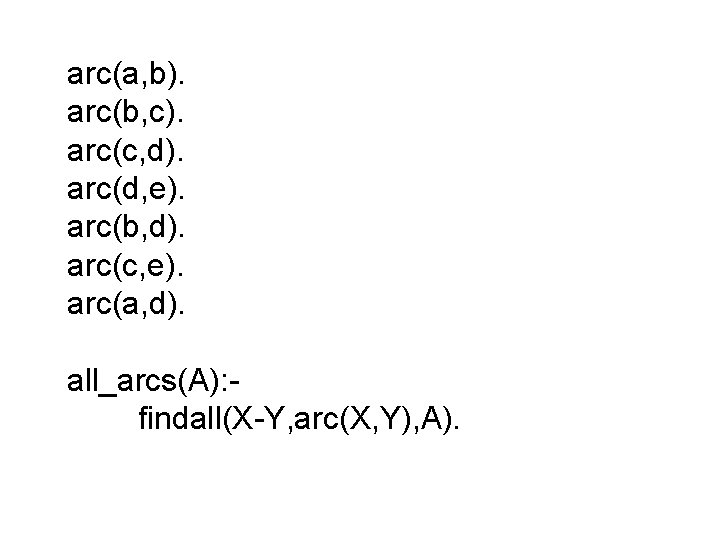
arc(a, b). arc(b, c). arc(c, d). arc(d, e). arc(b, d). arc(c, e). arc(a, d). all_arcs(A): findall(X-Y, arc(X, Y), A).
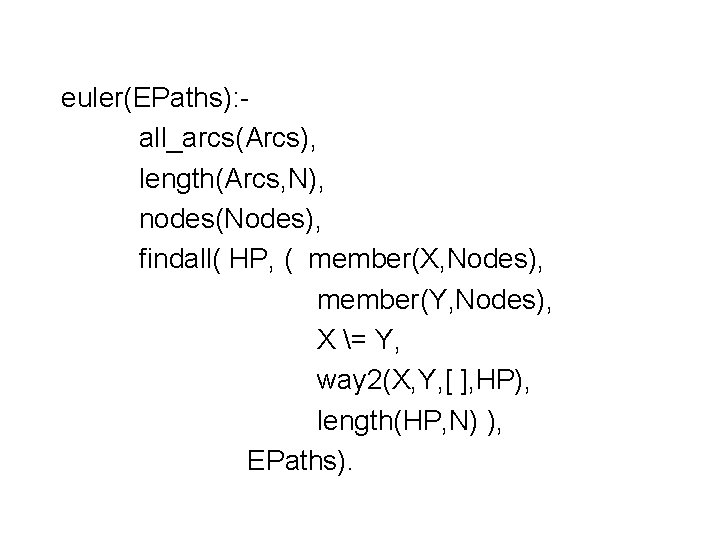
euler(EPaths): all_arcs(Arcs), length(Arcs, N), nodes(Nodes), findall( HP, ( member(X, Nodes), member(Y, Nodes), X = Y, way 2(X, Y, [ ], HP), length(HP, N) ), EPaths).
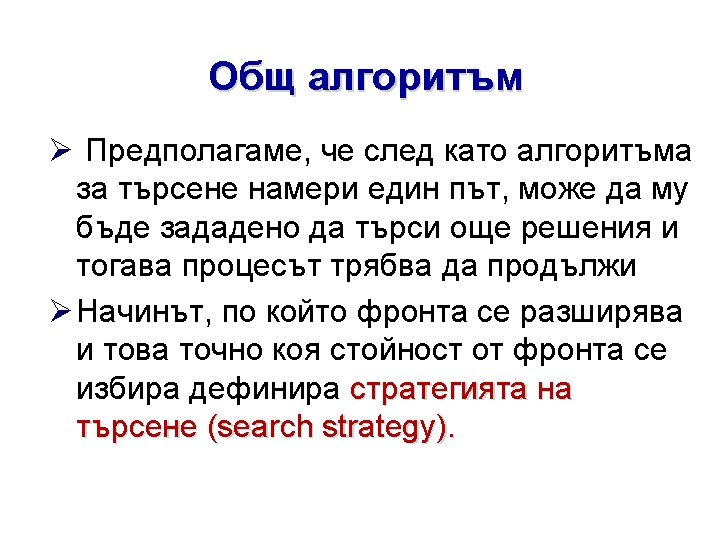
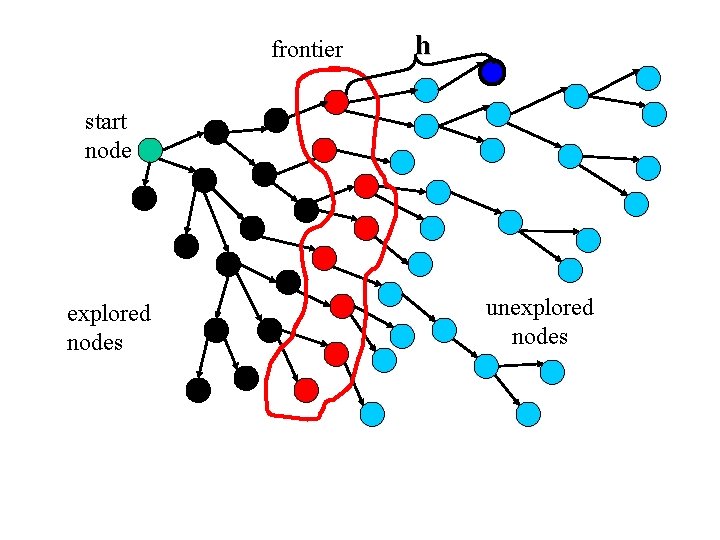
frontier start node explored nodes unexplored nodes
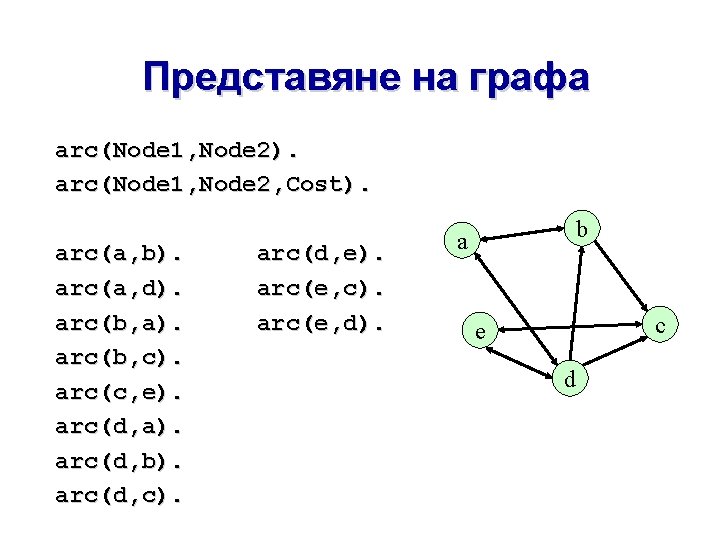
Представяне на графа arc(Node 1, Node 2). arc(Node 1, Node 2, Cost). arc(a, b). arc(a, d). arc(b, a). arc(b, c). arc(c, e). arc(d, a). arc(d, b). arc(d, c). arc(d, e). arc(e, c). arc(e, d). b a c e d
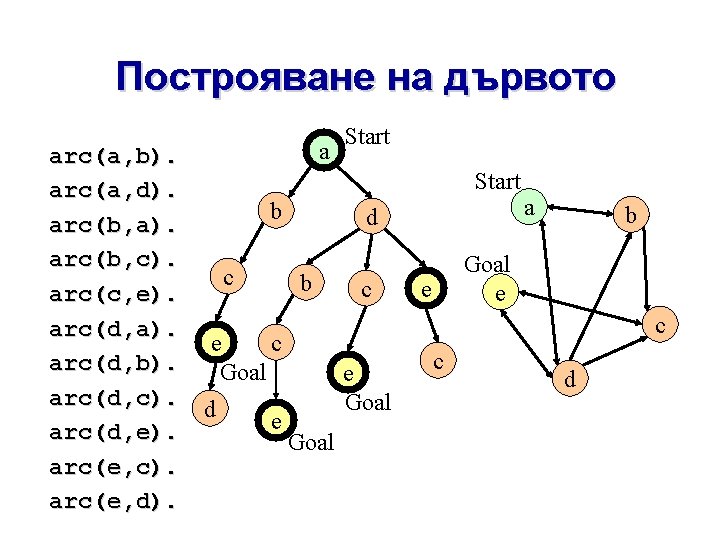
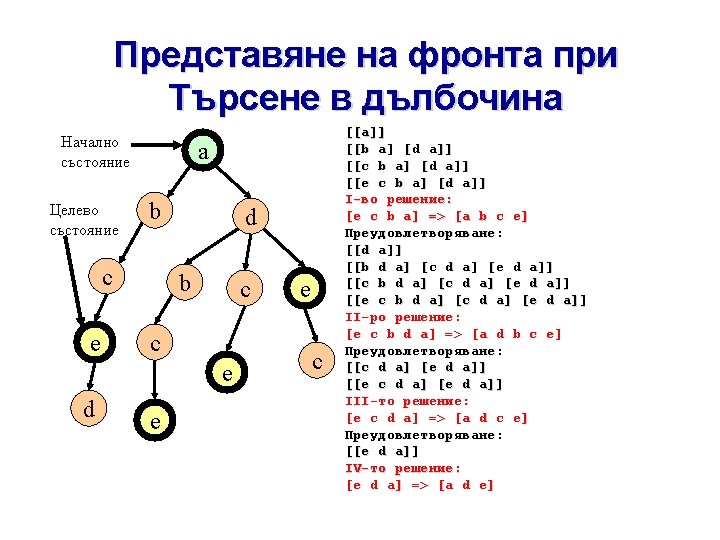
Построяване на дървото arc(a, b). arc(a, d). arc(b, a). arc(b, c). arc(c, e). arc(d, a). arc(d, b). arc(d, c). arc(d, e). arc(e, c). arc(e, d). a Start b c d b e b Goal e e c Goal d c a e Goal c d
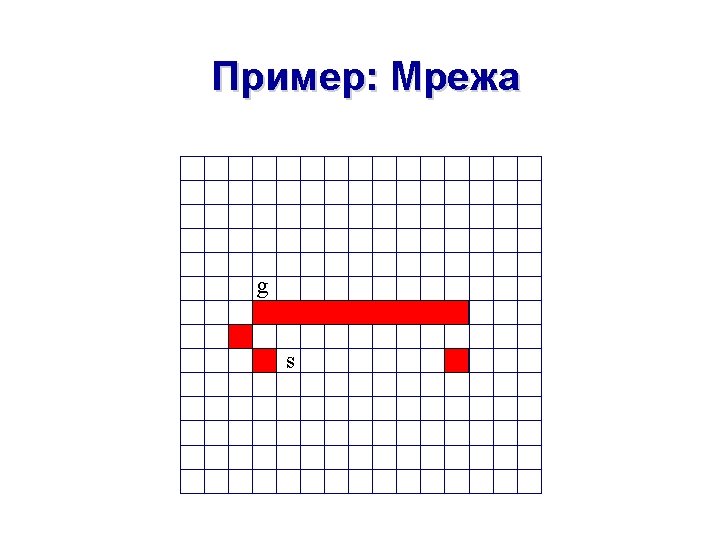
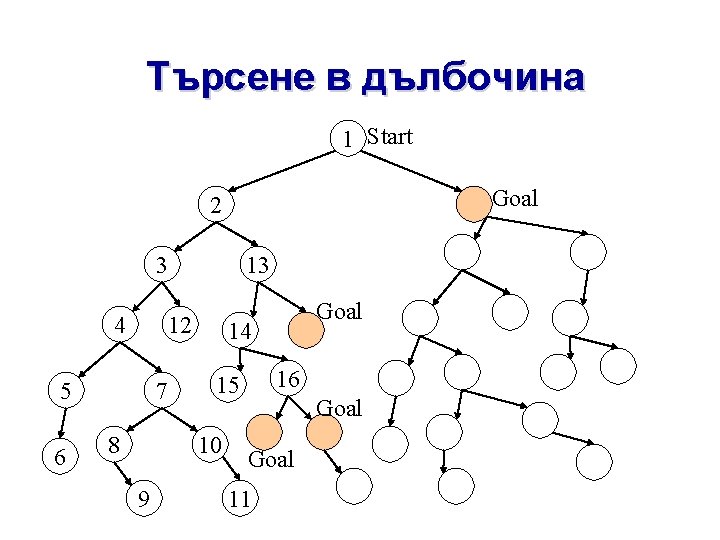
Търсене в дълбочина 1 Start Goal 2 3 4 12 5 6 13 7 8 14 16 15 10 9 Goal 11
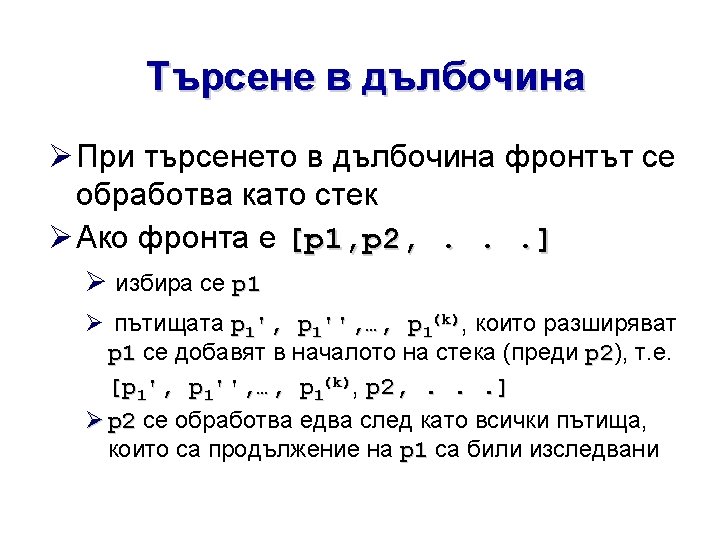
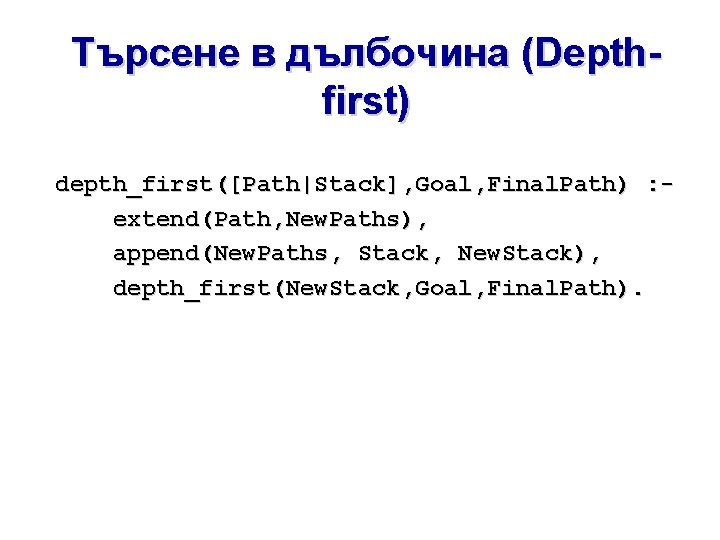
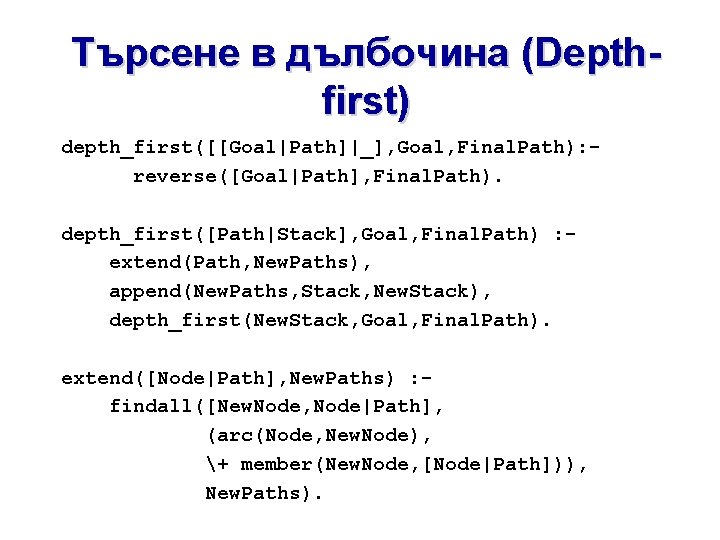
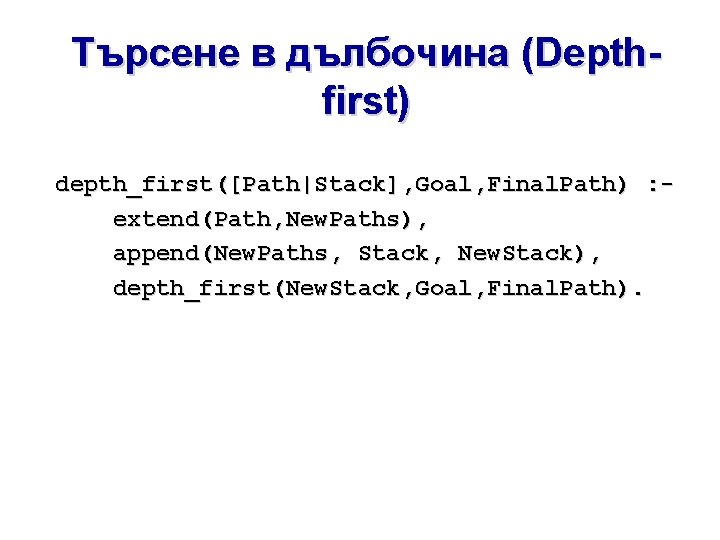
Търсене в дълбочина (Depthfirst) depth_first([Path|Stack], Goal, Final. Path) : extend(Path, New. Paths), append(New. Paths, Stack, New. Stack), depth_first(New. Stack, Goal, Final. Path).
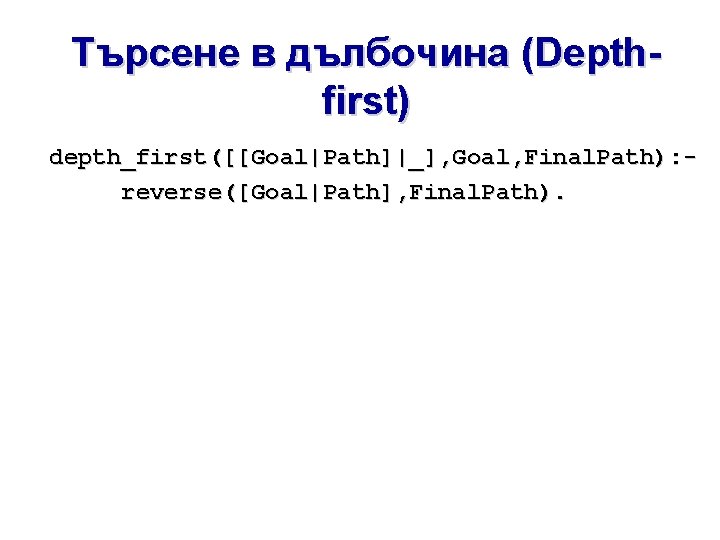
Търсене в дълбочина (Depthfirst) depth_first([[Goal|Path]|_], Goal, Final. Path): reverse([Goal|Path], Final. Path).
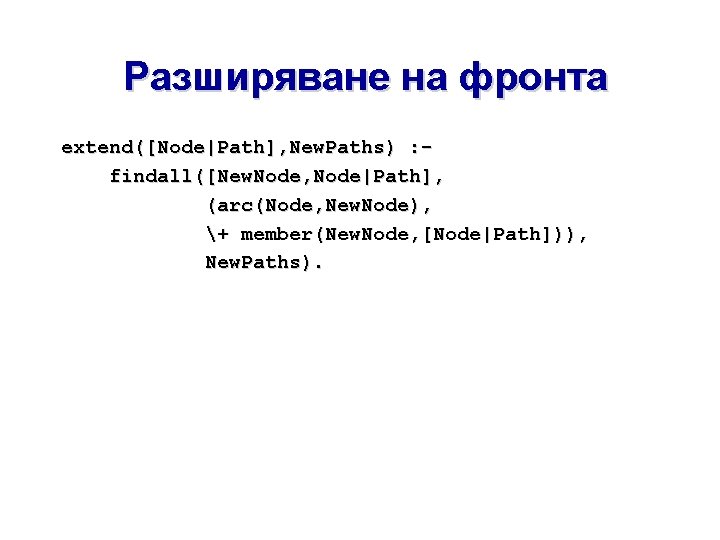
Разширяване на фронта extend([Node|Path], New. Paths) : findall([New. Node, Node|Path], (arc(Node, New. Node), + member(New. Node, [Node|Path])), New. Paths).
Търсене в дълбочина (Depthfirst) depth_first([[Goal|Path]|_], Goal, Final. Path): reverse([Goal|Path], Final. Path). depth_first([Path|Stack], Goal, Final. Path) : extend(Path, New. Paths), append(New. Paths, Stack, New. Stack), depth_first(New. Stack, Goal, Final. Path). extend([Node|Path], New. Paths) : findall([New. Node, Node|Path], (arc(Node, New. Node), + member(New. Node, [Node|Path])), New. Paths).
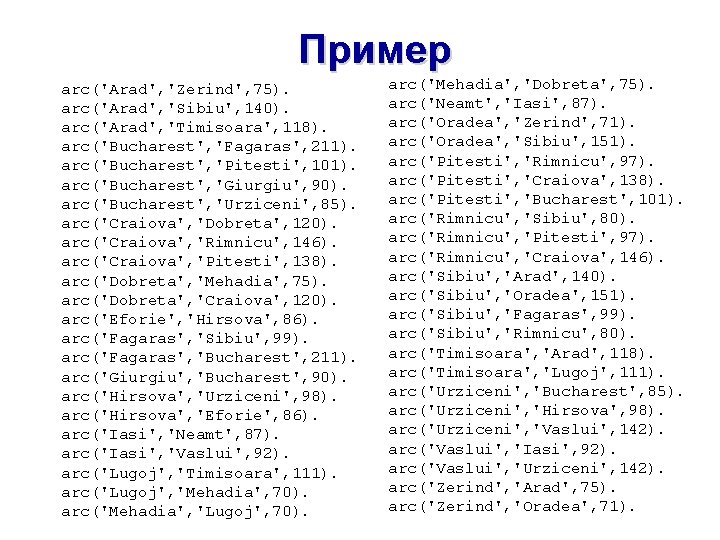
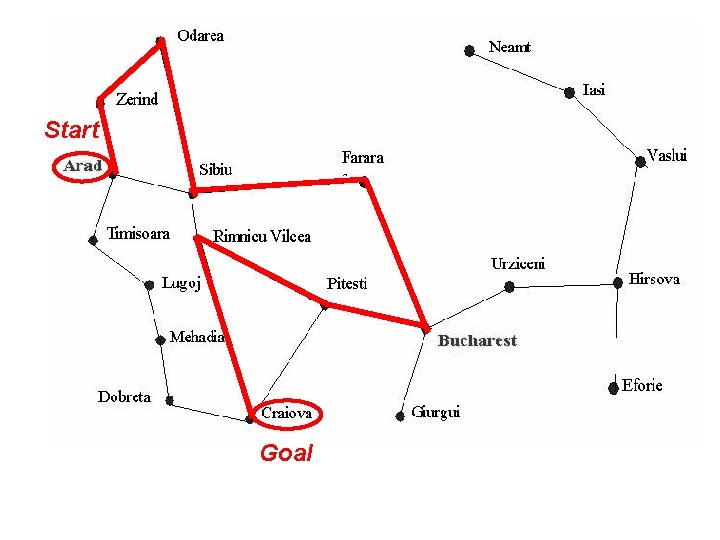
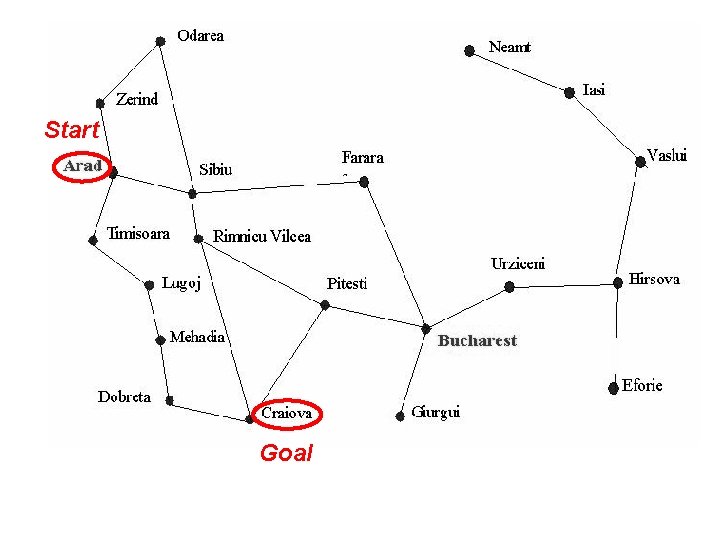
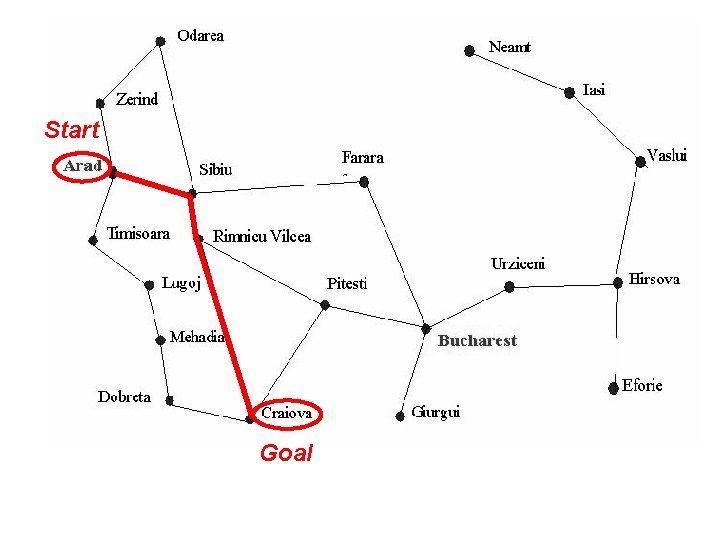
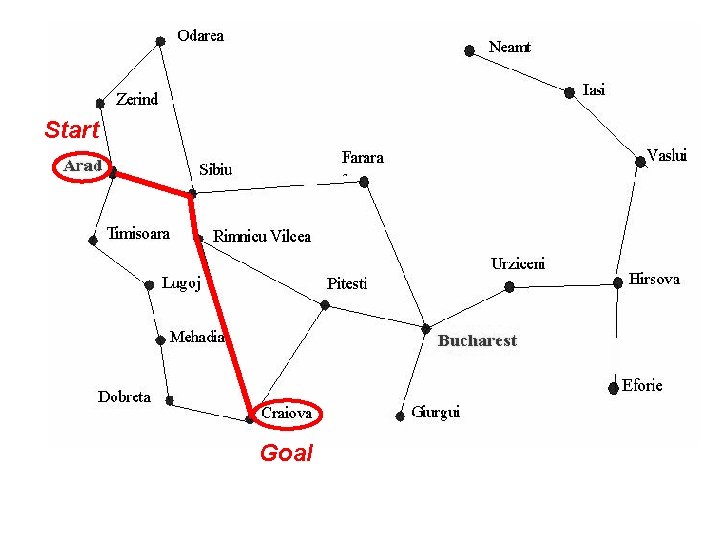
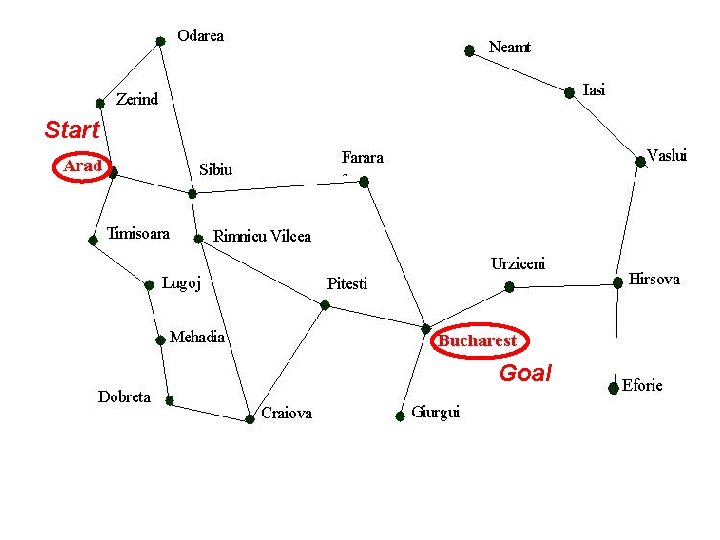
Пример arc('Arad', 'Zerind', 75). arc('Arad', 'Sibiu', 140). arc('Arad', 'Timisoara', 118). arc('Bucharest', 'Fagaras', 211). arc('Bucharest', 'Pitesti', 101). arc('Bucharest', 'Giurgiu', 90). arc('Bucharest', 'Urziceni', 85). arc('Craiova', 'Dobreta', 120). arc('Craiova', 'Rimnicu', 146). arc('Craiova', 'Pitesti', 138). arc('Dobreta', 'Mehadia', 75). arc('Dobreta', 'Craiova', 120). arc('Eforie', 'Hirsova', 86). arc('Fagaras', 'Sibiu', 99). arc('Fagaras', 'Bucharest', 211). arc('Giurgiu', 'Bucharest', 90). arc('Hirsova', 'Urziceni', 98). arc('Hirsova', 'Eforie', 86). arc('Iasi', 'Neamt', 87). arc('Iasi', 'Vaslui', 92). arc('Lugoj', 'Timisoara', 111). arc('Lugoj', 'Mehadia', 70). arc('Mehadia', 'Lugoj', 70). arc('Mehadia', 'Dobreta', 75). arc('Neamt', 'Iasi', 87). arc('Oradea', 'Zerind', 71). arc('Oradea', 'Sibiu', 151). arc('Pitesti', 'Rimnicu', 97). arc('Pitesti', 'Craiova', 138). arc('Pitesti', 'Bucharest', 101). arc('Rimnicu', 'Sibiu', 80). arc('Rimnicu', 'Pitesti', 97). arc('Rimnicu', 'Craiova', 146). arc('Sibiu', 'Arad', 140). arc('Sibiu', 'Oradea', 151). arc('Sibiu', 'Fagaras', 99). arc('Sibiu', 'Rimnicu', 80). arc('Timisoara', 'Arad', 118). arc('Timisoara', 'Lugoj', 111). arc('Urziceni', 'Bucharest', 85). arc('Urziceni', 'Hirsova', 98). arc('Urziceni', 'Vaslui', 142). arc('Vaslui', 'Iasi', 92). arc('Vaslui', 'Urziceni', 142). arc('Zerind', 'Arad', 75). arc('Zerind', 'Oradea', 71).
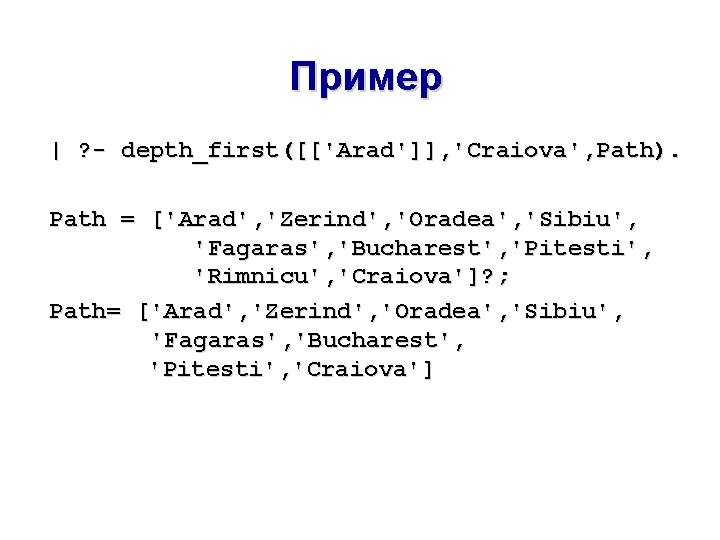
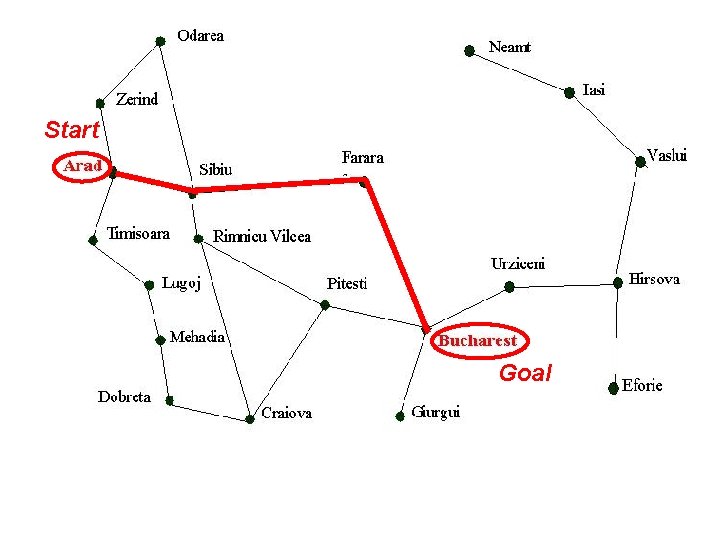
Пример | ? - depth_first([['Arad']], 'Craiova', Path). Path = ['Arad', 'Zerind', 'Oradea', 'Sibiu', 'Fagaras', 'Bucharest', 'Pitesti', 'Rimnicu', 'Craiova']? ; Path= ['Arad', 'Zerind', 'Oradea', 'Sibiu', 'Fagaras', 'Bucharest', 'Pitesti', 'Craiova']
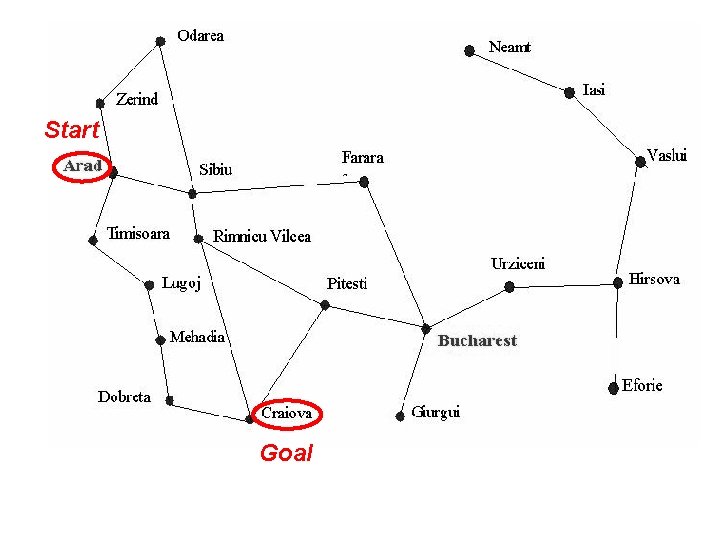
Start Goal
Start Goal
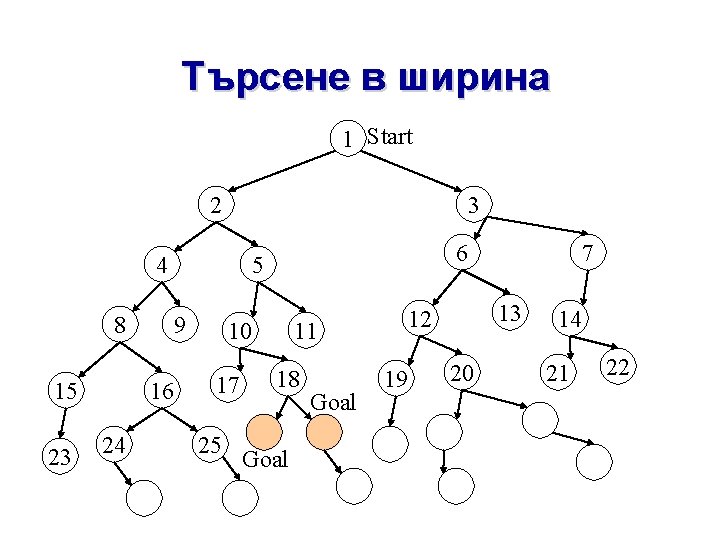
Търсене в ширина 1 Start 2 3 4 8 15 23 9 16 24 6 5 10 17 25 18 Goal 13 12 11 19 7 20 14 21 22
Търсене в дълбочина (Depthfirst) depth_first([Path|Stack], Goal, Final. Path) : extend(Path, New. Paths), append(New. Paths, Stack, New. Stack), depth_first(New. Stack, Goal, Final. Path).
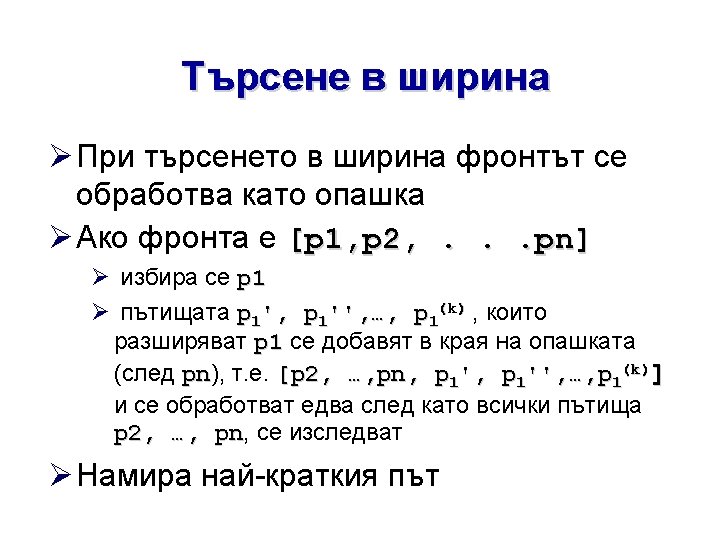
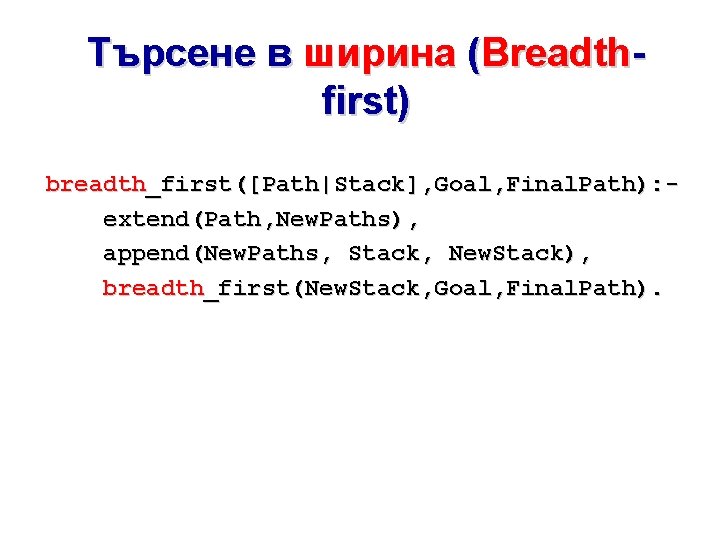
Търсене в ширина (Breadthfirst) breadth_first([Path|Stack], Goal, Final. Path): extend(Path, New. Paths), append(New. Paths, Stack, New. Stack), breadth_first(New. Stack, Goal, Final. Path).
Търсене в ширина (Breadthfirst) breadth_first([Path|Queue], Goal, Final. Path): extend(Path, New. Paths), append(New. Paths, Queue, New. Queue), breadth_first(New. Queue, Goal, Final. Path).
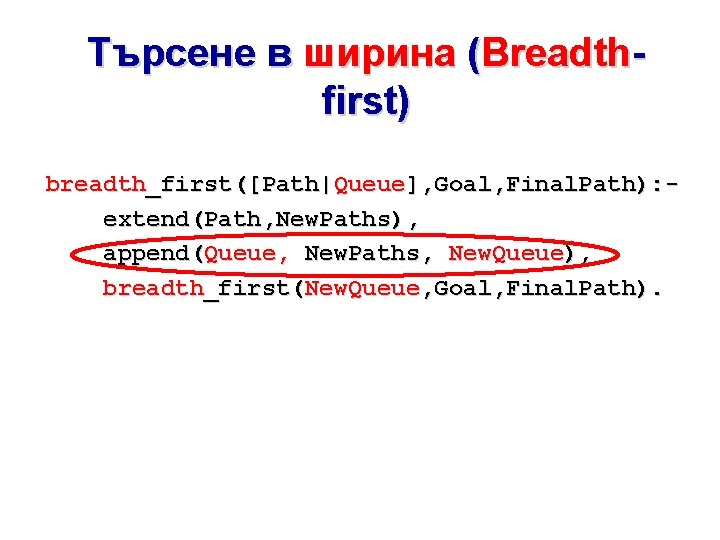
Търсене в ширина (Breadthfirst) breadth_first([Path|Queue], Goal, Final. Path): extend(Path, New. Paths), append(Queue, New. Paths, New. Queue), breadth_first(New. Queue, Goal, Final. Path).
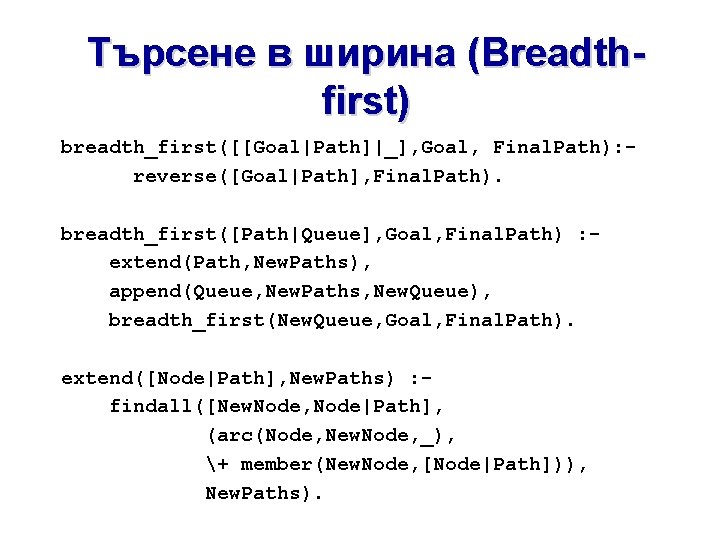
Търсене в ширина (Breadthfirst) breadth_first([[Goal|Path]|_], Goal, Final. Path): reverse([Goal|Path], Final. Path). breadth_first([Path|Queue], Goal, Final. Path) : extend(Path, New. Paths), append(Queue, New. Paths, New. Queue), breadth_first(New. Queue, Goal, Final. Path). extend([Node|Path], New. Paths) : findall([New. Node, Node|Path], (arc(Node, New. Node, _), + member(New. Node, [Node|Path])), New. Paths).
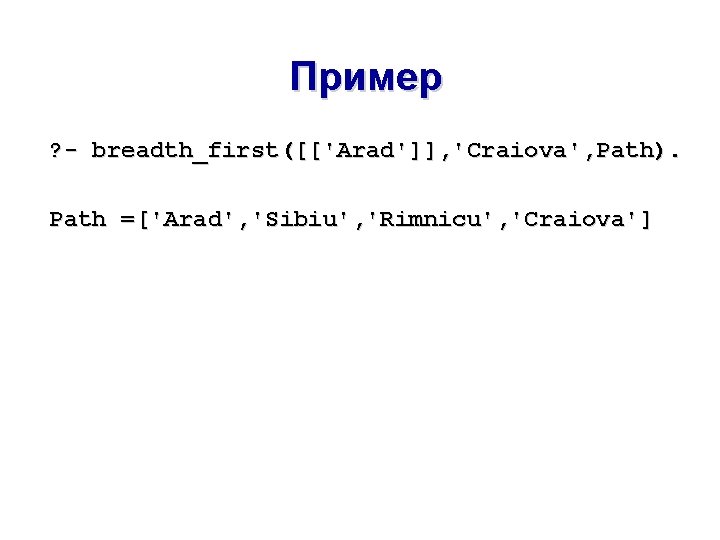
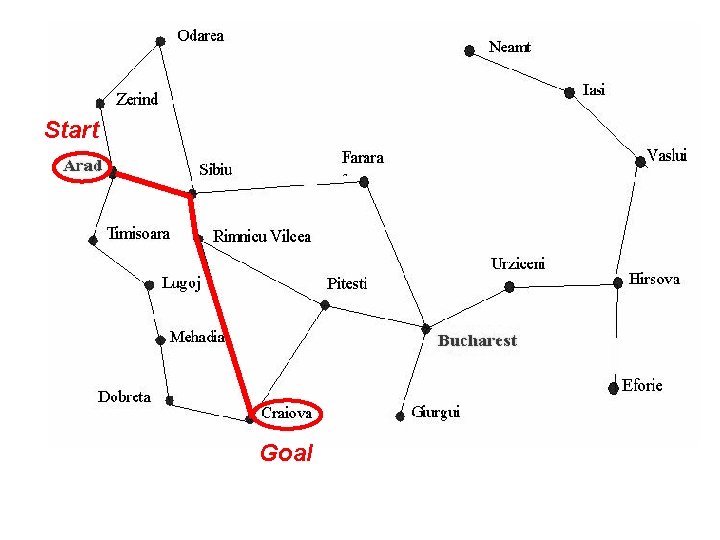
Пример ? - breadth_first([['Arad']], 'Craiova', Path). Path =['Arad', 'Sibiu', 'Rimnicu', 'Craiova']
Start Goal
Start Goal
Търсене в дълбочина (Depthfirst) depth_first([Path|Stack], Goal, Final. Path) : extend(Path, New. Paths), append(New. Paths, Stack, New. Stack), depth_first(New. Stack, Goal, Final. Path).
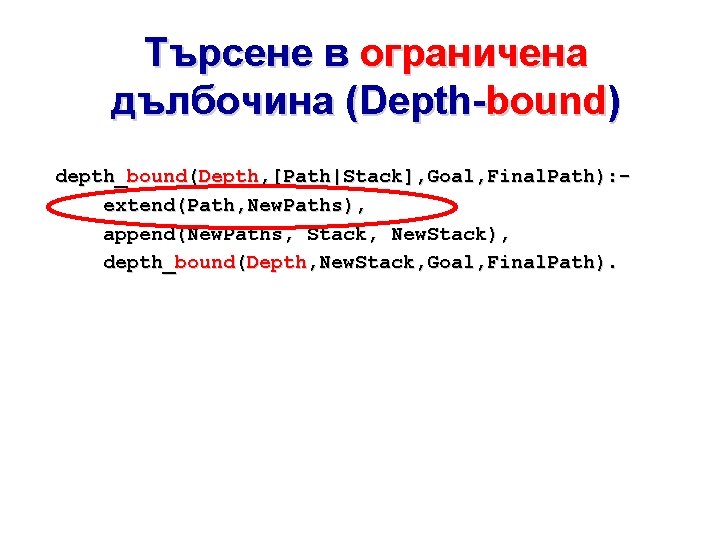
Търсене в ограничена дълбочина (Depth-bound) depth_bound(Depth, [Path|Stack], Goal, Final. Path): extend(Path, New. Paths), append(New. Paths, Stack, New. Stack), depth_bound(Depth, New. Stack, Goal, Final. Path).
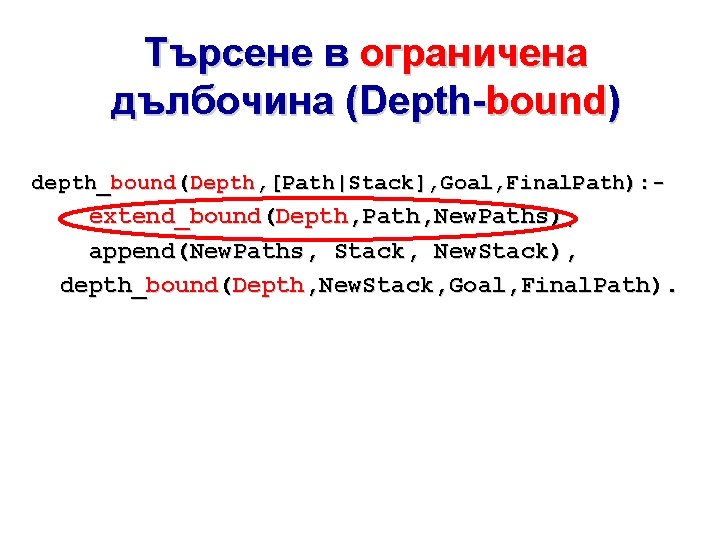
Търсене в ограничена дълбочина (Depth-bound) depth_bound(Depth, [Path|Stack], Goal, Final. Path): - extend_bound(Depth, Path, New. Paths), append(New. Paths, Stack, New. Stack), depth_bound(Depth, New. Stack, Goal, Final. Path).
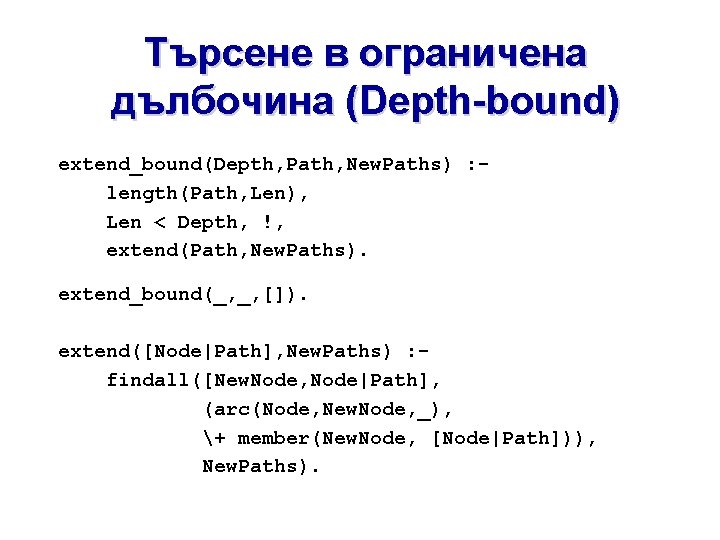
Търсене в ограничена дълбочина (Depth-bound) extend_bound(Depth, Path, New. Paths) : length(Path, Len), Len < Depth, !, extend(Path, New. Paths). extend_bound(_, _, []). extend([Node|Path], New. Paths) : findall([New. Node, Node|Path], (arc(Node, New. Node, _), + member(New. Node, [Node|Path])), New. Paths).
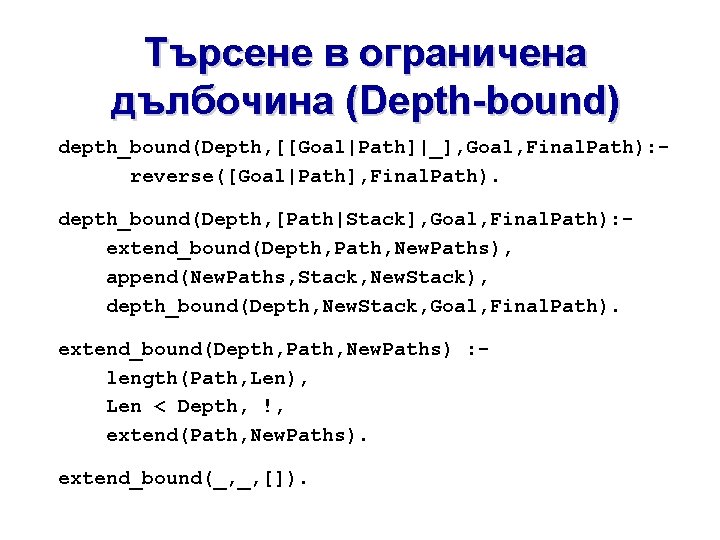
Търсене в ограничена дълбочина (Depth-bound) depth_bound(Depth, [[Goal|Path]|_], Goal, Final. Path): reverse([Goal|Path], Final. Path). depth_bound(Depth, [Path|Stack], Goal, Final. Path): extend_bound(Depth, Path, New. Paths), append(New. Paths, Stack, New. Stack), depth_bound(Depth, New. Stack, Goal, Final. Path). extend_bound(Depth, Path, New. Paths) : length(Path, Len), Len < Depth, !, extend(Path, New. Paths). extend_bound(_, _, []).
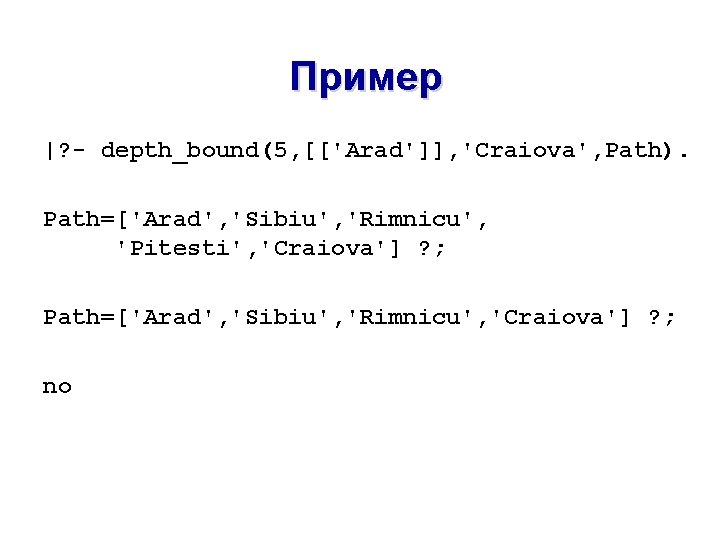
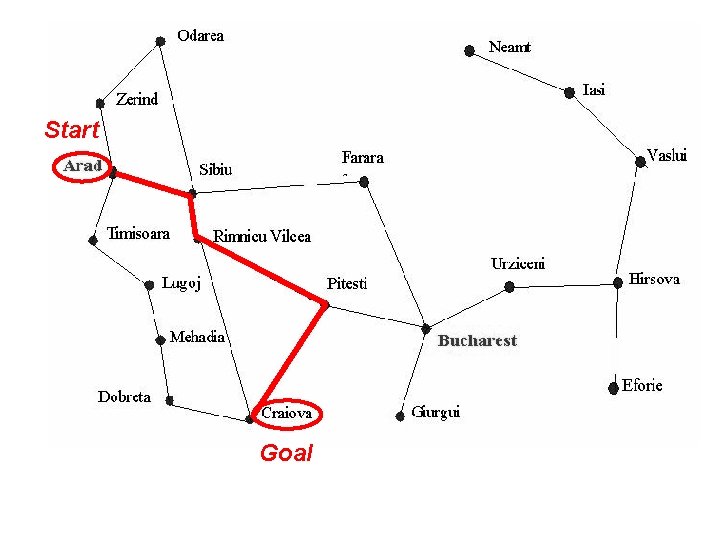
Пример |? - depth_bound(5, [['Arad']], 'Craiova', Path). Path=['Arad', 'Sibiu', 'Rimnicu', 'Pitesti', 'Craiova'] ? ; Path=['Arad', 'Sibiu', 'Rimnicu', 'Craiova'] ? ; no
Start Goal
Start Goal
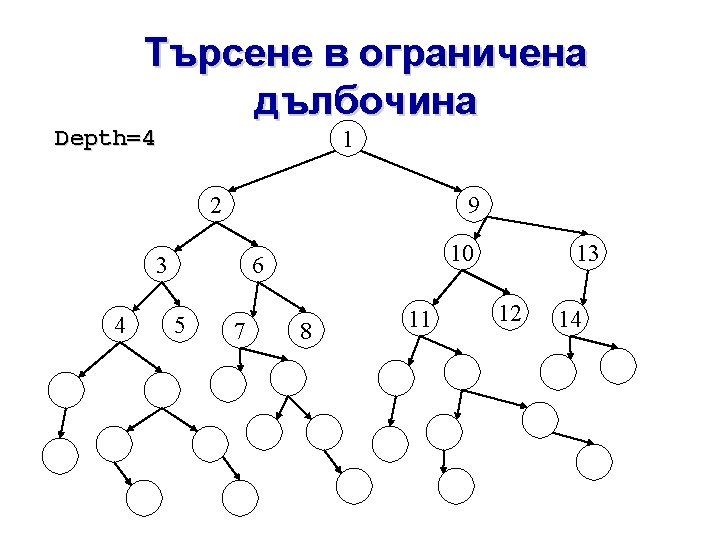
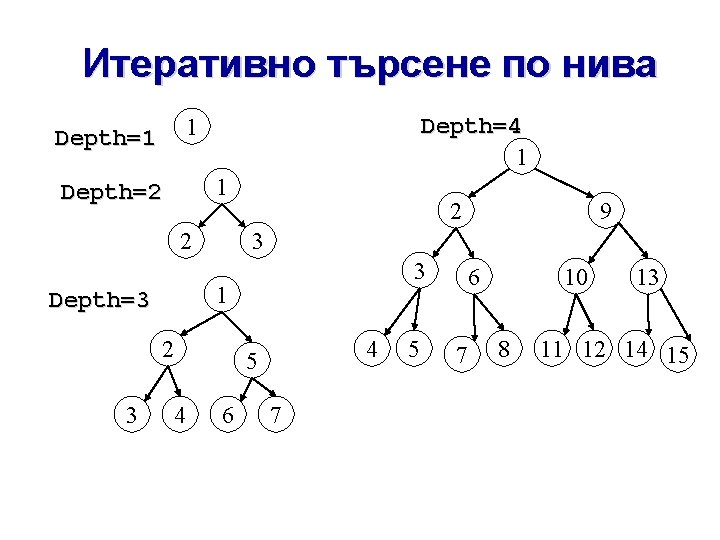
Итеративно търсене по нива Depth=4 1 1 Depth=2 2 2 3 4 5 4 9 3 1 Depth=3 3 2 6 7 5 6 7 10 8 13 11 12 14 15
Итеративно търсене по нива (Iterative deepening) iterative_deepening 1(Depth, Stack, Goal, Path, Max): nl, write(depth=Depth), depth_bound(Depth, Stack, Goal, Path). iterative_deepening 1(Depth, Stack, Goal, Path, Max): Depth 1 is Depth+1, Depth 1 =< Max, !, iterative_deepening 1(Depth 1, Stack, Goal, Path, Max).
Итеративно търсене по нива (Iterative deepening) iterative_deepening(Stack, Goal, Path) : findall(arc(X, Y, Z), Graph), length(Graph, N), iterative_deepening 1(1, Stack, Goal, Path, N). iterative_deepening 1(Depth, Stack, Goal, Path, Max) : nl, write(depth=Depth), depth_bound(Depth, Stack, Goal, Path). iterative_deepening 1(Depth, Stack, Goal, Path, Max) : Depth 1 is Depth+1, Depth 1 =< Max, !, iterative_deepening 1(Depth 1, Stack, Goal, Path, Max).
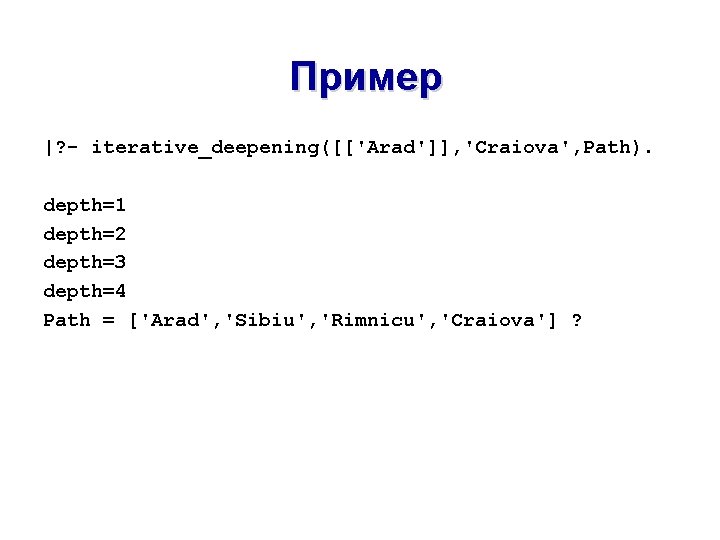
Пример |? - iterative_deepening([['Arad']], 'Craiova', Path). depth=1 depth=2 depth=3 depth=4 Path = ['Arad', 'Sibiu', 'Rimnicu', 'Craiova'] ?
Start Goal
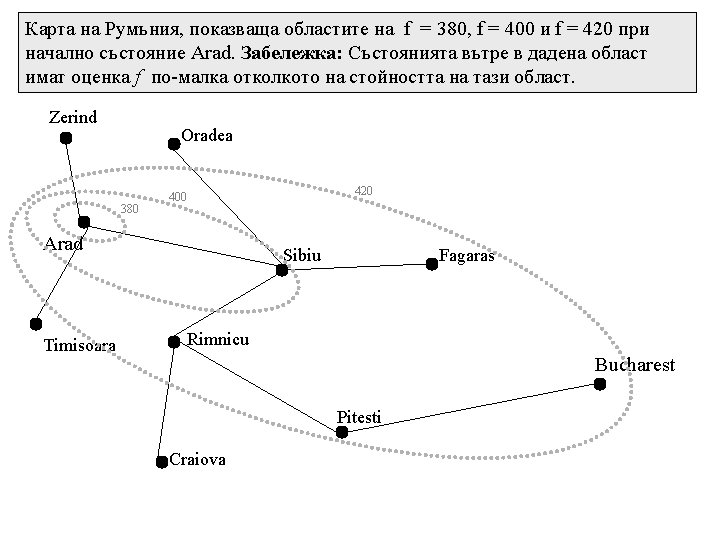
frontier h start node explored nodes unexplored nodes
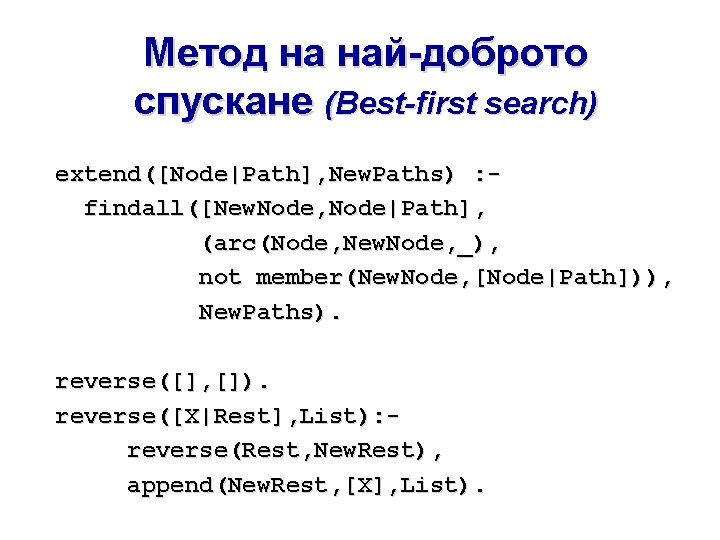
Метод на най-доброто спускане (Best-first search) best_first([[Goal|Path]|_], Goal, Final. Path): reverse([Goal|Path], Final. Path). best_first([Path|List], Goal, Final. Path): extend(Path, New. Paths), append(List, New. Paths, New. List), sort(New. List, Goal, Sorted. List), best_first(Sorted. List, Goal, Final. Path).
Метод на най-доброто спускане (Best-first search) extend([Node|Path], New. Paths) : findall([New. Node, Node|Path], (arc(Node, New. Node, _), not member(New. Node, [Node|Path])), New. Paths). reverse([], []). reverse([X|Rest], List): reverse(Rest, New. Rest), append(New. Rest, [X], List).
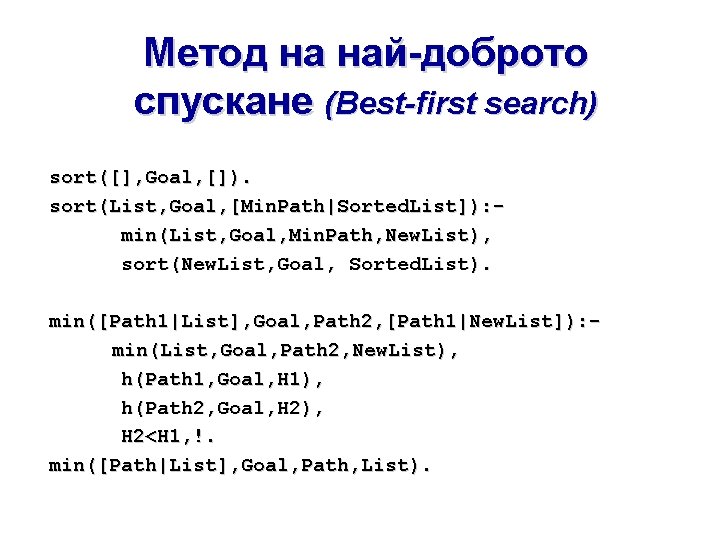
Метод на най-доброто спускане (Best-first search) sort([], Goal, []). sort(List, Goal, [Min. Path|Sorted. List]): min(List, Goal, Min. Path, New. List), sort(New. List, Goal, Sorted. List). min([Path 1|List], Goal, Path 2, [Path 1|New. List]): min(List, Goal, Path 2, New. List), h(Path 1, Goal, H 1), h(Path 2, Goal, H 2), H 2<H 1, !. min([Path|List], Goal, Path, List).
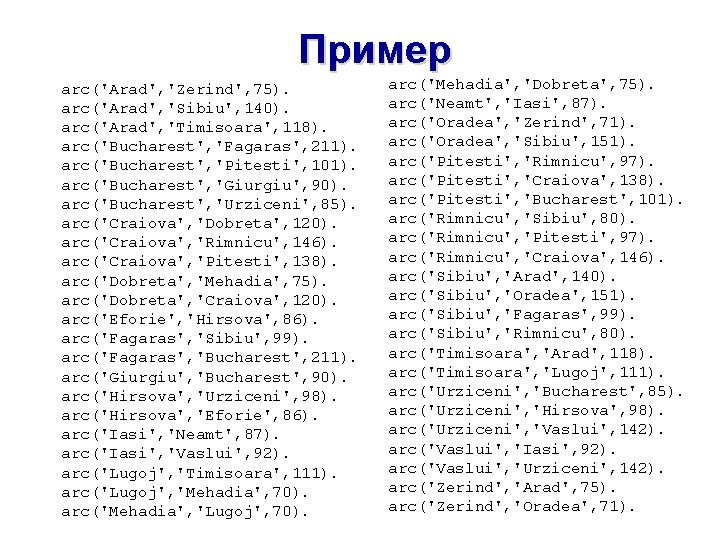
Пример arc('Arad', 'Zerind', 75). arc('Arad', 'Sibiu', 140). arc('Arad', 'Timisoara', 118). arc('Bucharest', 'Fagaras', 211). arc('Bucharest', 'Pitesti', 101). arc('Bucharest', 'Giurgiu', 90). arc('Bucharest', 'Urziceni', 85). arc('Craiova', 'Dobreta', 120). arc('Craiova', 'Rimnicu', 146). arc('Craiova', 'Pitesti', 138). arc('Dobreta', 'Mehadia', 75). arc('Dobreta', 'Craiova', 120). arc('Eforie', 'Hirsova', 86). arc('Fagaras', 'Sibiu', 99). arc('Fagaras', 'Bucharest', 211). arc('Giurgiu', 'Bucharest', 90). arc('Hirsova', 'Urziceni', 98). arc('Hirsova', 'Eforie', 86). arc('Iasi', 'Neamt', 87). arc('Iasi', 'Vaslui', 92). arc('Lugoj', 'Timisoara', 111). arc('Lugoj', 'Mehadia', 70). arc('Mehadia', 'Lugoj', 70). arc('Mehadia', 'Dobreta', 75). arc('Neamt', 'Iasi', 87). arc('Oradea', 'Zerind', 71). arc('Oradea', 'Sibiu', 151). arc('Pitesti', 'Rimnicu', 97). arc('Pitesti', 'Craiova', 138). arc('Pitesti', 'Bucharest', 101). arc('Rimnicu', 'Sibiu', 80). arc('Rimnicu', 'Pitesti', 97). arc('Rimnicu', 'Craiova', 146). arc('Sibiu', 'Arad', 140). arc('Sibiu', 'Oradea', 151). arc('Sibiu', 'Fagaras', 99). arc('Sibiu', 'Rimnicu', 80). arc('Timisoara', 'Arad', 118). arc('Timisoara', 'Lugoj', 111). arc('Urziceni', 'Bucharest', 85). arc('Urziceni', 'Hirsova', 98). arc('Urziceni', 'Vaslui', 142). arc('Vaslui', 'Iasi', 92). arc('Vaslui', 'Urziceni', 142). arc('Zerind', 'Arad', 75). arc('Zerind', 'Oradea', 71).
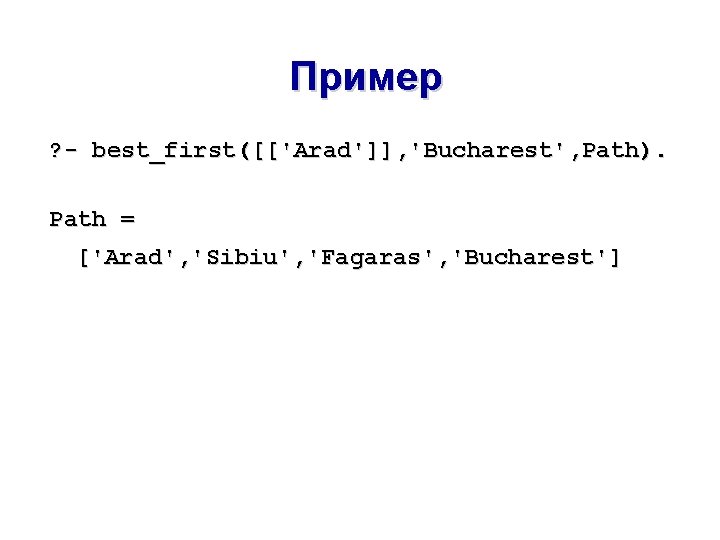
Пример ? - best_first([['Arad']], 'Bucharest', Path). Path = ['Arad', 'Sibiu', 'Fagaras', 'Bucharest']
Start Goal
Start Goal
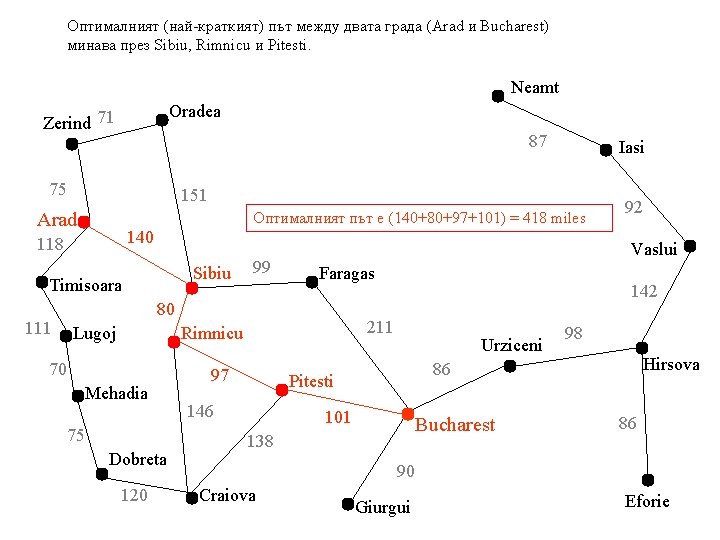
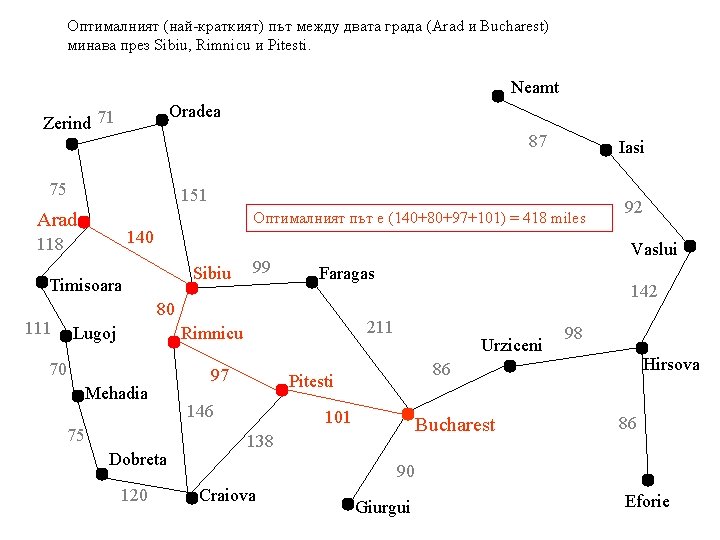
Оптималният (най-краткият) път между двата града (Arad и Bucharest) минава през Sibiu, Rimnicu и Pitesti. Neamt Oradea Zerind 71 87 75 151 Arad Оптималният път е (140+80+97+101) = 418 miles 140 118 Sibiu Timisoara 99 Lugoj Faragas Mehadia 75 Dobreta 120 142 211 Rimnicu 70 97 Urziceni 98 Hirsova 86 Pitesti 146 92 Vaslui 80 111 Iasi 101 Bucharest 138 86 90 Craiova Giurgui Eforie
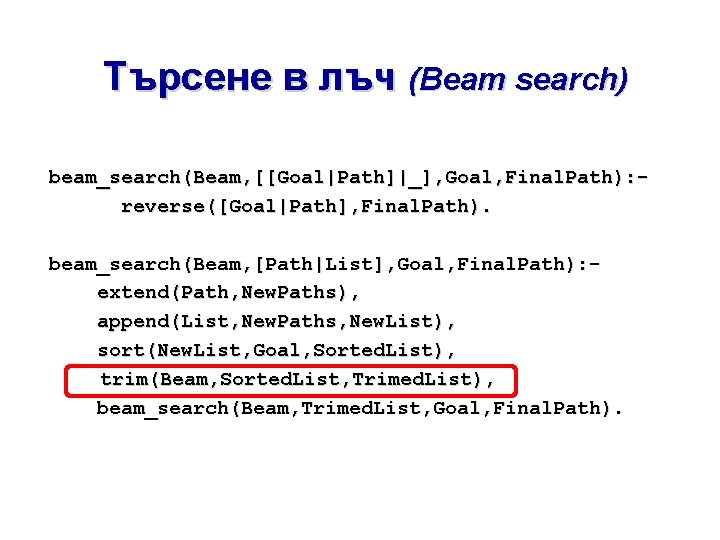
Търсене в лъч (Beam search) beam_search(Beam, [[Goal|Path]|_], Goal, Final. Path): reverse([Goal|Path], Final. Path). beam_search(Beam, [Path|List], Goal, Final. Path): extend(Path, New. Paths), append(List, New. Paths, New. List), sort(New. List, Goal, Sorted. List), trim(Beam, Sorted. List, Trimed. List), beam_search(Beam, Trimed. List, Goal, Final. Path).
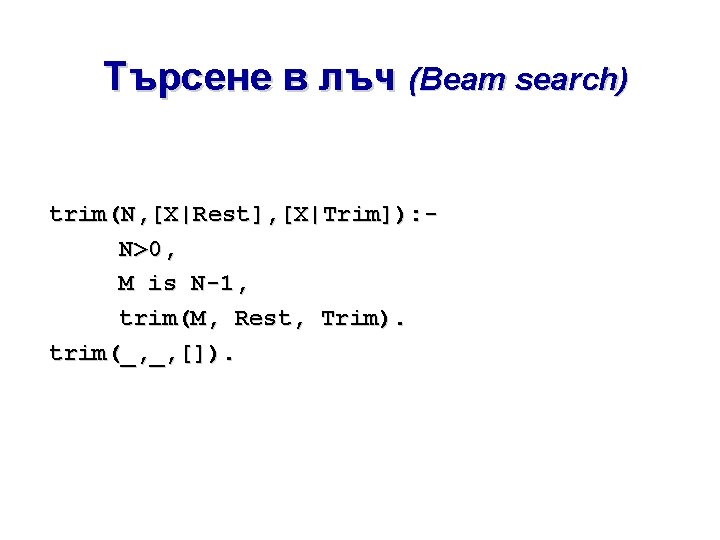
Търсене в лъч (Beam search) trim(N, [X|Rest], [X|Trim]): N>0, M is N-1, trim(M, Rest, Trim). trim(_, _, []).
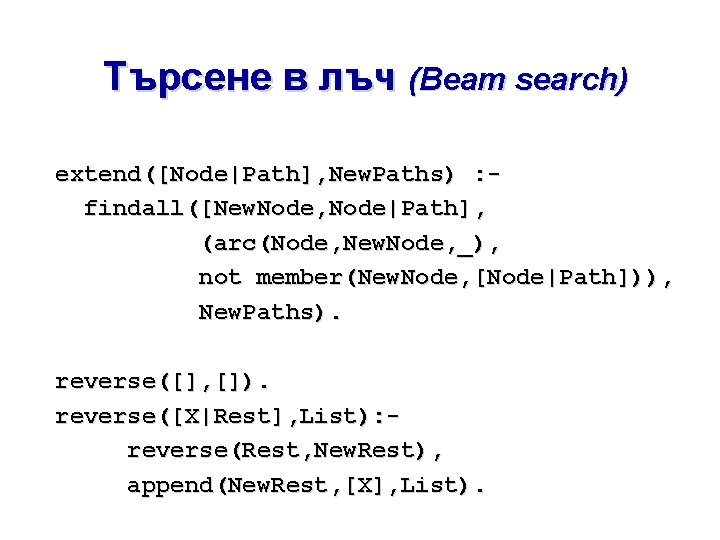
Търсене в лъч (Beam search) extend([Node|Path], New. Paths) : findall([New. Node, Node|Path], (arc(Node, New. Node, _), not member(New. Node, [Node|Path])), New. Paths). reverse([], []). reverse([X|Rest], List): reverse(Rest, New. Rest), append(New. Rest, [X], List).
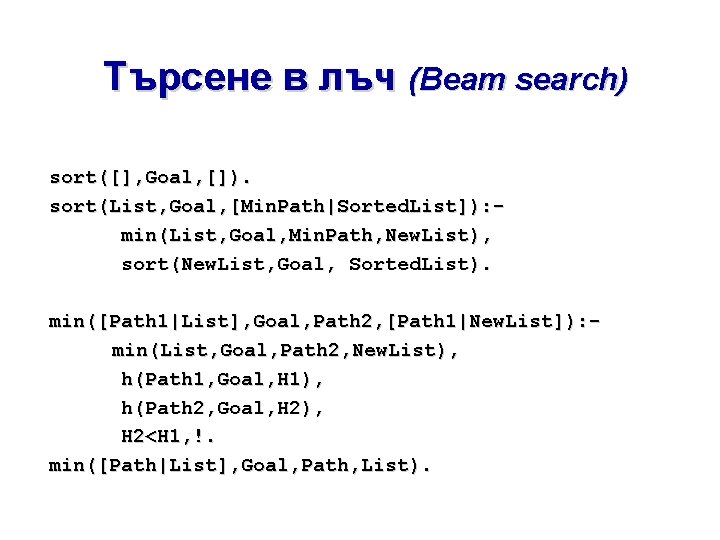
Търсене в лъч (Beam search) sort([], Goal, []). sort(List, Goal, [Min. Path|Sorted. List]): min(List, Goal, Min. Path, New. List), sort(New. List, Goal, Sorted. List). min([Path 1|List], Goal, Path 2, [Path 1|New. List]): min(List, Goal, Path 2, New. List), h(Path 1, Goal, H 1), h(Path 2, Goal, H 2), H 2<H 1, !. min([Path|List], Goal, Path, List).
Метод на изкачването (Hill Climbing) - 1 hill_climbing(List, Goal, Final. Path): beam_search(1, List, Goal, Final. Path).
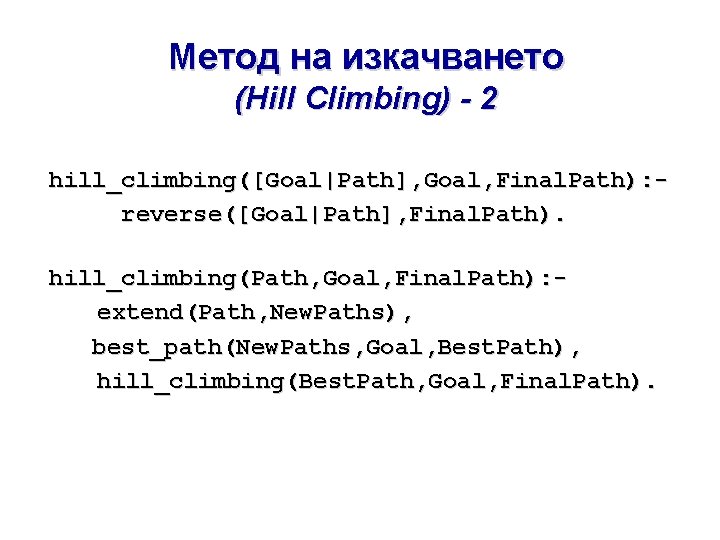
Метод на изкачването (Hill Climbing) - 2 hill_climbing([Goal|Path], Goal, Final. Path): reverse([Goal|Path], Final. Path). hill_climbing(Path, Goal, Final. Path): extend(Path, New. Paths), best_path(New. Paths, Goal, Best. Path), hill_climbing(Best. Path, Goal, Final. Path).
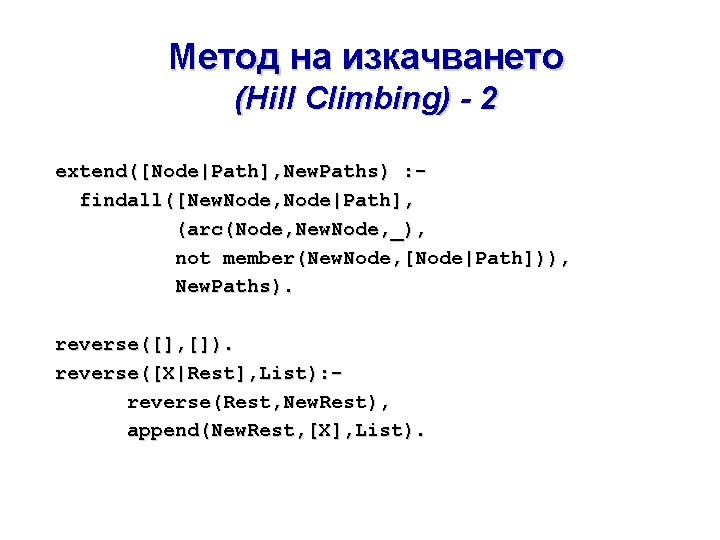
Метод на изкачването (Hill Climbing) - 2 extend([Node|Path], New. Paths) : findall([New. Node, Node|Path], (arc(Node, New. Node, _), not member(New. Node, [Node|Path])), New. Paths). reverse([], []). reverse([X|Rest], List): reverse(Rest, New. Rest), append(New. Rest, [X], List).
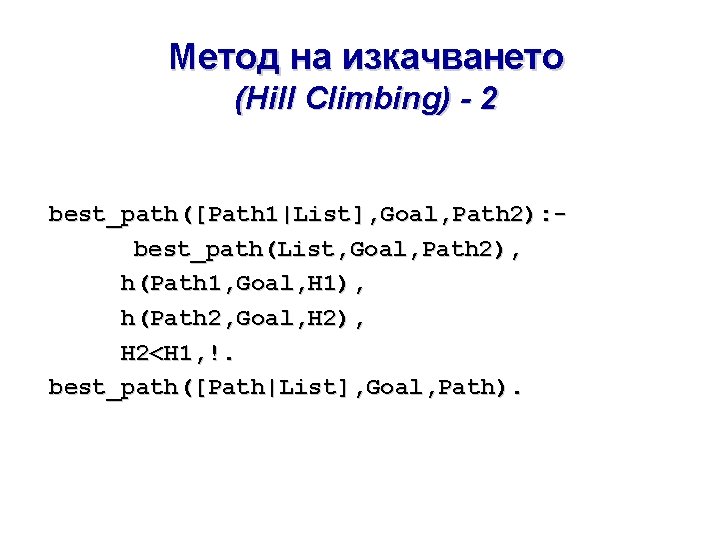
Метод на изкачването (Hill Climbing) - 2 best_path([Path 1|List], Goal, Path 2): best_path(List, Goal, Path 2), h(Path 1, Goal, H 1), h(Path 2, Goal, H 2), H 2<H 1, !. best_path([Path|List], Goal, Path).
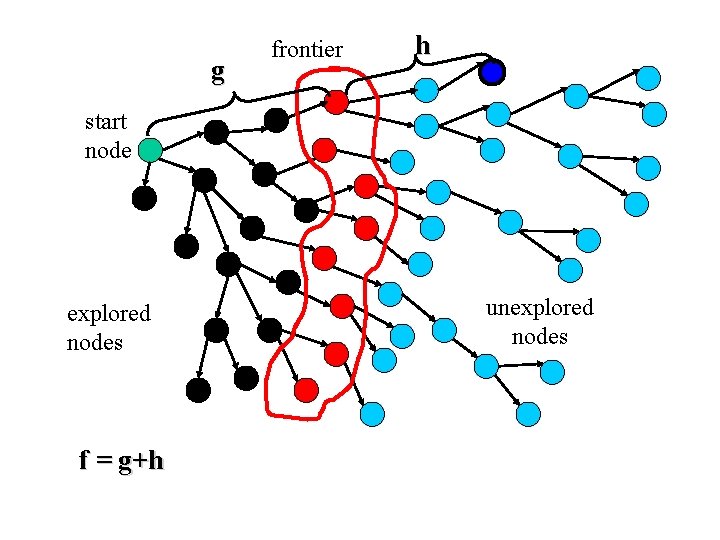
g frontier h start node explored nodes f = g+h unexplored nodes
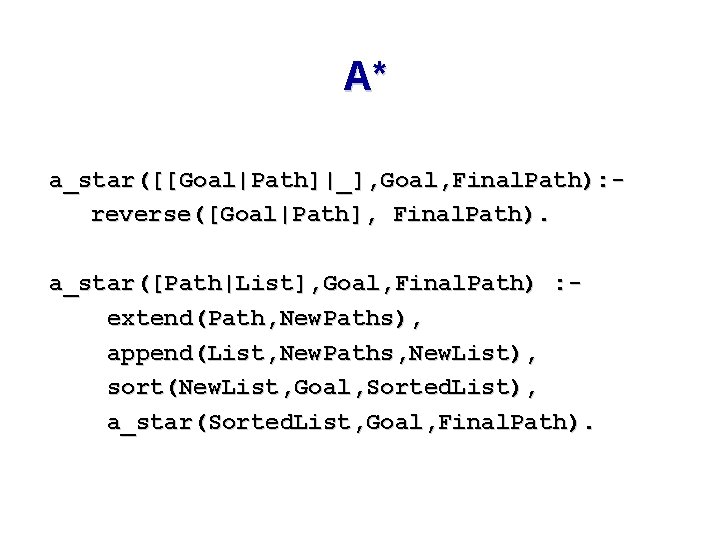
A* a_star([[Goal|Path]|_], Goal, Final. Path): reverse([Goal|Path], Final. Path). a_star([Path|List], Goal, Final. Path) : extend(Path, New. Paths), append(List, New. Paths, New. List), sort(New. List, Goal, Sorted. List), a_star(Sorted. List, Goal, Final. Path).
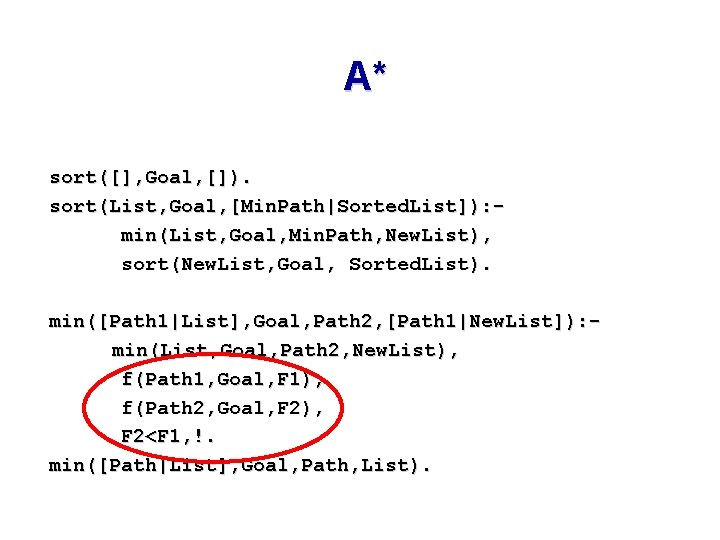
A* sort([], Goal, []). sort(List, Goal, [Min. Path|Sorted. List]): min(List, Goal, Min. Path, New. List), sort(New. List, Goal, Sorted. List). min([Path 1|List], Goal, Path 2, [Path 1|New. List]): min(List, Goal, Path 2, New. List), f(Path 1, Goal, F 1), f(Path 2, Goal, F 2), F 2<F 1, !. min([Path|List], Goal, Path, List).
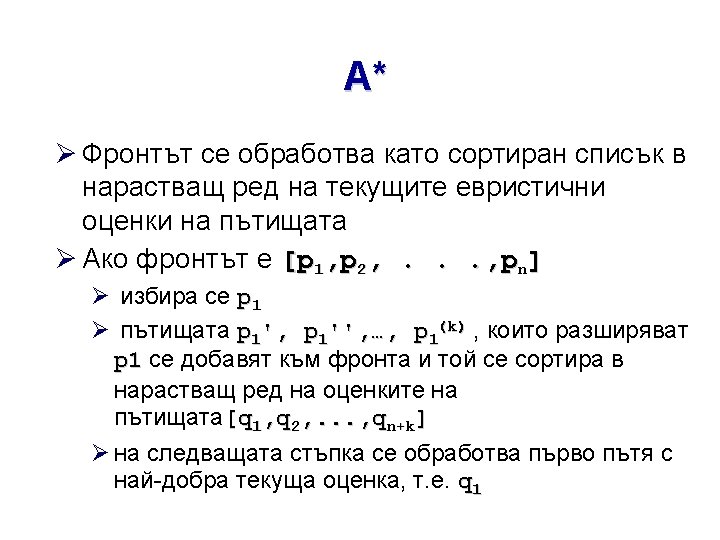
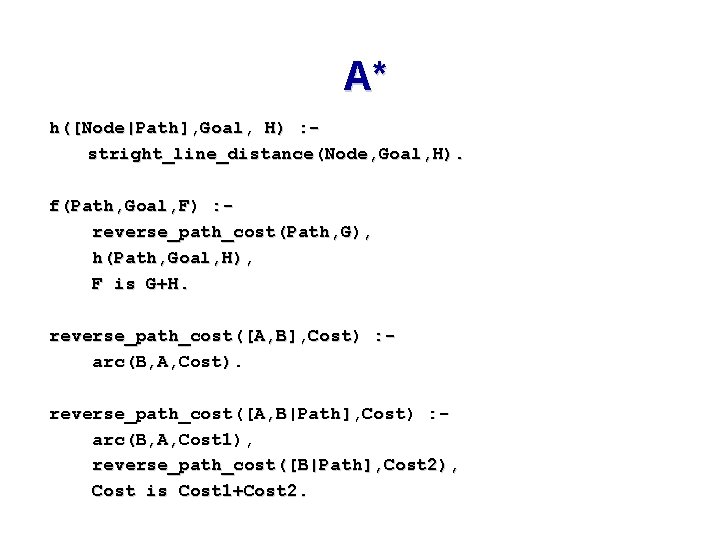
A* h([Node|Path], Goal, H) : stright_line_distance(Node, Goal, H). f(Path, Goal, F) : reverse_path_cost(Path, G), h(Path, Goal, H), F is G+H. reverse_path_cost([A, B], Cost) : arc(B, A, Cost). reverse_path_cost([A, B|Path], Cost) : arc(B, A, Cost 1), reverse_path_cost([B|Path], Cost 2), Cost is Cost 1+Cost 2.
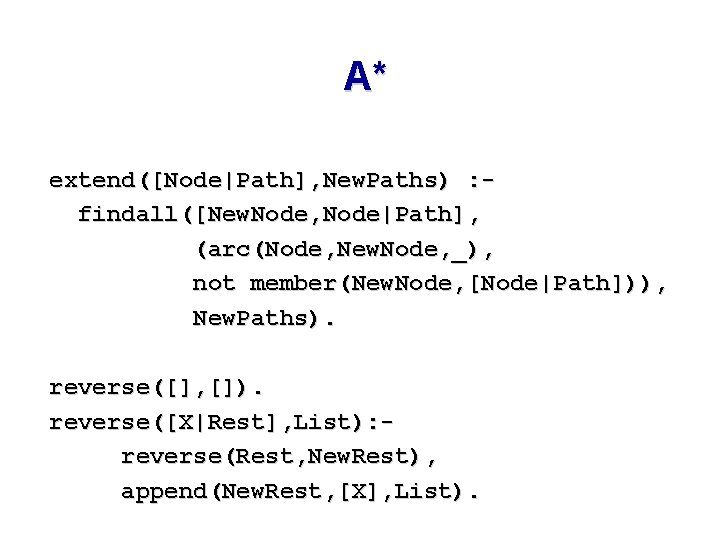
A* extend([Node|Path], New. Paths) : findall([New. Node, Node|Path], (arc(Node, New. Node, _), not member(New. Node, [Node|Path])), New. Paths). reverse([], []). reverse([X|Rest], List): reverse(Rest, New. Rest), append(New. Rest, [X], List).
Оптималният (най-краткият) път между двата града (Arad и Bucharest) минава през Sibiu, Rimnicu и Pitesti. Neamt Oradea Zerind 71 87 75 151 Arad Оптималният път е (140+80+97+101) = 418 miles 140 118 Sibiu Timisoara 99 Lugoj Faragas Mehadia 75 Dobreta 120 142 211 Rimnicu 70 97 Urziceni 98 Hirsova 86 Pitesti 146 92 Vaslui 80 111 Iasi 101 Bucharest 138 86 90 Craiova Giurgui Eforie
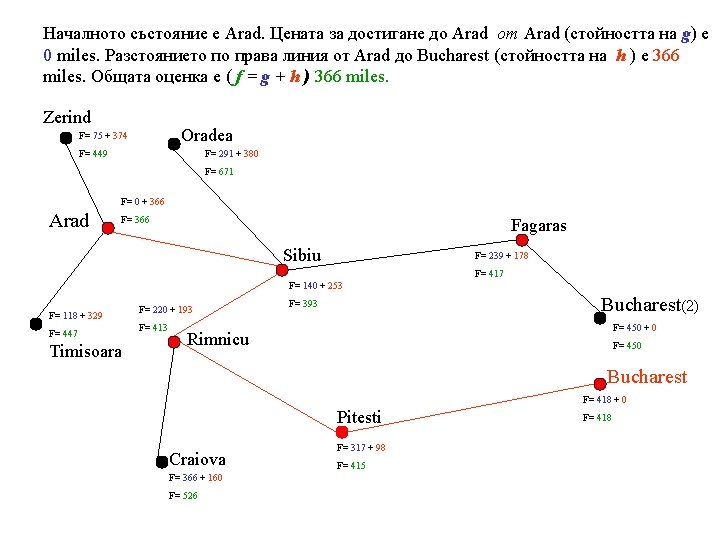
Началното състояние е Arad. Цената за достигане до Arad от Arad (стойността на g) е 0 miles. Разстоянието по права линия от Arad до Bucharest (стойността на h ) е 366 miles. Общата оценка е ( f = g + h ) 366 miles. Zerind Oradea F= 75 + 374 F= 449 F= 291 + 380 F= 671 F= 0 + 366 Arad F= 366 Fagaras Sibiu F= 239 + 178 F= 417 F= 140 + 253 F= 118 + 329 F= 447 Timisoara F= 220 + 193 F= 413 Bucharest(2) F= 393 F= 450 + 0 Rimnicu F= 450 Bucharest F= 418 + 0 Pitesti Craiova F= 366 + 160 F= 526 F= 317 + 98 F= 415 F= 418
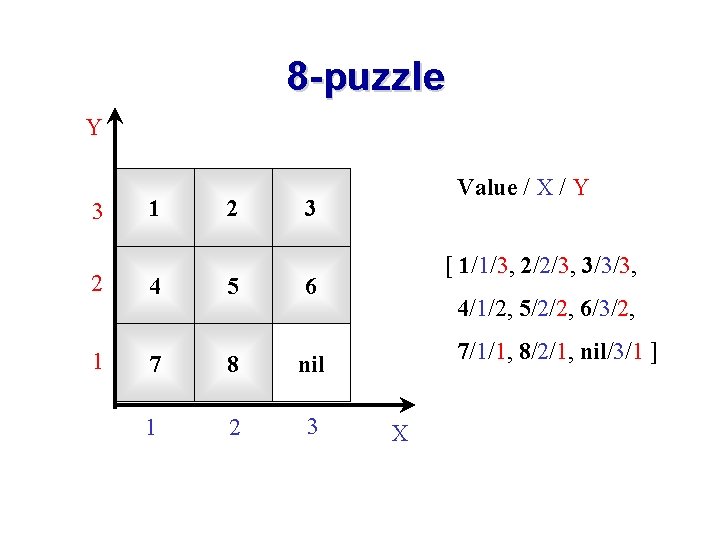
8 -puzzle Y 3 1 2 Value / X / Y 3 2 4 5 6 1 7 8 nil 1 2 3 [ 1/1/3, 2/2/3, 3/3/3, 4/1/2, 5/2/2, 6/3/2, 7/1/1, 8/2/1, nil/3/1 ] X
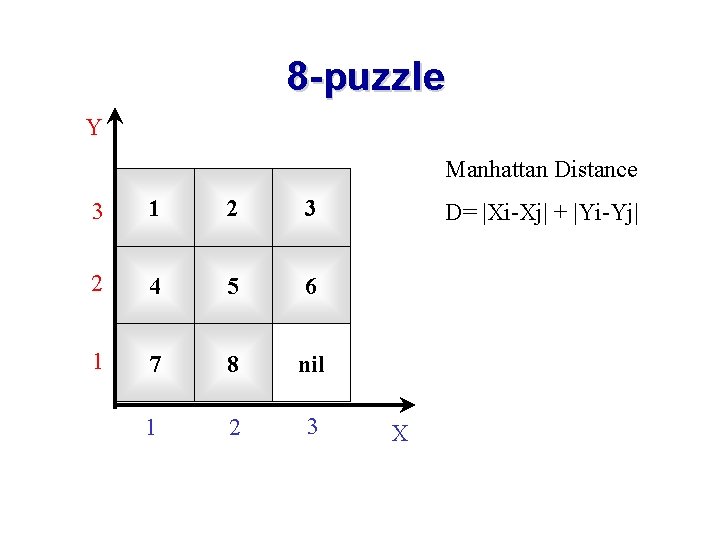
8 -puzzle Y Manhattan Distance 3 1 2 3 2 4 5 6 1 7 8 nil 1 2 3 D= |Xi-Xj| + |Yi-Yj| X
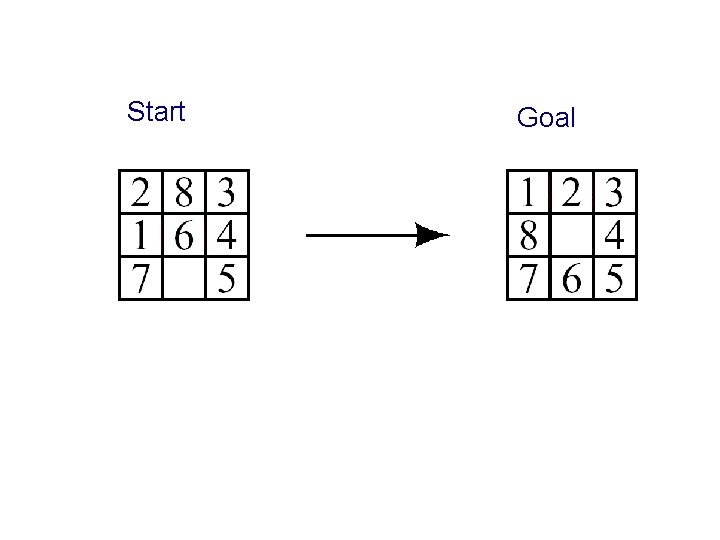
Start Goal