
Pixel tracker update 1 Vertex improvements after GSI
- Slides: 11
Pixel tracker update 1. Vertex improvements after GSI data taking 2. Inner Tracker ( IT ) status 3. Magnetic system 4. Overall mechanical support (S. Tomassini report) 6. Conclusions 05/12/2019 E. Spiriti (FOOT GM - Roma) 1
Vertex improvements after GSI data taking Two main problems in the April GSI Data Taking Vertex readout: • Wrong FPGA internal firmware trigger delay The delay was the one foreseen for the M 26 sensor used in FIRST. The size was about half and so was the integration time ( one frame readout time ). The Delay was set in number of frames! Tested at the BTF in june using an external time unit. Firmware modified accordingly. • Data from one sensor arrives form two serial line, 16 MSBs from one and 16 LSBs from the second. They are desrialized in the FPGA and assembled in one word by the readout code running in the ARM linux CPU ( in the FPGA ) code. A bug, writing zero instead the real data in some special situations has been removed. Those two problems produced a strong reduction of efficiency down to about 25%!!!!!! 05/12/2019 E. Spiriti (FOOT GM - Roma) 2
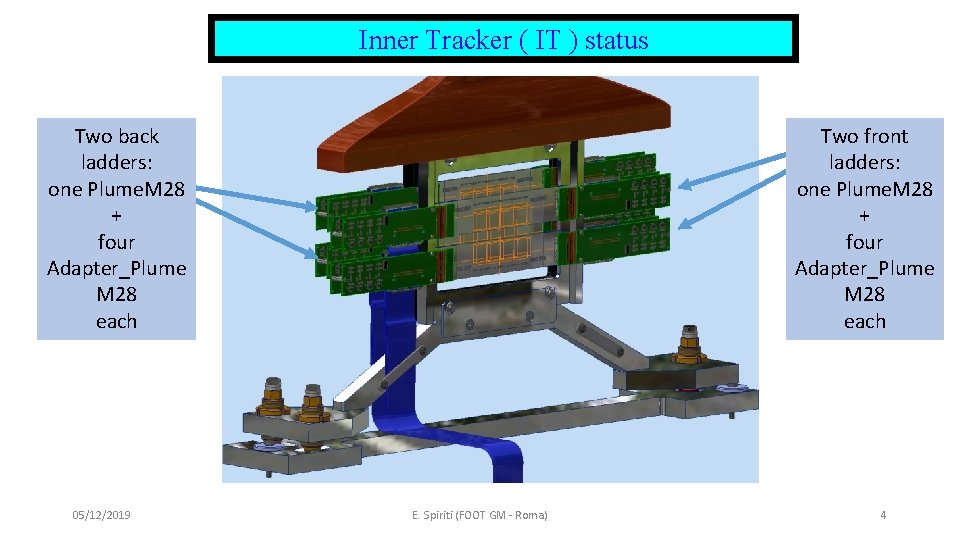
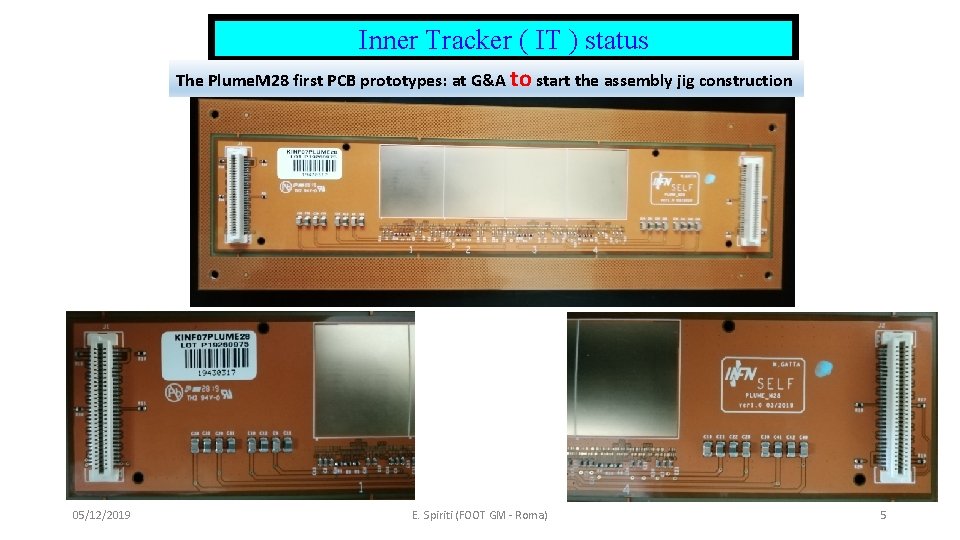
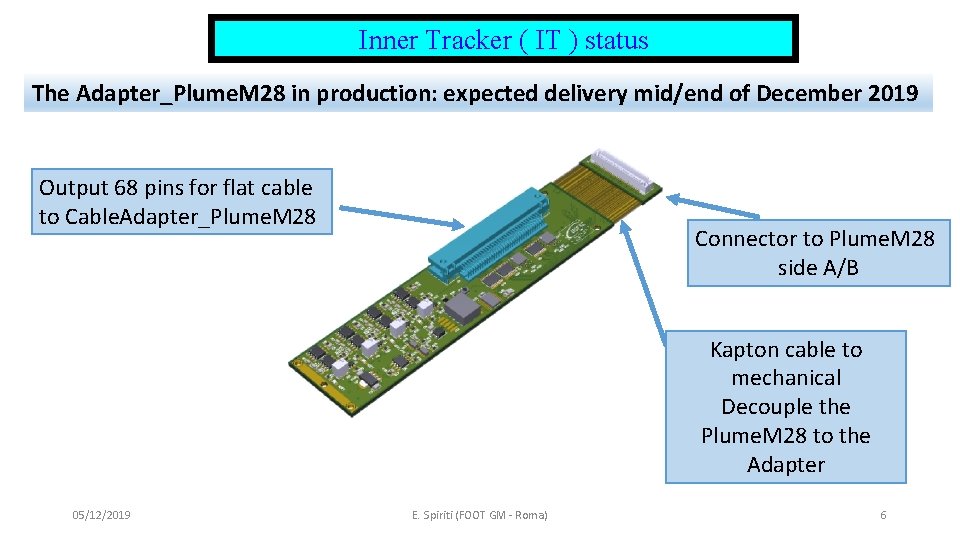
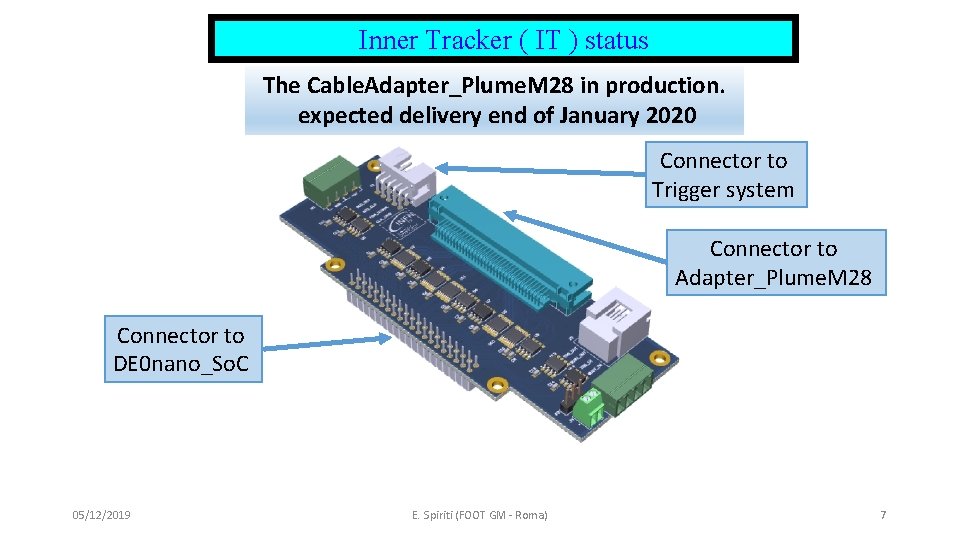
Inner Tracker ( IT ) status The CADENCE problem caused a delay in the schedule from 6 to 9 months. Overall for the IT we need 3 differnt PCBs: • Plume. M 28 ( kapton PCB ) to hold the sensors 1 Plume. M 28 holds 4 sensors and is definde a module. Two glued modules assembled with a RVC ( Resistive Vitreous Carbon foam ) spacer thick 2 mm forms a Ladder. The Inner Tracker is composed by 4 Ladders covering (acceptance ) about 8 x 8 cm. • Adapter_Plume. M 28 ( Flex-Rigid PCB ) to collect signals from 2 sensors ( half of Plume. M 28 ) on each side of a module and houses transcievers, monitors currents and voltages and includes “interlock” circuitry. Each adpapter_Plume. M 28 is connected by a 68 wires flat cable to the subsequent Cable. Adapter_Plume. M 28 board. • Cable. Adapter_Plume. M 28 that translates all differential signals to single ended, provide the power supplies and master the Tigger, Busy, clocsk, etc… control signal. Two of this boards ( we need 16 of this boards ) are connectet to a DE 0_nano_So. C 05/12/2019 E. Spiriti (FOOT GM - Roma) 3
Inner Tracker ( IT ) status Two back ladders: one Plume. M 28 + four Adapter_Plume M 28 each 05/12/2019 Two front ladders: one Plume. M 28 + four Adapter_Plume M 28 each E. Spiriti (FOOT GM - Roma) 4
Inner Tracker ( IT ) status The Plume. M 28 first PCB prototypes: at G&A to start the assembly jig construction 05/12/2019 E. Spiriti (FOOT GM - Roma) 5
Inner Tracker ( IT ) status The Adapter_Plume. M 28 in production: expected delivery mid/end of December 2019 Output 68 pins for flat cable to Cable. Adapter_Plume. M 28 Connector to Plume. M 28 side A/B Kapton cable to mechanical Decouple the Plume. M 28 to the Adapter 05/12/2019 E. Spiriti (FOOT GM - Roma) 6
Inner Tracker ( IT ) status The Cable. Adapter_Plume. M 28 in production. expected delivery end of January 2020 Connector to Trigger system Connector to Adapter_Plume. M 28 Connector to DE 0 nano_So. C 05/12/2019 E. Spiriti (FOOT GM - Roma) 7
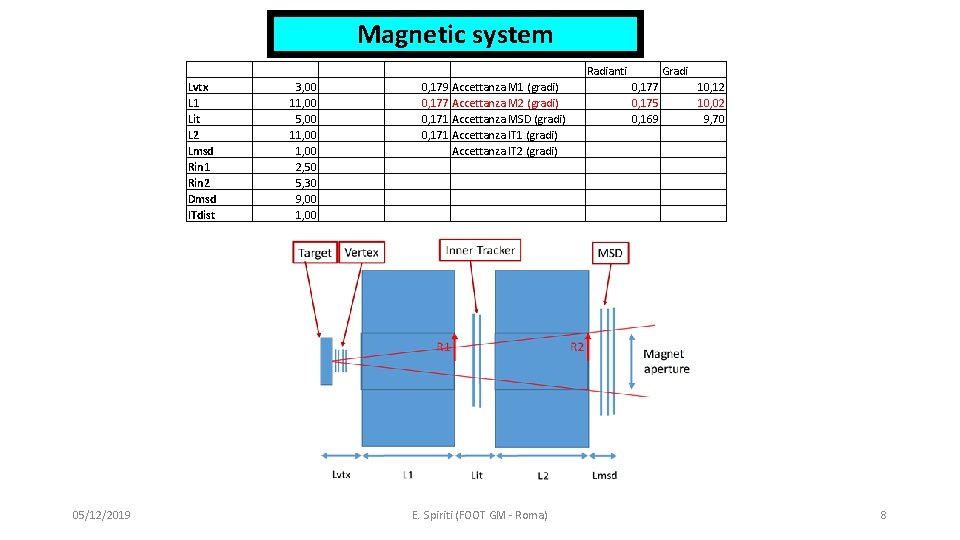
Magnetic system Lvtx L 1 Lit L 2 Lmsd Rin 1 Rin 2 Dmsd ITdist 05/12/2019 3, 00 11, 00 5, 00 11, 00 2, 50 5, 30 9, 00 1, 00 0, 179 Accettanza M 1 (gradi) 0, 177 Accettanza M 2 (gradi) 0, 171 Accettanza MSD (gradi) 0, 171 Accettanza IT 1 (gradi) Accettanza IT 2 (gradi) E. Spiriti (FOOT GM - Roma) Radianti Gradi 0, 177 0, 175 0, 169 10, 12 10, 02 9, 70 8
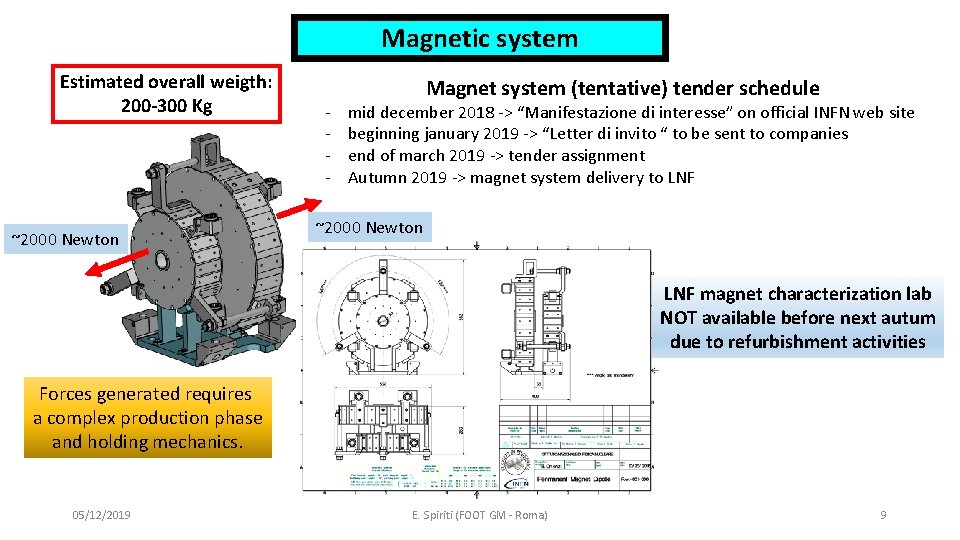
Magnetic system Estimated overall weigth: 200 -300 Kg ~2000 Newton - Magnet system (tentative) tender schedule mid december 2018 -> “Manifestazione di interesse” on official INFN web site beginning january 2019 -> “Letter di invito “ to be sent to companies end of march 2019 -> tender assignment Autumn 2019 -> magnet system delivery to LNF ~2000 Newton LNF magnet characterization lab NOT available before next autum due to refurbishment activities Forces generated requires a complex production phase and holding mechanics. 05/12/2019 E. Spiriti (FOOT GM - Roma) 9
Magnetic system The first half of 2019 was devoted to the Magnet bids: • Six companies invited: • Three participants • One company was compliant with the price • No one accepted the “contractual conditions” they want a sizeble amount of money in advance 50/60% of cost is magnetic material. We are starting a new bid: • Increased the overall budget • New contractual conditions • New RUP: A. Moggi from Pisa Really many thanks to our Pisa collaborators 05/12/2019 E. Spiriti (FOOT GM - Roma) 10
Conclusions FOOT tracker mechanical setup: • A realistic solution has been envisaged • Construction foreseen for next year (2020) • Financial request to “commissione III” (FUNDS GRANTED – Sufficient? ? ? ) Pixel vertex detector: ( DONE ) • The basic block holding PCB constructed and tested • Test in vacuum successful • New daq system ready • Firmware for threshold scan debugged Software procedure available. Magnet system: • Final technical decision taken • Market search accomplished • Funding upgrade obtained by Comm. III (Sufficient? ) • All elements to start the NEW bid prepared (bureucracy under way) Inner tracker: • All board designed and in production • All pieces available or under production • The overall mechanical solution defined • Jigs for assembly to be constructed for final construction at G&A. 05/12/2019 E. Spiriti (FOOT GM - Roma) 11