
Online GraphBased Tracking Postech Computer Vision Lab Hyeonseob
Online Graph-Based Tracking Postech Computer Vision Lab. Hyeonseob Nam
Outline • Introduction • Algorithm Overview • Main Algorithm – Density Propagation – Weighted Density Aggregation – Model Update • Results
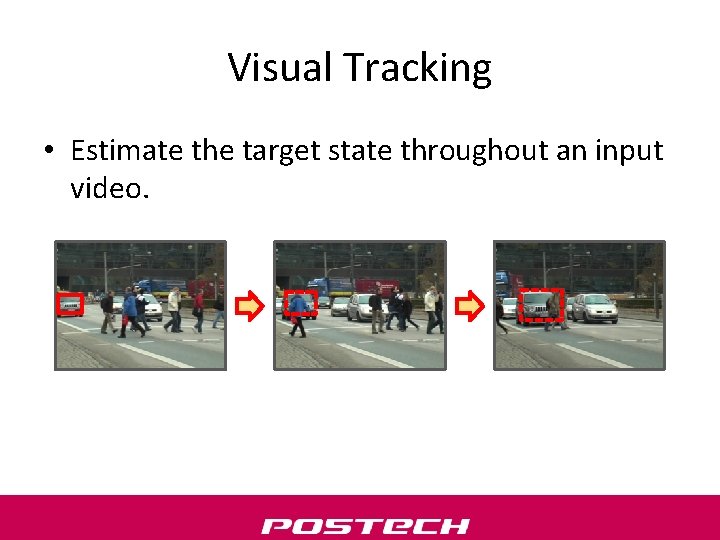
Visual Tracking • Estimate the target state throughout an input video.
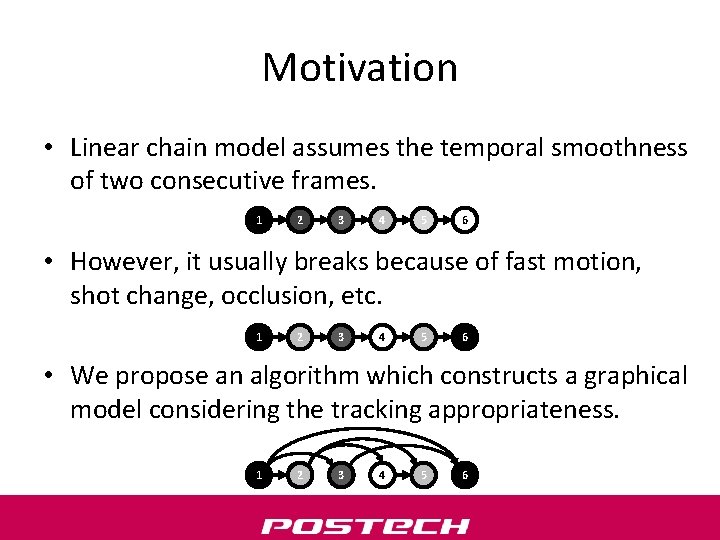
Motivation • Linear chain model assumes the temporal smoothness of two consecutive frames. 1 2 3 4 5 6 • However, it usually breaks because of fast motion, shot change, occlusion, etc. 1 2 3 4 5 6 • We propose an algorithm which constructs a graphical model considering the tracking appropriateness. 1 2 3 4 5 6
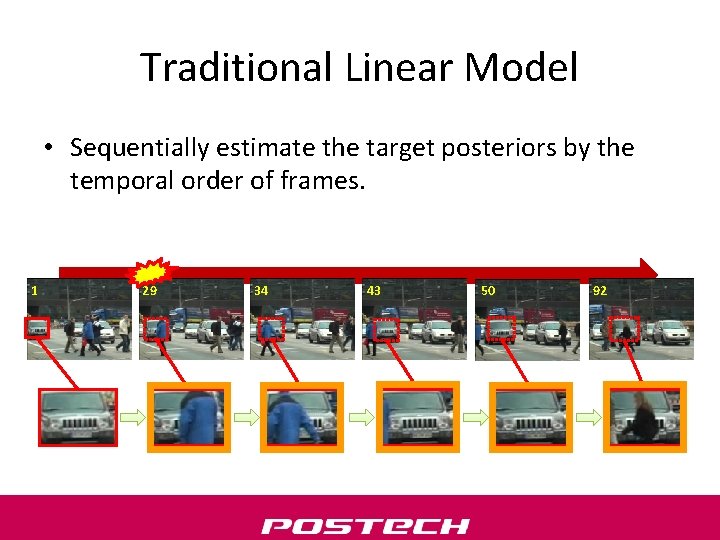
Traditional Linear Model • Sequentially estimate the target posteriors by the temporal order of frames. 1 29 34 43 50 92
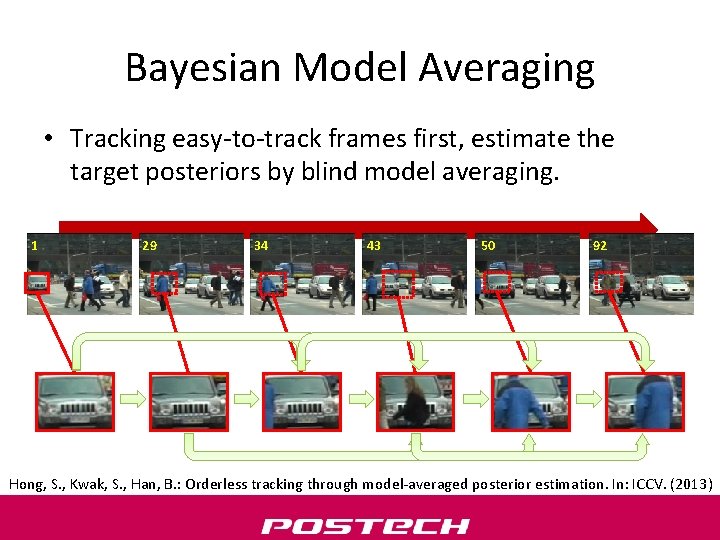
Bayesian Model Averaging • Tracking easy-to-track frames first, estimate the target posteriors by blind model averaging. 1 29 34 43 50 92 Hong, S. , Kwak, S. , Han, B. : Orderless tracking through model-averaged posterior estimation. In: ICCV. (2013)
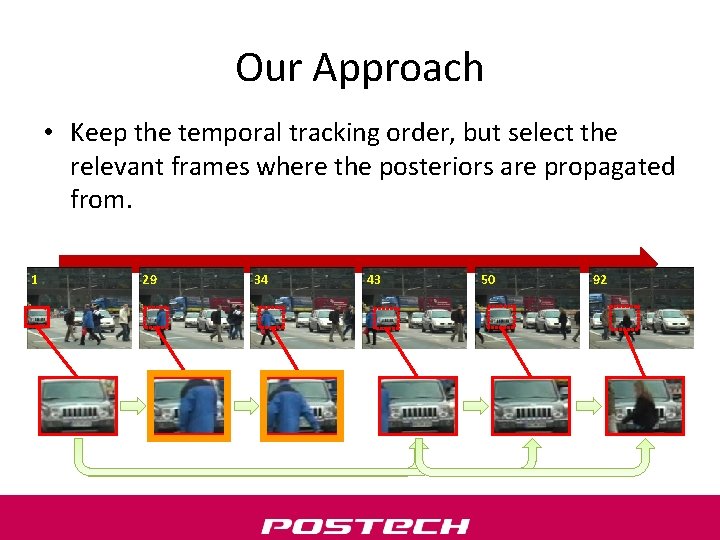
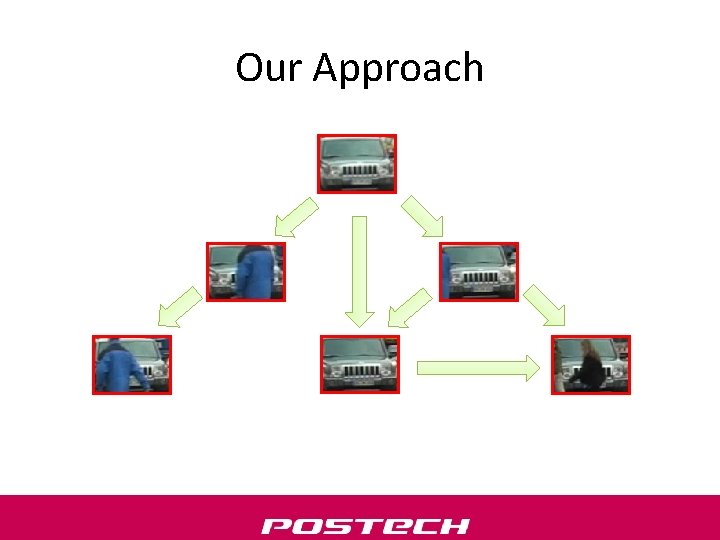
Our Approach • Keep the temporal tracking order, but select the relevant frames where the posteriors are propagated from. 1 29 34 43 50 92
Our Approach
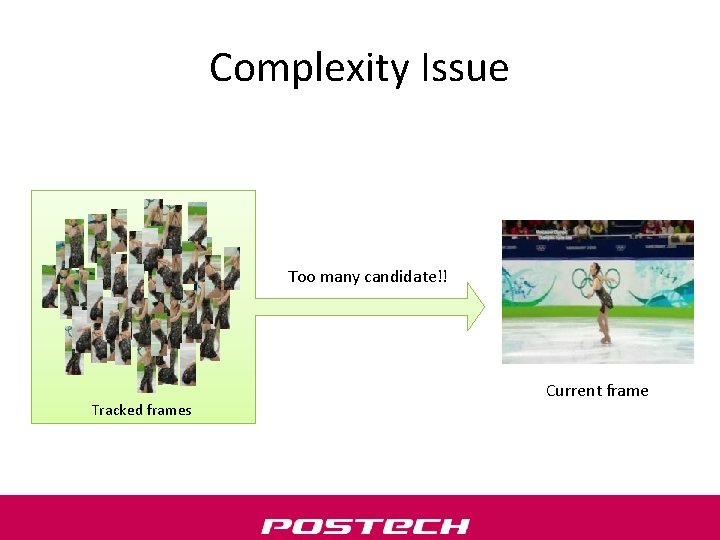
Complexity Issue Too many candidate!! Tracked frames Current frame
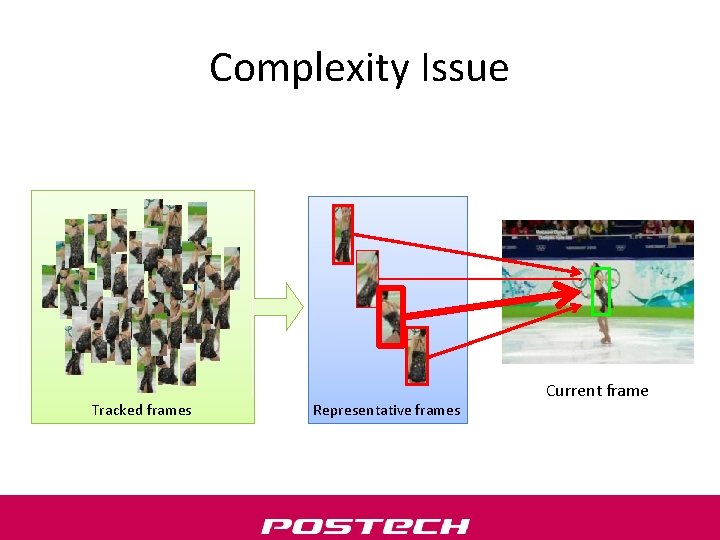
Complexity Issue Tracked frames Representative frames Current frame
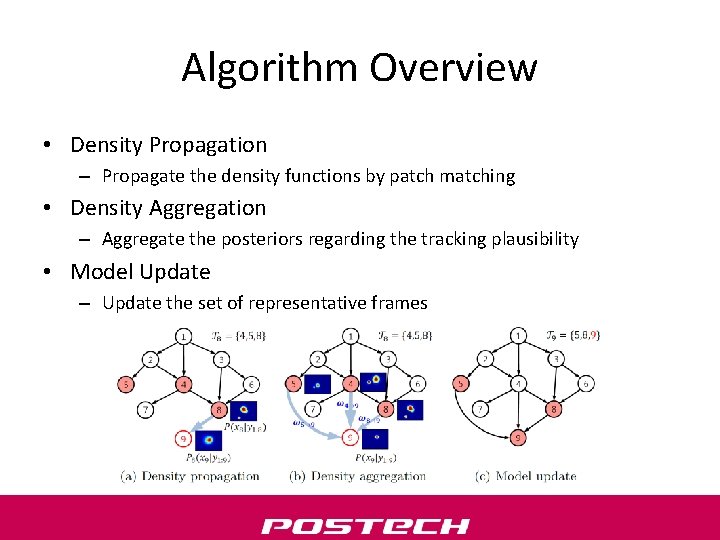
Algorithm Overview • Density Propagation – Propagate the density functions by patch matching • Density Aggregation – Aggregate the posteriors regarding the tracking plausibility • Model Update – Update the set of representative frames
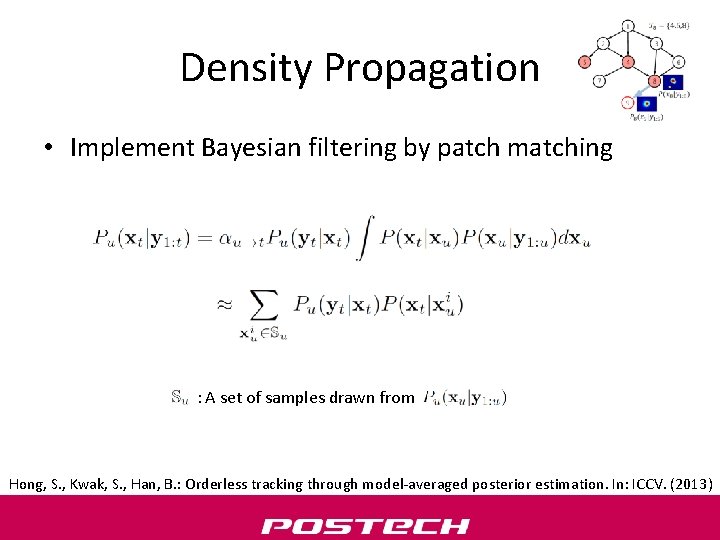
Density Propagation • Implement Bayesian filtering by patch matching : A set of samples drawn from Hong, S. , Kwak, S. , Han, B. : Orderless tracking through model-averaged posterior estimation. In: ICCV. (2013)
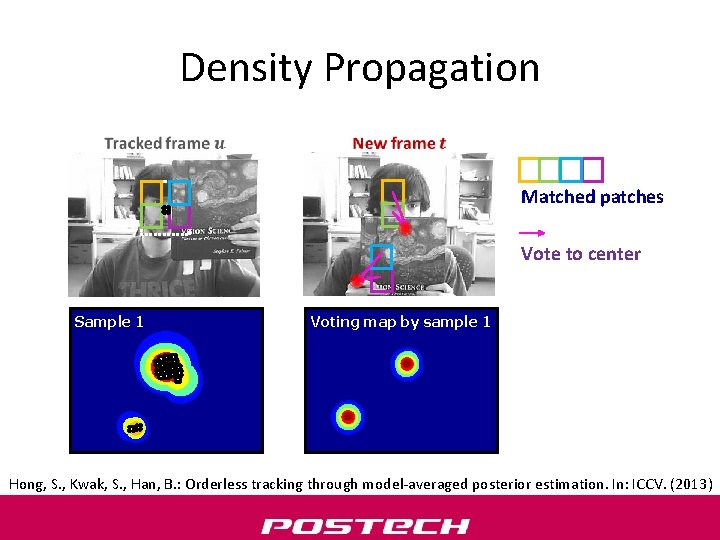
Density Propagation Matched patches Vote to center Sample 1 Voting map by sample 1 Hong, S. , Kwak, S. , Han, B. : Orderless tracking through model-averaged posterior estimation. In: ICCV. (2013)
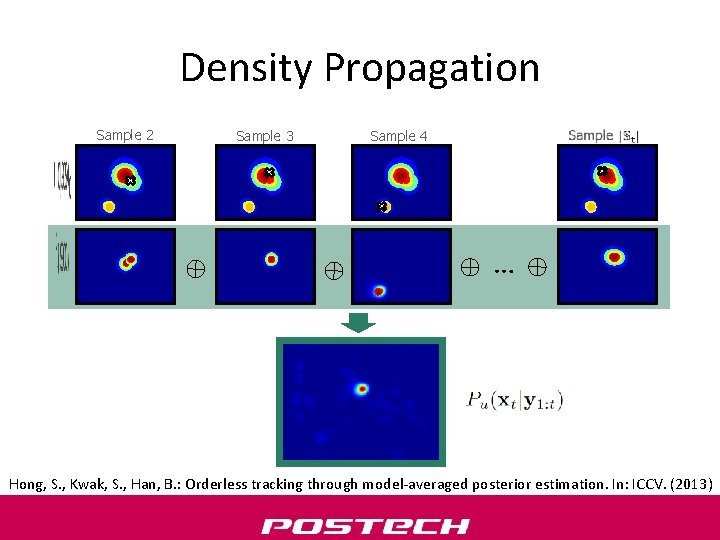
Density Propagation Sample 3 Sample 4 Sample 2 … Hong, S. , Kwak, S. , Han, B. : Orderless tracking through model-averaged posterior estimation. In: ICCV. (2013)
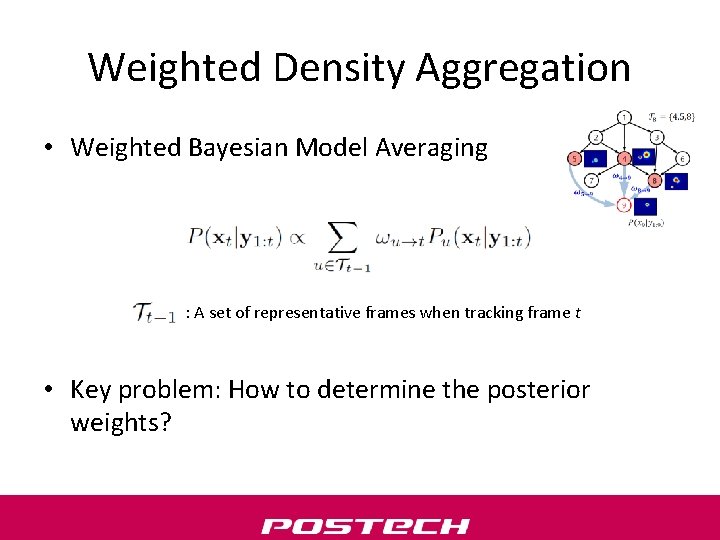
Weighted Density Aggregation • Weighted Bayesian Model Averaging : A set of representative frames when tracking frame t • Key problem: How to determine the posterior weights?
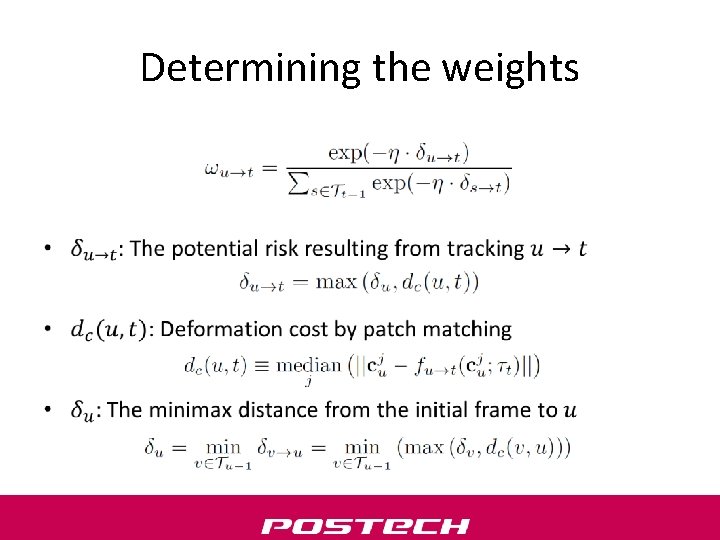
Determining the weights •
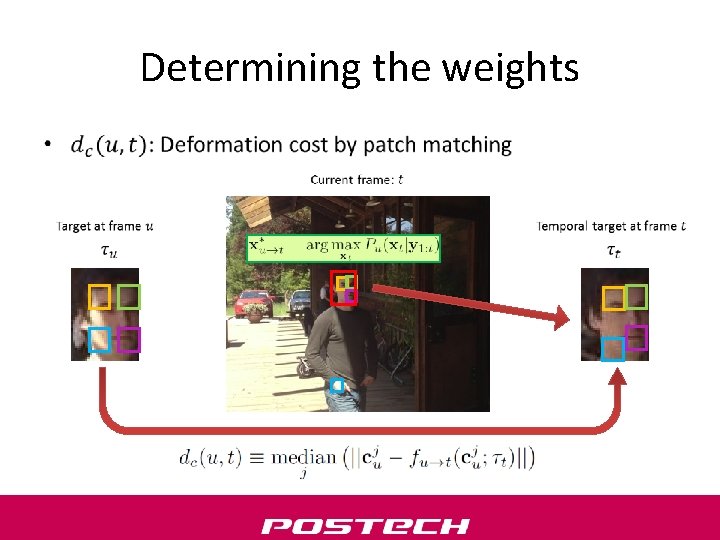
Determining the weights •
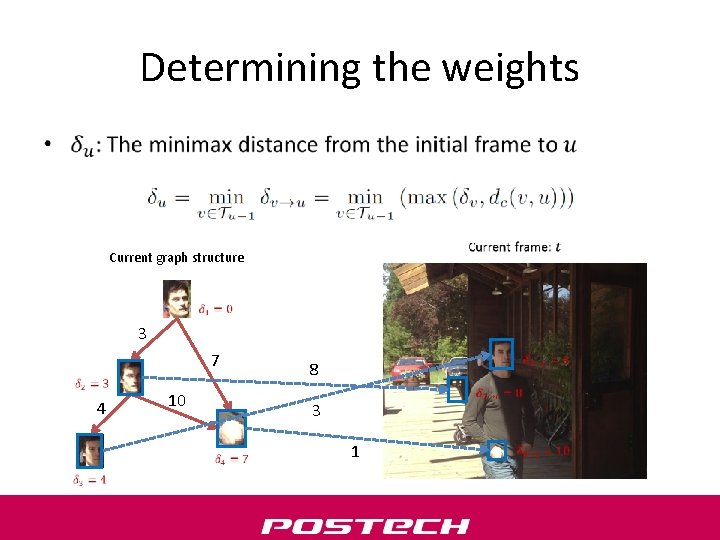
Determining the weights • Current graph structure 3 7 4 10 8 3 1
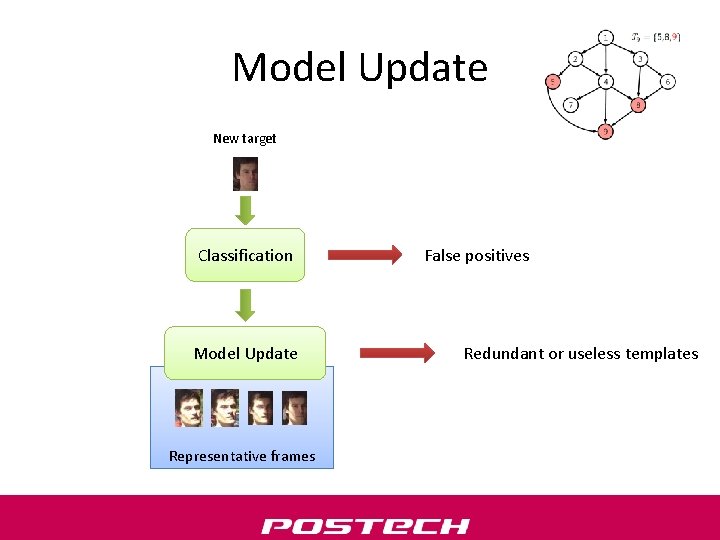
Model Update New target Classification Model Update Representative frames False positives Redundant or useless templates
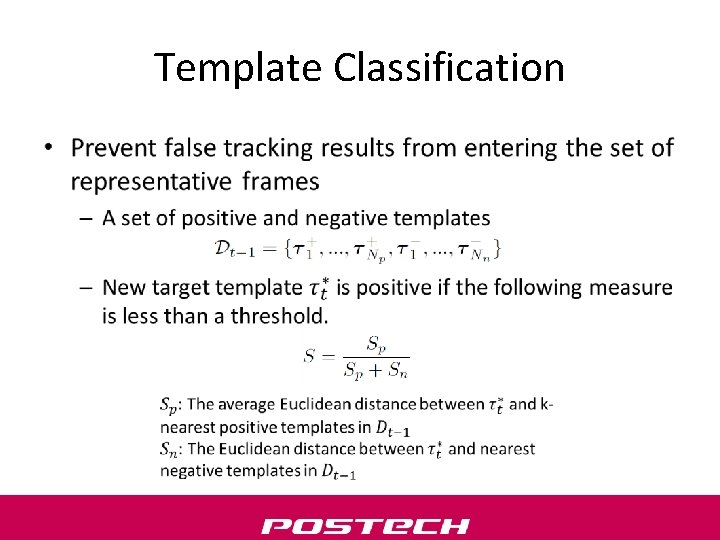
Template Classification •
Maintaining Representative Frames • Each template in the representative set should be distinct and useful for further tracking.
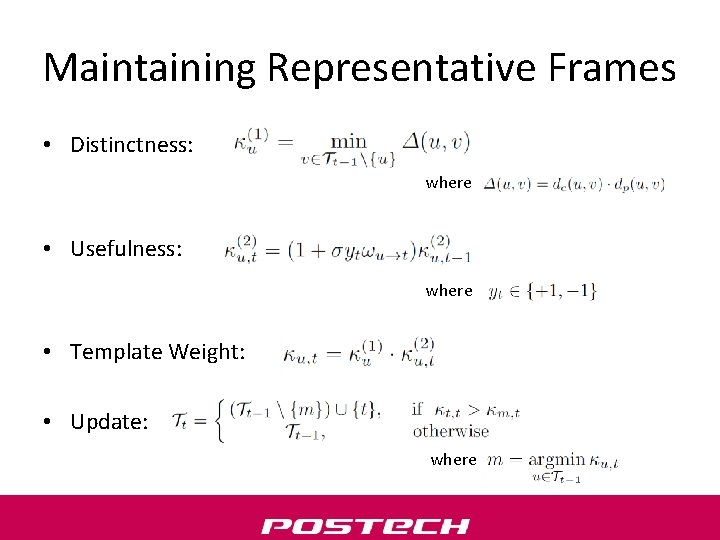
Maintaining Representative Frames • Distinctness: where • Usefulness: where • Template Weight: • Update: where
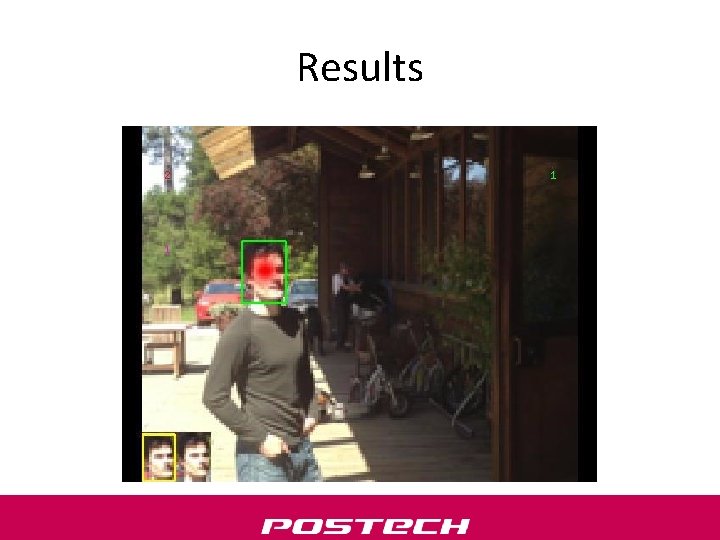
Results
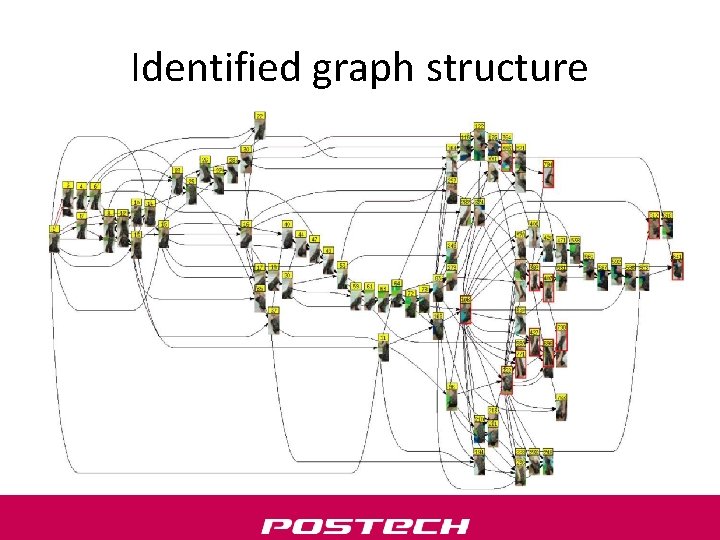
Identified graph structure
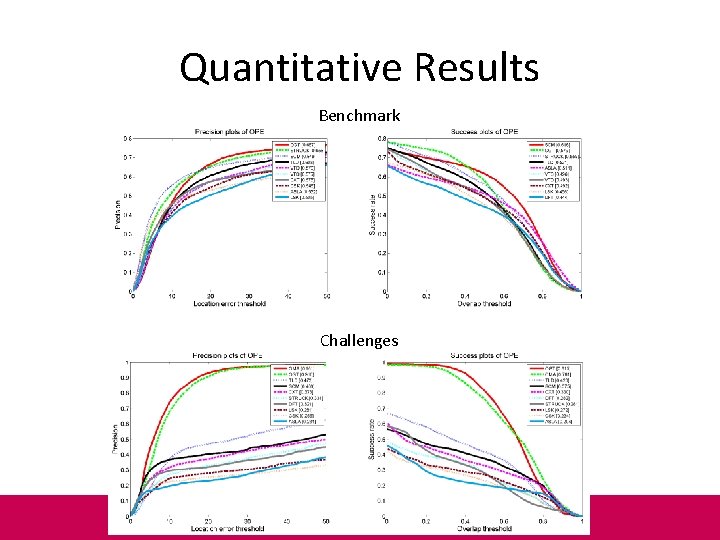
Quantitative Results Benchmark Challenges
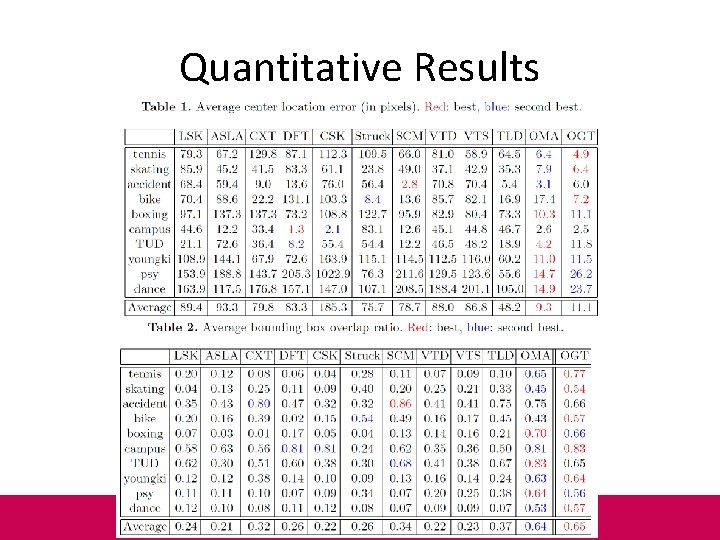
Quantitative Results
Summary • We propose an adaptive and active algorithm to identify a general graphical model for a robust tracking. • A new target posterior is estimated by a selective and weighted model averaging. • For efficiency, only a small number of frames capture the important characteristics of input video. • Outstanding experimental results on 50 sequences in the tracking benchmark and 10 more challenging sequences show the benefit of our progressive graph construction algorithm.
- Slides: 27