
Mobile Robot Navigation with Human Interface Device David
Mobile Robot Navigation with Human Interface Device David Buckles Brian Walsh Advisor: Dr. Malinowski
Outline • • • Project Summary Previous Work Project Description Equipment List Schedule of Tasks
Project Summary • A pioneer 3 D-X robot shall map an environment in open. GL. • This map shall be displayed on an LCD eyepiece in real time. • The robot shall navigate an environment using potential field planning or direct manual control via a sensor glove.
Previous Work • In 2010 Scott Tipton and Nicholas Halabi programmed the Pioneer 3 D-X to use potential field planning and had joystick control. • Inertial Measurement Unit specification and filter research completed by Weston Taylor and Chris Budzynski. • Inertial Measurement Unit filter research completed by Luke Pfister and Daniel Monroe.
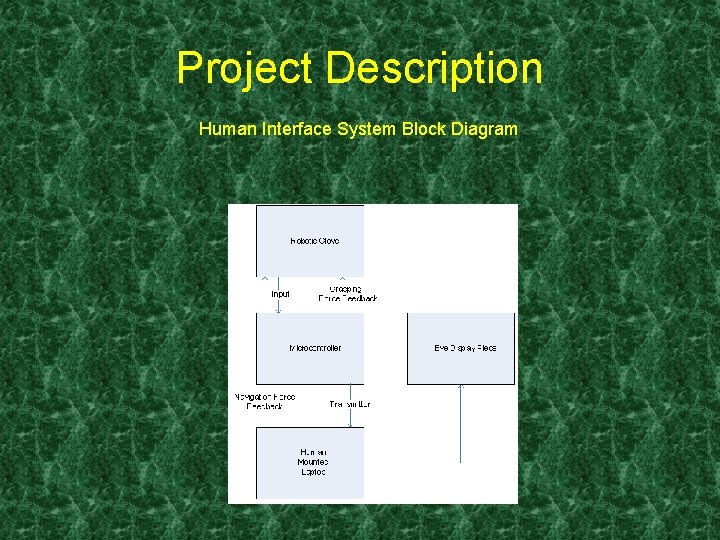
Project Description Human Interface System Block Diagram
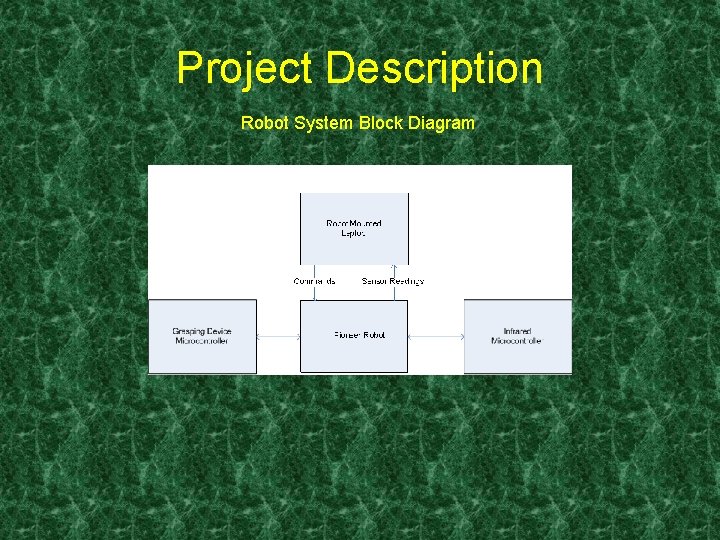
Project Description Robot System Block Diagram
Project Description - Goals • Mapping the robot’s current environment in 3 D, in real time, and utilizing Open. GL to display the data on an LCD eyepiece to provide visual feedback • Provide user override of the automated navigation systems via a glove with sensors and software with feature recognition • Implement a sensor (possibly ultrasonic) to detect ceiling height • Implement a grasping device controllable by the sensing glove
Project Description - Goals • If time permits, attach a 2 degree of freedom robotic arm to the grasping device, also controllable via sensor glove with feature recognition • If time permits, implement Potential Field planning as a method for the robot to navigate and map its environment • If time permits, add force-feedback functionality to the glove that is used to provide feedback from the grasping mechanism or in manual override mode for obstacle avoidance.
Project Description • Hand sensors shall have < 3 degrees/second of drift. • Eyepiece shall have a 12 Hz refresh rate. • Eyepiece shall have 180 degree range of vision with 5 degree accuracy. • Robot shall be able to measure walls within 20 to 150 cm with 2 cm accuracy. • Robot shall be able to measure ceiling within 3 m with 5 cm accuracy.
Equipment List - Hardware • • 1 x Pioneer 3 D-X 2 x Laptop 1 x LCD eyepiece 1 x Sensor Glove 2 x Micro. Controller 1 x 2 -Axis Gyroscope 1 x 3 -Axis Accelerometer 1 x 3 -Axis Digital Compass
Equipment List - Software • Microsoft Visual Studio 2005 – open. GL Utility Toolbox – Aria Mobile Robot Platform • Silicon Labs IDE
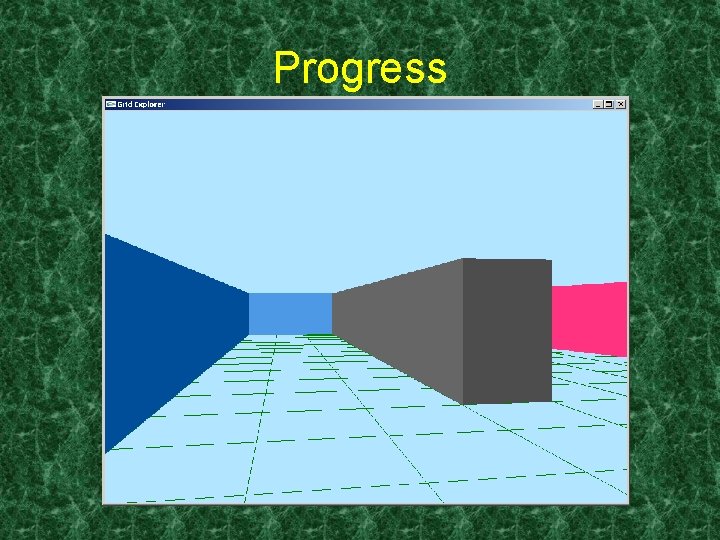
Progress • An open. GL environment is fully navigable by a simulated robot. • A set of draw. Wall functions can reproduce an existing map. • Determined specifications for project components. • Researched sensor fusion techniques • Selected components to meet specifications.
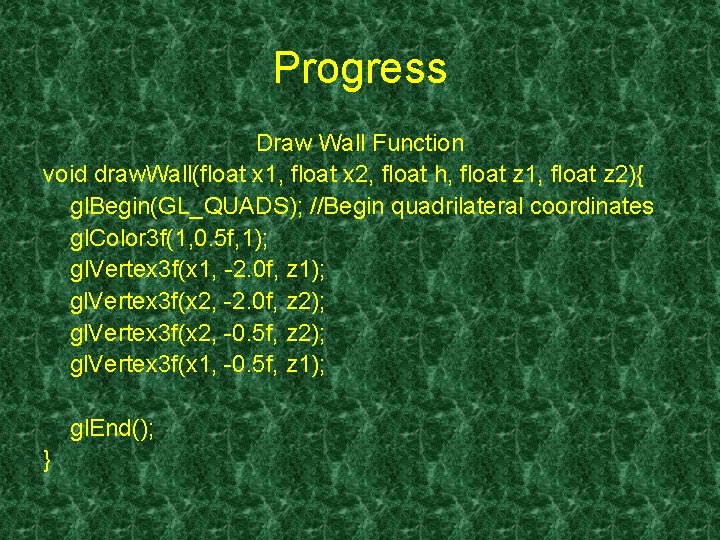
Progress Draw Wall Function void draw. Wall(float x 1, float x 2, float h, float z 1, float z 2){ gl. Begin(GL_QUADS); //Begin quadrilateral coordinates gl. Color 3 f(1, 0. 5 f, 1); gl. Vertex 3 f(x 1, -2. 0 f, z 1); gl. Vertex 3 f(x 2, -2. 0 f, z 2); gl. Vertex 3 f(x 2, -0. 5 f, z 2); gl. Vertex 3 f(x 1, -0. 5 f, z 1); gl. End(); }
Progress
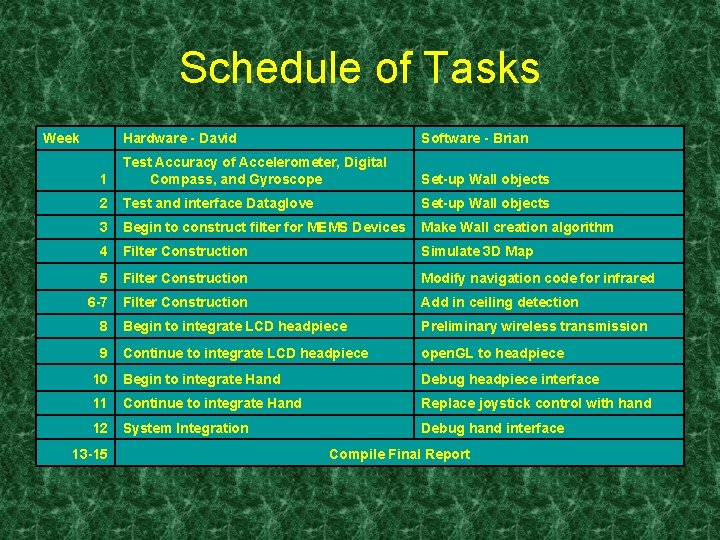
Schedule of Tasks Week Hardware - David Software - Brian 1 Test Accuracy of Accelerometer, Digital Compass, and Gyroscope Set-up Wall objects 2 Test and interface Dataglove Set-up Wall objects 3 Begin to construct filter for MEMS Devices Make Wall creation algorithm 4 Filter Construction Simulate 3 D Map 5 Filter Construction Modify navigation code for infrared 6 -7 Filter Construction Add in ceiling detection 8 Begin to integrate LCD headpiece Preliminary wireless transmission 9 Continue to integrate LCD headpiece open. GL to headpiece 10 Begin to integrate Hand Debug headpiece interface 11 Continue to integrate Hand Replace joystick control with hand 12 System Integration Debug hand interface 13 -15 Compile Final Report
Questions?
Answers – 5 -Degree of Freedom Combo Board: 2 -axis 500 degree gyroscope IDG 500 – 3 -axis 3 g accelerometer ADXL 335 – 3 -Degree of Freedom Digital Compass on Breakout Board HMC 5843 – DGV-5 Dataglove
- Slides: 18