
MARSUPIAL Detailed Design Review Carnegie Robotics LLC 10
MARSUPIAL Detailed Design Review Carnegie Robotics LLC. #10 40 th Street Pittsburgh, PA 15201 Jared Raby Nico Gallardo Chris Griffin Sean Greenslade Wesly Rice © 2014 Carnegie Robotics LLC. Use or disclosure of document data is subject to the restrictions on the title page Page 1
Agenda • Introduction • Systems Design ® Tracks/Suspension ® Wireless Node Payload ® Wireless Node Deployment ® Electrical Systems • Risks • MSD II Schedule • Questions © 2014 Carnegie Robotics LLC. Use or disclosure of document data is subject to the restrictions on the title page Page 2
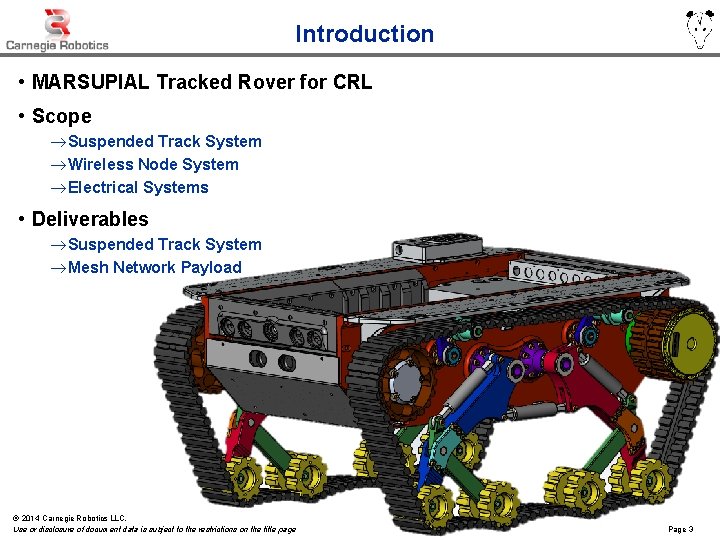
Introduction • MARSUPIAL Tracked Rover for CRL • Scope ® Suspended Track System ® Wireless Node System ® Electrical Systems • Deliverables ® Suspended Track System ® Mesh Network Payload © 2014 Carnegie Robotics LLC. Use or disclosure of document data is subject to the restrictions on the title page Page 3
Wes TRACKS AND SUSPENSION © 2014 Carnegie Robotics LLC. Use or disclosure of document data is subject to the restrictions on the title page Page 4
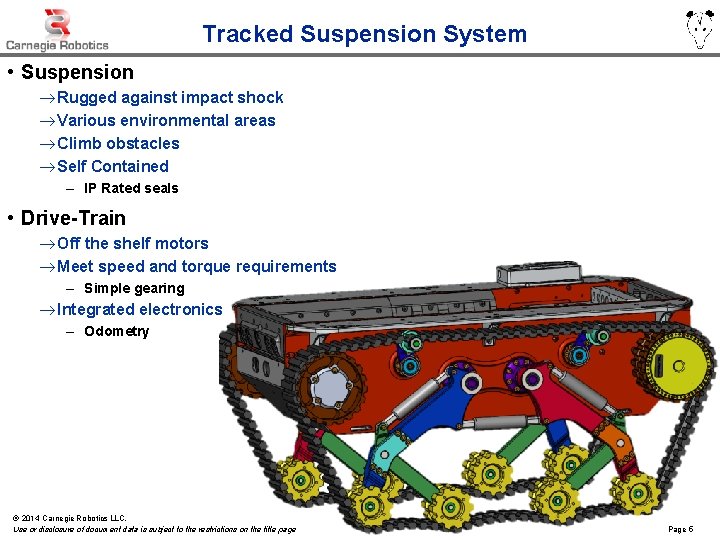
Tracked Suspension System • Suspension ® Rugged against impact shock ® Various environmental areas ® Climb obstacles ® Self Contained – IP Rated seals • Drive-Train ® Off the shelf motors ® Meet speed and torque requirements – Simple gearing ® Integrated electronics – Odometry © 2014 Carnegie Robotics LLC. Use or disclosure of document data is subject to the restrictions on the title page Page 5
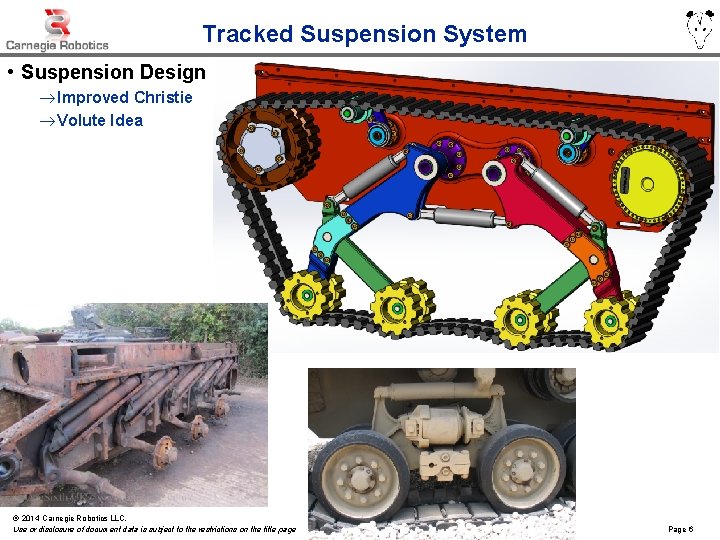
Tracked Suspension System • Suspension Design ® Improved Christie ® Volute Idea © 2014 Carnegie Robotics LLC. Use or disclosure of document data is subject to the restrictions on the title page Page 6
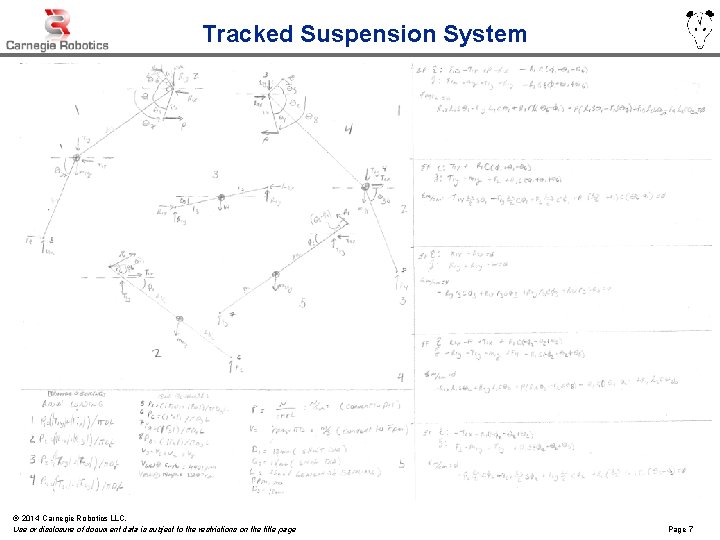
Tracked Suspension System © 2014 Carnegie Robotics LLC. Use or disclosure of document data is subject to the restrictions on the title page Page 7
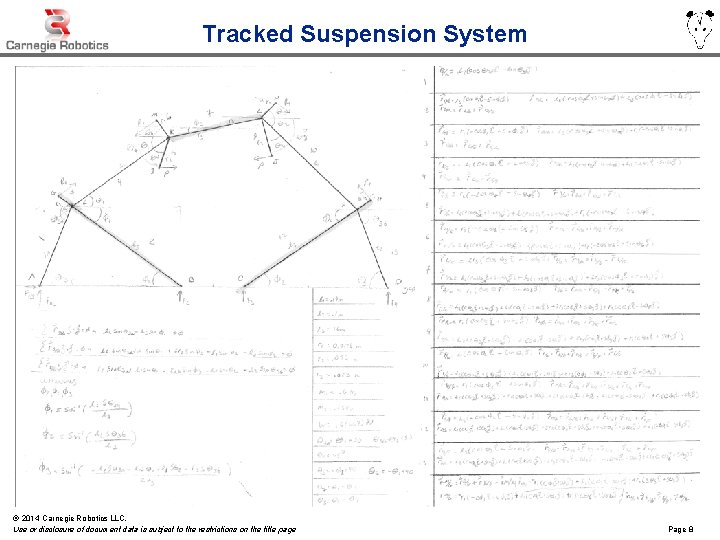
Tracked Suspension System © 2014 Carnegie Robotics LLC. Use or disclosure of document data is subject to the restrictions on the title page Page 8
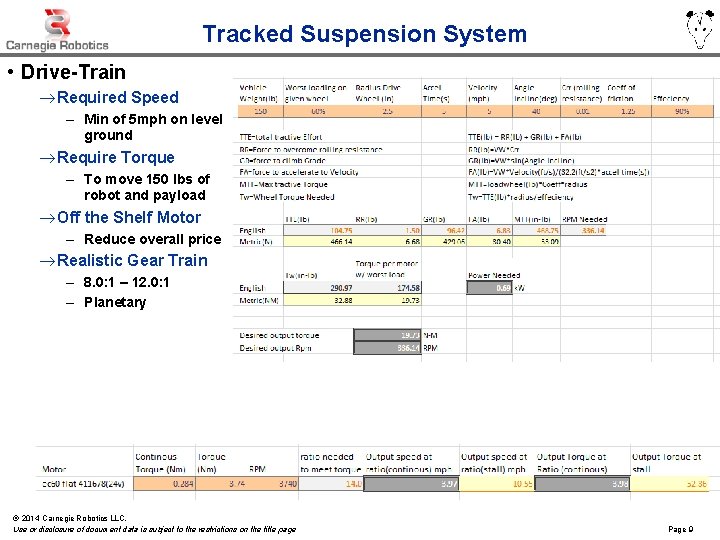
Tracked Suspension System • Drive-Train ® Required Speed – Min of 5 mph on level ground ® Require Torque – To move 150 lbs of robot and payload ® Off the Shelf Motor – Reduce overall price ® Realistic Gear Train – 8. 0: 1 – 12. 0: 1 – Planetary © 2014 Carnegie Robotics LLC. Use or disclosure of document data is subject to the restrictions on the title page Page 9
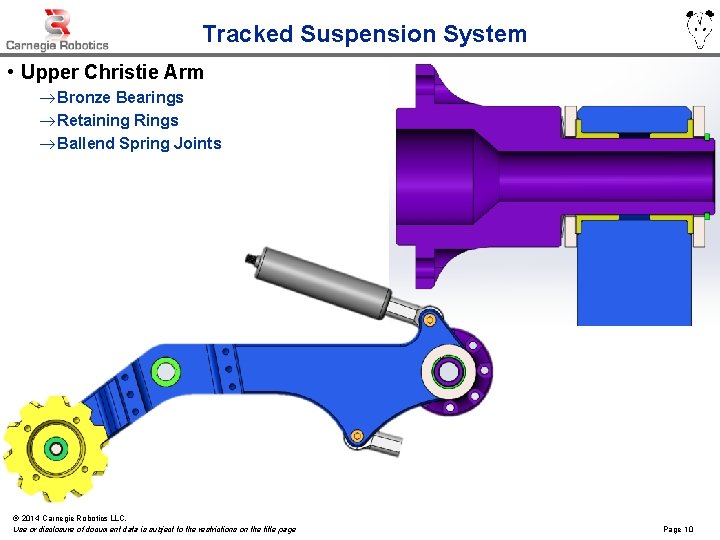
Tracked Suspension System • Upper Christie Arm ® Bronze Bearings ® Retaining Rings ® Ballend Spring Joints © 2014 Carnegie Robotics LLC. Use or disclosure of document data is subject to the restrictions on the title page Page 10
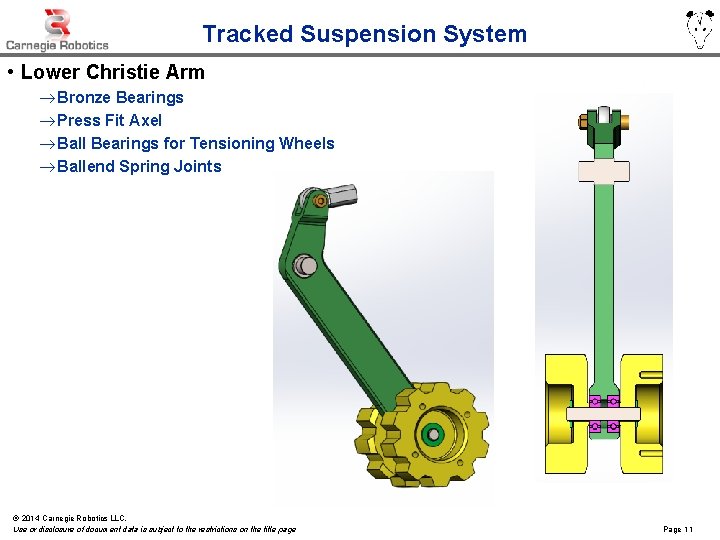
Tracked Suspension System • Lower Christie Arm ® Bronze Bearings ® Press Fit Axel ® Ball Bearings for Tensioning Wheels ® Ballend Spring Joints © 2014 Carnegie Robotics LLC. Use or disclosure of document data is subject to the restrictions on the title page Page 11
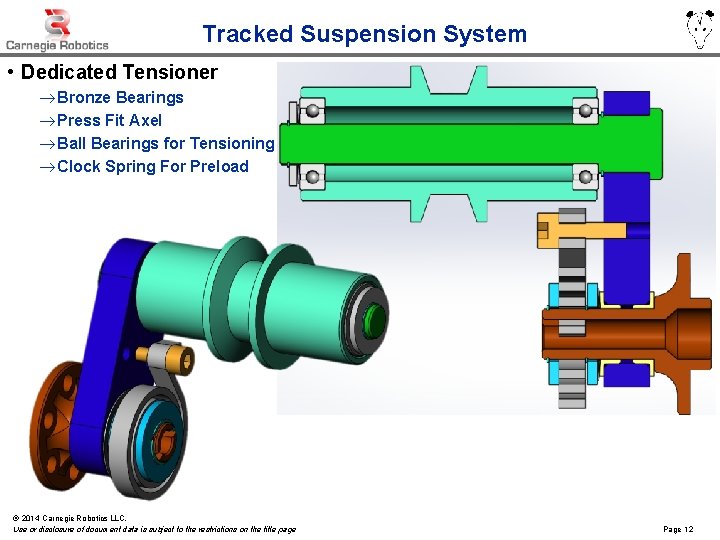
Tracked Suspension System • Dedicated Tensioner ® Bronze Bearings ® Press Fit Axel ® Ball Bearings for Tensioning Wheels ® Clock Spring For Preload © 2014 Carnegie Robotics LLC. Use or disclosure of document data is subject to the restrictions on the title page Page 12
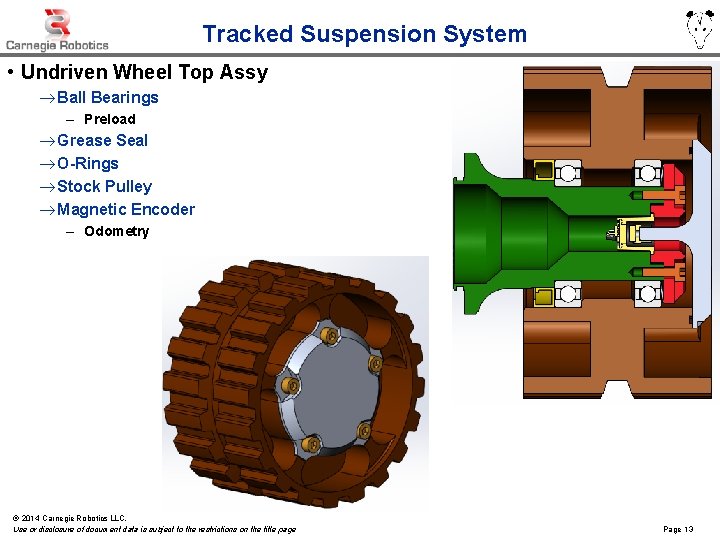
Tracked Suspension System • Undriven Wheel Top Assy ® Ball Bearings – Preload ® Grease Seal ® O-Rings ® Stock Pulley ® Magnetic Encoder – Odometry © 2014 Carnegie Robotics LLC. Use or disclosure of document data is subject to the restrictions on the title page Page 13
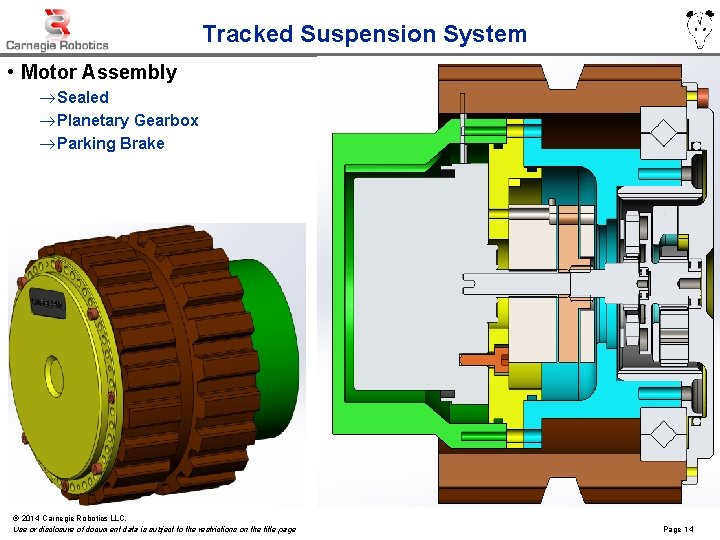
Tracked Suspension System • Motor Assembly ® Sealed ® Planetary Gearbox ® Parking Brake © 2014 Carnegie Robotics LLC. Use or disclosure of document data is subject to the restrictions on the title page Page 14
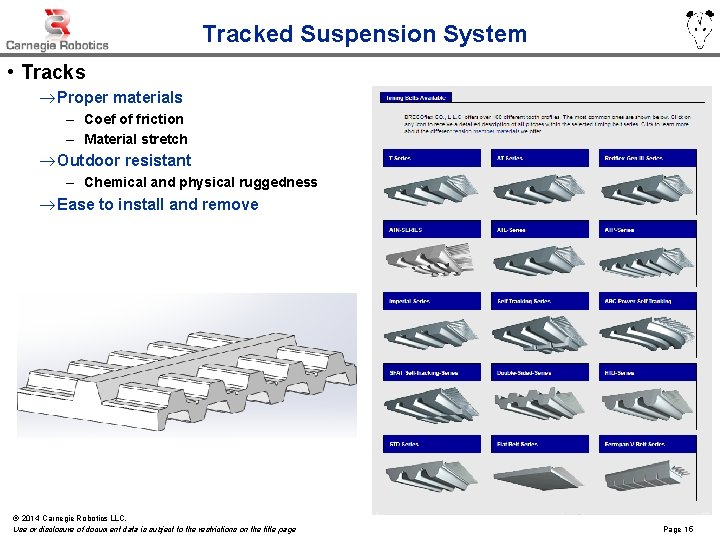
Tracked Suspension System • Tracks ® Proper materials – Coef of friction – Material stretch ® Outdoor resistant – Chemical and physical ruggedness ® Ease to install and remove © 2014 Carnegie Robotics LLC. Use or disclosure of document data is subject to the restrictions on the title page Page 15
Tracked Suspension System BOM © 2014 Carnegie Robotics LLC. Use or disclosure of document data is subject to the restrictions on the title page Page 16
Tracked Suspension System BOM 2 © 2014 Carnegie Robotics LLC. Use or disclosure of document data is subject to the restrictions on the title page Page 17
Tracked Suspension System BOM 3 © 2014 Carnegie Robotics LLC. Use or disclosure of document data is subject to the restrictions on the title page Page 18
Sean WIRELESS NODE PAYLOAD © 2014 Carnegie Robotics LLC. Use or disclosure of document data is subject to the restrictions on the title page Page 19
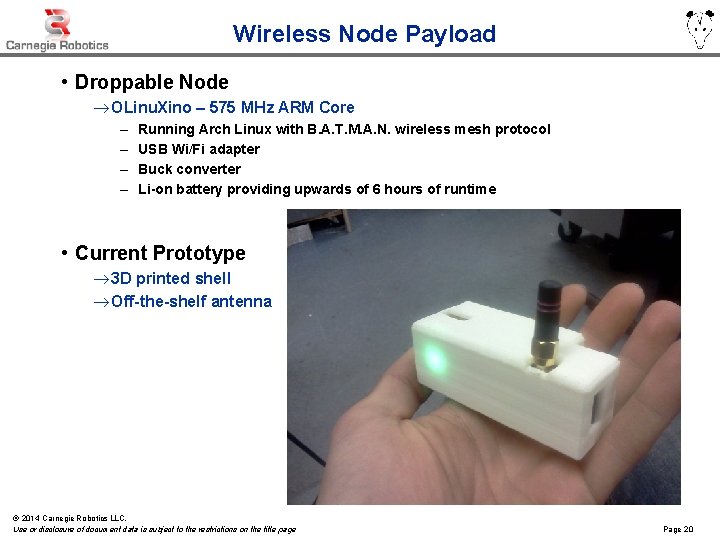
Wireless Node Payload • Droppable Node ® OLinu. Xino – 575 MHz ARM Core – – Running Arch Linux with B. A. T. M. A. N. wireless mesh protocol USB Wi/Fi adapter Buck converter Li-on battery providing upwards of 6 hours of runtime • Current Prototype ® 3 D printed shell ® Off-the-shelf antenna © 2014 Carnegie Robotics LLC. Use or disclosure of document data is subject to the restrictions on the title page Page 20
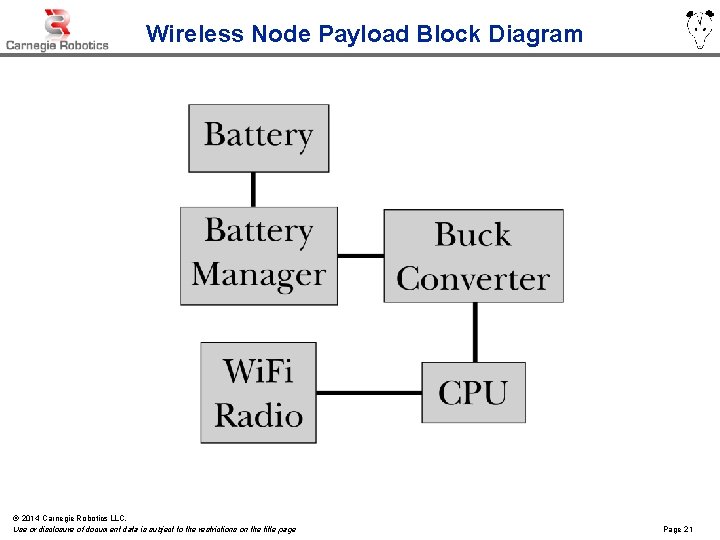
Wireless Node Payload Block Diagram © 2014 Carnegie Robotics LLC. Use or disclosure of document data is subject to the restrictions on the title page Page 21
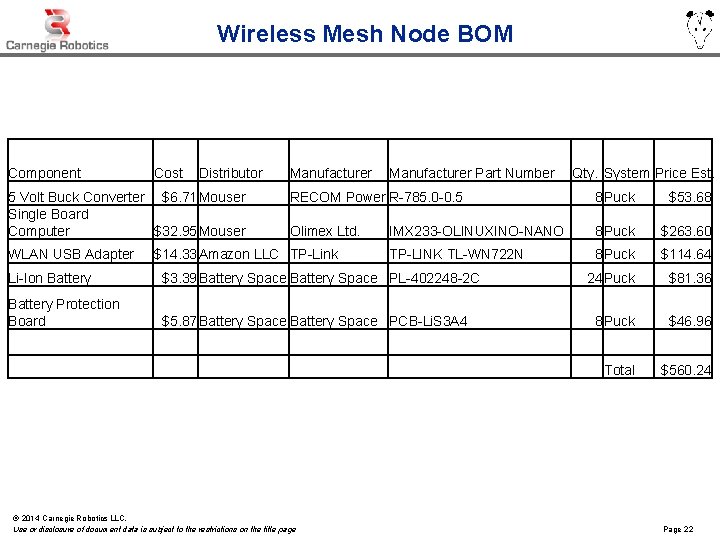
Wireless Mesh Node BOM Component Cost Distributor 5 Volt Buck Converter $6. 71 Mouser Single Board Computer $32. 95 Mouser WLAN USB Adapter Manufacturer Part Number Qty. System Price Est. RECOM Power R-785. 0 -0. 5 8 Puck $53. 68 Olimex Ltd. IMX 233 -OLINUXINO-NANO 8 Puck $263. 60 TP-LINK TL-WN 722 N 8 Puck $114. 64 24 Puck $81. 36 8 Puck $46. 96 Total $560. 24 $14. 33 Amazon LLC TP-Link Li-Ion Battery $3. 39 Battery Space PL-402248 -2 C Battery Protection Board $5. 87 Battery Space PCB-Li. S 3 A 4 © 2014 Carnegie Robotics LLC. Use or disclosure of document data is subject to the restrictions on the title page Page 22
Jared WIRELESS NODE DEPLOYMENT © 2014 Carnegie Robotics LLC. Use or disclosure of document data is subject to the restrictions on the title page Page 23
Wireless Node Deployment System • Needs to readily deploy the node while keeping in place during high impact moments ® High holding strength ® Ability to drop the puck easily • Deployment system should be isolated from the outside to comply with IP standards ® Dust / water prevention ® Short circuit protection • Magnetic holding system developed ® Magnetic slide in the track © 2014 Carnegie Robotics LLC. Use or disclosure of document data is subject to the restrictions on the title page Page 24
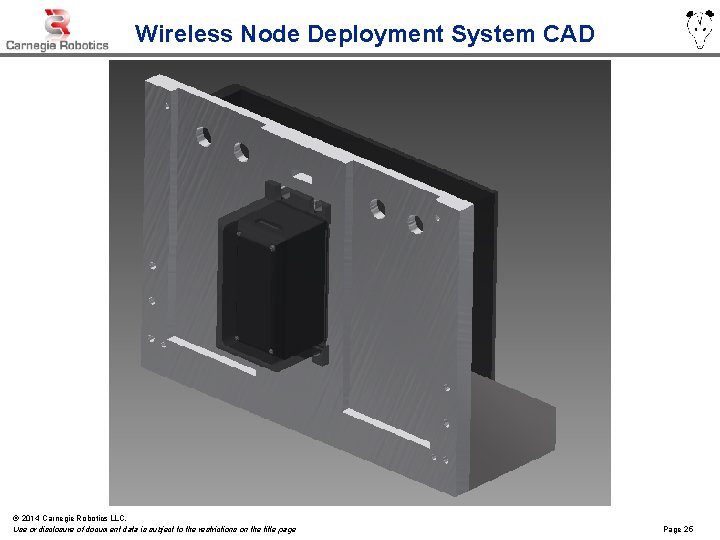
Wireless Node Deployment System CAD © 2014 Carnegie Robotics LLC. Use or disclosure of document data is subject to the restrictions on the title page Page 25
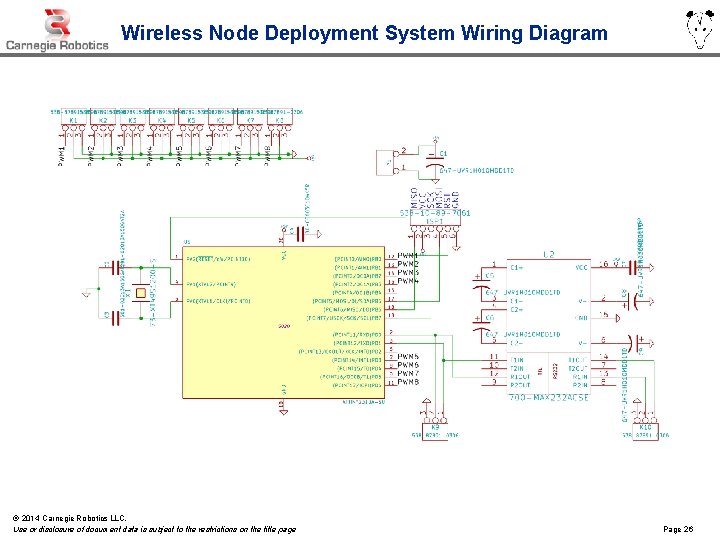
Wireless Node Deployment System Wiring Diagram © 2014 Carnegie Robotics LLC. Use or disclosure of document data is subject to the restrictions on the title page Page 26
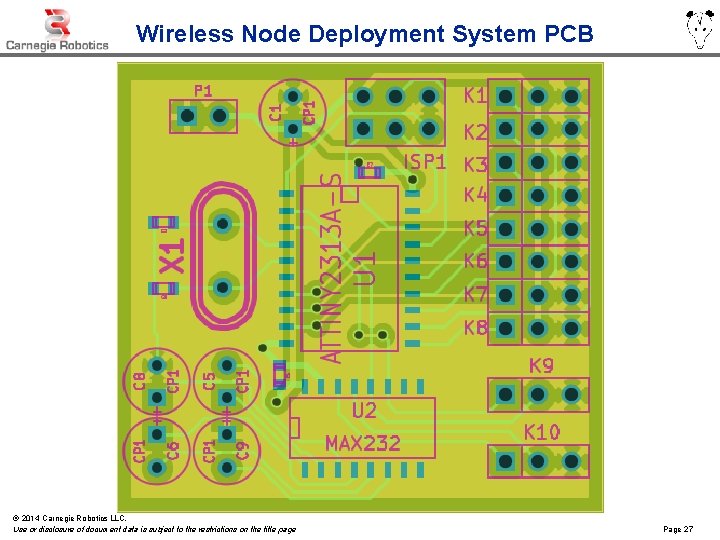
Wireless Node Deployment System PCB © 2014 Carnegie Robotics LLC. Use or disclosure of document data is subject to the restrictions on the title page Page 27
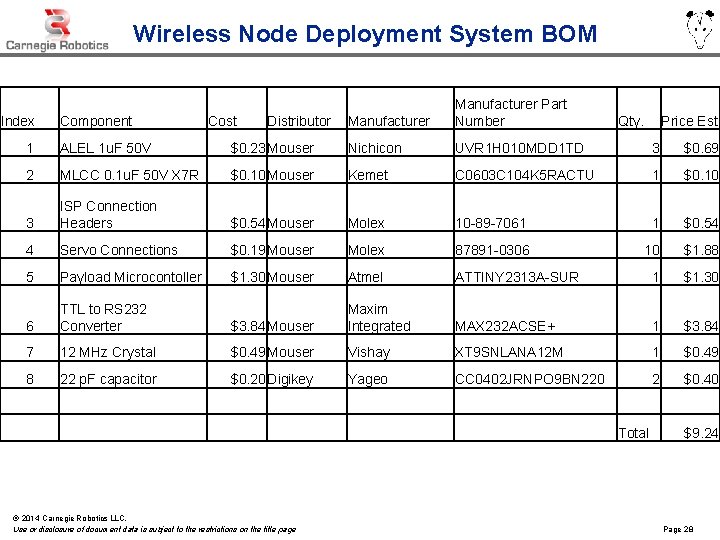
Wireless Node Deployment System BOM Index Component Cost Distributor Manufacturer Part Number Qty. Price Est. 1 ALEL 1 u. F 50 V $0. 23 Mouser Nichicon UVR 1 H 010 MDD 1 TD 3 $0. 69 2 MLCC 0. 1 u. F 50 V X 7 R $0. 10 Mouser Kemet C 0603 C 104 K 5 RACTU 1 $0. 10 3 ISP Connection Headers $0. 54 Mouser Molex 10 -89 -7061 1 $0. 54 4 Servo Connections $0. 19 Mouser Molex 87891 -0306 10 $1. 88 5 Payload Microcontoller $1. 30 Mouser Atmel ATTINY 2313 A-SUR 1 $1. 30 6 TTL to RS 232 Converter $3. 84 Mouser Maxim Integrated MAX 232 ACSE+ 1 $3. 84 7 12 MHz Crystal $0. 49 Mouser Vishay XT 9 SNLANA 12 M 1 $0. 49 8 22 p. F capacitor $0. 20 Digikey Yageo CC 0402 JRNPO 9 BN 220 2 $0. 40 Total © 2014 Carnegie Robotics LLC. Use or disclosure of document data is subject to the restrictions on the title page $9. 24 Page 28
Nico and Chris POWER MANAGEMENT AND DISTRIBUTION © 2014 Carnegie Robotics LLC. Use or disclosure of document data is subject to the restrictions on the title page Page 29
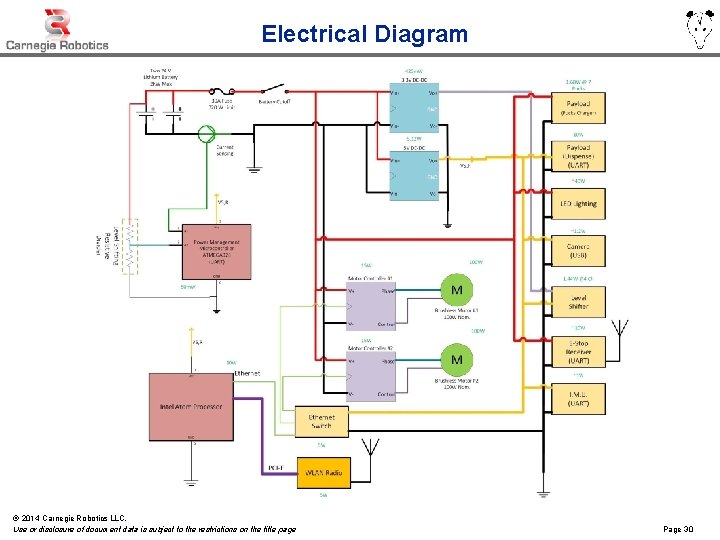
Electrical Diagram © 2014 Carnegie Robotics LLC. Use or disclosure of document data is subject to the restrictions on the title page Page 30
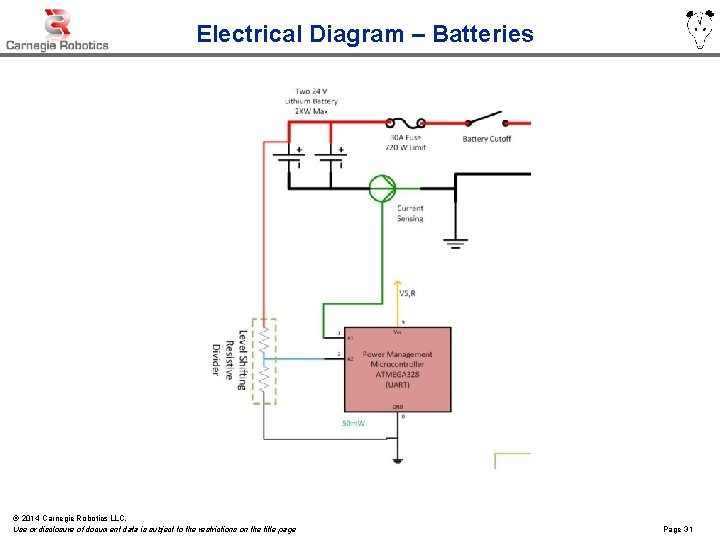
Electrical Diagram – Batteries © 2014 Carnegie Robotics LLC. Use or disclosure of document data is subject to the restrictions on the title page Page 31
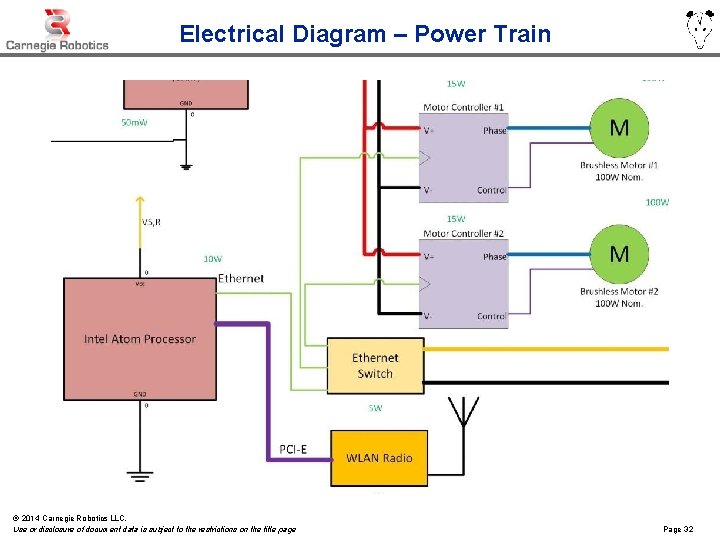
Electrical Diagram – Power Train © 2014 Carnegie Robotics LLC. Use or disclosure of document data is subject to the restrictions on the title page Page 32
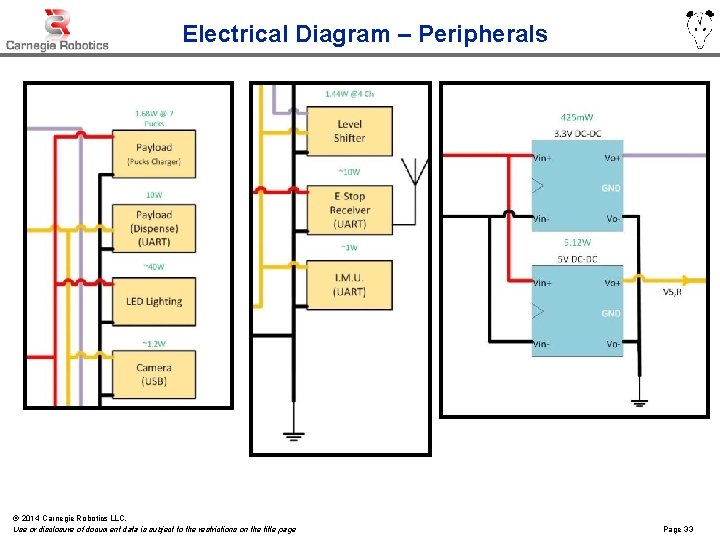
Electrical Diagram – Peripherals © 2014 Carnegie Robotics LLC. Use or disclosure of document data is subject to the restrictions on the title page Page 33
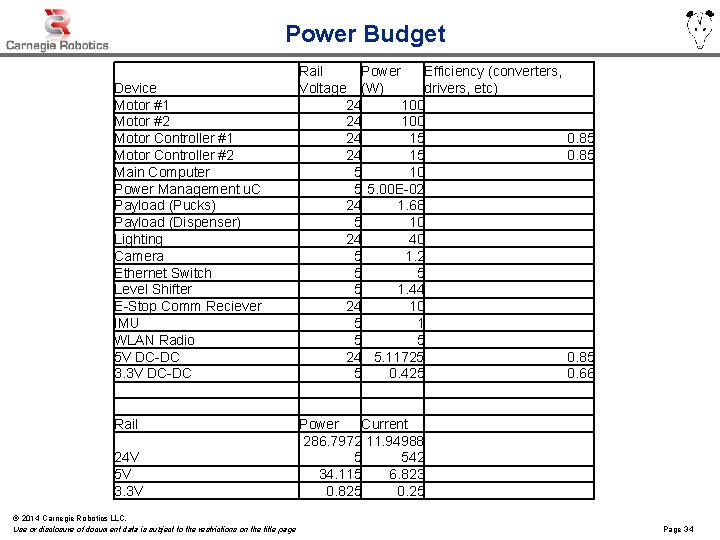
Power Budget Device Motor #1 Motor #2 Motor Controller #1 Motor Controller #2 Main Computer Power Management u. C Payload (Pucks) Payload (Dispenser) Lighting Camera Ethernet Switch Level Shifter E-Stop Comm Reciever IMU WLAN Radio 5 V DC-DC 3. 3 V DC-DC Rail 24 V 5 V 3. 3 V © 2014 Carnegie Robotics LLC. Use or disclosure of document data is subject to the restrictions on the title page Rail Power Efficiency (converters, Voltage (W) drivers, etc) 24 100 24 15 0. 85 5 10 5 5. 00 E-02 24 1. 68 5 10 24 40 5 1. 2 5 5 5 1. 44 24 10 5 1 5 5 24 5. 11725 0. 85 5 0. 425 0. 66 Power Current 286. 7972 11. 94988 5 542 34. 115 6. 823 0. 825 0. 25 Page 34
Electrical Systems © 2014 Carnegie Robotics LLC. Use or disclosure of document data is subject to the restrictions on the title page Page 35
RISKS © 2014 Carnegie Robotics LLC. Use or disclosure of document data is subject to the restrictions on the title page Page 36
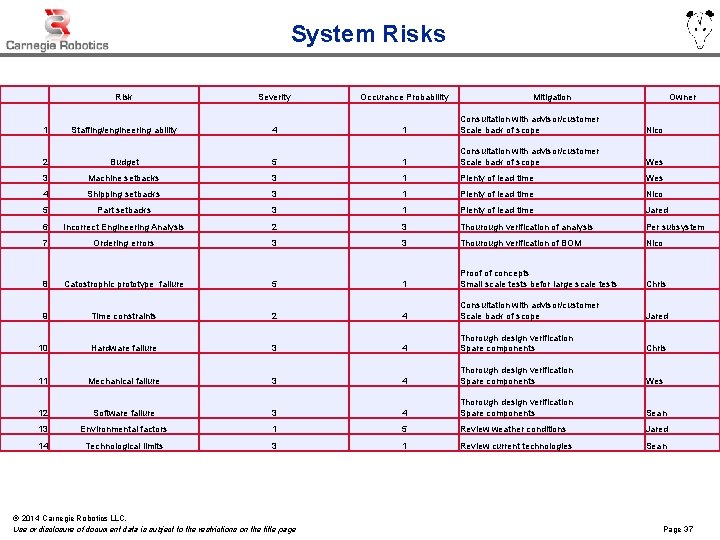
System Risks Risk Severity Occurance Probability 1 Staffing/engineering ability 4 1 Consultation with advisor/customer Scale back of scope Nico 2 Budget 5 1 Consultation with advisor/customer Scale back of scope Wes 3 Machine setbacks 3 1 Plenty of lead time Wes 4 Shipping setbacks 3 1 Plenty of lead time Nico 5 Part setbacks 3 1 Plenty of lead time Jared 6 Incorrect Engineering Analysis 2 3 Thourough verification of analysis Per subsystem 7 Ordering errors 3 3 Thourough verification of BOM Nico 8 Catostrophic prototype failure 5 1 Proof of concepts Small scale tests befor large scale tests Chris 9 Time constraints 2 4 Consultation with advisor/customer Scale back of scope Jared 10 Hardware failure 3 4 Thorough design verification Spare components Chris 11 Mechanical failure 3 4 Thorough design verification Spare components Wes 12 Software failure 3 4 Thorough design verification Spare components Sean 13 Environmental factors 1 5 Review weather conditions Jared 14 Technological limits 3 1 Review current technologies Sean © 2014 Carnegie Robotics LLC. Use or disclosure of document data is subject to the restrictions on the title page Mitigation Owner Page 37
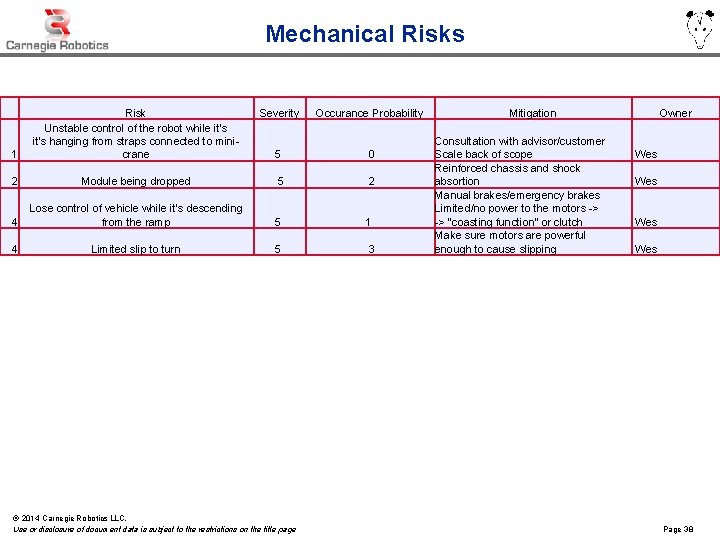
Mechanical Risks Severity Occurance Probability 1 Risk Unstable control of the robot while it's hanging from straps connected to minicrane 5 0 2 Module being dropped 5 2 4 Lose control of vehicle while it's descending from the ramp 5 1 4 Limited slip to turn 5 3 © 2014 Carnegie Robotics LLC. Use or disclosure of document data is subject to the restrictions on the title page Mitigation Consultation with advisor/customer Scale back of scope Reinforced chassis and shock absortion Manual brakes/emergency brakes Limited/no power to the motors -> -> "coasting function" or clutch Make sure motors are powerful enough to cause slipping Owner Wes Wes Page 38
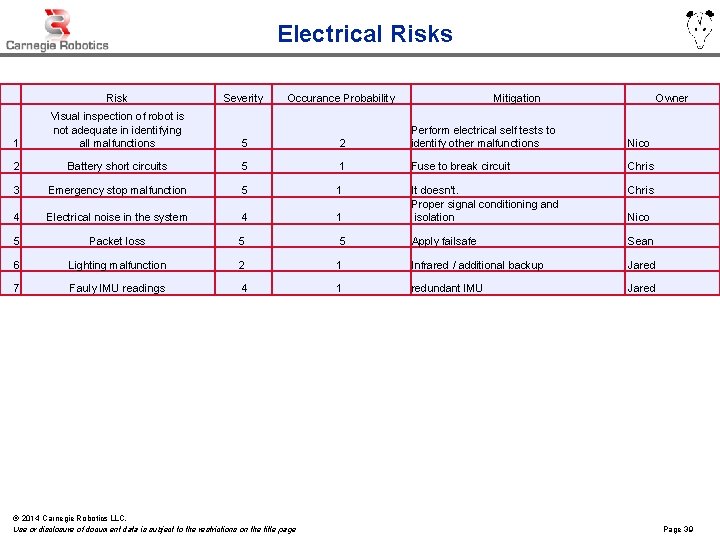
Electrical Risks Risk Severity Occurance Probability 1 Visual inspection of robot is not adequate in identifying all malfunctions 5 2 Perform electrical self tests to identify other malfunctions Nico 2 Battery short circuits 5 1 Fuse to break circuit Chris 3 Emergency stop malfunction 5 1 Chris 4 Electrical noise in the system 4 1 It doesn't. Proper signal conditioning and isolation 5 Packet loss 5 5 Apply failsafe Sean 6 Lighting malfunction 2 1 Infrared / additional backup Jared 7 Fauly IMU readings 4 1 redundant IMU Jared © 2014 Carnegie Robotics LLC. Use or disclosure of document data is subject to the restrictions on the title page Mitigation Owner Nico Page 39
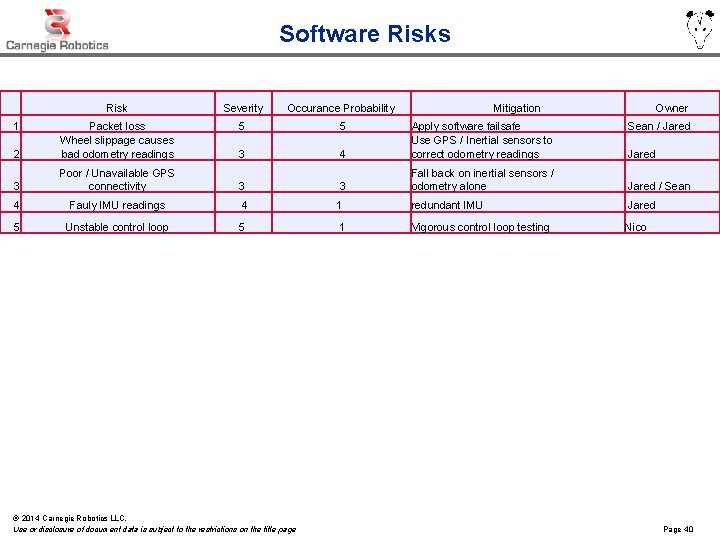
Software Risks Risk Severity Occurance Probability 5 5 2 Packet loss Wheel slippage causes bad odometry readings 3 4 Apply software failsafe Use GPS / Inertial sensors to correct odometry readings 3 Poor / Unavailable GPS connectivity 3 3 Fall back on inertial sensors / odometry alone Jared / Sean 4 Fauly IMU readings 4 1 redundant IMU Jared 5 Unstable control loop 5 1 Vigorous control loop testing Nico 1 © 2014 Carnegie Robotics LLC. Use or disclosure of document data is subject to the restrictions on the title page Mitigation Owner Sean / Jared Page 40
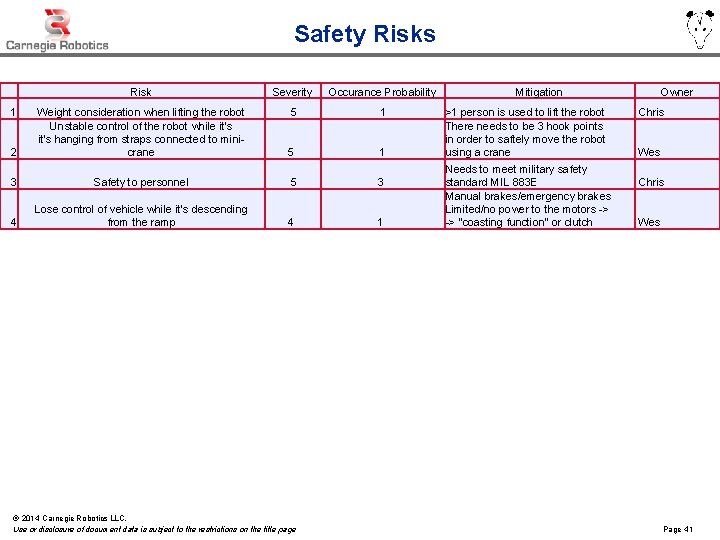
Safety Risks Risk Severity Occurance Probability 5 1 2 Weight consideration when lifting the robot Unstable control of the robot while it's hanging from straps connected to minicrane 5 1 3 Safety to personnel 5 3 4 Lose control of vehicle while it's descending from the ramp 4 1 1 © 2014 Carnegie Robotics LLC. Use or disclosure of document data is subject to the restrictions on the title page Mitigation >1 person is used to lift the robot There needs to be 3 hook points in order to saftely move the robot using a crane Needs to meet military safety standard MIL 883 E Manual brakes/emergency brakes Limited/no power to the motors -> -> "coasting function" or clutch Owner Chris Wes Page 41
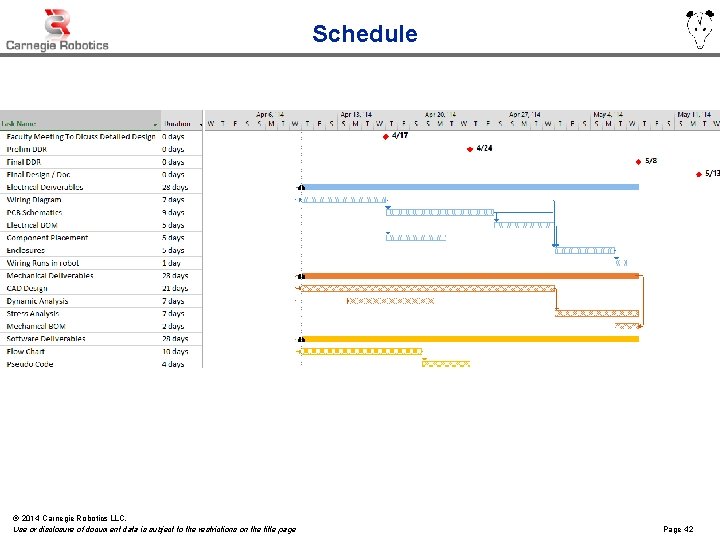
Schedule © 2014 Carnegie Robotics LLC. Use or disclosure of document data is subject to the restrictions on the title page Page 42
To be accomplished • EMF interference mitigation • Further node deployment development ® Prototyping • Schematic and PCB design • Full BOMs • Detailed Design Review Slideshow • Final Detailed Design Review Slideshow • Continued EDGE Updates © 2014 Carnegie Robotics LLC. Use or disclosure of document data is subject to the restrictions on the title page Page 43
Questions © 2014 Carnegie Robotics LLC. Use or disclosure of document data is subject to the restrictions on the title page Page 44
- Slides: 44