
MAGIC Magnetometer Imperial College Patrick Brown Tim Horbury
MAGIC (Magnetometer Imperial College) Patrick Brown & Tim Horbury, Blackett Laboratory, Imperial College 1
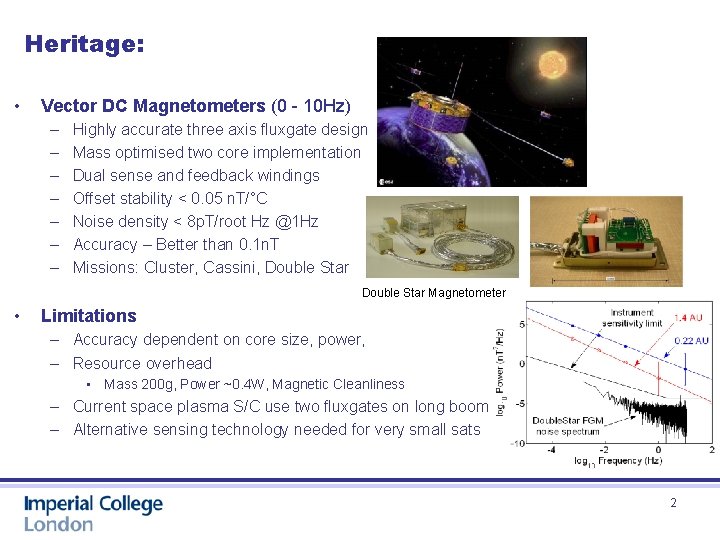
Heritage: • Vector DC Magnetometers (0 - 10 Hz) – – – – Highly accurate three axis fluxgate design Mass optimised two core implementation Dual sense and feedback windings Offset stability < 0. 05 n. T/°C Noise density < 8 p. T/root Hz @1 Hz Accuracy – Better than 0. 1 n. T Missions: Cluster, Cassini, Double Star Magnetometer • Limitations – Accuracy dependent on core size, power, – Resource overhead • Mass 200 g, Power ~0. 4 W, Magnetic Cleanliness – Current space plasma S/C use two fluxgates on long boom – Alternative sensing technology needed for very small sats 2
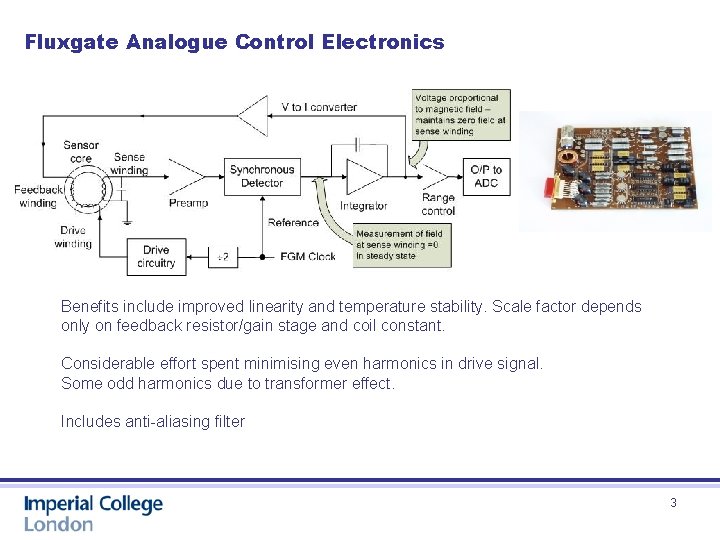
Fluxgate Analogue Control Electronics Benefits include improved linearity and temperature stability. Scale factor depends only on feedback resistor/gain stage and coil constant. Considerable effort spent minimising even harmonics in drive signal. Some odd harmonics due to transformer effect. Includes anti-aliasing filter 3
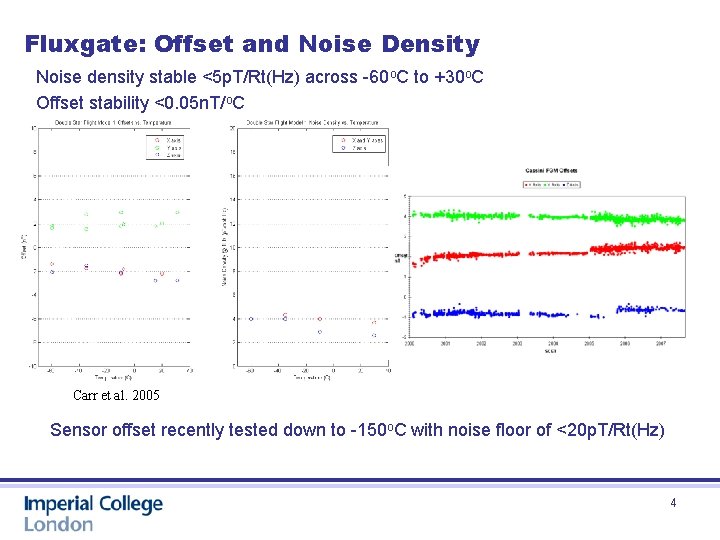
Fluxgate: Offset and Noise Density Noise density stable <5 p. T/Rt(Hz) across -60 o. C to +30 o. C Offset stability <0. 05 n. T/o. C Carr et al. 2005 Sensor offset recently tested down to -150 o. C with noise floor of <20 p. T/Rt(Hz) 4
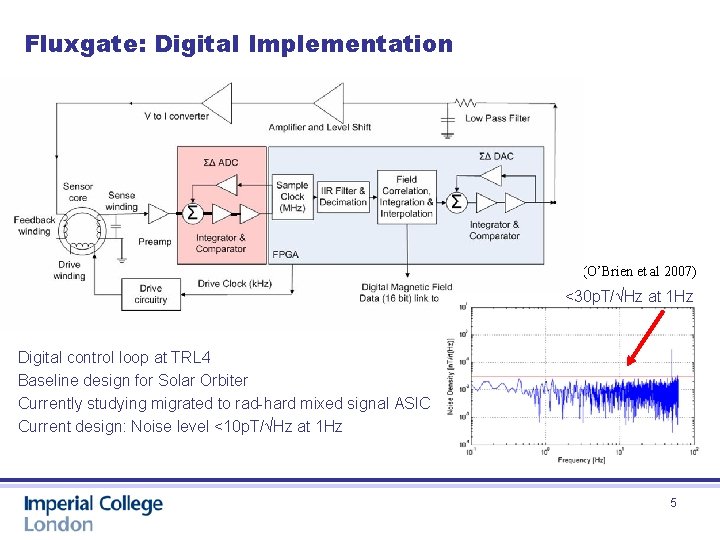
Fluxgate: Digital Implementation (O’Brien et al 2007) <30 p. T/√Hz at 1 Hz Digital control loop at TRL 4 Baseline design for Solar Orbiter Currently studying migrated to rad-hard mixed signal ASIC Current design: Noise level <10 p. T/√Hz at 1 Hz 5

Anisotropic Magnetoresistance • Magneto Resistance Effect – Change of resistance in magnetic field – AMR single layer permalloy, – AMR ΔR/Rmin of order 1 - 2% • Barber Poles – Max, sensitivity & linearity at M v H 45 o – Conductive strips for linear operation • AMR Sensors – Thin film solid state devices – Mass <1 g – Implemented as Wheatstone bridge – Sensitivity varies with bridge voltage, VB Picture Courtesy Philips 6
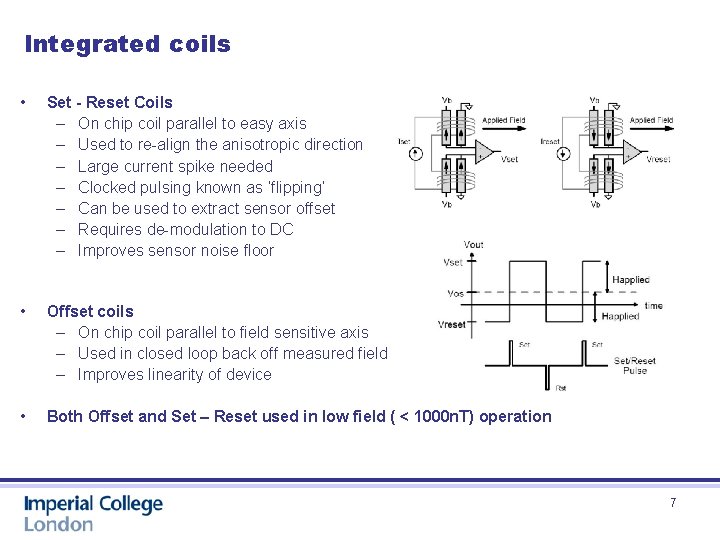
Integrated coils • Set - Reset Coils – On chip coil parallel to easy axis – Used to re-align the anisotropic direction – Large current spike needed – Clocked pulsing known as ‘flipping’ – Can be used to extract sensor offset – Requires de-modulation to DC – Improves sensor noise floor • Offset coils – On chip coil parallel to field sensitive axis – Used in closed loop back off measured field – Improves linearity of device • Both Offset and Set – Reset used in low field ( < 1000 n. T) operation 7
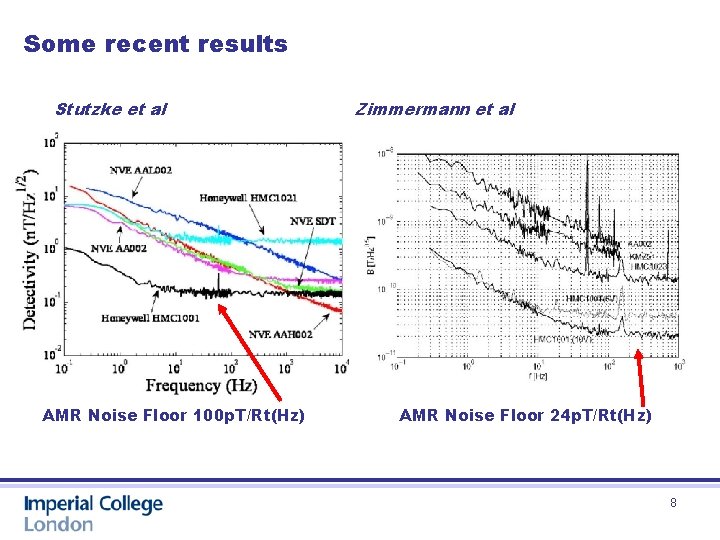
Some recent results Stutzke et al AMR Noise Floor 100 p. T/Rt(Hz) Zimmermann et al AMR Noise Floor 24 p. T/Rt(Hz) 8

Magnetoresistive magnetometer Single axis MR • Control loop will be compatible with Digimag ASIC • Hybrid 3 axis sensor as a single chip planned for late 2010 • MAGIC Breadboard currently single axis 3 axis Fluxgate CINEMA OB Triaxial sensor 9
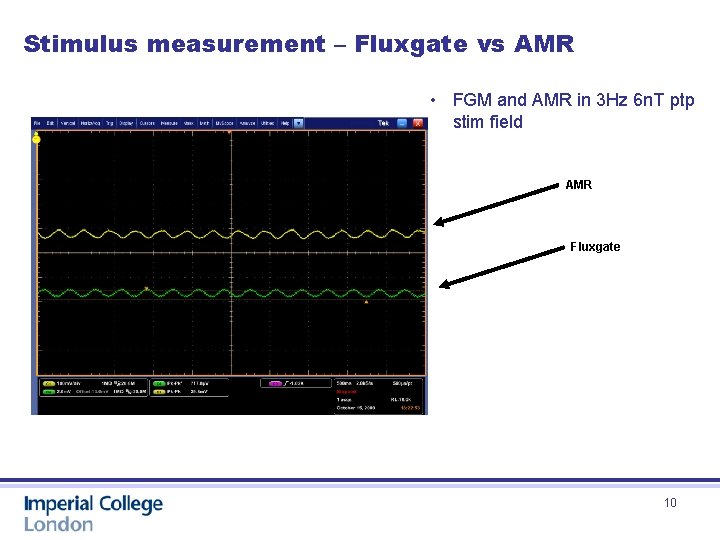
Stimulus measurement – Fluxgate vs AMR • FGM and AMR in 3 Hz 6 n. T ptp stim field AMR Fluxgate 10
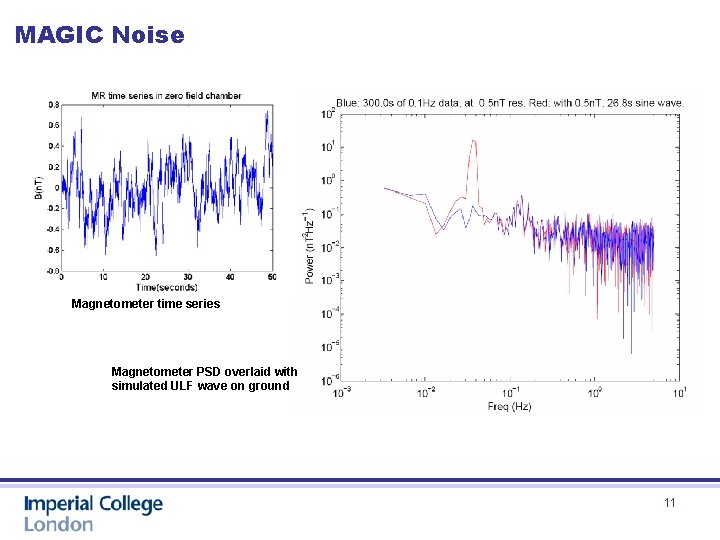
MAGIC Noise Magnetometer time series Magnetometer PSD overlaid with simulated ULF wave on ground 11
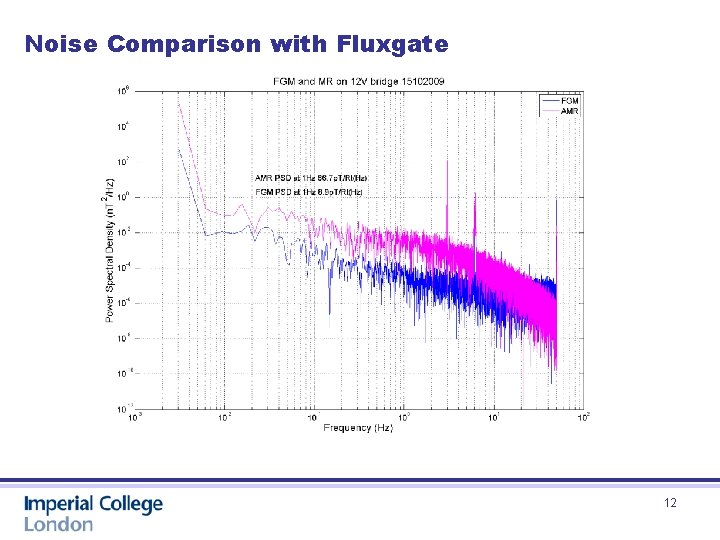
Noise Comparison with Fluxgate 12
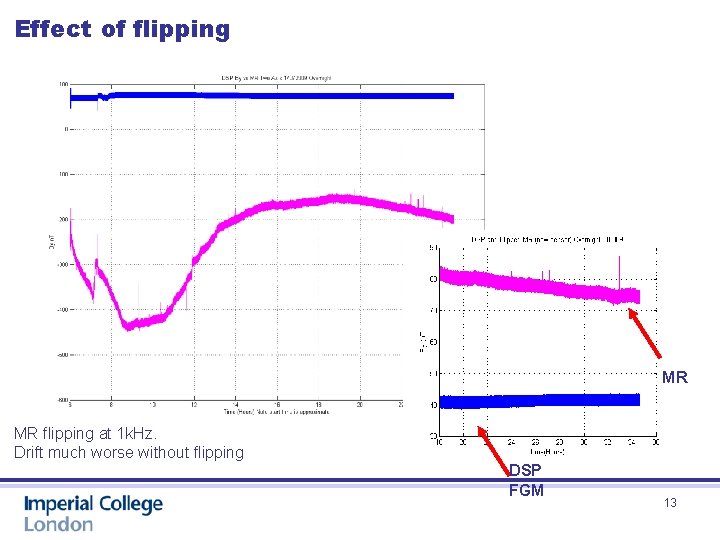
Effect of flipping MR MR flipping at 1 k. Hz. Drift much worse without flipping DSP FGM 13
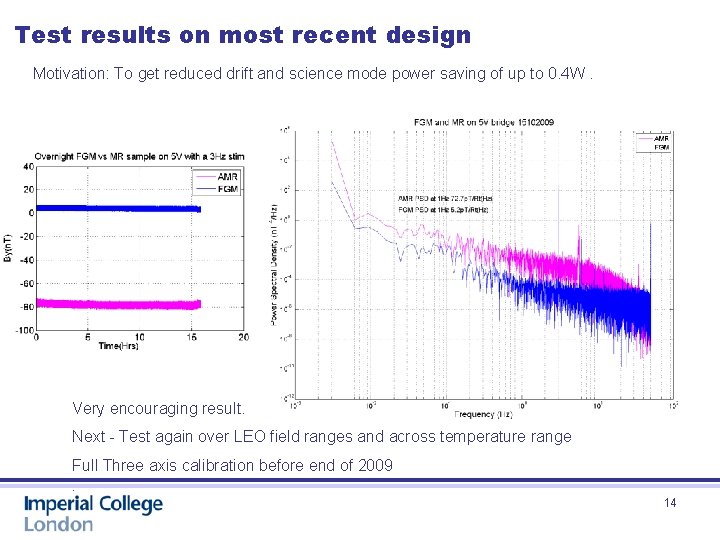
Test results on most recent design Motivation: To get reduced drift and science mode power saving of up to 0. 4 W . Very encouraging result. Next - Test again over LEO field ranges and across temperature range Full Three axis calibration before end of 2009. 14
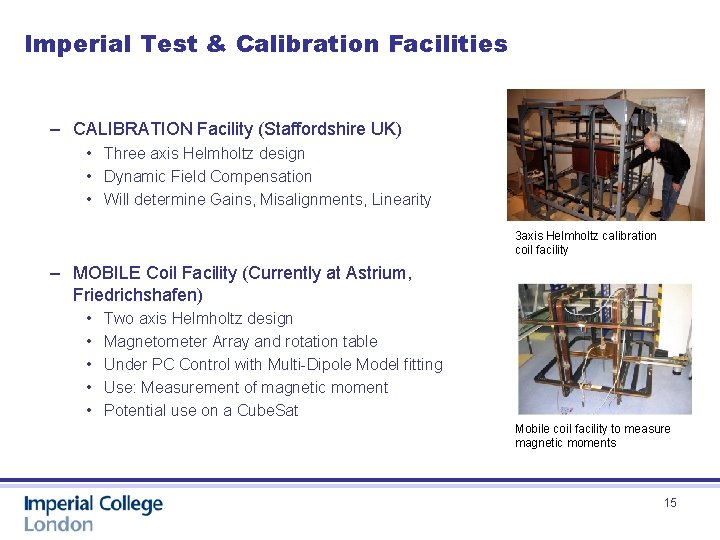
Imperial Test & Calibration Facilities – CALIBRATION Facility (Staffordshire UK) • Three axis Helmholtz design • Dynamic Field Compensation • Will determine Gains, Misalignments, Linearity 3 axis Helmholtz calibration coil facility – MOBILE Coil Facility (Currently at Astrium, Friedrichshafen) • • • Two axis Helmholtz design Magnetometer Array and rotation table Under PC Control with Multi-Dipole Model fitting Use: Measurement of magnetic moment Potential use on a Cube. Sat Mobile coil facility to measure magnetic moments 15
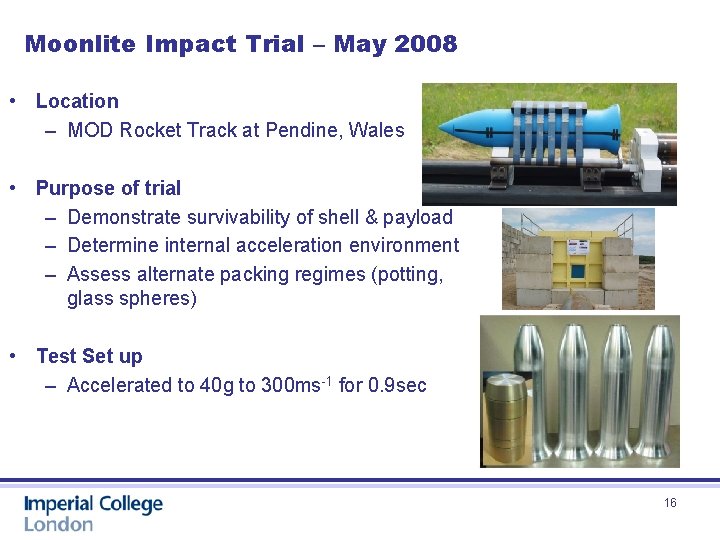
Moonlite Impact Trial – May 2008 • Location – MOD Rocket Track at Pendine, Wales • Purpose of trial – Demonstrate survivability of shell & payload – Determine internal acceleration environment – Assess alternate packing regimes (potting, glass spheres) • Test Set up – Accelerated to 40 g to 300 ms-1 for 0. 9 sec 16
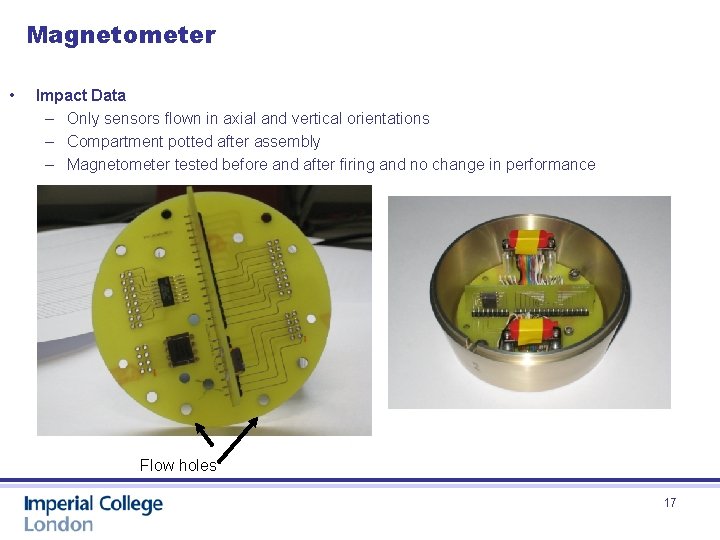
Magnetometer • Impact Data – Only sensors flown in axial and vertical orientations – Compartment potted after assembly – Magnetometer tested before and after firing and no change in performance Flow holes 17
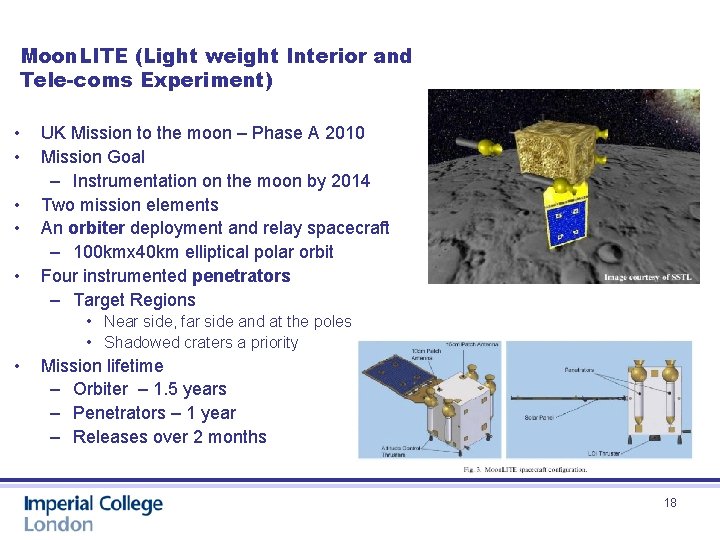
Moon. LITE (Light weight Interior and Tele-coms Experiment) • • • UK Mission to the moon – Phase A 2010 Mission Goal – Instrumentation on the moon by 2014 Two mission elements An orbiter deployment and relay spacecraft – 100 kmx 40 km elliptical polar orbit Four instrumented penetrators – Target Regions • Near side, far side and at the poles • Shadowed craters a priority • Mission lifetime – Orbiter – 1. 5 years – Penetrators – 1 year – Releases over 2 months 18
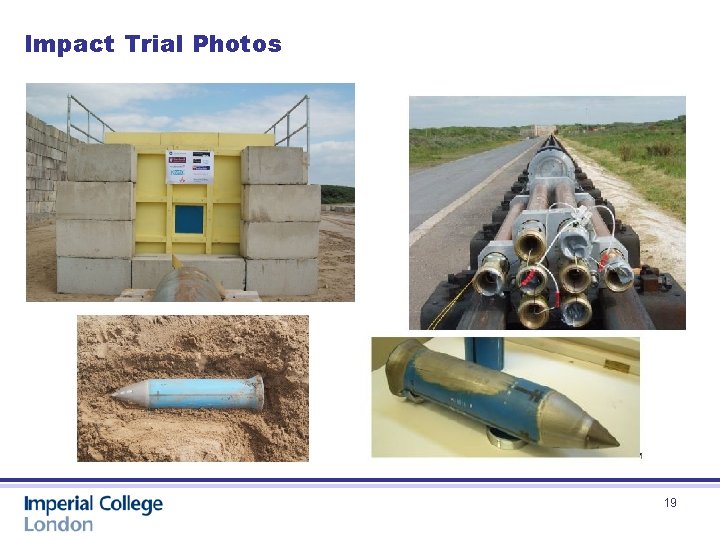
Impact Trial Photos 19
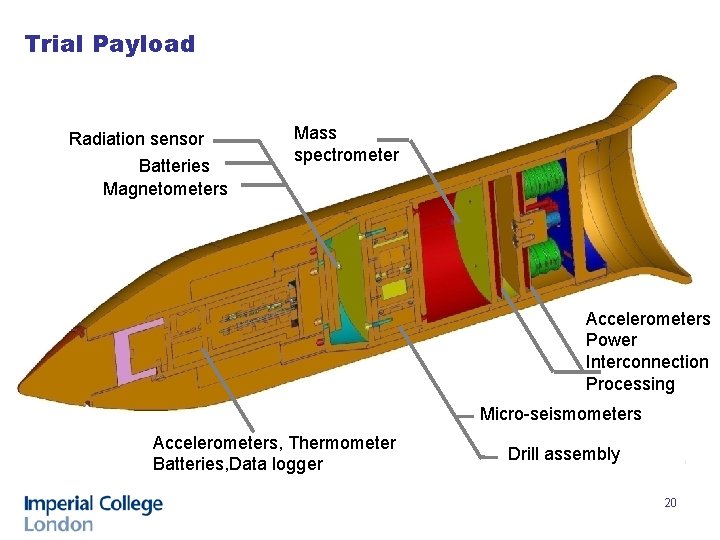
Trial Payload Radiation sensor Batteries Magnetometers Mass spectrometer Accelerometers Power Interconnection Processing Micro-seismometers Accelerometers, Thermometer Batteries, Data logger Drill assembly 20
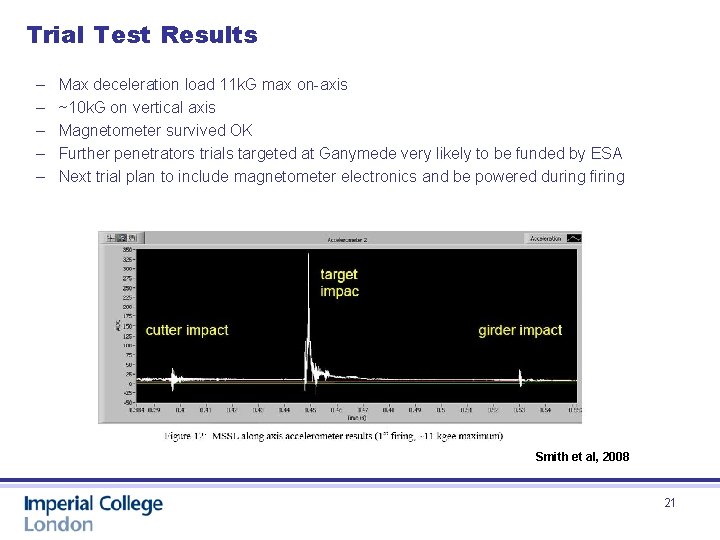
Trial Test Results – – – Max deceleration load 11 k. G max on-axis ~10 k. G on vertical axis Magnetometer survived OK Further penetrators trials targeted at Ganymede very likely to be funded by ESA Next trial plan to include magnetometer electronics and be powered during firing Smith et al, 2008 21
- Slides: 21