
Magellan Software Specification Software Design Options For SemiAutonomous
- Slides: 12
Magellan Software Specification Software Design Options For Semi-Autonomous Mine Mapping Robot
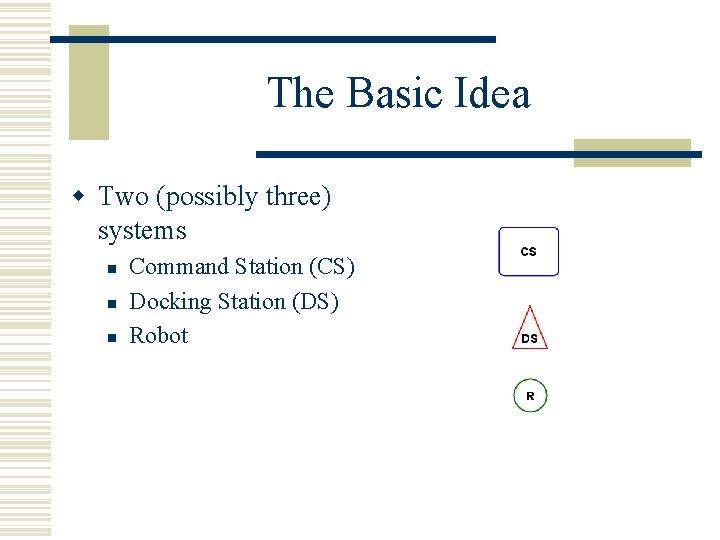
The Basic Idea w Two (possibly three) systems n n n Command Station (CS) Docking Station (DS) Robot
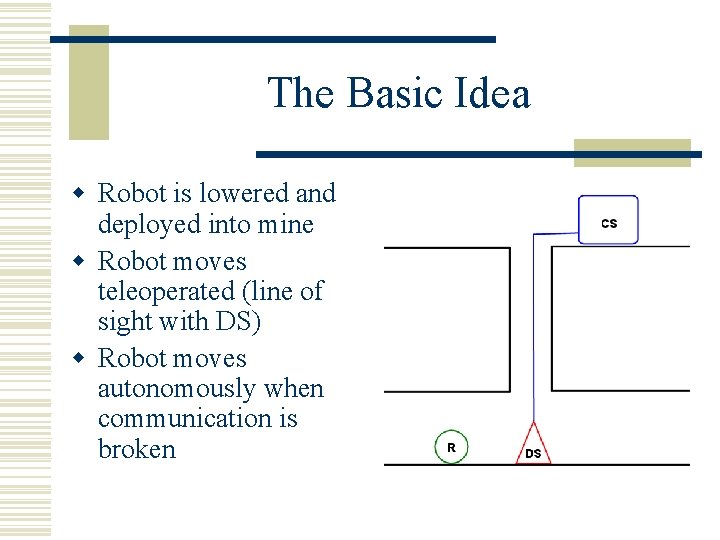
The Basic Idea w Robot is lowered and deployed into mine w Robot moves teleoperated (line of sight with DS) w Robot moves autonomously when communication is broken
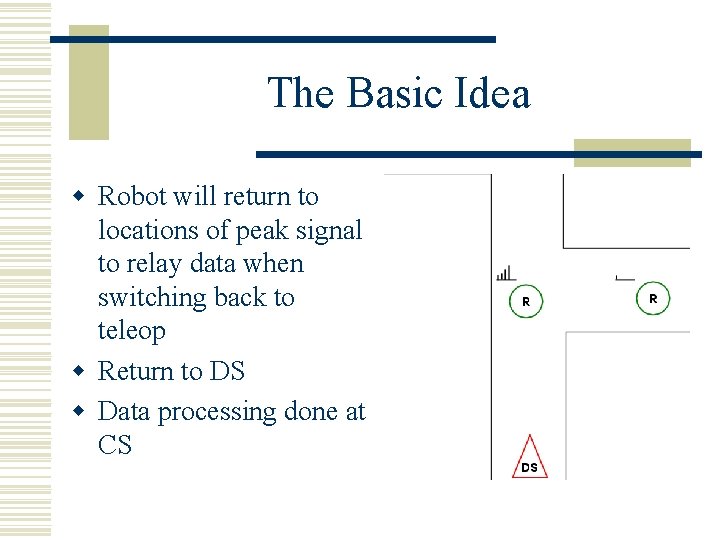
The Basic Idea w Robot will return to locations of peak signal to relay data when switching back to teleop w Return to DS w Data processing done at CS
Categorical Decomposition of Software w Mapping and Localization w Teleoperation w Autonomy *Motor control software, communication software, etc. are sub -categories of these primary themes
Mapping and Localization w Data Acquisition (sensor dependent) n Sensor Interfacing l n drivers, ports, protocols Heterogeneous Sensor Integration w Data Analysis n n n Filtering Map Generation Robot Motion Planning (Localization)
Teleoperation w User Interface n n Graphical Interface Modes and means of interaction w Contextual Transfer n Sensor Interpretation l issues of power consumption, bandwidth, etc w Communication Protocol w Level of Control
Autonomous w Autonomous objectives (obstacles, deployment) w Failure Modes w Path planning algorithm w Switching to/from Autonomous mode
Specifications w Mapping Software: n n Sebastian’s SLAM techniques if aided Occupancy Grid techniques w Autonomous Navigation: n n D* Wall following / Wall centering
Specifications w Teleoperation n Point-and-click w Communciation n n Wireless to DS. Raw data is buffered to DS then to CS while in teleop. Data is held while autonomous until strong signal is detected. Storage capacity issue.
Ideas or Arguments w Camera? n Advantages Improve Teleop l Get over obstacles l n Disadvantages Need Lights… major power l Consume processing and bandwidth l Offers nothing directly to mapping l
More Ideas… Closer to Design w OS: Linux or Windows w Off-board computing from CS w Obstacle scaling w Any others?