
Lecture 05 Analysis I Time Response and State
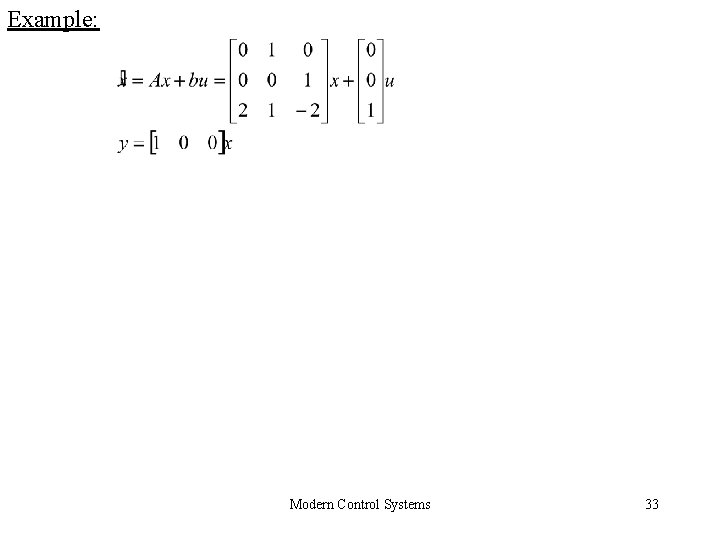
- Slides: 33
Lecture 05 Analysis (I) Time Response and State Transition Matrix 5. 1 State Transition Matrix 5. 2 Modal decomposition --Diagonalization 5. 3 Cayley-Hamilton Theorem Modern Control Systems 1
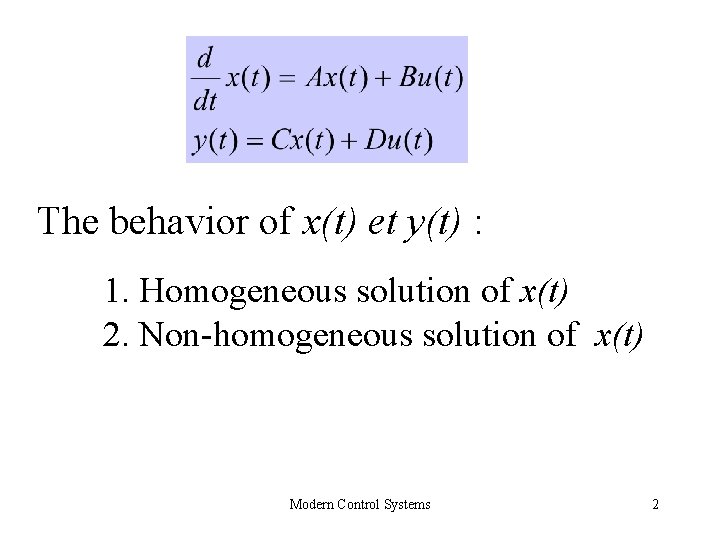
The behavior of x(t) et y(t) : 1. Homogeneous solution of x(t) 2. Non-homogeneous solution of x(t) Modern Control Systems 2
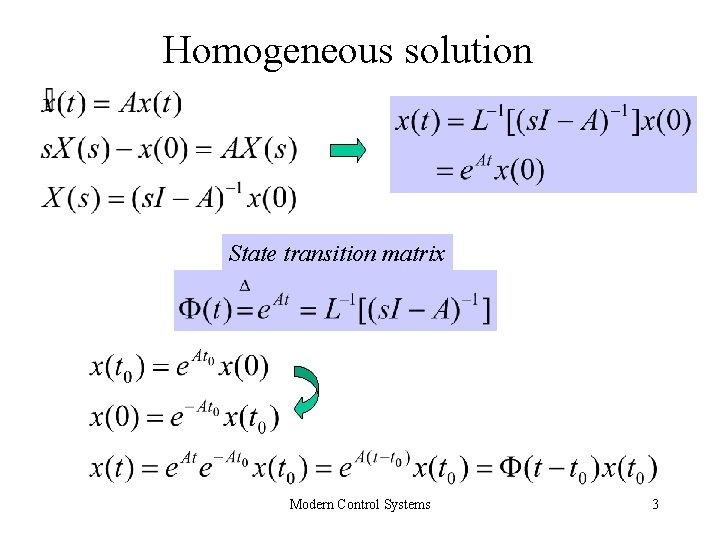
Homogeneous solution State transition matrix Modern Control Systems 3
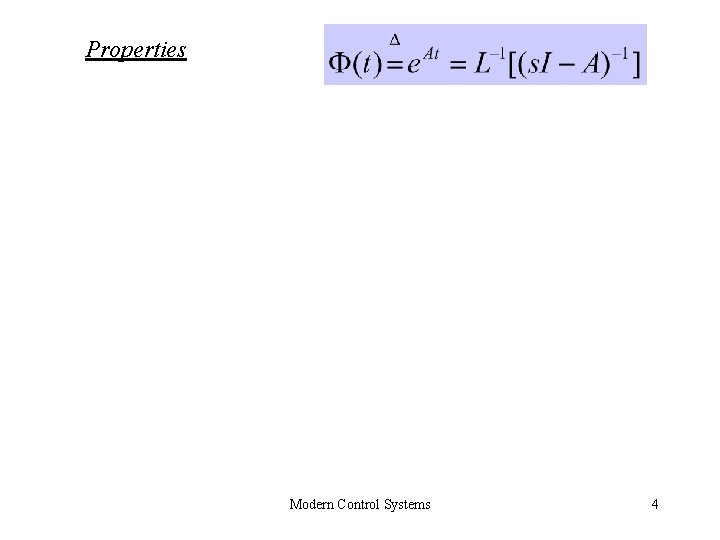
Properties Modern Control Systems 4
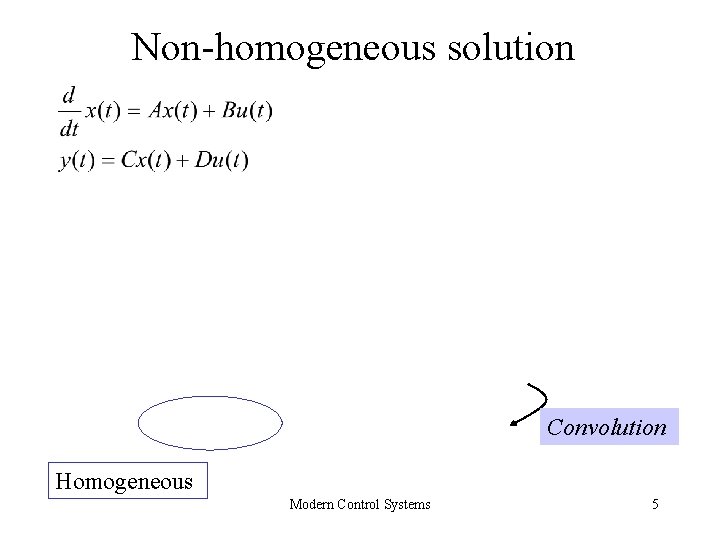
Non-homogeneous solution Convolution Homogeneous Modern Control Systems 5
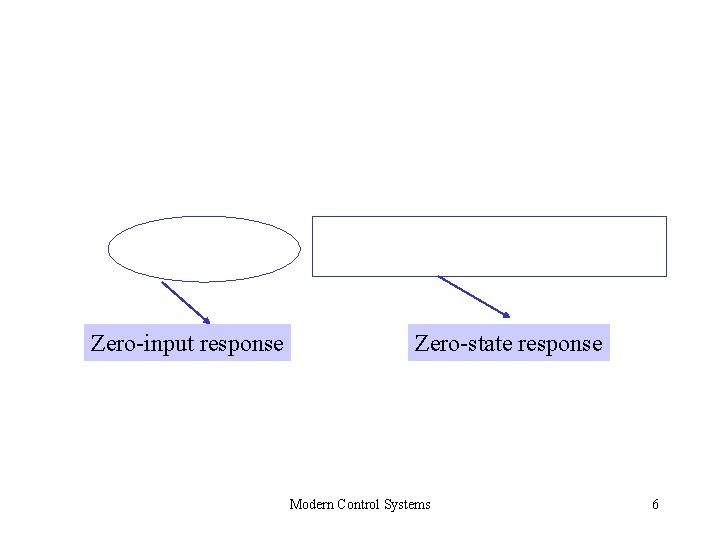
Zero-input response Zero-state response Modern Control Systems 6
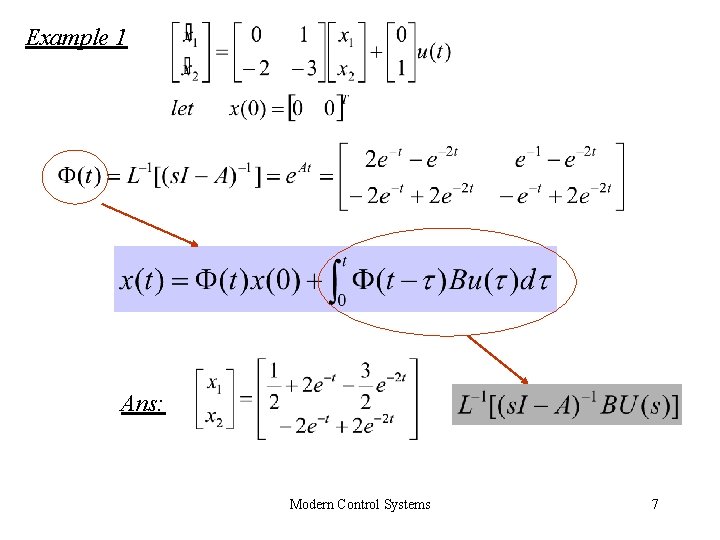
Example 1 Ans: Modern Control Systems 7
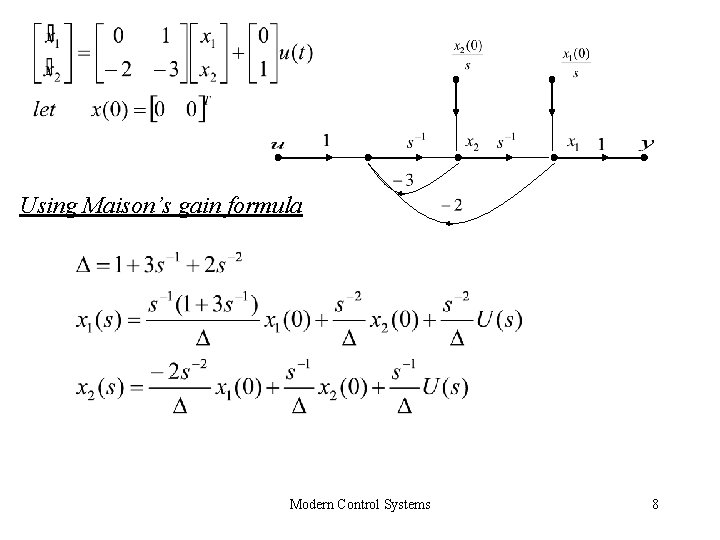
Using Maison’s gain formula Modern Control Systems 8
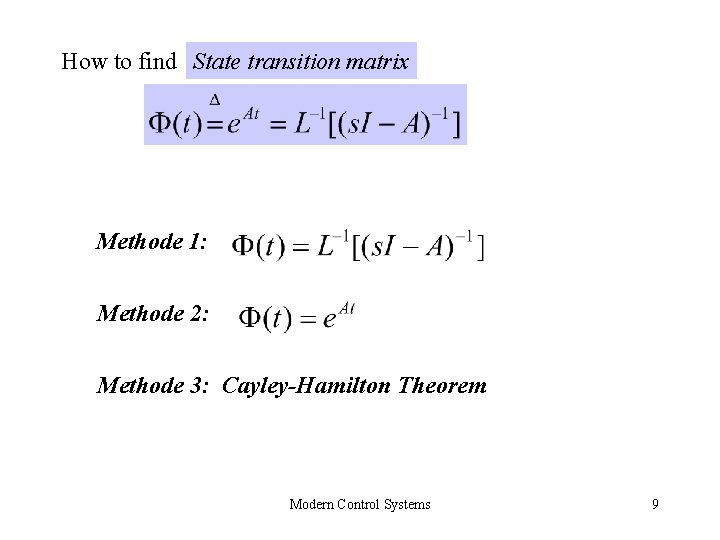
How to find State transition matrix Methode 1: Methode 2: Methode 3: Cayley-Hamilton Theorem Modern Control Systems 9
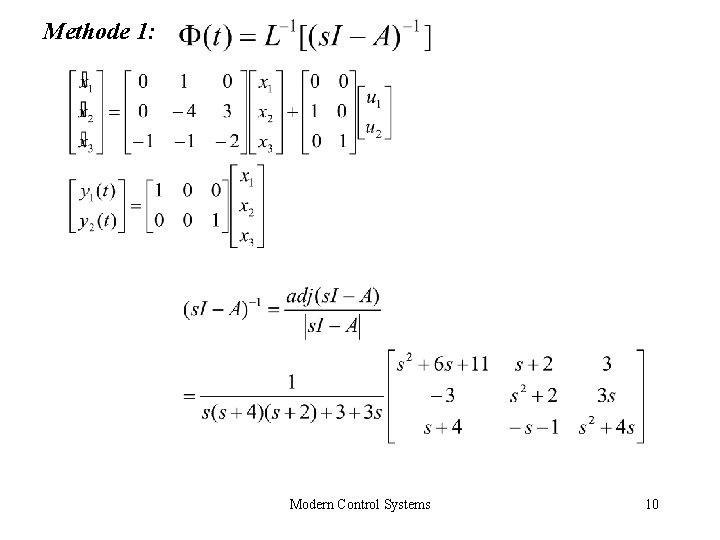
Methode 1: Modern Control Systems 10
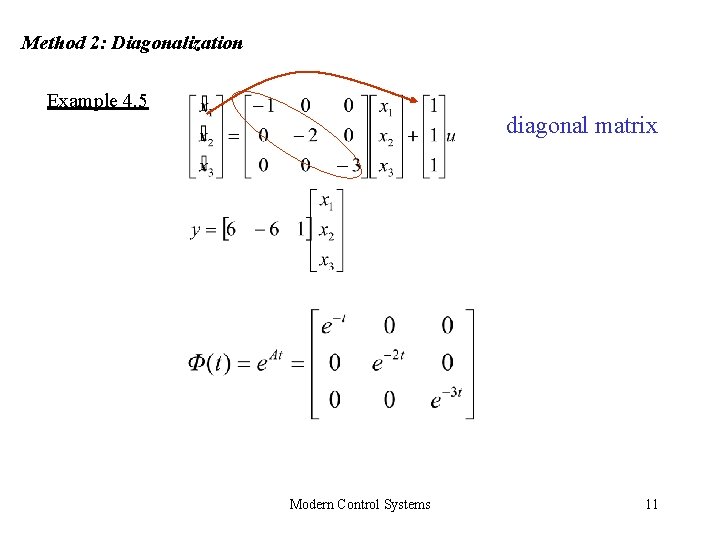
Method 2: Diagonalization Example 4. 5 diagonal matrix Modern Control Systems 11
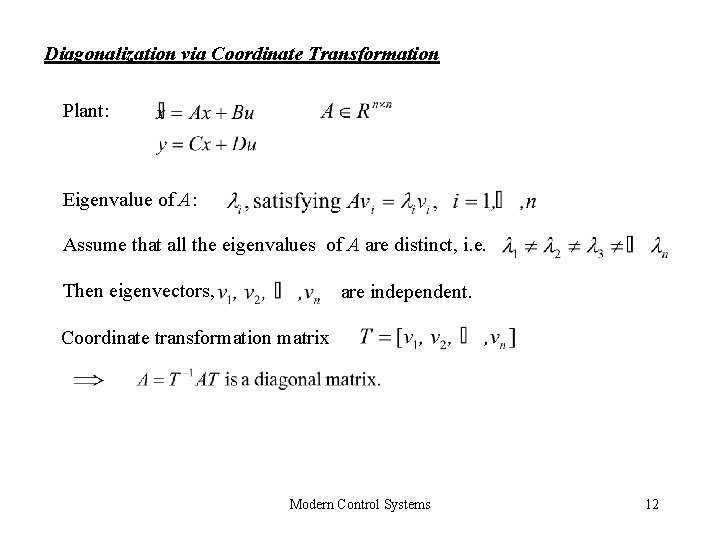
Diagonalization via Coordinate Transformation Plant: Eigenvalue of A: Assume that all the eigenvalues of A are distinct, i. e. Then eigenvectors, are independent. Coordinate transformation matrix Modern Control Systems 12
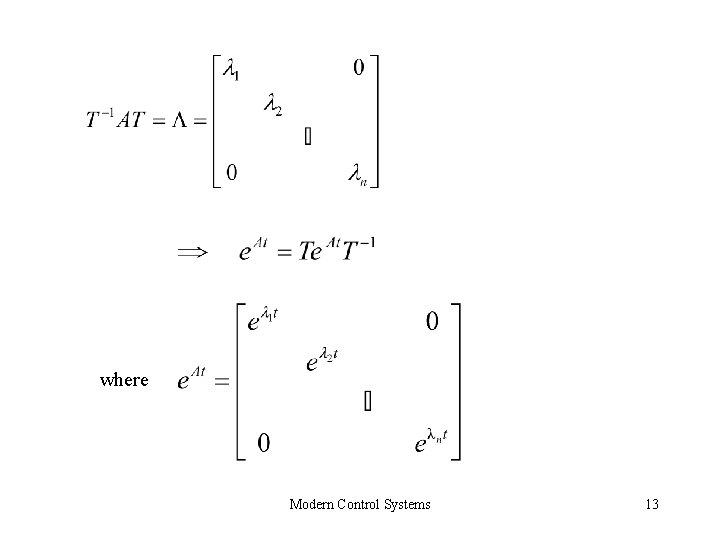
where Modern Control Systems 13
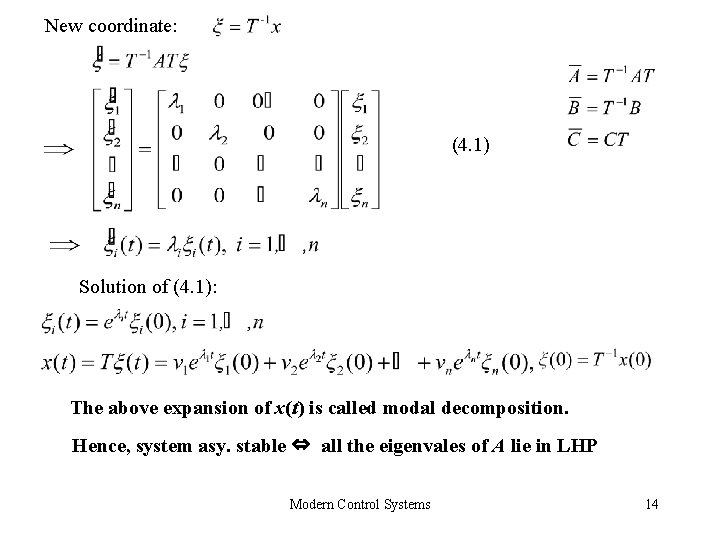
New coordinate: (4. 1) Solution of (4. 1): The above expansion of x(t) is called modal decomposition. Hence, system asy. stable ⇔ all the eigenvales of A lie in LHP Modern Control Systems 14
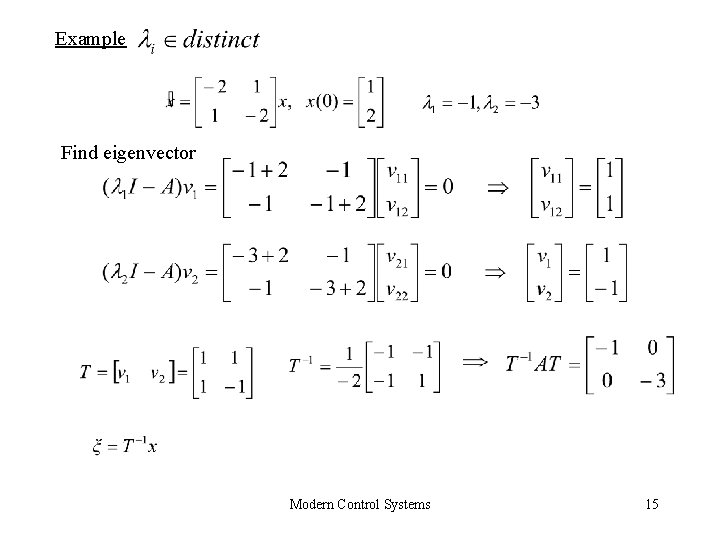
Example Find eigenvector Modern Control Systems 15
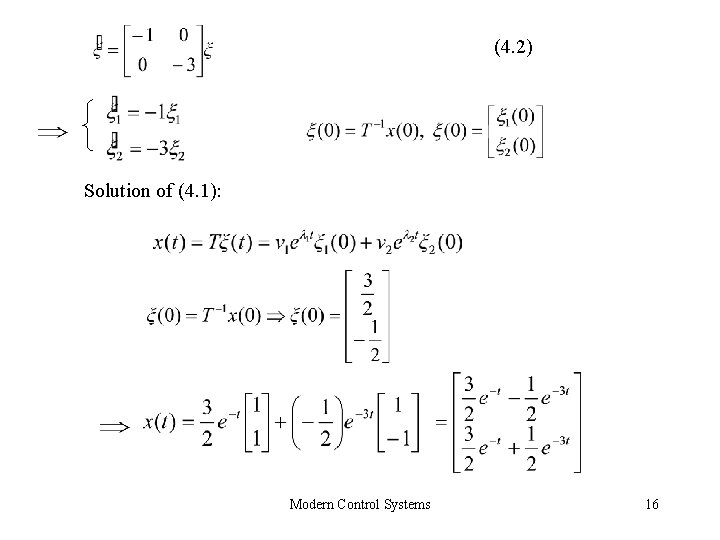
(4. 2) Solution of (4. 1): Modern Control Systems 16
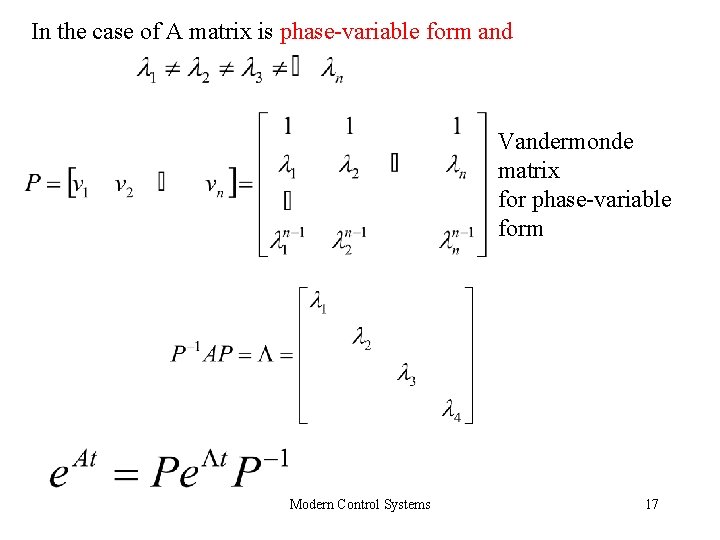
In the case of A matrix is phase-variable form and Vandermonde matrix for phase-variable form Modern Control Systems 17
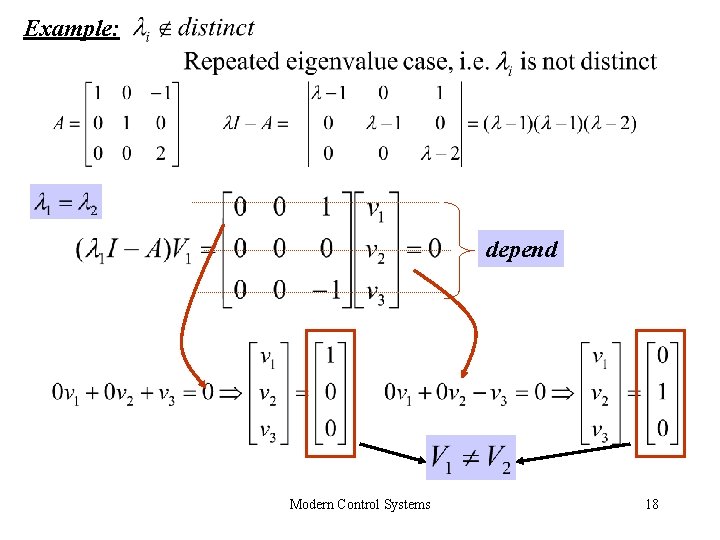
Example: depend Modern Control Systems 18
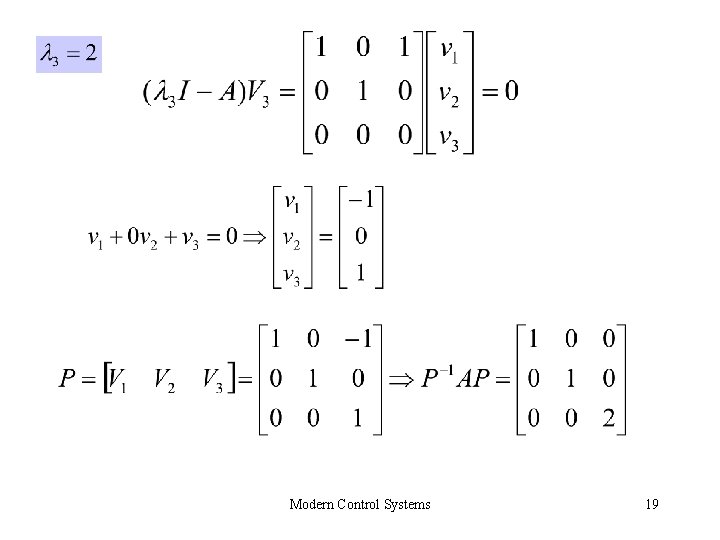
Modern Control Systems 19
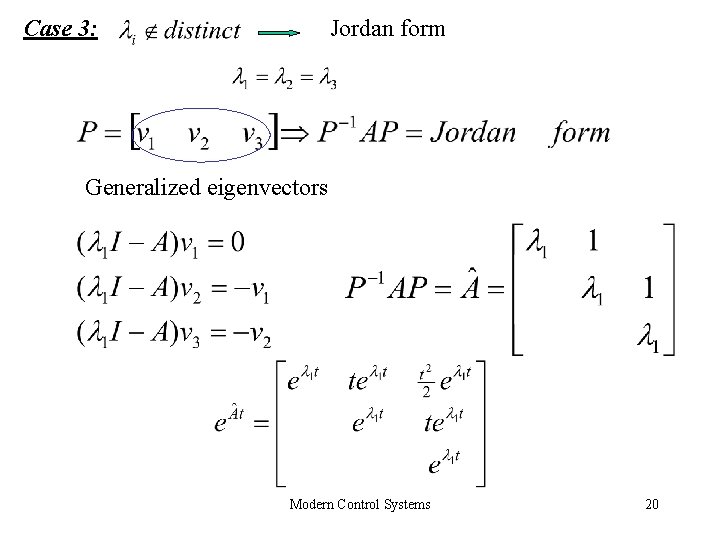
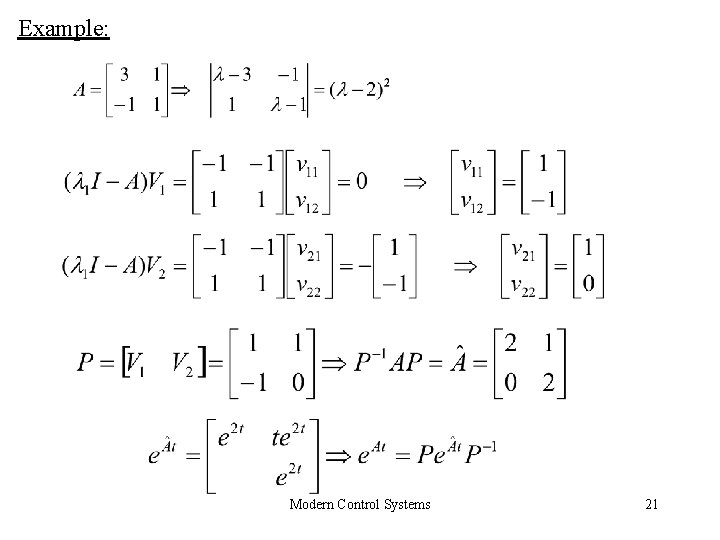
Case 3: Jordan form Generalized eigenvectors Modern Control Systems 20
Example: Modern Control Systems 21
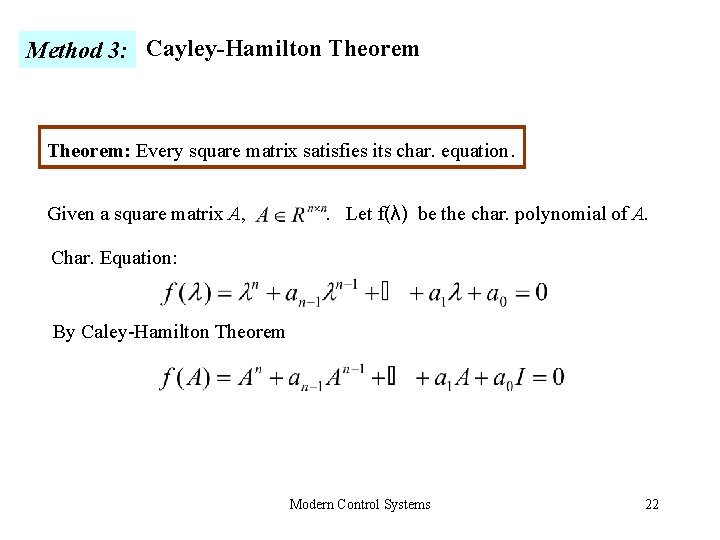
Method 3: Cayley-Hamilton Theorem: Every square matrix satisfies its char. equation. Given a square matrix A, . Let f(λ) be the char. polynomial of A. Char. Equation: By Caley-Hamilton Theorem Modern Control Systems 22
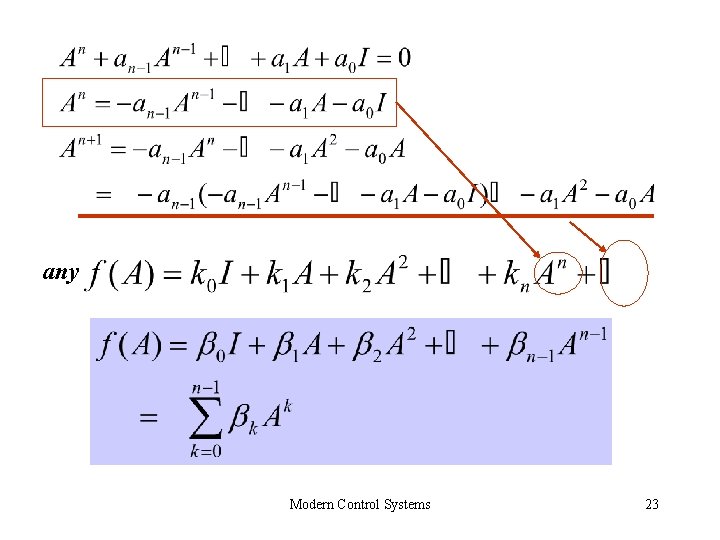
any Modern Control Systems 23
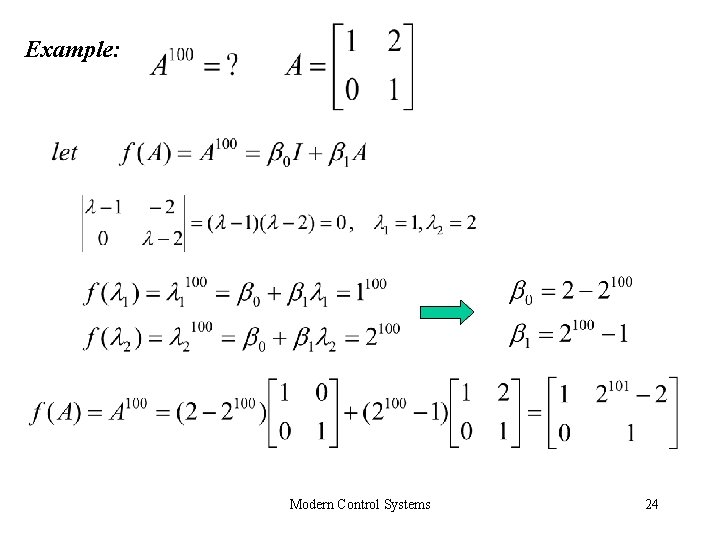
Example: Modern Control Systems 24
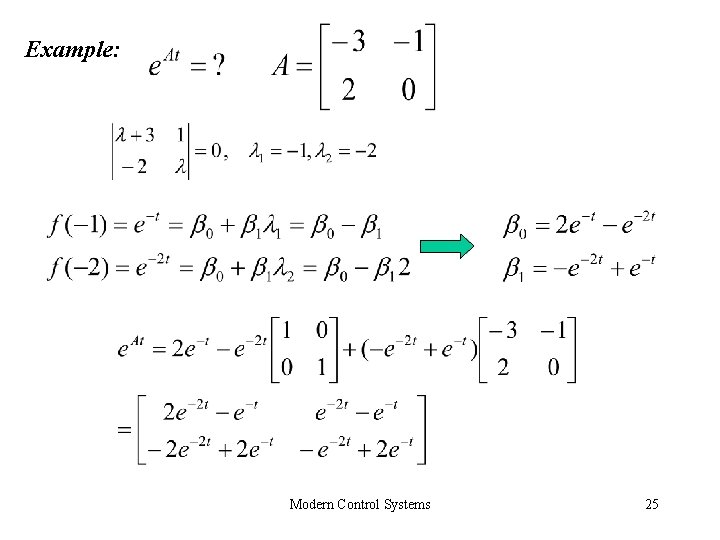
Example: Modern Control Systems 25
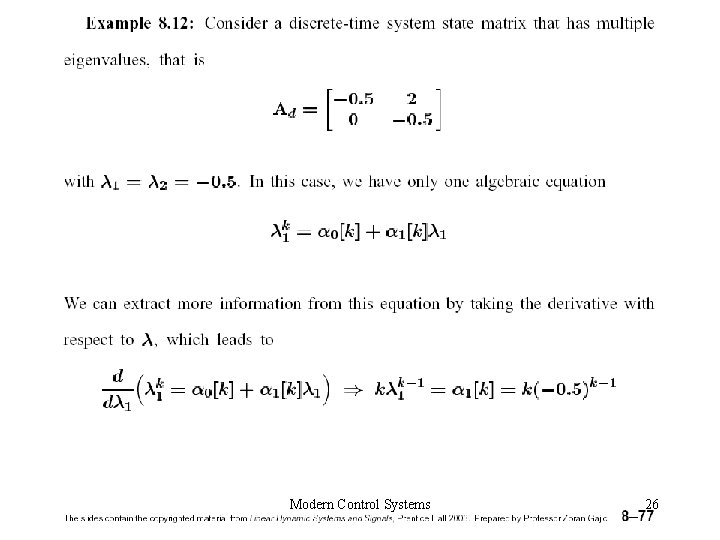
Modern Control Systems 26
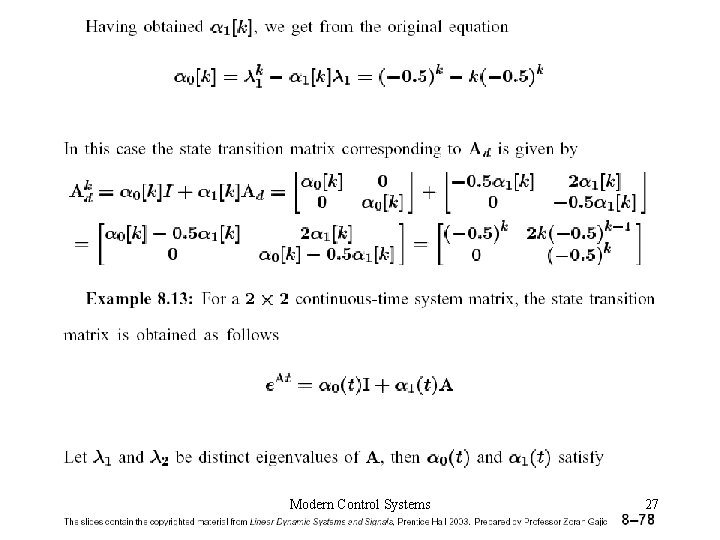
Modern Control Systems 27
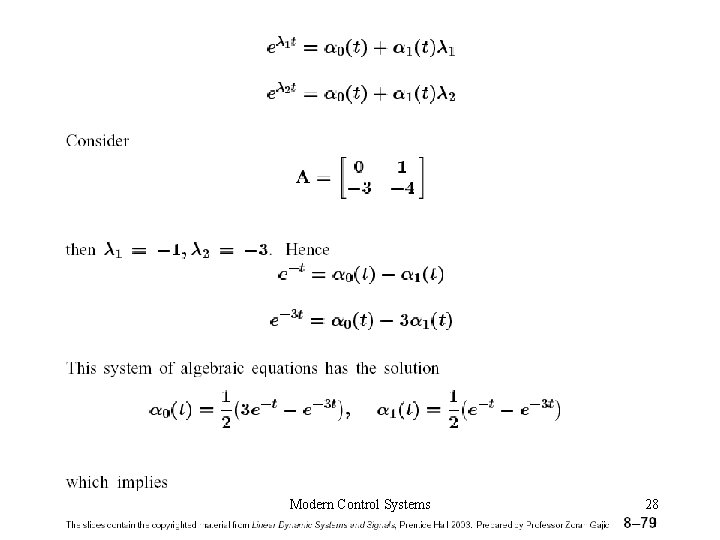
Modern Control Systems 28
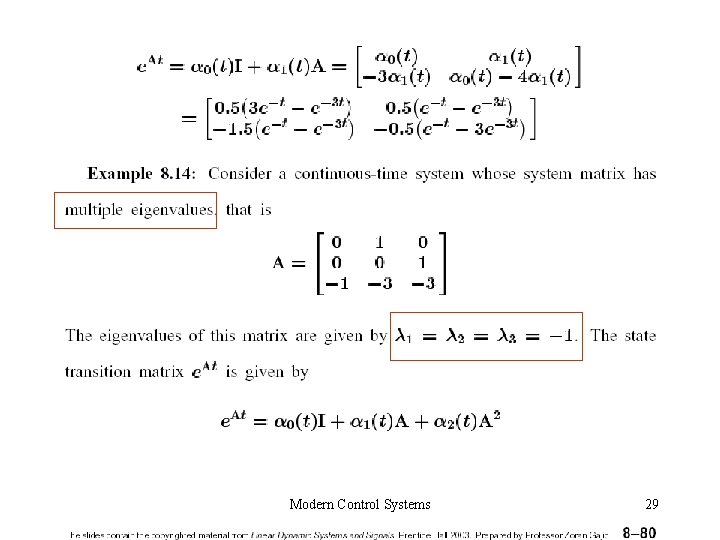
Modern Control Systems 29
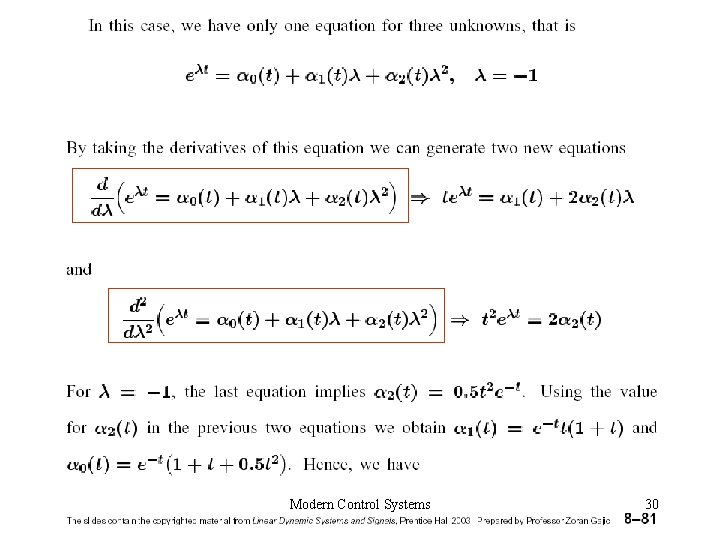
Modern Control Systems 30
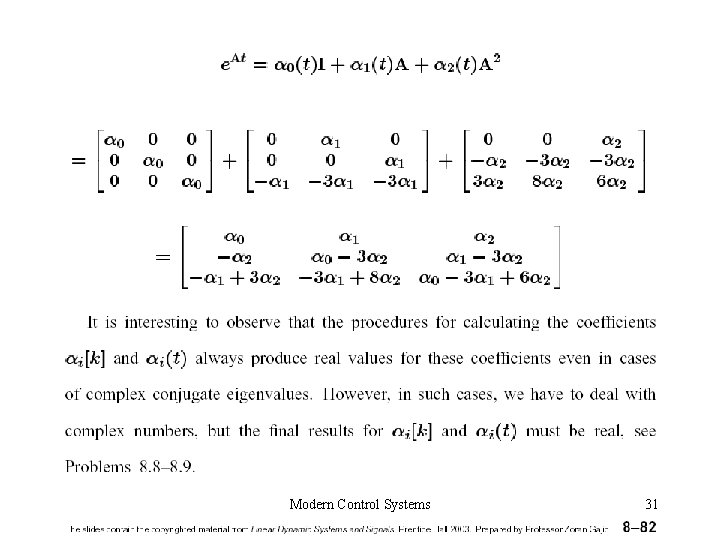
Modern Control Systems 31
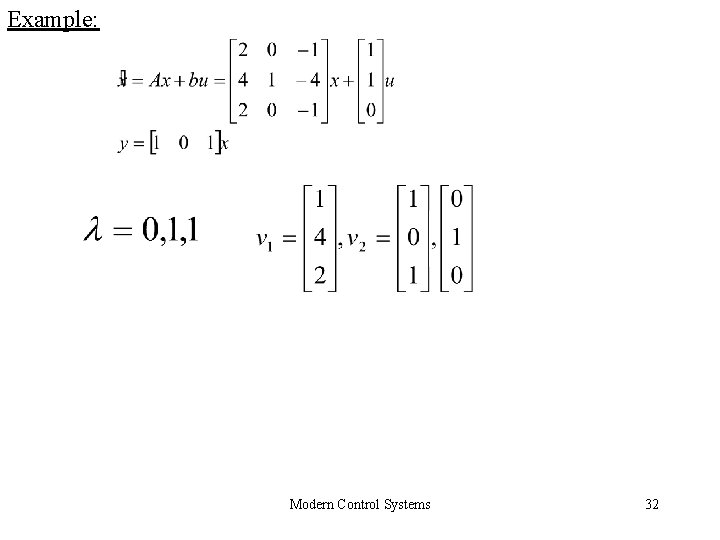
Example: Modern Control Systems 32
Example: Modern Control Systems 33