
Kalman Filter Results Fred Astaire and Ginger Rogers
- Slides: 6
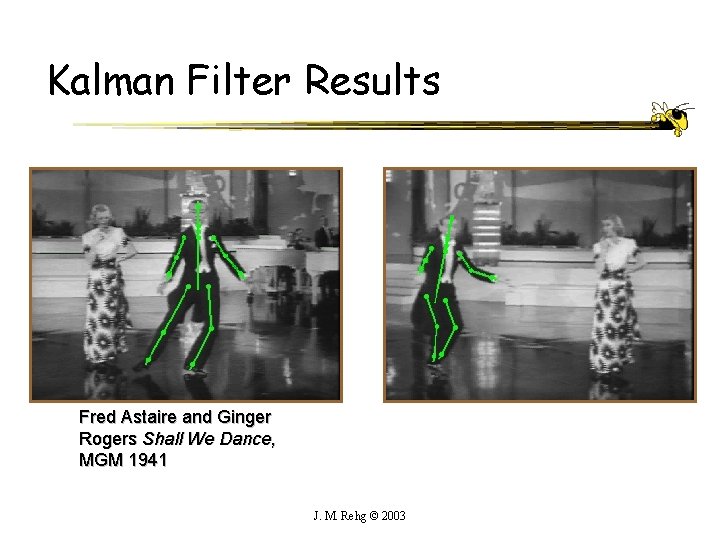
Kalman Filter Results Fred Astaire and Ginger Rogers Shall We Dance, MGM 1941 J. M. Rehg © 2003
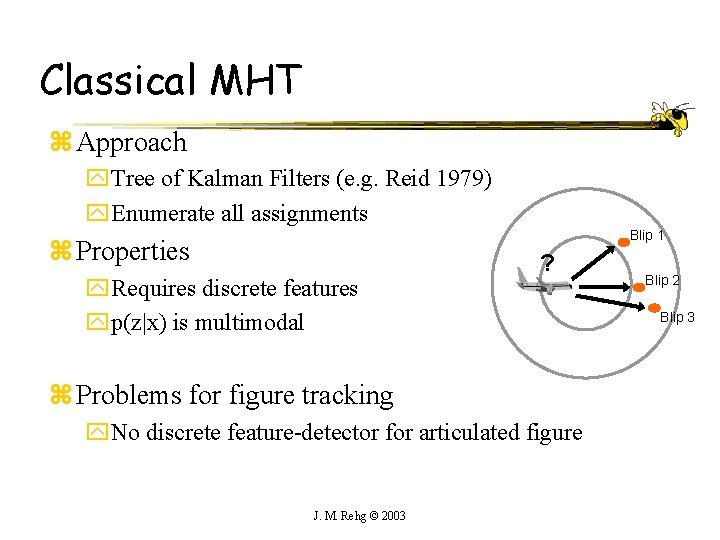
Classical MHT z Approach y. Tree of Kalman Filters (e. g. Reid 1979) y. Enumerate all assignments Blip 1 z Properties y. Requires discrete features yp(z|x) is multimodal ? z Problems for figure tracking y. No discrete feature-detector for articulated figure J. M. Rehg © 2003 Blip 2 Blip 3
Monte-Carlo Methods z Approach y. Nonparametric (sample-based) pdf updated via SIR. y. Particle filter for time series data ye. g. CONDENSATION algorithm (Isard & Blake 1996) z Properties y. Can approximate arbitrary density functions y. Number of samples exponential in size of state space z Problems for figure tracking: y. Prohibitive number of samples are required due to x. High dimensions (38 states) x. Weak dynamical model (constant velocity) J. M. Rehg © 2003
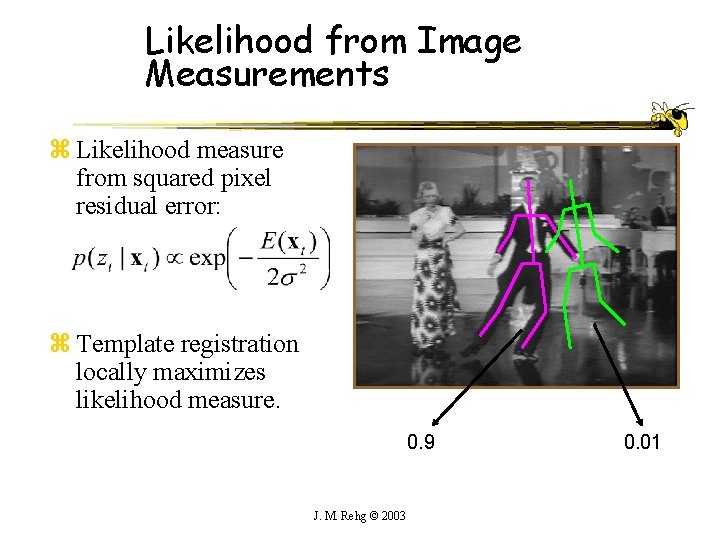
Likelihood from Image Measurements z Likelihood measure from squared pixel residual error: z Template registration locally maximizes likelihood measure. 0. 9 J. M. Rehg © 2003 0. 01
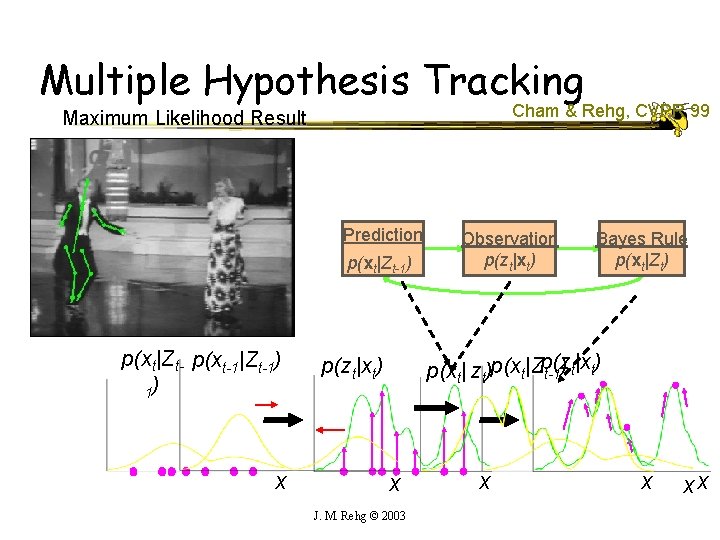
Multiple Hypothesis Tracking Cham & Rehg, CVPR 99 Maximum Likelihood Result Prediction p(xt|Zt-1) p(xt|Zt- p(xt-1|Zt-1) 1) x Observation p(zt|xt) Bayes Rule p(xt|Zt) |x ) p(xt| zt)p(xt|Zp(z t-1) t t p(zt|xt) x J. M. Rehg © 2003 x x xx
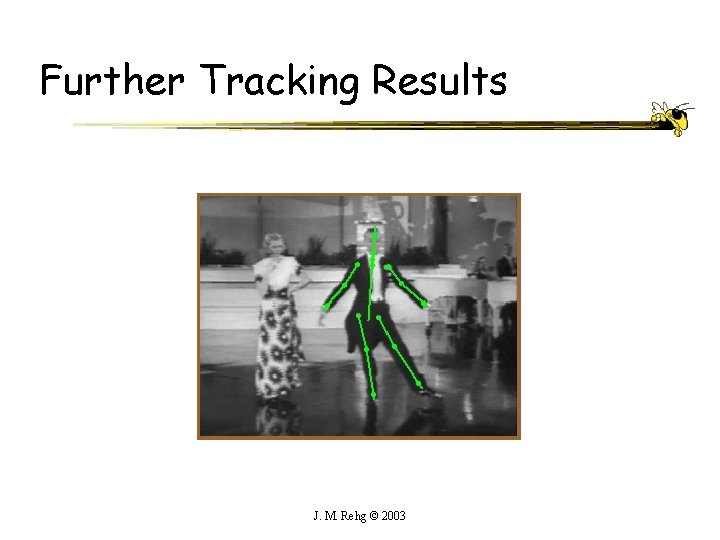
Further Tracking Results J. M. Rehg © 2003