
ISO 26262 PROCESS Req Technical Req BMW Group
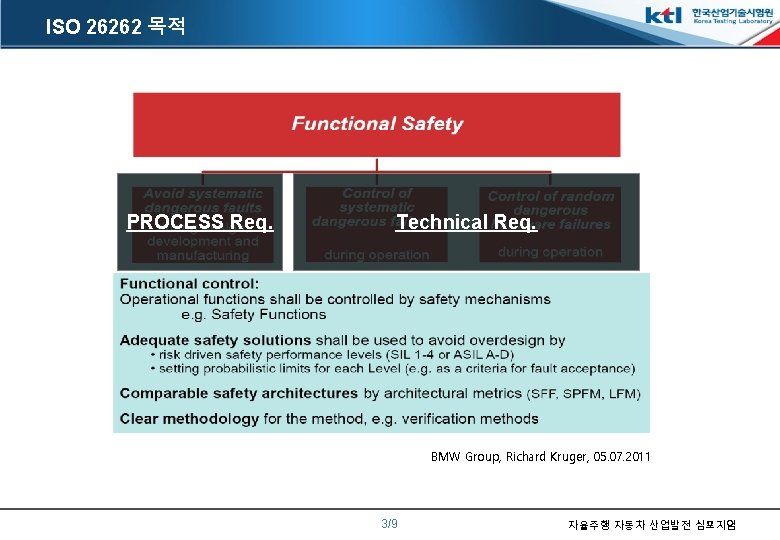
ISO 26262 목적 PROCESS Req. Technical Req. BMW Group, Richard Kruger, 05. 07. 2011 3/9 자율주행 자동차 산업발전 심포지엄
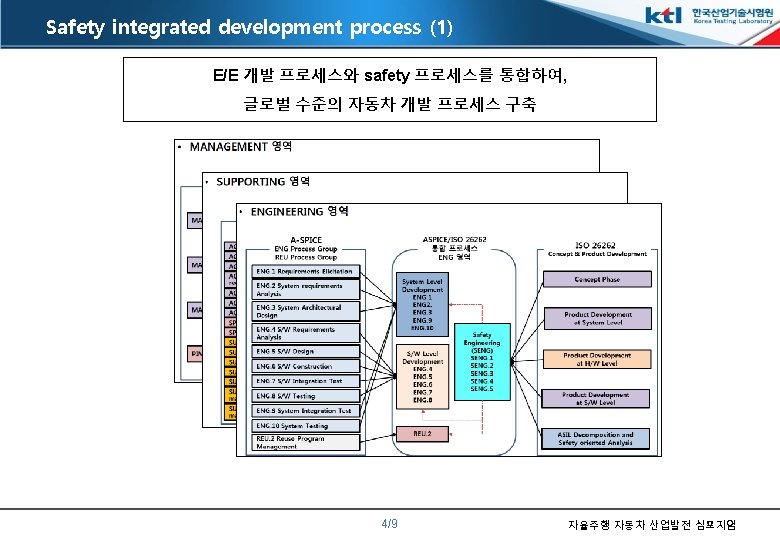
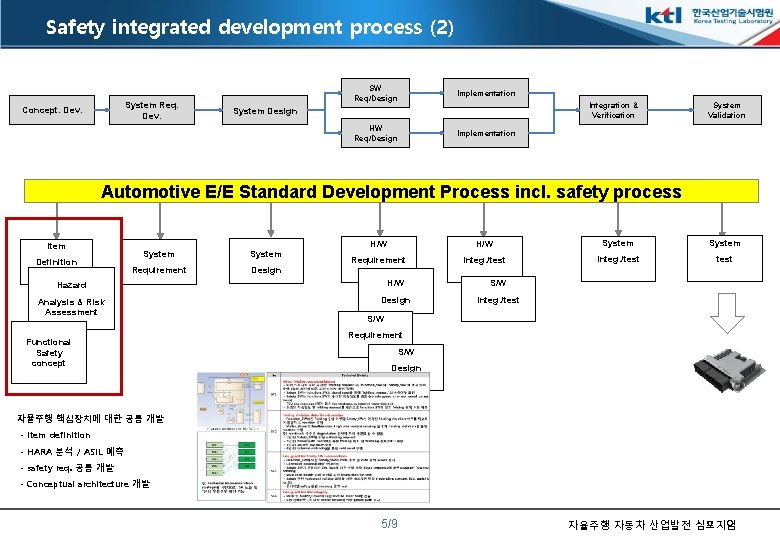
Safety integrated development process (2) System Req. Dev. Concept. Dev. SW Req/Design Implementation HW Req/Design Implementation Integration & Verification System Design System Validation Automotive E/E Standard Development Process incl. safety process H/W System Requirement Integ. /test Hazard H/W S/W Analysis & Risk Assessment Design Integ. /test Item Definition System Requirement Design S/W Requirement Functional Safety concept S/W Design 자동비상제동장치(AEBS) 실시간 원격자율주행(군집주행) 차량상태 모니터링 보행자 추돌 경고 시스템(PCW, Pedestrian Collision Warning) 자율주행 핵심장치에 대한 공통 개발 - Item definition - HARA 분석 / ASIL 예측 - safety req. 공통 개발 - Conceptual architecture 개발 조명 변화 및 차선 불연속에 강인한 차선 인식 기술(Lane detection) 협력적 적응 순항제어(CACC, Cooperative Adaptive Cruise Control) 차선 유지 보조 시스템(LKAS, Lane Keeping Assistance System) 적응형 상향등 제어(AHBC, Adaptive High Beam Control) 후/측면 접근차량 경고 시스템(CTA, Cross Traffic Alert) 후진 물체 경고 시스템(ERBA, Extended Range Backing Aid System) ………. . 5/9 자율주행 자동차 산업발전 심포지엄
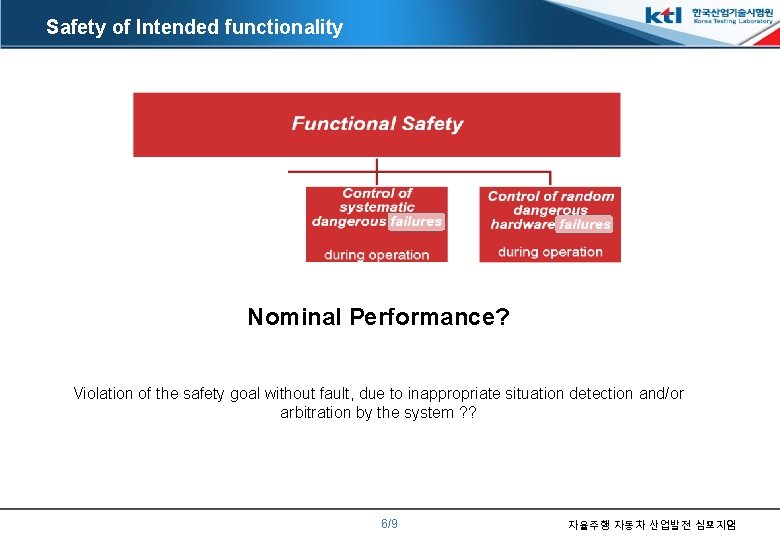
Safety of Intended functionality Nominal Performance? Violation of the safety goal without fault, due to inappropriate situation detection and/or arbitration by the system ? ? BMW Group, Richard Kruger, 05. 07. 2011 6/9 자율주행 자동차 산업발전 심포지엄
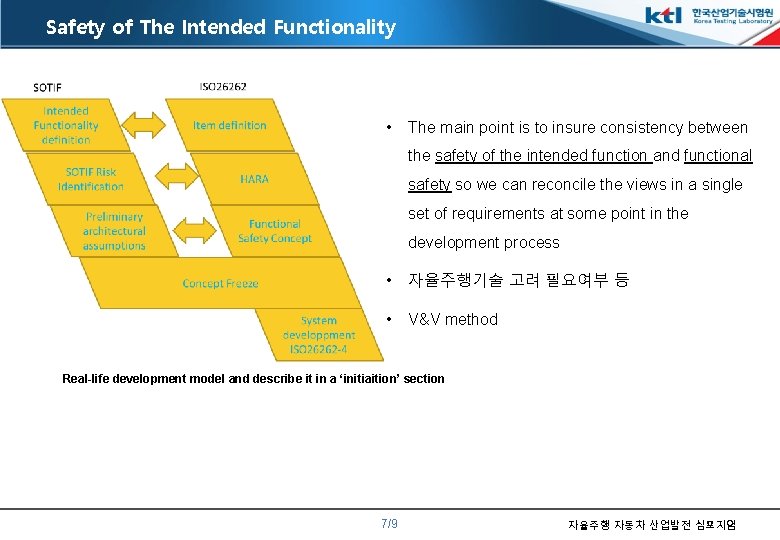
Safety of The Intended Functionality • The main point is to insure consistency between the safety of the intended function and functional safety so we can reconcile the views in a single set of requirements at some point in the development process • 자율주행기술 고려 필요여부 등 • V&V method Real-life development model and describe it in a ‘initiaition’ section 7/9 자율주행 자동차 산업발전 심포지엄
Summary • Safety integration development process 필요 (Automotive SPICE, ISO 26262 등) • ISO 26262를 고려한 자율주행기술 개발을 위하여, 핵심장치에 대한 HARA, ASIL 예측, safety requirement, safety concept architecture 등 공통 개발 (정부 주도) sensor, controller, actuator, semiconductor 제조사 개발 지원 • 자율주행 기술에 대한 V&V(Verification & Validation) 기술 개발 보급 - Sensor / Controller(decision algorithm) / Actuator 컴포넌트별 V&V - Robustness(against Noise) / Controllerability V&V - SIL, HIL, Long term vehicle test 방법 등등 개발 고병각(bgkoh@ktl. re. kr) 042 -939 -6001 8/9 자율주행 자동차 산업발전 심포지엄
END of Presentation 고병각(bgkoh@ktl. re. kr) 042 -939 -6001 9/9 자율주행 자동차 산업발전 심포지엄
- Slides: 9