
Introduction to Twin CAT 3 1 and Ether
- Slides: 36
Introduction to Twin. CAT 3. 1 and Ether. CAT in the context of VLT Instrumentation Control Systems D. Popovic, ESO/Do. E/CSE/ICSSW Instrument Control Systems Seminar 2014, 20 th-24 th October
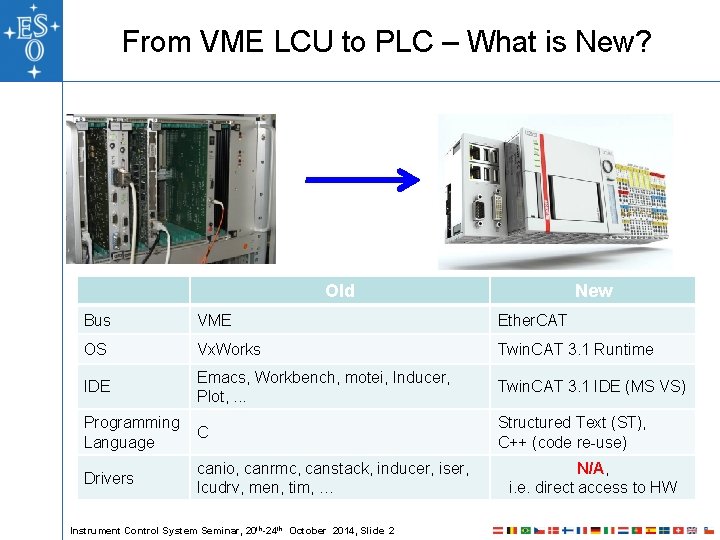
From VME LCU to PLC – What is New? Old New Bus VME Ether. CAT OS Vx. Works Twin. CAT 3. 1 Runtime IDE Emacs, Workbench, motei, Inducer, Plot, . . . Twin. CAT 3. 1 IDE (MS VS) Programming Language C Structured Text (ST), C++ (code re-use) Drivers canio, canrmc, canstack, inducer, iser, lcudrv, men, tim, … Instrument Control System Seminar, 20 th-24 th October 2014, Slide 2 N/A, i. e. direct access to HW
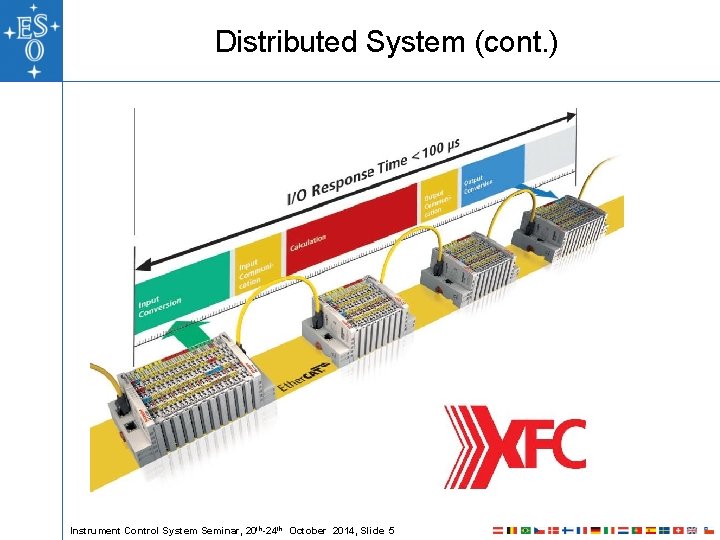
Ether. CAT Fieldbus • • Ethernet for Control Automation Technology Ethernet-based fieldbus system Ether. Type 0 x 88 A 4 Ether. CAT protocol optimized for process data Real-time capabilities - 1000 I/Os in 30 µs Flexible Topology Supports Distributed Clocks – IEEE 1588 Instrument Control System Seminar, 20 th-24 th October 2014, Slide 3
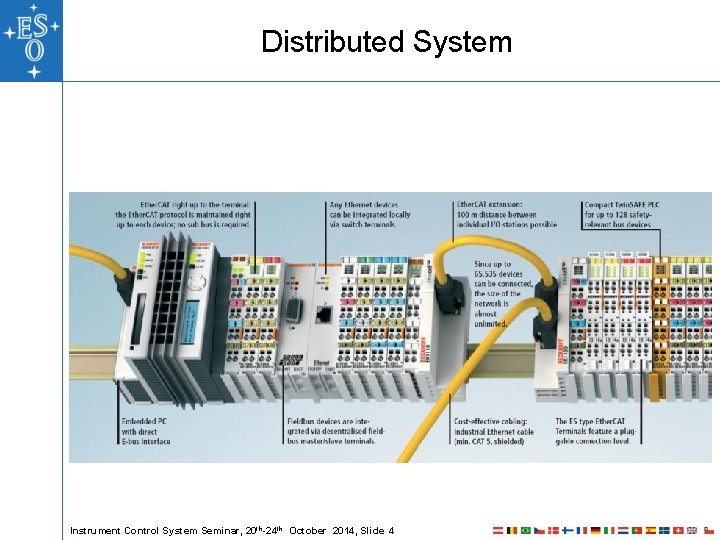
Distributed System Instrument Control System Seminar, 20 th-24 th October 2014, Slide 4
Distributed System (cont. ) Instrument Control System Seminar, 20 th-24 th October 2014, Slide 5
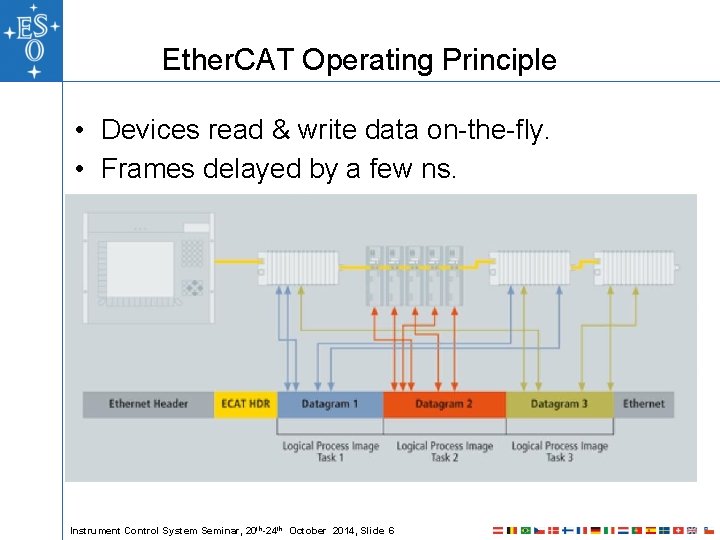
Ether. CAT Operating Principle • Devices read & write data on-the-fly. • Frames delayed by a few ns. Instrument Control System Seminar, 20 th-24 th October 2014, Slide 6
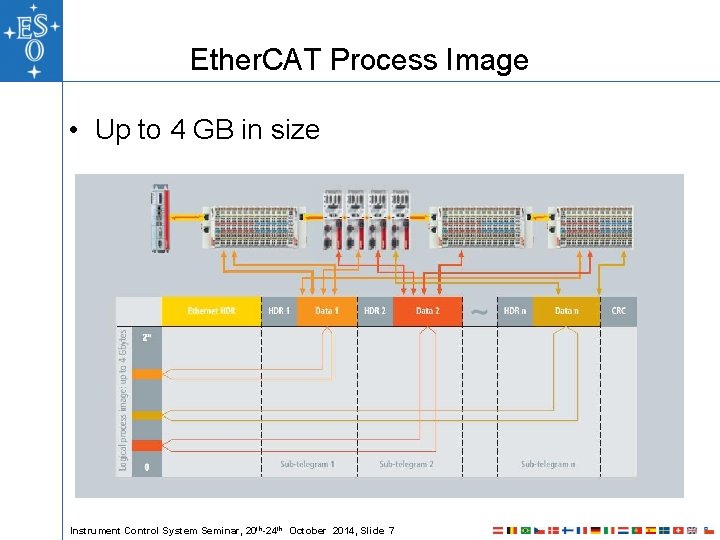
Ether. CAT Process Image • Up to 4 GB in size Instrument Control System Seminar, 20 th-24 th October 2014, Slide 7
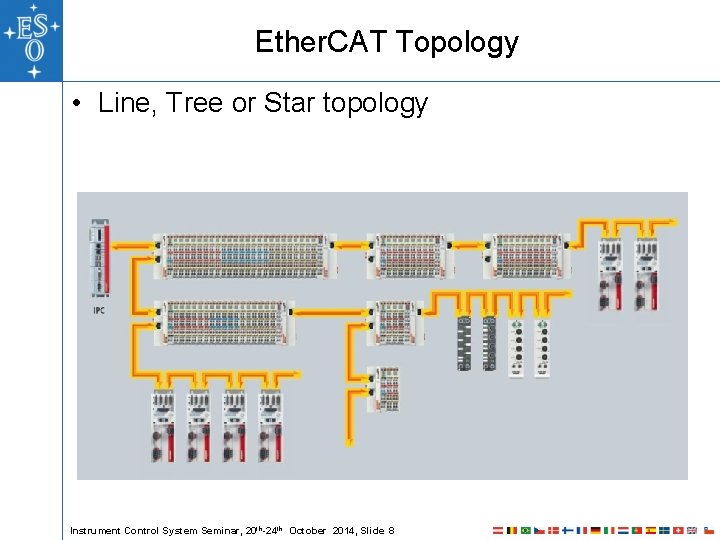
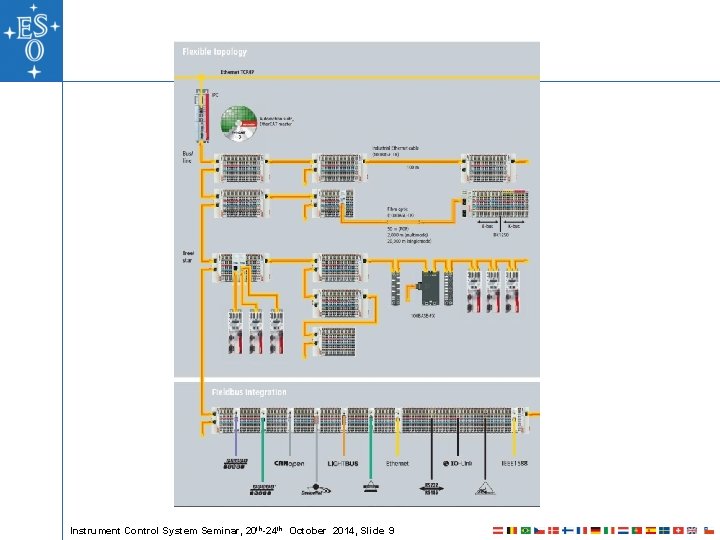
Ether. CAT Topology • Line, Tree or Star topology Instrument Control System Seminar, 20 th-24 th October 2014, Slide 8
Instrument Control System Seminar, 20 th-24 th October 2014, Slide 9
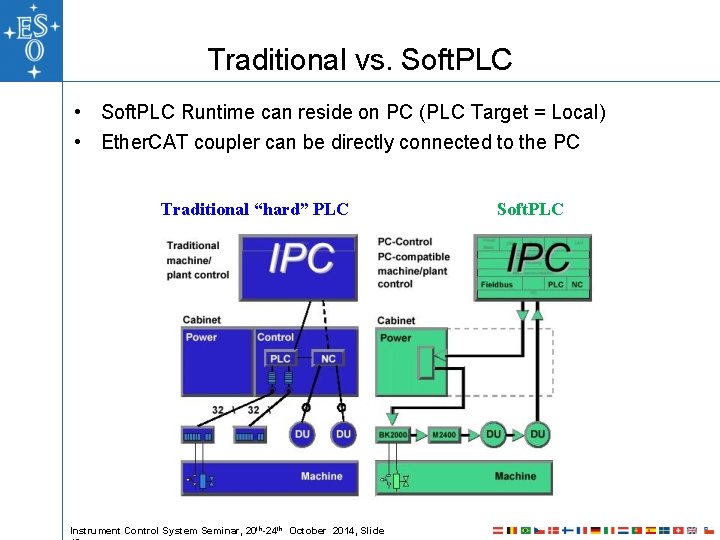
Traditional vs. Soft. PLC • Soft. PLC Runtime can reside on PC (PLC Target = Local) • Ether. CAT coupler can be directly connected to the PC Traditional “hard” PLC Instrument Control System Seminar, 20 th-24 th October 2014, Slide Soft. PLC
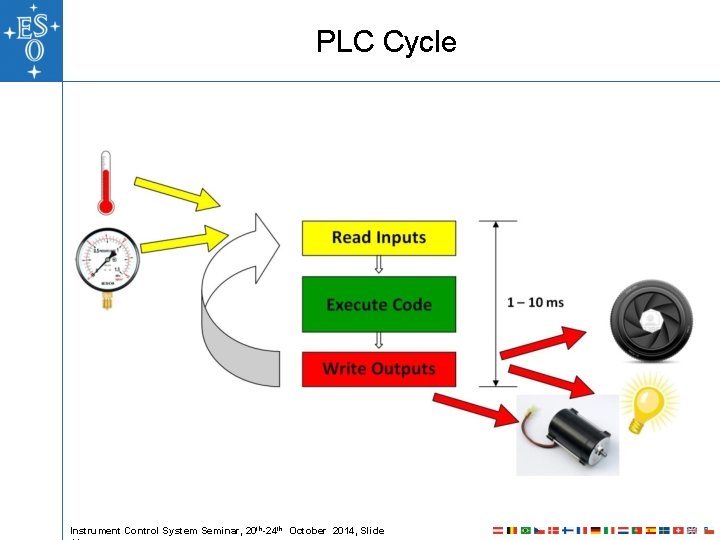
PLC Cycle Instrument Control System Seminar, 20 th-24 th October 2014, Slide
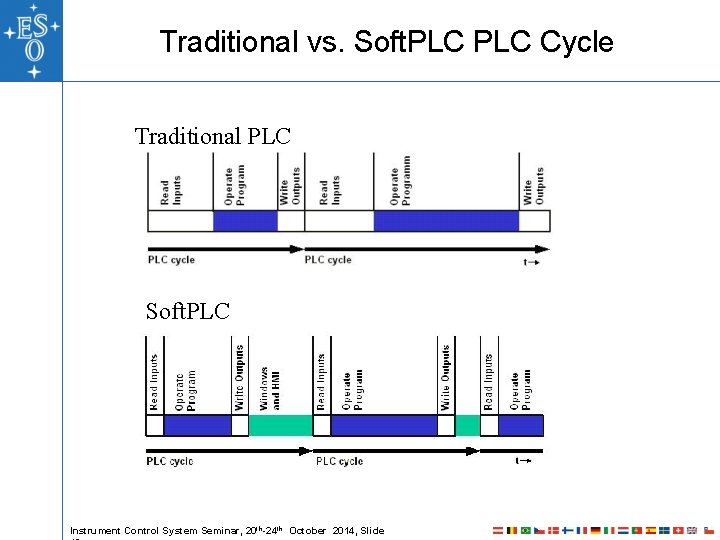
Traditional vs. Soft. PLC Cycle Traditional PLC Soft. PLC Instrument Control System Seminar, 20 th-24 th October 2014, Slide
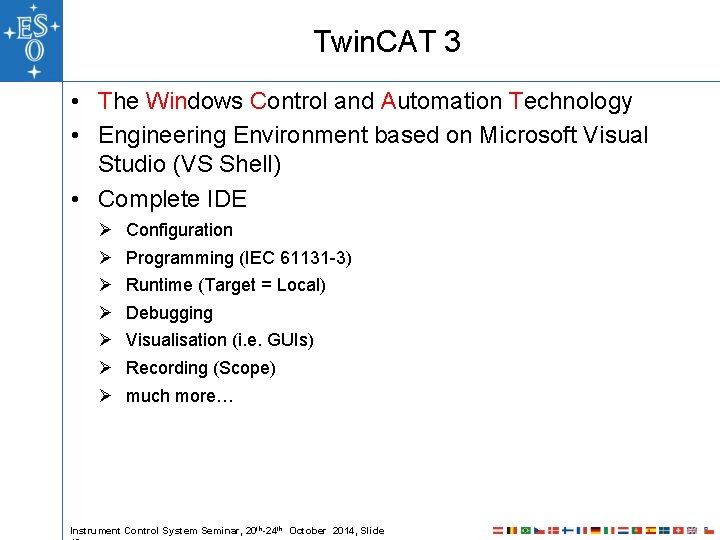
Twin. CAT 3 • The Windows Control and Automation Technology • Engineering Environment based on Microsoft Visual Studio (VS Shell) • Complete IDE Ø Ø Ø Ø Configuration Programming (IEC 61131 -3) Runtime (Target = Local) Debugging Visualisation (i. e. GUIs) Recording (Scope) much more… Instrument Control System Seminar, 20 th-24 th October 2014, Slide
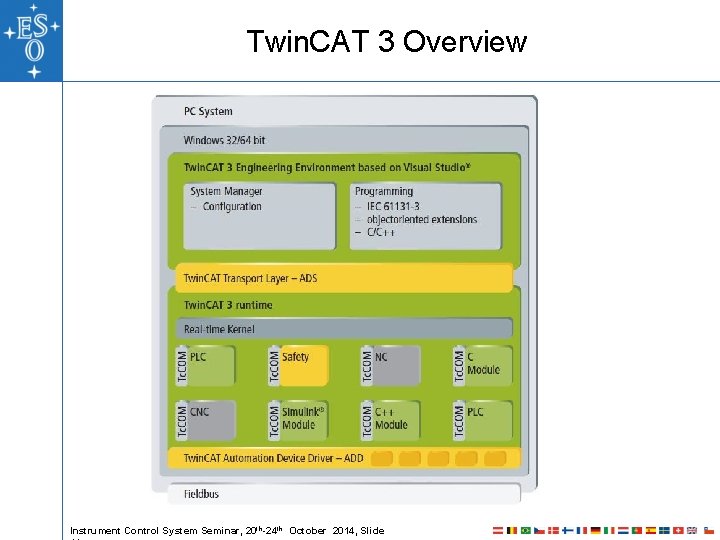
Twin. CAT 3 Overview Instrument Control System Seminar, 20 th-24 th October 2014, Slide
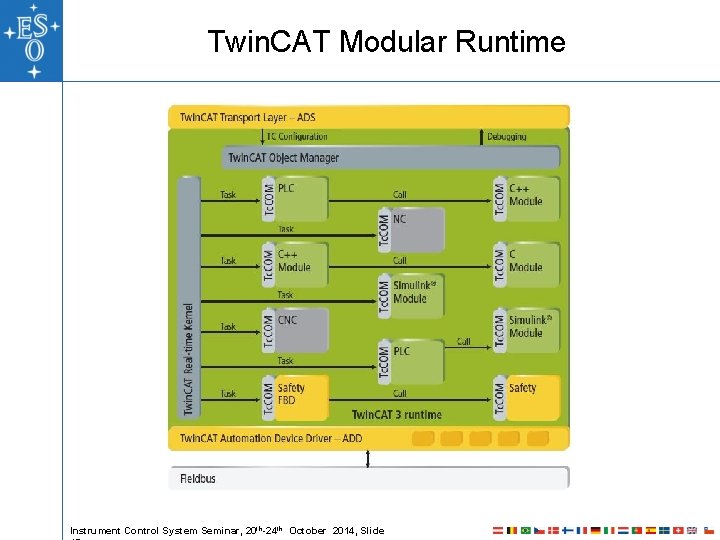
Twin. CAT Modular Runtime Instrument Control System Seminar, 20 th-24 th October 2014, Slide
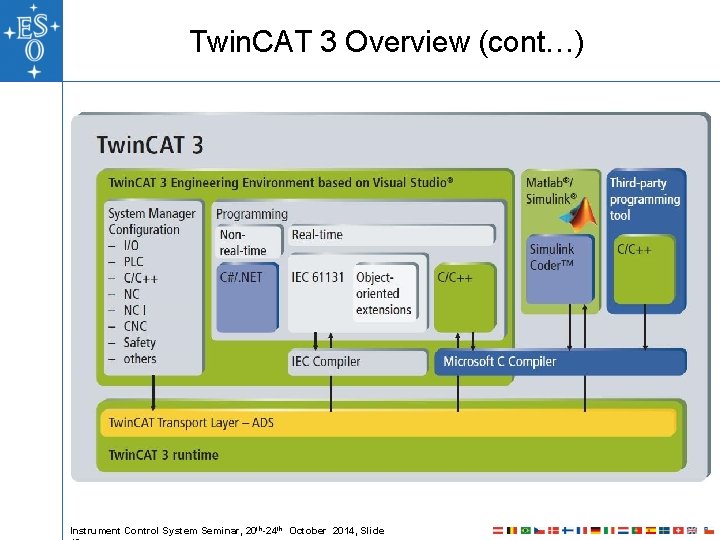
Twin. CAT 3 Overview (cont…) Instrument Control System Seminar, 20 th-24 th October 2014, Slide
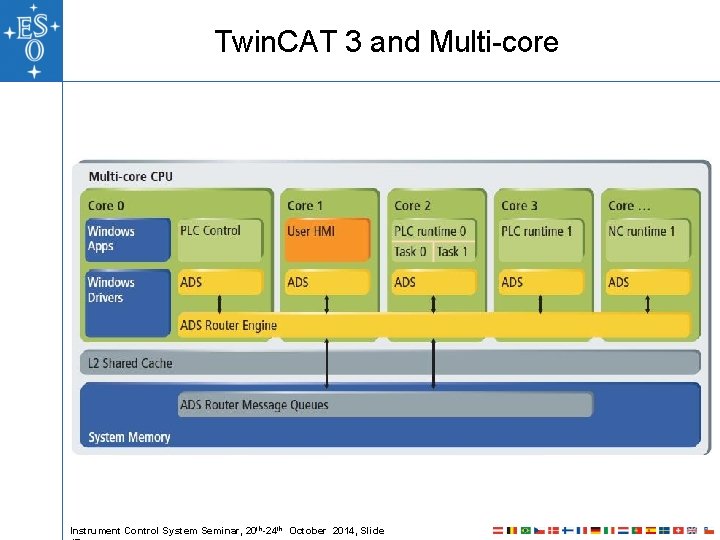
Twin. CAT 3 and Multi-core Instrument Control System Seminar, 20 th-24 th October 2014, Slide
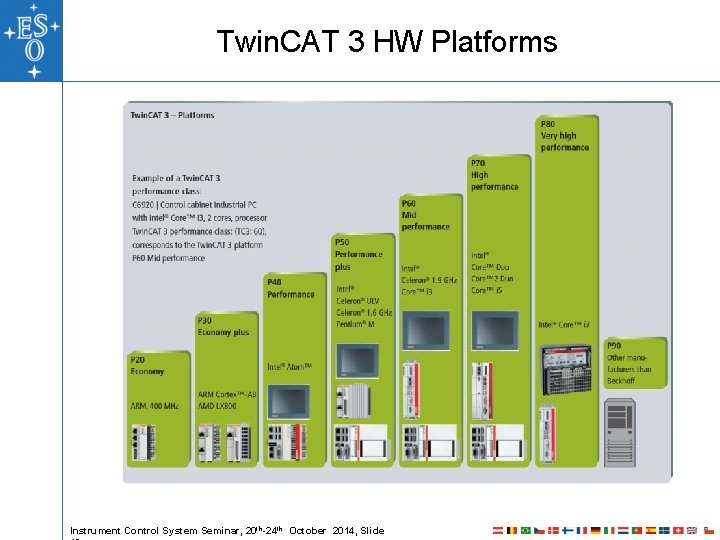
Twin. CAT 3 HW Platforms Instrument Control System Seminar, 20 th-24 th October 2014, Slide
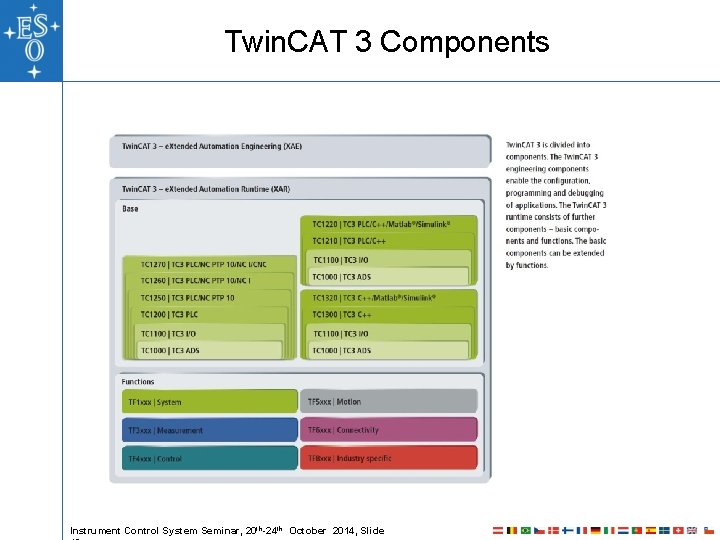
Twin. CAT 3 Components Instrument Control System Seminar, 20 th-24 th October 2014, Slide
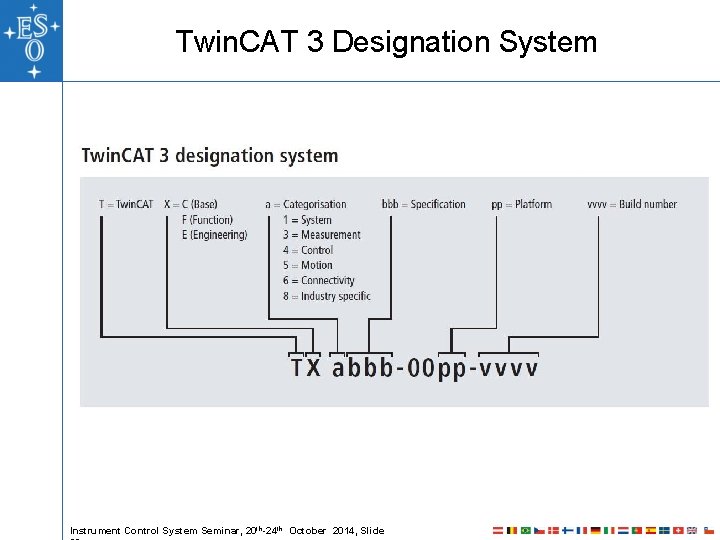
Twin. CAT 3 Designation System Instrument Control System Seminar, 20 th-24 th October 2014, Slide
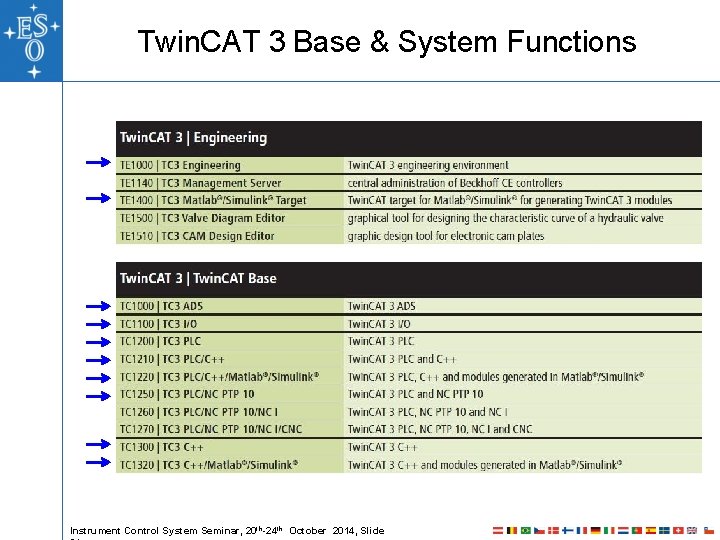
Twin. CAT 3 Base & System Functions Instrument Control System Seminar, 20 th-24 th October 2014, Slide
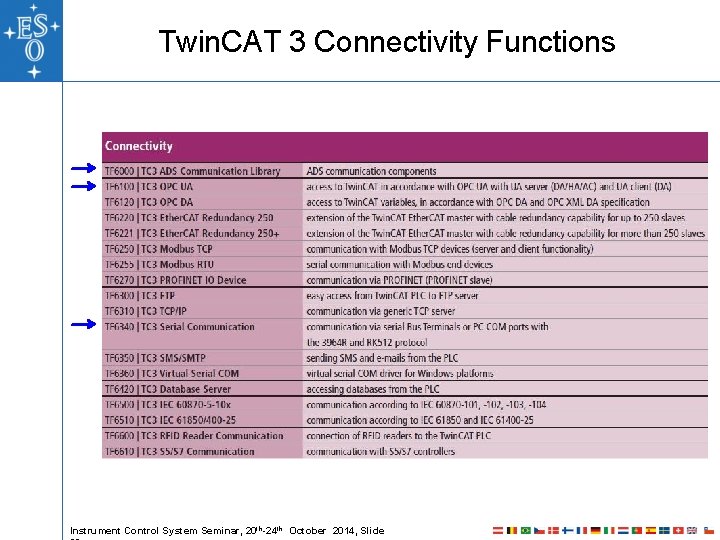
Twin. CAT 3 Connectivity Functions Instrument Control System Seminar, 20 th-24 th October 2014, Slide
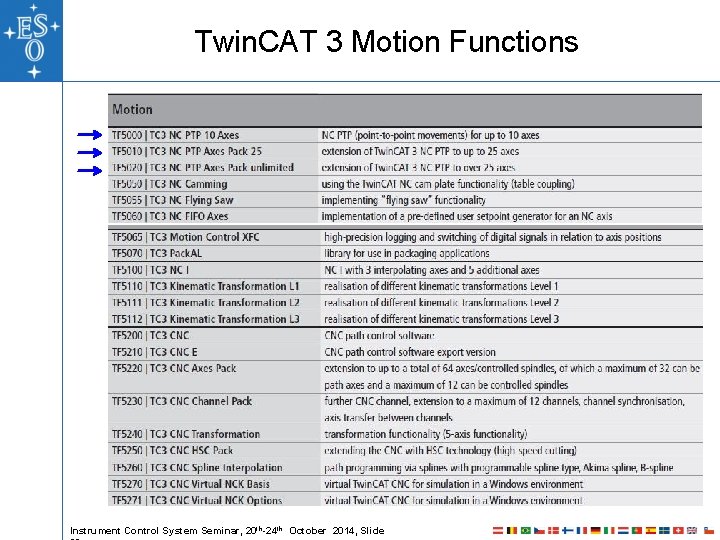
Twin. CAT 3 Motion Functions Instrument Control System Seminar, 20 th-24 th October 2014, Slide
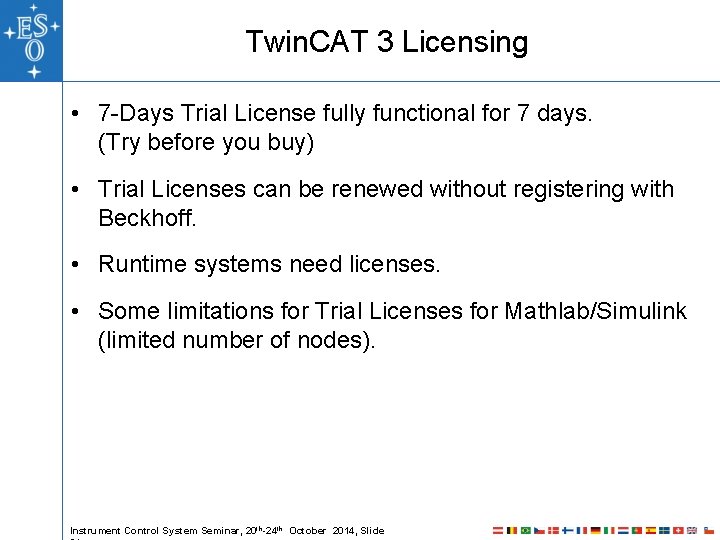
Twin. CAT 3 Licensing • 7 -Days Trial License fully functional for 7 days. (Try before you buy) • Trial Licenses can be renewed without registering with Beckhoff. • Runtime systems need licenses. • Some limitations for Trial Licenses for Mathlab/Simulink (limited number of nodes). Instrument Control System Seminar, 20 th-24 th October 2014, Slide
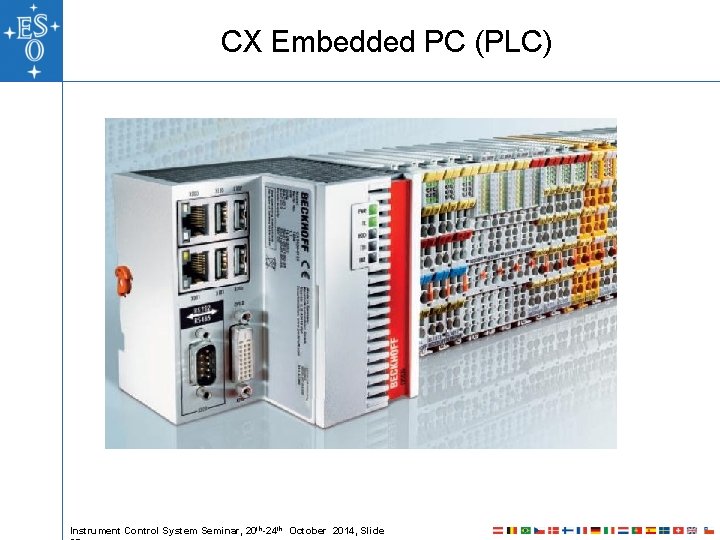
CX Embedded PC (PLC) Instrument Control System Seminar, 20 th-24 th October 2014, Slide
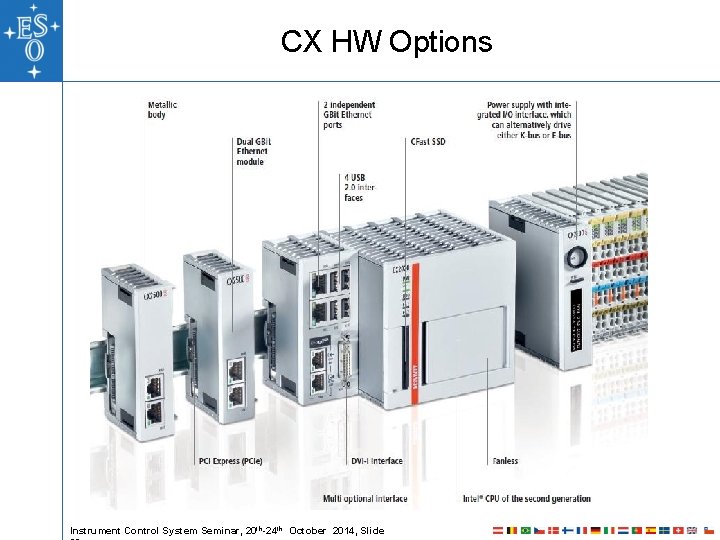
CX HW Options Instrument Control System Seminar, 20 th-24 th October 2014, Slide
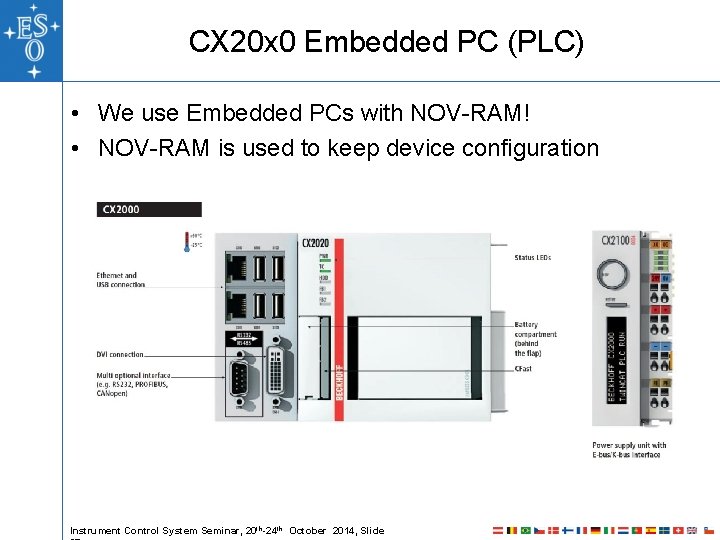
CX 20 x 0 Embedded PC (PLC) • We use Embedded PCs with NOV-RAM! • NOV-RAM is used to keep device configuration Instrument Control System Seminar, 20 th-24 th October 2014, Slide
HW Configuration Examples • Example 1 - I/O Control, - no Motion Control u u CX 2030 -0120 CPU (Cat. 60, Win 7 Embedded) (1500 EUR) CX 2100 -0004 Power Supply (195 EUR) TC 1200 -0060 TC 3 PLC (450 EUR) TF 6100 -0060 OPC UA Server License (160 EUR) Instrument Control System Seminar, 20 th-24 th October 2014, Slide
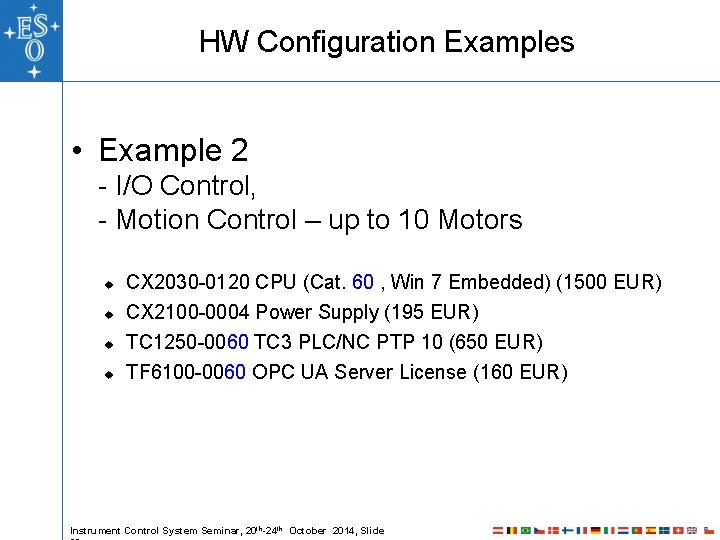
HW Configuration Examples • Example 2 - I/O Control, - Motion Control – up to 10 Motors u u CX 2030 -0120 CPU (Cat. 60 , Win 7 Embedded) (1500 EUR) CX 2100 -0004 Power Supply (195 EUR) TC 1250 -0060 TC 3 PLC/NC PTP 10 (650 EUR) TF 6100 -0060 OPC UA Server License (160 EUR) Instrument Control System Seminar, 20 th-24 th October 2014, Slide
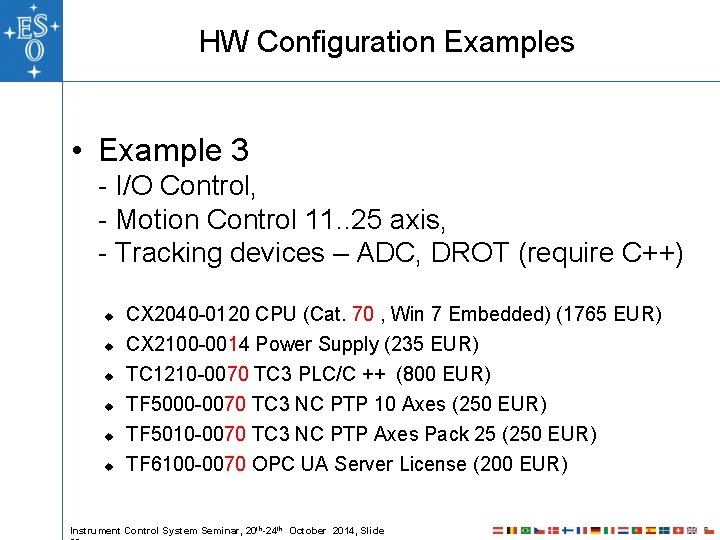
HW Configuration Examples • Example 3 - I/O Control, - Motion Control 11. . 25 axis, - Tracking devices – ADC, DROT (require C++) u u u CX 2040 -0120 CPU (Cat. 70 , Win 7 Embedded) (1765 EUR) CX 2100 -0014 Power Supply (235 EUR) TC 1210 -0070 TC 3 PLC/C ++ (800 EUR) TF 5000 -0070 TC 3 NC PTP 10 Axes (250 EUR) TF 5010 -0070 TC 3 NC PTP Axes Pack 25 (250 EUR) TF 6100 -0070 OPC UA Server License (200 EUR) Instrument Control System Seminar, 20 th-24 th October 2014, Slide
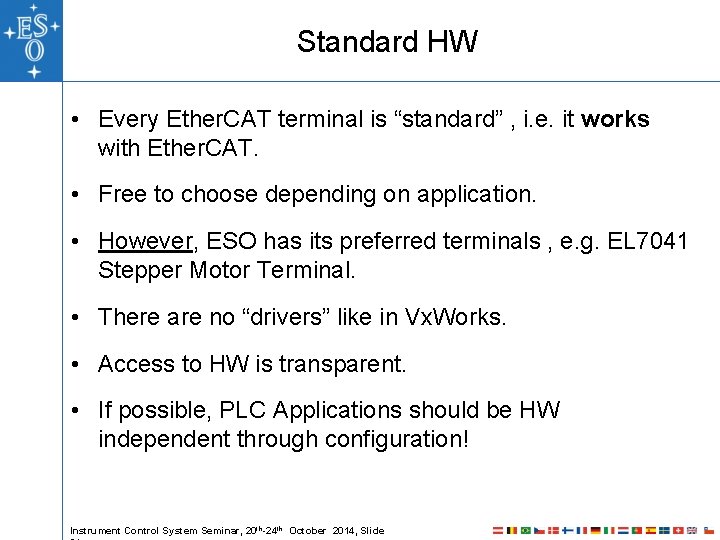
Standard HW • Every Ether. CAT terminal is “standard” , i. e. it works with Ether. CAT. • Free to choose depending on application. • However, ESO has its preferred terminals , e. g. EL 7041 Stepper Motor Terminal. • There are no “drivers” like in Vx. Works. • Access to HW is transparent. • If possible, PLC Applications should be HW independent through configuration! Instrument Control System Seminar, 20 th-24 th October 2014, Slide
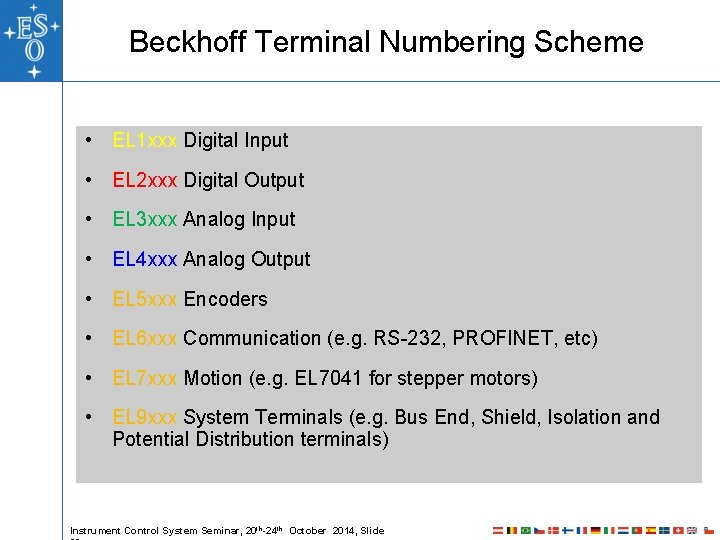
Beckhoff Terminal Numbering Scheme • EL 1 xxx Digital Input • EL 2 xxx Digital Output • EL 3 xxx Analog Input • EL 4 xxx Analog Output • EL 5 xxx Encoders • EL 6 xxx Communication (e. g. RS-232, PROFINET, etc) • EL 7 xxx Motion (e. g. EL 7041 for stepper motors) • EL 9 xxx System Terminals (e. g. Bus End, Shield, Isolation and Potential Distribution terminals) Instrument Control System Seminar, 20 th-24 th October 2014, Slide
ELxxxx vs ESxxxx Terminals • The only difference is in connectors. The terminals are electrically identical. • ELxxxx – Standard Terminals + - Easy to mount/dismount Might need to disconnect wires before mounting/dismounting • ESxxxx –Terminals with removable contacts + - No need to disconnect wires before mounting/dismounting Front face with contacts has to be removed before dismounting • ES is the preferred option, i. e. standard. Instrument Control System Seminar, 20 th-24 th October 2014, Slide
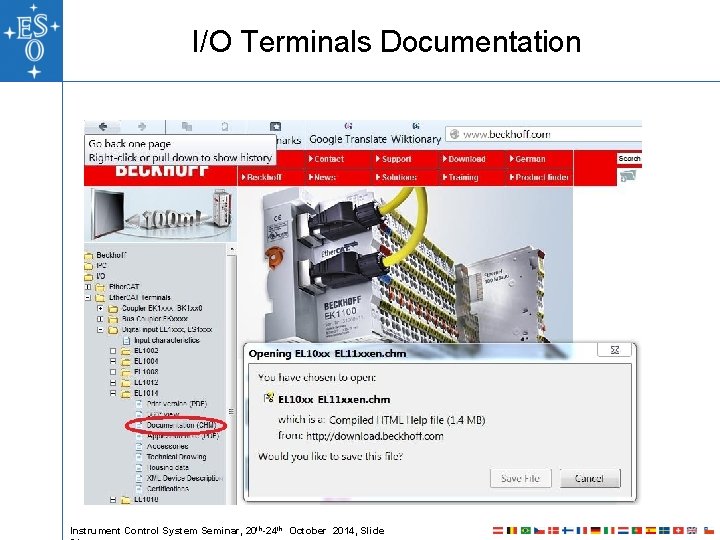
I/O Terminals Documentation Instrument Control System Seminar, 20 th-24 th October 2014, Slide
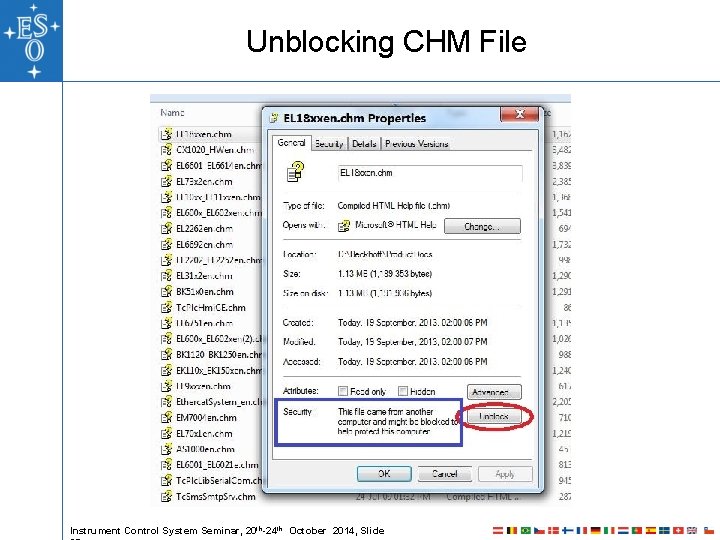
Unblocking CHM File Instrument Control System Seminar, 20 th-24 th October 2014, Slide
Questions ? Instrument Control System Seminar, 20 th-24 th October 2014, Slide