
Hydraulic Servo and Related Systems Chris Paredis Wayne
- Slides: 34
Hydraulic Servo and Related Systems Chris Paredis / Wayne J. Book G. W. Woodruff School of Mechanical Engineering Georgia Institute of Technology
Lecture Overview • • • Why fluid power? Basic fluid-power circuits Simple dynamic model Efficiency considerations Advanced metering methods
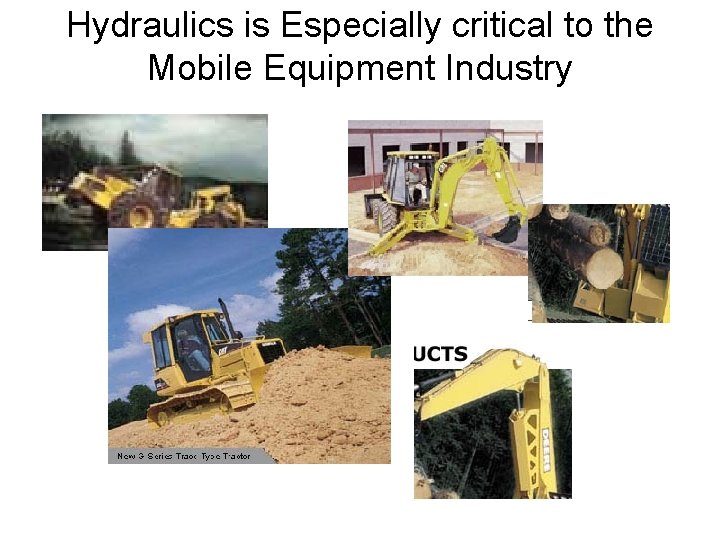
Hydraulics is Especially critical to the Mobile Equipment Industry
The Strengths of Fluid Power (Hydraulic, to a lesser extent pneumatic) • High force at moderate speed • High power density at point of action – Fluid removes waste heat – Prime mover is removed from point of action – Conditioned power can be routed in flexible a fashion • Potentially “Stiff” position control • Controllable either electrically or manually – Resulting high bandwidth motion control at high forces • NO SUBSTITUTE FOR MANY HEAVY APPLICATIONS
Difficulties with Fluid Power • Possible leakage • Noise generated by pumps and transmitted by lines • Energy loss due to fluid flows • Expensive in some applications • Susceptibility of working fluid to contamination • Lack of understanding of recently graduated practicing engineers – Multidisciplinary – Cost of laboratories – Displaced in curriculum by more recent technologies
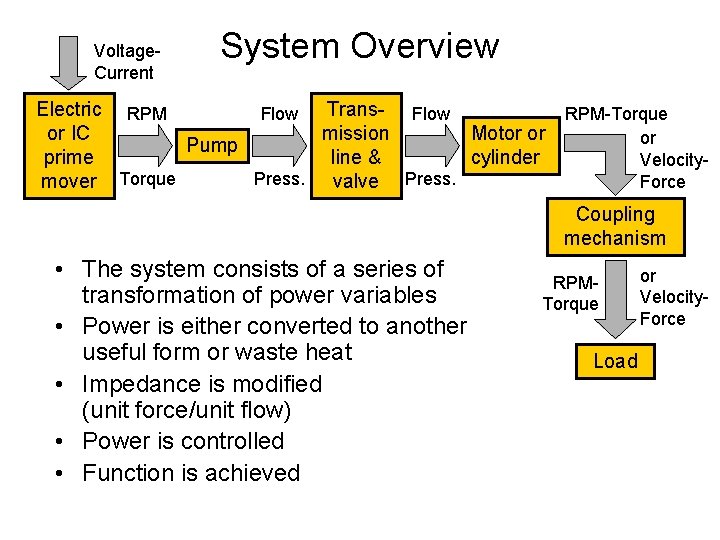
Voltage. Current System Overview Electric RPM Trans- Flow RPM-Torque or IC mission Motor or or Pump cylinder prime line & Velocity. Press. Force mover Torque valve Press. Coupling mechanism • The system consists of a series of transformation of power variables • Power is either converted to another useful form or waste heat • Impedance is modified (unit force/unit flow) • Power is controlled • Function is achieved RPMTorque Load or Velocity. Force
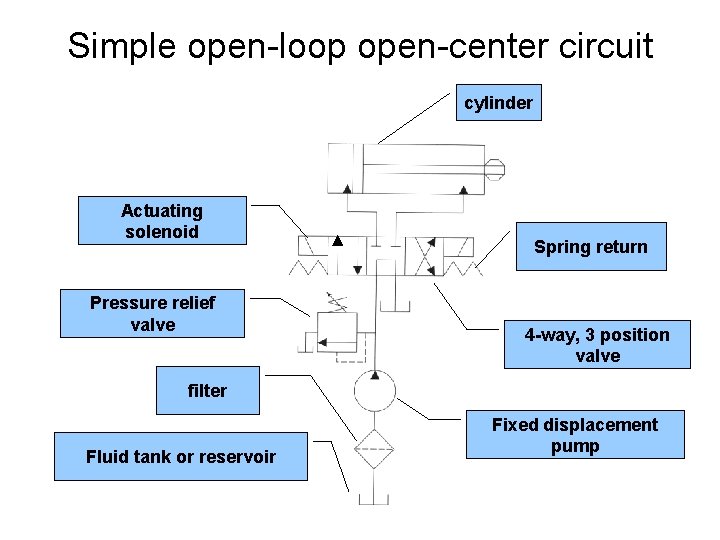
Simple open-loop open-center circuit cylinder Actuating solenoid Pressure relief valve Spring return 4 -way, 3 position valve filter Fluid tank or reservoir Fixed displacement pump
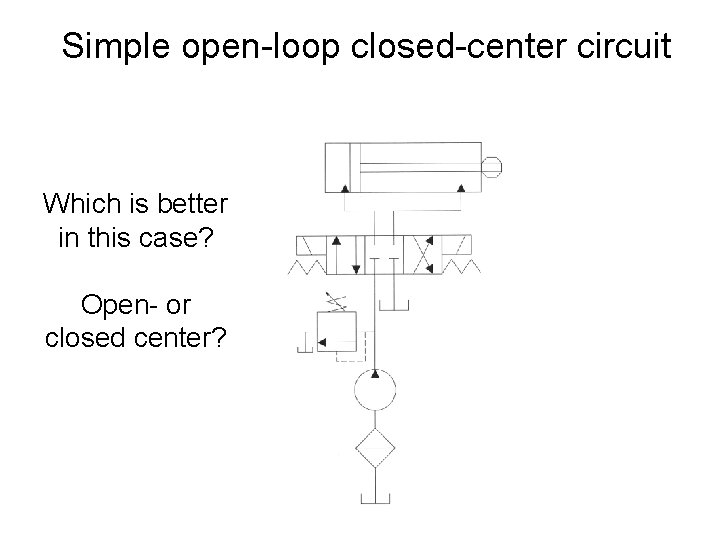
Simple open-loop closed-center circuit Which is better in this case? Open- or closed center?
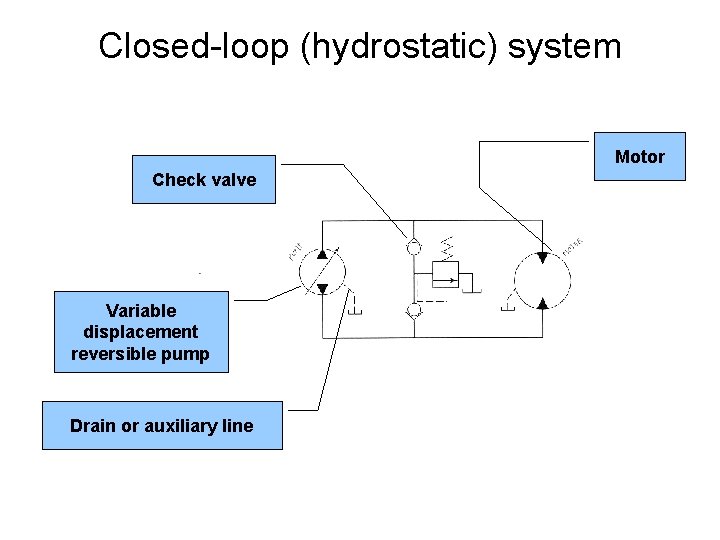
Closed-loop (hydrostatic) system Motor Check valve Variable displacement reversible pump Drain or auxiliary line
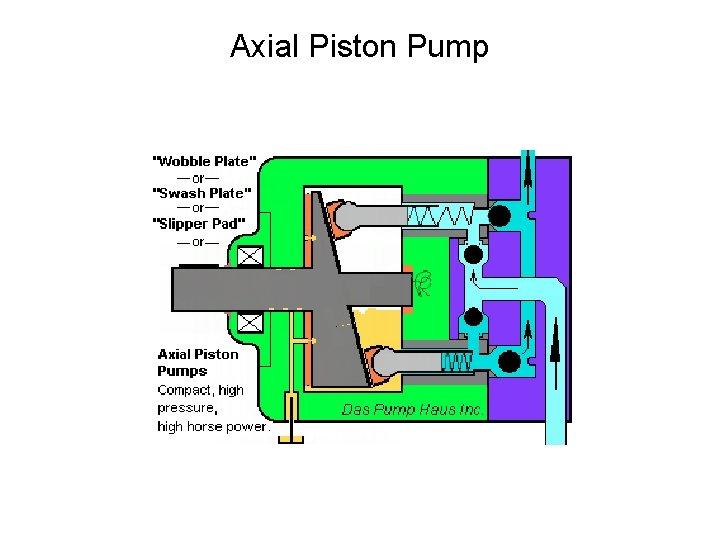
Axial Piston Pump
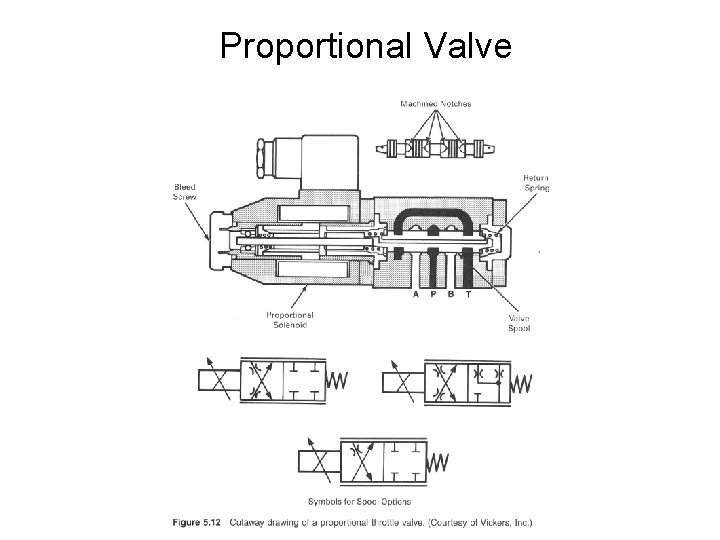
Proportional Valve
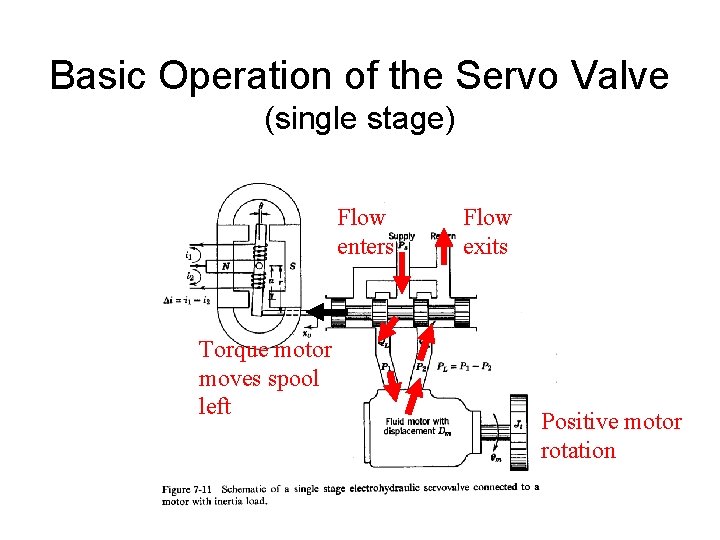
Basic Operation of the Servo Valve (single stage) Flow enters Torque motor moves spool left Flow exits Positive motor rotation
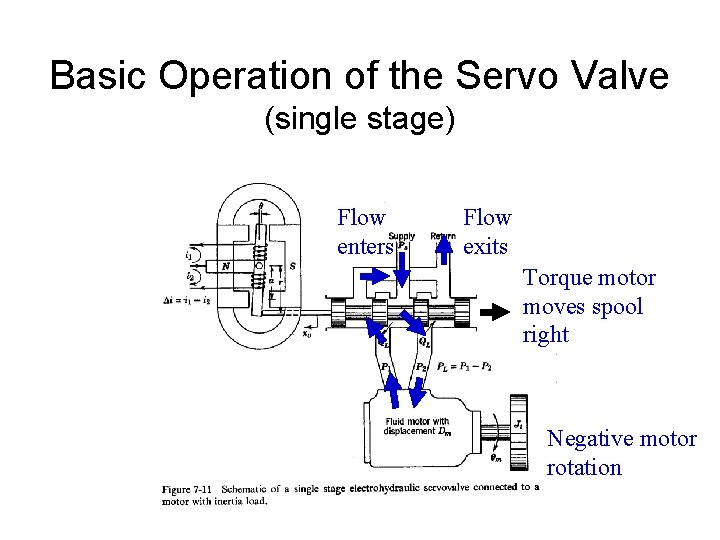
Basic Operation of the Servo Valve (single stage) Flow enters Flow exits Torque motor moves spool right Negative motor rotation
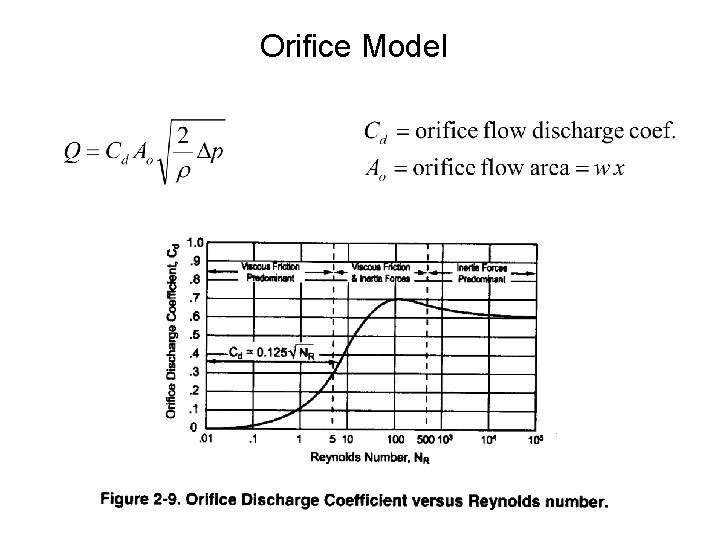
Orifice Model
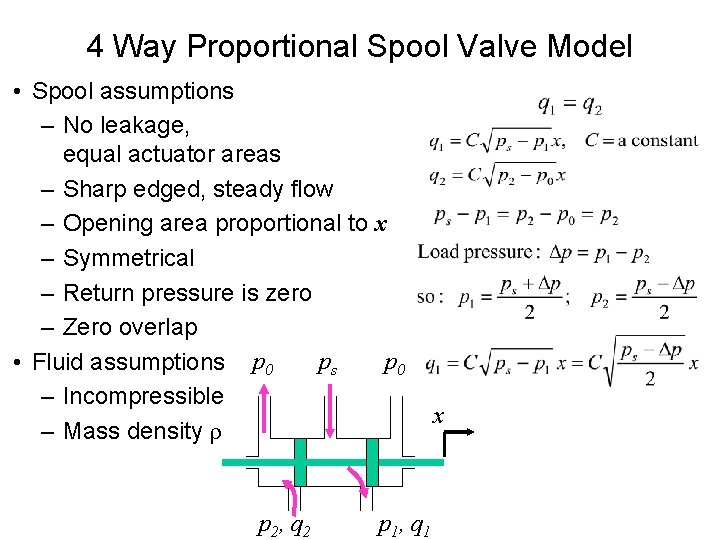
4 Way Proportional Spool Valve Model • Spool assumptions – No leakage, equal actuator areas – Sharp edged, steady flow – Opening area proportional to x – Symmetrical – Return pressure is zero – Zero overlap ps p 0 • Fluid assumptions p 0 – Incompressible – Mass density p 2, q 2 p 1, q 1 x
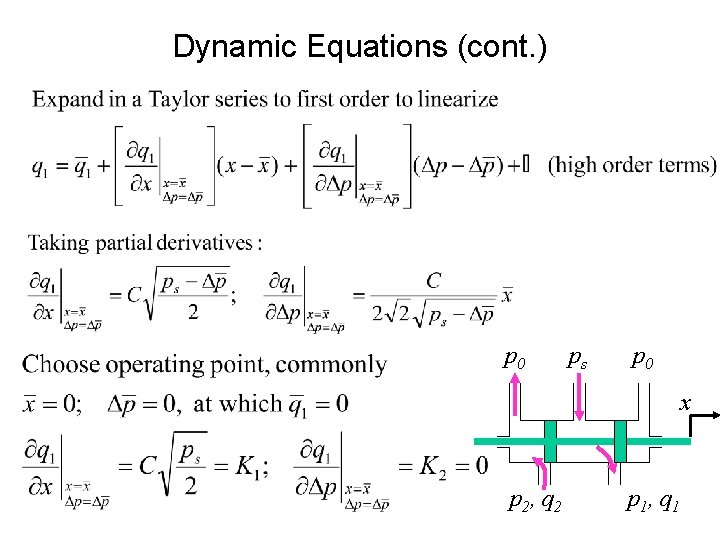
Dynamic Equations (cont. ) p 0 ps p 0 x p 2, q 2 p 1, q 1
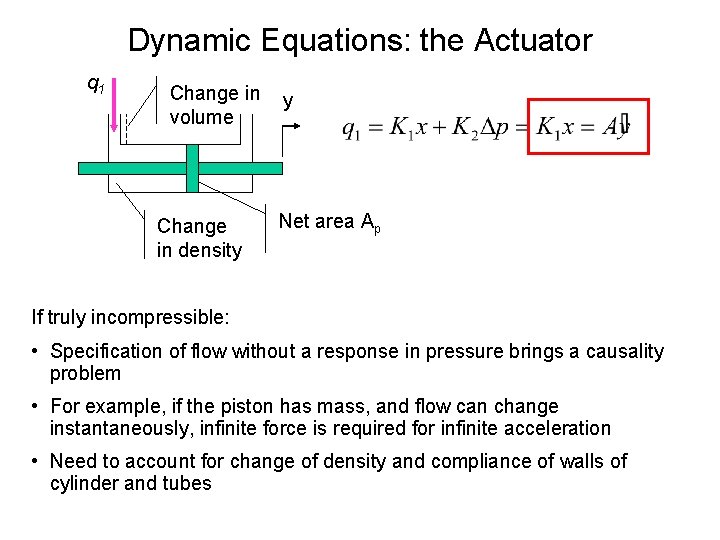
Dynamic Equations: the Actuator q 1 Change in volume Change in density y Net area Ap If truly incompressible: • Specification of flow without a response in pressure brings a causality problem • For example, if the piston has mass, and flow can change instantaneously, infinite force is required for infinite acceleration • Need to account for change of density and compliance of walls of cylinder and tubes
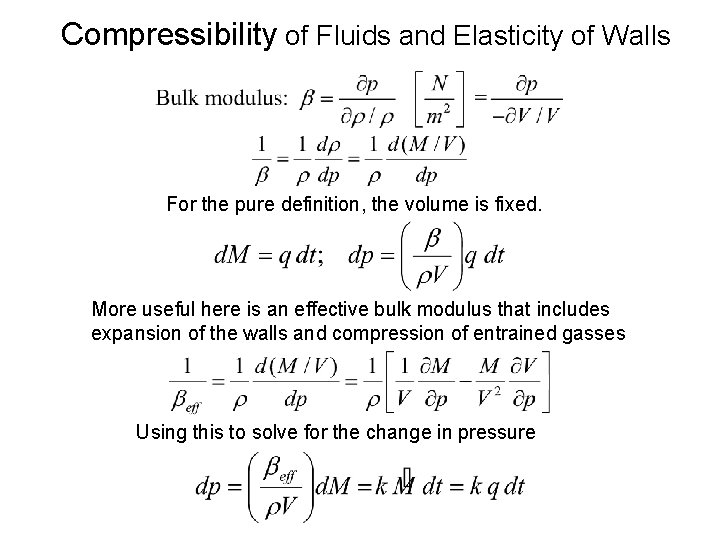
Compressibility of Fluids and Elasticity of Walls For the pure definition, the volume is fixed. More useful here is an effective bulk modulus that includes expansion of the walls and compression of entrained gasses Using this to solve for the change in pressure
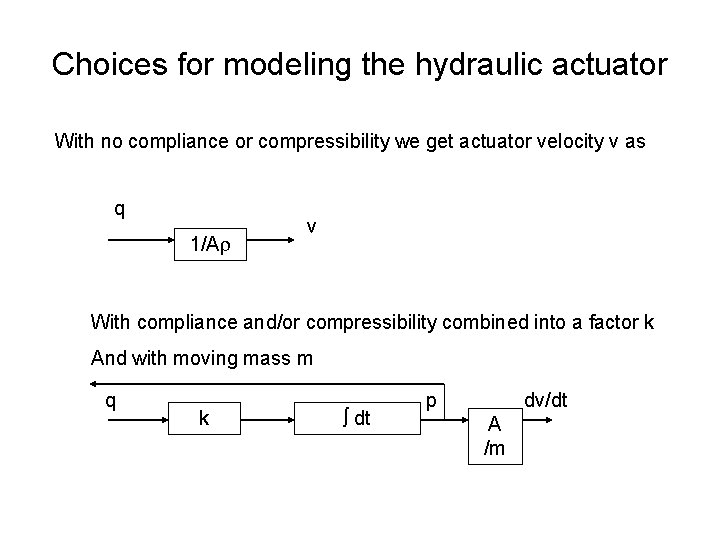
Choices for modeling the hydraulic actuator With no compliance or compressibility we get actuator velocity v as q 1/A v With compliance and/or compressibility combined into a factor k And with moving mass m q k dt p dv/dt A /m
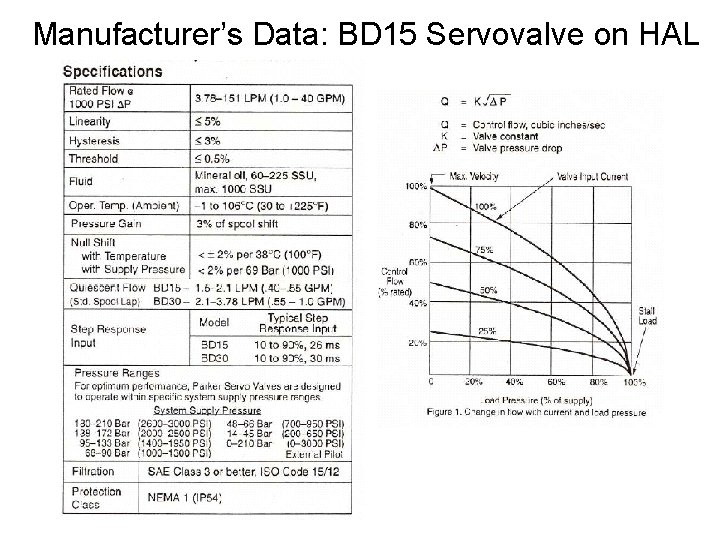
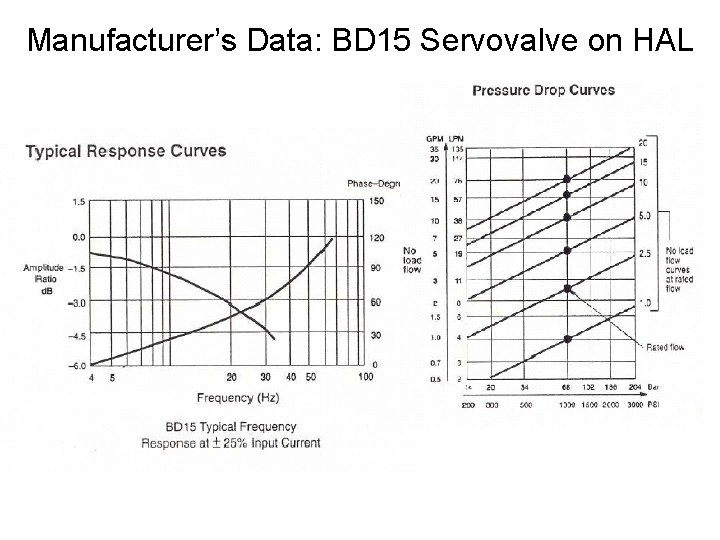
Manufacturer’s Data: BD 15 Servovalve on HAL
Manufacturer’s Data: BD 15 Servovalve on HAL
Controls Issues: Summary • Nonlinearities • Good velocity control – Velocity approximately proportional to valve position – Bandwidth determined by compressibility and spool dynamics • How about position control? • How about force control?
Lecture Overview • • • Why fluid power? Basic fluid-power circuits Simple dynamic model Efficiency considerations Advanced metering methods
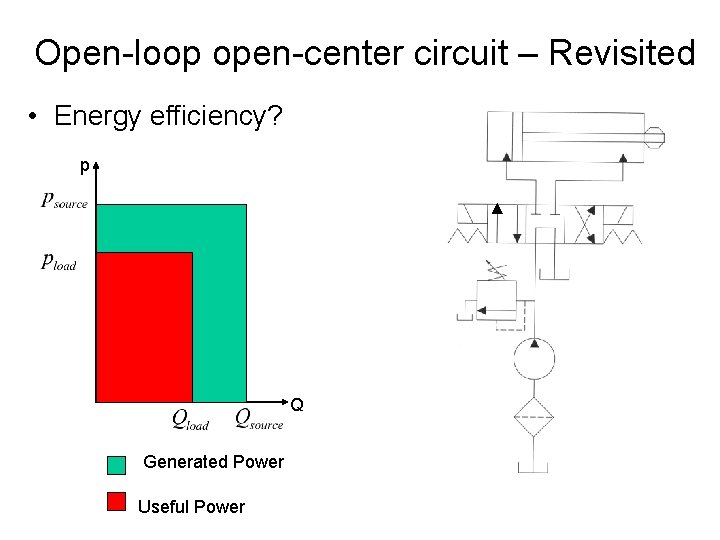
Open-loop open-center circuit – Revisited • Energy efficiency? p Q Generated Power Useful Power
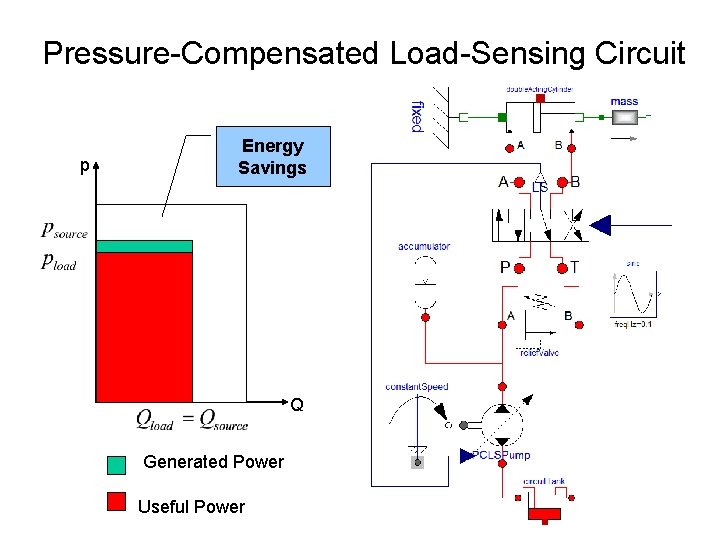
Pressure-Compensated Load-Sensing Circuit p Energy Savings Q Generated Power Useful Power
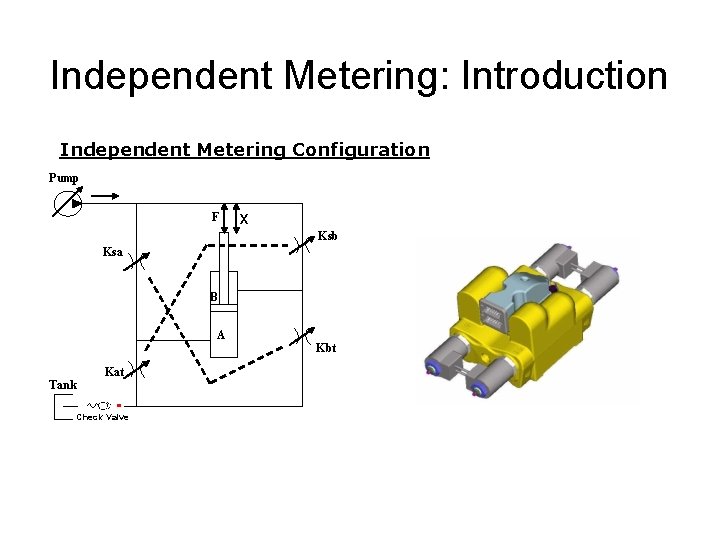
Independent Metering: Introduction Independent Metering Configuration Pump F x Ksb Ksa B A Tank Kat Check Valve Kbt
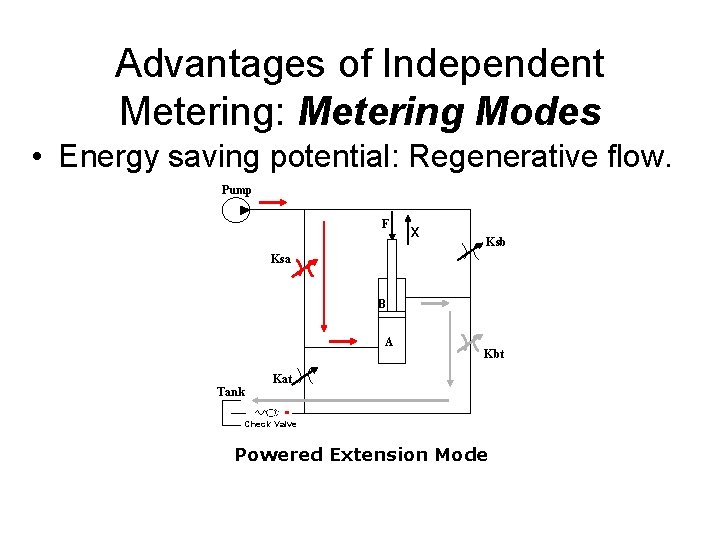
Advantages of Independent Metering: Metering Modes • Energy saving potential: Regenerative flow. Pump F x Ksb Ksa B A Tank Kbt Kat Check Valve Powered Extension Mode
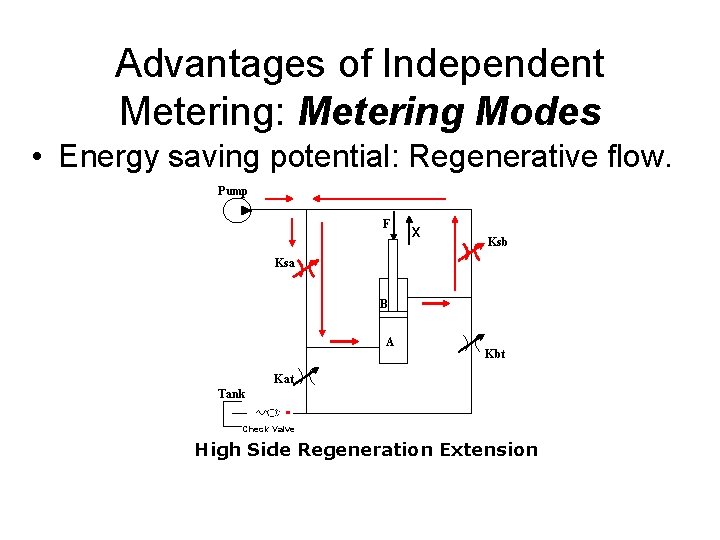
Advantages of Independent Metering: Metering Modes • Energy saving potential: Regenerative flow. Pump F x Ksb Ksa B A Kbt Kat Tank Check Valve High Side Regeneration Extension
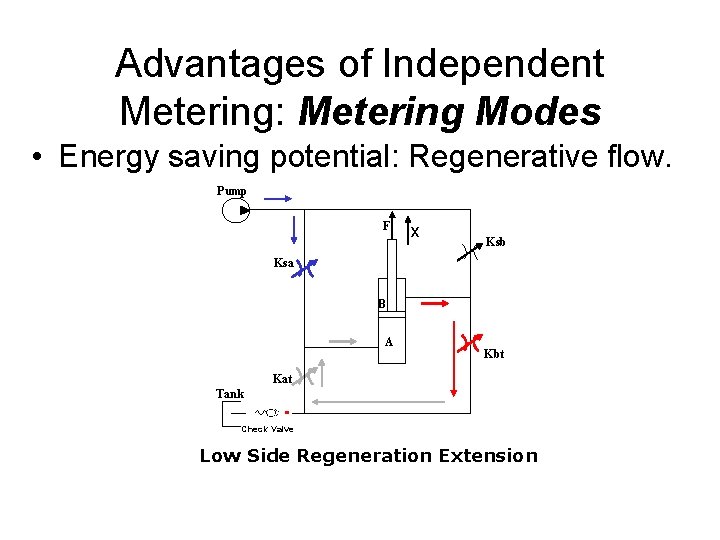
Advantages of Independent Metering: Metering Modes • Energy saving potential: Regenerative flow. Pump F x Ksb Ksa B A Kbt Kat Tank Check Valve Low Side Regeneration Extension
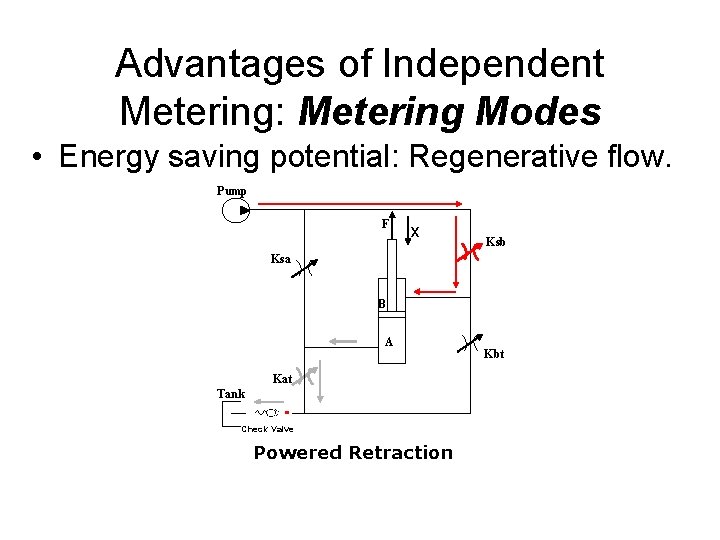
Advantages of Independent Metering: Metering Modes • Energy saving potential: Regenerative flow. Pump F x Ksb Ksa B A Kat Tank Check Valve Powered Retraction Kbt
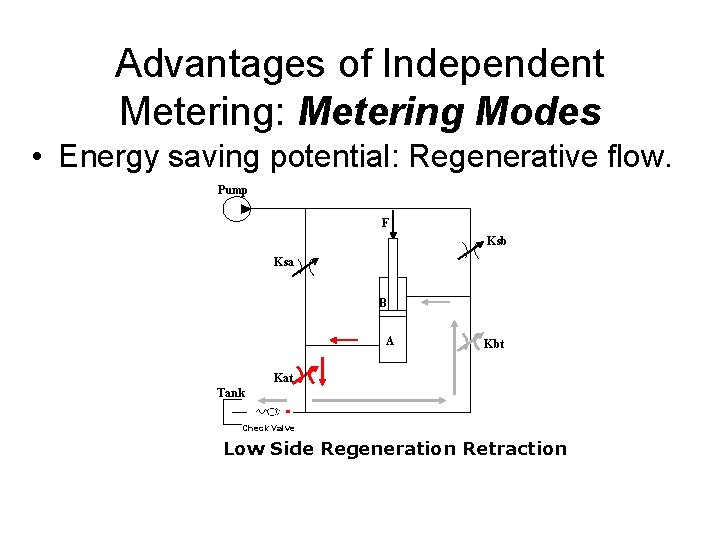
Advantages of Independent Metering: Metering Modes • Energy saving potential: Regenerative flow. Pump F Ksb Ksa B A Kbt Kat Tank Check Valve Low Side Regeneration Retraction
Advantages of Independent Metering: Metering Modes • Energy saving potential: Regenerative flow. Regeneration flow can be defined as pumping the fluid from one chamber to the other to achieve motion control of the load with using no or minimum flow from the pump.
Summary • Main advantage of fluid power: – Very high forces/torques at moderate speed – Very high power density at point of action • Challenges: – Energy efficiency – hot research topic – Compactness (including prime mover) – User friendliness (leakage, noise, etc. )
References 1. Norvelle, F. D. Fluid Power Control Systems, Prentice Hall, 2000. 2. Fitch, E. C. and Hong I. T. Hydraulic Component Design and Selection, Bar. Dyne, Stillwater, OK, 2001. 3. Cundiff, J. S. Fluid Power Circuits and Controls, CRC Press, Boca Raton, FL, 2002. 4. Merritt, H. E. Hydraulic Control Systems, John Wiley and Sons, New York, 1967. 5. Fluid Power Design Engineers Handbook, Parker Hannifin Company (various editions).