
Honeywell Navigation Communication and Control SAE GC Committee
- Slides: 4
Honeywell Navigation, Communication and Control SAE G&C Committee Meeting Oct 19, 2005 sanjay. parthasarathy@honeywell. com
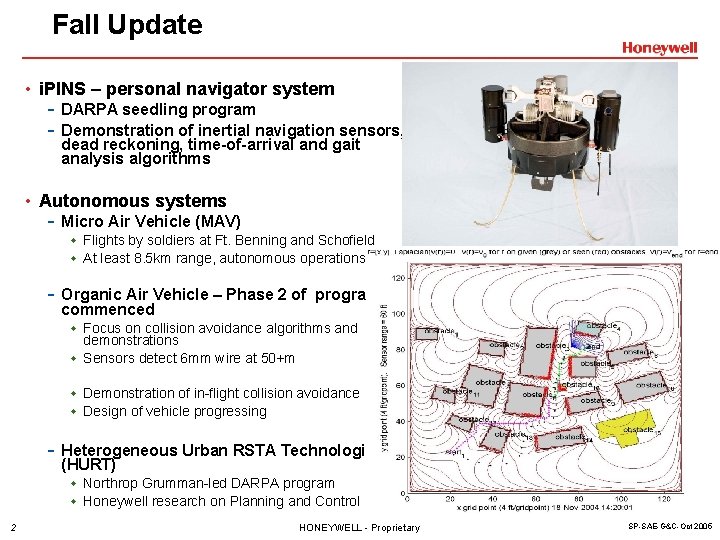
Fall Update • i. PINS – personal navigator system - DARPA seedling program - Demonstration of inertial navigation sensors, dead reckoning, time-of-arrival and gait analysis algorithms • Autonomous systems - Micro Air Vehicle (MAV) w Flights by soldiers at Ft. Benning and Schofield w At least 8. 5 km range, autonomous operations - Organic Air Vehicle – Phase 2 of program commenced w Focus on collision avoidance algorithms and demonstrations w Sensors detect 6 mm wire at 50+m w Demonstration of in-flight collision avoidance w Design of vehicle progressing - Heterogeneous Urban RSTA Technologies (HURT) w Northrop Grumman-led DARPA program w Honeywell research on Planning and Control 2 HONEYWELL - Proprietary SP-SAE-G&C-Oct 2005
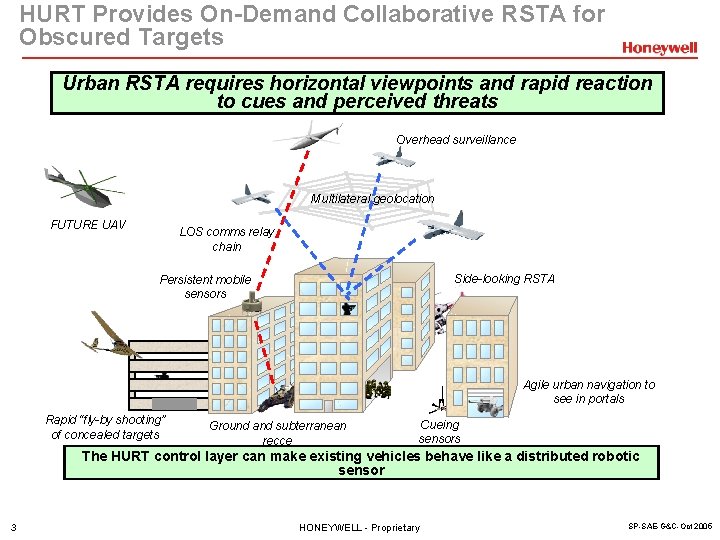
HURT Provides On-Demand Collaborative RSTA for Obscured Targets Urban RSTA requires horizontal viewpoints and rapid reaction to cues and perceived threats Overhead surveillance Multilateral geolocation FUTURE UAV LOS comms relay chain Side-looking RSTA Persistent mobile sensors Agile urban navigation to see in portals Rapid “fly-by shooting” of concealed targets Ground and subterranean recce Cueing sensors The HURT control layer can make existing vehicles behave like a distributed robotic sensor 3 HONEYWELL - Proprietary SP-SAE-G&C-Oct 2005
Demonstration results • Sept 22, 2005 at Victorville, CA • 4 small UAVs - 2 pointers - 1 raven - 1 Yamaha R-Max • Honeywell – provided vehicle tracking and surveillance algorithms, integrated into the HURT ground control station • The HURT system autonomously prioritized each request and directed the most suitable UAV to the location for a closer look while maintaining continuous broad-area surveillance by the other UAVs. 4 HONEYWELL - Proprietary SP-SAE-G&C-Oct 2005