
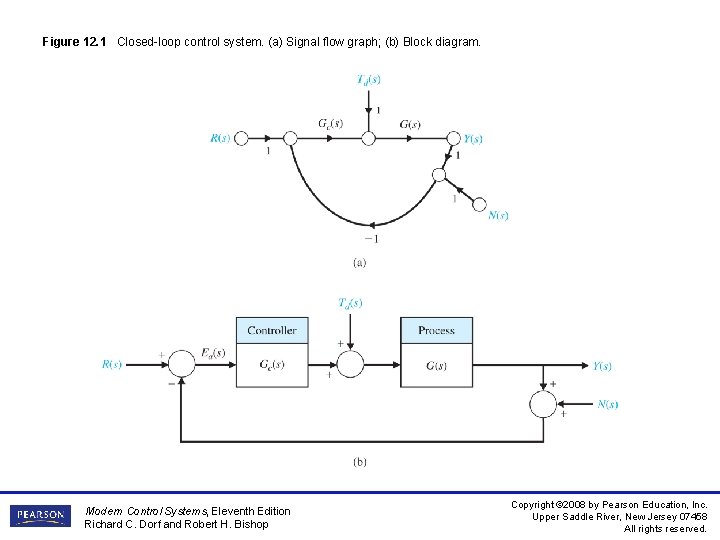
Figure 12 1 Closedloop control system a Signal
- Slides: 92
Figure 12. 1 Closed-loop control system. (a) Signal flow graph; (b) Block diagram. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
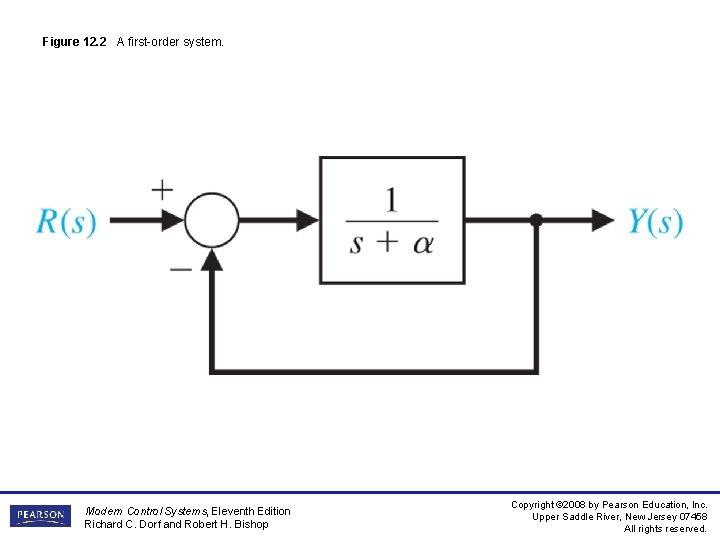
Figure 12. 2 A first-order system. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
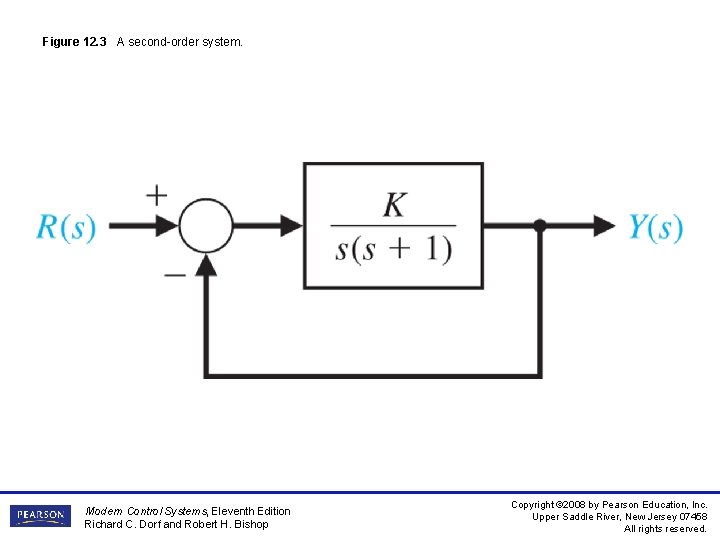
Figure 12. 3 A second-order system. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
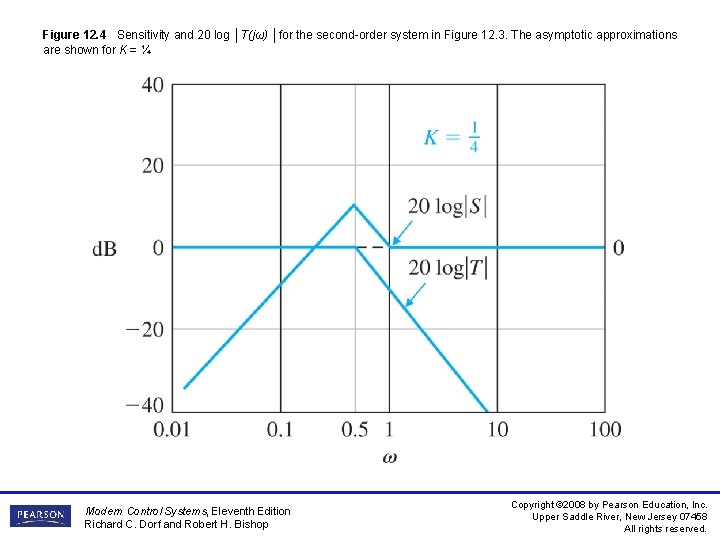
Figure 12. 4 Sensitivity and 20 log │T(jω) │for the second-order system in Figure 12. 3. The asymptotic approximations are shown for K = ¼ Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
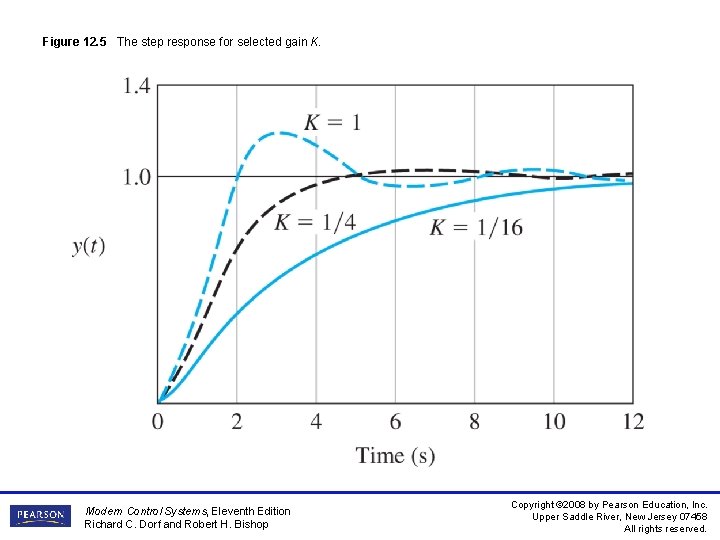
Figure 12. 5 The step response for selected gain K. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
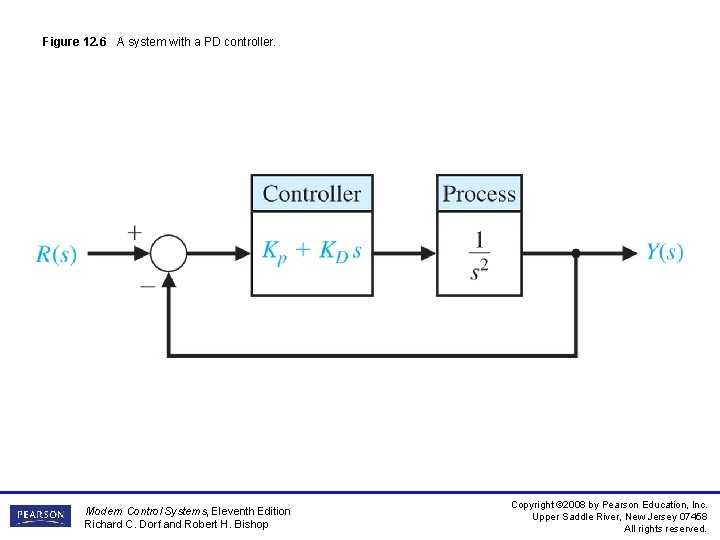
Figure 12. 6 A system with a PD controller. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
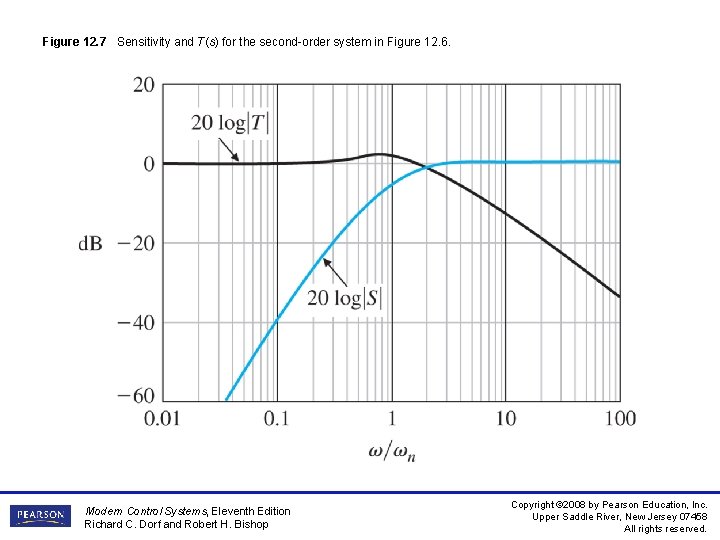
Figure 12. 7 Sensitivity and T(s) for the second-order system in Figure 12. 6. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
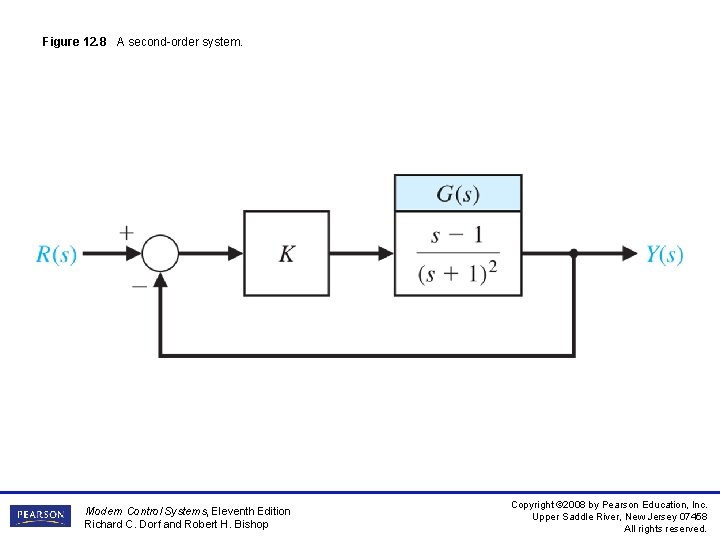
Figure 12. 8 A second-order system. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
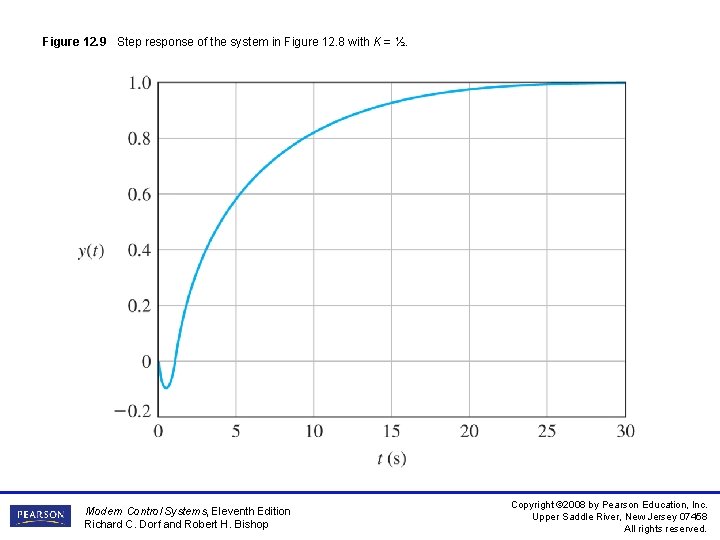
Figure 12. 9 Step response of the system in Figure 12. 8 with K = ½. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
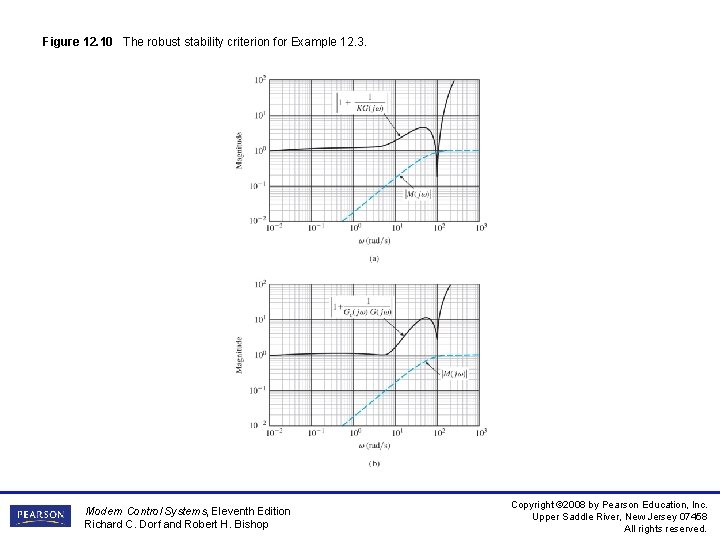
Figure 12. 10 The robust stability criterion for Example 12. 3. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
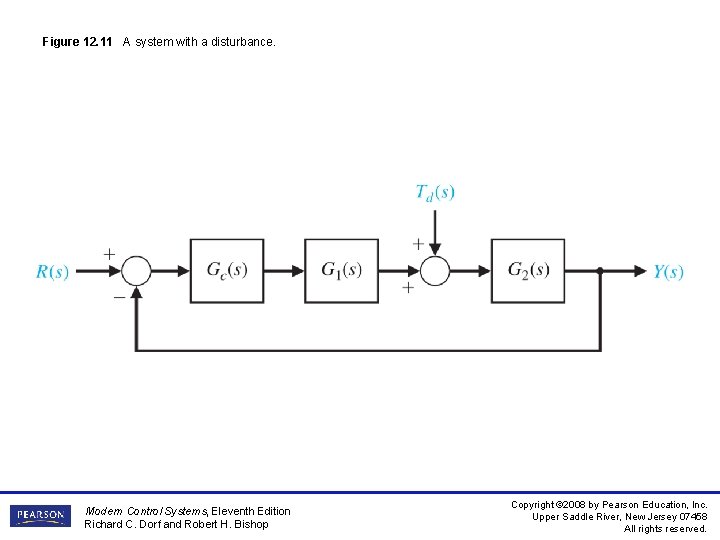
Figure 12. 11 A system with a disturbance. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
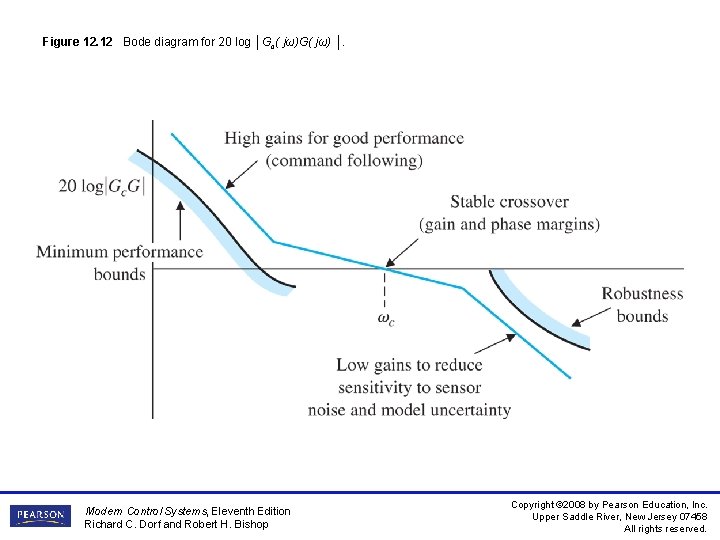
Figure 12. 12 Bode diagram for 20 log │Gc( jω)G( jω) │. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
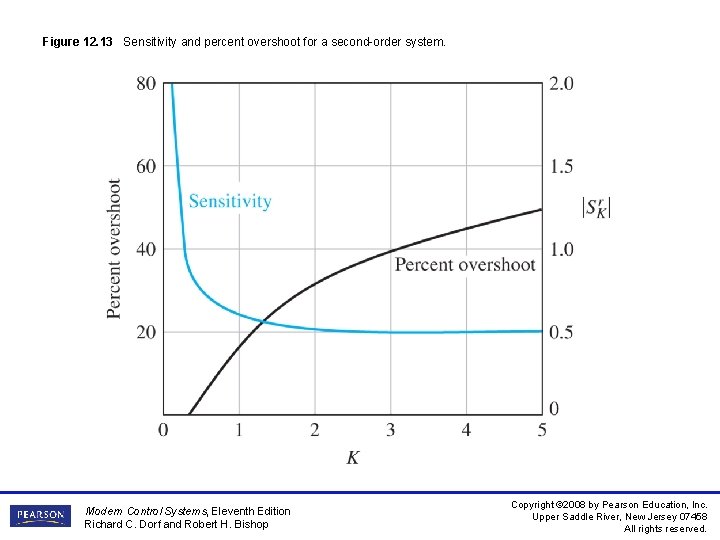
Figure 12. 13 Sensitivity and percent overshoot for a second-order system. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
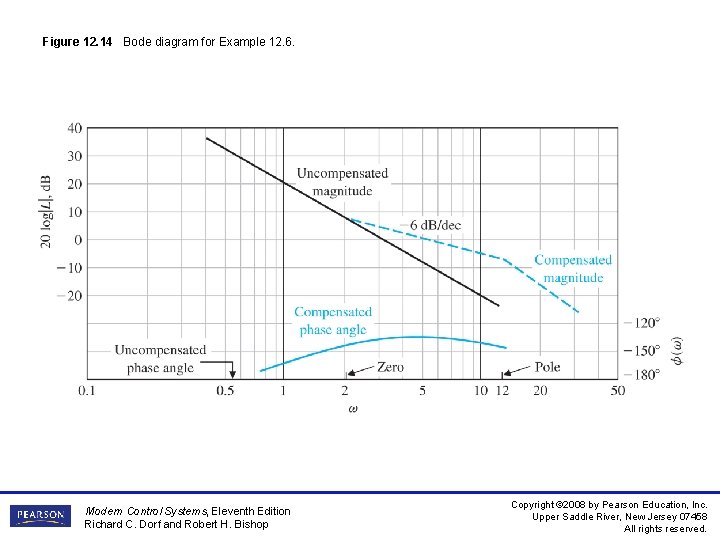
Figure 12. 14 Bode diagram for Example 12. 6. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
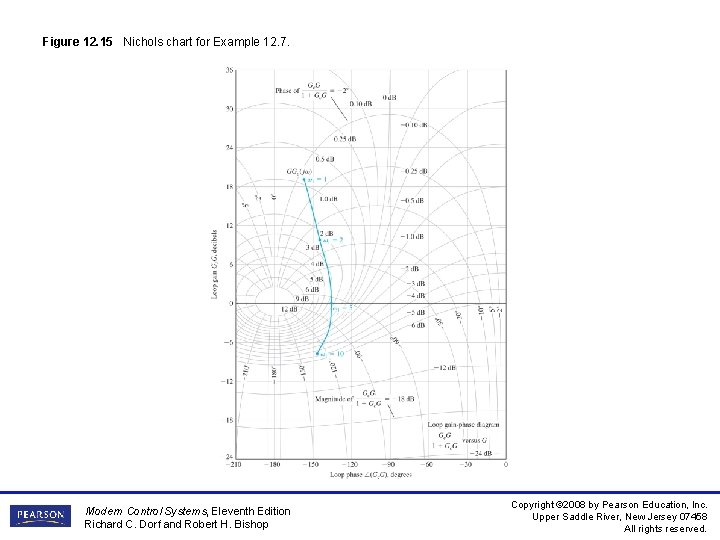
Figure 12. 15 Nichols chart for Example 12. 7. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
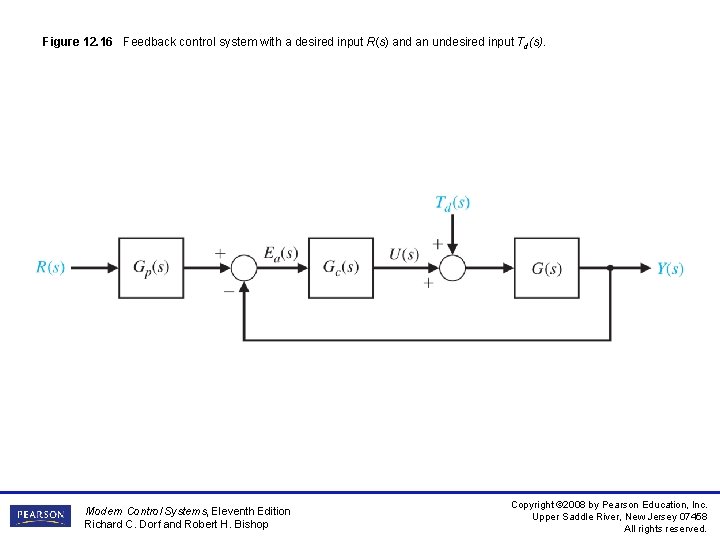
Figure 12. 16 Feedback control system with a desired input R(s) and an undesired input Td(s). Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
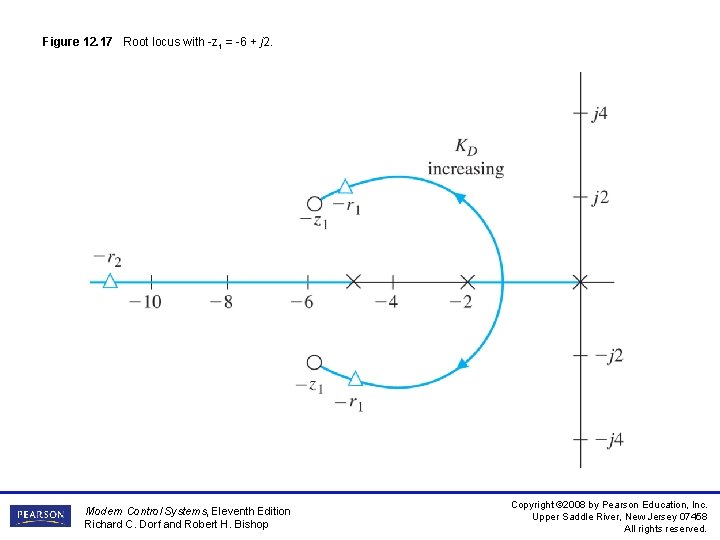
Figure 12. 17 Root locus with -z 1 = -6 + j 2. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
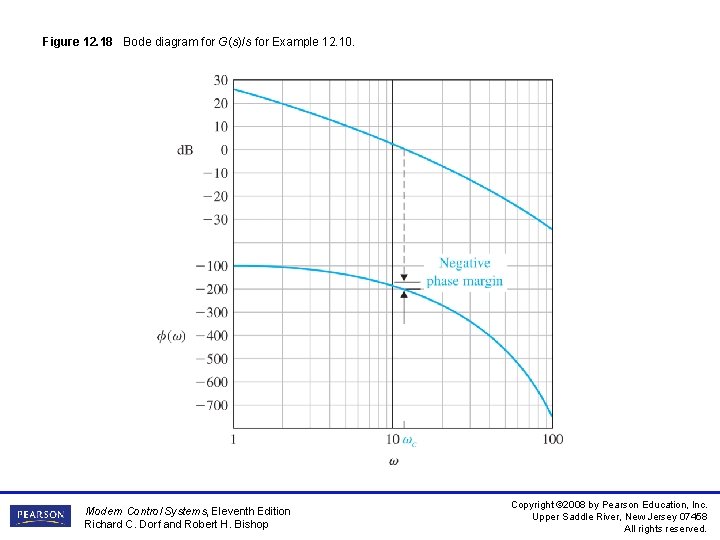
Figure 12. 18 Bode diagram for G(s)/s for Example 12. 10. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
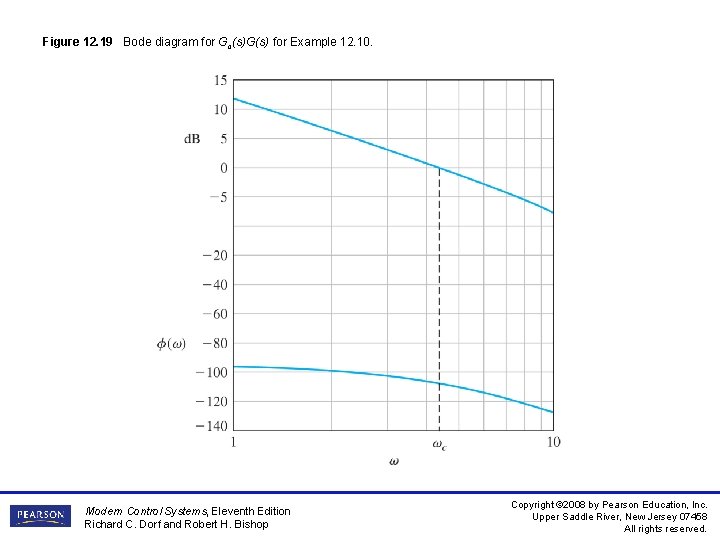
Figure 12. 19 Bode diagram for Gc(s)G(s) for Example 12. 10. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
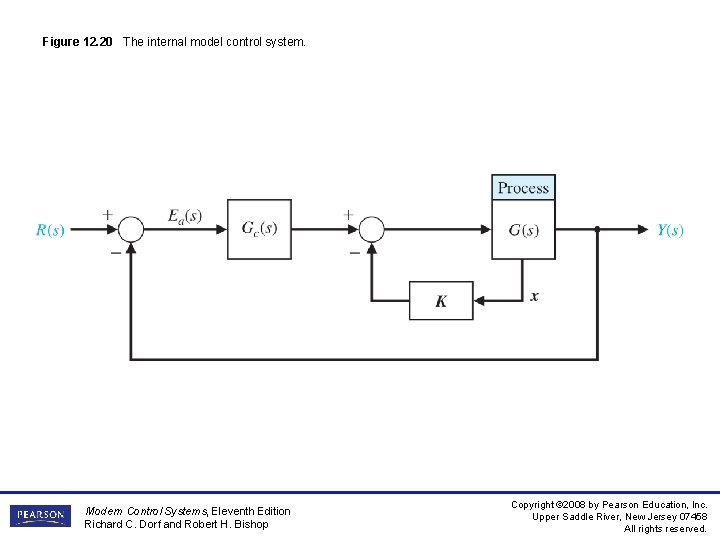
Figure 12. 20 The internal model control system. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
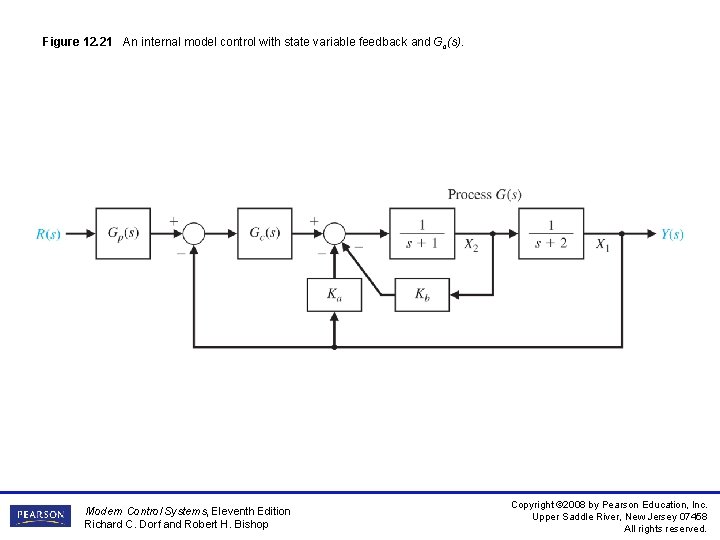
Figure 12. 21 An internal model control with state variable feedback and Gc(s). Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
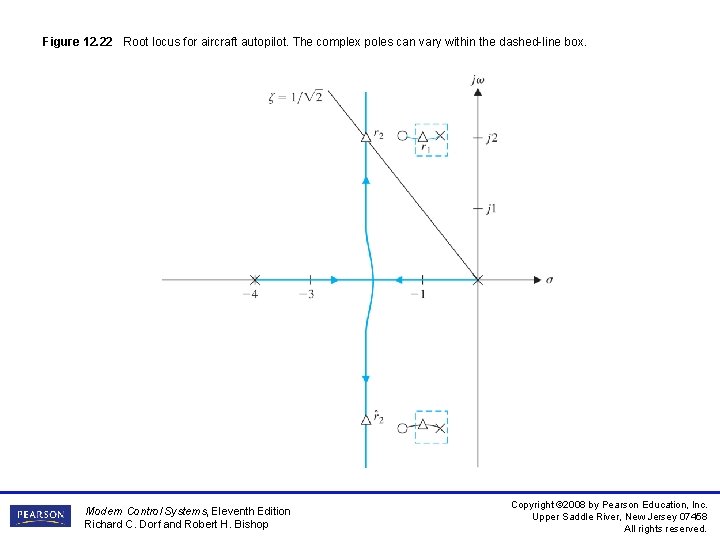
Figure 12. 22 Root locus for aircraft autopilot. The complex poles can vary within the dashed-line box. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
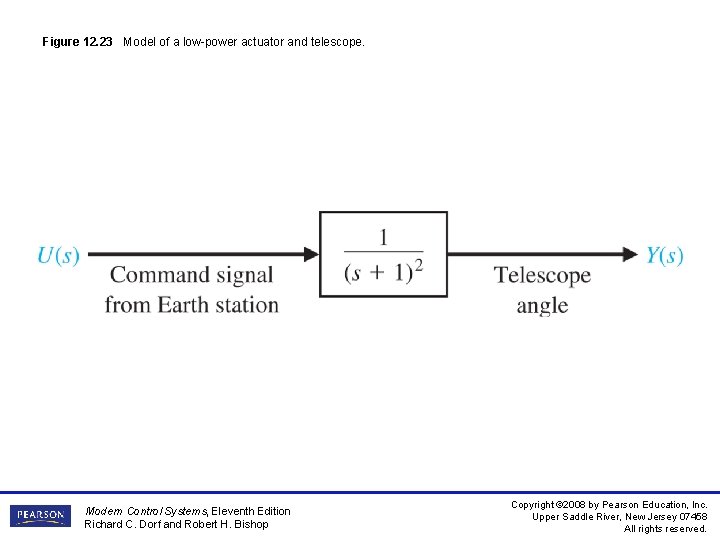
Figure 12. 23 Model of a low-power actuator and telescope. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
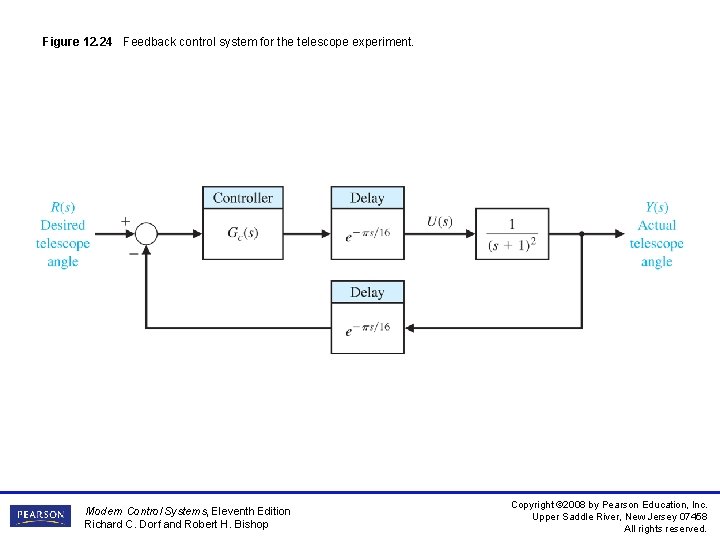
Figure 12. 24 Feedback control system for the telescope experiment. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
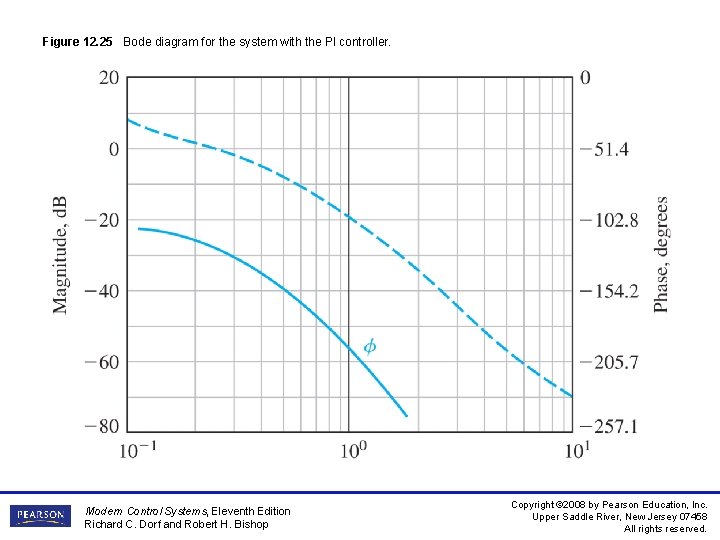
Figure 12. 25 Bode diagram for the system with the PI controller. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
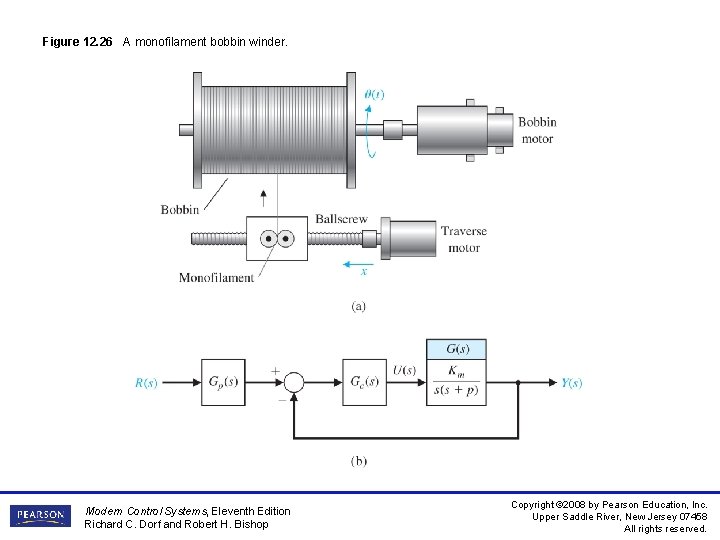
Figure 12. 26 A monofilament bobbin winder. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
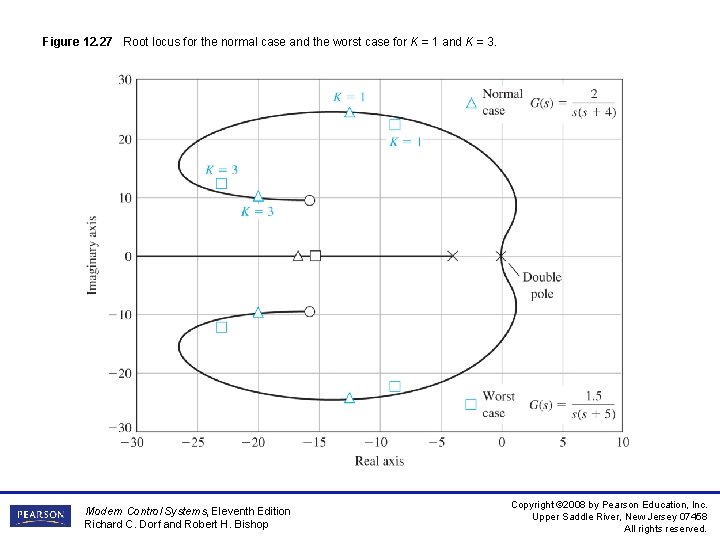
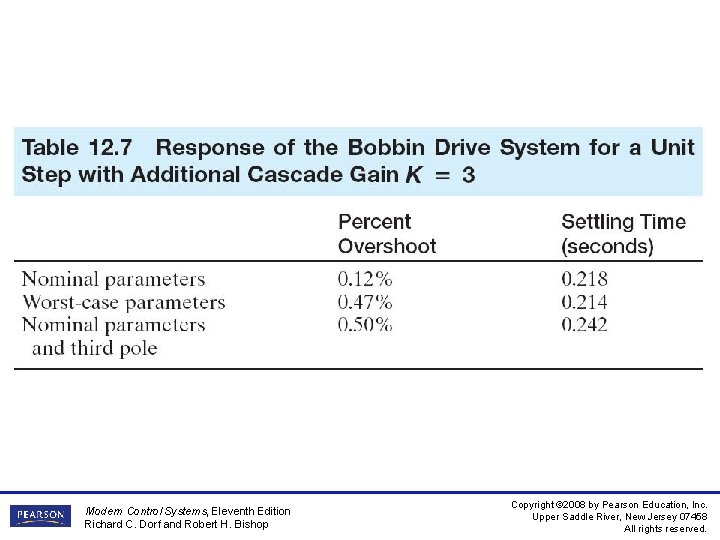
Figure 12. 27 Root locus for the normal case and the worst case for K = 1 and K = 3. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
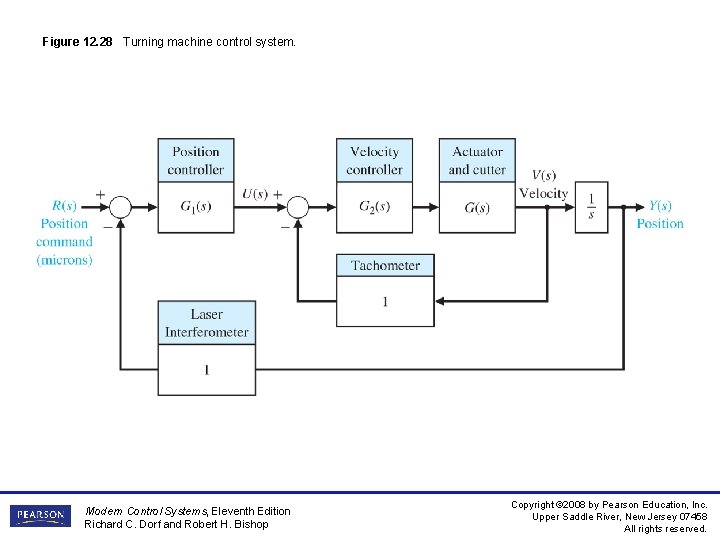
Figure 12. 28 Turning machine control system. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
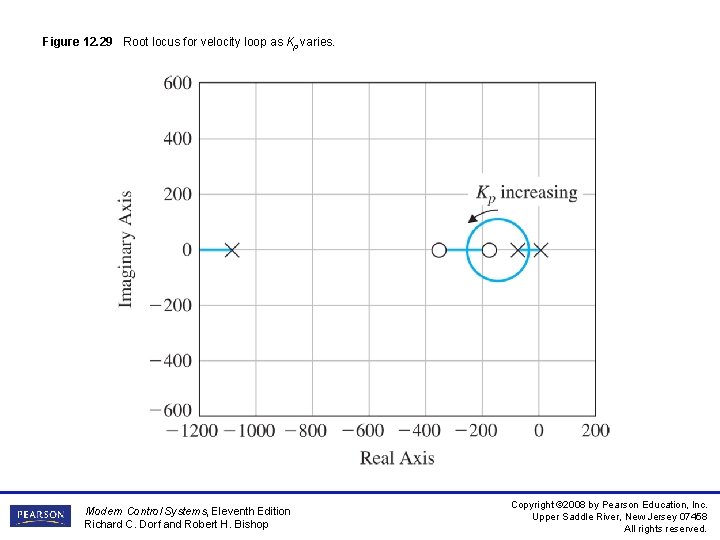
Figure 12. 29 Root locus for velocity loop as Kp varies. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
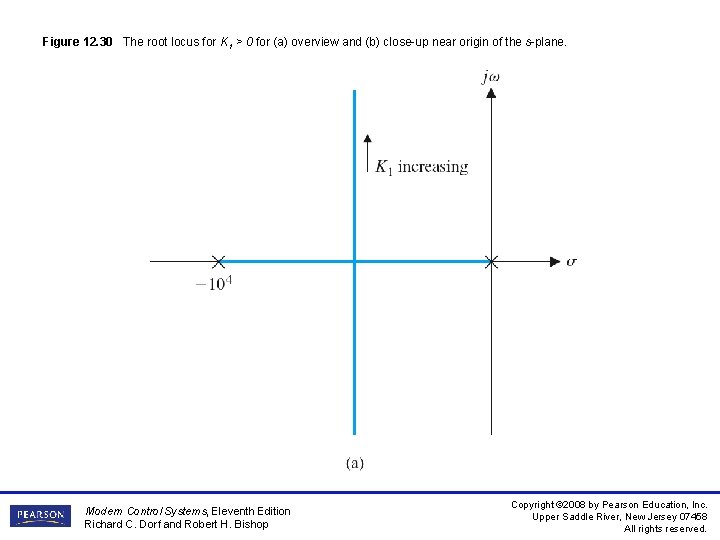
Figure 12. 30 The root locus for K 1 > 0 for (a) overview and (b) close-up near origin of the s-plane. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
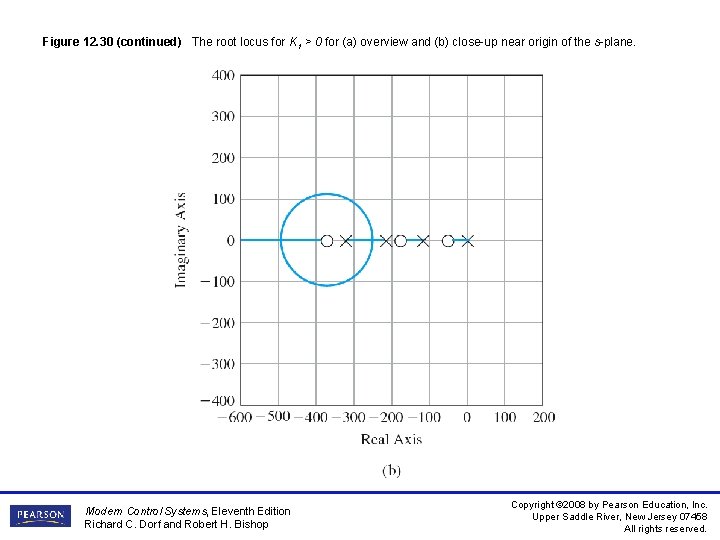
Figure 12. 30 (continued) The root locus for K 1 > 0 for (a) overview and (b) close-up near origin of the s-plane. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
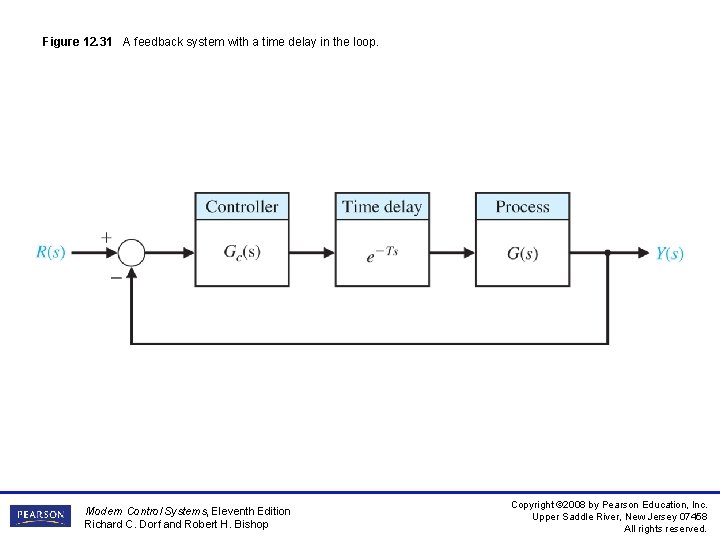
Figure 12. 31 A feedback system with a time delay in the loop. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
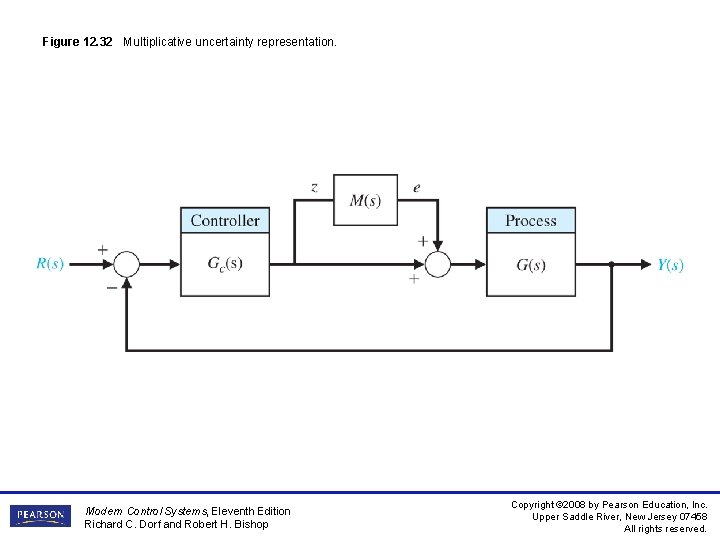
Figure 12. 32 Multiplicative uncertainty representation. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
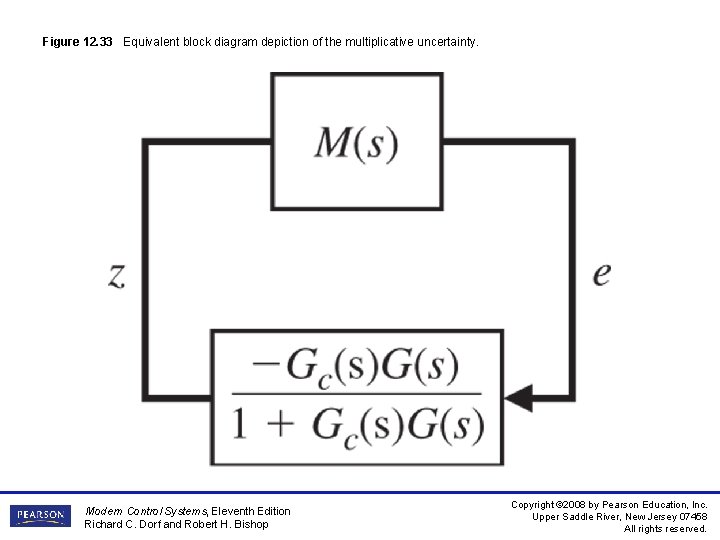
Figure 12. 33 Equivalent block diagram depiction of the multiplicative uncertainty. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
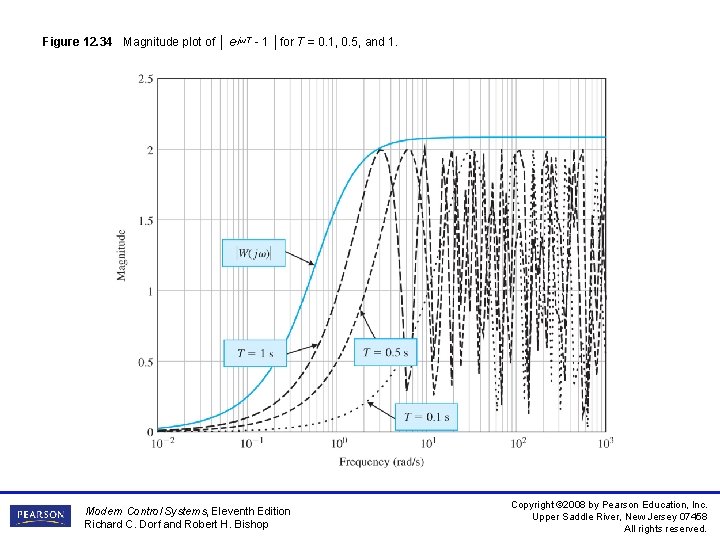
Figure 12. 34 Magnitude plot of │ e-jωT - 1 │for T = 0. 1, 0. 5, and 1. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
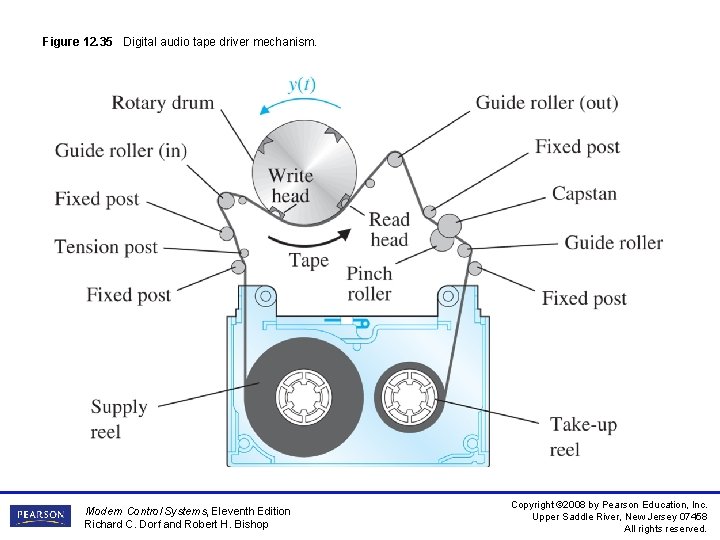
Figure 12. 35 Digital audio tape driver mechanism. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
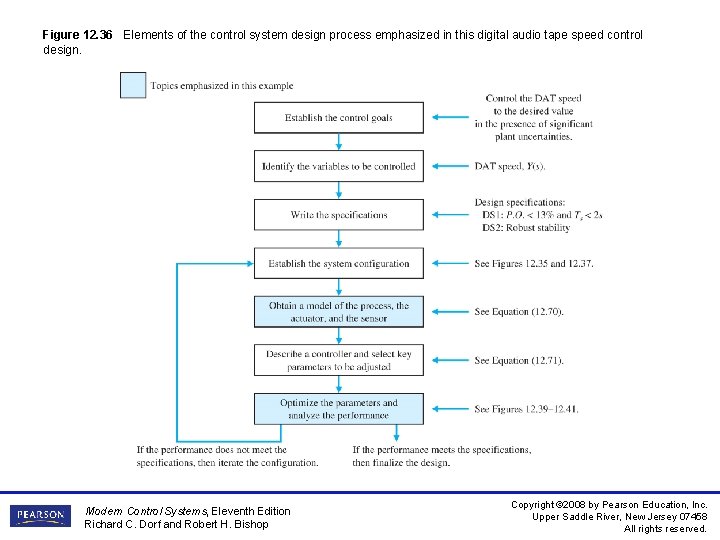
Figure 12. 36 Elements of the control system design process emphasized in this digital audio tape speed control design. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
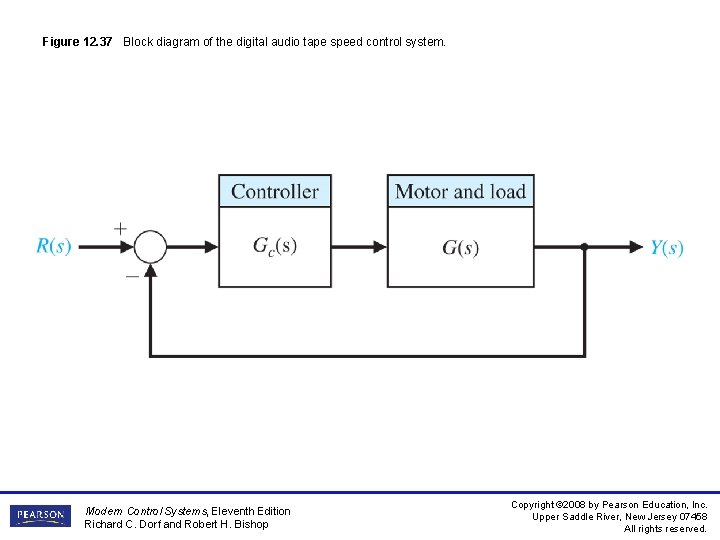
Figure 12. 37 Block diagram of the digital audio tape speed control system. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
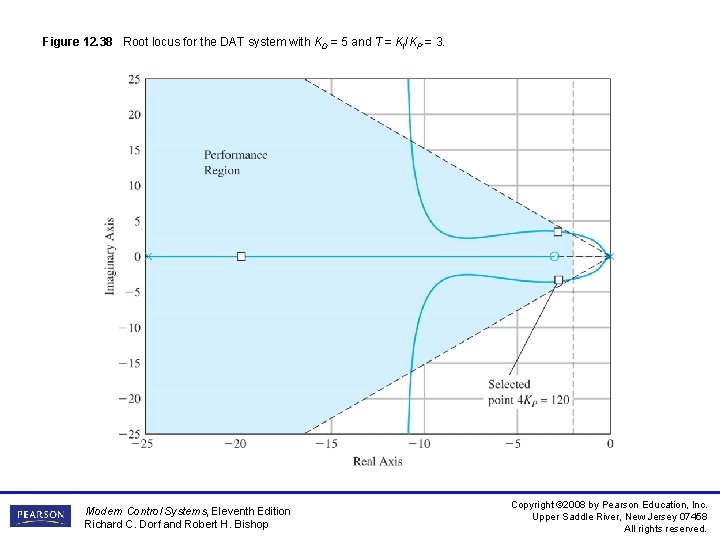
Figure 12. 38 Root locus for the DAT system with KD = 5 and Ƭ = KI/KP = 3. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
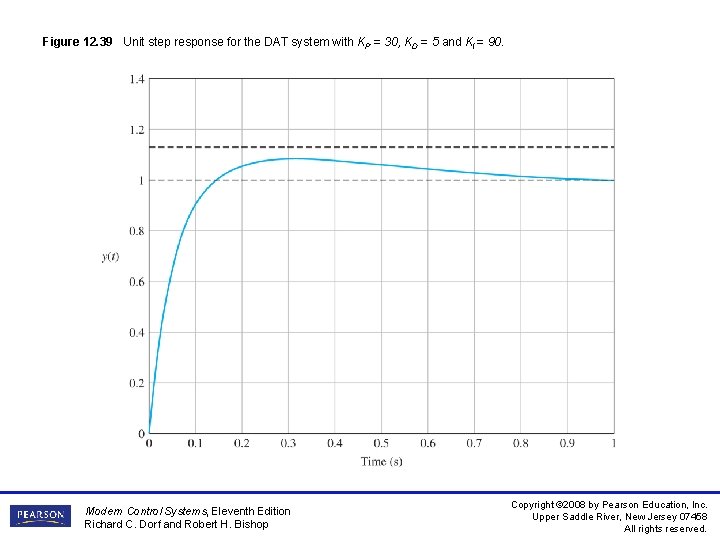
Figure 12. 39 Unit step response for the DAT system with KP = 30, KD = 5 and KI = 90. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
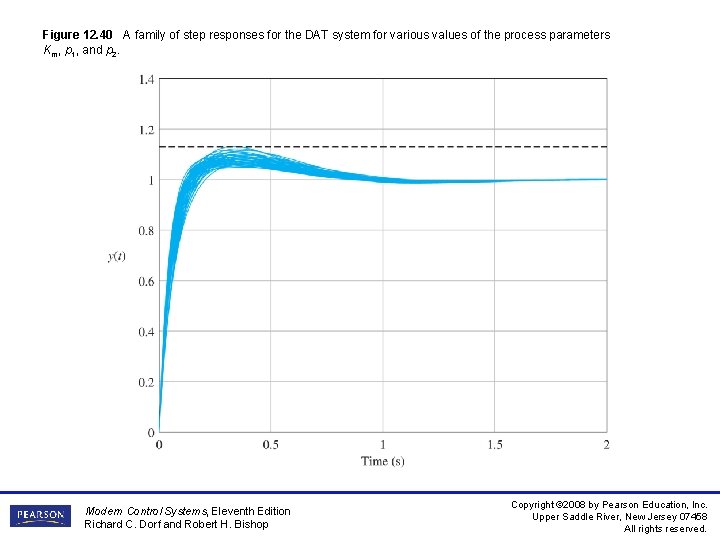
Figure 12. 40 A family of step responses for the DAT system for various values of the process parameters Km, p 1, and p 2. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
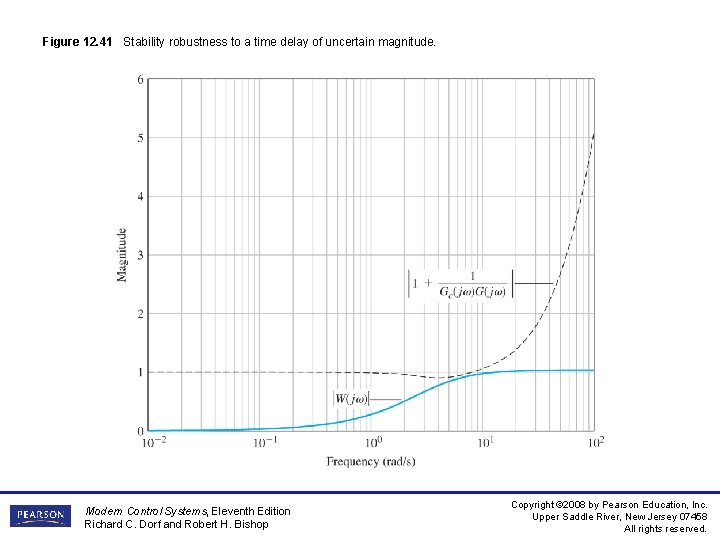
Figure 12. 41 Stability robustness to a time delay of uncertain magnitude. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
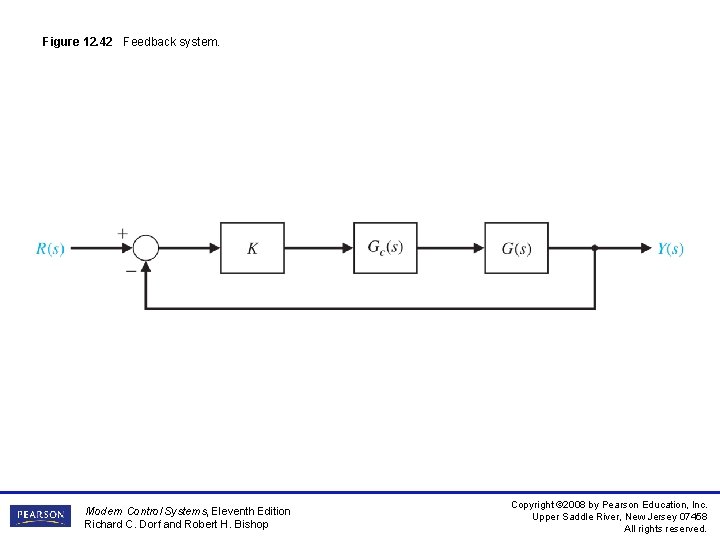
Figure 12. 42 Feedback system. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
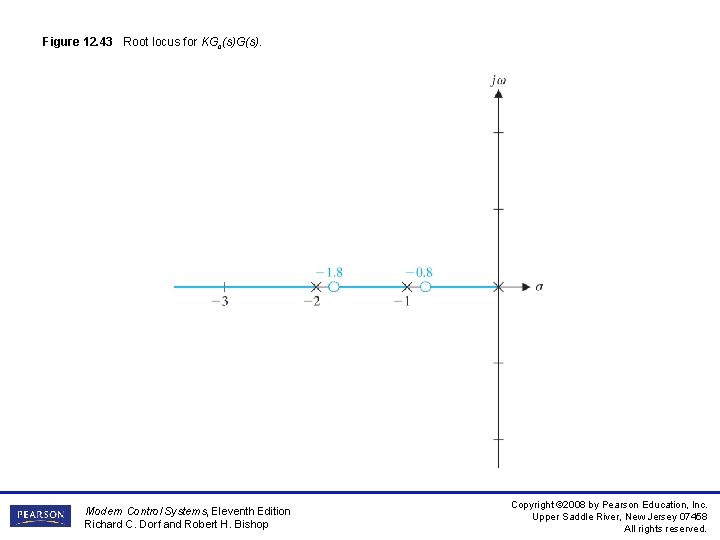
Figure 12. 43 Root locus for KGc(s)G(s). Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
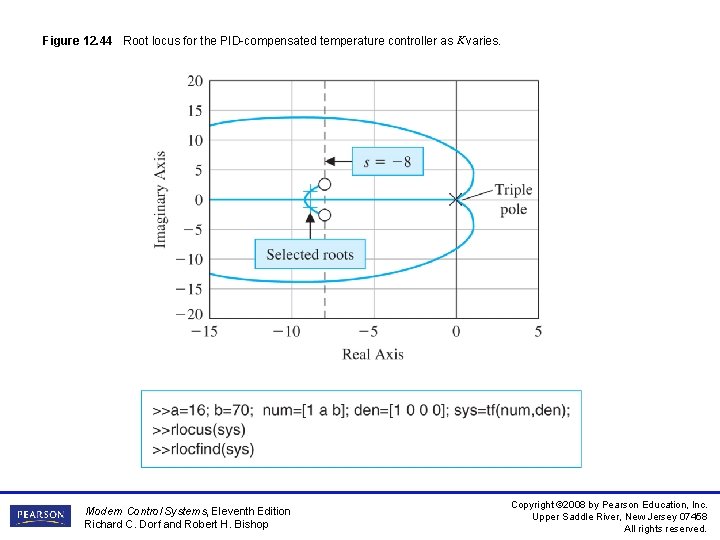
Figure 12. 44 Root locus for the PID-compensated temperature controller as K varies. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
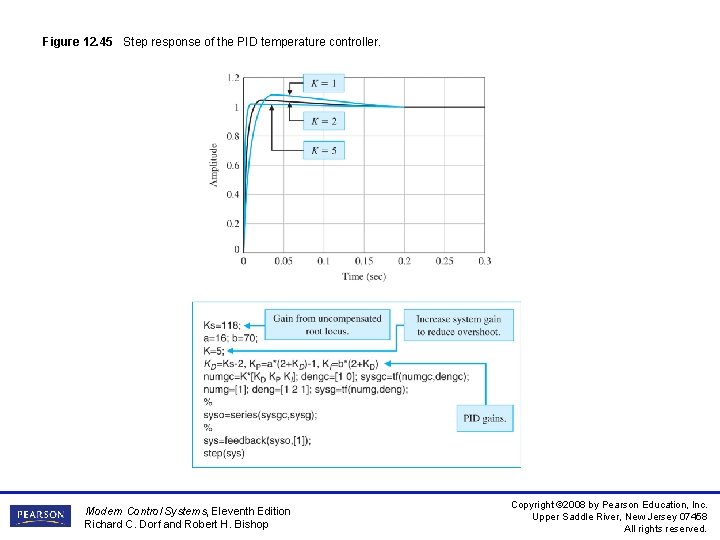
Figure 12. 45 Step response of the PID temperature controller. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
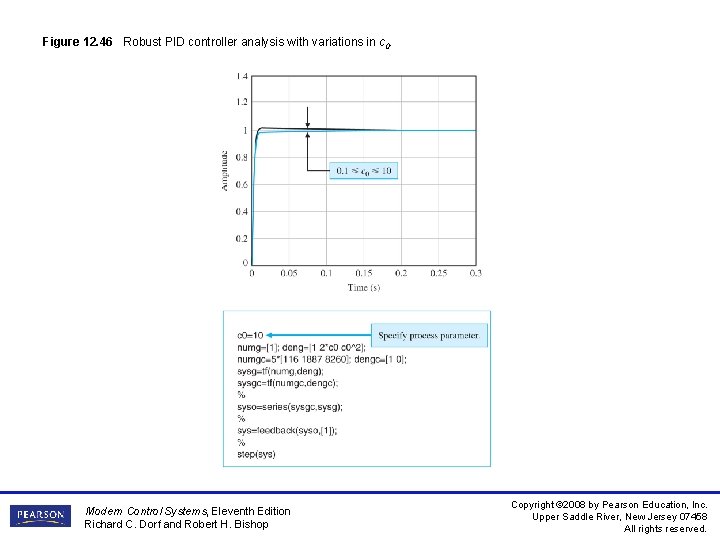
Figure 12. 46 Robust PID controller analysis with variations in c 0. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
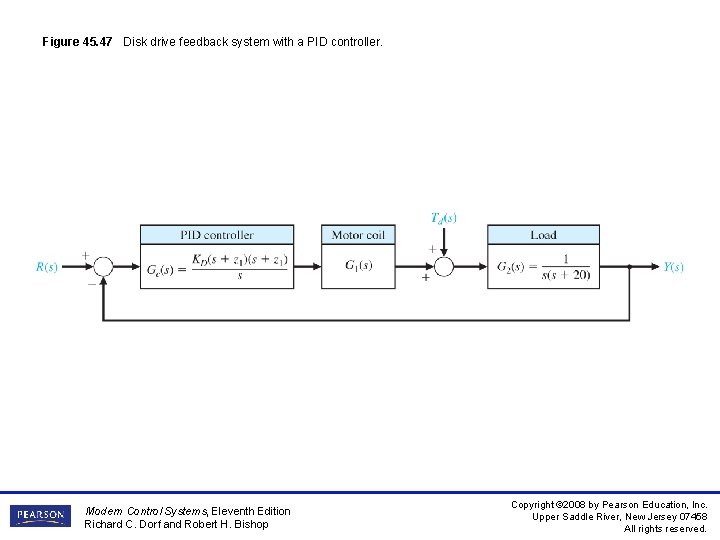
Figure 45. 47 Disk drive feedback system with a PID controller. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
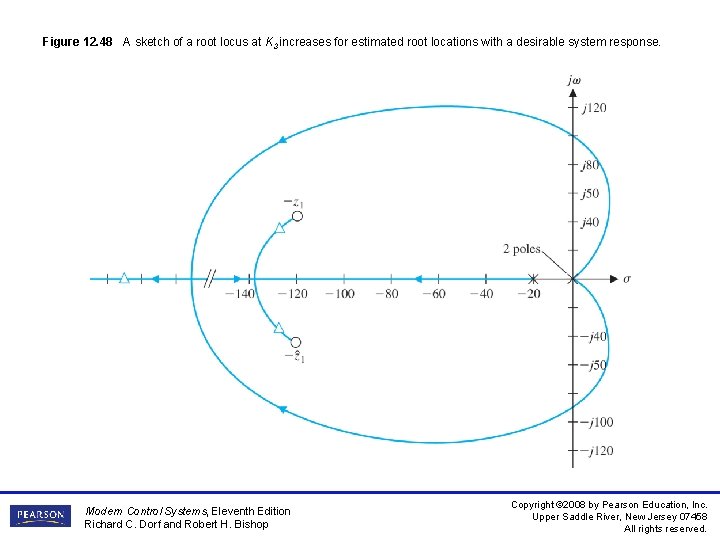
Figure 12. 48 A sketch of a root locus at K 3 increases for estimated root locations with a desirable system response. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
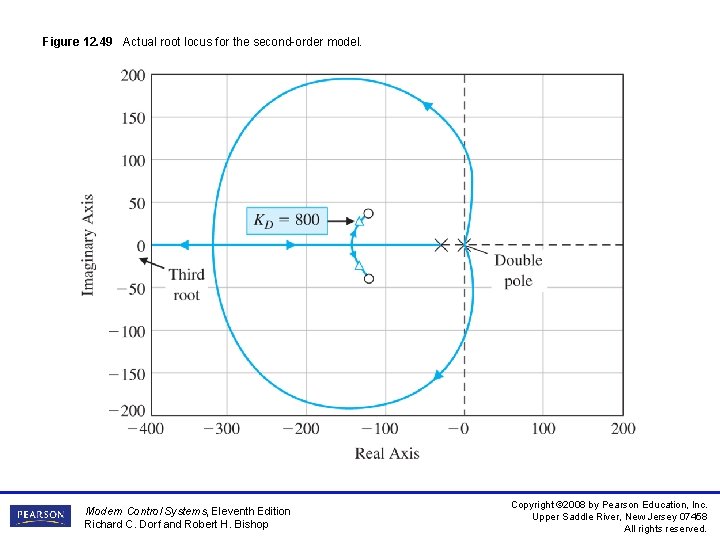
Figure 12. 49 Actual root locus for the second-order model. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
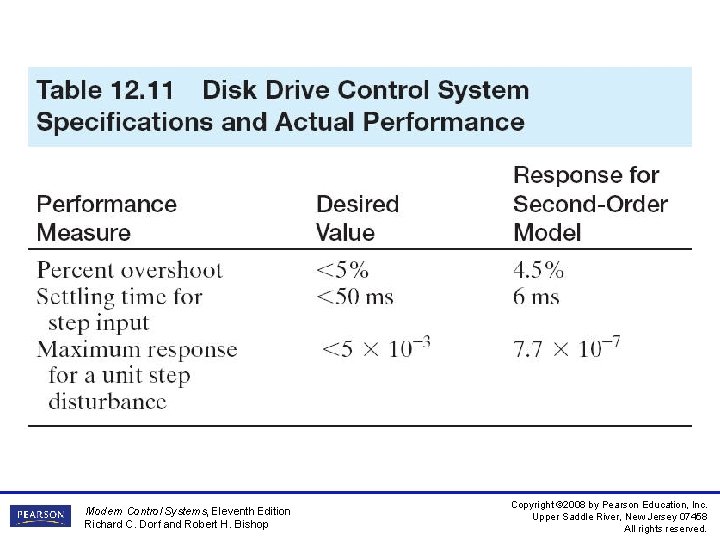
Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
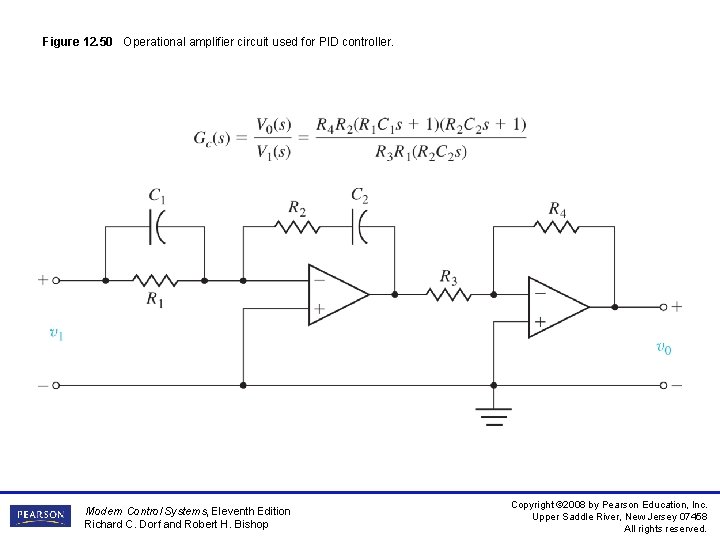
Figure 12. 50 Operational amplifier circuit used for PID controller. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
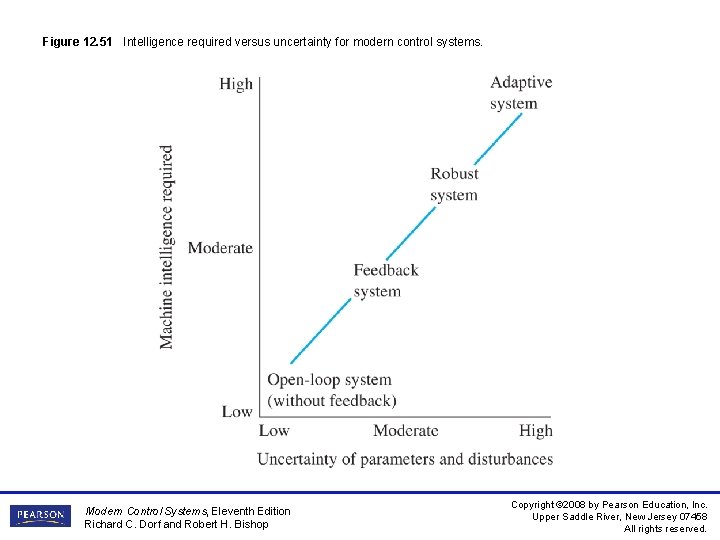
Figure 12. 51 Intelligence required versus uncertainty for modern control systems. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
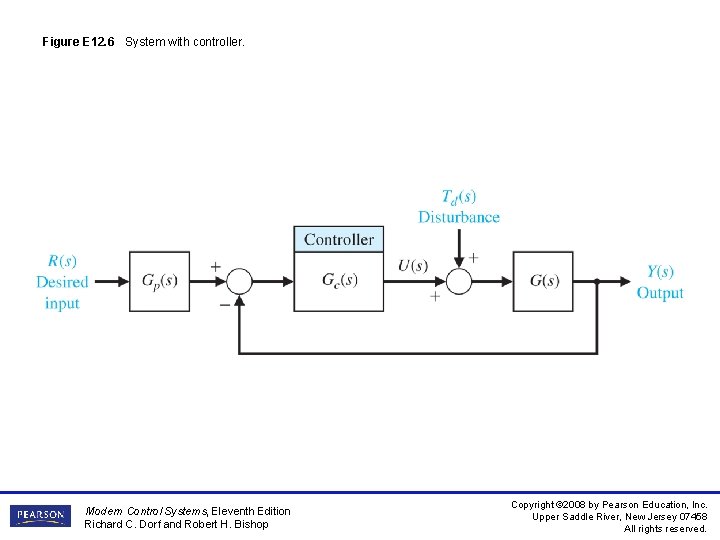
Figure E 12. 6 System with controller. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
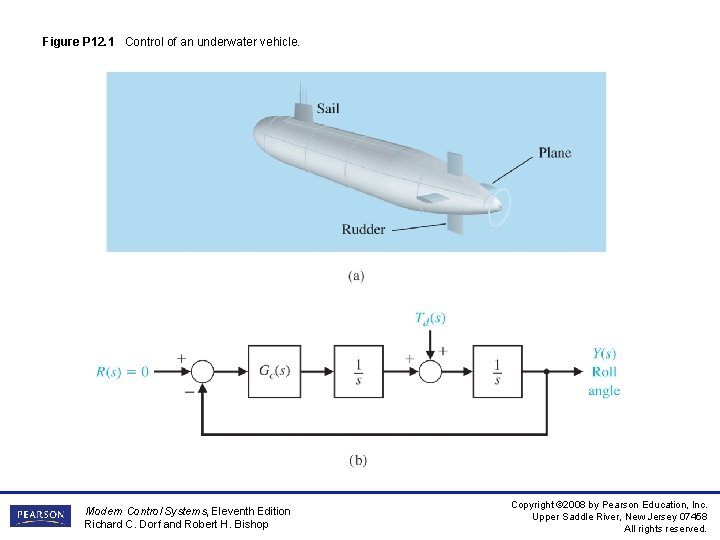
Figure P 12. 1 Control of an underwater vehicle. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
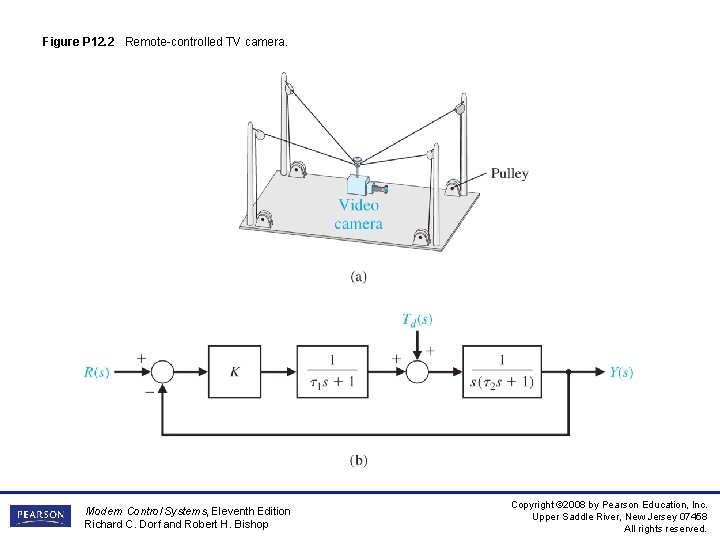
Figure P 12. 2 Remote-controlled TV camera. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
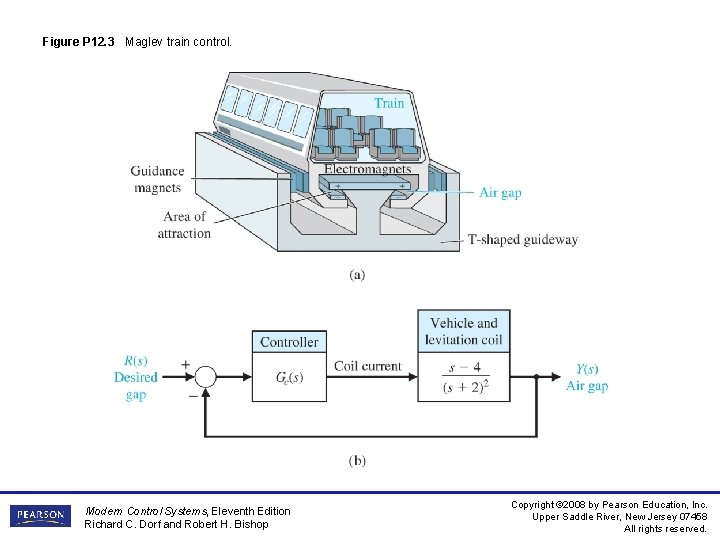
Figure P 12. 3 Maglev train control. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
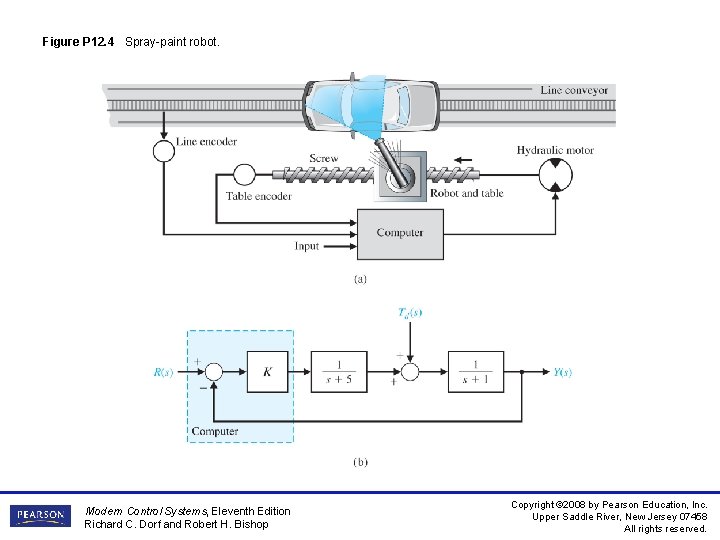
Figure P 12. 4 Spray-paint robot. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
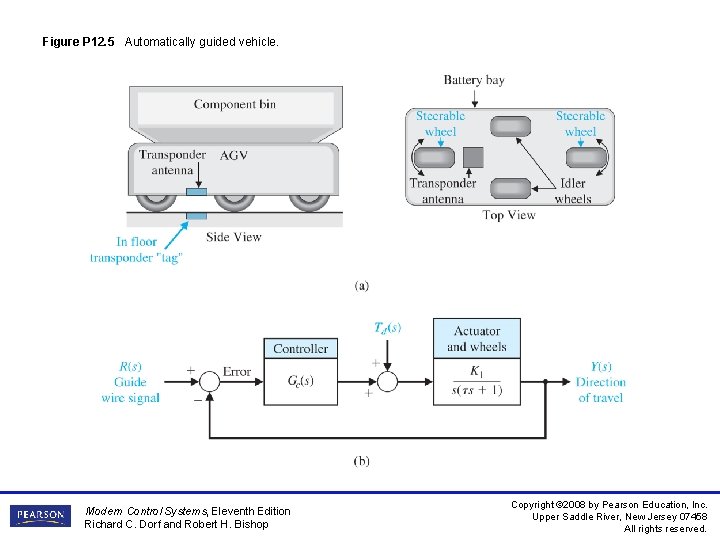
Figure P 12. 5 Automatically guided vehicle. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
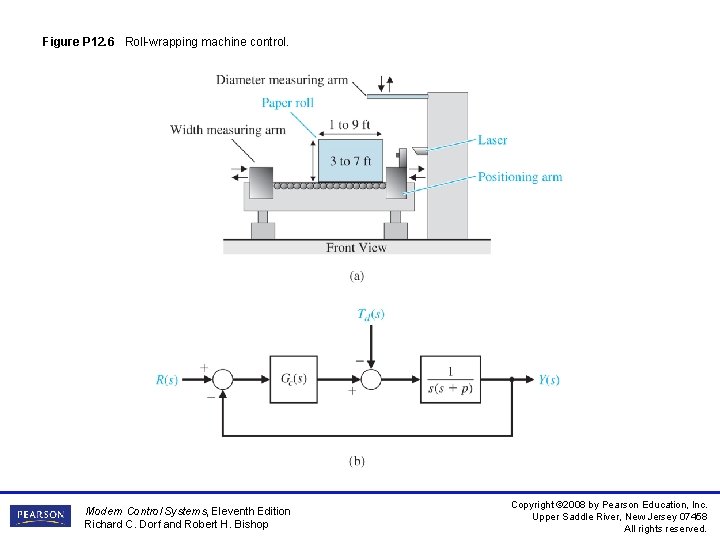
Figure P 12. 6 Roll-wrapping machine control. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
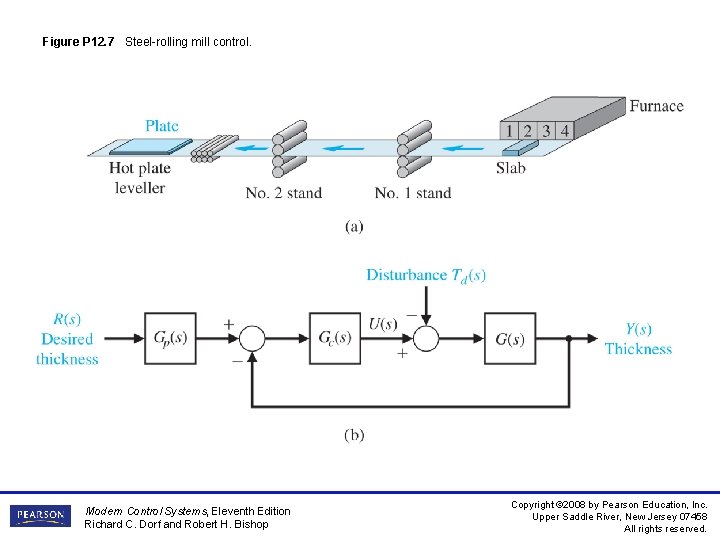
Figure P 12. 7 Steel-rolling mill control. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
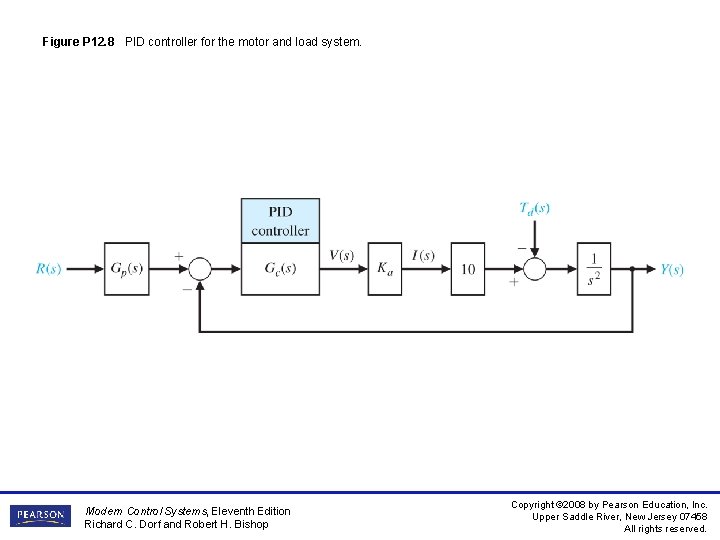
Figure P 12. 8 PID controller for the motor and load system. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
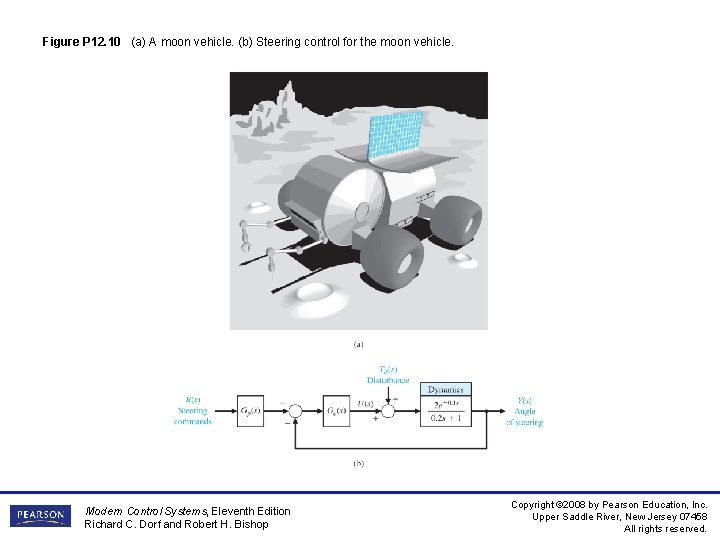
Figure P 12. 10 (a) A moon vehicle. (b) Steering control for the moon vehicle. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
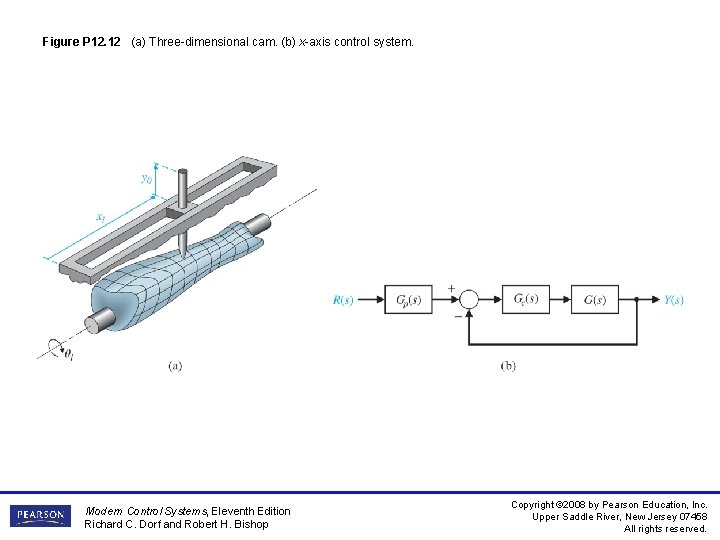
Figure P 12. 12 (a) Three-dimensional cam. (b) x-axis control system. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
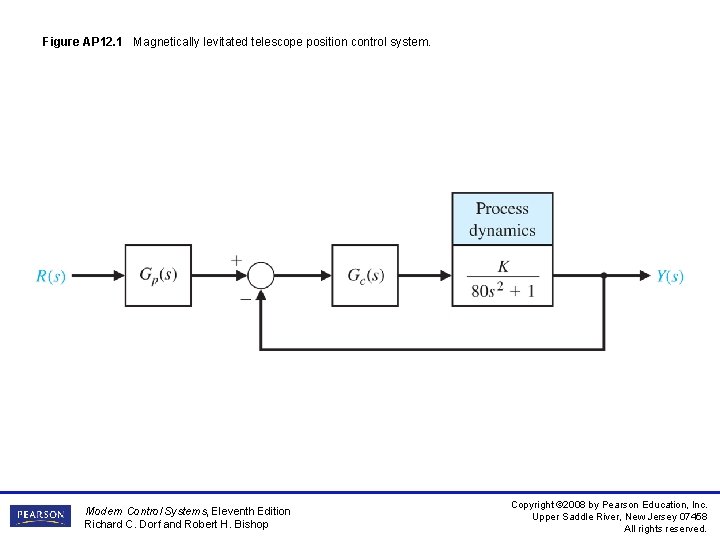
Figure AP 12. 1 Magnetically levitated telescope position control system. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
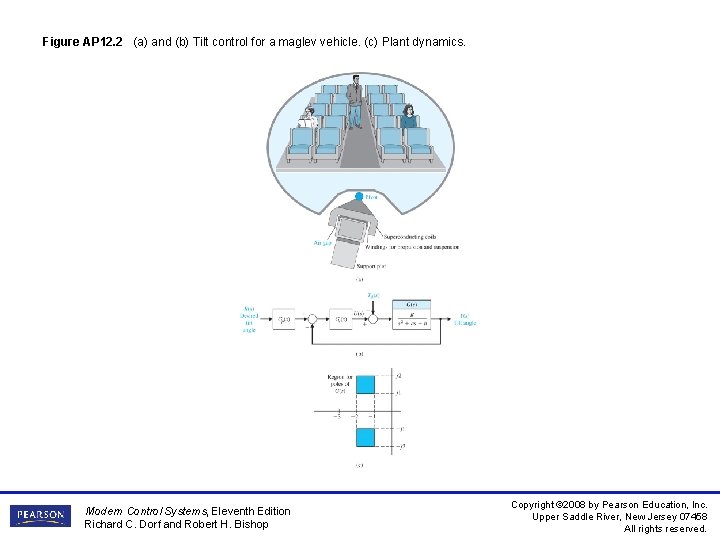
Figure AP 12. 2 (a) and (b) Tilt control for a maglev vehicle. (c) Plant dynamics. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
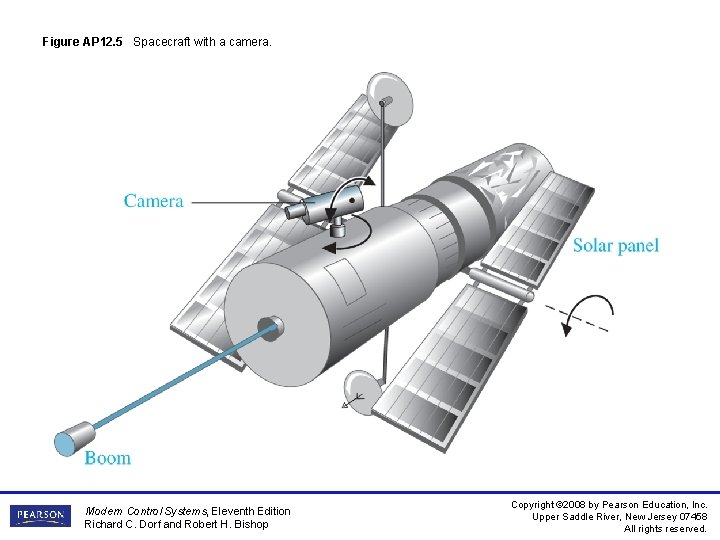
Figure AP 12. 5 Spacecraft with a camera. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
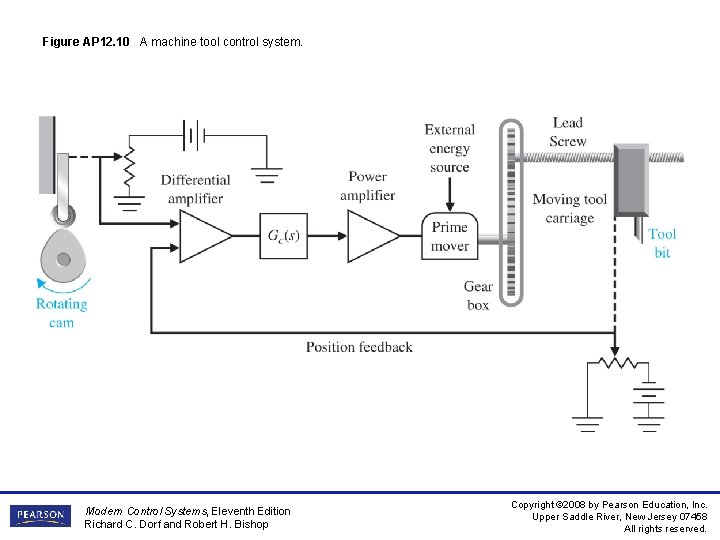
Figure AP 12. 10 A machine tool control system. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
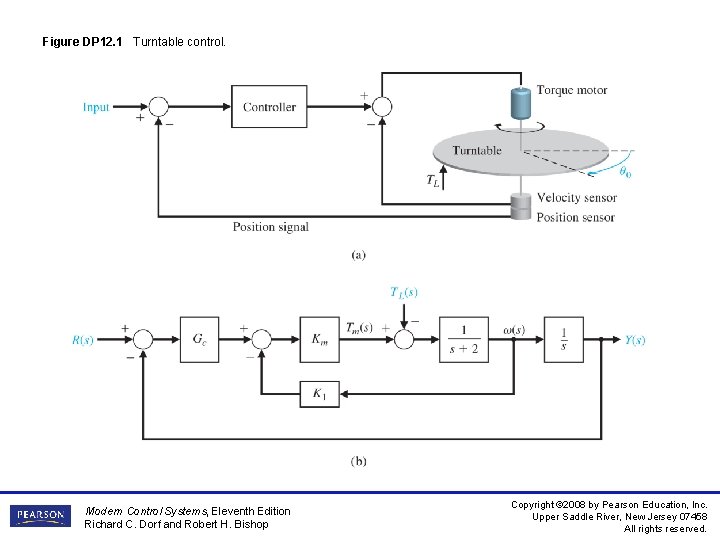
Figure DP 12. 1 Turntable control. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
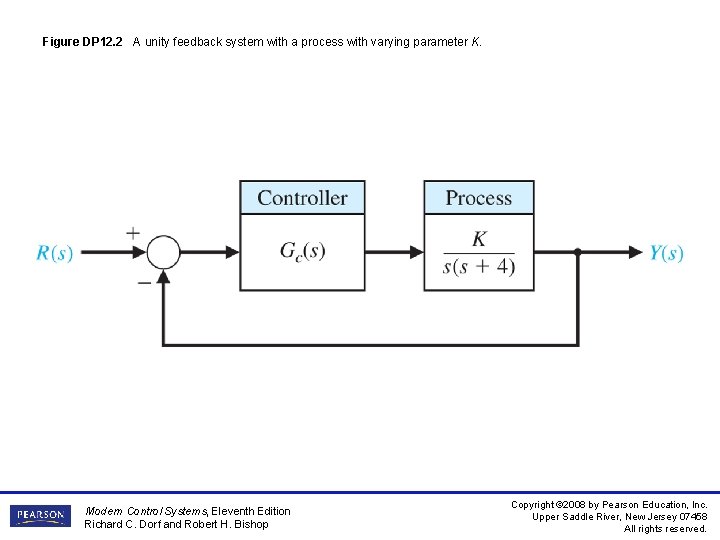
Figure DP 12. 2 A unity feedback system with a process with varying parameter K. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
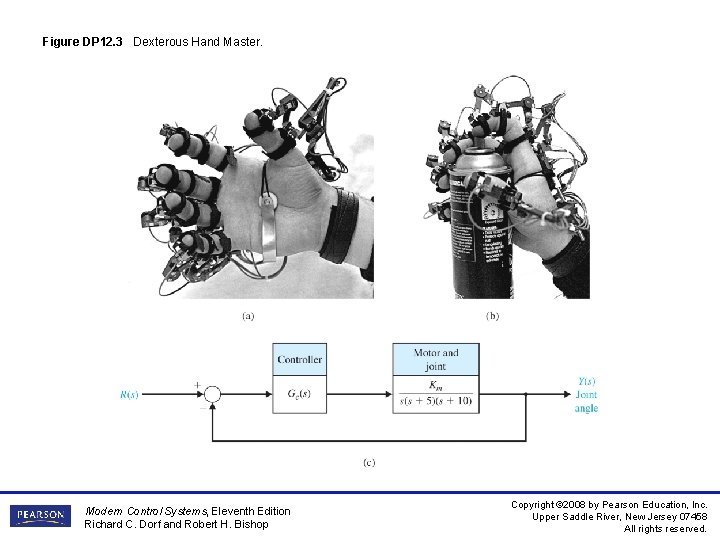
Figure DP 12. 3 Dexterous Hand Master. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
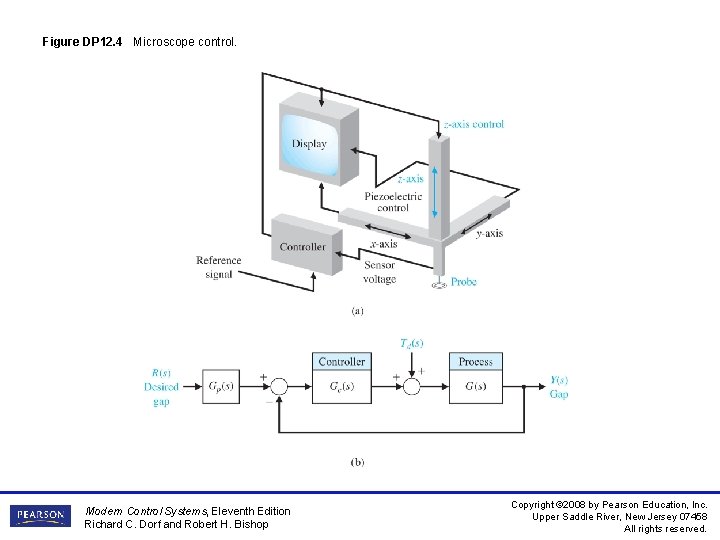
Figure DP 12. 4 Microscope control. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
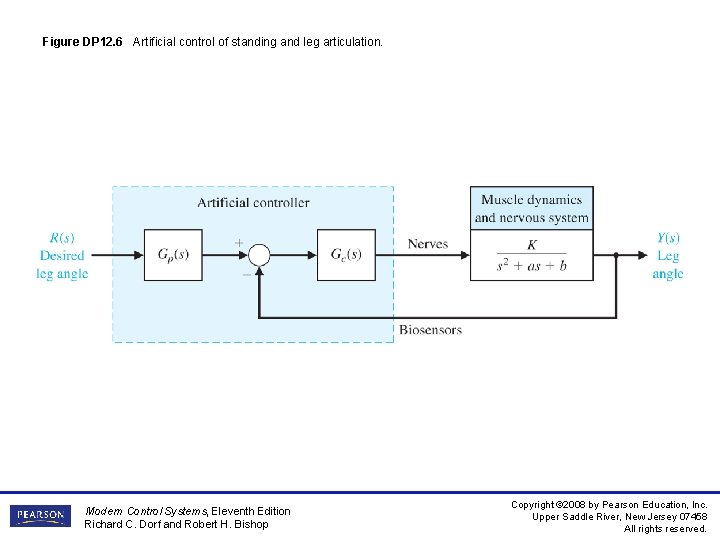
Figure DP 12. 6 Artificial control of standing and leg articulation. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
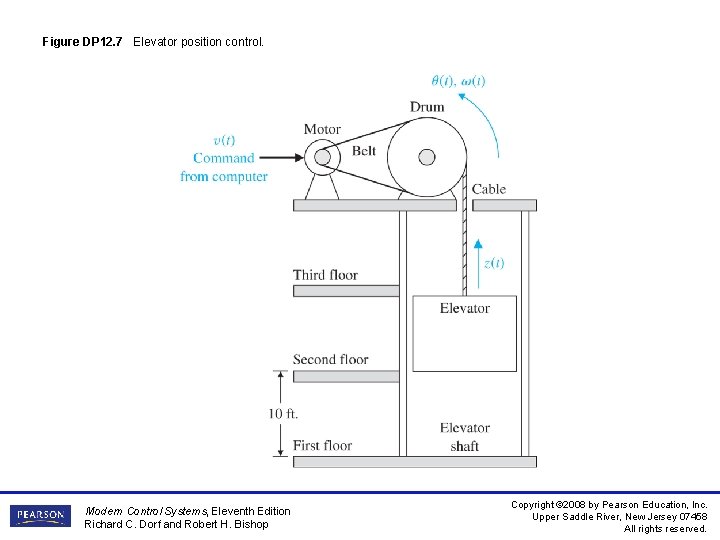
Figure DP 12. 7 Elevator position control. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
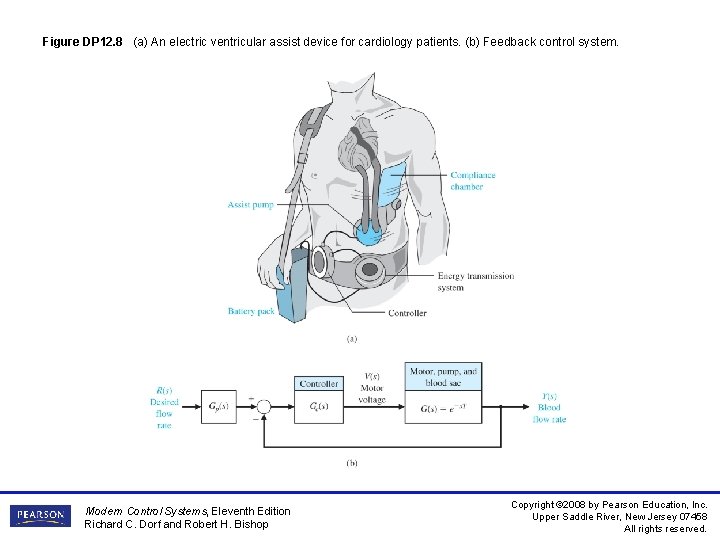
Figure DP 12. 8 (a) An electric ventricular assist device for cardiology patients. (b) Feedback control system. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
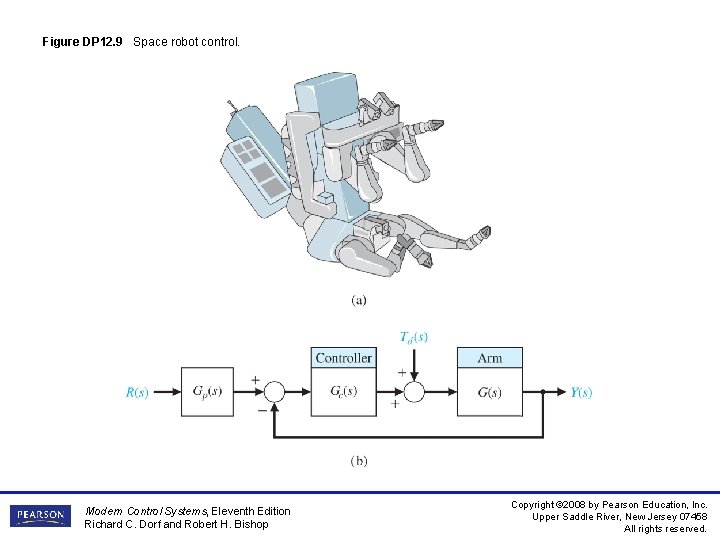
Figure DP 12. 9 Space robot control. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
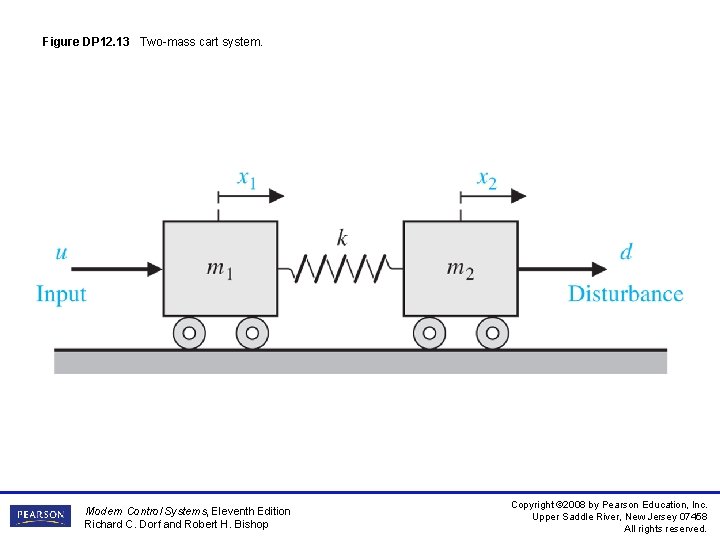
Figure DP 12. 13 Two-mass cart system. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
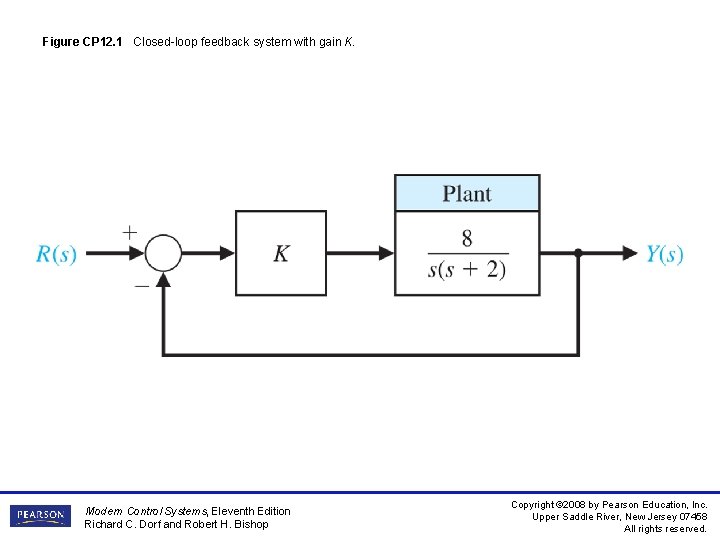
Figure CP 12. 1 Closed-loop feedback system with gain K. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
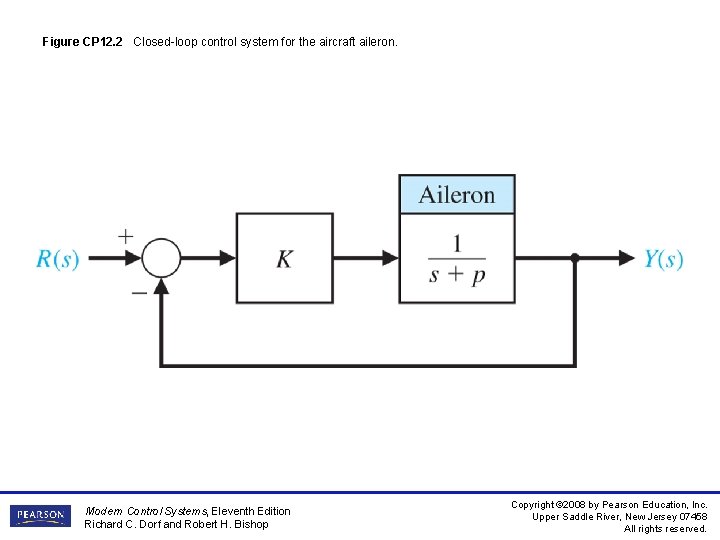
Figure CP 12. 2 Closed-loop control system for the aircraft aileron. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
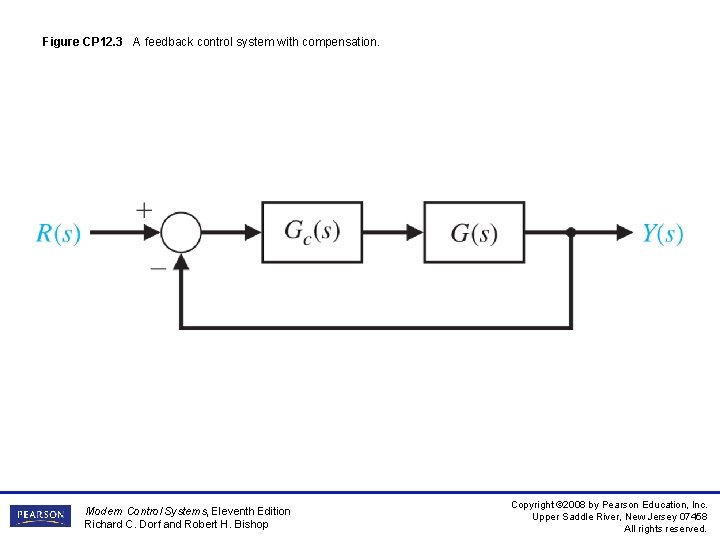
Figure CP 12. 3 A feedback control system with compensation. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
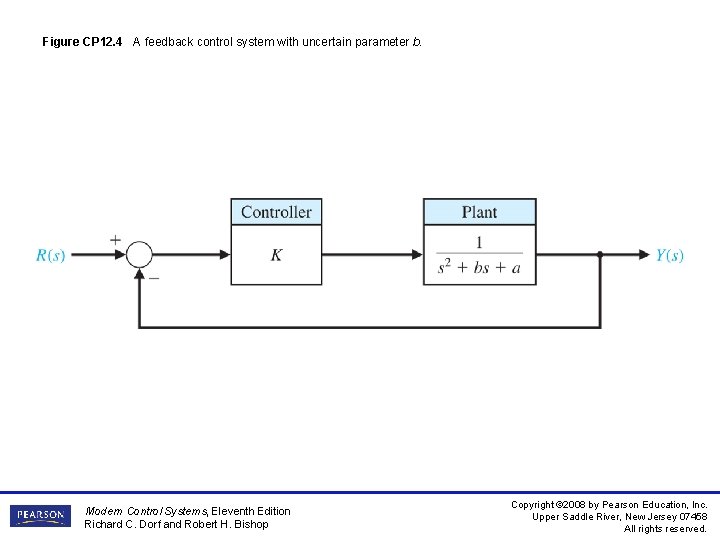
Figure CP 12. 4 A feedback control system with uncertain parameter b. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
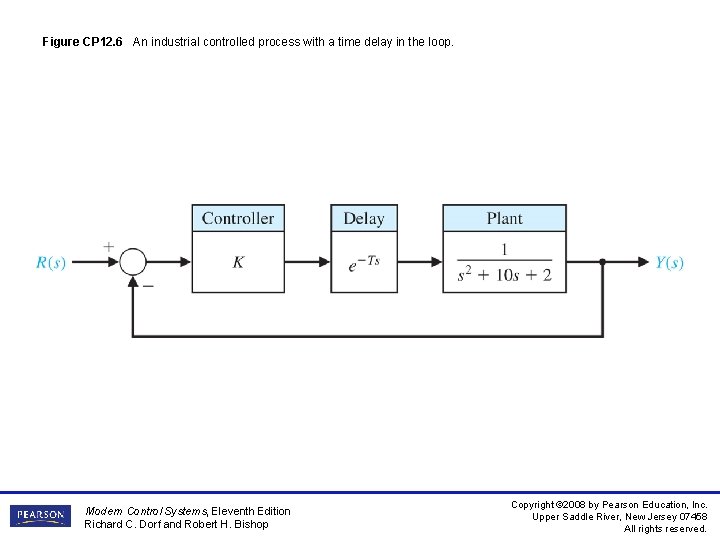
Figure CP 12. 6 An industrial controlled process with a time delay in the loop. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.
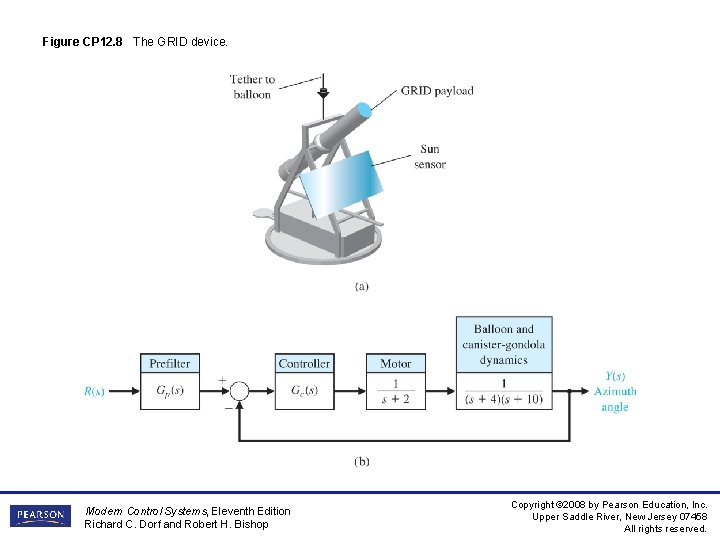
Figure CP 12. 8 The GRID device. Modern Control Systems, Eleventh Edition Richard C. Dorf and Robert H. Bishop Copyright © 2008 by Pearson Education, Inc. Upper Saddle River, New Jersey 07458 All rights reserved.