
EKT 221 DIGITAL 2 ASM Date 24 August
- Slides: 21
EKT 221 : DIGITAL 2 ASM Date: 24 August 2010
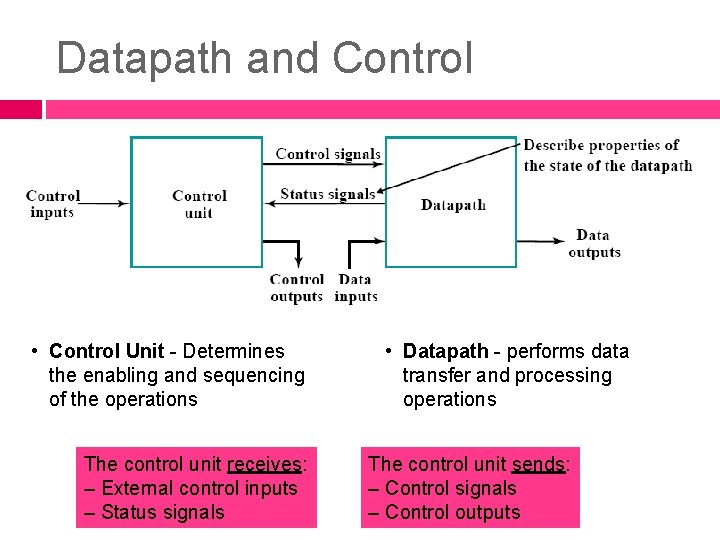
Datapath and Control • Control Unit - Determines the enabling and sequencing of the operations The control unit receives: – External control inputs – Status signals • Datapath - performs data transfer and processing operations The control unit sends: – Control signals – Control outputs
Types of Control Unit 2 types: Programmable System Programmable Non-programmable Input consist of sequence of instructions Instruction are usually stored in memory (RAM or ROM) Address comes from PC (Program Counter) Non-programmable (This chapter FOCUS on this) Control unit is NOT responsible for getting instructions from memory or sequencing, hence NO PC Control unit determines the operation based on inputs and status bit from the datapath.
ALGORITHMIC STATE MACHINE (ASM) The function of a state machine (or sequential circuit) can be represented by a state table or a state diagram. A flowchart is a way of showing actions and control flow in an algorithm. An Algorithmic State Machine (ASM) is simply a flowchart-like way to specify state diagrams for sequential logic and, optionally, actions performed in a datapath. While flowcharts typically do not specify “time”, an ASM explicitly specifies a sequence of actions and their timing relationships.
ALGORITHMIC STATE MACHINE (ASM) A Flowchart is a convenient way to specify a sequence of procedural steps and decision paths for an algorithm. ASM chart provides not only sequence of events, but it distinguished by the fact that it describes the timing relationship between states of the CU and the datapath actions in response to clock pulses.
ASM Chart 4 basic elements: State box Scalar decision box Conditional output box Vector decision box
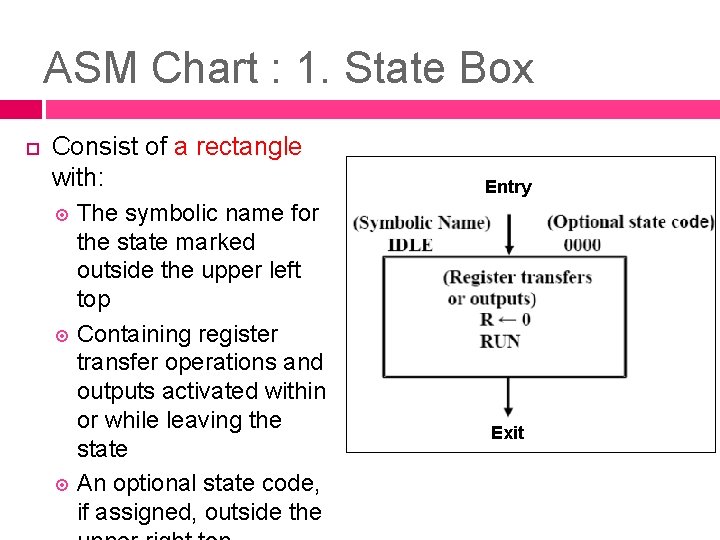
ASM Chart : 1. State Box Consist of a rectangle with: The symbolic name for the state marked outside the upper left top Containing register transfer operations and outputs activated within or while leaving the state An optional state code, if assigned, outside the Entry Exit
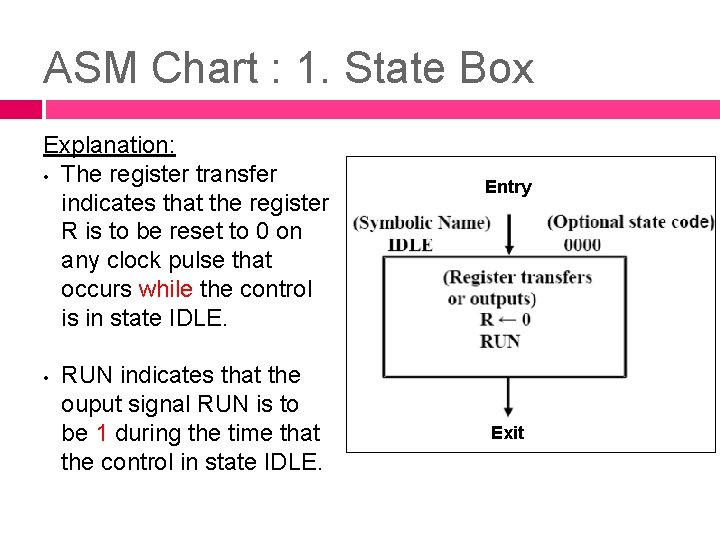
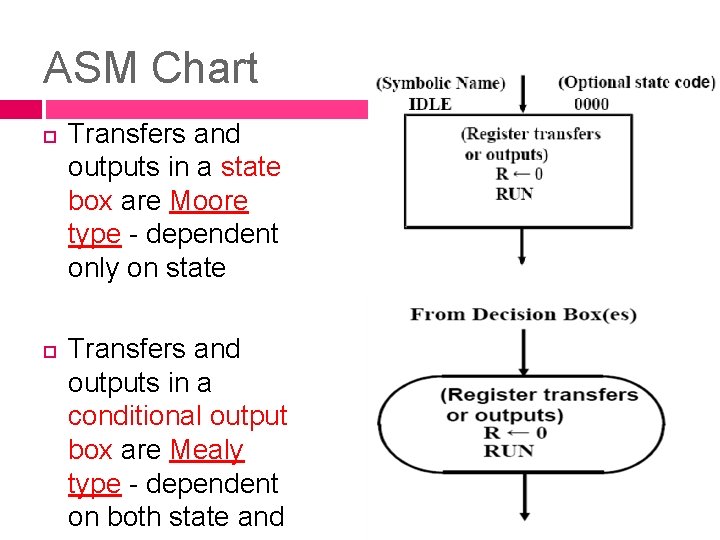
ASM Chart : 1. State Box Explanation: • The register transfer indicates that the register R is to be reset to 0 on any clock pulse that occurs while the control is in state IDLE. • RUN indicates that the ouput signal RUN is to be 1 during the time that the control in state IDLE. Entry Exit
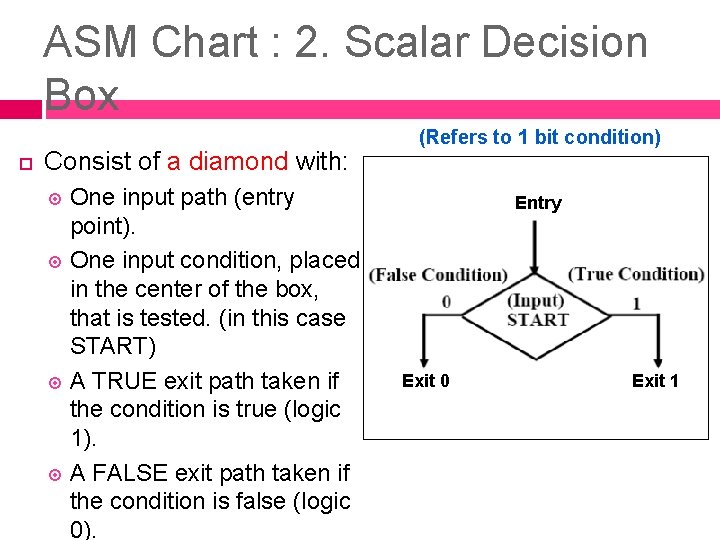
ASM Chart : 2. Scalar Decision Box Consist of a diamond with: One input path (entry point). One input condition, placed in the center of the box, that is tested. (in this case START) A TRUE exit path taken if the condition is true (logic 1). A FALSE exit path taken if the condition is false (logic 0). (Refers to 1 bit condition) Entry Exit 0 Exit 1
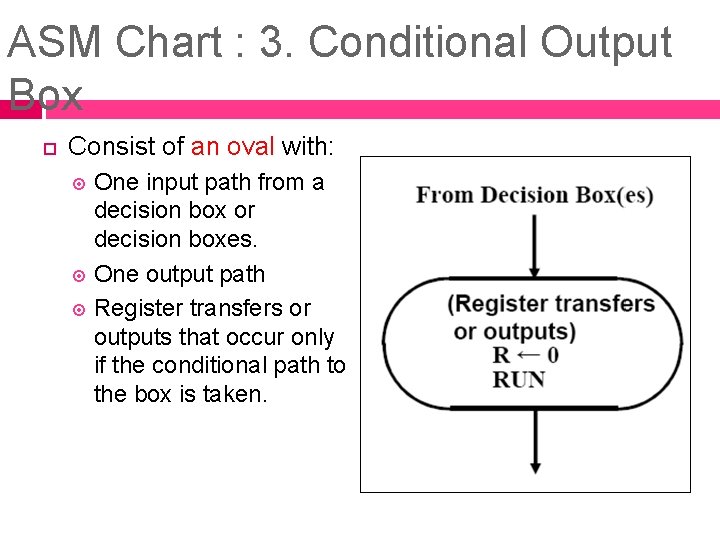
ASM Chart : 3. Conditional Output Box Consist of an oval with: One input path from a decision box or decision boxes. One output path Register transfers or outputs that occur only if the conditional path to the box is taken.
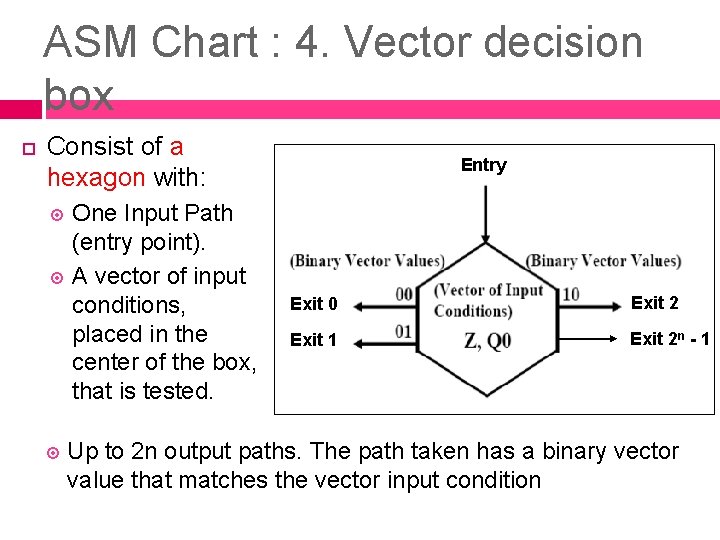
ASM Chart : 4. Vector decision box Consist of a hexagon with: One Input Path (entry point). A vector of input conditions, placed in the center of the box, that is tested. Entry Exit 0 Exit 2 Exit 1 Exit 2 n - 1 Up to 2 n output paths. The path taken has a binary vector value that matches the vector input condition
ASM Chart Transfers and outputs in a state box are Moore type - dependent only on state Transfers and outputs in a conditional output box are Mealy type - dependent on both state and
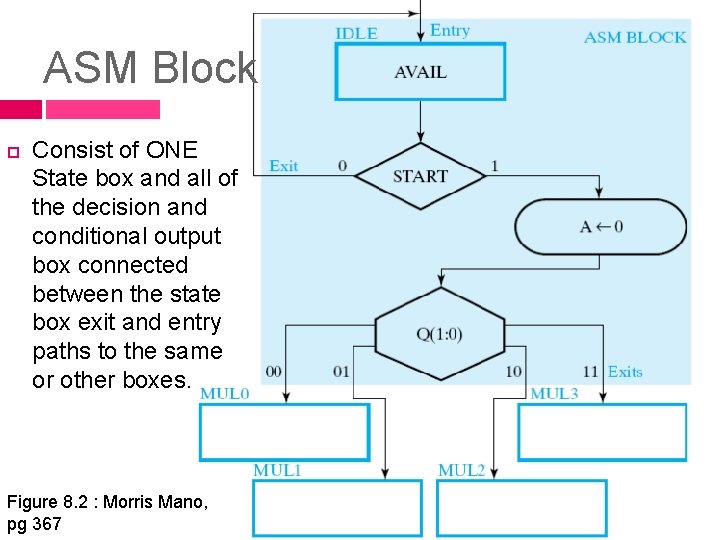
ASM Block Consist of ONE State box and all of the decision and conditional output box connected between the state box exit and entry paths to the same or other boxes. Figure 8. 2 : Morris Mano, pg 367
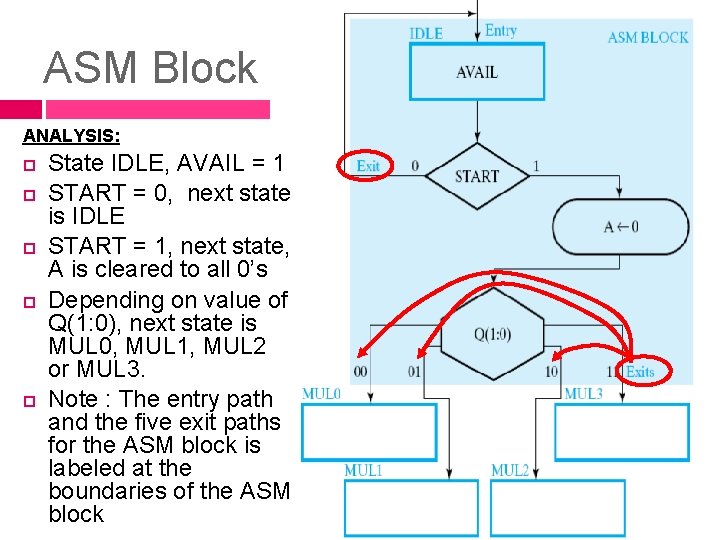
ASM Block ANALYSIS: State IDLE, AVAIL = 1 START = 0, next state is IDLE START = 1, next state, A is cleared to all 0’s Depending on value of Q(1: 0), next state is MUL 0, MUL 1, MUL 2 or MUL 3. Note : The entry path and the five exit paths for the ASM block is labeled at the boundaries of the ASM block
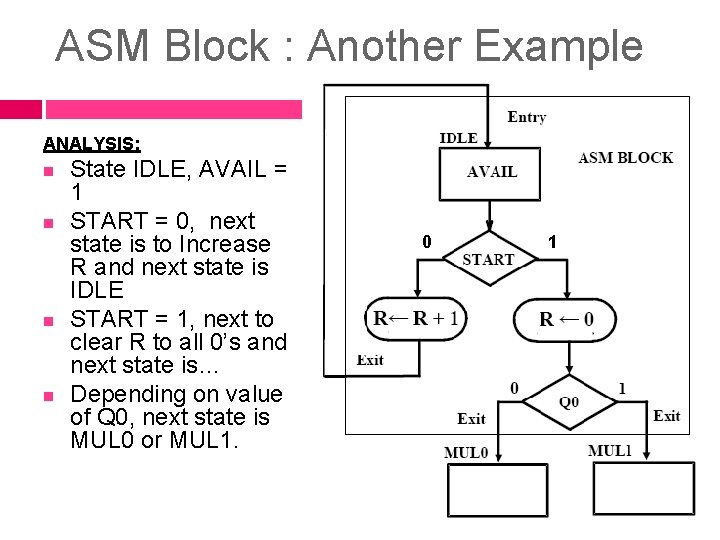
ASM Block : Another Example ANALYSIS: n n State IDLE, AVAIL = 1 START = 0, next state is to Increase R and next state is IDLE START = 1, next to clear R to all 0’s and next state is… Depending on value of Q 0, next state is MUL 0 or MUL 1. 0 1
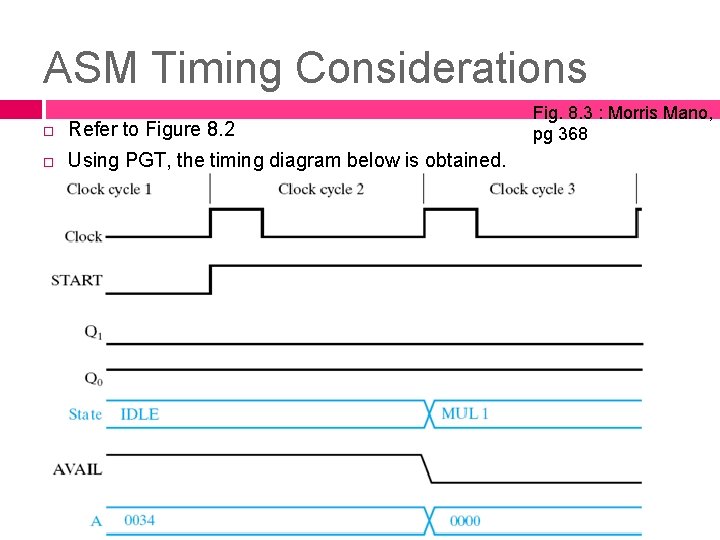
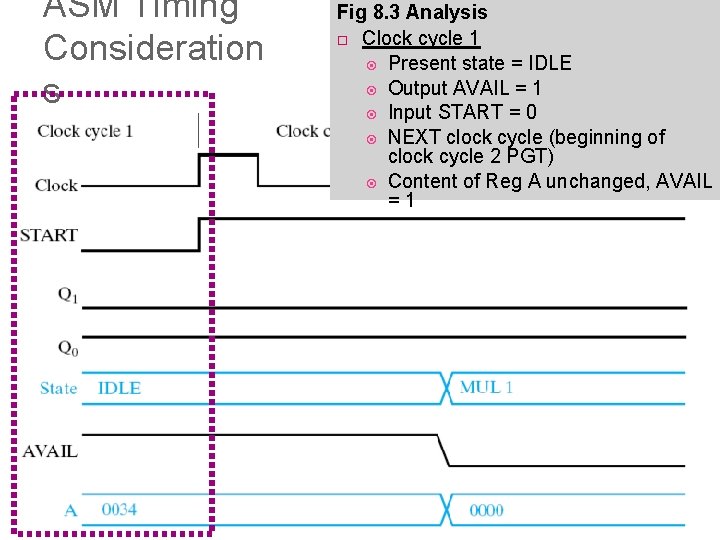
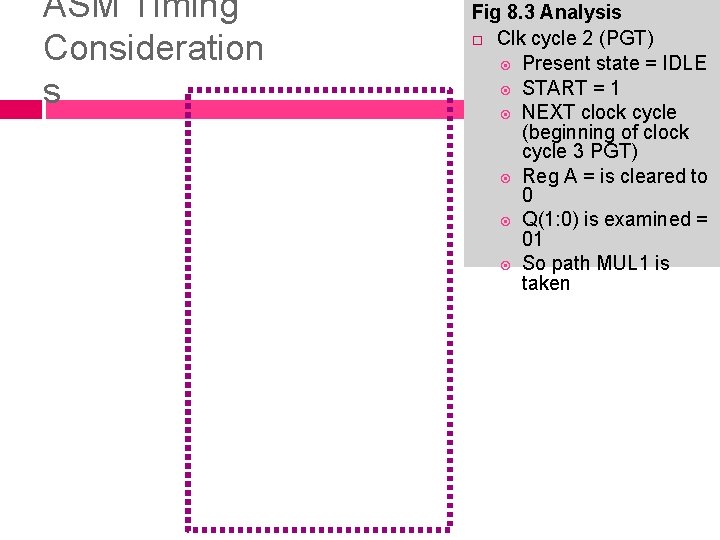
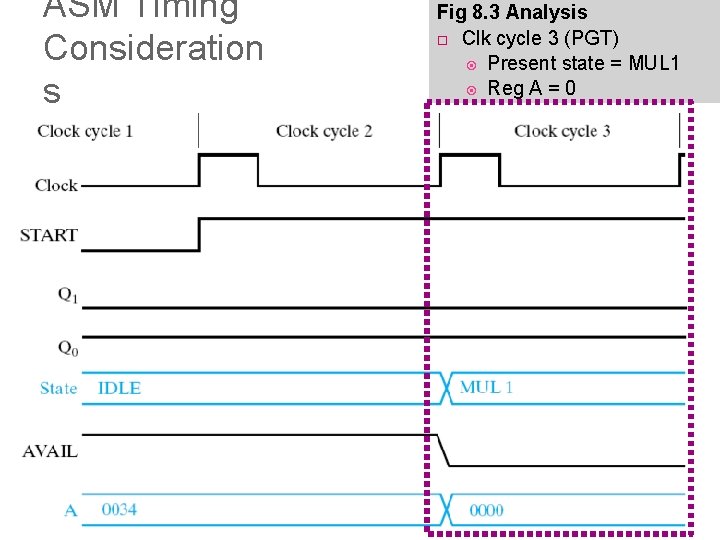
ASM Timing Considerations Refer to Figure 8. 2 Using PGT, the timing diagram below is obtained. Fig. 8. 3 : Morris Mano, pg 368
ASM Timing Consideration s Fig 8. 3 Analysis Clock cycle 1 Present state = IDLE Output AVAIL = 1 Input START = 0 NEXT clock cycle (beginning of clock cycle 2 PGT) Content of Reg A unchanged, AVAIL =1
ASM Timing Consideration s Fig 8. 3 Analysis Clk cycle 2 (PGT) Present state = IDLE START = 1 NEXT clock cycle (beginning of clock cycle 3 PGT) Reg A = is cleared to 0 Q(1: 0) is examined = 01 So path MUL 1 is taken
ASM Timing Consideration s Fig 8. 3 Analysis Clk cycle 3 (PGT) Present state = MUL 1 Reg A = 0
ASM Timing - Conclusion Outputs appear while in the state (in response to state and input values) Register transfers occur at the clock while exiting the state – So, new value occur in the next state!
THANK YOU