
ECE 477 Final Presentation Group 1 Fall 2005
- Slides: 46
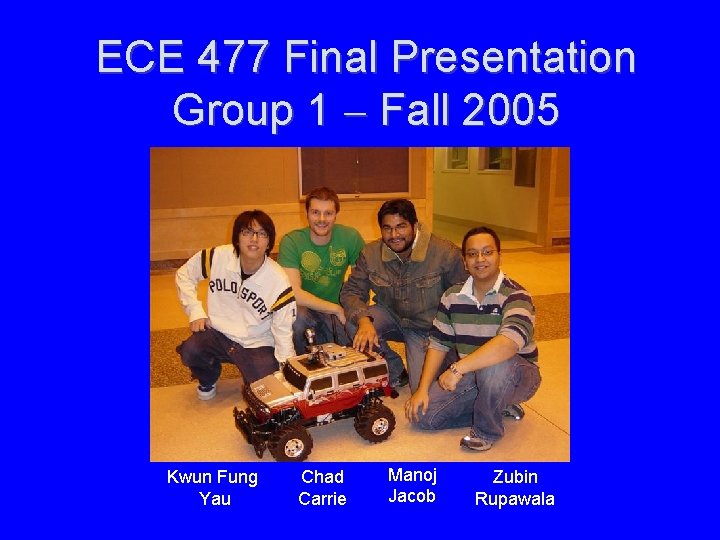
ECE 477 Final Presentation Group 1 Fall 2005 Kwun Fung Yau Chad Carrie Manoj Jacob Zubin Rupawala
Outline • • Project overview Block diagram Professional components Design components Success criteria demonstrations Individual contributions Project summary Questions / discussion
Project Overview • Remote Controlled vehicle with a water cannon mounted on a pan/tilt turret along with a camera • Controller by a remote user at a PC via 802. 11 b Wireless (UDP) and navigated by the video camera • Intuitive PC interface (designed to be controlled like an FPS game – Mouse + WASD) • Sensors mounted on vehicle for obstacle avoidance
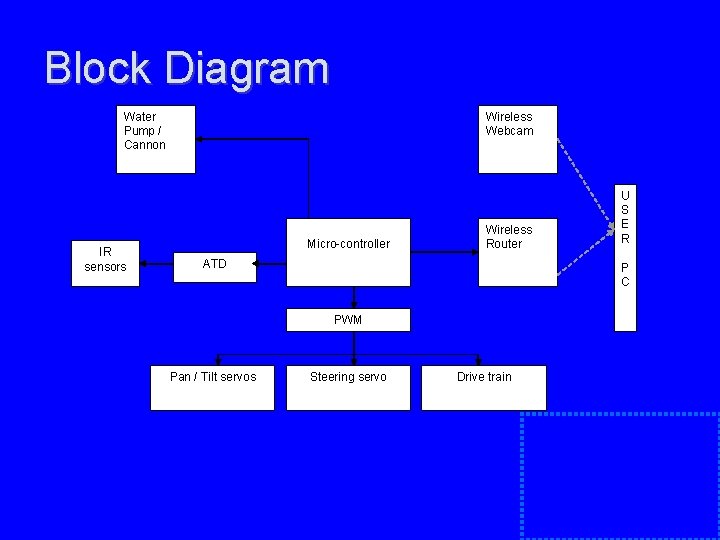
Block Diagram Water Pump / Cannon IR sensors Wireless Webcam Micro-controller Wireless Router ATD P C PWM Pan / Tilt servos U S E R Steering servo Drive train
Professional Components • Constraint analysis and component selection rationale • Patent liability analysis • Reliability and safety analysis • Ethical and environmental impact analysis
Constraint Analysis (Chad) • Power Supply - Large current needs (turned out to need less current than planned) - Several different voltage requirements • Microcontroller – Freescale MC 9 S 12 NE 64 CPV – Code. Warrior – reliable IDE – 80 pins (38 general IO pins) – Built in Ethernet interface – ATD (for analog infrared sensors) – Emulated PWM (motors and servos) – Rabbit RCM 3000 has no ATD! – Can program with BDM
Constraint Analysis (Chad) • Water Pump - Hargraves Advanced Fluidic Solutions LTC W 311 -11 diaphragm pump - 30 psi - planned on 5 feet of water travel - ~ 25 feet of actual water travel • Webcam - Linksys WVC 11 B - Wireless - Capable of 802. 11 b format - Built-in Web Server
Constraint Analysis • Sensors - 6 x Sharp GP 2 Y 0 A 02 YK (~ 4 foot range) (analog) • Battery - 19. 2 VDC battery pack from Hummer H 2 - 12 VDC battery pack, 2400 m. Ah • Pan/Tilt servos – Devantech SR 0 FX - Pre-built for pan and tilt motions - Would have been cheaper and better to build our own
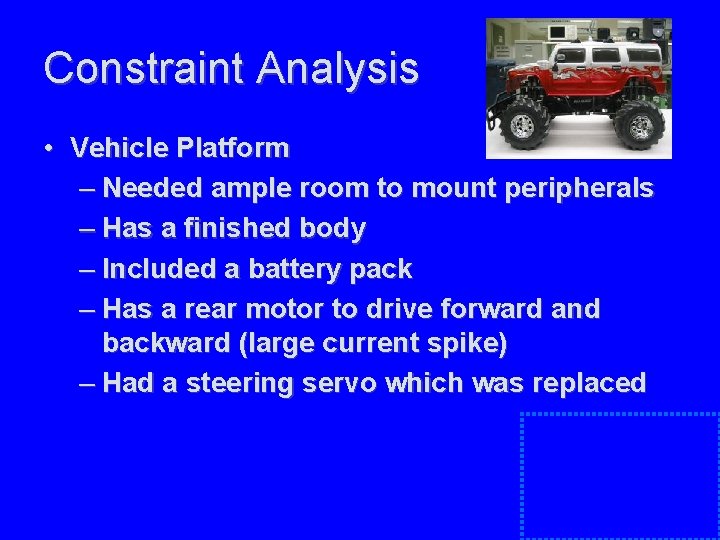
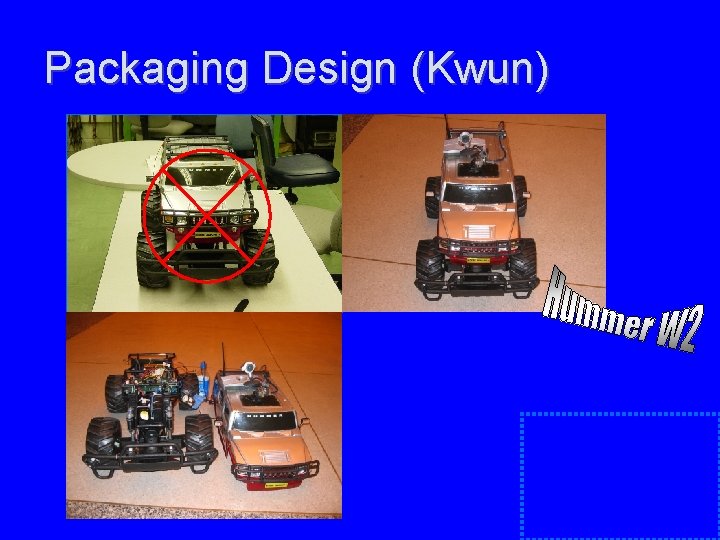
Constraint Analysis • Vehicle Platform – Needed ample room to mount peripherals – Has a finished body – Included a battery pack – Has a rear motor to drive forward and backward (large current spike) – Had a steering servo which was replaced
Patent Liability Analysis (Zubin) • Patents found – # 6, 645, 037 - Programmable toy and game – # 6, 533, 191 - Water projection device and method for projecting water – # 6, 658, 325 - Mobile Robotic with web server and digital radio link – # 6, 845, 297 - Method and system for remote control of mobile robot
Patent Liability Analysis (Zubin) • Literal Infringements – # 6, 658, 325 - Mobile Robotic with web server and digital radio link • Infringements under Doctrine of Equivalents – All others • Shooting water • Keyboard Control • Control Mechanism
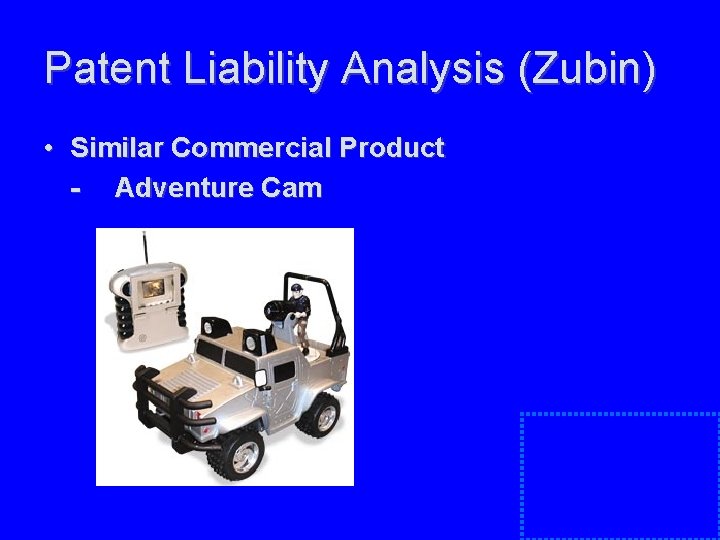
Patent Liability Analysis (Zubin) • Similar Commercial Product - Adventure Cam
Reliability/Safety Analysis (Kwun) • Reliability Analysis (MTTF Analysis) - Freescale MC 9 S 12 NE 64 MCU – 25. 71 years - Vishay SUD 50 DN 02 -06 Power MOSFET for water pump – 17. 85 years - Vishay Si 1865 DL Load Switch for Power Options – 47. 61 years - Ana. Chip AP 1501 A Power Regulator – 773 years
Reliability/Safety Analysis (Kwun) • FMECA - High Criticality (high potential to cause injury) 1. Microcontroller 2. Power 3. Drive Train 4. Wireless bridge and webcam - Low Criticality 1. Water Pump 2. Sensors
Ethical/Environmental Analysis (Manoj) • Warning labels - The 19. 2 V and 12 V battery. - The Pan/Tilt servos - PCB • Example: WARNING: Live Electrical Components. May Cause Shock! In case of problems, take product to manufacturer.
Ethical/Environmental Analysis (Manoj) • Hazard due to water - Secure wires against water - Seal the water tank, pump and pipe against leaks • Battery recharger - Design a battery recharger to plug into the shell
Ethical/Environmental Analysis (Manoj) • Objects entering through the undercarriage - Fitting a plastic plate underneath the Hummer W 2 • Erratic circuit behavior due to low battery charge - Install a voltage monitor • Hummer W 2 will collide with objects and people - Sensors will prevent collision
Ethical/Environmental Analysis (Manoj) • Dangerous chemicals used in PCB fabrication - Use chemicals like Peroxy- Sulfuric acid • Disposal of the Hummer W 2 can pose a problem - Consumers can call Solid & Hazardous Waste Division (801 -538 -6170)
Design Components • • Packaging design considerations Schematic design considerations PCB layout design considerations Software design considerations
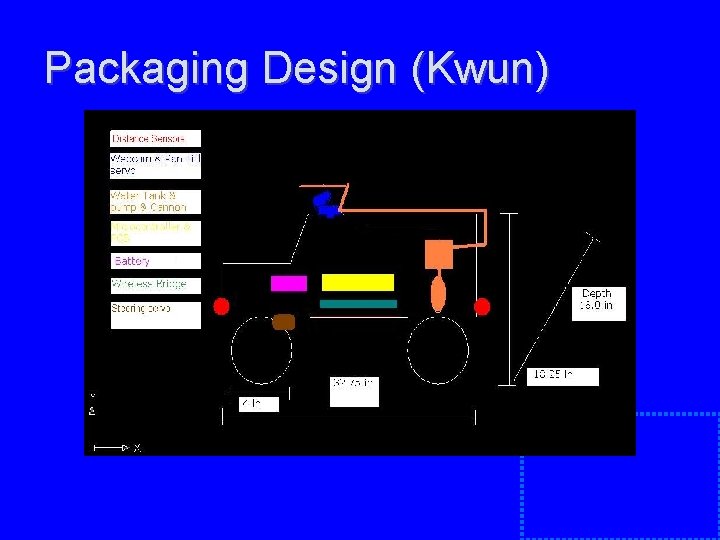
Packaging Design (Kwun)
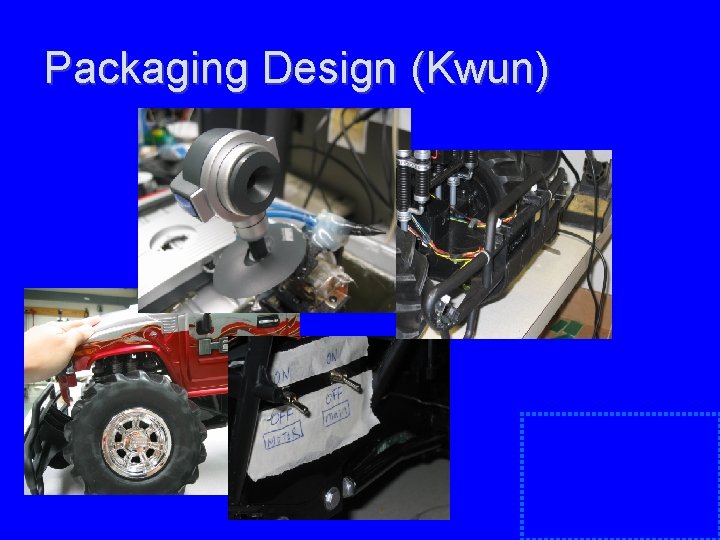
Packaging Design (Kwun)
Packaging Design (Kwun)
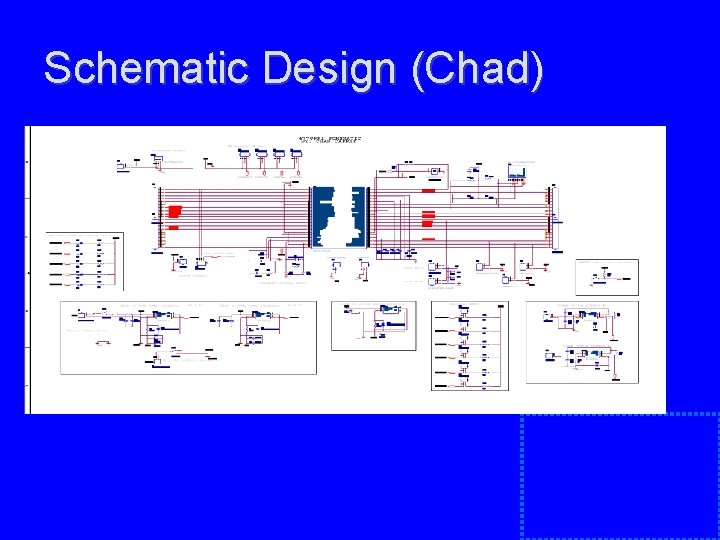
Schematic Design (Chad)
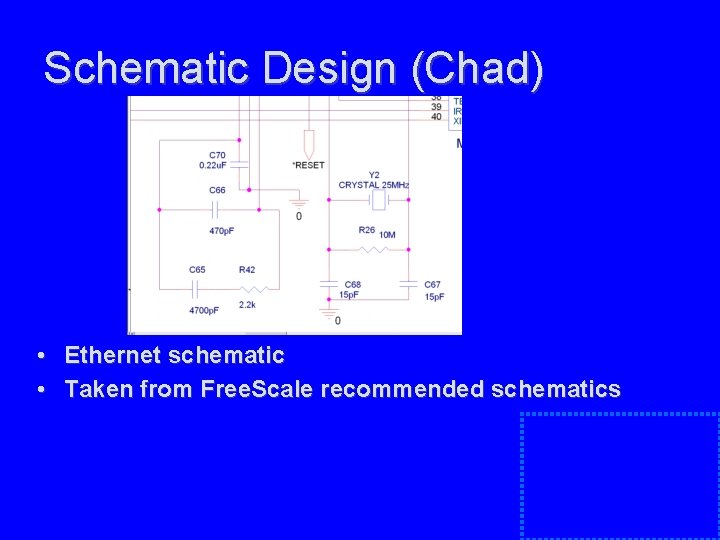
Schematic Design (Chad) • Ethernet schematic • Taken from Free. Scale recommended schematics
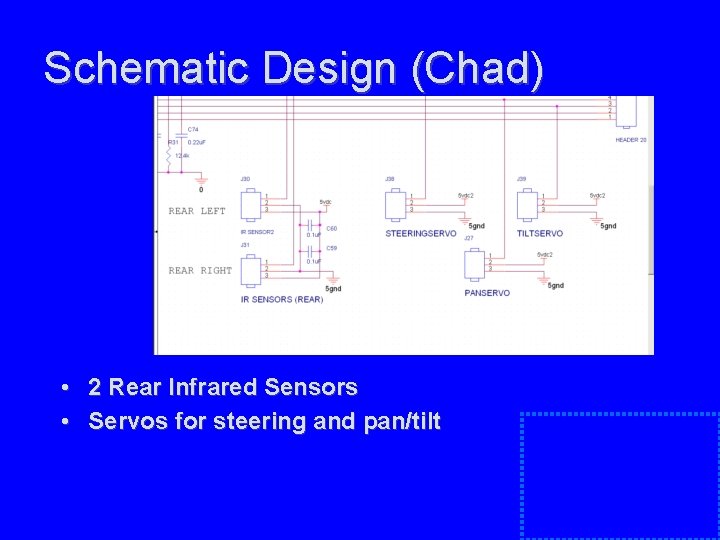
Schematic Design (Chad) • 2 Rear Infrared Sensors • Servos for steering and pan/tilt
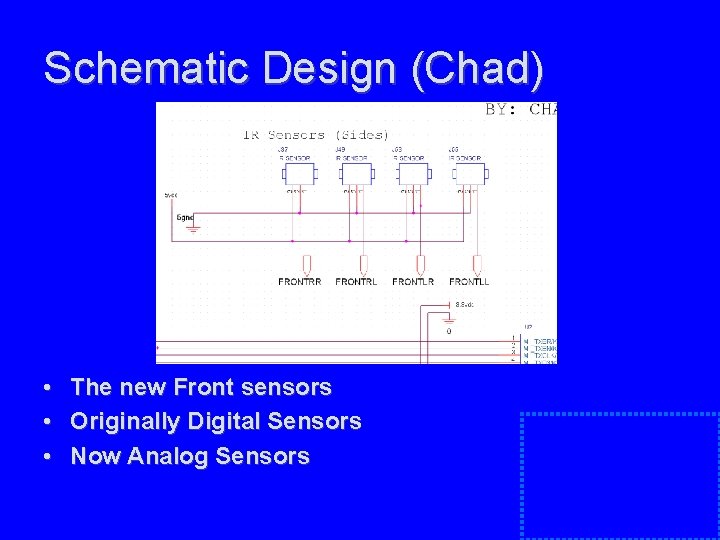
Schematic Design (Chad) • • • The new Front sensors Originally Digital Sensors Now Analog Sensors
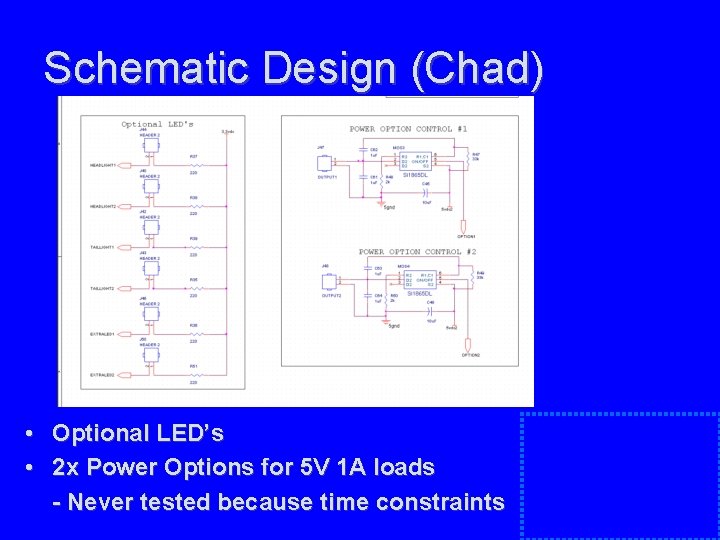
Schematic Design (Chad) • Optional LED’s • 2 x Power Options for 5 V 1 A loads - Never tested because time constraints
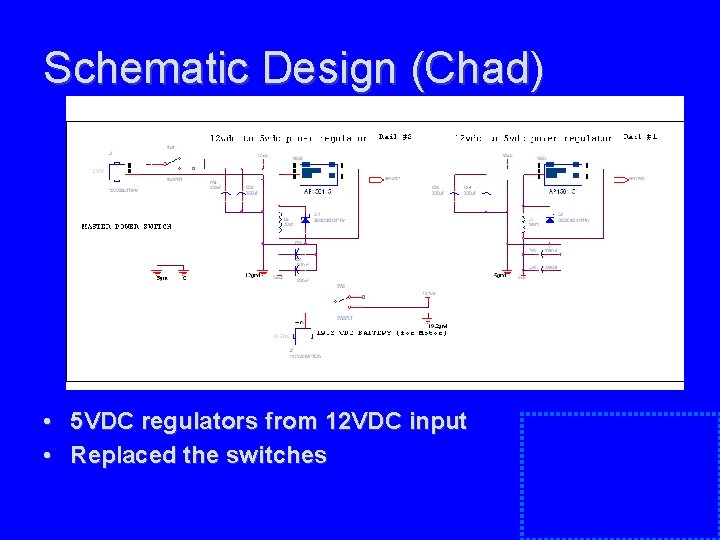
Schematic Design (Chad) • 5 VDC regulators from 12 VDC input • Replaced the switches
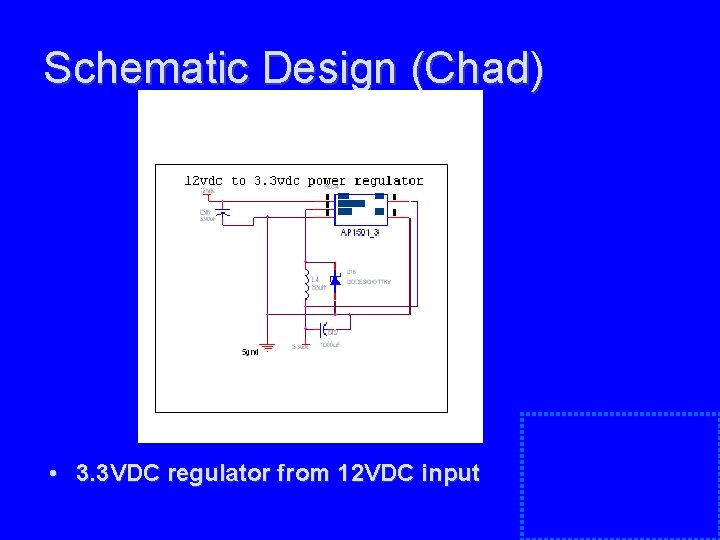
Schematic Design (Chad) • 3. 3 VDC regulator from 12 VDC input
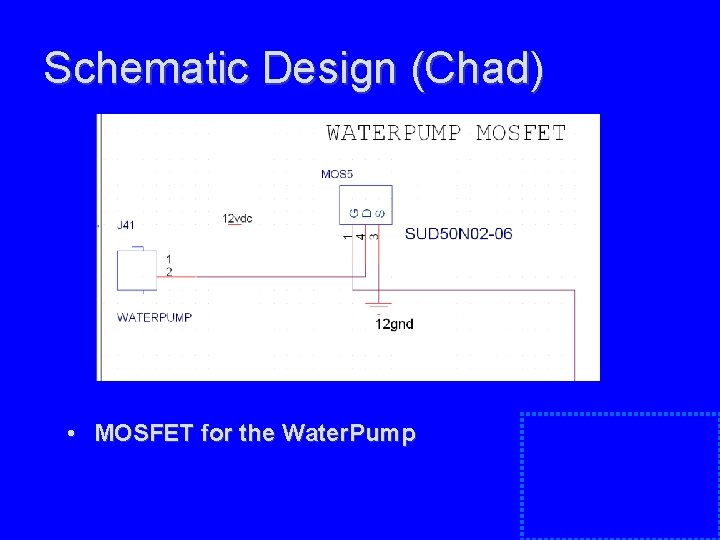
Schematic Design (Chad) • MOSFET for the Water. Pump
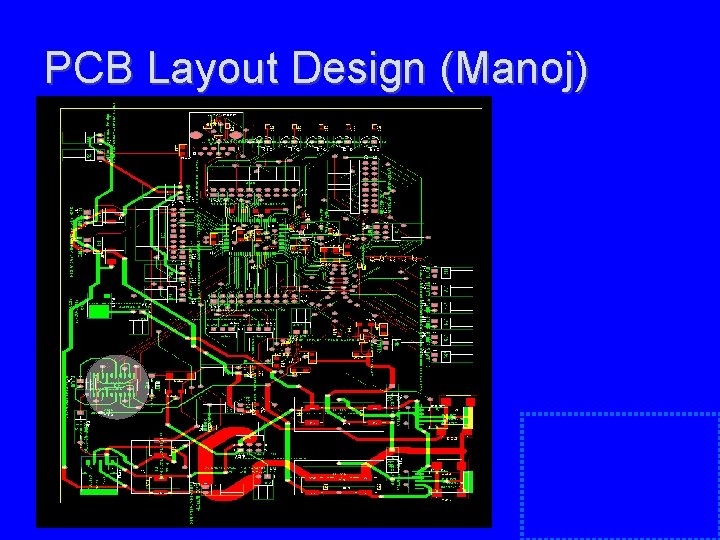
PCB Layout Design (Manoj)
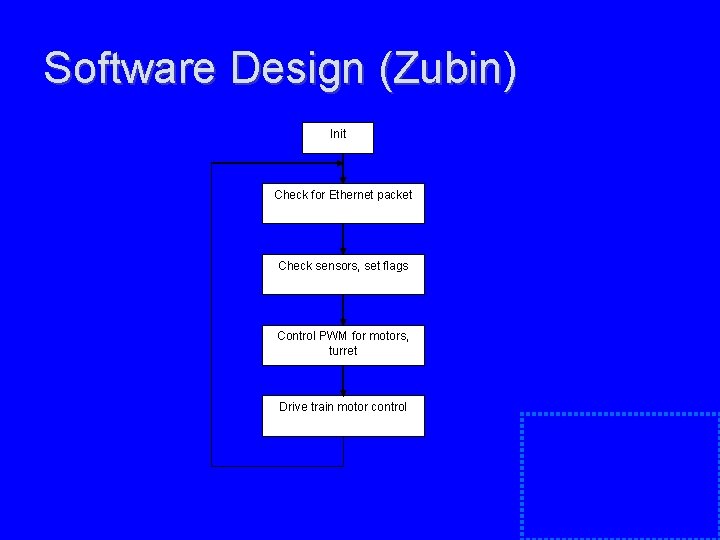
Software Design (Zubin) • Two parts – Microcontroller – PC Interface • Microcontroller – Polling loop – Interfaced to PC via UDP (over Ethernet/wireless) – Using the Open. TCP stack – Used (TIM) Simple PWM for servo motors, ATD for sensors – Fits in 64 KB flash of MC 9 S 12 NE 64
Software Design (Zubin) Init Check for Ethernet packet Check sensors, set flags Control PWM for motors, turret Drive train motor control
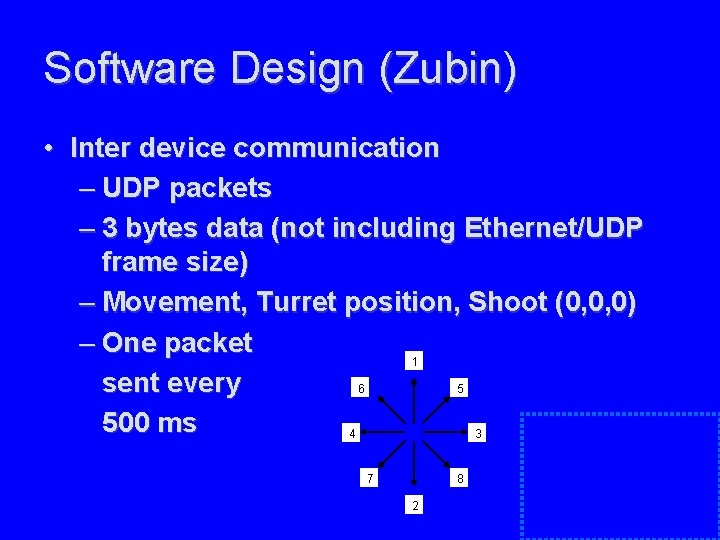
Software Design (Zubin) • Inter device communication – UDP packets – 3 bytes data (not including Ethernet/UDP frame size) – Movement, Turret position, Shoot (0, 0, 0) – One packet 1 sent every 6 5 500 ms 4 3 7 8 2
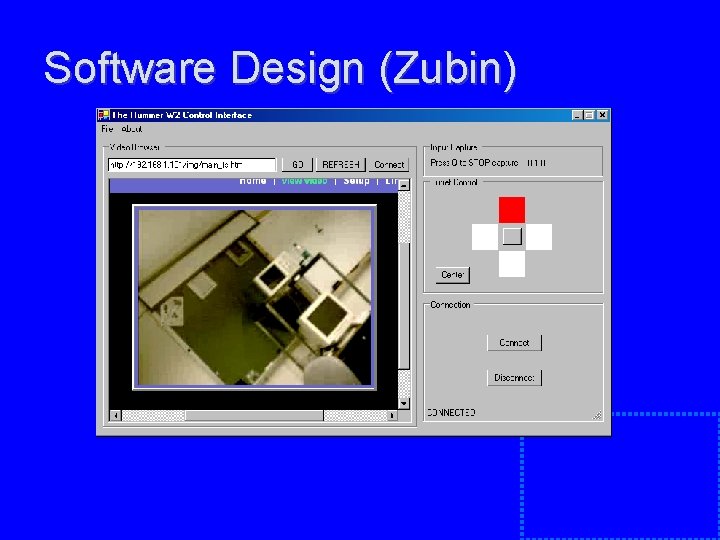
Software Design (Zubin) • PC Interface – Written in Visual Studio. NET with C# – Communicates with Microcontroller via UDP packets – Controls the motors and water cannon – Displays the video from webcam
Software Design (Zubin)
Success Criteria Demonstrations 1. Ability to control vehicle drive train (forward/ reverse/ speed/ turn) - demo 2. Ability to position turret (rotation / elevation) - demo 3. Ability to fire water cannon - demo 4. Ability to avoid collisions - demo 5. Ability to receive/decode UDP stream over Ethernet/wireless to control vehicle, turret and cannon
Individual Contributions • • Team Leader - Chad Carrie Member 2 - Zubin Rupawala Member 3 - Manoj Jacob Member 4 - Kwun Fung Yun
Team Leader – Chad Carrie • • Ordered most of the parts Constraint Analysis Paper Schematic Design Paper Populated the PCB Helped with the PCB Layout Package Construction Repaired after damaging
Member 2 – Zubin Rupawala • Designed entire software logic • Designed the control interface with visual studio. NET (GUI) with C# • Implemented the UDP decode subsystem • Programmed the ATD and TIM modules for sensors and servo motors with help of Manoj and Kwun • Patent Liability • Helped with actual construction • Debugged and Tested system
Member 3 – Manoj Jacob • • • Research on parts required Tested theory of operation Helped with Schematic design PCB design Ethical and Environmental Analysis Helped with Package Construction
Member 4 – Kwun Fung Yau • Designed the user control interface with Visual Studio. NET in C# • Programmed the keyboard and mouse movement logic • Programmed the ATD modules for sensors • Help with debugging • Packaging Design • Reliability and safety analysis • Helped with hardware integration • Order parts • Debugged and Tested system
Project Summary • Important lessons learned – Zip ties and hot glue and proto-boards are essential for prototyping – Ground/power traces should be extra thick – DC motors and current spikes – For prototyping, local sources should be used for parts acquisition – Don’t use ready-made parts (“intelligent” h-bridge, pan/tilt)
Project Summary • Important lessons learnt – Headers are invaluable – Code-warrior/debugging skills – Team work and time-management skills
Project Summary • Second iteration enhancements – Build own H-bridge – Use custom parts (no reverse engineering) – Use better turret (pan/tilt) – Use only one battery – Add more functionality
Questions / Discussion