
CREATION OF DIGITAL SURFACE MODELS USING RESURSP STEREO
- Slides: 18
CREATION OF DIGITAL SURFACE MODELS USING RESURS-P STEREO PAIRS Alexey Peshkun Deputy Head of Department 15 th International Scientific and Technical Conference FROM IMAGERY TO MAP: digital photogrammetric technologies Cancun, Mexico 10. 26. 2015 – 10. 28. 2015
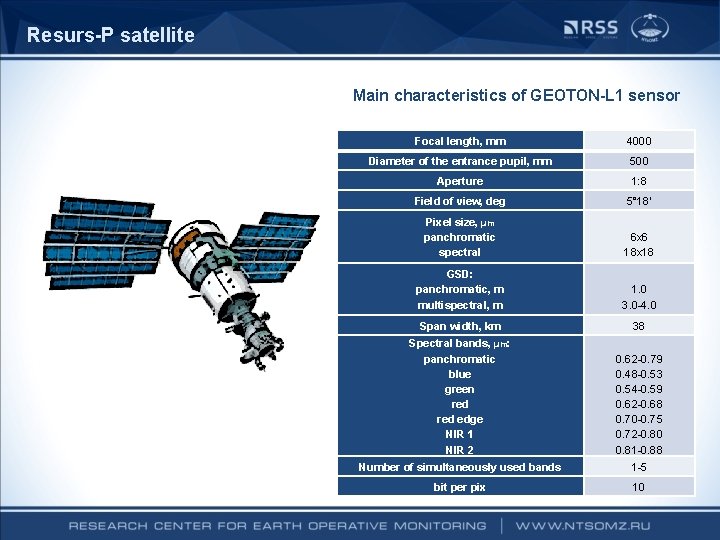
Resurs-P satellite Main characteristics of GEOTON-L 1 sensor Focal length, mm 4000 Diameter of the entrance pupil, mm 500 Aperture 1: 8 Field of view, deg 5° 18’ Pixel size, µm panchromatic spectral 6 х6 18 х18 GSD: panchromatic, m multispectral, m 1. 0 3. 0 -4. 0 Span width, km 38 Spectral bands, µm: panchromatic blue green red edge NIR 1 NIR 2 0. 62 -0. 79 0. 48 -0. 53 0. 54 -0. 59 0. 62 -0. 68 0. 70 -0. 75 0. 72 -0. 80 0. 81 -0. 88 Number of simultaneously used bands 1 -5 bit per pix 10
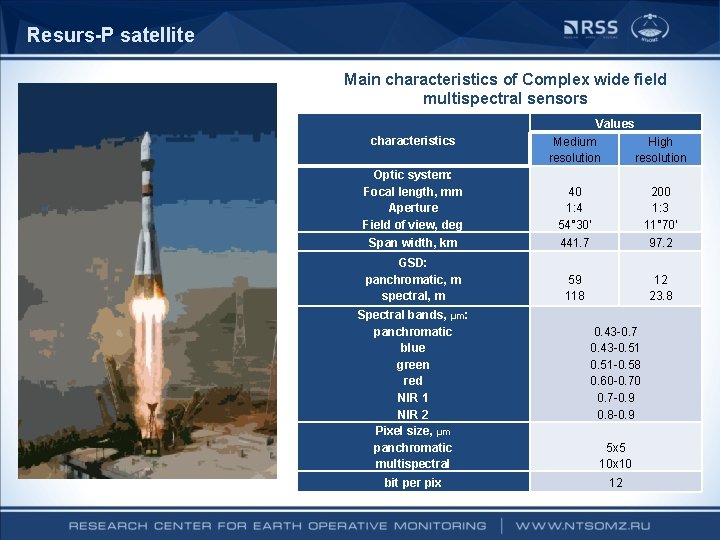
Resurs-P satellite Main characteristics of Complex wide field multispectral sensors characteristics Optic system: Focal length, mm Aperture Field of view, deg Span width, km GSD: panchromatic, m spectral, m Values Medium High resolution 40 200 1: 4 1: 3 54° 30’ 11° 70’ 441. 7 97. 2 59 118 12 23. 8 Spectral bands, µm: panchromatic blue green red NIR 1 NIR 2 Pixel size, µm panchromatic multispectral 0. 43 -0. 7 0. 43 -0. 51 -0. 58 0. 60 -0. 70 0. 7 -0. 9 0. 8 -0. 9 5 х5 10 х10 bit per pix 12
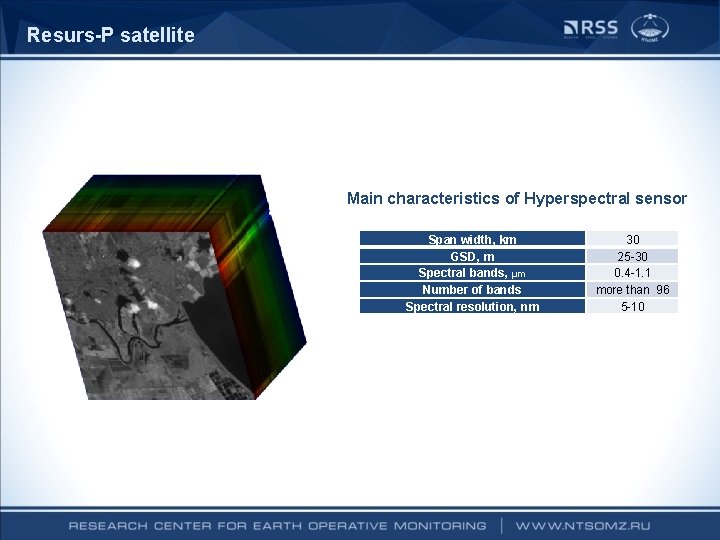
Resurs-P satellite Main characteristics of Hyperspectral sensor Span width, km GSD, m Spectral bands, µm Number of bands Spectral resolution, nm 30 25 -30 0. 4 -1. 1 more than 96 5 -10
Resurs-P satellite Orbit parameters Type circular sun-synchronous Height, km 475 Inclination, deg 97. 28 Revisit time, days 3 Orbital period, min 94
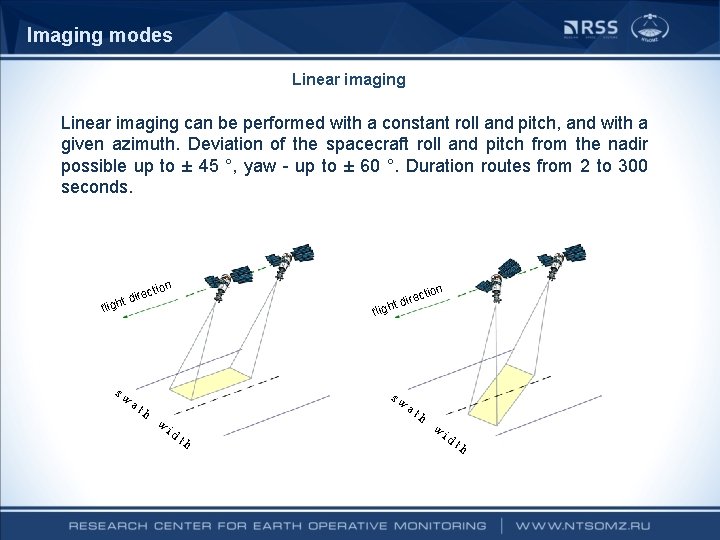
Imaging modes Linear imaging can be performed with a constant roll and pitch, and with a given azimuth. Deviation of the spacecraft roll and pitch from the nadir possible up to ± 45 °, yaw - up to ± 60 °. Duration routes from 2 to 300 seconds. on cti dire t h g ire ht d fli sw at h flig sw w n ctio id th at h w id th
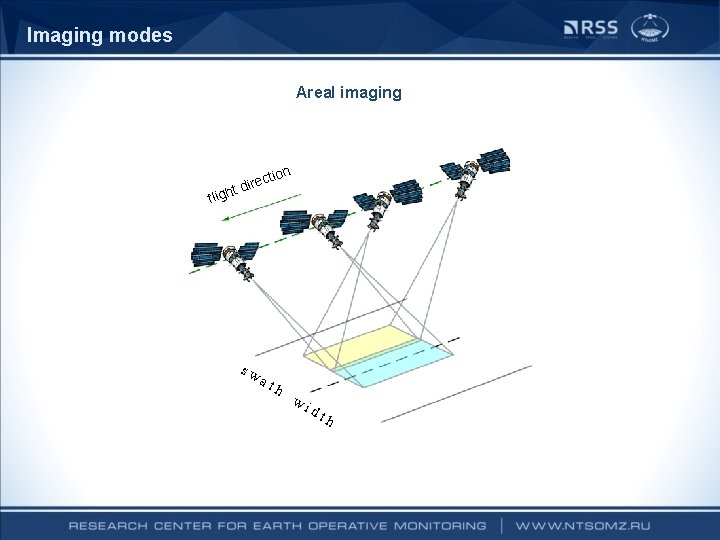
Imaging modes Areal imaging tion irec ht d flig sw at h wi dt h
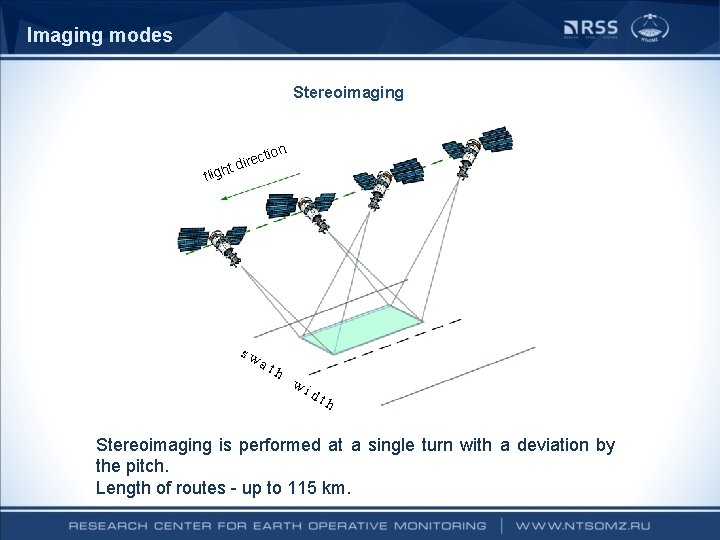
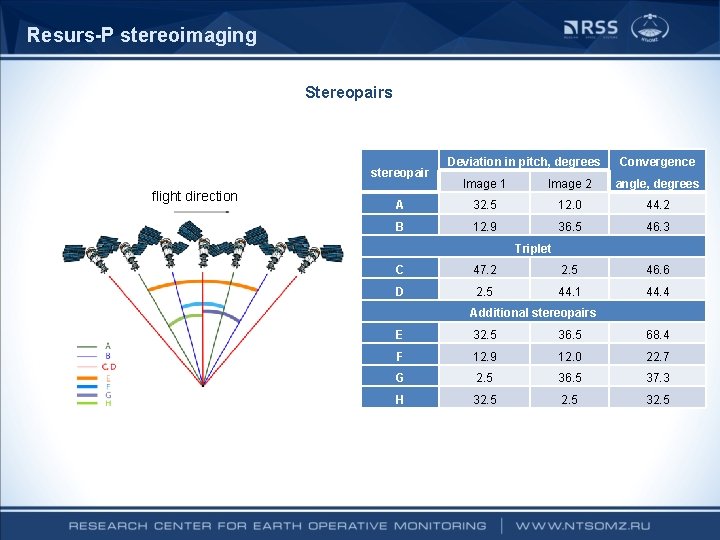
Imaging modes Stereoimaging c dire t h flig sw tion at h wi dt h Stereoimaging is performed at a single turn with a deviation by the pitch. Length of routes - up to 115 km.
Resurs-P stereoimaging Stereopairs stereopair flight direction Deviation in pitch, degrees Convergence Image 1 Image 2 angle, degrees A 32. 5 12. 0 44. 2 B 12. 9 36. 5 46. 3 Triplet C 47. 2 2. 5 46. 6 D 2. 5 44. 1 44. 4 Additional stereopairs E 32. 5 36. 5 68. 4 F 12. 9 12. 0 22. 7 G 2. 5 36. 5 37. 3 H 32. 5
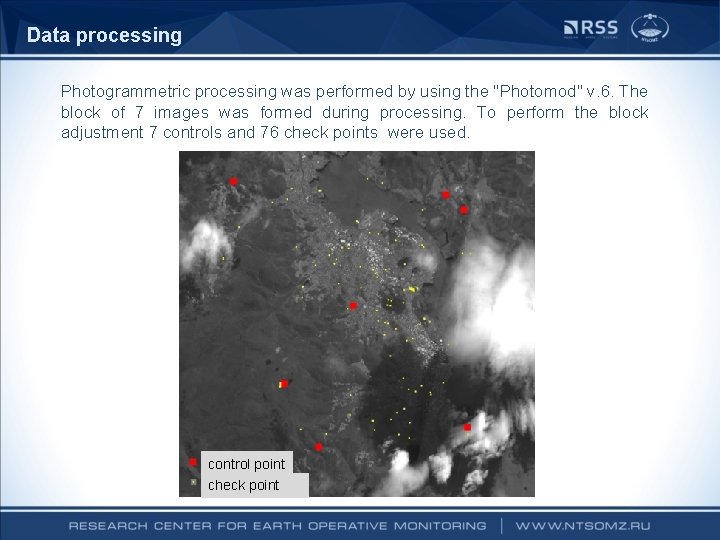
Data processing Photogrammetric processing was performed by using the "Photomod" v. 6. The block of 7 images was formed during processing. To perform the block adjustment 7 controls and 76 check points were used. control point check point
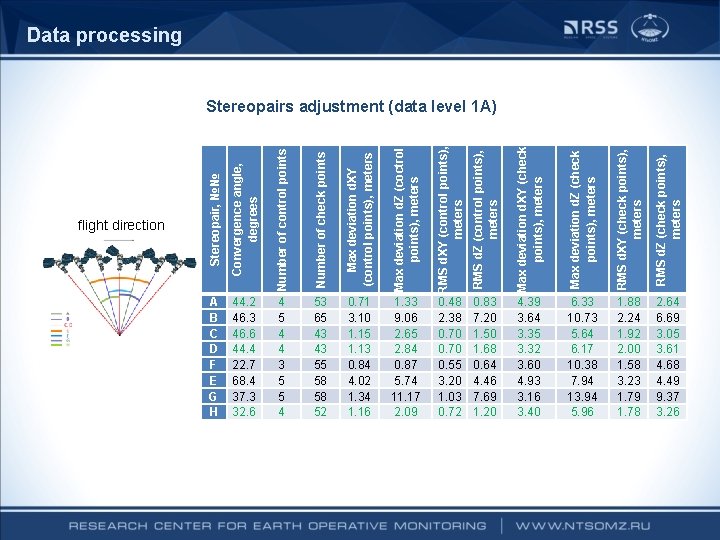
Data processing Convergence angle, degrees Number of control points Number of check points Max deviation d. XY (control points), meters Max deviation d. Z (coctrol points), meters RMS d. XY (control points), meters RMS d. Z (control points), meters Max deviation d. XY (check points), meters Max deviation d. Z (check points), meters RMS d. XY (check points), meters RMS d. Z (check points), meters flight direction Stereopair, №№ Stereopairs adjustment (data level 1 А) A B C D F E G H 44. 2 46. 3 46. 6 44. 4 22. 7 68. 4 37. 3 32. 6 4 5 4 4 3 5 5 4 53 65 43 43 55 58 58 52 0. 71 3. 10 1. 15 1. 13 0. 84 4. 02 1. 34 1. 16 1. 33 9. 06 2. 65 2. 84 0. 87 5. 74 11. 17 2. 09 0. 48 2. 38 0. 70 0. 55 3. 20 1. 03 0. 72 0. 83 7. 20 1. 50 1. 68 0. 64 4. 46 7. 69 1. 20 4. 39 3. 64 3. 35 3. 32 3. 60 4. 93 3. 16 3. 40 6. 33 10. 73 5. 64 6. 17 10. 38 7. 94 13. 94 5. 96 1. 88 2. 24 1. 92 2. 00 1. 58 3. 23 1. 79 1. 78 2. 64 6. 69 3. 05 3. 61 4. 68 4. 49 9. 37 3. 26
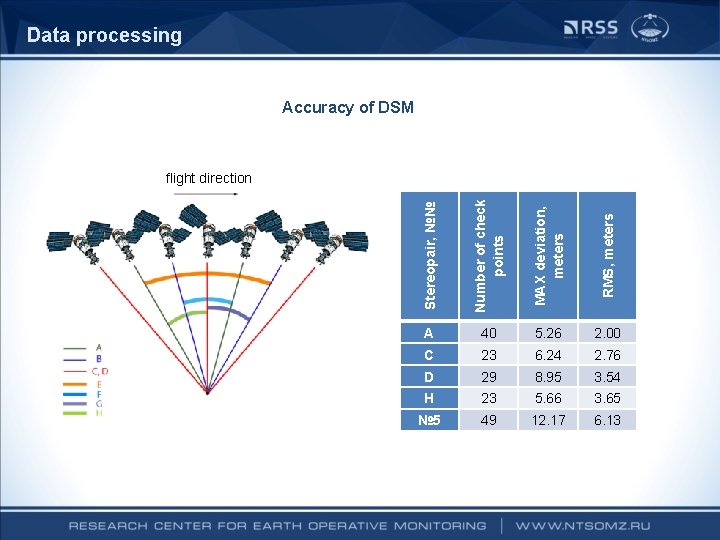
Data processing Accuracy of DSM Stereopair, №№ Number of check points MAX deviation, meters RMS, meters flight direction A 40 5. 26 2. 00 C 23 6. 24 2. 76 D 29 8. 95 3. 54 H 23 5. 66 3. 65 № 5 49 12. 17 6. 13
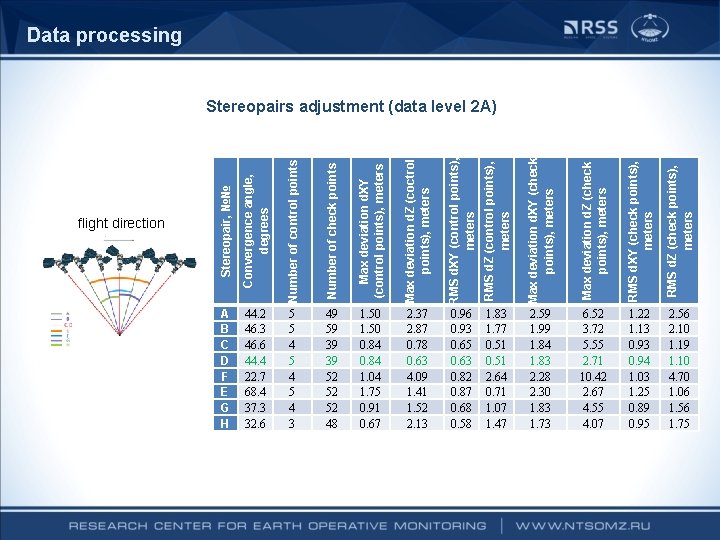
Data processing Convergence angle, degrees Number of control points Number of check points Max deviation d. XY (control points), meters Max deviation d. Z (coctrol points), meters RMS d. XY (control points), meters RMS d. Z (control points), meters Max deviation d. XY (check points), meters Max deviation d. Z (check points), meters RMS d. XY (check points), meters RMS d. Z (check points), meters flight direction Stereopair, №№ Stereopairs adjustment (data level 2 А) A B C D F E G H 44. 2 46. 3 46. 6 44. 4 22. 7 68. 4 37. 3 32. 6 5 5 4 5 4 3 49 59 39 39 52 52 52 48 1. 50 0. 84 1. 04 1. 75 0. 91 0. 67 2. 37 2. 87 0. 78 0. 63 4. 09 1. 41 1. 52 2. 13 0. 96 0. 93 0. 65 0. 63 0. 82 0. 87 0. 68 0. 58 1. 83 1. 77 0. 51 2. 64 0. 71 1. 07 1. 47 2. 59 1. 99 1. 84 1. 83 2. 28 2. 30 1. 83 1. 73 6. 52 3. 72 5. 55 2. 71 10. 42 2. 67 4. 55 4. 07 1. 22 1. 13 0. 94 1. 03 1. 25 0. 89 0. 95 2. 56 2. 10 1. 19 1. 10 4. 70 1. 06 1. 56 1. 75
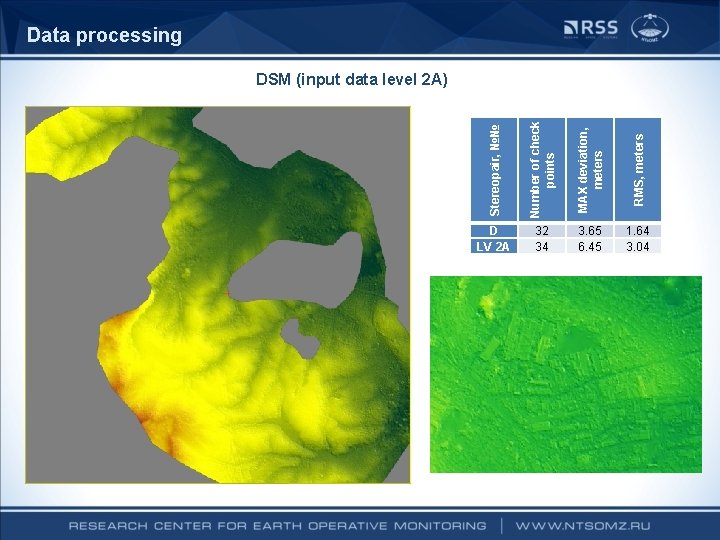
Data processing Stereopair, №№ Number of check points MAX deviation, meters RMS, meters DSM (input data level 2 A) D LV 2 А 32 34 3. 65 6. 45 1. 64 3. 04
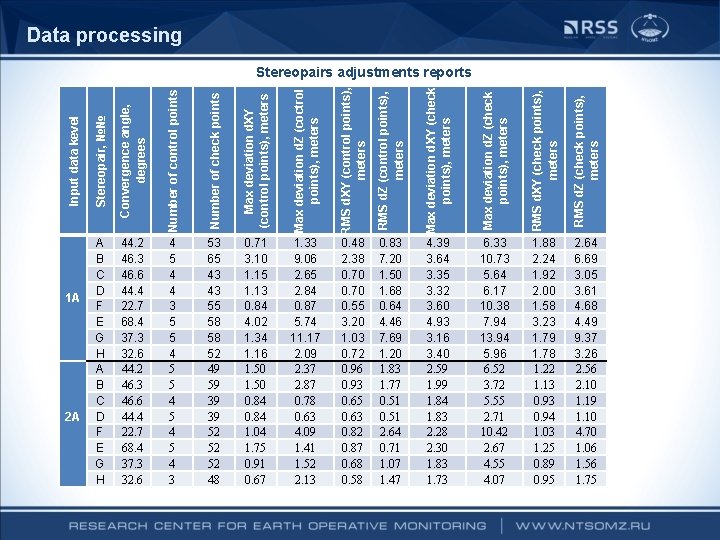
Data processing Number of control points Number of check points Max deviation d. XY (control points), meters Max deviation d. Z (coctrol points), meters RMS d. XY (control points), meters RMS d. Z (control points), meters Max deviation d. XY (check points), meters Max deviation d. Z (check points), meters RMS d. XY (check points), meters RMS d. Z (check points), meters 2 A Convergence angle, degrees 1 A Stereopair, №№ Input data kevel Stereopairs adjustments reports A B C D F E G H 44. 2 46. 3 46. 6 44. 4 22. 7 68. 4 37. 3 32. 6 4 5 4 4 3 5 5 4 5 4 3 53 65 43 43 55 58 58 52 49 59 39 39 52 52 52 48 0. 71 3. 10 1. 15 1. 13 0. 84 4. 02 1. 34 1. 16 1. 50 0. 84 1. 04 1. 75 0. 91 0. 67 1. 33 9. 06 2. 65 2. 84 0. 87 5. 74 11. 17 2. 09 2. 37 2. 87 0. 78 0. 63 4. 09 1. 41 1. 52 2. 13 0. 48 2. 38 0. 70 0. 55 3. 20 1. 03 0. 72 0. 96 0. 93 0. 65 0. 63 0. 82 0. 87 0. 68 0. 58 0. 83 7. 20 1. 50 1. 68 0. 64 4. 46 7. 69 1. 20 1. 83 1. 77 0. 51 2. 64 0. 71 1. 07 1. 47 4. 39 3. 64 3. 35 3. 32 3. 60 4. 93 3. 16 3. 40 2. 59 1. 99 1. 84 1. 83 2. 28 2. 30 1. 83 1. 73 6. 33 10. 73 5. 64 6. 17 10. 38 7. 94 13. 94 5. 96 6. 52 3. 72 5. 55 2. 71 10. 42 2. 67 4. 55 4. 07 1. 88 2. 24 1. 92 2. 00 1. 58 3. 23 1. 79 1. 78 1. 22 1. 13 0. 94 1. 03 1. 25 0. 89 0. 95 2. 64 6. 69 3. 05 3. 61 4. 68 4. 49 9. 37 3. 26 2. 56 2. 10 1. 19 1. 10 4. 70 1. 06 1. 56 1. 75
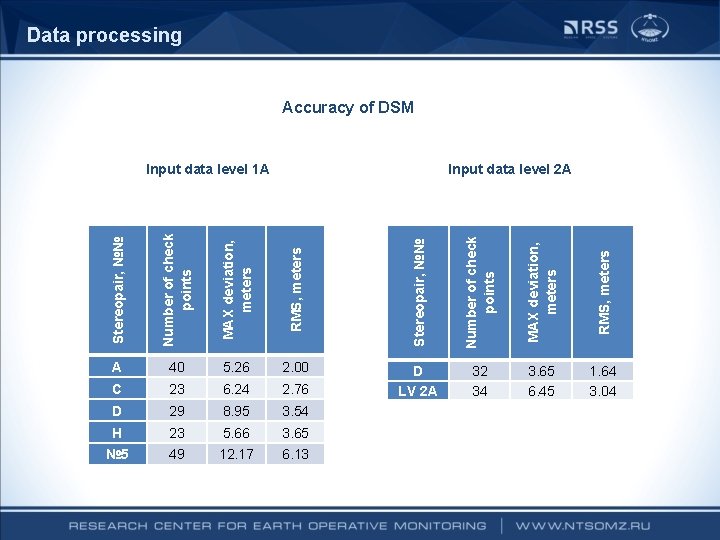
Data processing Accuracy of DSM 2. 00 C 23 6. 24 2. 76 D 29 8. 95 3. 54 H 23 5. 66 3. 65 № 5 49 12. 17 6. 13 RMS, meters 5. 26 MAX deviation, meters RMS, meters 40 Number of check points MAX deviation, meters A Stereopair, №№ Number of check points Input data level 2 А Stereopair, №№ Input data level 1 А D LV 2 А 32 34 3. 65 6. 45 1. 64 3. 04
Thank you for attention!