
CONFIGURATION SPACE Theorem Kempe 1876 A linkage is
- Slides: 11
CONFIGURATION SPACE Theorem (Kempe 1876) A linkage is a graph with fixed lengths for the edges (or bars); some of the vertices may have fixed locations in the plane. A configuration is an embedding of the graph into the plane which satisfies the bar-length and fixed-vertex constraints There is a linkage which signs your name, iff your name is any compact subset of Rd This means that there is a vertex in the linkage whose locus of possible positions in all configurations is exactly f(x, y)=0.
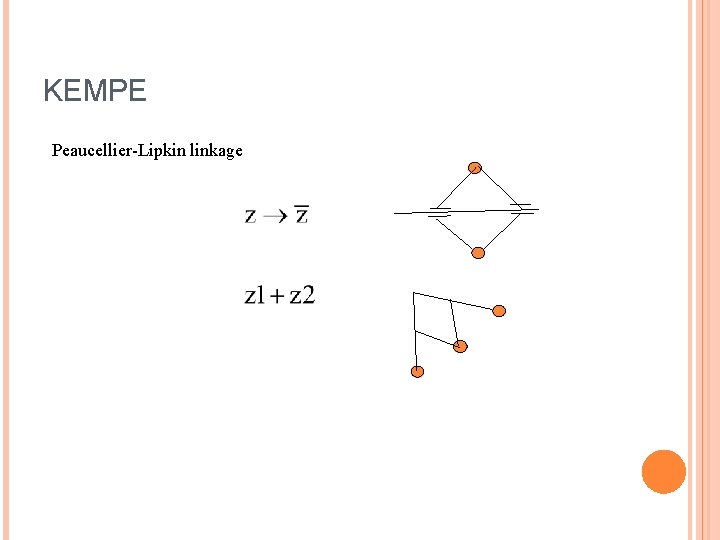
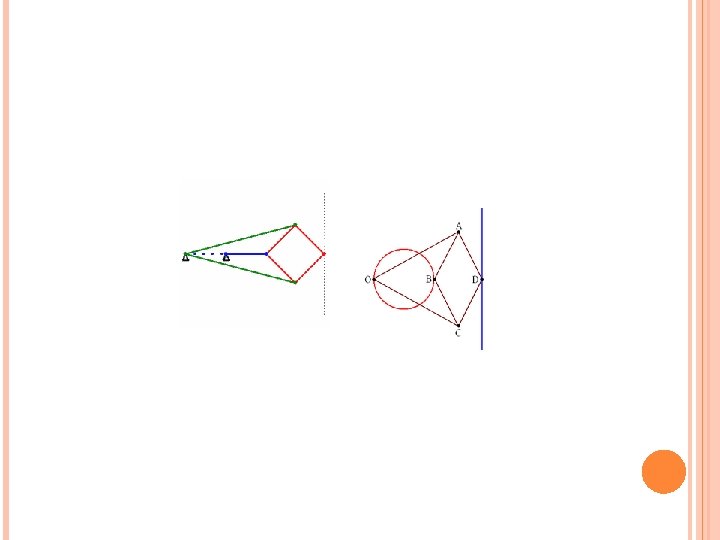
KEMPE Peaucellier-Lipkin linkage
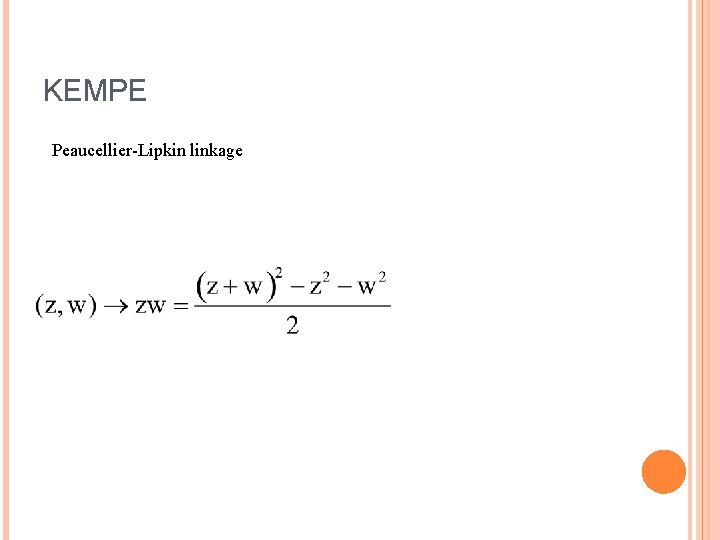
KEMPE Peaucellier-Lipkin linkage
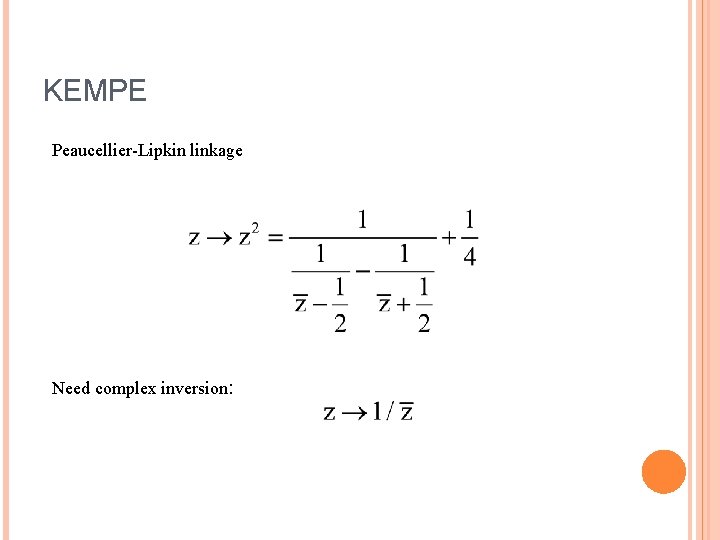
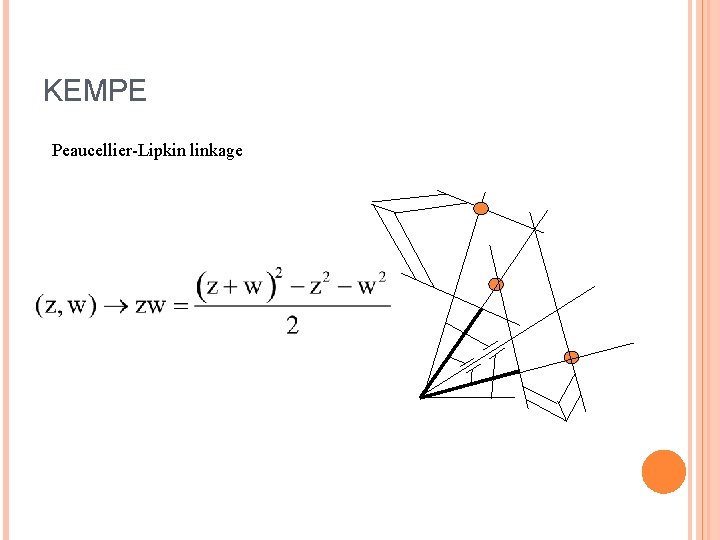
KEMPE Peaucellier-Lipkin linkage Need complex inversion:
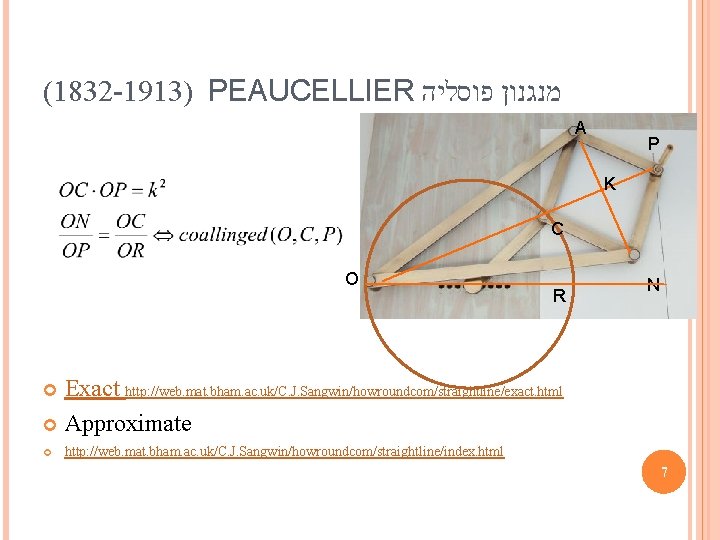
(1832 -1913) PEAUCELLIER מנגנון פוסליה A P K C O R N Exact http: //web. mat. bham. ac. uk/C. J. Sangwin/howroundcom/straightline/exact. html Approximate http: //web. mat. bham. ac. uk/C. J. Sangwin/howroundcom/straightline/index. html 7
KEMPE Peaucellier-Lipkin linkage
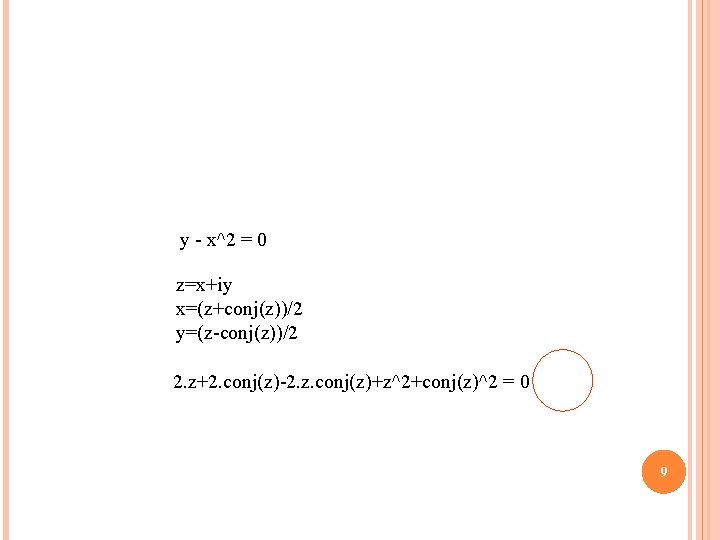
C-Space as a Pullback y - x^2 = 0 z=x+iy x=(z+conj(z))/2 y=(z-conj(z))/2 2. z+2. conj(z)-2. z. conj(z)+z^2+conj(z)^2 = 0 9
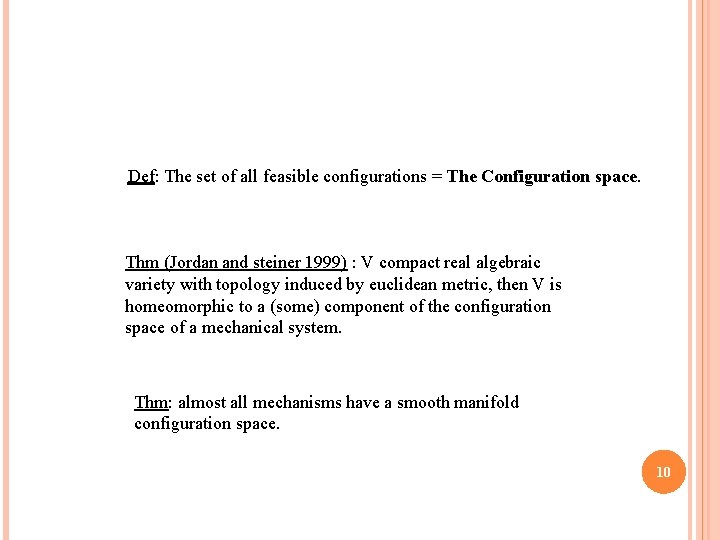
C-Space as a Pullback Def: The set of all feasible configurations = The Configuration space. Thm (Jordan and steiner 1999) : V compact real algebraic variety with topology induced by euclidean metric, then V is homeomorphic to a (some) component of the configuration space of a mechanical system. Thm: almost all mechanisms have a smooth manifold configuration space. 10
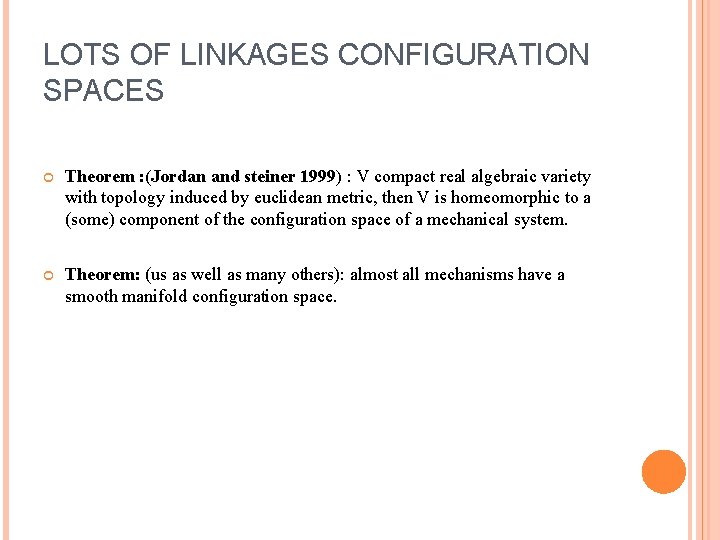
LOTS OF LINKAGES CONFIGURATION SPACES Theorem : (Jordan and steiner 1999) : V compact real algebraic variety with topology induced by euclidean metric, then V is homeomorphic to a (some) component of the configuration space of a mechanical system. Theorem: (us as well as many others): almost all mechanisms have a smooth manifold configuration space.