
Camera Stabilization Marit Brocker Mitchell Cook Caleb Disbrow
Camera Stabilization Marit Brocker ● Mitchell Cook ● Caleb Disbrow ● Alex Wilson 1

Agenda ● Reintroduction o o Needs Specifications ● Components and Design ● Risks ● Testing 2
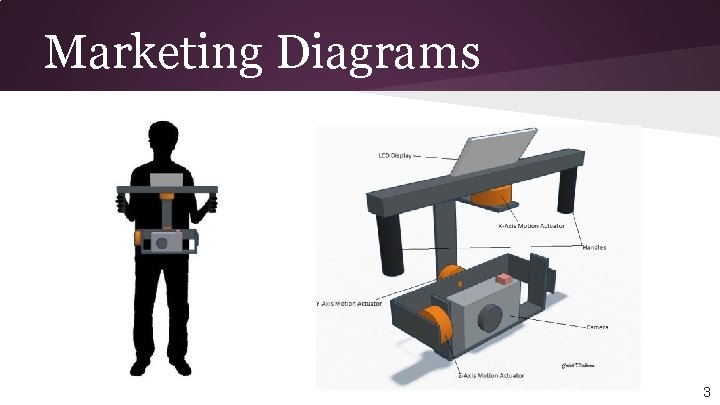
Marketing Diagrams 3
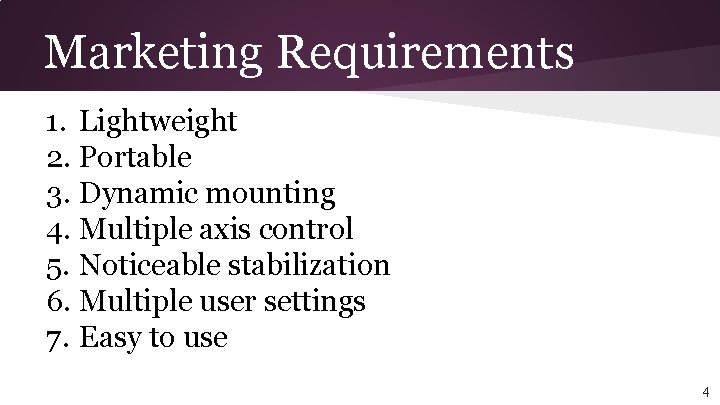
Marketing Requirements 1. Lightweight 2. Portable 3. Dynamic mounting 4. Multiple axis control 5. Noticeable stabilization 6. Multiple user settings 7. Easy to use 4
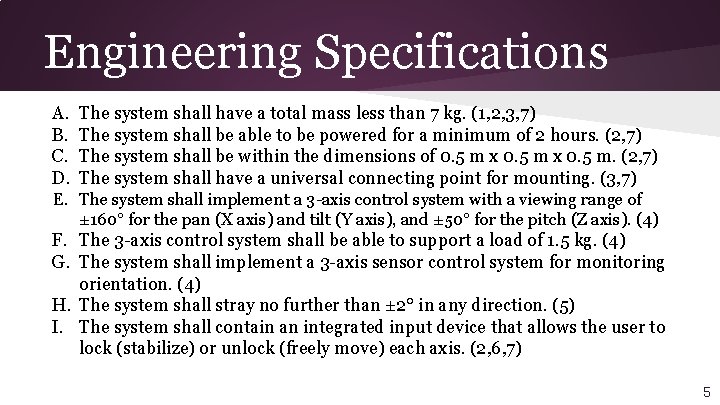
Engineering Specifications A. B. C. D. The system shall have a total mass less than 7 kg. (1, 2, 3, 7) The system shall be able to be powered for a minimum of 2 hours. (2, 7) The system shall be within the dimensions of 0. 5 m x 0. 5 m. (2, 7) The system shall have a universal connecting point for mounting. (3, 7) E. The system shall implement a 3 -axis control system with a viewing range of ± 160° for the pan (X axis) and tilt (Y axis), and ± 50° for the pitch (Z axis). (4) F. The 3 -axis control system shall be able to support a load of 1. 5 kg. (4) G. The system shall implement a 3 -axis sensor control system for monitoring orientation. (4) H. The system shall stray no further than ± 2° in any direction. (5) I. The system shall contain an integrated input device that allows the user to lock (stabilize) or unlock (freely move) each axis. (2, 6, 7) 5
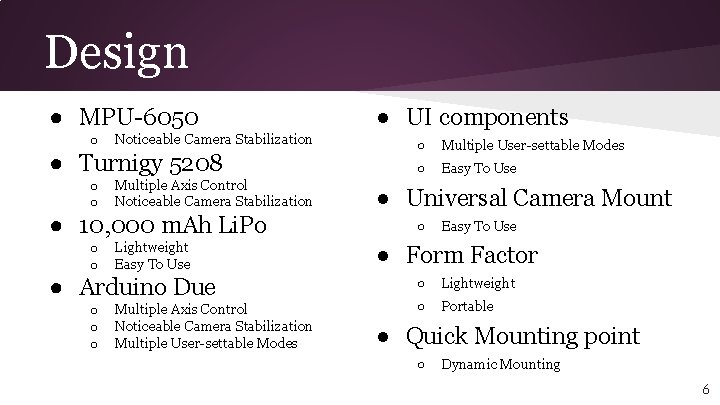
Design ● MPU-6050 o Noticeable Camera Stabilization ● Turnigy 5208 o o Multiple Axis Control Noticeable Camera Stabilization ● 10, 000 m. Ah Li. Po o o Lightweight Easy To Use ● Arduino Due o o o Multiple Axis Control Noticeable Camera Stabilization Multiple User-settable Modes ● UI components ○ Multiple User-settable Modes ○ Easy To Use ● Universal Camera Mount ○ Easy To Use ● Form Factor ○ Lightweight ○ Portable ● Quick Mounting point ○ Dynamic Mounting 6
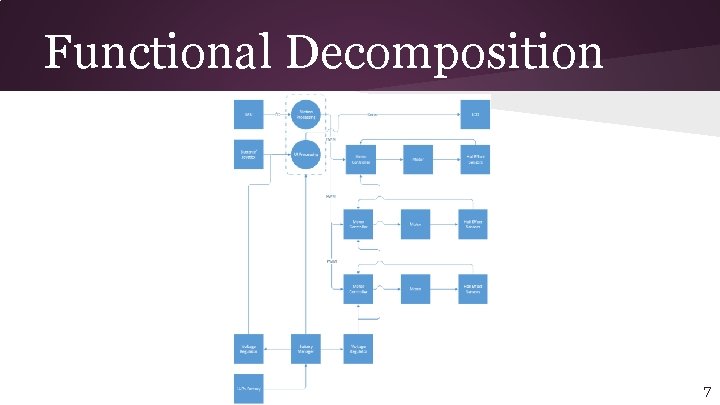
Functional Decomposition 7
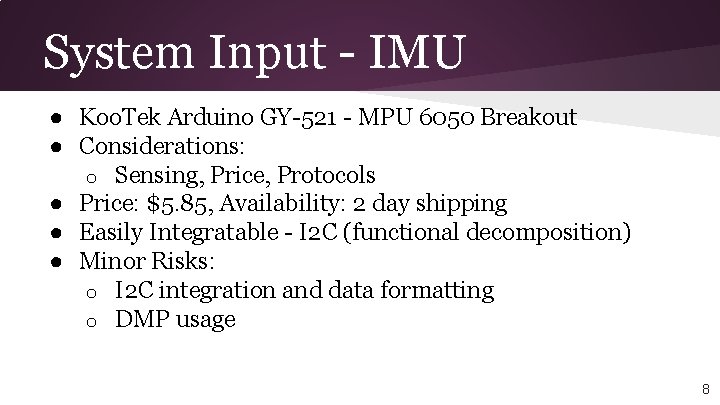
System Input - IMU ● Koo. Tek Arduino GY-521 - MPU 6050 Breakout ● Considerations: o Sensing, Price, Protocols ● Price: $5. 85, Availability: 2 day shipping ● Easily Integratable - I 2 C (functional decomposition) ● Minor Risks: o I 2 C integration and data formatting o DMP usage 8
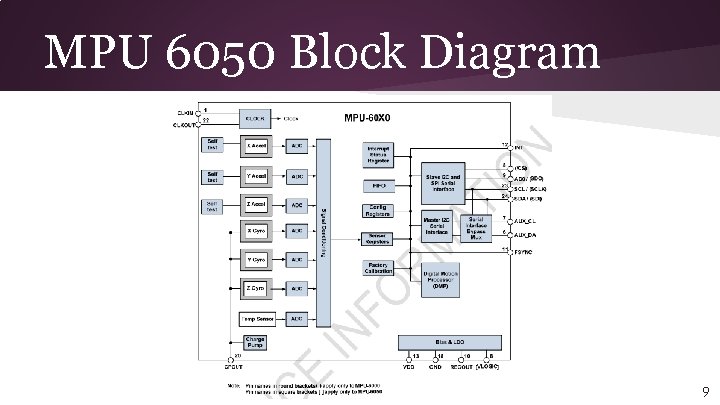
MPU 6050 Block Diagram 9
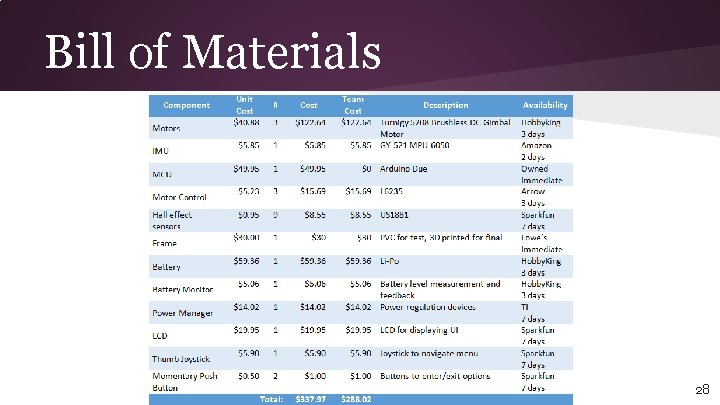
Power ● Li. Po Battery with Conversion and Watch Circuits ● Considerations: o Lightweight, portable, sustainable output over time, easily maintained ● Price o Li. Po (10, 000 m. Ah) - $59. 36 (3 days) o Battery Monitor - $5. 06 (3 days) o Power Manager - $14. 02 (7 days) o SPDT Mini Power Switch - $1. 50 (7 days) 10
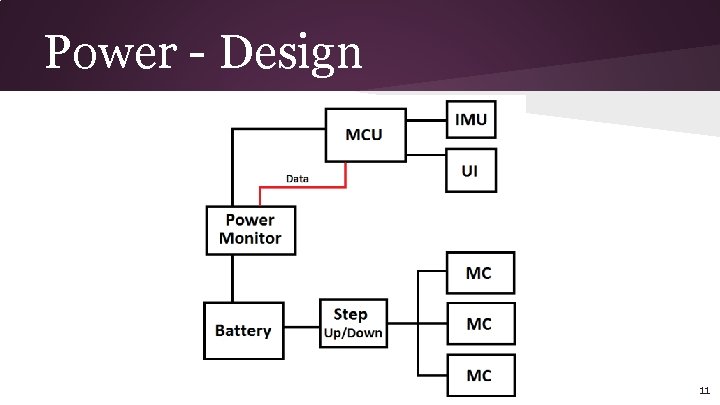
Power - Design 11
MCU and Control Systems ● PID Control Algorithm with Filtering and Feedback on Arduino Due ● Price Arduino Due - $49. 95 (own/7 days) MPU 6050 - $5. 85 (2 days) ● Combine a PID controller with complementary filters to account for any drift or inaccuracy of movement within the system. Use an additional IMU or the Hall Effect sensors to determine inaccuracies in motor movement. o o 12
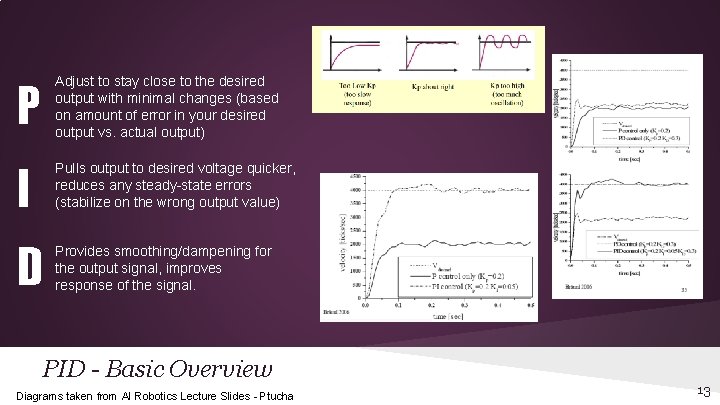
P Adjust to stay close to the desired output with minimal changes (based on amount of error in your desired output vs. actual output) I Pulls output to desired voltage quicker, reduces any steady-state errors (stabilize on the wrong output value) D Provides smoothing/dampening for the output signal, improves response of the signal. PID - Basic Overview Diagrams taken from AI Robotics Lecture Slides - Ptucha 13
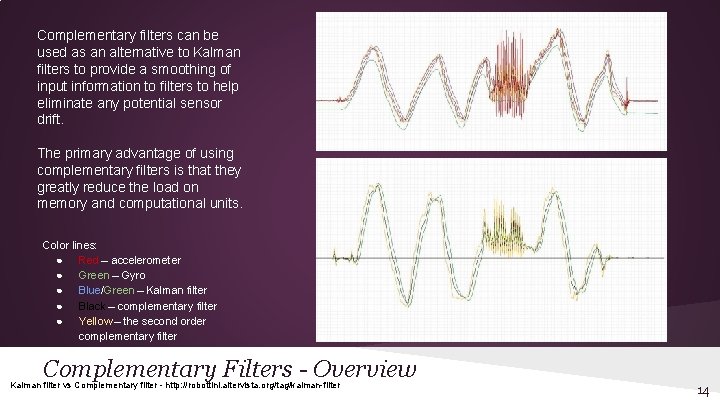
Complementary filters can be used as an alternative to Kalman filters to provide a smoothing of input information to filters to help eliminate any potential sensor drift. The primary advantage of using complementary filters is that they greatly reduce the load on memory and computational units. Color lines: ● Red – accelerometer ● Green – Gyro ● Blue/Green – Kalman filter ● Black – complementary filter ● Yellow – the second order complementary filter Complementary Filters - Overview Kalman filter vs Complementary filter - http: //robottini. altervista. org/tag/kalman-filter 14
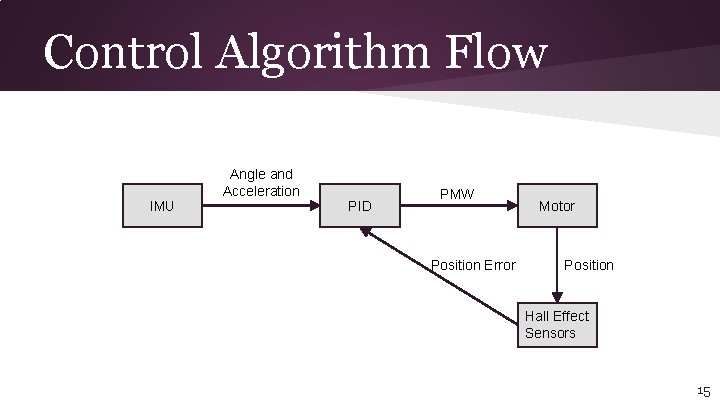
Control Algorithm Flow IMU Angle and Acceleration PID PMW Position Error Motor Position Hall Effect Sensors 15
System Output - PWM ● Arduino Output ● 3 PWM signals with 120° phase per motor ● No additional materials o Many solutions directly from Arduino libraries ● Risks o o o Duty cycle adjustment for speed Aligning signals for proper performance Checking with control algorithm feedback 16
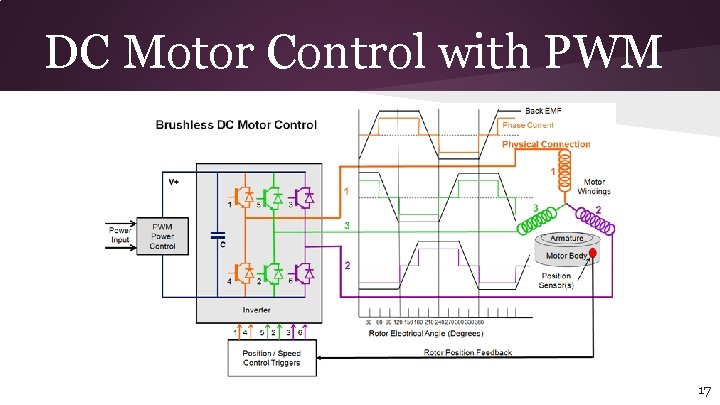
DC Motor Control with PWM 17
Motor Driver ● L 6235 3 -phase Motor Controller ● Alternatives: o H-Bridge, Modified ESC ● Considerations: o Ease of Use, Response Time, Pricing ● Price: $5. 23 (need 3), Availability: 3 day shipping ● Minor Risks: o Over-Current o Over-Voltage 18
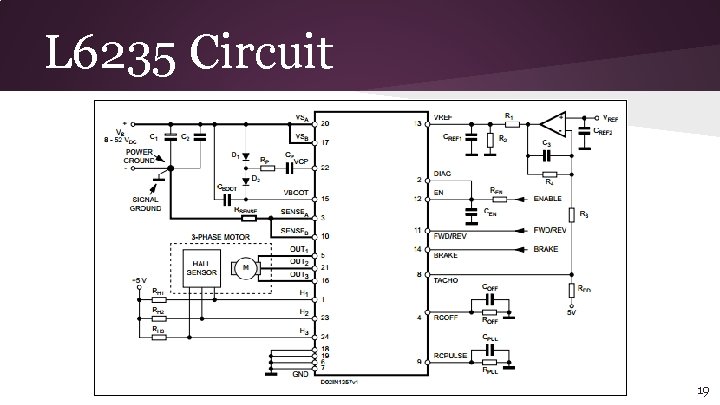
L 6235 Circuit 19
Motors ● Turnigy HD 5208 Brushless Three-phase Gimbal Motor ● Alternatives: o Continuous DC, Servo, Stepper ● Considerations: o Acceleration, Torque, Load Capacity, Pricing ● Price: $40. 88 (need 3), Availability: 3 day shipping ● Easily Integratable - PWM (functional decomposition) ● Minor Risks: o Slow Response time 20
Motor Feedback ● US 1881 Hall Effect Sensors ● Alternatives: o Alternative Rotary Encoders ● Considerations: o Pricing, Sensitivity, Ease of Use ● Price: $0. 95 (need 9), Availability: 7 day shipping ● Provides easy positioning for the motors. ● Minor Risks: o If a Hall effect sensor breaks, a motor will no longer function. 21
User Interface ● LCD with Basic Input and Direct Axis Movement ● Considerations: o Simple interface, logical progression, minimal additional weight to overall system ● Price o LCD - $19. 95 (7 days) o Thumb Joystick - $5. 90 (7 days) o Momentary Push Button (2) - $1. 00 (7 days) 22
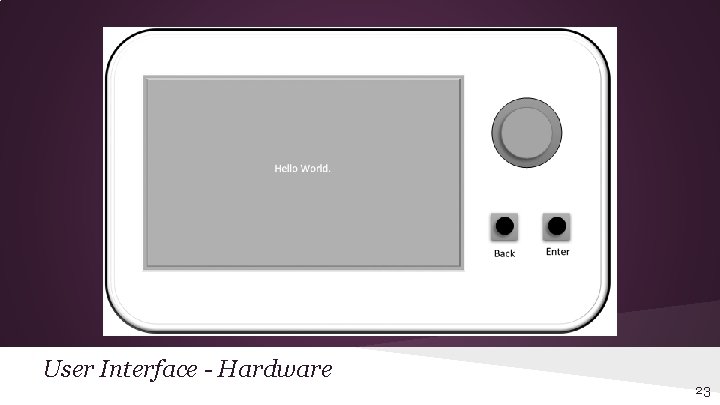
User Interface - Hardware 23
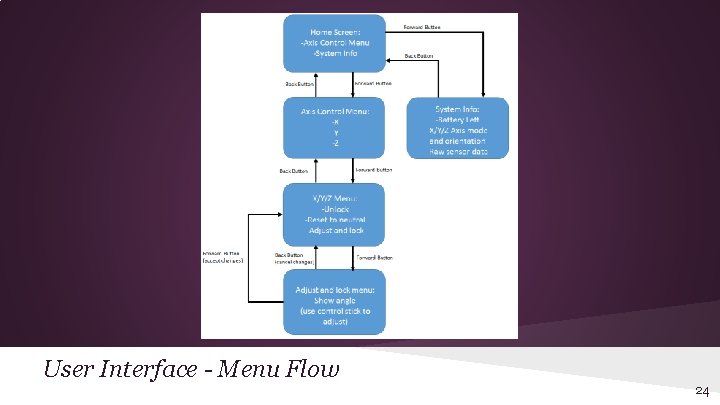
User Interface - Menu Flow 24
Frame and Mounting ● Prototype: PVC and Folded Aluminium Considerations: price, availability, assembly § Use mass produced parts § Readily available from Lowe’s or Home Depot § Easy to work with o Risks § Material Strength o 25
Frame and Mounting ● Final: 3 D printed PLA plastic and Extruded Aluminium Channels (Actobotics) o o o Highly customizable Lightweight, with aluminum providing structure Looks better than PVC 3 D printers available on campus Risks § Production time 26
Primary Risks ● Primary risks to consider o o o PID Tuning Accuracy Battery Life Frame Design and Implementation Weight Ease of Use 27
Bill of Materials 28
Testing ● Broken into unit tests, integration, and acceptance tests ● Comprehensive tests created by component within the system. ● Each test has a clear result to test for and the steps are outlined for each test procedure so that any errors should be easily recreatable. 29
Testing - Unit Tests for individual systems to ensure they function correctly before combining with the rest of the overall system. Examples: ● ● ● IMU Communication protocols UI Navigation Microcontroller Power System Motors 30
Testing - Integration Tests how individual components interact. Examples: ● Microcontroller to motors ● IMU to microcontroller ● UI to control algorithm ● Loaded power system 31
Testing - Acceptance Designed to directly test the customer’s needs. Examples: ● ● ● Sensitivity to Motion Accurate Control Algorithm System Weight Operation Time (load, no load) Movement Limitations Supported Load 32
Summary ● Primary concern: o Control system programming and tuning ● Some components need finishing touches: o Frame, UI ● Still minor degree of uncertainty in some engineering specification values. ● Under budget! ● Design is feasible! 33
Citations ● MPU-6050 Datasheet ● http: //www. mpoweruk. com/motorsbrushless. htm ● L 6235 Datasheet 34
- Slides: 34