
Building a Universal Planar Manipulator Dan Reznik Emil
Building a Universal Planar Manipulator Dan Reznik Emil Moshkovich John Canny UC-Berkeley
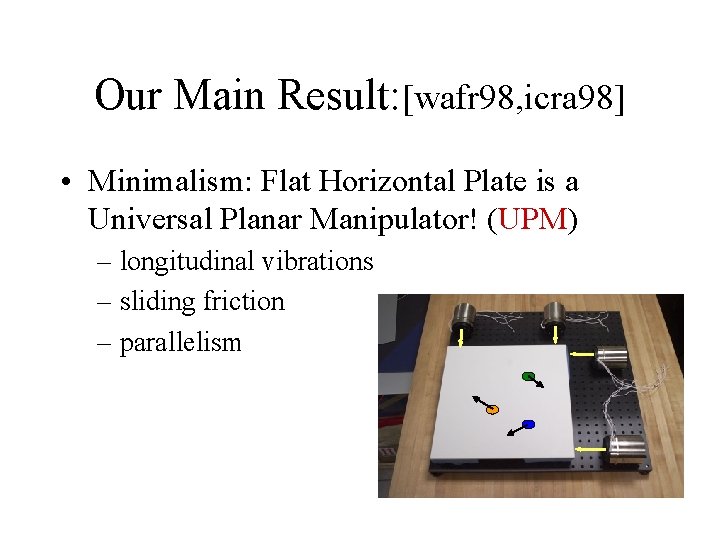
Our Main Result: [wafr 98, icra 98] • Minimalism: Flat Horizontal Plate is a Universal Planar Manipulator! (UPM) – longitudinal vibrations – sliding friction – parallelism
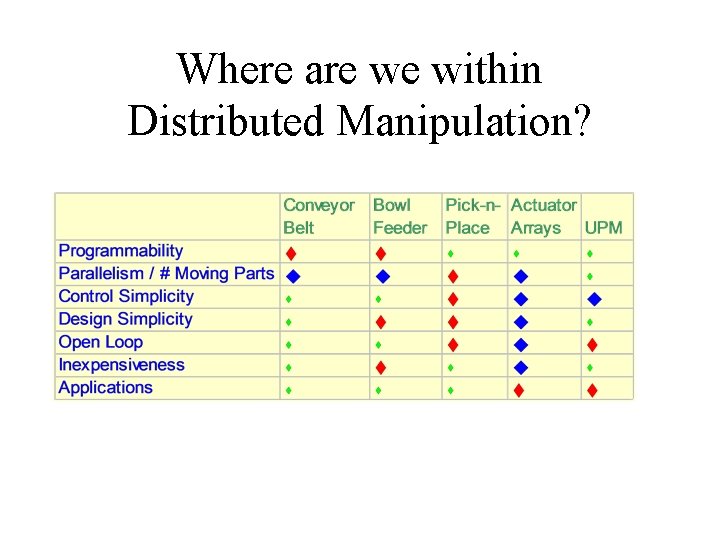
Where are we within Distributed Manipulation?
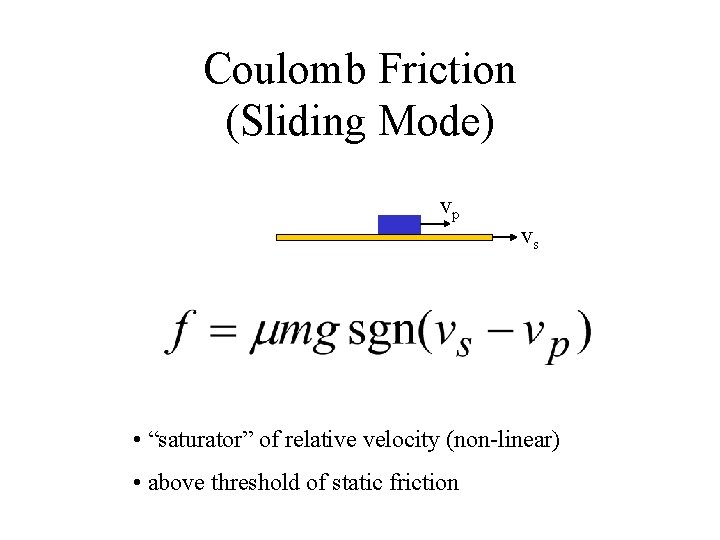
Coulomb Friction (Sliding Mode) vp vs • “saturator” of relative velocity (non-linear) • above threshold of static friction
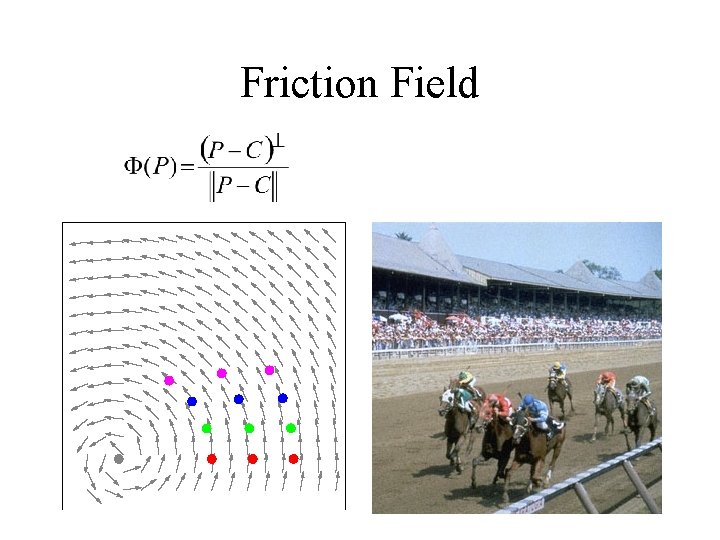
Friction Field
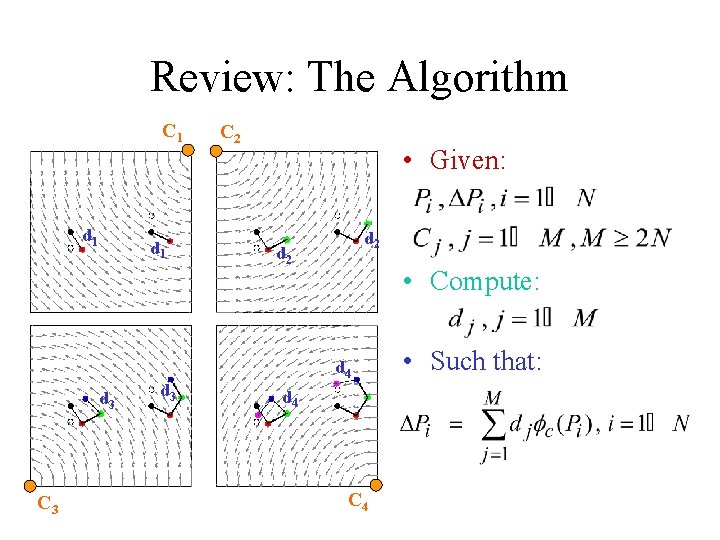
Review: The Algorithm C 1 d 1 d 3 C 3 d 3 C 2 • Given: d 2 • Compute: d 4 C 4 • Such that:
Goal of the talk • Algorithm ok, in simulation • Show algorithmic requirements are being met in practice!
Practical Requirements • • Generate a non-linear field Flexibly choose centers of rotation Real-time detect coins’ positions H/W & S/W integration
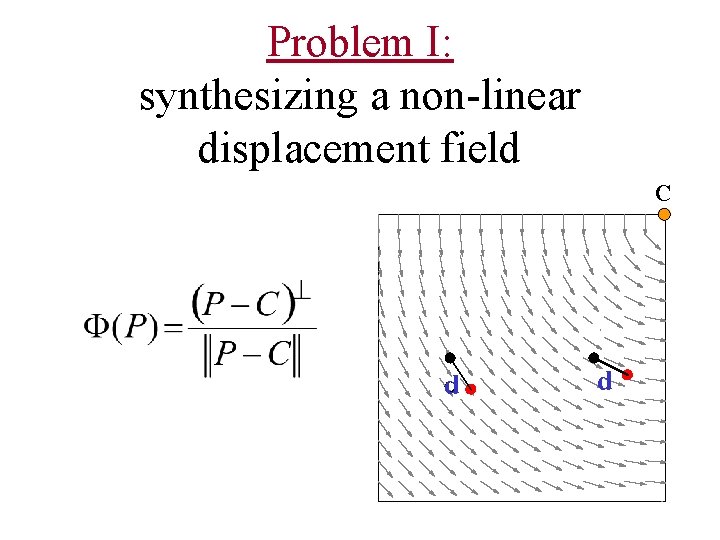
Problem I: synthesizing a non-linear displacement field C d d
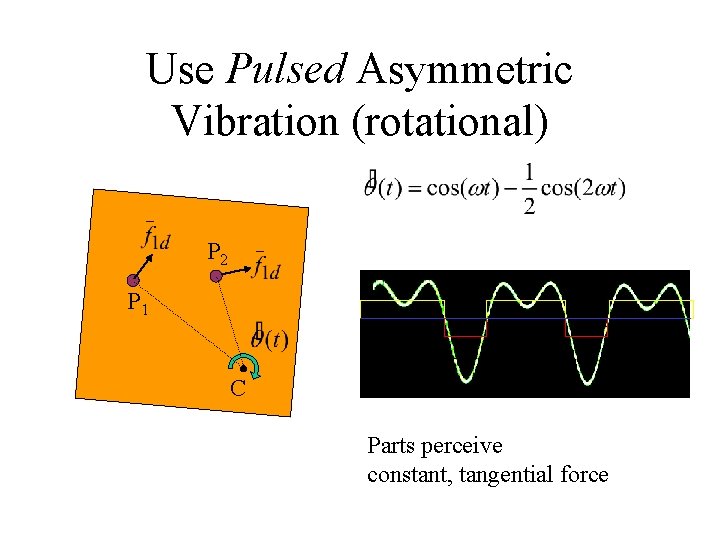
Use Pulsed Asymmetric Vibration (rotational) P 2 P 1 C Parts perceive constant, tangential force
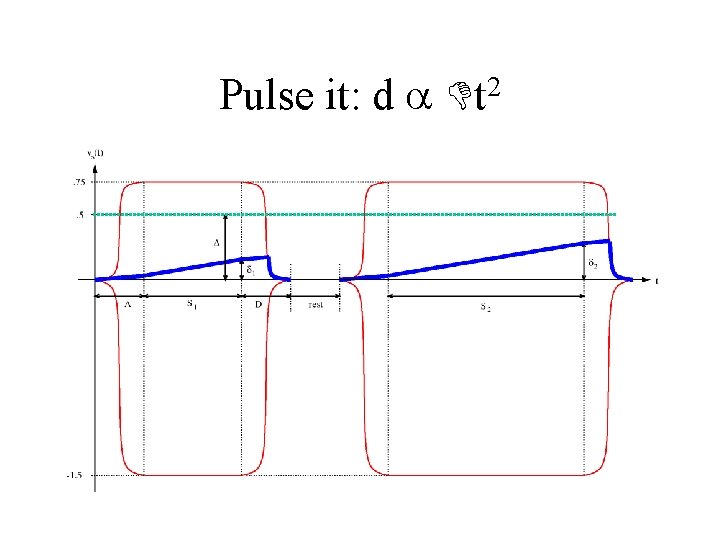
Pulse it: d 2 t
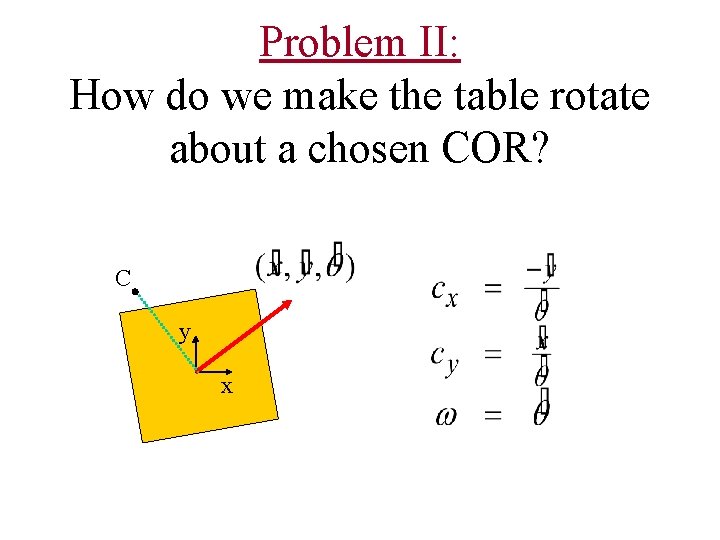
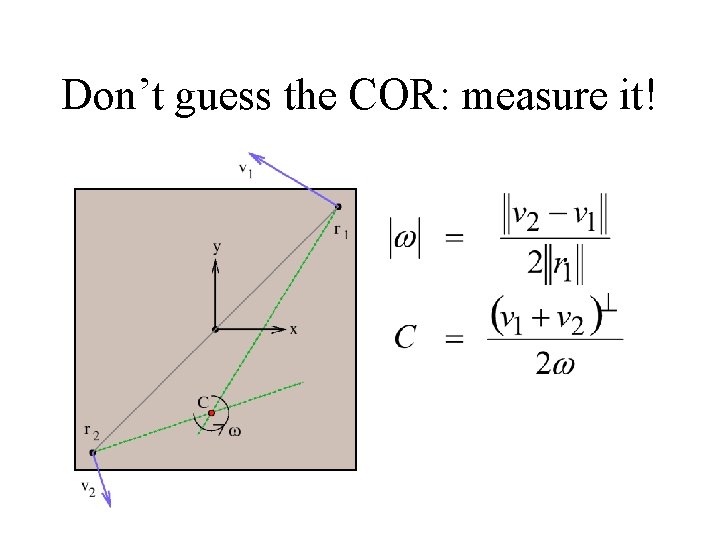
Problem II: How do we make the table rotate about a chosen COR? C y x
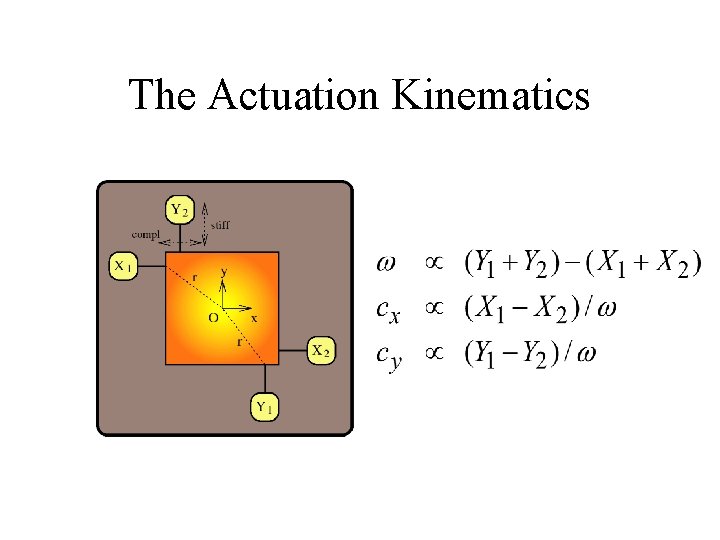
The Actuation Kinematics
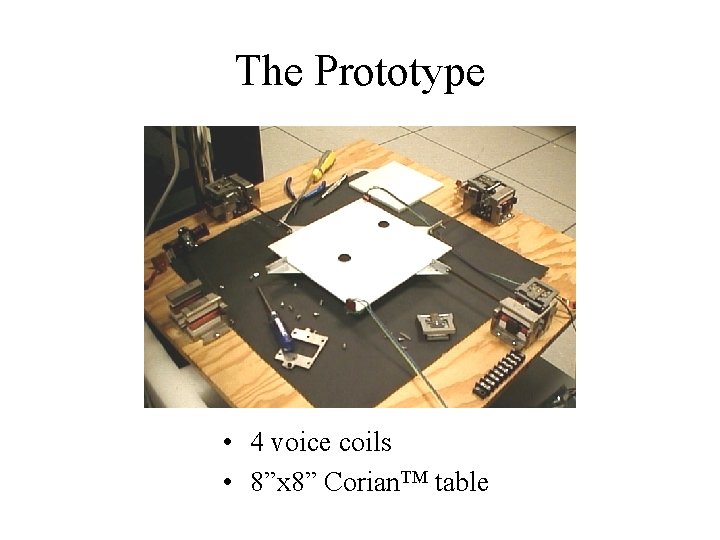
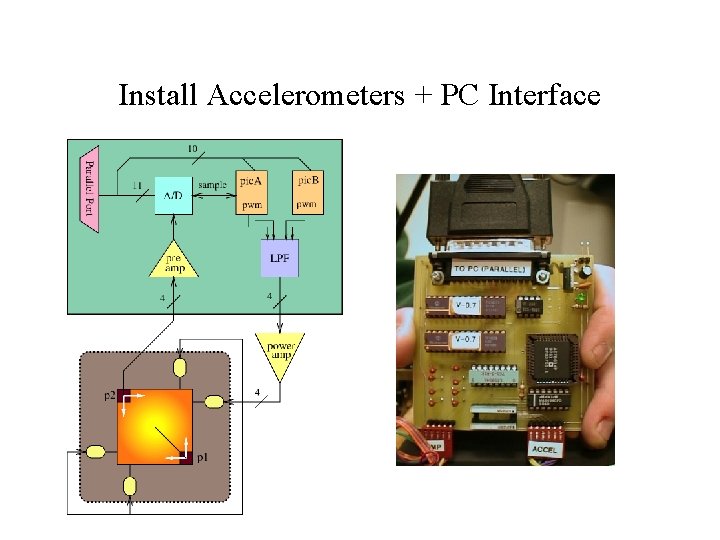
The Prototype • 4 voice coils • 8”x 8” Corian. TM table
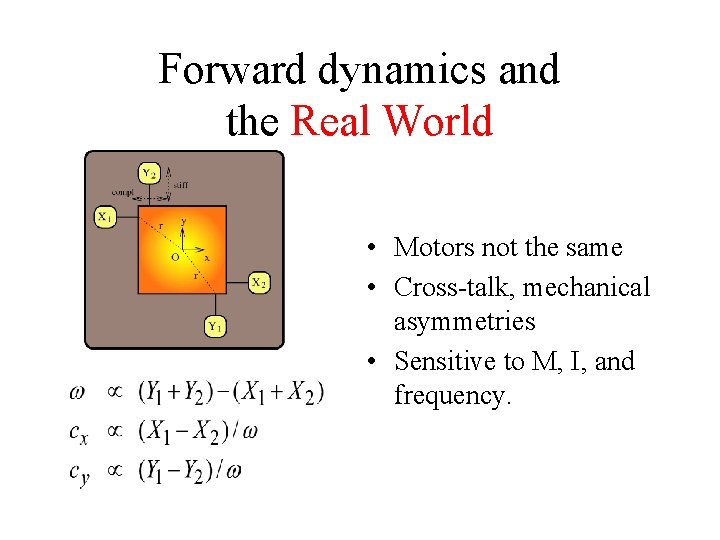
Forward dynamics and the Real World • Motors not the same • Cross-talk, mechanical asymmetries • Sensitive to M, I, and frequency.
Back to the white board. . .
Don’t guess the COR: measure it!
Install Accelerometers + PC Interface
Acceleration Curve Fit recover amplitude integrate & adjust
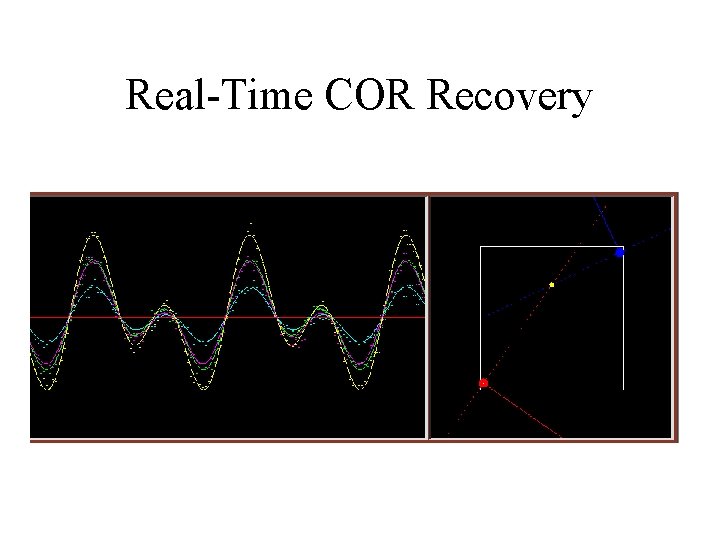
Real-Time COR Recovery
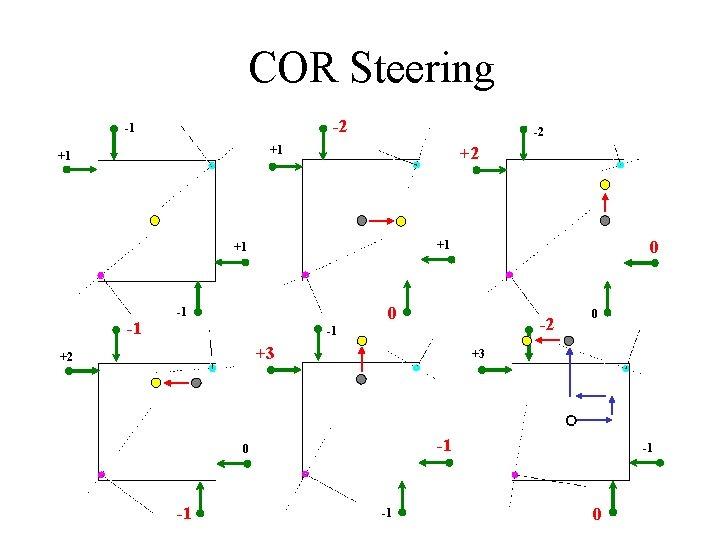
COR Steering -2 -1 -2 +2 +1 +1 -1 0 +1 +1 0 -1 -2 -1 +3 +2 +3 -1 0 -1 -1 0
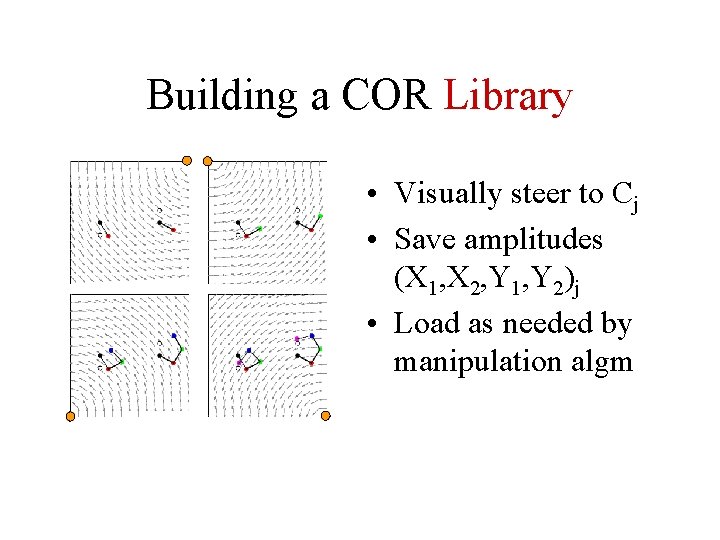
Building a COR Library • Visually steer to Cj • Save amplitudes (X 1, X 2, Y 1, Y 2)j • Load as needed by manipulation algm
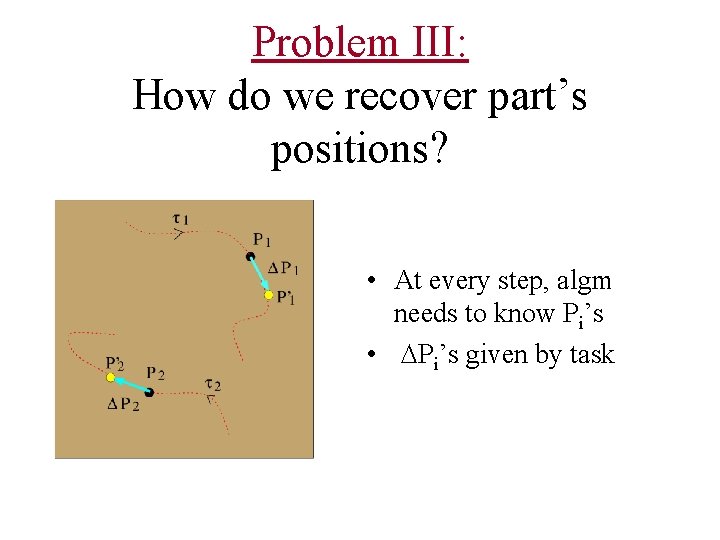
Problem III: How do we recover part’s positions? • At every step, algm needs to know Pi’s • DPi’s given by task
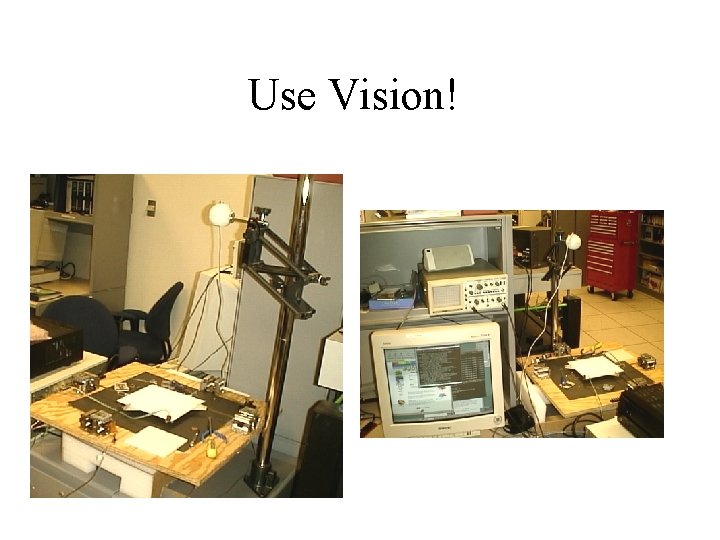
Use Vision!
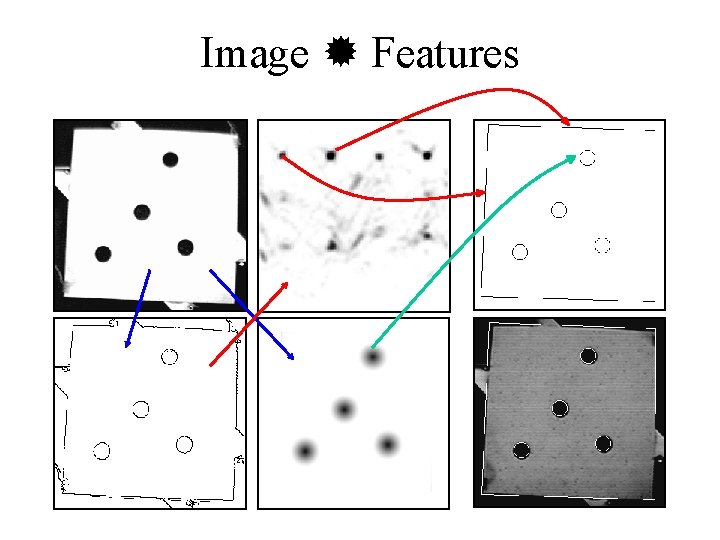
Image Features
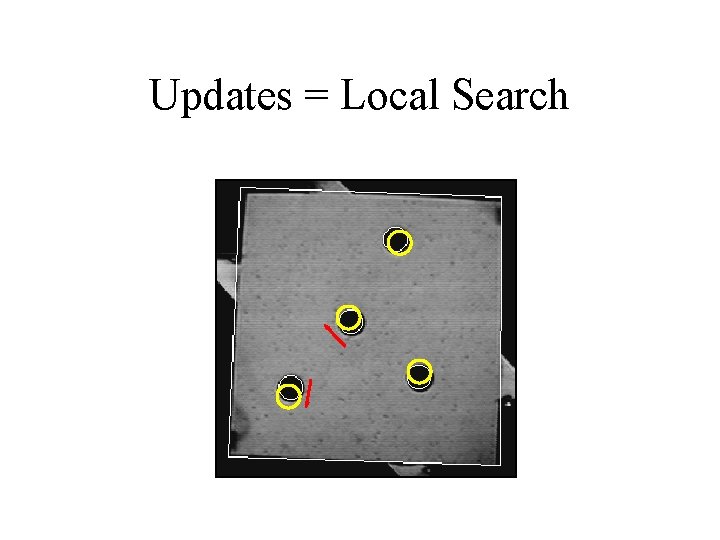
Updates = Local Search
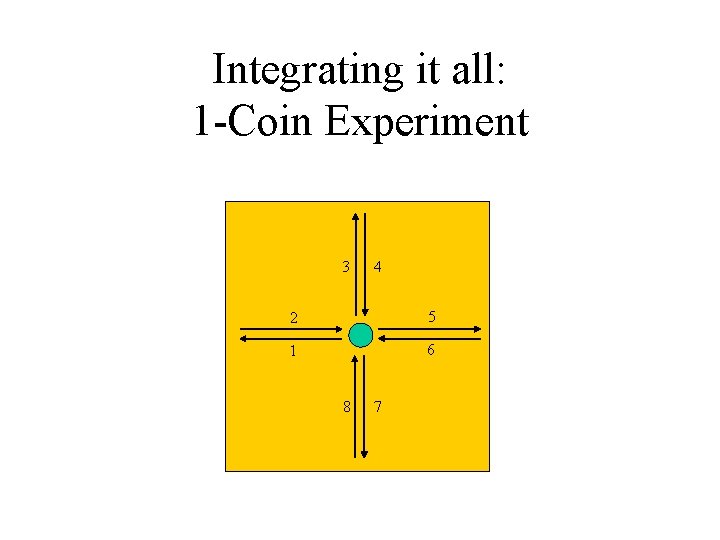
Integrating it all: 1 -Coin Experiment 3 4 2 5 1 6 8 7
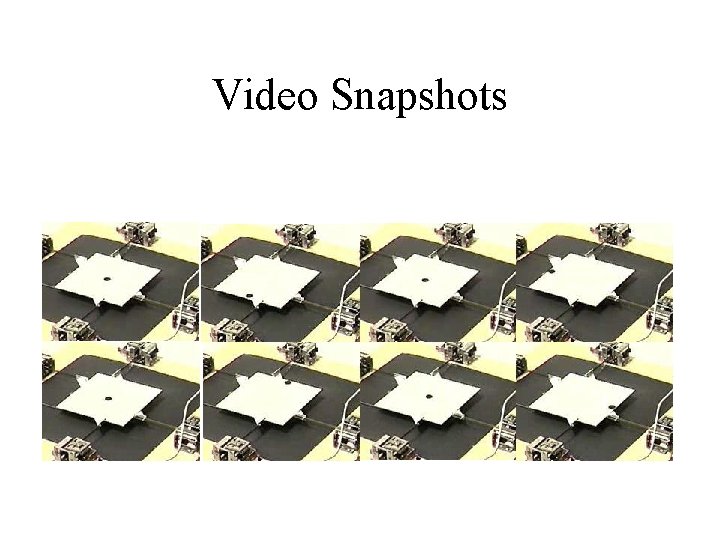
Video Snapshots
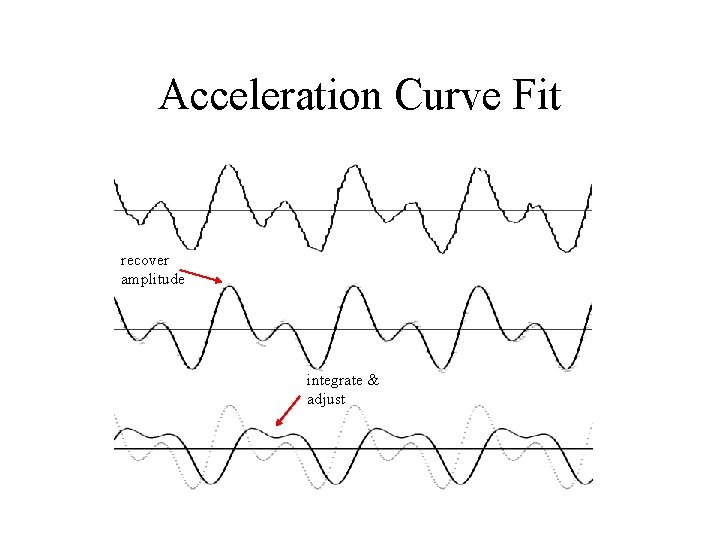
Summary: Problems Solved • I: Synthesize non-linear manipulation primitive • friction + asymmetric rotation • cool actuation design • II: Make the table rotate about chosen COR • install accelerometers • least-squares fit to cos(t)+(cos 2 t)/2 • recover amplitudes, solve simple equation • III: Recover part’s positions • simple image processing
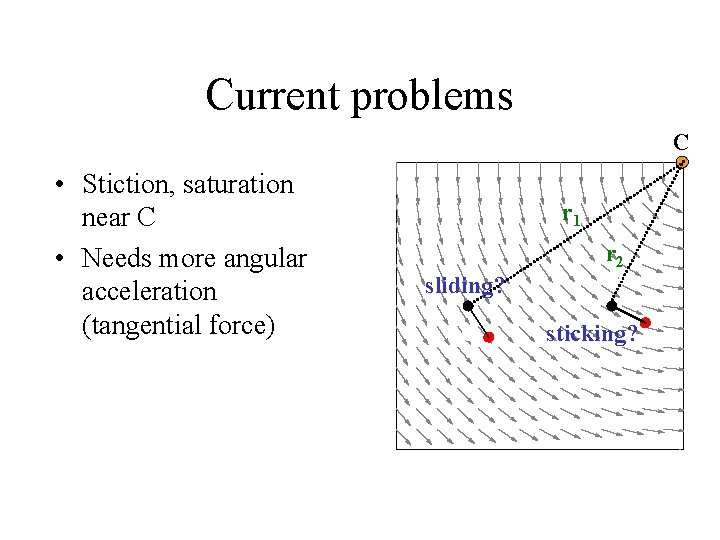
Current problems C • Stiction, saturation near C • Needs more angular acceleration (tangential force) r 1 r 2 sliding? sticking?
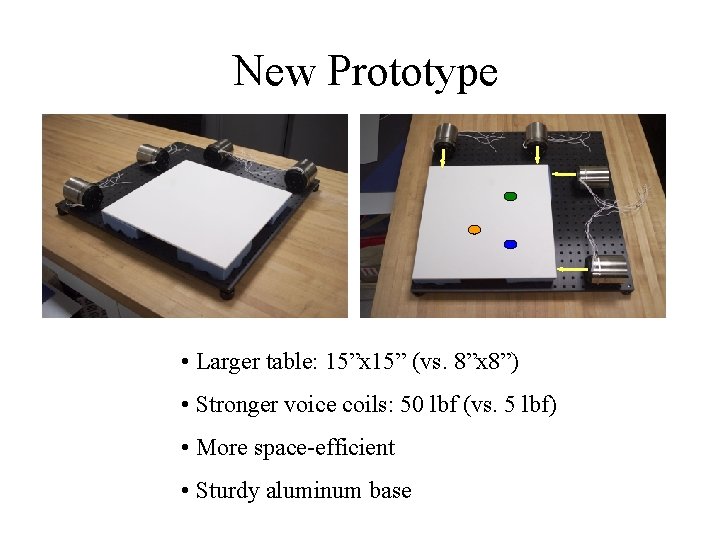
New Prototype • Larger table: 15”x 15” (vs. 8”x 8”) • Stronger voice coils: 50 lbf (vs. 5 lbf) • More space-efficient • Sturdy aluminum base
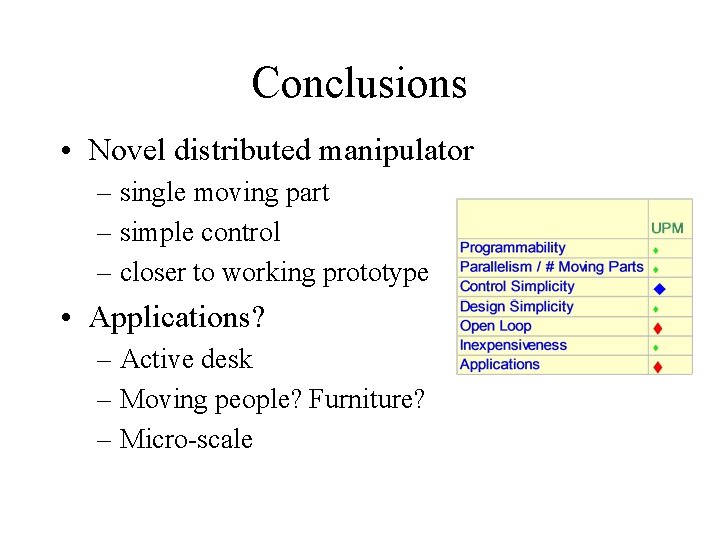
Conclusions • Novel distributed manipulator – single moving part – simple control – closer to working prototype • Applications? – Active desk – Moving people? Furniture? – Micro-scale
Dangers of Vibratory Manipulation
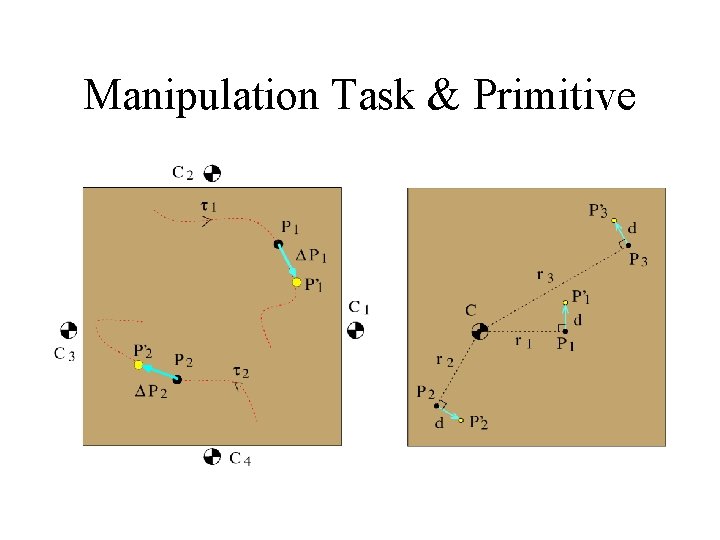
Manipulation Task & Primitive
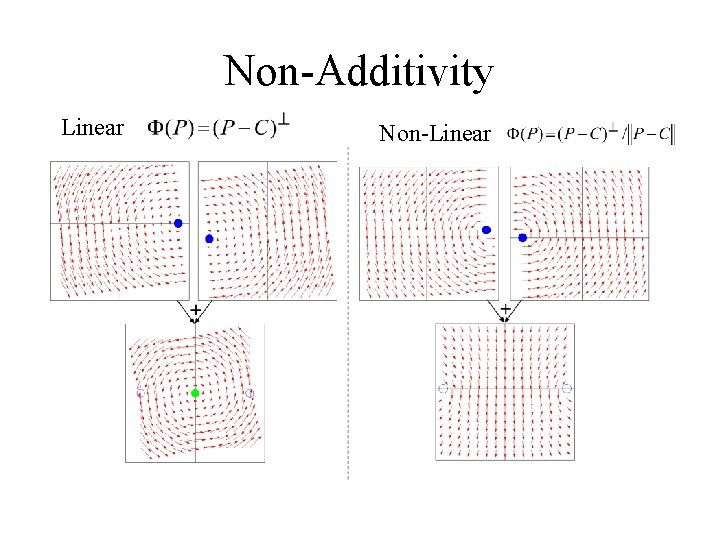
Non-Additivity Linear Non-Linear
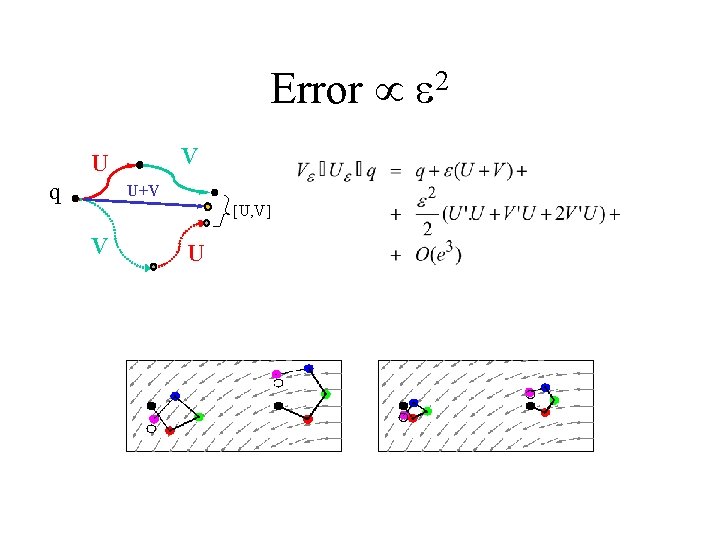
Error e 2 V U q U+V [U, V] V U
- Slides: 37